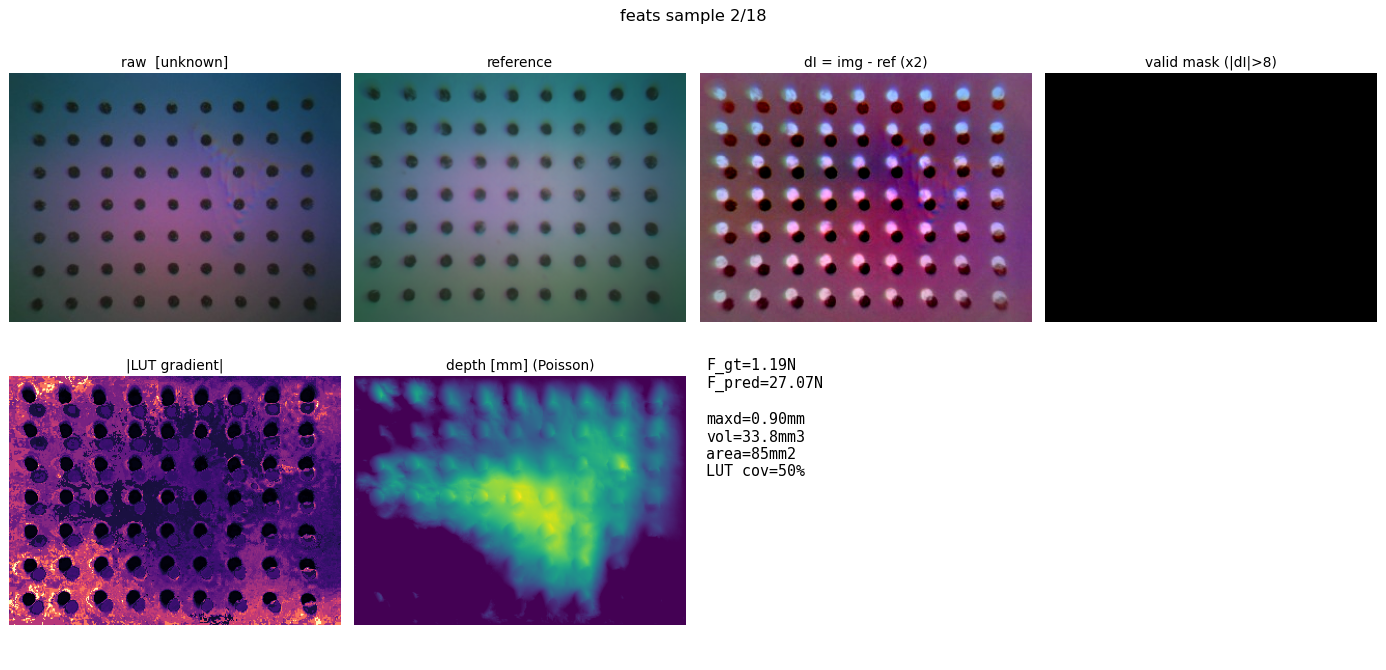
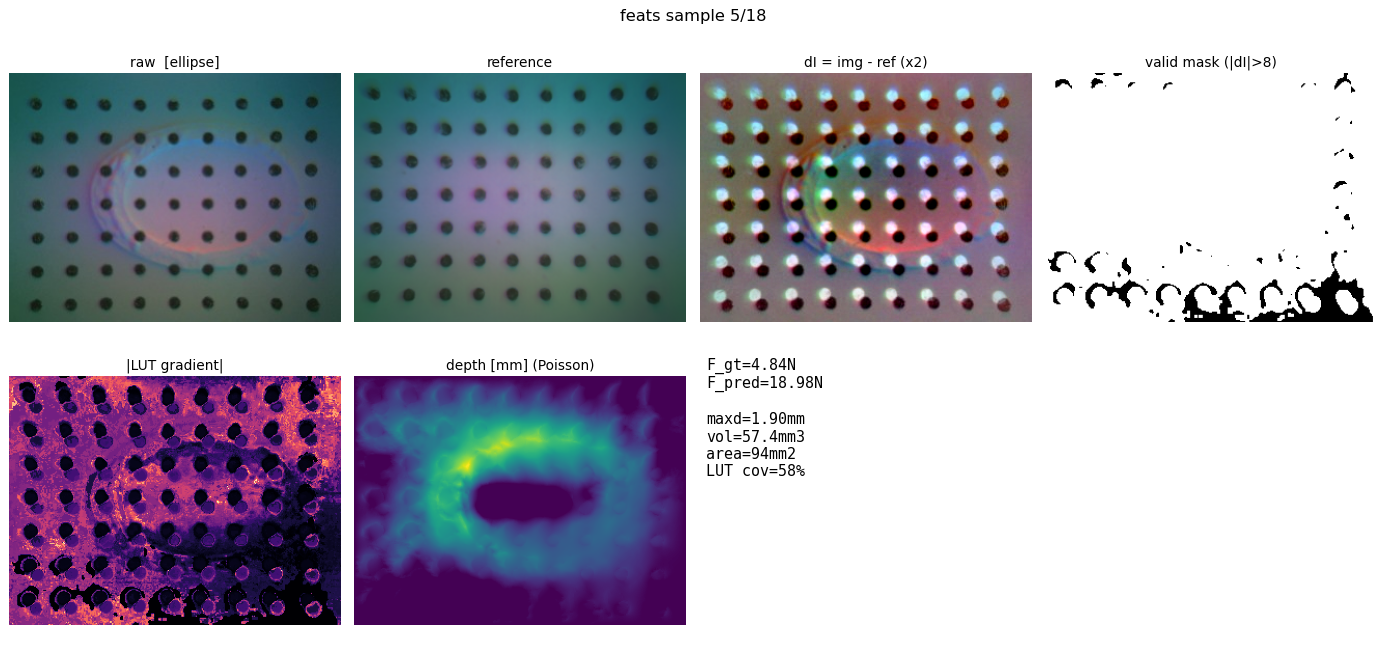
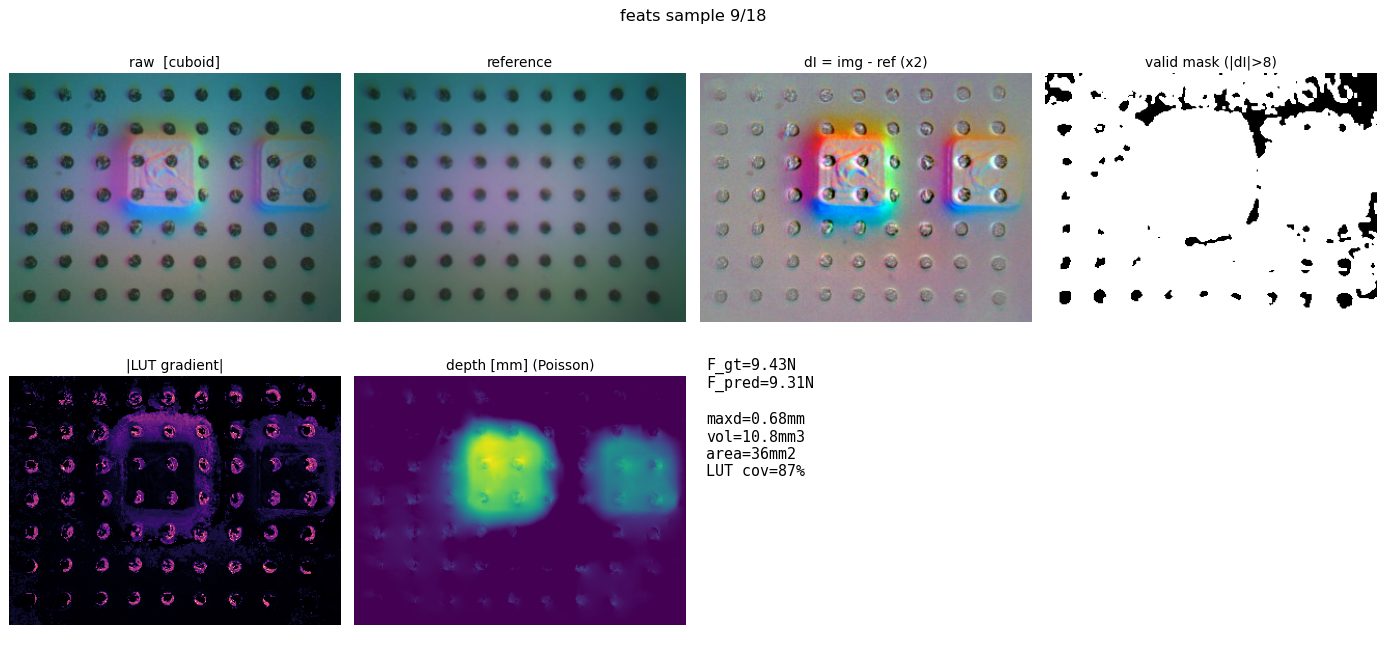
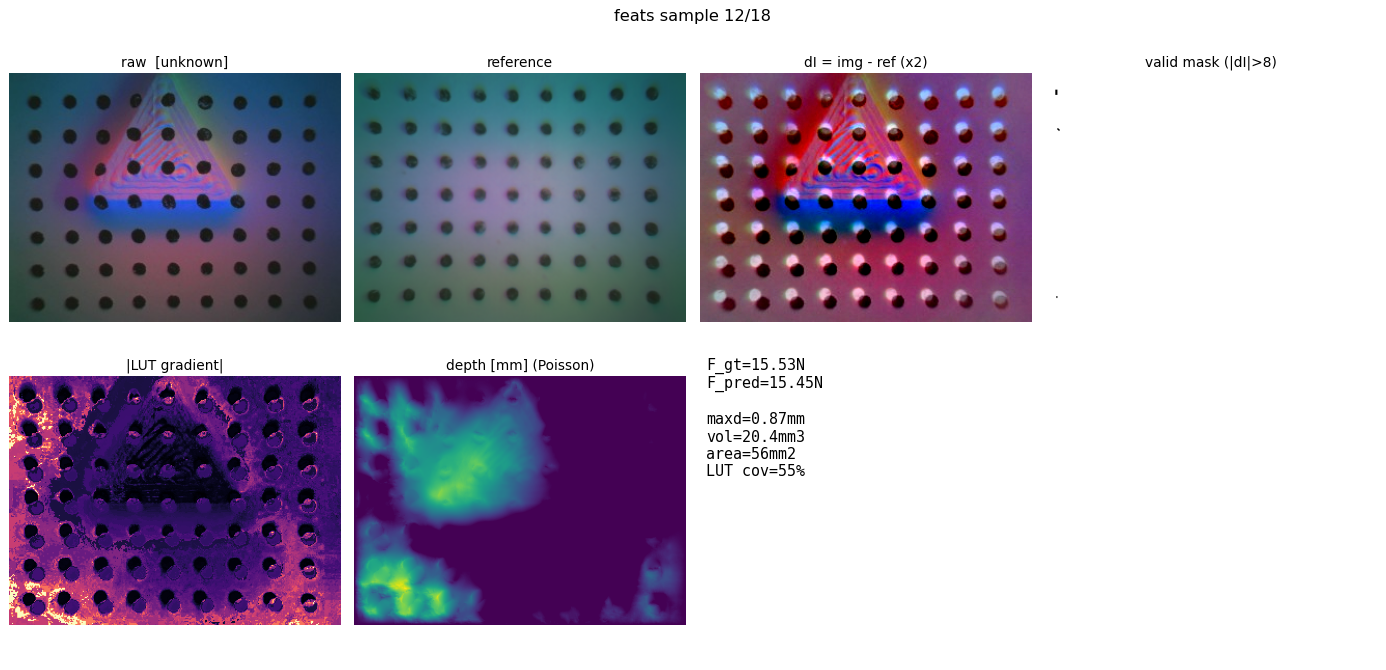
From raw image to force, step by step
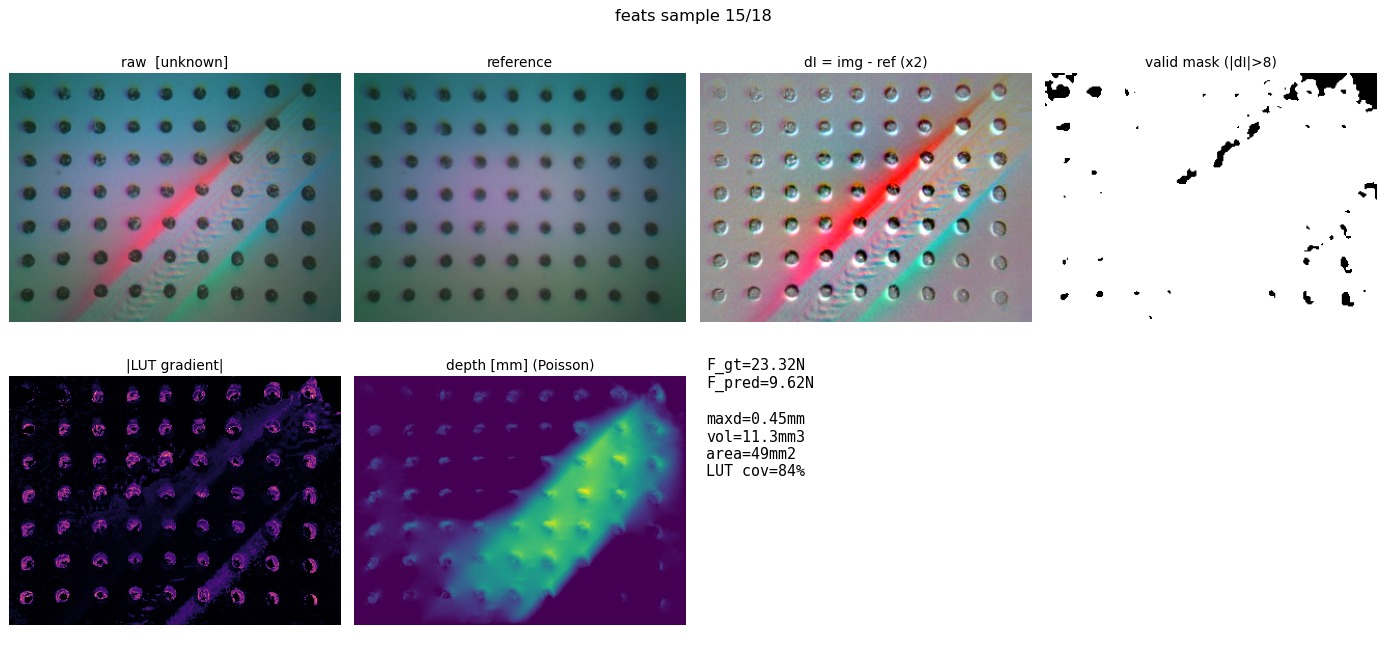
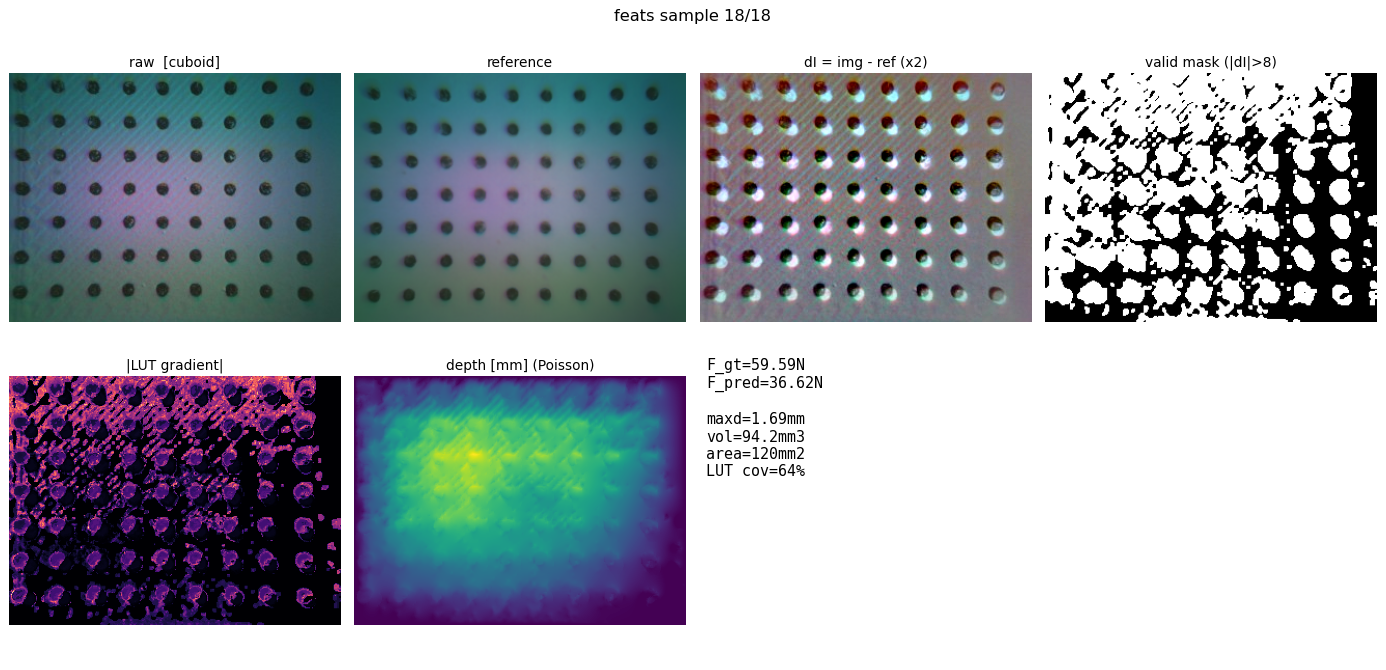
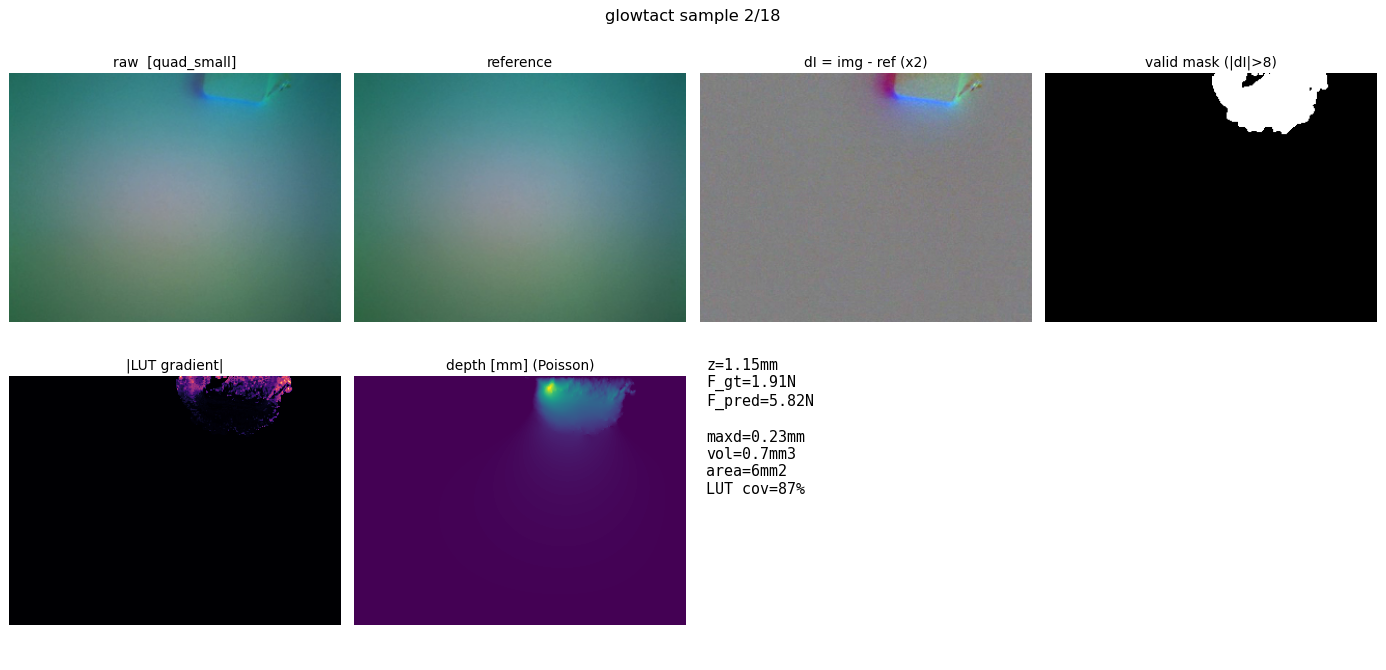
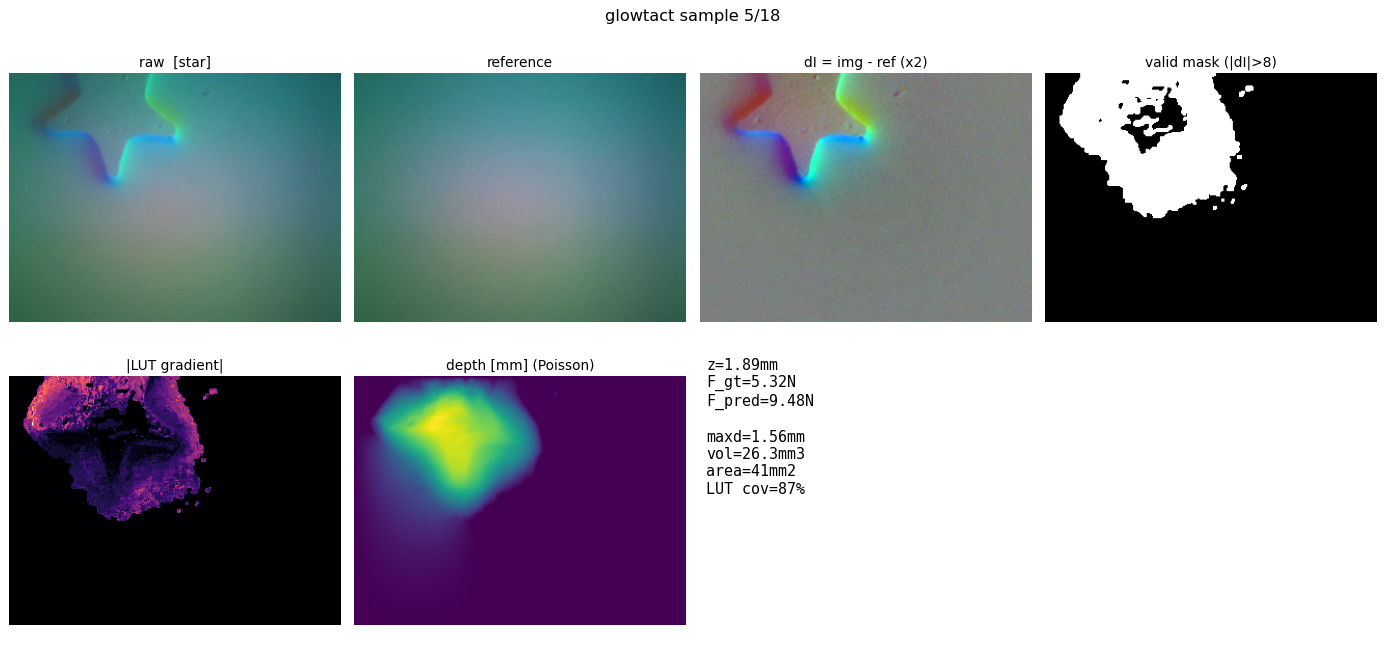
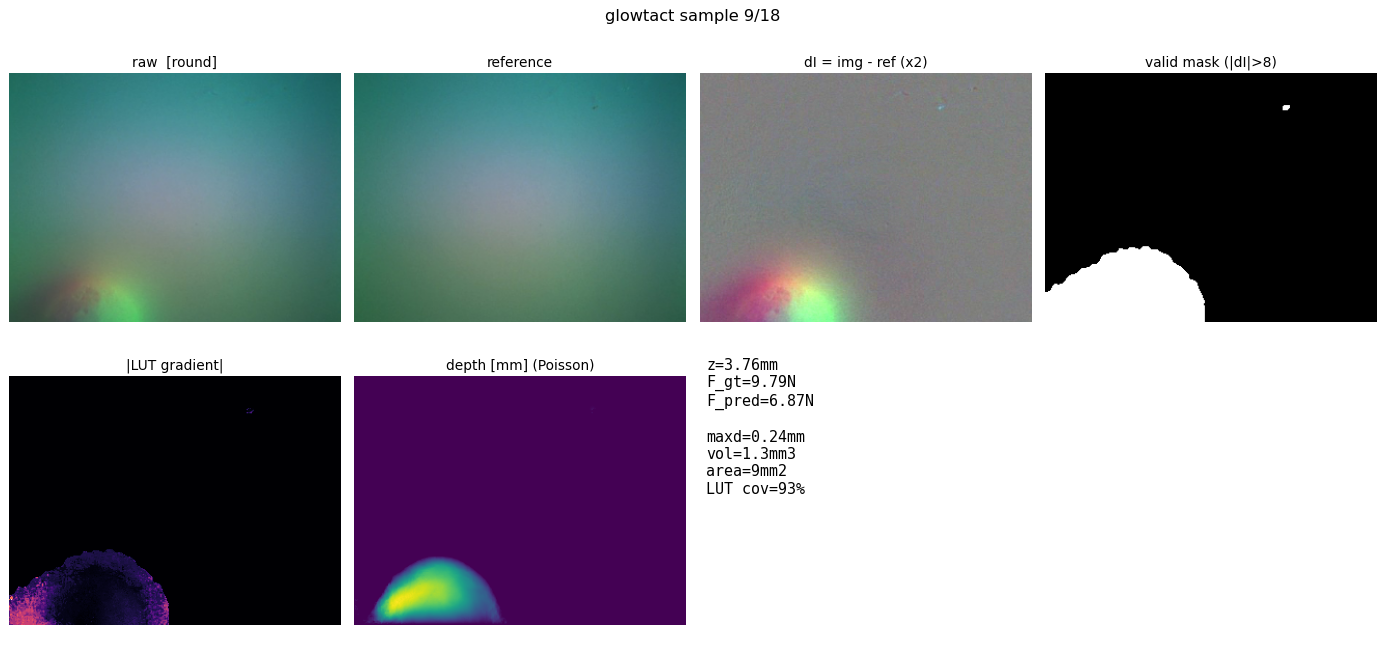
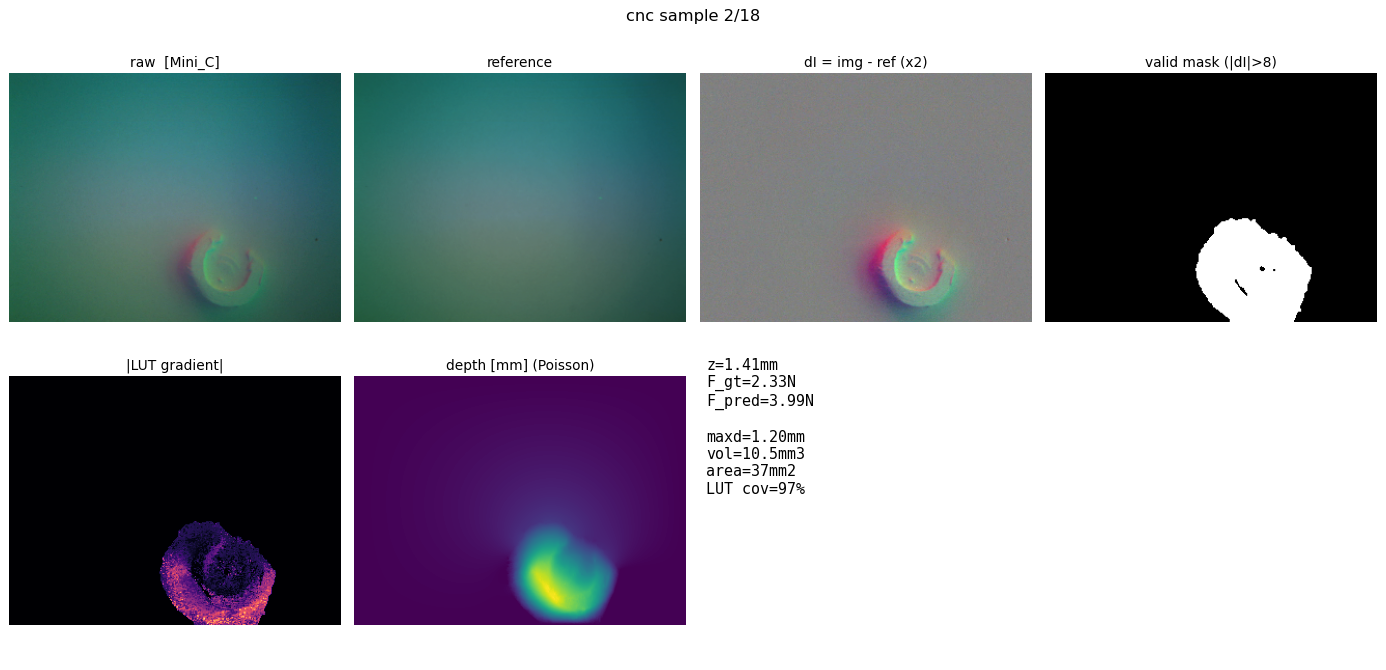
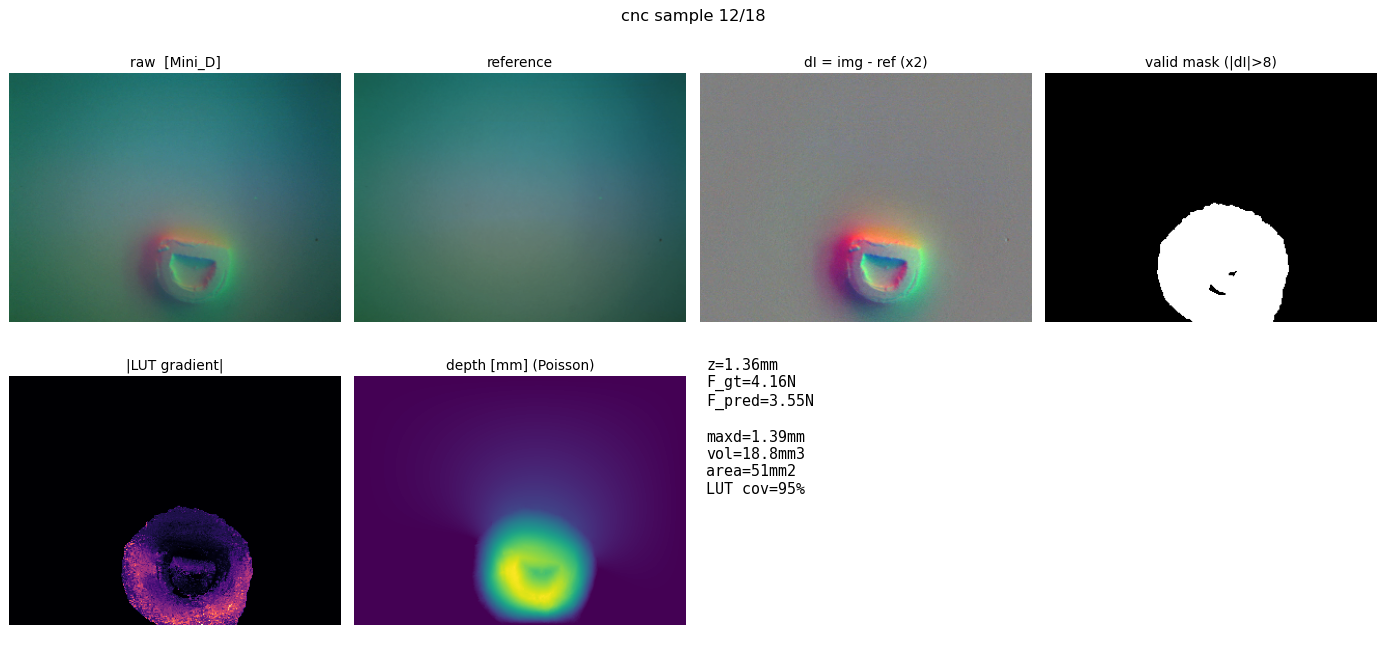
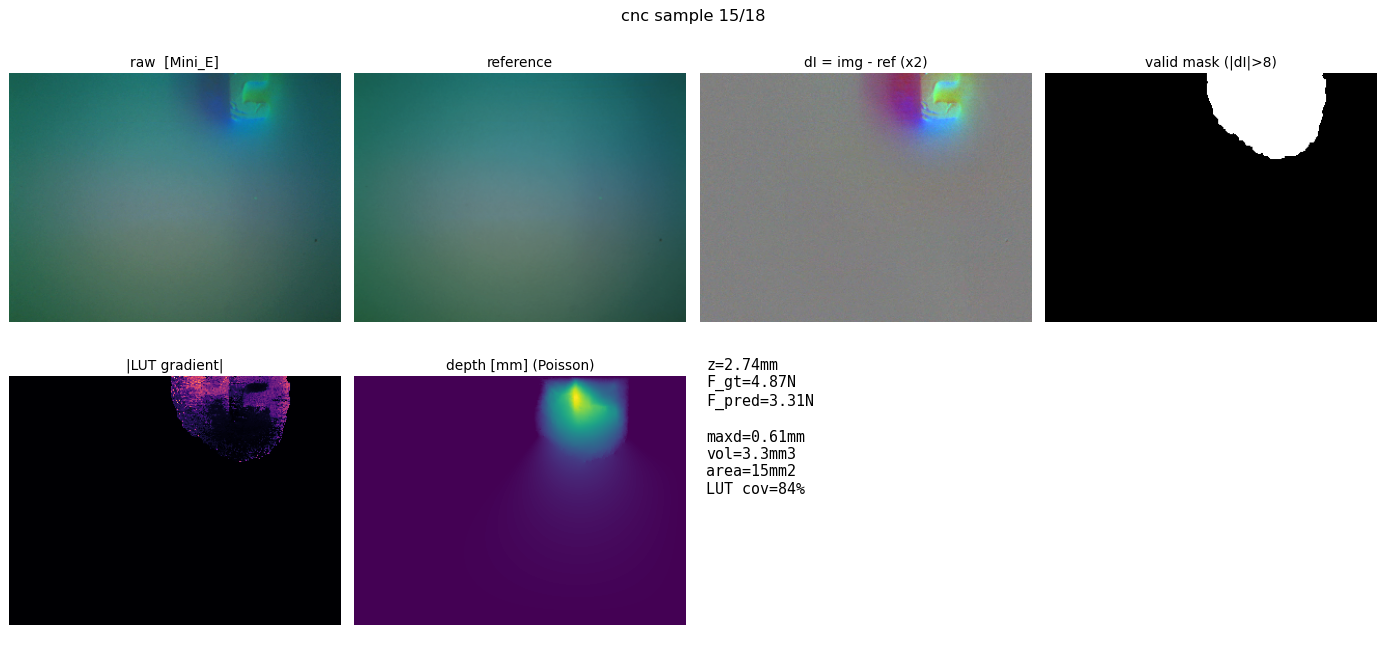
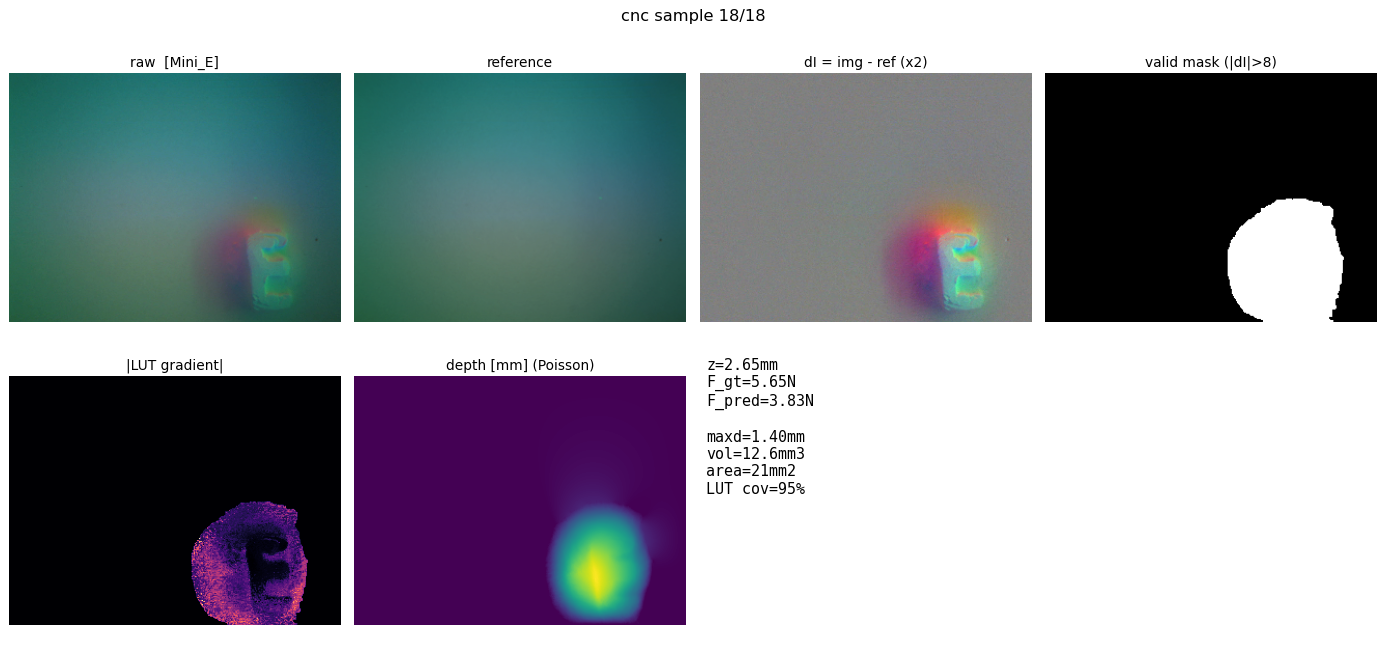
Each row: raw → reference → dI=img−ref → valid mask → |LUT gradient| → Poisson depth → features and predicted vs ground-truth force. Same pipeline, three datasets.
Why cnc_Mini looked broken — and what it actually was
Neither bad labels nor a broken reconstruction: the cnc press grid spans the full 20×16 mm pad while the cropped camera view sees only ≈13×10 mm, so two thirds of the presses are partially outside the image and their contact features are systematically underestimated. Restricted to presses fully in view, the same reconstruction reaches GlowTact-level accuracy. Label quality is fine (force CV 4.5% at fixed probe/position/depth). This retracts our earlier “dataset ceiling” argument: in-view ρ=0.94 exceeds the commanded-depth proxy (0.78–0.88) that argument relied on.
| scope (cnc, 3351 frames) | n | per-probe ρ (A–F) | median ρ | MAE |
|---|---|---|---|---|
| all press positions | 3351 | 0.09–0.16 | 0.113 | 0.74 N |
| interior x∈[3.5,14.5] | 1232 | 0.79–0.85 | 0.835 | 0.39 N |
| strictly in view x∈[5,13] | 671 | 0.94 0.94 0.93 0.91 0.95 0.95 | 0.941 | 0.26 N |
Per-probe half/half fit, 7 seeds, LUT pipeline with z-supervised gain field. Dot-type control: FEATS presses are always centered, so the raw pipeline already gives ρ=0.72 there, vs 0.46 raw on GlowTact — the gain field and scope, not markers, are the binding factors.
The same failure mode, on four datasets
The cnc story above is not a cnc story. Exact per-pixel ground truth on Tactile MNIST shows the identical effect from the other side: 420/420 touches have a contact that runs off the pad, and a control that moves one sphere cap from mid-pad to the edge collapses its reconstructed peak 1.39 → 0.30 mm against a 0.90 mm truth. Sparsh shows it a third time — its clipped frames carry the highest median force and still score worse. The cause is structural: the Poisson solve's zero boundary cannot represent a surface that leaves the frame, so a clipped contact is integrated as if it ended at the image edge. Contact visibility, not force range or gel type, is this pipeline's biggest external failure mode.
The same ground truth also puts a number on the mask you see in column 4: against the true contact region it scores IoU 0.614 with recall 0.917 and over-segmentation 0.531 — it finds nearly all of the contact, then adds half as much again in halo. That is why a halo pedestal has to be subtracted before any 3D view.
GlowTact — markerless, the LUT's home sensor (control)


FoTa cnc_Mini — markerless, foreign sensor, press grid larger than the field of view
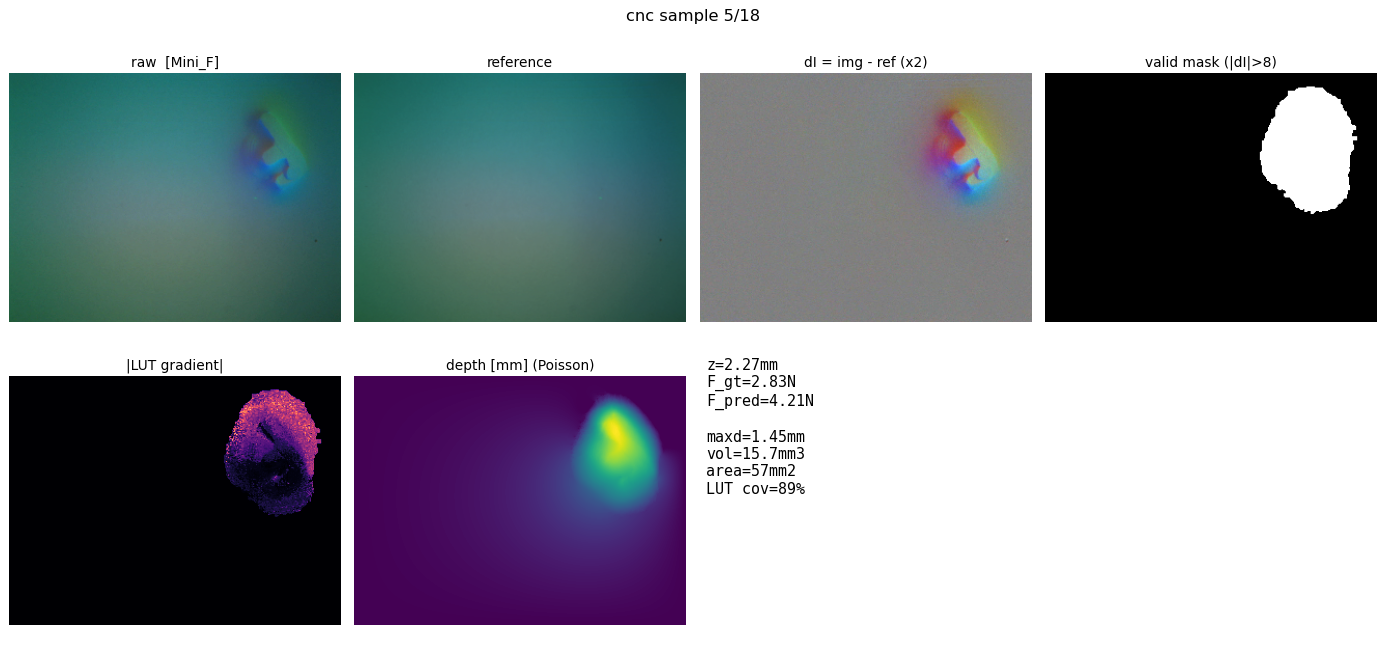
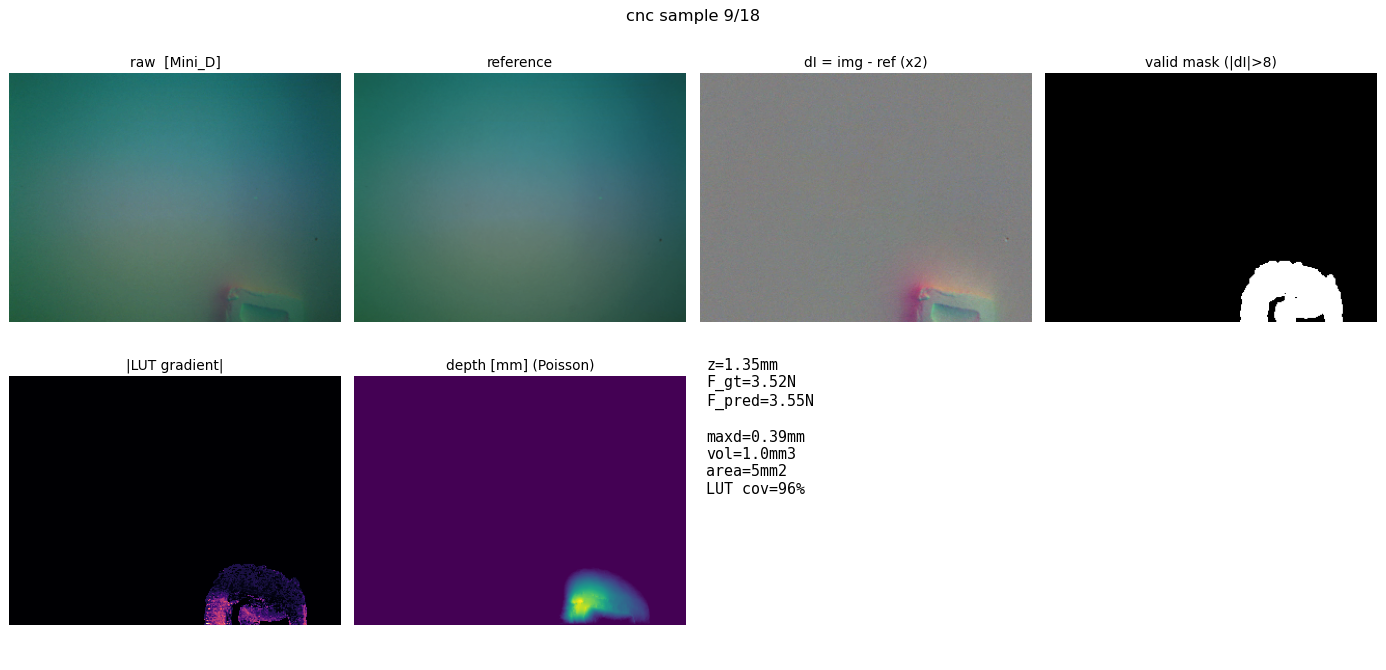
FEATS — dot/marker gel; these panels are the FORCE path, so the dots are still in them (marker inpainting ships for geometry only)