---
license: other
license_name: commonroad-scenarios
license_link: https://commonroad.in.tum.de/
pretty_name: PlannerForge Scenario Corpus
language:
- en
tags:
- autonomous-driving
- scenario-based-testing
- motion-planning
- commonroad
- sumo
size_categories:
- n<1K
---
# PlannerForge Scenario Corpus
The 582 CommonRoad scenarios used by **PlannerForge: LLM Agents for Scenario-Based Testing of
Motion Planners in Autonomous Driving** (EMNLP 2026 Main Conference).
- 📑 Paper and project page: https://github.com/TUM-AVS/PlannerForge
> **Important:** the scenarios in this corpus are **not** original work of the PlannerForge
> authors. They come from the [CommonRoad scenario
> database](https://commonroad.in.tum.de/scenarios/) and carry their own credits in each
> file's XML metadata. Cite CommonRoad alongside this corpus — see
> [Provenance and credits](#provenance-and-credits).
## What this is
This is the scenario database behind three parts of the paper:
- the **Selection** benchmark — 200 natural-language queries retrieve from this corpus through a
five-stage funnel (reported as `sat_all`, `sat_top1`, `sat_any@5`);
- the **Modification** benchmark — 200 of these scenarios are the base scenarios for the four
edit types (Trajectory, Behaviour, Participant, Goal);
- **Test Execution and ADS Assessment** — scenarios are run through the Frenetix and MP-RBFN
motion planners.
Scenarios generated *by* PlannerForge from natural language are not included here; the
Generation benchmark builds those from OpenStreetMap at run time.
## What the scenarios look like
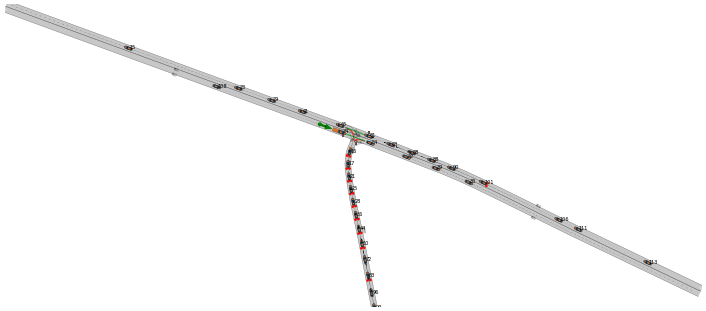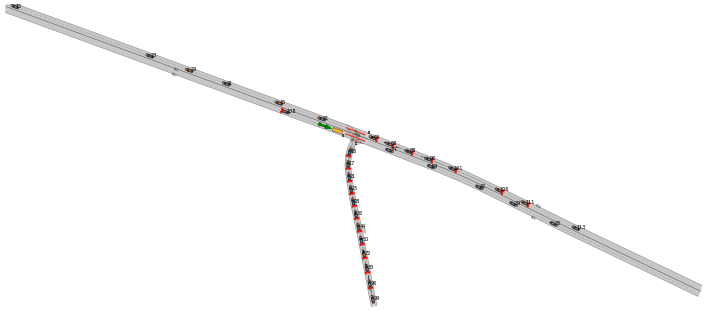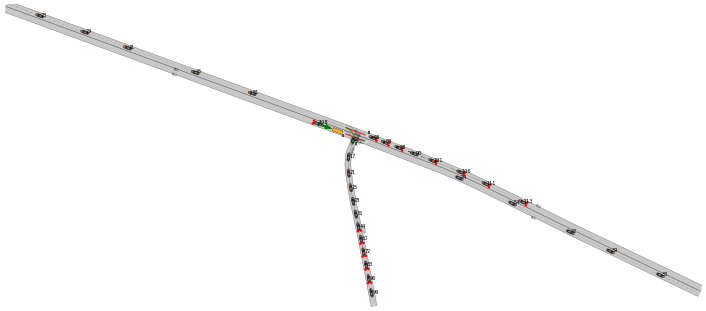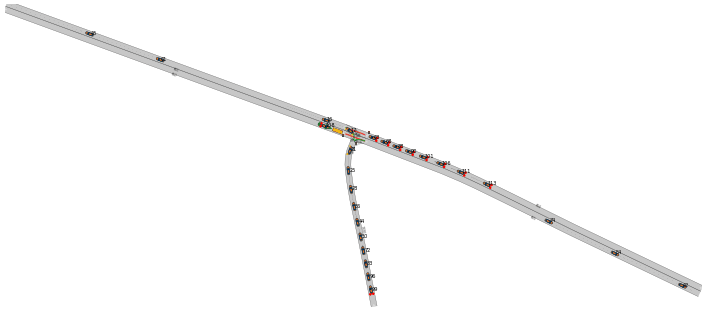
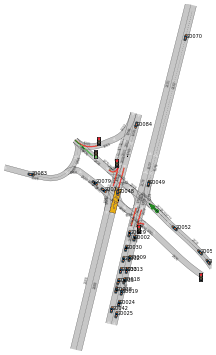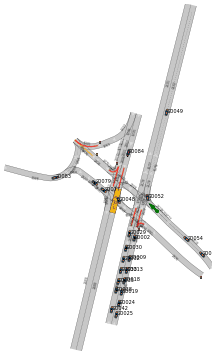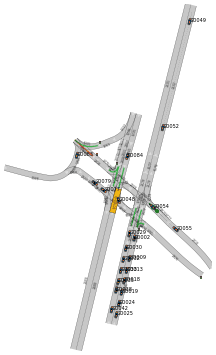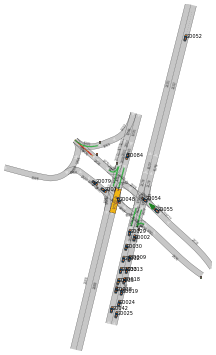
Four scenarios from the corpus, animated over their recorded horizon. Vehicles, traffic lights
and traffic signs are all part of the scenario; the numbers are lanelet and obstacle IDs.
| | |
| :---: | :---: |
| 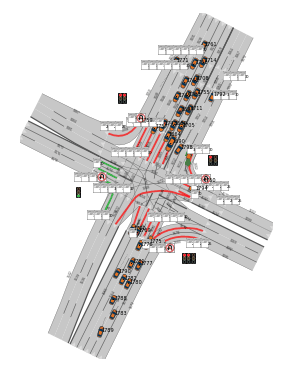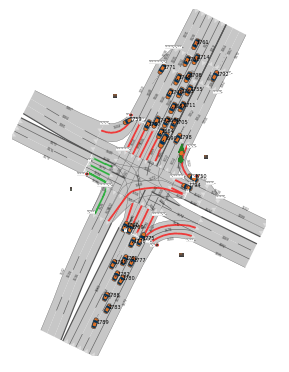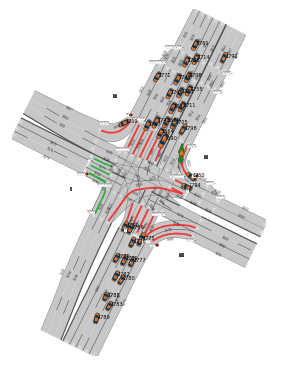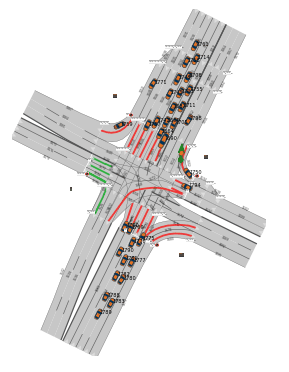 | 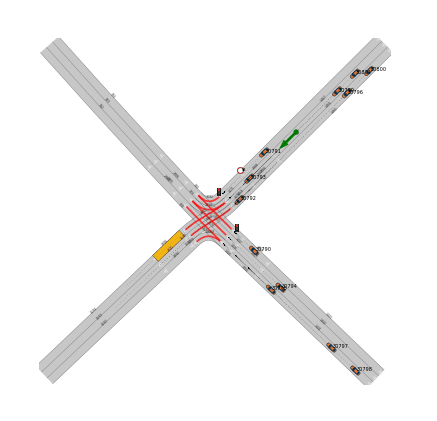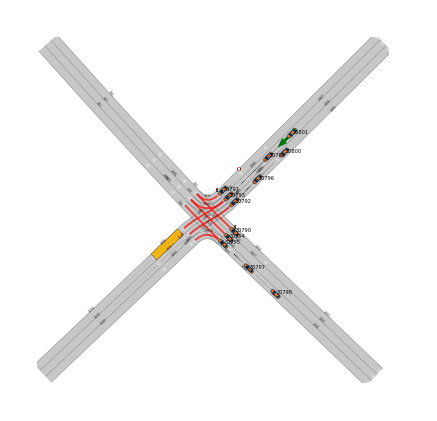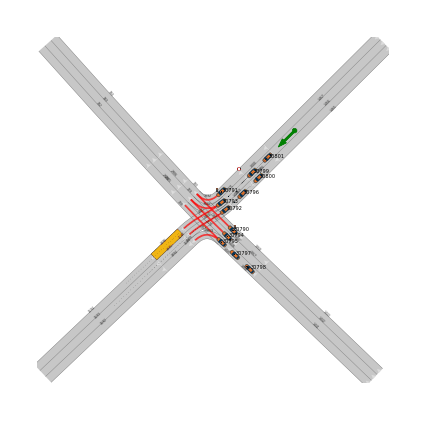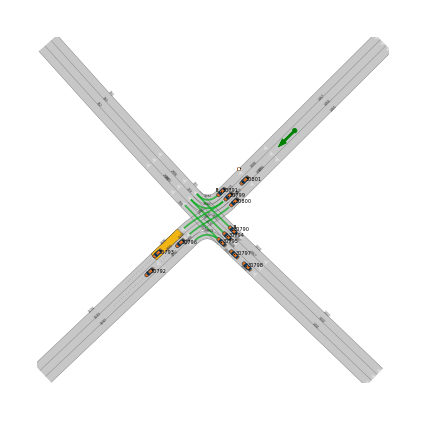 |
| **`USA_Lanker-1_4_T-1`** — signalised multi-lane intersection
34 vehicles · 95 lanelets · 8 traffic lights | **`ESP_Barcelona-37_31_T-1`** — signalised crossing
12 vehicles · 44 lanelets · 2 traffic lights · 15 s |
|  |  |
| **`DEU_Weimar-71_1_T-4`** — merging junction
32 vehicles · 3 traffic lights · 10 s | **`GRC_NeaSmyrni-26_1_T-8`** — multi-way junction
24 vehicles · 71 lanelets · 5 traffic lights · 15 s |
Rendered with the PlannerForge CommonRoad renderer (`osm_pipeline/gif_cr.py`), 28 frames each.
## Contents
```
scenarios/ 582 CommonRoad XML files, ~890 MB
previews/ 4 animated previews of the scenarios above
```
Each file is a self-contained CommonRoad scenario (`commonRoadVersion="2020a"`) holding the
lanelet network, static and dynamic obstacles with their trajectories, and one or more planning
problems. File names follow the CommonRoad benchmark ID convention,
`_-__T-.xml`, e.g. `DEU_Muc-2_1_T-1.xml`.
### Coverage
582 scenarios across **19 countries**:
| Country | Scenarios | | Country | Scenarios |
| --- | --- | --- | --- | --- |
| DEU (Germany) | 228 | | FRA (France) | 23 |
| USA | 83 | | CHN (China) | 19 |
| ESP (Spain) | 68 | | ZAM (Zambia) | 30 |
| GRC (Greece) | 43 | | POL (Poland) | 30 |
…plus 11 further countries (58 scenarios).
## Loading
These are CommonRoad XML files, not a tabular dataset — load them with `commonroad-io` rather
than `datasets.load_dataset`:
```python
from huggingface_hub import snapshot_download
from commonroad.common.file_reader import CommonRoadFileReader
path = snapshot_download("Yuan-avs/PlannerForge-Scenarios", repo_type="dataset")
scenario, planning_problem_set = CommonRoadFileReader(
f"{path}/scenarios/DEU_Muc-2_1_T-1.xml").open()
print(scenario.scenario_id, len(scenario.dynamic_obstacles))
```
To fetch a single scenario without the full 890 MB:
```python
from huggingface_hub import hf_hub_download
f = hf_hub_download("Yuan-avs/PlannerForge-Scenarios",
"scenarios/DEU_Muc-2_1_T-1.xml", repo_type="dataset")
```
## Provenance and credits
These scenarios come from the **CommonRoad scenario database** —
— maintained by the Technical University of Munich.
They are redistributed here unchanged, as the exact set used in the paper, so that the
Selection, Modification and Test results can be reproduced against identical inputs.
Per-scenario author and source credits are embedded in each file's `` root element.
Please honour the [CommonRoad terms of use](https://commonroad.in.tum.de/) and cite CommonRoad
alongside this corpus:
```bibtex
@inproceedings{althoff2017commonroad,
title = {CommonRoad: Composable benchmarks for motion planning on roads},
author = {Althoff, Matthias and Koschi, Markus and Manzinger, Stefanie},
booktitle = {2017 IEEE Intelligent Vehicles Symposium (IV)},
pages = {719--726},
year = {2017},
organization = {IEEE}
}
```
Most of the corpus was produced with **Scenario Factory 2.0**, which PlannerForge also uses as
its rule-based generation baseline in the paper:
```bibtex
@article{finkeldei2025scenariofactory,
title = {Scenario Factory 2.0: Scenario-Based Testing of Automated Vehicles with {CommonRoad}},
author = {Finkeldei, Florian and Thees, Christoph and Weghorn, Jan-Niklas and Althoff, Matthias},
journal = {Automotive Innovation},
volume = {8},
number = {2},
pages = {207--220},
year = {2025}
}
```
### A note on contents
Three `*.con.xml` files present in the working corpus were **excluded**: they are SUMO
connection files emitted by the CommonRoad Scenario Designer, not scenarios, and each has a
proper CommonRoad twin already in the set.
## Citation
```bibtex
@inproceedings{gao2026plannerforge,
title = {PlannerForge: LLM Agents for Scenario-Based Testing of
Motion Planners in Autonomous Driving},
author = {Gao, Yuan and M{\"u}ller, Sebastian and Piccinini, Mattia and
Kaufeld, Marc and Zhang, Yuchen and Sch{\"a}fer, Finn Rasmus and
Song, Qunying and Betz, Johannes},
booktitle = {Proceedings of the 2026 Conference on Empirical Methods in
Natural Language Processing (EMNLP)},
year = {2026},
address = {Budapest, Hungary},
note = {Code and data:
https://github.com/TUM-AVS/PlannerForge}
}
```
When you use these scenarios, please cite CommonRoad as well as this corpus.