
Datasets:

Add files using upload-large-folder tool
Browse files- assets/task_suite_infographic.png +2 -2
- data/project_status.json +332 -339
- data/publication_audit.json +12 -9
- docs/assets/charts/tier2_task_suite.svg +2 -2
- docs/assets/task_suite_infographic.png +2 -2
- docs/data/artifact_index.json +107 -74
- docs/data/evaluation_protocol.json +91 -36
- docs/data/figure_index.json +11 -11
- docs/data/mirror_parity.json +0 -0
- docs/data/project_brief.json +4 -4
- docs/data/project_manifest.json +9 -5
- docs/data/project_packet.json +168 -163
- docs/data/project_status.json +332 -339
- docs/data/public_surface_qa.json +10 -9
- docs/data/publication_audit.json +12 -9
- docs/data/quality_gates.json +2 -2
- docs/data/reproducibility_matrix.json +6 -6
- docs/data/scope_claims_audit.json +1 -1
- docs/data/source_alignment_audit.json +1 -1
- docs/data/task_suite_20.json +723 -0
- docs/data/task_surface_integrity.json +1 -1
- docs/data/tier2_task_suite.json +28 -27
- docs/data/website_integrity.json +34 -29
- results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md +18 -16
- results/episode_task_suite/tier2_task_suite/action_object_relation/metrics.json +1 -1
- results/episode_task_suite/tier2_task_suite/camera_view_sync_retrieval/metrics.json +1 -1
- results/episode_task_suite/tier2_task_suite/imu_to_hand_pose/metrics.json +1 -1
- results/episode_task_suite/tier2_task_suite/interaction_text_prediction/metrics.json +1 -1
- results/episode_task_suite/tier2_task_suite/long_horizon_next_action/metrics.json +1 -1
- results/episode_task_suite/tier2_task_suite/neural_mlp/action_object_relation/metrics.json +1 -1
- results/episode_task_suite/tier2_task_suite/neural_mlp/camera_view_sync_retrieval/metrics.json +1 -1
- results/episode_task_suite/tier2_task_suite/neural_mlp/imu_to_hand_pose/metrics.json +1 -1
- results/episode_task_suite/tier2_task_suite/neural_mlp/interaction_text_prediction/metrics.json +1 -1
- results/episode_task_suite/tier2_task_suite/neural_mlp/long_horizon_next_action/metrics.json +1 -1
- results/episode_task_suite/tier2_task_suite/neural_mlp/object_set_forecast/metrics.json +1 -1
- results/episode_task_suite/tier2_task_suite/neural_mlp/time_to_transition/metrics.json +1 -1
- results/episode_task_suite/tier2_task_suite/next_subtask_forecast/metrics.json +1 -1
- results/episode_task_suite/tier2_task_suite/object_set_forecast/metrics.json +1 -1
- results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json +28 -27
- results/episode_task_suite/tier2_task_suite/time_to_transition/metrics.json +1 -1
assets/task_suite_infographic.png
CHANGED

|
Git LFS Details
|

|
Git LFS Details
|
data/project_status.json
CHANGED
|
@@ -1,352 +1,345 @@
|
|
| 1 |
{
|
| 2 |
-
|
| 3 |
-
|
| 4 |
-
|
| 5 |
-
|
| 6 |
-
|
| 7 |
-
|
| 8 |
-
|
| 9 |
-
|
| 10 |
-
|
| 11 |
-
"core_task_count": 12,
|
| 12 |
-
"tier2_extension_task_count": 8,
|
| 13 |
"neural_head_count": 12,
|
| 14 |
-
|
| 15 |
-
|
| 16 |
-
|
| 17 |
-
|
| 18 |
-
|
| 19 |
-
|
| 20 |
-
|
| 21 |
-
|
| 22 |
-
|
| 23 |
-
|
| 24 |
-
|
| 25 |
-
|
| 26 |
-
|
| 27 |
-
|
| 28 |
-
|
| 29 |
-
|
| 30 |
-
|
| 31 |
-
|
| 32 |
-
|
| 33 |
-
|
| 34 |
-
|
| 35 |
-
|
| 36 |
-
|
| 37 |
-
|
| 38 |
-
|
| 39 |
-
|
| 40 |
-
|
| 41 |
-
|
| 42 |
-
|
| 43 |
-
|
| 44 |
-
|
| 45 |
-
|
| 46 |
-
|
| 47 |
-
|
| 48 |
-
|
| 49 |
-
|
| 50 |
-
|
| 51 |
-
|
| 52 |
-
|
| 53 |
-
|
| 54 |
-
|
| 55 |
-
|
| 56 |
-
|
| 57 |
-
|
| 58 |
-
|
| 59 |
-
|
| 60 |
-
|
| 61 |
-
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 62 |
},
|
| 63 |
-
"rows": [
|
| 64 |
-
{
|
| 65 |
-
"area": "Public-sample pipeline",
|
| 66 |
-
"status": "verified",
|
| 67 |
-
"evidence": [
|
| 68 |
-
"results/episode_task_suite/summary_report.json",
|
| 69 |
-
"results/episode_task_suite/windows.csv",
|
| 70 |
-
"results/episode_task_suite/feature_manifest.json"
|
| 71 |
-
],
|
| 72 |
-
"readout": "One public Xperience-10M sample episode is converted into 5,821 frames, 1,161 aligned 20-frame windows, and an 8,546-dimensional representation for repeatable task evaluation."
|
| 73 |
-
},
|
| 74 |
{
|
| 75 |
-
"area": "
|
| 76 |
"status": "verified",
|
| 77 |
-
|
| 78 |
-
|
| 79 |
-
|
| 80 |
-
"docs/data/summary_metrics.json"
|
| 81 |
],
|
| 82 |
-
"readout": "
|
| 83 |
},
|
| 84 |
{
|
| 85 |
-
"area": "
|
| 86 |
"status": "verified",
|
| 87 |
"evidence": [
|
| 88 |
-
"
|
| 89 |
-
"
|
| 90 |
-
"
|
| 91 |
],
|
| 92 |
-
"readout": "
|
| 93 |
},
|
| 94 |
-
|
| 95 |
-
|
| 96 |
-
|
| 97 |
-
|
| 98 |
-
|
| 99 |
-
|
| 100 |
-
|
| 101 |
-
|
| 102 |
-
|
| 103 |
-
|
| 104 |
-
|
| 105 |
-
|
| 106 |
-
|
| 107 |
-
|
| 108 |
-
|
| 109 |
-
|
| 110 |
-
|
| 111 |
-
|
| 112 |
-
|
| 113 |
-
|
| 114 |
-
|
| 115 |
-
|
| 116 |
-
|
| 117 |
-
|
| 118 |
-
|
| 119 |
-
|
| 120 |
-
|
| 121 |
-
|
| 122 |
-
|
| 123 |
-
|
| 124 |
-
|
| 125 |
-
|
| 126 |
-
|
| 127 |
-
|
| 128 |
-
|
| 129 |
-
|
| 130 |
-
|
| 131 |
-
|
| 132 |
-
|
| 133 |
-
|
| 134 |
-
|
| 135 |
-
|
| 136 |
-
|
| 137 |
-
|
| 138 |
-
|
| 139 |
-
|
| 140 |
-
|
| 141 |
-
|
| 142 |
-
|
| 143 |
-
|
| 144 |
-
|
| 145 |
-
|
| 146 |
-
|
| 147 |
-
|
| 148 |
-
|
| 149 |
-
|
| 150 |
-
|
| 151 |
-
|
| 152 |
-
|
| 153 |
-
|
| 154 |
-
|
| 155 |
-
|
| 156 |
-
|
| 157 |
-
|
| 158 |
-
|
| 159 |
-
|
| 160 |
-
|
| 161 |
-
|
| 162 |
-
|
| 163 |
-
|
| 164 |
-
|
| 165 |
-
|
| 166 |
-
|
| 167 |
-
|
| 168 |
-
|
| 169 |
-
|
| 170 |
-
|
| 171 |
-
|
| 172 |
-
|
| 173 |
-
|
| 174 |
-
|
| 175 |
-
|
| 176 |
-
|
| 177 |
-
|
| 178 |
-
|
| 179 |
-
|
| 180 |
-
|
| 181 |
-
|
| 182 |
-
|
| 183 |
-
|
| 184 |
-
|
| 185 |
-
|
| 186 |
-
|
| 187 |
-
|
| 188 |
-
|
| 189 |
-
|
| 190 |
-
|
| 191 |
-
|
| 192 |
-
|
| 193 |
-
|
| 194 |
-
|
| 195 |
-
|
| 196 |
-
|
| 197 |
-
|
| 198 |
-
|
| 199 |
-
|
| 200 |
-
|
| 201 |
-
|
| 202 |
-
|
| 203 |
-
|
| 204 |
-
|
| 205 |
-
|
| 206 |
-
|
| 207 |
-
|
| 208 |
-
|
| 209 |
-
|
| 210 |
-
|
| 211 |
-
|
| 212 |
-
|
| 213 |
-
|
| 214 |
-
|
| 215 |
-
|
| 216 |
-
|
| 217 |
-
|
| 218 |
-
|
| 219 |
-
|
| 220 |
-
|
| 221 |
-
|
| 222 |
-
|
| 223 |
-
|
| 224 |
-
|
| 225 |
-
|
| 226 |
-
|
| 227 |
-
|
| 228 |
-
|
| 229 |
-
|
| 230 |
-
|
| 231 |
-
|
| 232 |
-
|
| 233 |
-
|
| 234 |
-
|
| 235 |
-
|
| 236 |
-
|
| 237 |
-
|
| 238 |
-
|
| 239 |
-
|
| 240 |
-
|
| 241 |
-
|
| 242 |
-
|
| 243 |
-
|
| 244 |
-
|
| 245 |
-
|
| 246 |
-
"scripts/omni/build_omni_model_comparison.py"
|
| 247 |
-
],
|
| 248 |
-
"readout": "The public comparison now has two views: the three result layers and a model-family grouping. The model grouping pairs 1-episode and 128-episode entries for task-head baselines, separates Qwen3-Omni sensor-adapter smoke from 128-episode LoRA diagnostics, separates Cosmos3-Nano future-window compatibility from Cosmos3-Super base-weight Reasoner evaluation, and adds Cosmos3-Super Forward-Dynamics LoRA as a loss-based fine-tuned adapter branch."
|
| 249 |
-
},
|
| 250 |
-
{
|
| 251 |
-
"area": "Qwen3-Omni fine-tuning",
|
| 252 |
-
"status": "final_verified_diagnostic_result_json_target_met",
|
| 253 |
-
"evidence": [
|
| 254 |
-
"docs/data/omni_finetune_verified_result.json",
|
| 255 |
-
"docs/data/qwen3_v5_v6_comparison.json",
|
| 256 |
-
"results/omni_finetune/QWEN3_V5_V6_COMPARISON_20260614.md",
|
| 257 |
-
"results/omni_finetune/verified_public/xperience10m_qwen3_omni_128ep_multiscale_cap96_v6_rank64_lr5e5_full8gpu_lora_eval_test_full/",
|
| 258 |
-
"https://huggingface.co/cy0307/ropedia-qwen3-omni-lora-128ep",
|
| 259 |
-
"scripts/omni/package_verified_omni_result.py",
|
| 260 |
-
"scripts/omni/audit_verified_omni_package.py",
|
| 261 |
-
"scripts/omni/analyze_qwen3_omni_errors.py"
|
| 262 |
-
],
|
| 263 |
-
"readout": "The selected 96/16/16 episode split now has a current v6 rank64/lr5e-5 public-safe held-out package with 34,269 exported windows, 4,032 test predictions, validation/audit summaries, and a public LoRA adapter repo. JSON validity is 99.90%, meeting the 98% target; transition accuracy is 98.98%, contact accuracy is 81.77%, object micro-F1 is 30.65%, next-action accuracy is 4.31%, and action/subtask metrics remain weak. v6 improves action macro-F1 and contact accuracy versus v5, but v5 remains stronger on JSON validity, subtask, next-action, transition, and object metrics."
|
| 264 |
-
},
|
| 265 |
-
{
|
| 266 |
-
"area": "Cosmos3-Nano future-window branch",
|
| 267 |
-
"status": "verified_compatibility_result",
|
| 268 |
-
"evidence": [
|
| 269 |
-
"configs/omni_backbones/cosmos_world_model.json",
|
| 270 |
-
"scripts/omni/export_cosmos3_future_window_dataset.py",
|
| 271 |
-
"scripts/omni/eval_cosmos3_future_window_retrieval.py",
|
| 272 |
-
"results/omni_finetune/verified_public/xperience10m_cosmos3_nano_128ep_future_window_h5_compat_adapter_eval_test_full/verified_result_summary.json"
|
| 273 |
-
],
|
| 274 |
-
"readout": "The Cosmos3-Nano branch now has a public-safe verified future-window compatibility package with 3,213 future-window samples, 378 held-out test predictions, future retrieval MRR 0.0221, temporal consistency 0.0952, transition accuracy 0.9683, and contact accuracy 0.7434. It is a compatibility adapter result, not a full Cosmos diffusion-weight fine-tune."
|
| 275 |
-
},
|
| 276 |
-
{
|
| 277 |
-
"area": "Cosmos3-Super Reasoner branch",
|
| 278 |
-
"status": "verified_base_weight_result",
|
| 279 |
-
"evidence": [
|
| 280 |
-
"configs/omni_backbones/cosmos3_super_reasoner.json",
|
| 281 |
-
"scripts/omni/eval_cosmos3_super_reasoner.py",
|
| 282 |
-
"scripts/omni/run_cosmos3_super_reasoner_eval.sh",
|
| 283 |
-
"results/omni_finetune/verified_public/xperience10m_cosmos3_super_reasoner_128ep_test_full_20260607/verified_result_summary.json"
|
| 284 |
-
],
|
| 285 |
-
"readout": "Cosmos3-Super Reasoner now has a public-safe verified 448-window held-out evaluation on the same structured JSON task as Qwen3. It uses staged nv-community/Cosmos3-Super base weights through an 8-GPU vLLM server, not fine-tuned weights: JSON validity 0.5112, action macro-F1 0.0008, transition accuracy 0.3683, contact accuracy 0.3214, and object micro-F1 0.1370."
|
| 286 |
-
},
|
| 287 |
-
{
|
| 288 |
-
"area": "Cosmos3-Super action-target contract",
|
| 289 |
-
"status": "superseded_by_verified_forward_dynamics_lora",
|
| 290 |
-
"evidence": [
|
| 291 |
-
"scripts/omni/export_cosmos3_camera_pose_targets.py",
|
| 292 |
-
"scripts/omni/pack_cosmos3_super_action_batch.py",
|
| 293 |
-
"results/omni_finetune/xperience10m_cosmos3_camera_pose_targets_20260608/target_manifest.json",
|
| 294 |
-
"results/omni_finetune/xperience10m_cosmos3_super_training_contract_audit_camera_pose_20260608/training_contract_audit.json",
|
| 295 |
-
"results/omni_finetune/xperience10m_cosmos3_super_action_packer_schema_smoke_20260608/packer_summary.json"
|
| 296 |
-
],
|
| 297 |
-
"readout": "The selected 128-episode JSONL is augmented with 3,808/3,808 valid camera_pose proxy cosmos_action_target records from SLAM pose deltas. The contract and packer smoke enabled the verified forward-dynamics LoRA run; it supervises noisy vision tokens under camera-pose conditioning and does not supervise preds_action."
|
| 298 |
-
},
|
| 299 |
-
{
|
| 300 |
-
"area": "Cosmos3-Super Forward-Dynamics LoRA",
|
| 301 |
-
"status": "verified_fine_tuned_adapter_result",
|
| 302 |
-
"evidence": [
|
| 303 |
-
"configs/omni_backbones/cosmos3_super_forward_dynamics.json",
|
| 304 |
-
"scripts/omni/train_cosmos3_super_forward_dynamics_lora.py",
|
| 305 |
-
"scripts/omni/eval_cosmos3_super_forward_dynamics_lora.py",
|
| 306 |
-
"results/omni_finetune/verified_public/xperience10m_cosmos3_super_forward_dynamics_lora_128ep_train1epoch_256_attn_full8gpu_20260608_eval_test_full_fsdp/verified_result_summary.json",
|
| 307 |
-
"results/omni_finetune/verified_public/xperience10m_cosmos3_super_forward_dynamics_lora_128ep_train1epoch_256_attn_full8gpu_20260608_eval_test_full_fsdp/package_audit.json"
|
| 308 |
-
],
|
| 309 |
-
"readout": "The first fine-tuned Cosmos3-Super adapter branch is verified as a public-safe package: 8-GPU FSDP LoRA, 26.2M adapter parameters, 2,848 train rows, 512 validation rows, 448 held-out test rows, validation MSE 4.0082, and test MSE 3.6853. The package excludes adapter safetensors; weights are published separately at cy0307/ropedia-cosmos3-super-forward-dynamics-lora-128ep."
|
| 310 |
-
},
|
| 311 |
-
{
|
| 312 |
-
"area": "Raw Xperience-10M redistribution",
|
| 313 |
-
"status": "not_included",
|
| 314 |
-
"evidence": [
|
| 315 |
-
"DATA_NOTICE.md",
|
| 316 |
-
"docs/data/publication_audit.json"
|
| 317 |
-
],
|
| 318 |
-
"readout": "Raw MP4, HDF5, RRD files, private gated data, and full Qwen weights are intentionally excluded."
|
| 319 |
-
}
|
| 320 |
-
],
|
| 321 |
-
"fast_research_route": [
|
| 322 |
-
"Read PROJECT_STATUS.md and EVIDENCE_CONTRACT.md to establish what is implemented.",
|
| 323 |
-
"Open docs/data/project_packet.json for the machine-readable project path.",
|
| 324 |
-
"Inspect RESEARCH_TAKEAWAYS.md and docs/data/research_takeaways.json before interpreting model scores.",
|
| 325 |
-
"Inspect RESEARCH_ROADMAP.md and docs/data/research_roadmap.json for the path from public-sample task work to multi-episode modeling.",
|
| 326 |
-
"Inspect FOUNDATION_MODEL_PLAN.md and docs/data/foundation_model_plan.json before choosing a backbone branch.",
|
| 327 |
-
"Inspect OMNI_MODEL_EXTENSION_CONTRACT.md and run python scripts/omni/backbone_registry.py --validate --json before adding a new Qwen, Cosmos-style, or VLA/policy branch.",
|
| 328 |
-
"Inspect XPERIENCE_EMBODIED_FOUNDATION_MODEL_PRETRAINING.md for the long-term full-corpus pretraining goal.",
|
| 329 |
-
"Inspect docs/data/summary_metrics.json and results/episode_task_suite/neural_mlp/ to check the 12-task outputs.",
|
| 330 |
-
"Inspect results/audio_ablation/AUDIO_ABLATION_SUMMARY.md before judging whether audio helps the current task suite.",
|
| 331 |
-
"Inspect EVALUATION_PROTOCOL.md before judging task metrics or leakage controls.",
|
| 332 |
-
"Inspect SOURCE_ALIGNMENT_AUDIT.md before judging source-card consistency across public surfaces.",
|
| 333 |
-
"Inspect XPERIENCE10M_DATASET_CARD_ALIGNMENT.md before judging dataset wording.",
|
| 334 |
-
"Inspect results/omni_finetune/multi_episode_128_task_baselines/BASELINE_ALIGNMENT_REPORT.md before comparing simple/NN baselines to the selected 128-episode setup.",
|
| 335 |
-
"Inspect TASK_SUITE_ENHANCEMENT_128.md and docs/data/task_suite_enhancement_128.json before deciding whether more episodes are needed; the current recommended no-new-episode export is multiscale_20s10_40s20_80s40.",
|
| 336 |
-
"Inspect docs/data/omni_model_comparison.json before comparing the current three result versions or the model-family 1-episode versus 128-episode groupings.",
|
| 337 |
-
"Inspect docs/data/omni_finetune_verified_result.json before judging the Qwen3-Omni diagnostic pilot."
|
| 338 |
-
],
|
| 339 |
-
"current_reading_notes": [
|
| 340 |
-
"The latest Qwen3-Omni v6 diagnostic branch is verified and meets the strict-JSON target, but action/subtask held-out quality is still weak: JSON validity is 99.90%, action macro-F1 is 0.0029, and subtask accuracy is 0.0037. v5 remains the pinned prior release row because it is still stronger on several metrics.",
|
| 341 |
-
"Use TASK_SUITE_ENHANCEMENT_128.md and docs/data/task_suite_enhancement_128.json to push the current 128-episode suite without more raw episodes through multiscale_20s10_40s20_80s40, hierarchical labels, label-normalized scoring, and raw-feature shard export.",
|
| 342 |
-
"Use docs/data/omni_model_comparison.json to compare both views: the single-episode/128-baseline/model-branch result layers and the model-family grouping for task heads, Qwen3-Omni LoRA, Cosmos3-Nano, and Cosmos3-Super.",
|
| 343 |
-
"The 128-episode aligned simple/NN baselines use metadata/text features from the derived Qwen JSONL export; they align the split and task ids but do not replace raw-modality baselines for trajectory, retrieval, reconstruction, or misalignment tasks.",
|
| 344 |
-
"The Cosmos3-Nano future-window branch is verified as a compatibility adapter result, Cosmos3-Super Reasoner is verified as a base-weight evaluation, and Cosmos3-Super Forward-Dynamics LoRA is verified as the first fine-tuned Super adapter branch. Cosmos3-Super adapter weights belong in cy0307/ropedia-cosmos3-super-forward-dynamics-lora-128ep; verified_public packages exclude safetensors.",
|
| 345 |
-
"The current reconstruction task reconstructs feature vectors, not pixel-depth, mesh, NeRF, or Gaussian reconstruction.",
|
| 346 |
-
"Audio is one of the synchronized source modalities in the current task representation.",
|
| 347 |
-
"The audio ablation report compares audio/no-audio variants across all 12 task contracts in results/audio_ablation/.",
|
| 348 |
-
"Foundation-model selection is explicit: Qwen3-Omni is the structured JSON baseline, Cosmos 3 is the world-model branch with Nano compatibility and Super forward-dynamics LoRA results, and policy models such as OpenVLA/openpi/GR00T wait for robot-compatible action-target conversion.",
|
| 349 |
-
"Future model branches should be added through the backbone registry and verified package contract, not as one-off result folders with incompatible metrics or publication rules.",
|
| 350 |
-
"The Xperience Embodied Foundation Model is a future native-pretraining goal, not a completed model or current benchmark."
|
| 351 |
-
]
|
| 352 |
}
|
|
|
|
| 1 |
{
|
| 2 |
+
"title": "Ropedia Xperience-10M Task Suite Project Status",
|
| 3 |
+
"version": "2026-06-14",
|
| 4 |
+
"decision": "public_sample_pipeline_verified_128_enhancement_qwen3_v6_cosmos_comparison",
|
| 5 |
+
"research_positioning": "A research-engineering study that makes one public Xperience-10M sample episode inspectable, defines embodied-AI tasks over synchronized modalities, records baseline behavior, aligns simple/NN baselines to the selected 128-episode split, compares verified Qwen3-Omni and Cosmos3 branch packages as early cross-episode diagnostics, and now records a no-new-episode enhancement pack for pushing the current 128-episode suite harder.",
|
| 6 |
+
"scope_boundary": {
|
| 7 |
+
"validated_episode_count": 1,
|
| 8 |
+
"aligned_frames": 5821,
|
| 9 |
+
"sliding_windows": 1161,
|
| 10 |
+
"current_feature_dimensions": 8546,
|
|
|
|
|
|
|
| 11 |
"neural_head_count": 12,
|
| 12 |
+
"direction_extension_probe_count": 4,
|
| 13 |
+
"audio_featurized": true,
|
| 14 |
+
"raw_xperience10m_data_redistributed": false,
|
| 15 |
+
"qwen3_omni_32_episode_claim": false,
|
| 16 |
+
"qwen3_omni_verified_diagnostic_pilot": true,
|
| 17 |
+
"qwen3_omni_selected_episode_counts": {
|
| 18 |
+
"train": 96,
|
| 19 |
+
"val": 16,
|
| 20 |
+
"test": 16
|
| 21 |
+
},
|
| 22 |
+
"qwen3_omni_exported_window_counts": {
|
| 23 |
+
"train": 25629,
|
| 24 |
+
"val": 4608,
|
| 25 |
+
"test": 4032
|
| 26 |
+
},
|
| 27 |
+
"qwen3_omni_json_validity_rate": 0.9990079365079365,
|
| 28 |
+
"qwen3_omni_validation_aware": true,
|
| 29 |
+
"qwen3_omni_json_quality_target_met": true,
|
| 30 |
+
"qwen3_omni_lora_adapter_repo": "https://huggingface.co/cy0307/ropedia-qwen3-omni-lora-128ep",
|
| 31 |
+
"cosmos3_nano_future_window_compatibility_verified": true,
|
| 32 |
+
"cosmos3_nano_future_window_test_predictions": 378,
|
| 33 |
+
"cosmos3_super_reasoner_verified": true,
|
| 34 |
+
"cosmos3_super_reasoner_test_predictions": 448,
|
| 35 |
+
"cosmos3_super_reasoner_json_validity_rate": 0.5111607142857143,
|
| 36 |
+
"cosmos3_super_forward_dynamics_lora_verified": true,
|
| 37 |
+
"cosmos3_super_forward_dynamics_train_rows": 2848,
|
| 38 |
+
"cosmos3_super_forward_dynamics_val_rows": 512,
|
| 39 |
+
"cosmos3_super_forward_dynamics_test_rows": 448,
|
| 40 |
+
"cosmos3_super_forward_dynamics_test_mse": 3.6853174321087345,
|
| 41 |
+
"cosmos3_super_forward_dynamics_adapter_params": 26214400,
|
| 42 |
+
"omni_model_comparison_available": true,
|
| 43 |
+
"multi_episode_128_aligned_baselines": true,
|
| 44 |
+
"multi_episode_128_baseline_window_counts": {
|
| 45 |
+
"train": 2848,
|
| 46 |
+
"val": 512,
|
| 47 |
+
"test": 448
|
| 48 |
+
},
|
| 49 |
+
"multi_episode_128_baseline_task_count": 12,
|
| 50 |
+
"qwen3_omni_current_eval_run_id": "xperience10m_qwen3_omni_128ep_multiscale_cap96_v6_rank64_lr5e5_full8gpu_lora_eval_test_full",
|
| 51 |
+
"qwen3_omni_current_train_epochs": 2,
|
| 52 |
+
"qwen3_omni_action_macro_f1": 0.0028830723979596335,
|
| 53 |
+
"qwen3_omni_subtask_accuracy": 0.0037313432835820895,
|
| 54 |
+
"qwen3_omni_contact_accuracy": 0.8177083333333334,
|
| 55 |
+
"qwen3_omni_object_micro_f1": 0.3064982378331287,
|
| 56 |
+
"task_suite_enhancement_128_available": true,
|
| 57 |
+
"task_suite_enhancement_128_current_windows": 3808,
|
| 58 |
+
"task_suite_enhancement_128_recommended_export": "multiscale_20s10_40s20_80s40",
|
| 59 |
+
"task_suite_enhancement_128_estimated_windows": 106095,
|
| 60 |
+
"task_count": 20,
|
| 61 |
+
"original_public_sample_task_count": 12,
|
| 62 |
+
"additional_public_sample_task_count": 8,
|
| 63 |
+
"legacy_tasks_13_to_20_result_path": "docs/data/tier2_task_suite.json"
|
| 64 |
+
},
|
| 65 |
+
"rows": [
|
| 66 |
+
{
|
| 67 |
+
"area": "Public-sample pipeline",
|
| 68 |
+
"status": "verified",
|
| 69 |
+
"evidence": [
|
| 70 |
+
"results/episode_task_suite/summary_report.json",
|
| 71 |
+
"results/episode_task_suite/windows.csv",
|
| 72 |
+
"results/episode_task_suite/feature_manifest.json"
|
| 73 |
+
],
|
| 74 |
+
"readout": "One public Xperience-10M sample episode is converted into 5,821 frames, 1,161 aligned 20-frame windows, and an 8,546-dimensional representation for repeatable task evaluation."
|
| 75 |
+
},
|
| 76 |
+
{
|
| 77 |
+
"area": "Unified 20-task suite",
|
| 78 |
+
"status": "verified",
|
| 79 |
+
"evidence": [
|
| 80 |
+
"TASK_SUITE_20.md",
|
| 81 |
+
"docs/data/task_suite_20.json",
|
| 82 |
+
"results/episode_task_suite/",
|
| 83 |
+
"results/episode_task_suite/tier2_task_suite/"
|
| 84 |
+
],
|
| 85 |
+
"readout": "All 20 task contracts have committed minimal metrics; tasks 13-20 reuse the same 20-frame windows, 5-frame stride, chronological split, and minimal/neural head pattern. The tier2_task_suite path is historical and now stores tasks 13-20, not a separate public tier."
|
| 86 |
+
},
|
| 87 |
+
{
|
| 88 |
+
"area": "Neural heads",
|
| 89 |
+
"status": "verified",
|
| 90 |
+
"evidence": [
|
| 91 |
+
"scripts/neural_task_models.py",
|
| 92 |
+
"results/episode_task_suite/neural_mlp/"
|
| 93 |
+
],
|
| 94 |
+
"readout": "Each task also has a compact PyTorch MLP run over the same feature tensor and chronological split."
|
| 95 |
+
},
|
| 96 |
+
{
|
| 97 |
+
"area": "Audio contribution study",
|
| 98 |
+
"status": "verified",
|
| 99 |
+
"evidence": [
|
| 100 |
+
"scripts/audio_ablation_and_raw_upgrade.py",
|
| 101 |
+
"results/audio_ablation/",
|
| 102 |
+
"docs/data/audio_ablation_summary.json"
|
| 103 |
+
],
|
| 104 |
+
"readout": "Audio variants improve the primary metric on 6 of 12 task contracts in this single-episode setting."
|
| 105 |
+
},
|
| 106 |
+
{
|
| 107 |
+
"area": "Evaluation protocol",
|
| 108 |
+
"status": "verified",
|
| 109 |
+
"evidence": [
|
| 110 |
+
"EVALUATION_PROTOCOL.md",
|
| 111 |
+
"docs/data/evaluation_protocol.json",
|
| 112 |
+
"scripts/build_evaluation_protocol.py"
|
| 113 |
+
],
|
| 114 |
+
"readout": "Windowing, chronological split, per-task metrics, leakage controls, and current limitations are generated from committed metric artifacts."
|
| 115 |
+
},
|
| 116 |
+
{
|
| 117 |
+
"area": "Research takeaways",
|
| 118 |
+
"status": "verified",
|
| 119 |
+
"evidence": [
|
| 120 |
+
"RESEARCH_TAKEAWAYS.md",
|
| 121 |
+
"docs/data/research_takeaways.json",
|
| 122 |
+
"scripts/build_research_takeaways.py"
|
| 123 |
+
],
|
| 124 |
+
"readout": "The main result interpretation is generated from committed metrics: chronological class shift, neural gains on dynamics/order/alignment, open retrieval/reconstruction problems, and the need for held-out episodes."
|
| 125 |
+
},
|
| 126 |
+
{
|
| 127 |
+
"area": "Research roadmap",
|
| 128 |
+
"status": "current",
|
| 129 |
+
"evidence": [
|
| 130 |
+
"RESEARCH_ROADMAP.md",
|
| 131 |
+
"docs/data/research_roadmap.json"
|
| 132 |
+
],
|
| 133 |
+
"readout": "The roadmap connects public-sample task development to the final verified Qwen3-Omni diagnostic result, same-split baseline alignment, the no-new-episode 128-suite enhancement pack, action/subtask error analysis, robustness runs, world/policy branches, and the future Xperience-native pretraining goal."
|
| 134 |
+
},
|
| 135 |
+
{
|
| 136 |
+
"area": "128-episode task-suite enhancement pack",
|
| 137 |
+
"status": "current_no_new_episode_plan",
|
| 138 |
+
"evidence": [
|
| 139 |
+
"TASK_SUITE_ENHANCEMENT_128.md",
|
| 140 |
+
"docs/data/task_suite_enhancement_128.json",
|
| 141 |
+
"results/omni_finetune/task_suite_enhancement_128_v1_20260608/enhancement_plan.json",
|
| 142 |
+
"scripts/omni/build_task_suite_enhancement_128.py"
|
| 143 |
+
],
|
| 144 |
+
"readout": "The current 3,808-window selected split can be stressed without more episodes by exporting denser and multiscale windows. The recommended next export is multiscale_20s10_40s20_80s40, estimated at 106,095 windows from observed frame spans; the pack also defines hierarchical action/subtask targets, raw-feature shard priorities for unsupported tasks, and Qwen/Cosmos follow-up run cards."
|
| 145 |
+
},
|
| 146 |
+
{
|
| 147 |
+
"area": "Foundation-model plan",
|
| 148 |
+
"status": "current",
|
| 149 |
+
"evidence": [
|
| 150 |
+
"FOUNDATION_MODEL_PLAN.md",
|
| 151 |
+
"docs/data/foundation_model_plan.json"
|
| 152 |
+
],
|
| 153 |
+
"readout": "Qwen3-Omni remains the first structured JSON LoRA baseline; Cosmos 3 is now represented by a verified Cosmos3-Nano future-window compatibility package, a verified Cosmos3-Super base-weight Reasoner evaluation, and a verified Cosmos3-Super Forward-Dynamics LoRA over camera-pose proxy targets. The Super LoRA target supports vision-velocity training under action conditioning, not supervised action-token prediction; OpenVLA/openpi/GR00T remain policy candidates after robot-compatible action targets are explicit."
|
| 154 |
+
},
|
| 155 |
+
{
|
| 156 |
+
"area": "Omni model extension contract",
|
| 157 |
+
"status": "current",
|
| 158 |
+
"evidence": [
|
| 159 |
+
"OMNI_MODEL_EXTENSION_CONTRACT.md",
|
| 160 |
+
"configs/omni_backbones/",
|
| 161 |
+
"scripts/omni/backbone_registry.py",
|
| 162 |
+
"scripts/omni/smoke_test_backbone_packaging.py"
|
| 163 |
+
],
|
| 164 |
+
"readout": "Future Qwen, Cosmos-style, and VLA/policy branches must keep the same episode split discipline, held-out metrics, validation gate, public-safe package contract, and explicit forbidden-artifact policy before reporting results."
|
| 165 |
+
},
|
| 166 |
+
{
|
| 167 |
+
"area": "Xperience Embodied Foundation Model",
|
| 168 |
+
"status": "future_goal",
|
| 169 |
+
"evidence": [
|
| 170 |
+
"XPERIENCE_EMBODIED_FOUNDATION_MODEL_PRETRAINING.md"
|
| 171 |
+
],
|
| 172 |
+
"readout": "A future full-corpus pretraining plan describes target modules, objectives, staged scale-up, hardware ranges, and evaluation for a domain-specific embodied foundation model."
|
| 173 |
},
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 174 |
{
|
| 175 |
+
"area": "Official dataset wording",
|
| 176 |
"status": "verified",
|
| 177 |
+
"evidence": [
|
| 178 |
+
"XPERIENCE10M_DATASET_CARD_ALIGNMENT.md",
|
| 179 |
+
"docs/data/xperience10m_dataset_card_alignment.json"
|
|
|
|
| 180 |
],
|
| 181 |
+
"readout": "Public wording is aligned to the official gated Xperience-10M dataset card, public sample card, and HF API metadata, including modalities, scale, access path, sample license/tooling, and current project coverage."
|
| 182 |
},
|
| 183 |
{
|
| 184 |
+
"area": "Source alignment",
|
| 185 |
"status": "verified",
|
| 186 |
"evidence": [
|
| 187 |
+
"SOURCE_ALIGNMENT_AUDIT.md",
|
| 188 |
+
"docs/data/source_alignment_audit.json",
|
| 189 |
+
"scripts/validate_source_alignment.py"
|
| 190 |
],
|
| 191 |
+
"readout": "Source facts, sample details, API-listing notes, and project coverage are checked across repo docs, website, and HF cards."
|
| 192 |
},
|
| 193 |
+
{
|
| 194 |
+
"area": "Website and HF mirrors",
|
| 195 |
+
"status": "verified",
|
| 196 |
+
"evidence": [
|
| 197 |
+
"docs/data/website_integrity.json",
|
| 198 |
+
"docs/data/mirror_parity.json",
|
| 199 |
+
"docs/data/live_publication_status.json"
|
| 200 |
+
],
|
| 201 |
+
"readout": "Local website links/assets pass, prepared mirrors match, and public GitHub/HF URLs have been checked after upload."
|
| 202 |
+
},
|
| 203 |
+
{
|
| 204 |
+
"area": "Publication package",
|
| 205 |
+
"status": "verified",
|
| 206 |
+
"evidence": [
|
| 207 |
+
"docs/data/publication_audit.json",
|
| 208 |
+
"QUALITY_GATES.md",
|
| 209 |
+
"docs/data/quality_gates.json"
|
| 210 |
+
],
|
| 211 |
+
"readout": "Public bundles are checked for raw-data exclusion, cache exclusion, heavy-archive exclusion, credential-text checks, and current presentation assets."
|
| 212 |
+
},
|
| 213 |
+
{
|
| 214 |
+
"area": "Reproducibility",
|
| 215 |
+
"status": "verified_for_public_sample",
|
| 216 |
+
"evidence": [
|
| 217 |
+
"REPRODUCIBILITY.md",
|
| 218 |
+
"docs/data/reproducibility_matrix.json",
|
| 219 |
+
"notes/reproducibility_audit.md"
|
| 220 |
+
],
|
| 221 |
+
"readout": "The public sample workflow has explicit commands, expected outputs, and exact-match reproduction evidence."
|
| 222 |
+
},
|
| 223 |
+
{
|
| 224 |
+
"area": "128-episode aligned baselines",
|
| 225 |
+
"status": "verified_companion_result",
|
| 226 |
+
"evidence": [
|
| 227 |
+
"results/omni_finetune/multi_episode_128_task_baselines/BASELINE_ALIGNMENT_REPORT.md",
|
| 228 |
+
"results/omni_finetune/multi_episode_128_task_baselines/summary_report.json",
|
| 229 |
+
"scripts/omni/run_128_task_baselines.py"
|
| 230 |
+
],
|
| 231 |
+
"readout": "The earlier simple and neural baseline framing is aligned to the selected 96/16/16 episode split used by the Qwen3-Omni pilot. JSON-supported tasks have metadata/text simple and neural MLP metrics; raw-feature-only tasks are explicitly marked unsupported until 128-run sensor feature blocks are available."
|
| 232 |
+
},
|
| 233 |
+
{
|
| 234 |
+
"area": "Current result comparison",
|
| 235 |
+
"status": "verified_generated_summary",
|
| 236 |
+
"evidence": [
|
| 237 |
+
"docs/data/omni_model_comparison.json",
|
| 238 |
+
"results/omni_finetune/OMNI_MODEL_COMPARISON.md",
|
| 239 |
+
"scripts/omni/build_omni_model_comparison.py"
|
| 240 |
+
],
|
| 241 |
+
"readout": "The public comparison now has two views: the three result layers and a model-family grouping. The model grouping pairs 1-episode and 128-episode entries for task-head baselines, separates Qwen3-Omni sensor-adapter smoke from 128-episode LoRA diagnostics, separates Cosmos3-Nano future-window compatibility from Cosmos3-Super base-weight Reasoner evaluation, and adds Cosmos3-Super Forward-Dynamics LoRA as a loss-based fine-tuned adapter branch."
|
| 242 |
+
},
|
| 243 |
+
{
|
| 244 |
+
"area": "Qwen3-Omni fine-tuning",
|
| 245 |
+
"status": "final_verified_diagnostic_result_json_target_met",
|
| 246 |
+
"evidence": [
|
| 247 |
+
"docs/data/omni_finetune_verified_result.json",
|
| 248 |
+
"docs/data/qwen3_v5_v6_comparison.json",
|
| 249 |
+
"results/omni_finetune/QWEN3_V5_V6_COMPARISON_20260614.md",
|
| 250 |
+
"results/omni_finetune/verified_public/xperience10m_qwen3_omni_128ep_multiscale_cap96_v6_rank64_lr5e5_full8gpu_lora_eval_test_full/",
|
| 251 |
+
"https://huggingface.co/cy0307/ropedia-qwen3-omni-lora-128ep",
|
| 252 |
+
"scripts/omni/package_verified_omni_result.py",
|
| 253 |
+
"scripts/omni/audit_verified_omni_package.py",
|
| 254 |
+
"scripts/omni/analyze_qwen3_omni_errors.py"
|
| 255 |
+
],
|
| 256 |
+
"readout": "The selected 96/16/16 episode split now has a current v6 rank64/lr5e-5 public-safe held-out package with 34,269 exported windows, 4,032 test predictions, validation/audit summaries, and a public LoRA adapter repo. JSON validity is 99.90%, meeting the 98% target; transition accuracy is 98.98%, contact accuracy is 81.77%, object micro-F1 is 30.65%, next-action accuracy is 4.31%, and action/subtask metrics remain weak. v6 improves action macro-F1 and contact accuracy versus v5, but v5 remains stronger on JSON validity, subtask, next-action, transition, and object metrics."
|
| 257 |
+
},
|
| 258 |
+
{
|
| 259 |
+
"area": "Cosmos3-Nano future-window branch",
|
| 260 |
+
"status": "verified_compatibility_result",
|
| 261 |
+
"evidence": [
|
| 262 |
+
"configs/omni_backbones/cosmos_world_model.json",
|
| 263 |
+
"scripts/omni/export_cosmos3_future_window_dataset.py",
|
| 264 |
+
"scripts/omni/eval_cosmos3_future_window_retrieval.py",
|
| 265 |
+
"results/omni_finetune/verified_public/xperience10m_cosmos3_nano_128ep_future_window_h5_compat_adapter_eval_test_full/verified_result_summary.json"
|
| 266 |
+
],
|
| 267 |
+
"readout": "The Cosmos3-Nano branch now has a public-safe verified future-window compatibility package with 3,213 future-window samples, 378 held-out test predictions, future retrieval MRR 0.0221, temporal consistency 0.0952, transition accuracy 0.9683, and contact accuracy 0.7434. It is a compatibility adapter result, not a full Cosmos diffusion-weight fine-tune."
|
| 268 |
+
},
|
| 269 |
+
{
|
| 270 |
+
"area": "Cosmos3-Super Reasoner branch",
|
| 271 |
+
"status": "verified_base_weight_result",
|
| 272 |
+
"evidence": [
|
| 273 |
+
"configs/omni_backbones/cosmos3_super_reasoner.json",
|
| 274 |
+
"scripts/omni/eval_cosmos3_super_reasoner.py",
|
| 275 |
+
"scripts/omni/run_cosmos3_super_reasoner_eval.sh",
|
| 276 |
+
"results/omni_finetune/verified_public/xperience10m_cosmos3_super_reasoner_128ep_test_full_20260607/verified_result_summary.json"
|
| 277 |
+
],
|
| 278 |
+
"readout": "Cosmos3-Super Reasoner now has a public-safe verified 448-window held-out evaluation on the same structured JSON task as Qwen3. It uses staged nv-community/Cosmos3-Super base weights through an 8-GPU vLLM server, not fine-tuned weights: JSON validity 0.5112, action macro-F1 0.0008, transition accuracy 0.3683, contact accuracy 0.3214, and object micro-F1 0.1370."
|
| 279 |
+
},
|
| 280 |
+
{
|
| 281 |
+
"area": "Cosmos3-Super action-target contract",
|
| 282 |
+
"status": "superseded_by_verified_forward_dynamics_lora",
|
| 283 |
+
"evidence": [
|
| 284 |
+
"scripts/omni/export_cosmos3_camera_pose_targets.py",
|
| 285 |
+
"scripts/omni/pack_cosmos3_super_action_batch.py",
|
| 286 |
+
"results/omni_finetune/xperience10m_cosmos3_camera_pose_targets_20260608/target_manifest.json",
|
| 287 |
+
"results/omni_finetune/xperience10m_cosmos3_super_training_contract_audit_camera_pose_20260608/training_contract_audit.json",
|
| 288 |
+
"results/omni_finetune/xperience10m_cosmos3_super_action_packer_schema_smoke_20260608/packer_summary.json"
|
| 289 |
+
],
|
| 290 |
+
"readout": "The selected 128-episode JSONL is augmented with 3,808/3,808 valid camera_pose proxy cosmos_action_target records from SLAM pose deltas. The contract and packer smoke enabled the verified forward-dynamics LoRA run; it supervises noisy vision tokens under camera-pose conditioning and does not supervise preds_action."
|
| 291 |
+
},
|
| 292 |
+
{
|
| 293 |
+
"area": "Cosmos3-Super Forward-Dynamics LoRA",
|
| 294 |
+
"status": "verified_fine_tuned_adapter_result",
|
| 295 |
+
"evidence": [
|
| 296 |
+
"configs/omni_backbones/cosmos3_super_forward_dynamics.json",
|
| 297 |
+
"scripts/omni/train_cosmos3_super_forward_dynamics_lora.py",
|
| 298 |
+
"scripts/omni/eval_cosmos3_super_forward_dynamics_lora.py",
|
| 299 |
+
"results/omni_finetune/verified_public/xperience10m_cosmos3_super_forward_dynamics_lora_128ep_train1epoch_256_attn_full8gpu_20260608_eval_test_full_fsdp/verified_result_summary.json",
|
| 300 |
+
"results/omni_finetune/verified_public/xperience10m_cosmos3_super_forward_dynamics_lora_128ep_train1epoch_256_attn_full8gpu_20260608_eval_test_full_fsdp/package_audit.json"
|
| 301 |
+
],
|
| 302 |
+
"readout": "The first fine-tuned Cosmos3-Super adapter branch is verified as a public-safe package: 8-GPU FSDP LoRA, 26.2M adapter parameters, 2,848 train rows, 512 validation rows, 448 held-out test rows, validation MSE 4.0082, and test MSE 3.6853. The package excludes adapter safetensors; weights are published separately at cy0307/ropedia-cosmos3-super-forward-dynamics-lora-128ep."
|
| 303 |
+
},
|
| 304 |
+
{
|
| 305 |
+
"area": "Raw Xperience-10M redistribution",
|
| 306 |
+
"status": "not_included",
|
| 307 |
+
"evidence": [
|
| 308 |
+
"DATA_NOTICE.md",
|
| 309 |
+
"docs/data/publication_audit.json"
|
| 310 |
+
],
|
| 311 |
+
"readout": "Raw MP4, HDF5, RRD files, private gated data, and full Qwen weights are intentionally excluded."
|
| 312 |
+
}
|
| 313 |
+
],
|
| 314 |
+
"fast_research_route": [
|
| 315 |
+
"Read PROJECT_STATUS.md and EVIDENCE_CONTRACT.md to establish what is implemented.",
|
| 316 |
+
"Open docs/data/project_packet.json for the machine-readable project path.",
|
| 317 |
+
"Inspect RESEARCH_TAKEAWAYS.md and docs/data/research_takeaways.json before interpreting model scores.",
|
| 318 |
+
"Inspect RESEARCH_ROADMAP.md and docs/data/research_roadmap.json for the path from public-sample task work to multi-episode modeling.",
|
| 319 |
+
"Inspect FOUNDATION_MODEL_PLAN.md and docs/data/foundation_model_plan.json before choosing a backbone branch.",
|
| 320 |
+
"Inspect OMNI_MODEL_EXTENSION_CONTRACT.md and run python scripts/omni/backbone_registry.py --validate --json before adding a new Qwen, Cosmos-style, or VLA/policy branch.",
|
| 321 |
+
"Inspect XPERIENCE_EMBODIED_FOUNDATION_MODEL_PRETRAINING.md for the long-term full-corpus pretraining goal.",
|
| 322 |
+
"Inspect TASK_SUITE_20.md, docs/data/task_suite_20.json, docs/data/summary_metrics.json, and results/episode_task_suite/neural_mlp/ to check the unified 20-task outputs.",
|
| 323 |
+
"Inspect results/audio_ablation/AUDIO_ABLATION_SUMMARY.md before judging whether audio helps the current task suite.",
|
| 324 |
+
"Inspect EVALUATION_PROTOCOL.md before judging task metrics or leakage controls.",
|
| 325 |
+
"Inspect SOURCE_ALIGNMENT_AUDIT.md before judging source-card consistency across public surfaces.",
|
| 326 |
+
"Inspect XPERIENCE10M_DATASET_CARD_ALIGNMENT.md before judging dataset wording.",
|
| 327 |
+
"Inspect results/omni_finetune/multi_episode_128_task_baselines/BASELINE_ALIGNMENT_REPORT.md before comparing simple/NN baselines to the selected 128-episode setup.",
|
| 328 |
+
"Inspect TASK_SUITE_ENHANCEMENT_128.md and docs/data/task_suite_enhancement_128.json before deciding whether more episodes are needed; the current recommended no-new-episode export is multiscale_20s10_40s20_80s40.",
|
| 329 |
+
"Inspect docs/data/omni_model_comparison.json before comparing the current three result versions or the model-family 1-episode versus 128-episode groupings.",
|
| 330 |
+
"Inspect docs/data/omni_finetune_verified_result.json before judging the Qwen3-Omni diagnostic pilot."
|
| 331 |
+
],
|
| 332 |
+
"current_reading_notes": [
|
| 333 |
+
"The latest Qwen3-Omni v6 diagnostic branch is verified and meets the strict-JSON target, but action/subtask held-out quality is still weak: JSON validity is 99.90%, action macro-F1 is 0.0029, and subtask accuracy is 0.0037. v5 remains the pinned prior release row because it is still stronger on several metrics.",
|
| 334 |
+
"Use TASK_SUITE_ENHANCEMENT_128.md and docs/data/task_suite_enhancement_128.json to push the current 128-episode suite without more raw episodes through multiscale_20s10_40s20_80s40, hierarchical labels, label-normalized scoring, and raw-feature shard export.",
|
| 335 |
+
"Use docs/data/omni_model_comparison.json to compare both views: the single-episode/128-baseline/model-branch result layers and the model-family grouping for task heads, Qwen3-Omni LoRA, Cosmos3-Nano, and Cosmos3-Super.",
|
| 336 |
+
"The 128-episode aligned simple/NN baselines use metadata/text features from the derived Qwen JSONL export; they align the split and task ids but do not replace raw-modality baselines for trajectory, retrieval, reconstruction, or misalignment tasks.",
|
| 337 |
+
"The Cosmos3-Nano future-window branch is verified as a compatibility adapter result, Cosmos3-Super Reasoner is verified as a base-weight evaluation, and Cosmos3-Super Forward-Dynamics LoRA is verified as the first fine-tuned Super adapter branch. Cosmos3-Super adapter weights belong in cy0307/ropedia-cosmos3-super-forward-dynamics-lora-128ep; verified_public packages exclude safetensors.",
|
| 338 |
+
"The current reconstruction task reconstructs feature vectors, not pixel-depth, mesh, NeRF, or Gaussian reconstruction.",
|
| 339 |
+
"Audio is one of the synchronized source modalities in the current task representation.",
|
| 340 |
+
"The audio ablation report compares audio/no-audio variants across all 12 task contracts in results/audio_ablation/.",
|
| 341 |
+
"Foundation-model selection is explicit: Qwen3-Omni is the structured JSON baseline, Cosmos 3 is the world-model branch with Nano compatibility and Super forward-dynamics LoRA results, and policy models such as OpenVLA/openpi/GR00T wait for robot-compatible action-target conversion.",
|
| 342 |
+
"Future model branches should be added through the backbone registry and verified package contract, not as one-off result folders with incompatible metrics or publication rules.",
|
| 343 |
+
"The Xperience Embodied Foundation Model is a future native-pretraining goal, not a completed model or current benchmark."
|
| 344 |
+
]
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 345 |
}
|
data/publication_audit.json
CHANGED
|
@@ -1,6 +1,6 @@
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
-
"generated_at_utc": "2026-06-
|
| 4 |
"checks": [
|
| 5 |
{
|
| 6 |
"name": "required_publication_assets_present",
|
|
@@ -57,6 +57,7 @@
|
|
| 57 |
"PUBLIC_SURFACE_QA.md": true,
|
| 58 |
"RENDERED_SITE_CHECK.md": true,
|
| 59 |
"EVALUATION_PROTOCOL.md": true,
|
|
|
|
| 60 |
"FIGURE_INDEX.md": true,
|
| 61 |
"SOURCE_ALIGNMENT_AUDIT.md": true,
|
| 62 |
"XPERIENCE10M_DATASET_CARD_ALIGNMENT.md": true,
|
|
@@ -96,6 +97,7 @@
|
|
| 96 |
"docs/data/task_surface_integrity.json": true,
|
| 97 |
"docs/data/website_integrity.json": true,
|
| 98 |
"docs/data/summary_metrics.json": true,
|
|
|
|
| 99 |
"docs/data/task_suite_enhancement_128.json": true,
|
| 100 |
"docs/assets/modalities/video.jpg": true,
|
| 101 |
"docs/assets/modalities/audio.png": true,
|
|
@@ -124,6 +126,7 @@
|
|
| 124 |
"scripts/build_artifact_index.py": true,
|
| 125 |
"scripts/build_brand_assets.py": true,
|
| 126 |
"scripts/build_evaluation_protocol.py": true,
|
|
|
|
| 127 |
"scripts/build_figure_index.py": true,
|
| 128 |
"scripts/build_quality_gates.py": true,
|
| 129 |
"scripts/build_public_surface_qa.py": true,
|
|
@@ -187,8 +190,8 @@
|
|
| 187 |
"github_repo": {
|
| 188 |
"root": "repo",
|
| 189 |
"exists": true,
|
| 190 |
-
"file_count":
|
| 191 |
-
"text_file_count":
|
| 192 |
"largest_file": {
|
| 193 |
"path": "results/episode_task_suite/modality_reconstruction/predictions.npz",
|
| 194 |
"bytes": 55702978
|
|
@@ -198,8 +201,8 @@
|
|
| 198 |
"hf_space_bundle": {
|
| 199 |
"root": "hf_publish/space",
|
| 200 |
"exists": true,
|
| 201 |
-
"file_count":
|
| 202 |
-
"text_file_count":
|
| 203 |
"largest_file": {
|
| 204 |
"path": "results/episode_task_suite/modality_reconstruction/predictions.npz",
|
| 205 |
"bytes": 55702978
|
|
@@ -209,8 +212,8 @@
|
|
| 209 |
"hf_artifact_bundle": {
|
| 210 |
"root": "hf_publish/artifacts",
|
| 211 |
"exists": true,
|
| 212 |
-
"file_count":
|
| 213 |
-
"text_file_count":
|
| 214 |
"largest_file": {
|
| 215 |
"path": "results/episode_task_suite/modality_reconstruction/predictions.npz",
|
| 216 |
"bytes": 55702978
|
|
@@ -220,8 +223,8 @@
|
|
| 220 |
"hf_model_bundle": {
|
| 221 |
"root": "hf_publish/model",
|
| 222 |
"exists": true,
|
| 223 |
-
"file_count":
|
| 224 |
-
"text_file_count":
|
| 225 |
"largest_file": {
|
| 226 |
"path": "pytorch_model.bin",
|
| 227 |
"bytes": 93495480
|
|
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
+
"generated_at_utc": "2026-06-16T04:57:05+00:00",
|
| 4 |
"checks": [
|
| 5 |
{
|
| 6 |
"name": "required_publication_assets_present",
|
|
|
|
| 57 |
"PUBLIC_SURFACE_QA.md": true,
|
| 58 |
"RENDERED_SITE_CHECK.md": true,
|
| 59 |
"EVALUATION_PROTOCOL.md": true,
|
| 60 |
+
"TASK_SUITE_20.md": true,
|
| 61 |
"FIGURE_INDEX.md": true,
|
| 62 |
"SOURCE_ALIGNMENT_AUDIT.md": true,
|
| 63 |
"XPERIENCE10M_DATASET_CARD_ALIGNMENT.md": true,
|
|
|
|
| 97 |
"docs/data/task_surface_integrity.json": true,
|
| 98 |
"docs/data/website_integrity.json": true,
|
| 99 |
"docs/data/summary_metrics.json": true,
|
| 100 |
+
"docs/data/task_suite_20.json": true,
|
| 101 |
"docs/data/task_suite_enhancement_128.json": true,
|
| 102 |
"docs/assets/modalities/video.jpg": true,
|
| 103 |
"docs/assets/modalities/audio.png": true,
|
|
|
|
| 126 |
"scripts/build_artifact_index.py": true,
|
| 127 |
"scripts/build_brand_assets.py": true,
|
| 128 |
"scripts/build_evaluation_protocol.py": true,
|
| 129 |
+
"scripts/build_unified_task_suite.py": true,
|
| 130 |
"scripts/build_figure_index.py": true,
|
| 131 |
"scripts/build_quality_gates.py": true,
|
| 132 |
"scripts/build_public_surface_qa.py": true,
|
|
|
|
| 190 |
"github_repo": {
|
| 191 |
"root": "repo",
|
| 192 |
"exists": true,
|
| 193 |
+
"file_count": 972,
|
| 194 |
+
"text_file_count": 793,
|
| 195 |
"largest_file": {
|
| 196 |
"path": "results/episode_task_suite/modality_reconstruction/predictions.npz",
|
| 197 |
"bytes": 55702978
|
|
|
|
| 201 |
"hf_space_bundle": {
|
| 202 |
"root": "hf_publish/space",
|
| 203 |
"exists": true,
|
| 204 |
+
"file_count": 757,
|
| 205 |
+
"text_file_count": 617,
|
| 206 |
"largest_file": {
|
| 207 |
"path": "results/episode_task_suite/modality_reconstruction/predictions.npz",
|
| 208 |
"bytes": 55702978
|
|
|
|
| 212 |
"hf_artifact_bundle": {
|
| 213 |
"root": "hf_publish/artifacts",
|
| 214 |
"exists": true,
|
| 215 |
+
"file_count": 1829,
|
| 216 |
+
"text_file_count": 793,
|
| 217 |
"largest_file": {
|
| 218 |
"path": "results/episode_task_suite/modality_reconstruction/predictions.npz",
|
| 219 |
"bytes": 55702978
|
|
|
|
| 223 |
"hf_model_bundle": {
|
| 224 |
"root": "hf_publish/model",
|
| 225 |
"exists": true,
|
| 226 |
+
"file_count": 2246,
|
| 227 |
+
"text_file_count": 951,
|
| 228 |
"largest_file": {
|
| 229 |
"path": "pytorch_model.bin",
|
| 230 |
"bytes": 93495480
|
docs/assets/charts/tier2_task_suite.svg
CHANGED
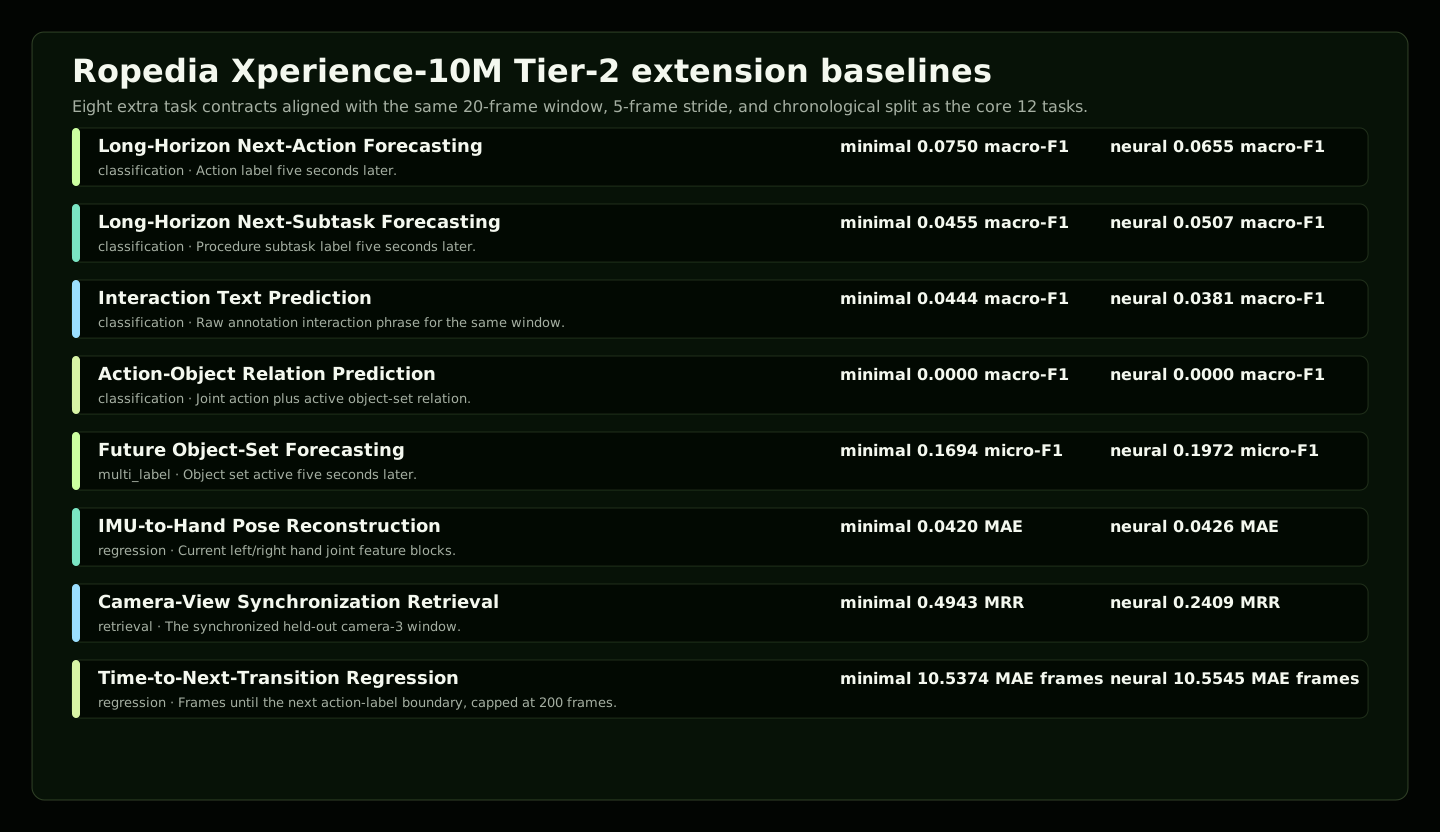
|
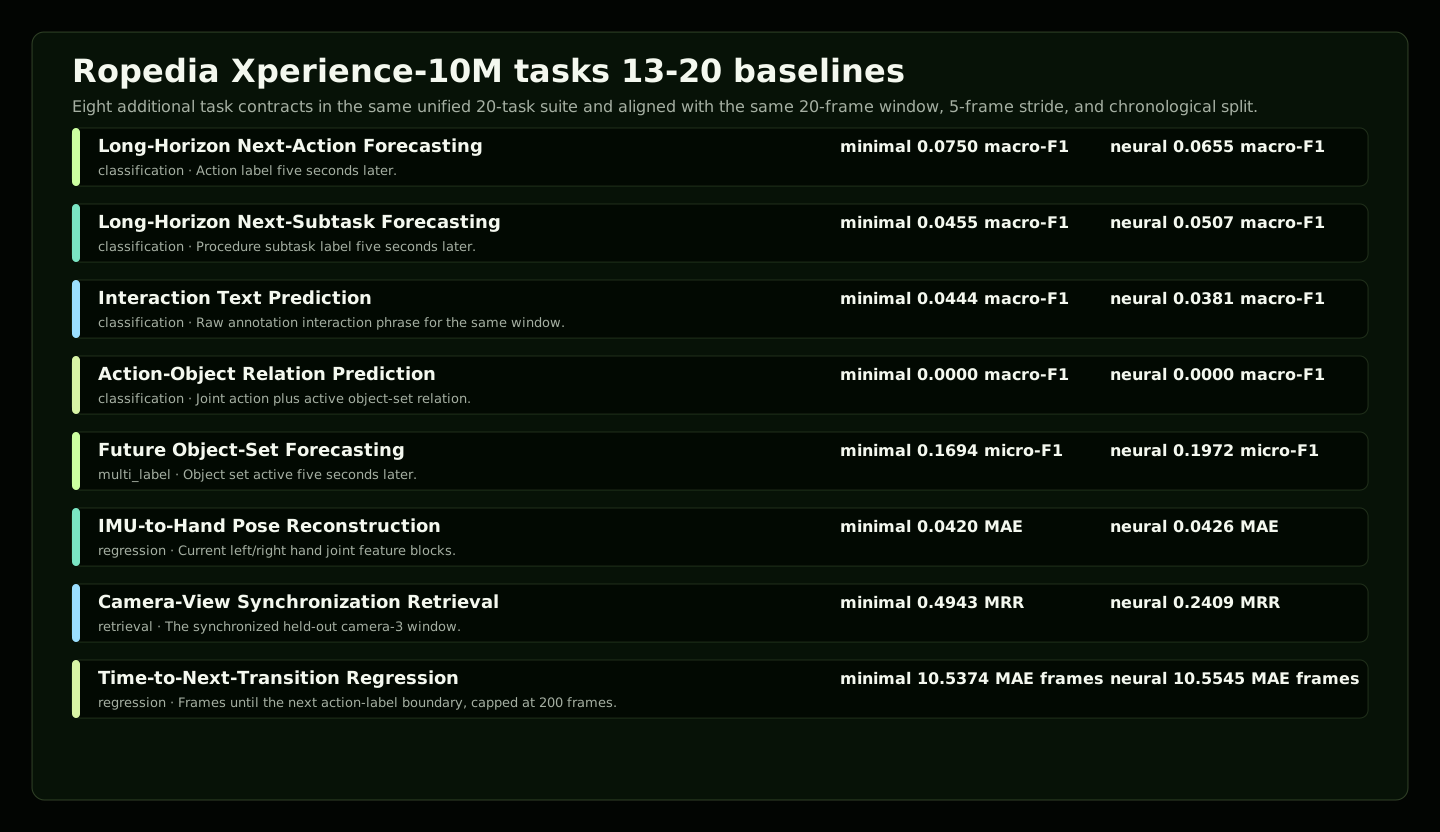
|
docs/assets/task_suite_infographic.png
CHANGED

|
Git LFS Details
|

|
Git LFS Details
|
docs/data/artifact_index.json
CHANGED
|
@@ -1,8 +1,8 @@
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Task Suite Artifact Index",
|
| 3 |
-
"generated_at_utc": "2026-06-
|
| 4 |
"status": "pass",
|
| 5 |
-
"artifact_count":
|
| 6 |
"missing": [],
|
| 7 |
"by_kind": {
|
| 8 |
"project_path": 14,
|
|
@@ -12,10 +12,10 @@
|
|
| 12 |
"reproducibility": 4,
|
| 13 |
"project_scope": 1,
|
| 14 |
"source_alignment": 5,
|
| 15 |
-
"evaluation_protocol":
|
|
|
|
| 16 |
"result_interpretation": 5,
|
| 17 |
"metrics_source": 27,
|
| 18 |
-
"website_data": 4,
|
| 19 |
"visual_evidence": 7,
|
| 20 |
"dataset_context": 1,
|
| 21 |
"quality_gate": 12,
|
|
@@ -44,8 +44,8 @@
|
|
| 44 |
"surface": "repo_hf",
|
| 45 |
"shows": "Gives first-pass readers a concise project shape before the detailed artifact trail.",
|
| 46 |
"exists": true,
|
| 47 |
-
"bytes":
|
| 48 |
-
"sha256": "
|
| 49 |
},
|
| 50 |
{
|
| 51 |
"id": "project_brief_json",
|
|
@@ -55,8 +55,8 @@
|
|
| 55 |
"surface": "website_hf",
|
| 56 |
"shows": "Machine-readable first-reader project brief for the website and Hugging Face mirrors.",
|
| 57 |
"exists": true,
|
| 58 |
-
"bytes":
|
| 59 |
-
"sha256": "
|
| 60 |
},
|
| 61 |
{
|
| 62 |
"id": "project_status",
|
|
@@ -66,8 +66,8 @@
|
|
| 66 |
"surface": "repo_hf",
|
| 67 |
"shows": "Gives a compact current-state table for first-pass readers.",
|
| 68 |
"exists": true,
|
| 69 |
-
"bytes":
|
| 70 |
-
"sha256": "
|
| 71 |
},
|
| 72 |
{
|
| 73 |
"id": "project_status_json",
|
|
@@ -77,8 +77,8 @@
|
|
| 77 |
"surface": "website_hf",
|
| 78 |
"shows": "Machine-readable copy of the current project status for website and HF mirrors.",
|
| 79 |
"exists": true,
|
| 80 |
-
"bytes":
|
| 81 |
-
"sha256": "
|
| 82 |
},
|
| 83 |
{
|
| 84 |
"id": "research_roadmap",
|
|
@@ -407,8 +407,8 @@
|
|
| 407 |
"surface": "website_hf",
|
| 408 |
"shows": "Gives a short project path with scope status and public surfaces.",
|
| 409 |
"exists": true,
|
| 410 |
-
"bytes":
|
| 411 |
-
"sha256": "
|
| 412 |
},
|
| 413 |
{
|
| 414 |
"id": "artifact_guide",
|
|
@@ -418,8 +418,8 @@
|
|
| 418 |
"surface": "repo_hf",
|
| 419 |
"shows": "Gives the human-readable map from project scope to data, tasks, platform mirrors, and scale-up status.",
|
| 420 |
"exists": true,
|
| 421 |
-
"bytes":
|
| 422 |
-
"sha256": "
|
| 423 |
},
|
| 424 |
{
|
| 425 |
"id": "official_dataset_card_alignment",
|
|
@@ -463,7 +463,7 @@
|
|
| 463 |
"shows": "Machine-readable source-alignment pass/fail check for repo, website, and HF surfaces.",
|
| 464 |
"exists": true,
|
| 465 |
"bytes": 4432,
|
| 466 |
-
"sha256": "
|
| 467 |
},
|
| 468 |
{
|
| 469 |
"id": "source_alignment_validator",
|
|
@@ -517,8 +517,8 @@
|
|
| 517 |
"surface": "repo_hf",
|
| 518 |
"shows": "Defines the window unit, chronological split, task metrics, leakage controls, and current limitations.",
|
| 519 |
"exists": true,
|
| 520 |
-
"bytes":
|
| 521 |
-
"sha256": "
|
| 522 |
},
|
| 523 |
{
|
| 524 |
"id": "evaluation_protocol_json",
|
|
@@ -528,8 +528,8 @@
|
|
| 528 |
"surface": "website_hf",
|
| 529 |
"shows": "Machine-readable protocol generated from committed task metrics for website and HF mirrors.",
|
| 530 |
"exists": true,
|
| 531 |
-
"bytes":
|
| 532 |
-
"sha256": "
|
| 533 |
},
|
| 534 |
{
|
| 535 |
"id": "evaluation_protocol_builder",
|
|
@@ -539,8 +539,41 @@
|
|
| 539 |
"surface": "repo_hf",
|
| 540 |
"shows": "Regenerates the protocol from committed summary metrics and task artifacts.",
|
| 541 |
"exists": true,
|
| 542 |
-
"bytes":
|
| 543 |
-
"sha256": "
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 544 |
},
|
| 545 |
{
|
| 546 |
"id": "research_takeaways",
|
|
@@ -581,7 +614,7 @@
|
|
| 581 |
"path": "scripts/audio_ablation_and_raw_upgrade.py",
|
| 582 |
"kind": "result_interpretation",
|
| 583 |
"surface": "repo_hf",
|
| 584 |
-
"shows": "Measures audio contribution variants across
|
| 585 |
"exists": true,
|
| 586 |
"bytes": 43144,
|
| 587 |
"sha256": "f7e3a38ec906dac7ca55b13c49720bd41ed89a1fd994c7d54730a4de5dfd1b59"
|
|
@@ -625,7 +658,7 @@
|
|
| 625 |
"path": "docs/assets/charts/audio_ablation_delta.svg",
|
| 626 |
"kind": "visual_evidence",
|
| 627 |
"surface": "website_hf",
|
| 628 |
-
"shows": "Bar chart of measured current-audio primary-metric deltas across the
|
| 629 |
"exists": true,
|
| 630 |
"bytes": 4146,
|
| 631 |
"sha256": "187dbabe01f9ff18841ff61a1e7fbf85bebdd188cc0f248bb5090d64528e7568"
|
|
@@ -638,8 +671,8 @@
|
|
| 638 |
"surface": "repo_hf",
|
| 639 |
"shows": "Catalogs public figures, charts, modality thumbnails, dimensions, hashes, roles, and source scripts.",
|
| 640 |
"exists": true,
|
| 641 |
-
"bytes":
|
| 642 |
-
"sha256": "
|
| 643 |
},
|
| 644 |
{
|
| 645 |
"id": "figure_index_json",
|
|
@@ -649,8 +682,8 @@
|
|
| 649 |
"surface": "website_hf",
|
| 650 |
"shows": "Machine-readable visual asset index for website and Hugging Face mirrors.",
|
| 651 |
"exists": true,
|
| 652 |
-
"bytes":
|
| 653 |
-
"sha256": "
|
| 654 |
},
|
| 655 |
{
|
| 656 |
"id": "figure_index_builder",
|
|
@@ -660,8 +693,8 @@
|
|
| 660 |
"surface": "repo_hf",
|
| 661 |
"shows": "Regenerates visual-asset hashes, dimensions, and source-script provenance.",
|
| 662 |
"exists": true,
|
| 663 |
-
"bytes":
|
| 664 |
-
"sha256": "
|
| 665 |
},
|
| 666 |
{
|
| 667 |
"id": "brand_assets_json",
|
|
@@ -726,8 +759,8 @@
|
|
| 726 |
"surface": "website_hf",
|
| 727 |
"shows": "Machine-readable release-check summary for validators, mirrors, and public project surfaces.",
|
| 728 |
"exists": true,
|
| 729 |
-
"bytes":
|
| 730 |
-
"sha256": "
|
| 731 |
},
|
| 732 |
{
|
| 733 |
"id": "public_surface_qa",
|
|
@@ -749,7 +782,7 @@
|
|
| 749 |
"volatile": true,
|
| 750 |
"shows": "Machine-readable report for SEO/social metadata, accessible tab semantics, public links, project links, and clear project presentation.",
|
| 751 |
"exists": true,
|
| 752 |
-
"bytes":
|
| 753 |
"hash_policy": "existence_and_size_only"
|
| 754 |
},
|
| 755 |
{
|
|
@@ -760,8 +793,8 @@
|
|
| 760 |
"surface": "repo_hf",
|
| 761 |
"shows": "Regenerates the public presentation report before release.",
|
| 762 |
"exists": true,
|
| 763 |
-
"bytes":
|
| 764 |
-
"sha256": "
|
| 765 |
},
|
| 766 |
{
|
| 767 |
"id": "task_surface_integrity",
|
|
@@ -770,7 +803,7 @@
|
|
| 770 |
"kind": "quality_gate",
|
| 771 |
"surface": "website_hf",
|
| 772 |
"volatile": true,
|
| 773 |
-
"shows": "Confirms the public
|
| 774 |
"exists": true,
|
| 775 |
"bytes": 45779,
|
| 776 |
"hash_policy": "existence_and_size_only"
|
|
@@ -830,7 +863,7 @@
|
|
| 830 |
"volatile": true,
|
| 831 |
"shows": "Records the last live GitHub/HF URL verification after upload.",
|
| 832 |
"exists": true,
|
| 833 |
-
"bytes":
|
| 834 |
"hash_policy": "existence_and_size_only"
|
| 835 |
},
|
| 836 |
{
|
|
@@ -841,8 +874,8 @@
|
|
| 841 |
"surface": "repo",
|
| 842 |
"shows": "Fetches the published GitHub/HF URLs and compares live hashes and public-card markers against the release assets.",
|
| 843 |
"exists": true,
|
| 844 |
-
"bytes":
|
| 845 |
-
"sha256": "
|
| 846 |
},
|
| 847 |
{
|
| 848 |
"id": "reproducibility_contract",
|
|
@@ -852,8 +885,8 @@
|
|
| 852 |
"surface": "repo_hf",
|
| 853 |
"shows": "Defines public reproduction commands, expected outputs, and non-reproducible scale-up boundaries.",
|
| 854 |
"exists": true,
|
| 855 |
-
"bytes":
|
| 856 |
-
"sha256": "
|
| 857 |
},
|
| 858 |
{
|
| 859 |
"id": "reproducibility_matrix",
|
|
@@ -863,8 +896,8 @@
|
|
| 863 |
"surface": "website_hf",
|
| 864 |
"shows": "Machine-readable reproduction steps with expected artifacts and public boundaries.",
|
| 865 |
"exists": true,
|
| 866 |
-
"bytes":
|
| 867 |
-
"sha256": "
|
| 868 |
},
|
| 869 |
{
|
| 870 |
"id": "artifact_index_builder",
|
|
@@ -874,8 +907,8 @@
|
|
| 874 |
"surface": "repo_hf",
|
| 875 |
"shows": "Generates the selective artifact catalog from local files.",
|
| 876 |
"exists": true,
|
| 877 |
-
"bytes":
|
| 878 |
-
"sha256": "
|
| 879 |
},
|
| 880 |
{
|
| 881 |
"id": "publication_audit",
|
|
@@ -886,7 +919,7 @@
|
|
| 886 |
"volatile": true,
|
| 887 |
"shows": "Confirms public bundles exclude raw data, caches, heavy archives, and credential text.",
|
| 888 |
"exists": true,
|
| 889 |
-
"bytes":
|
| 890 |
"hash_policy": "existence_and_size_only"
|
| 891 |
},
|
| 892 |
{
|
|
@@ -910,7 +943,7 @@
|
|
| 910 |
"volatile": true,
|
| 911 |
"shows": "Confirms prepared GitHub/HF Space/artifact/model mirrors share the same critical data, figure, website HTML, and validator files.",
|
| 912 |
"exists": true,
|
| 913 |
-
"bytes":
|
| 914 |
"hash_policy": "existence_and_size_only"
|
| 915 |
},
|
| 916 |
{
|
|
@@ -922,7 +955,7 @@
|
|
| 922 |
"volatile": true,
|
| 923 |
"shows": "Confirms local website links, anchors, JSON data files, and referenced images resolve.",
|
| 924 |
"exists": true,
|
| 925 |
-
"bytes":
|
| 926 |
"hash_policy": "existence_and_size_only"
|
| 927 |
},
|
| 928 |
{
|
|
@@ -933,12 +966,12 @@
|
|
| 933 |
"surface": "website_hf",
|
| 934 |
"shows": "Lists public URLs, upstream sources, and machine-readable project metadata.",
|
| 935 |
"exists": true,
|
| 936 |
-
"bytes":
|
| 937 |
-
"sha256": "
|
| 938 |
},
|
| 939 |
{
|
| 940 |
"id": "task_summary",
|
| 941 |
-
"title": "
|
| 942 |
"path": "results/episode_task_suite/summary_report.json",
|
| 943 |
"kind": "metrics_source",
|
| 944 |
"surface": "repo_hf",
|
|
@@ -997,7 +1030,7 @@
|
|
| 997 |
"path": "results/episode_task_suite/neural_mlp",
|
| 998 |
"kind": "result_directory",
|
| 999 |
"surface": "repo_hf_model",
|
| 1000 |
-
"shows": "Stores matching PyTorch MLP results for the
|
| 1001 |
"exists": true,
|
| 1002 |
"file_count": 60,
|
| 1003 |
"bytes": 90609517
|
|
@@ -1008,7 +1041,7 @@
|
|
| 1008 |
"path": "results/episode_task_suite/research_directions/research_direction_taxonomy.json",
|
| 1009 |
"kind": "taxonomy",
|
| 1010 |
"surface": "repo_hf",
|
| 1011 |
-
"shows": "Maps the
|
| 1012 |
"exists": true,
|
| 1013 |
"bytes": 19204,
|
| 1014 |
"sha256": "59bece1a151d8475fde50396fd2e70ed4abcfec33f10e400ef165148fd6e7dde"
|
|
@@ -1026,47 +1059,47 @@
|
|
| 1026 |
},
|
| 1027 |
{
|
| 1028 |
"id": "tier2_task_suite",
|
| 1029 |
-
"title": "
|
| 1030 |
"path": "results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 1031 |
"kind": "metrics_source",
|
| 1032 |
"surface": "repo_hf",
|
| 1033 |
-
"shows": "Stores
|
| 1034 |
"exists": true,
|
| 1035 |
-
"bytes":
|
| 1036 |
-
"sha256": "
|
| 1037 |
},
|
| 1038 |
{
|
| 1039 |
"id": "tier2_task_suite_json",
|
| 1040 |
-
"title": "
|
| 1041 |
"path": "docs/data/tier2_task_suite.json",
|
| 1042 |
"kind": "website_data",
|
| 1043 |
"surface": "website_hf",
|
| 1044 |
-
"shows": "Machine-readable
|
| 1045 |
"exists": true,
|
| 1046 |
-
"bytes":
|
| 1047 |
-
"sha256": "
|
| 1048 |
},
|
| 1049 |
{
|
| 1050 |
"id": "tier2_task_suite_chart",
|
| 1051 |
-
"title": "
|
| 1052 |
"path": "docs/assets/charts/tier2_task_suite.svg",
|
| 1053 |
"kind": "generated_figure",
|
| 1054 |
"surface": "website_hf",
|
| 1055 |
-
"shows": "Visual summary of the eight
|
| 1056 |
"exists": true,
|
| 1057 |
-
"bytes":
|
| 1058 |
-
"sha256": "
|
| 1059 |
},
|
| 1060 |
{
|
| 1061 |
"id": "tier2_task_suite_builder",
|
| 1062 |
-
"title": "
|
| 1063 |
"path": "scripts/tier2_task_suite.py",
|
| 1064 |
"kind": "evaluation_protocol",
|
| 1065 |
"surface": "repo_hf",
|
| 1066 |
-
"shows": "Regenerates
|
| 1067 |
"exists": true,
|
| 1068 |
-
"bytes":
|
| 1069 |
-
"sha256": "
|
| 1070 |
},
|
| 1071 |
{
|
| 1072 |
"id": "task_walkthroughs",
|
|
@@ -1081,14 +1114,14 @@
|
|
| 1081 |
},
|
| 1082 |
{
|
| 1083 |
"id": "task_suite_infographic",
|
| 1084 |
-
"title": "
|
| 1085 |
"path": "docs/assets/task_suite_infographic.png",
|
| 1086 |
"kind": "generated_figure",
|
| 1087 |
"surface": "website_hf",
|
| 1088 |
"shows": "Presents the task suite and sample modality thumbnails with metrics generated from committed files.",
|
| 1089 |
"exists": true,
|
| 1090 |
-
"bytes":
|
| 1091 |
-
"sha256": "
|
| 1092 |
},
|
| 1093 |
{
|
| 1094 |
"id": "modality_atlas",
|
|
@@ -1195,7 +1228,7 @@
|
|
| 1195 |
"path": "results/omni_finetune/multi_episode_128_task_baselines/BASELINE_ALIGNMENT_REPORT.md",
|
| 1196 |
"kind": "scaleup_status",
|
| 1197 |
"surface": "repo_hf",
|
| 1198 |
-
"shows": "Summarizes same-split simple and neural metadata baselines for the 12 task ids, with unsupported markers for tasks that need missing raw 128 feature blocks.",
|
| 1199 |
"exists": true,
|
| 1200 |
"bytes": 2238,
|
| 1201 |
"sha256": "c70440aa502ec569a840159ab7e05b8e7d4ed70e0091ad9a4b2fb3fb0d3803c1"
|
|
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Task Suite Artifact Index",
|
| 3 |
+
"generated_at_utc": "2026-06-16T04:56:20+00:00",
|
| 4 |
"status": "pass",
|
| 5 |
+
"artifact_count": 172,
|
| 6 |
"missing": [],
|
| 7 |
"by_kind": {
|
| 8 |
"project_path": 14,
|
|
|
|
| 12 |
"reproducibility": 4,
|
| 13 |
"project_scope": 1,
|
| 14 |
"source_alignment": 5,
|
| 15 |
+
"evaluation_protocol": 6,
|
| 16 |
+
"website_data": 5,
|
| 17 |
"result_interpretation": 5,
|
| 18 |
"metrics_source": 27,
|
|
|
|
| 19 |
"visual_evidence": 7,
|
| 20 |
"dataset_context": 1,
|
| 21 |
"quality_gate": 12,
|
|
|
|
| 44 |
"surface": "repo_hf",
|
| 45 |
"shows": "Gives first-pass readers a concise project shape before the detailed artifact trail.",
|
| 46 |
"exists": true,
|
| 47 |
+
"bytes": 4047,
|
| 48 |
+
"sha256": "b92d363caa8cc149a22647c6b8c340e86e850847fb1e1173a0245139850c87c7"
|
| 49 |
},
|
| 50 |
{
|
| 51 |
"id": "project_brief_json",
|
|
|
|
| 55 |
"surface": "website_hf",
|
| 56 |
"shows": "Machine-readable first-reader project brief for the website and Hugging Face mirrors.",
|
| 57 |
"exists": true,
|
| 58 |
+
"bytes": 4019,
|
| 59 |
+
"sha256": "9521556a750941a0f9ee8e9541903acbb0fbec2501fd05ed4e7a017fc18cf794"
|
| 60 |
},
|
| 61 |
{
|
| 62 |
"id": "project_status",
|
|
|
|
| 66 |
"surface": "repo_hf",
|
| 67 |
"shows": "Gives a compact current-state table for first-pass readers.",
|
| 68 |
"exists": true,
|
| 69 |
+
"bytes": 14218,
|
| 70 |
+
"sha256": "079868a224fd516aa4d90a545f21f6281f3b270ea98bd23d4a1fbdb08b722a20"
|
| 71 |
},
|
| 72 |
{
|
| 73 |
"id": "project_status_json",
|
|
|
|
| 77 |
"surface": "website_hf",
|
| 78 |
"shows": "Machine-readable copy of the current project status for website and HF mirrors.",
|
| 79 |
"exists": true,
|
| 80 |
+
"bytes": 22080,
|
| 81 |
+
"sha256": "bd57e2701085294a8ff32640c3b6012753826ef90e0bd500d111501aa88e08f4"
|
| 82 |
},
|
| 83 |
{
|
| 84 |
"id": "research_roadmap",
|
|
|
|
| 407 |
"surface": "website_hf",
|
| 408 |
"shows": "Gives a short project path with scope status and public surfaces.",
|
| 409 |
"exists": true,
|
| 410 |
+
"bytes": 10009,
|
| 411 |
+
"sha256": "e0f8bd65cd15b0fe68c8079045b4c72552daaf644c35b8a7a68426250a4aa441"
|
| 412 |
},
|
| 413 |
{
|
| 414 |
"id": "artifact_guide",
|
|
|
|
| 418 |
"surface": "repo_hf",
|
| 419 |
"shows": "Gives the human-readable map from project scope to data, tasks, platform mirrors, and scale-up status.",
|
| 420 |
"exists": true,
|
| 421 |
+
"bytes": 20096,
|
| 422 |
+
"sha256": "f4450170d655366ad7c1073a8468d61152ea27eea46f89b9e16e141e04bdfcf7"
|
| 423 |
},
|
| 424 |
{
|
| 425 |
"id": "official_dataset_card_alignment",
|
|
|
|
| 463 |
"shows": "Machine-readable source-alignment pass/fail check for repo, website, and HF surfaces.",
|
| 464 |
"exists": true,
|
| 465 |
"bytes": 4432,
|
| 466 |
+
"sha256": "c5401a313bcc68152e590cf06fa7c5219d42617566dff9cf82cc80905a4c288e"
|
| 467 |
},
|
| 468 |
{
|
| 469 |
"id": "source_alignment_validator",
|
|
|
|
| 517 |
"surface": "repo_hf",
|
| 518 |
"shows": "Defines the window unit, chronological split, task metrics, leakage controls, and current limitations.",
|
| 519 |
"exists": true,
|
| 520 |
+
"bytes": 9195,
|
| 521 |
+
"sha256": "ca60203b000726bb8e8cb3a2dc37e7e0821f7e7013a3437a1612f670269cc1df"
|
| 522 |
},
|
| 523 |
{
|
| 524 |
"id": "evaluation_protocol_json",
|
|
|
|
| 528 |
"surface": "website_hf",
|
| 529 |
"shows": "Machine-readable protocol generated from committed task metrics for website and HF mirrors.",
|
| 530 |
"exists": true,
|
| 531 |
+
"bytes": 24020,
|
| 532 |
+
"sha256": "df8da790182374a64b7e5aed94f9cc945fdecef11faf37b707220bc91c1ac9a7"
|
| 533 |
},
|
| 534 |
{
|
| 535 |
"id": "evaluation_protocol_builder",
|
|
|
|
| 539 |
"surface": "repo_hf",
|
| 540 |
"shows": "Regenerates the protocol from committed summary metrics and task artifacts.",
|
| 541 |
"exists": true,
|
| 542 |
+
"bytes": 19994,
|
| 543 |
+
"sha256": "153d1e82fa34f3e22fd1a37f3bf012f8a0eae98002278435991d973b2053d31e"
|
| 544 |
+
},
|
| 545 |
+
{
|
| 546 |
+
"id": "task_suite_20",
|
| 547 |
+
"title": "Unified 20-task suite",
|
| 548 |
+
"path": "TASK_SUITE_20.md",
|
| 549 |
+
"kind": "evaluation_protocol",
|
| 550 |
+
"surface": "repo_hf",
|
| 551 |
+
"shows": "Reader-facing table for the single unified public-sample task suite: tasks 1-12 plus tasks 13-20 under the same window, split, feature, and baseline contract.",
|
| 552 |
+
"exists": true,
|
| 553 |
+
"bytes": 5243,
|
| 554 |
+
"sha256": "57c5c742a43d37c2d17a2ee365374273f5d25f973b46b945972a3cfffd42aef7"
|
| 555 |
+
},
|
| 556 |
+
{
|
| 557 |
+
"id": "task_suite_20_json",
|
| 558 |
+
"title": "Unified 20-task suite JSON",
|
| 559 |
+
"path": "docs/data/task_suite_20.json",
|
| 560 |
+
"kind": "website_data",
|
| 561 |
+
"surface": "website_hf",
|
| 562 |
+
"shows": "Machine-readable unified 20-task index for the website, Hugging Face mirrors, and live verification.",
|
| 563 |
+
"exists": true,
|
| 564 |
+
"bytes": 34648,
|
| 565 |
+
"sha256": "3849e69949d65d1cf6c08bc77fc398c7c33b62b6cf2d0212cb8695fb976c3731"
|
| 566 |
+
},
|
| 567 |
+
{
|
| 568 |
+
"id": "task_suite_20_builder",
|
| 569 |
+
"title": "Unified 20-task suite builder",
|
| 570 |
+
"path": "scripts/build_unified_task_suite.py",
|
| 571 |
+
"kind": "evaluation_protocol",
|
| 572 |
+
"surface": "repo_hf",
|
| 573 |
+
"shows": "Regenerates the unified 20-task JSON and Markdown from the original 12-task metrics plus the tasks 13-20 result bundle.",
|
| 574 |
+
"exists": true,
|
| 575 |
+
"bytes": 12322,
|
| 576 |
+
"sha256": "ad2ae2f918fb8362e47d271ae8f1c1f3807b009a7241fa7df94f84fbddccffe8"
|
| 577 |
},
|
| 578 |
{
|
| 579 |
"id": "research_takeaways",
|
|
|
|
| 614 |
"path": "scripts/audio_ablation_and_raw_upgrade.py",
|
| 615 |
"kind": "result_interpretation",
|
| 616 |
"surface": "repo_hf",
|
| 617 |
+
"shows": "Measures audio contribution variants across the original task contracts.",
|
| 618 |
"exists": true,
|
| 619 |
"bytes": 43144,
|
| 620 |
"sha256": "f7e3a38ec906dac7ca55b13c49720bd41ed89a1fd994c7d54730a4de5dfd1b59"
|
|
|
|
| 658 |
"path": "docs/assets/charts/audio_ablation_delta.svg",
|
| 659 |
"kind": "visual_evidence",
|
| 660 |
"surface": "website_hf",
|
| 661 |
+
"shows": "Bar chart of measured current-audio primary-metric deltas across the original tasks.",
|
| 662 |
"exists": true,
|
| 663 |
"bytes": 4146,
|
| 664 |
"sha256": "187dbabe01f9ff18841ff61a1e7fbf85bebdd188cc0f248bb5090d64528e7568"
|
|
|
|
| 671 |
"surface": "repo_hf",
|
| 672 |
"shows": "Catalogs public figures, charts, modality thumbnails, dimensions, hashes, roles, and source scripts.",
|
| 673 |
"exists": true,
|
| 674 |
+
"bytes": 5301,
|
| 675 |
+
"sha256": "5cf29b921e910de49fba8692603ef22d559d243fc1c6b84503c0a9336d3eeeea"
|
| 676 |
},
|
| 677 |
{
|
| 678 |
"id": "figure_index_json",
|
|
|
|
| 682 |
"surface": "website_hf",
|
| 683 |
"shows": "Machine-readable visual asset index for website and Hugging Face mirrors.",
|
| 684 |
"exists": true,
|
| 685 |
+
"bytes": 14939,
|
| 686 |
+
"sha256": "fdf8d2d06d580908cc7fe70974cbd28c7490180cb314f5d532ba55985edcea6d"
|
| 687 |
},
|
| 688 |
{
|
| 689 |
"id": "figure_index_builder",
|
|
|
|
| 693 |
"surface": "repo_hf",
|
| 694 |
"shows": "Regenerates visual-asset hashes, dimensions, and source-script provenance.",
|
| 695 |
"exists": true,
|
| 696 |
+
"bytes": 13934,
|
| 697 |
+
"sha256": "a10e699097c86b645ecb03e42ac4fc2409e10170431a5bccbc38abad403ef209"
|
| 698 |
},
|
| 699 |
{
|
| 700 |
"id": "brand_assets_json",
|
|
|
|
| 759 |
"surface": "website_hf",
|
| 760 |
"shows": "Machine-readable release-check summary for validators, mirrors, and public project surfaces.",
|
| 761 |
"exists": true,
|
| 762 |
+
"bytes": 8100,
|
| 763 |
+
"sha256": "f7d8517ba185cc99e0cde2db8412d7651bf906bdfc6ad2f881c34764b3f802fa"
|
| 764 |
},
|
| 765 |
{
|
| 766 |
"id": "public_surface_qa",
|
|
|
|
| 782 |
"volatile": true,
|
| 783 |
"shows": "Machine-readable report for SEO/social metadata, accessible tab semantics, public links, project links, and clear project presentation.",
|
| 784 |
"exists": true,
|
| 785 |
+
"bytes": 5698,
|
| 786 |
"hash_policy": "existence_and_size_only"
|
| 787 |
},
|
| 788 |
{
|
|
|
|
| 793 |
"surface": "repo_hf",
|
| 794 |
"shows": "Regenerates the public presentation report before release.",
|
| 795 |
"exists": true,
|
| 796 |
+
"bytes": 12235,
|
| 797 |
+
"sha256": "fc5742789d882ceca8b7ce8a21ed401c2731fa22036c406847167199a724f09d"
|
| 798 |
},
|
| 799 |
{
|
| 800 |
"id": "task_surface_integrity",
|
|
|
|
| 803 |
"kind": "quality_gate",
|
| 804 |
"surface": "website_hf",
|
| 805 |
"volatile": true,
|
| 806 |
+
"shows": "Confirms the public original-task cards use human-readable research names, representative modality thumbnails, and the interactive walkthrough/player JSON contract.",
|
| 807 |
"exists": true,
|
| 808 |
"bytes": 45779,
|
| 809 |
"hash_policy": "existence_and_size_only"
|
|
|
|
| 863 |
"volatile": true,
|
| 864 |
"shows": "Records the last live GitHub/HF URL verification after upload.",
|
| 865 |
"exists": true,
|
| 866 |
+
"bytes": 123218,
|
| 867 |
"hash_policy": "existence_and_size_only"
|
| 868 |
},
|
| 869 |
{
|
|
|
|
| 874 |
"surface": "repo",
|
| 875 |
"shows": "Fetches the published GitHub/HF URLs and compares live hashes and public-card markers against the release assets.",
|
| 876 |
"exists": true,
|
| 877 |
+
"bytes": 49719,
|
| 878 |
+
"sha256": "db6769f5ed43301f123950e0e2d3d1e8564115dbc6b43ea7a9080da4c9d4c3aa"
|
| 879 |
},
|
| 880 |
{
|
| 881 |
"id": "reproducibility_contract",
|
|
|
|
| 885 |
"surface": "repo_hf",
|
| 886 |
"shows": "Defines public reproduction commands, expected outputs, and non-reproducible scale-up boundaries.",
|
| 887 |
"exists": true,
|
| 888 |
+
"bytes": 9878,
|
| 889 |
+
"sha256": "3d0525785f9a1eaad399aeed249fc899d0b141efd778d0d2f3f229dd9b6594a3"
|
| 890 |
},
|
| 891 |
{
|
| 892 |
"id": "reproducibility_matrix",
|
|
|
|
| 896 |
"surface": "website_hf",
|
| 897 |
"shows": "Machine-readable reproduction steps with expected artifacts and public boundaries.",
|
| 898 |
"exists": true,
|
| 899 |
+
"bytes": 6673,
|
| 900 |
+
"sha256": "585c4e7c67b0bfca80628267b71c7fd5f0ac0c534bdc964c6509d8c53a0e0e83"
|
| 901 |
},
|
| 902 |
{
|
| 903 |
"id": "artifact_index_builder",
|
|
|
|
| 907 |
"surface": "repo_hf",
|
| 908 |
"shows": "Generates the selective artifact catalog from local files.",
|
| 909 |
"exists": true,
|
| 910 |
+
"bytes": 46648,
|
| 911 |
+
"sha256": "86feb8e47b9766762cd683c94bac88a195e36c877e0a470604ff708da738fd00"
|
| 912 |
},
|
| 913 |
{
|
| 914 |
"id": "publication_audit",
|
|
|
|
| 919 |
"volatile": true,
|
| 920 |
"shows": "Confirms public bundles exclude raw data, caches, heavy archives, and credential text.",
|
| 921 |
"exists": true,
|
| 922 |
+
"bytes": 7712,
|
| 923 |
"hash_policy": "existence_and_size_only"
|
| 924 |
},
|
| 925 |
{
|
|
|
|
| 943 |
"volatile": true,
|
| 944 |
"shows": "Confirms prepared GitHub/HF Space/artifact/model mirrors share the same critical data, figure, website HTML, and validator files.",
|
| 945 |
"exists": true,
|
| 946 |
+
"bytes": 631418,
|
| 947 |
"hash_policy": "existence_and_size_only"
|
| 948 |
},
|
| 949 |
{
|
|
|
|
| 955 |
"volatile": true,
|
| 956 |
"shows": "Confirms local website links, anchors, JSON data files, and referenced images resolve.",
|
| 957 |
"exists": true,
|
| 958 |
+
"bytes": 17815,
|
| 959 |
"hash_policy": "existence_and_size_only"
|
| 960 |
},
|
| 961 |
{
|
|
|
|
| 966 |
"surface": "website_hf",
|
| 967 |
"shows": "Lists public URLs, upstream sources, and machine-readable project metadata.",
|
| 968 |
"exists": true,
|
| 969 |
+
"bytes": 5672,
|
| 970 |
+
"sha256": "53584e1428f275dceee875aec6a2c0d36517e6dd2d368caee409504217f9aa75"
|
| 971 |
},
|
| 972 |
{
|
| 973 |
"id": "task_summary",
|
| 974 |
+
"title": "Original task summary report",
|
| 975 |
"path": "results/episode_task_suite/summary_report.json",
|
| 976 |
"kind": "metrics_source",
|
| 977 |
"surface": "repo_hf",
|
|
|
|
| 1030 |
"path": "results/episode_task_suite/neural_mlp",
|
| 1031 |
"kind": "result_directory",
|
| 1032 |
"surface": "repo_hf_model",
|
| 1033 |
+
"shows": "Stores matching PyTorch MLP results for the original task contracts.",
|
| 1034 |
"exists": true,
|
| 1035 |
"file_count": 60,
|
| 1036 |
"bytes": 90609517
|
|
|
|
| 1041 |
"path": "results/episode_task_suite/research_directions/research_direction_taxonomy.json",
|
| 1042 |
"kind": "taxonomy",
|
| 1043 |
"surface": "repo_hf",
|
| 1044 |
+
"shows": "Maps the original tasks to the four Ropedia research directions as direct/proxy/diagnostic.",
|
| 1045 |
"exists": true,
|
| 1046 |
"bytes": 19204,
|
| 1047 |
"sha256": "59bece1a151d8475fde50396fd2e70ed4abcfec33f10e400ef165148fd6e7dde"
|
|
|
|
| 1059 |
},
|
| 1060 |
{
|
| 1061 |
"id": "tier2_task_suite",
|
| 1062 |
+
"title": "Tasks 13-20 result bundle",
|
| 1063 |
"path": "results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 1064 |
"kind": "metrics_source",
|
| 1065 |
"surface": "repo_hf",
|
| 1066 |
+
"shows": "Stores the historical result bundle for unified tasks 13-20 with minimal and neural baselines aligned to the same 20-task window/split setup.",
|
| 1067 |
"exists": true,
|
| 1068 |
+
"bytes": 33402,
|
| 1069 |
+
"sha256": "d4c47e7ae318d7e287b22f8b3293ff19ea573cf3513cb042b8cc2b7cee4bc355"
|
| 1070 |
},
|
| 1071 |
{
|
| 1072 |
"id": "tier2_task_suite_json",
|
| 1073 |
+
"title": "Tasks 13-20 result JSON",
|
| 1074 |
"path": "docs/data/tier2_task_suite.json",
|
| 1075 |
"kind": "website_data",
|
| 1076 |
"surface": "website_hf",
|
| 1077 |
+
"shows": "Machine-readable tasks 13-20 definitions, setup alignment, metrics, and public source paths; the file name is historical.",
|
| 1078 |
"exists": true,
|
| 1079 |
+
"bytes": 33402,
|
| 1080 |
+
"sha256": "d4c47e7ae318d7e287b22f8b3293ff19ea573cf3513cb042b8cc2b7cee4bc355"
|
| 1081 |
},
|
| 1082 |
{
|
| 1083 |
"id": "tier2_task_suite_chart",
|
| 1084 |
+
"title": "Tasks 13-20 chart",
|
| 1085 |
"path": "docs/assets/charts/tier2_task_suite.svg",
|
| 1086 |
"kind": "generated_figure",
|
| 1087 |
"surface": "website_hf",
|
| 1088 |
+
"shows": "Visual summary of the eight additional task baseline metrics in the unified 20-task suite.",
|
| 1089 |
"exists": true,
|
| 1090 |
+
"bytes": 5437,
|
| 1091 |
+
"sha256": "3e35e476f559cd6188e5417e4d28c25efc130abafc9cab2d941bc77d559177a1"
|
| 1092 |
},
|
| 1093 |
{
|
| 1094 |
"id": "tier2_task_suite_builder",
|
| 1095 |
+
"title": "Tasks 13-20 builder",
|
| 1096 |
"path": "scripts/tier2_task_suite.py",
|
| 1097 |
"kind": "evaluation_protocol",
|
| 1098 |
"surface": "repo_hf",
|
| 1099 |
+
"shows": "Regenerates tasks 13-20 from shared windows plus the local public-sample annotation HDF5; the script name is historical.",
|
| 1100 |
"exists": true,
|
| 1101 |
+
"bytes": 47071,
|
| 1102 |
+
"sha256": "3143c711af1edc20efd390a6470941c9e087677c6259486d0bdf1b0e06a543e5"
|
| 1103 |
},
|
| 1104 |
{
|
| 1105 |
"id": "task_walkthroughs",
|
|
|
|
| 1114 |
},
|
| 1115 |
{
|
| 1116 |
"id": "task_suite_infographic",
|
| 1117 |
+
"title": "Original task-suite infographic",
|
| 1118 |
"path": "docs/assets/task_suite_infographic.png",
|
| 1119 |
"kind": "generated_figure",
|
| 1120 |
"surface": "website_hf",
|
| 1121 |
"shows": "Presents the task suite and sample modality thumbnails with metrics generated from committed files.",
|
| 1122 |
"exists": true,
|
| 1123 |
+
"bytes": 2627286,
|
| 1124 |
+
"sha256": "664c44bec150c4e857cae95d798e379f8a051067863bab1e51ec06d113a34fe4"
|
| 1125 |
},
|
| 1126 |
{
|
| 1127 |
"id": "modality_atlas",
|
|
|
|
| 1228 |
"path": "results/omni_finetune/multi_episode_128_task_baselines/BASELINE_ALIGNMENT_REPORT.md",
|
| 1229 |
"kind": "scaleup_status",
|
| 1230 |
"surface": "repo_hf",
|
| 1231 |
+
"shows": "Summarizes same-split simple and neural metadata baselines for the 12 original task ids, with unsupported markers for tasks that need missing raw 128 feature blocks.",
|
| 1232 |
"exists": true,
|
| 1233 |
"bytes": 2238,
|
| 1234 |
"sha256": "c70440aa502ec569a840159ab7e05b8e7d4ed70e0091ad9a4b2fb3fb0d3803c1"
|
docs/data/evaluation_protocol.json
CHANGED
|
@@ -2,12 +2,13 @@
|
|
| 2 |
"title": "Ropedia Xperience-10M Task Suite Evaluation Protocol",
|
| 3 |
"status": "pass",
|
| 4 |
"version": "2026-06-01",
|
| 5 |
-
"generated_at_utc": "2026-06-
|
| 6 |
"source_files": [
|
| 7 |
"docs/data/summary_metrics.json",
|
| 8 |
"results/episode_task_suite/summary_report.json",
|
| 9 |
"results/episode_task_suite/windows.csv",
|
| 10 |
"results/episode_task_suite/feature_manifest.json",
|
|
|
|
| 11 |
"docs/data/tier2_task_suite.json",
|
| 12 |
"results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json"
|
| 13 |
],
|
|
@@ -22,18 +23,14 @@
|
|
| 22 |
"audio_featurized": true,
|
| 23 |
"raw_data_redistributed": false
|
| 24 |
},
|
| 25 |
-
"
|
| 26 |
-
"
|
| 27 |
-
|
| 28 |
-
|
| 29 |
-
|
| 30 |
-
|
| 31 |
-
"
|
| 32 |
-
|
| 33 |
-
"task_count": 8,
|
| 34 |
-
"results": "docs/data/tier2_task_suite.json",
|
| 35 |
-
"combined_task_count": 20
|
| 36 |
-
}
|
| 37 |
},
|
| 38 |
"split_policy": {
|
| 39 |
"name": "single_episode_chronological",
|
|
@@ -85,6 +82,7 @@
|
|
| 85 |
{
|
| 86 |
"task": "timeline_action",
|
| 87 |
"task_display_name": "Action Recognition",
|
|
|
|
| 88 |
"family": "supervised classification",
|
| 89 |
"unit": "single window",
|
| 90 |
"input": "current 20-frame all-feature window",
|
|
@@ -100,11 +98,14 @@
|
|
| 100 |
"minimal_primary_metric": 0.05,
|
| 101 |
"neural_primary_metric": 0.014814814814814814,
|
| 102 |
"minimal_metric_source": "results/episode_task_suite/timeline_action/metrics.json",
|
| 103 |
-
"neural_metric_source": "results/episode_task_suite/neural_mlp/timeline_action/metrics.json"
|
|
|
|
|
|
|
| 104 |
},
|
| 105 |
{
|
| 106 |
"task": "timeline_subtask",
|
| 107 |
"task_display_name": "Procedure Step Recognition",
|
|
|
|
| 108 |
"family": "supervised classification",
|
| 109 |
"unit": "single window",
|
| 110 |
"input": "current 20-frame all-feature window",
|
|
@@ -120,11 +121,14 @@
|
|
| 120 |
"minimal_primary_metric": 0.05056355513846935,
|
| 121 |
"neural_primary_metric": 0.02810810810810811,
|
| 122 |
"minimal_metric_source": "results/episode_task_suite/timeline_subtask/metrics.json",
|
| 123 |
-
"neural_metric_source": "results/episode_task_suite/neural_mlp/timeline_subtask/metrics.json"
|
|
|
|
|
|
|
| 124 |
},
|
| 125 |
{
|
| 126 |
"task": "transition_detection",
|
| 127 |
"task_display_name": "Action Boundary Detection",
|
|
|
|
| 128 |
"family": "temporal diagnostic",
|
| 129 |
"unit": "single window",
|
| 130 |
"input": "current 20-frame all-feature window",
|
|
@@ -140,11 +144,14 @@
|
|
| 140 |
"minimal_primary_metric": 0.6118237590630229,
|
| 141 |
"neural_primary_metric": 0.5862068965517241,
|
| 142 |
"minimal_metric_source": "results/episode_task_suite/transition_detection/metrics.json",
|
| 143 |
-
"neural_metric_source": "results/episode_task_suite/neural_mlp/transition_detection/metrics.json"
|
|
|
|
|
|
|
| 144 |
},
|
| 145 |
{
|
| 146 |
"task": "next_action",
|
| 147 |
"task_display_name": "Next-Action Prediction",
|
|
|
|
| 148 |
"family": "short-horizon prediction",
|
| 149 |
"unit": "single window",
|
| 150 |
"input": "current 20-frame all-feature window at time t",
|
|
@@ -160,11 +167,14 @@
|
|
| 160 |
"minimal_primary_metric": 0.05925925925925927,
|
| 161 |
"neural_primary_metric": 0.04186046511627907,
|
| 162 |
"minimal_metric_source": "results/episode_task_suite/next_action/metrics.json",
|
| 163 |
-
"neural_metric_source": "results/episode_task_suite/neural_mlp/next_action/metrics.json"
|
|
|
|
|
|
|
| 164 |
},
|
| 165 |
{
|
| 166 |
"task": "hand_trajectory_forecast",
|
| 167 |
"task_display_name": "Hand Trajectory Forecasting",
|
|
|
|
| 168 |
"family": "trajectory regression",
|
| 169 |
"unit": "single window",
|
| 170 |
"input": "current all-feature window",
|
|
@@ -180,11 +190,14 @@
|
|
| 180 |
"minimal_primary_metric": 0.8646570444107056,
|
| 181 |
"neural_primary_metric": 0.10785018652677536,
|
| 182 |
"minimal_metric_source": "results/episode_task_suite/hand_trajectory_forecast/metrics.json",
|
| 183 |
-
"neural_metric_source": "results/episode_task_suite/neural_mlp/hand_trajectory_forecast/metrics.json"
|
|
|
|
|
|
|
| 184 |
},
|
| 185 |
{
|
| 186 |
"task": "contact_prediction",
|
| 187 |
"task_display_name": "Contact State Prediction",
|
|
|
|
| 188 |
"family": "binary classification",
|
| 189 |
"unit": "single window",
|
| 190 |
"input": "non-contact and non-caption feature blocks",
|
|
@@ -200,11 +213,14 @@
|
|
| 200 |
"minimal_primary_metric": 1.0,
|
| 201 |
"neural_primary_metric": 1.0,
|
| 202 |
"minimal_metric_source": "results/episode_task_suite/contact_prediction/metrics.json",
|
| 203 |
-
"neural_metric_source": "results/episode_task_suite/neural_mlp/contact_prediction/metrics.json"
|
|
|
|
|
|
|
| 204 |
},
|
| 205 |
{
|
| 206 |
"task": "object_relevance",
|
| 207 |
"task_display_name": "Object Relevance Prediction",
|
|
|
|
| 208 |
"family": "multi-label classification",
|
| 209 |
"unit": "single window",
|
| 210 |
"input": "non-caption feature blocks",
|
|
@@ -220,11 +236,14 @@
|
|
| 220 |
"minimal_primary_metric": 0.18034382095361662,
|
| 221 |
"neural_primary_metric": 0.1679279279279279,
|
| 222 |
"minimal_metric_source": "results/episode_task_suite/object_relevance/metrics.json",
|
| 223 |
-
"neural_metric_source": "results/episode_task_suite/neural_mlp/object_relevance/metrics.json"
|
|
|
|
|
|
|
| 224 |
},
|
| 225 |
{
|
| 226 |
"task": "caption_grounding",
|
| 227 |
"task_display_name": "Language Grounding",
|
|
|
|
| 228 |
"family": "retrieval",
|
| 229 |
"unit": "caption query",
|
| 230 |
"input": "caption object/interaction query plus candidate sensor windows",
|
|
@@ -240,11 +259,14 @@
|
|
| 240 |
"minimal_primary_metric": 0.016023479050338015,
|
| 241 |
"neural_primary_metric": 0.01684125567132316,
|
| 242 |
"minimal_metric_source": "results/episode_task_suite/caption_grounding/metrics.json",
|
| 243 |
-
"neural_metric_source": "results/episode_task_suite/neural_mlp/caption_grounding/metrics.json"
|
|
|
|
|
|
|
| 244 |
},
|
| 245 |
{
|
| 246 |
"task": "cross_modal_retrieval",
|
| 247 |
"task_display_name": "Cross-Modal Retrieval",
|
|
|
|
| 248 |
"family": "retrieval",
|
| 249 |
"unit": "sensor query",
|
| 250 |
"input": "motion, IMU, and camera query features",
|
|
@@ -260,11 +282,14 @@
|
|
| 260 |
"minimal_primary_metric": 0.367816091954023,
|
| 261 |
"neural_primary_metric": 0.19827586206896552,
|
| 262 |
"minimal_metric_source": "results/episode_task_suite/cross_modal_retrieval/metrics.json",
|
| 263 |
-
"neural_metric_source": "results/episode_task_suite/neural_mlp/cross_modal_retrieval/metrics.json"
|
|
|
|
|
|
|
| 264 |
},
|
| 265 |
{
|
| 266 |
"task": "modality_reconstruction",
|
| 267 |
"task_display_name": "Cross-Modal Reconstruction",
|
|
|
|
| 268 |
"family": "cross-modal regression",
|
| 269 |
"unit": "single window",
|
| 270 |
"input": "motion, IMU, and camera features",
|
|
@@ -279,11 +304,14 @@
|
|
| 279 |
"minimal_primary_metric": -0.015271898913936655,
|
| 280 |
"neural_primary_metric": -0.010171410134180991,
|
| 281 |
"minimal_metric_source": "results/episode_task_suite/modality_reconstruction/metrics.json",
|
| 282 |
-
"neural_metric_source": "results/episode_task_suite/neural_mlp/modality_reconstruction/metrics.json"
|
|
|
|
|
|
|
| 283 |
},
|
| 284 |
{
|
| 285 |
"task": "temporal_order",
|
| 286 |
"task_display_name": "Temporal Order Verification",
|
|
|
|
| 287 |
"family": "pairwise diagnostic",
|
| 288 |
"unit": "adjacent window pair",
|
| 289 |
"input": "two adjacent windows",
|
|
@@ -299,11 +327,14 @@
|
|
| 299 |
"minimal_primary_metric": 0.5399515738498789,
|
| 300 |
"neural_primary_metric": 0.8520179372197308,
|
| 301 |
"minimal_metric_source": "results/episode_task_suite/temporal_order/metrics.json",
|
| 302 |
-
"neural_metric_source": "results/episode_task_suite/neural_mlp/temporal_order/metrics.json"
|
|
|
|
|
|
|
| 303 |
},
|
| 304 |
{
|
| 305 |
"task": "misalignment_detection",
|
| 306 |
"task_display_name": "Multimodal Synchronization Detection",
|
|
|
|
| 307 |
"family": "pairwise diagnostic",
|
| 308 |
"unit": "paired modality window",
|
| 309 |
"input": "motion side plus visual/depth side",
|
|
@@ -319,13 +350,14 @@
|
|
| 319 |
"minimal_primary_metric": 0.5051698670605613,
|
| 320 |
"neural_primary_metric": 0.7152682255845944,
|
| 321 |
"minimal_metric_source": "results/episode_task_suite/misalignment_detection/metrics.json",
|
| 322 |
-
"neural_metric_source": "results/episode_task_suite/neural_mlp/misalignment_detection/metrics.json"
|
| 323 |
-
|
| 324 |
-
|
| 325 |
-
|
| 326 |
{
|
| 327 |
"task": "long_horizon_next_action",
|
| 328 |
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
|
|
|
| 329 |
"family": "classification",
|
| 330 |
"unit": "single aligned window",
|
| 331 |
"input": "Current 20-frame non-caption multimodal window.",
|
|
@@ -336,11 +368,14 @@
|
|
| 336 |
"neural_primary_metric": 0.06545454545454546,
|
| 337 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/long_horizon_next_action/metrics.json",
|
| 338 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/long_horizon_next_action/metrics.json",
|
| 339 |
-
"meaning": "Tests whether the current state carries enough procedure context to forecast beyond the one-second core next-action task."
|
|
|
|
|
|
|
| 340 |
},
|
| 341 |
{
|
| 342 |
"task": "next_subtask_forecast",
|
| 343 |
"task_display_name": "Long-Horizon Next-Subtask Forecasting",
|
|
|
|
| 344 |
"family": "classification",
|
| 345 |
"unit": "single aligned window",
|
| 346 |
"input": "Current 20-frame non-caption multimodal window.",
|
|
@@ -351,11 +386,14 @@
|
|
| 351 |
"neural_primary_metric": 0.050724637681159424,
|
| 352 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/next_subtask_forecast/metrics.json",
|
| 353 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/next_subtask_forecast/metrics.json",
|
| 354 |
-
"meaning": "Moves from immediate action anticipation to higher-level procedure-state prediction."
|
|
|
|
|
|
|
| 355 |
},
|
| 356 |
{
|
| 357 |
"task": "interaction_text_prediction",
|
| 358 |
"task_display_name": "Interaction Text Prediction",
|
|
|
|
| 359 |
"family": "classification",
|
| 360 |
"unit": "single aligned window",
|
| 361 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
|
@@ -366,11 +404,14 @@
|
|
| 366 |
"neural_primary_metric": 0.0380952380952381,
|
| 367 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/interaction_text_prediction/metrics.json",
|
| 368 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/interaction_text_prediction/metrics.json",
|
| 369 |
-
"meaning": "Uses the raw caption JSON interaction field as a language target instead of only the hashed text feature."
|
|
|
|
|
|
|
| 370 |
},
|
| 371 |
{
|
| 372 |
"task": "action_object_relation",
|
| 373 |
"task_display_name": "Action-Object Relation Prediction",
|
|
|
|
| 374 |
"family": "classification",
|
| 375 |
"unit": "single aligned window",
|
| 376 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
|
@@ -381,11 +422,14 @@
|
|
| 381 |
"neural_primary_metric": 0.0,
|
| 382 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/action_object_relation/metrics.json",
|
| 383 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/action_object_relation/metrics.json",
|
| 384 |
-
"meaning": "Evaluates whether a model can bind what action is happening to which objects are involved."
|
|
|
|
|
|
|
| 385 |
},
|
| 386 |
{
|
| 387 |
"task": "object_set_forecast",
|
| 388 |
"task_display_name": "Future Object-Set Forecasting",
|
|
|
|
| 389 |
"family": "multi_label",
|
| 390 |
"unit": "single aligned window",
|
| 391 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
|
@@ -396,11 +440,14 @@
|
|
| 396 |
"neural_primary_metric": 0.19718309859154928,
|
| 397 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/object_set_forecast/metrics.json",
|
| 398 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/object_set_forecast/metrics.json",
|
| 399 |
-
"meaning": "Predicts which objects will become relevant soon, not only which objects are relevant now."
|
|
|
|
|
|
|
| 400 |
},
|
| 401 |
{
|
| 402 |
"task": "imu_to_hand_pose",
|
| 403 |
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
|
|
|
| 404 |
"family": "regression",
|
| 405 |
"unit": "single aligned window",
|
| 406 |
"input": "Current IMU acceleration/gyroscope feature block only.",
|
|
@@ -411,11 +458,14 @@
|
|
| 411 |
"neural_primary_metric": 0.042562149465084076,
|
| 412 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/imu_to_hand_pose/metrics.json",
|
| 413 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/imu_to_hand_pose/metrics.json",
|
| 414 |
-
"meaning": "A sensor-bridge probe for how much hand configuration can be recovered from inertial motion alone."
|
|
|
|
|
|
|
| 415 |
},
|
| 416 |
{
|
| 417 |
"task": "camera_view_sync_retrieval",
|
| 418 |
"task_display_name": "Camera-View Synchronization Retrieval",
|
|
|
|
| 419 |
"family": "retrieval",
|
| 420 |
"unit": "held-out query window",
|
| 421 |
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
|
@@ -426,11 +476,14 @@
|
|
| 426 |
"neural_primary_metric": 0.24086658656597137,
|
| 427 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/camera_view_sync_retrieval/metrics.json",
|
| 428 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/camera_view_sync_retrieval/metrics.json",
|
| 429 |
-
"meaning": "Stress-tests multi-camera time alignment beyond the core cross-modal retrieval task."
|
|
|
|
|
|
|
| 430 |
},
|
| 431 |
{
|
| 432 |
"task": "time_to_transition",
|
| 433 |
"task_display_name": "Time-to-Next-Transition Regression",
|
|
|
|
| 434 |
"family": "regression",
|
| 435 |
"unit": "single aligned window",
|
| 436 |
"input": "Current 20-frame non-caption multimodal window.",
|
|
@@ -441,7 +494,9 @@
|
|
| 441 |
"neural_primary_metric": 10.55449390411377,
|
| 442 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/time_to_transition/metrics.json",
|
| 443 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/time_to_transition/metrics.json",
|
| 444 |
-
"meaning": "Turns boundary detection into a continuous timing estimate for procedural control."
|
|
|
|
|
|
|
| 445 |
}
|
| 446 |
],
|
| 447 |
"global_leakage_controls": [
|
|
|
|
| 2 |
"title": "Ropedia Xperience-10M Task Suite Evaluation Protocol",
|
| 3 |
"status": "pass",
|
| 4 |
"version": "2026-06-01",
|
| 5 |
+
"generated_at_utc": "2026-06-16T04:47:57+00:00",
|
| 6 |
"source_files": [
|
| 7 |
"docs/data/summary_metrics.json",
|
| 8 |
"results/episode_task_suite/summary_report.json",
|
| 9 |
"results/episode_task_suite/windows.csv",
|
| 10 |
"results/episode_task_suite/feature_manifest.json",
|
| 11 |
+
"docs/data/task_suite_20.json",
|
| 12 |
"docs/data/tier2_task_suite.json",
|
| 13 |
"results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json"
|
| 14 |
],
|
|
|
|
| 23 |
"audio_featurized": true,
|
| 24 |
"raw_data_redistributed": false
|
| 25 |
},
|
| 26 |
+
"task_suite": {
|
| 27 |
+
"status": "unified_public_sample_suite",
|
| 28 |
+
"task_count": 20,
|
| 29 |
+
"original_public_sample_tasks": 12,
|
| 30 |
+
"additional_public_sample_tasks": 8,
|
| 31 |
+
"unified_results": "docs/data/task_suite_20.json",
|
| 32 |
+
"legacy_additional_task_result_path": "docs/data/tier2_task_suite.json",
|
| 33 |
+
"legacy_path_note": "The tier2_task_suite path is retained for stable links only; tasks 13-20 are presented as part of the same 20-task suite."
|
|
|
|
|
|
|
|
|
|
|
|
|
| 34 |
},
|
| 35 |
"split_policy": {
|
| 36 |
"name": "single_episode_chronological",
|
|
|
|
| 82 |
{
|
| 83 |
"task": "timeline_action",
|
| 84 |
"task_display_name": "Action Recognition",
|
| 85 |
+
"origin": "original_public_sample_tasks",
|
| 86 |
"family": "supervised classification",
|
| 87 |
"unit": "single window",
|
| 88 |
"input": "current 20-frame all-feature window",
|
|
|
|
| 98 |
"minimal_primary_metric": 0.05,
|
| 99 |
"neural_primary_metric": 0.014814814814814814,
|
| 100 |
"minimal_metric_source": "results/episode_task_suite/timeline_action/metrics.json",
|
| 101 |
+
"neural_metric_source": "results/episode_task_suite/neural_mlp/timeline_action/metrics.json",
|
| 102 |
+
"task_number": 1,
|
| 103 |
+
"suite_label": "Task 01"
|
| 104 |
},
|
| 105 |
{
|
| 106 |
"task": "timeline_subtask",
|
| 107 |
"task_display_name": "Procedure Step Recognition",
|
| 108 |
+
"origin": "original_public_sample_tasks",
|
| 109 |
"family": "supervised classification",
|
| 110 |
"unit": "single window",
|
| 111 |
"input": "current 20-frame all-feature window",
|
|
|
|
| 121 |
"minimal_primary_metric": 0.05056355513846935,
|
| 122 |
"neural_primary_metric": 0.02810810810810811,
|
| 123 |
"minimal_metric_source": "results/episode_task_suite/timeline_subtask/metrics.json",
|
| 124 |
+
"neural_metric_source": "results/episode_task_suite/neural_mlp/timeline_subtask/metrics.json",
|
| 125 |
+
"task_number": 2,
|
| 126 |
+
"suite_label": "Task 02"
|
| 127 |
},
|
| 128 |
{
|
| 129 |
"task": "transition_detection",
|
| 130 |
"task_display_name": "Action Boundary Detection",
|
| 131 |
+
"origin": "original_public_sample_tasks",
|
| 132 |
"family": "temporal diagnostic",
|
| 133 |
"unit": "single window",
|
| 134 |
"input": "current 20-frame all-feature window",
|
|
|
|
| 144 |
"minimal_primary_metric": 0.6118237590630229,
|
| 145 |
"neural_primary_metric": 0.5862068965517241,
|
| 146 |
"minimal_metric_source": "results/episode_task_suite/transition_detection/metrics.json",
|
| 147 |
+
"neural_metric_source": "results/episode_task_suite/neural_mlp/transition_detection/metrics.json",
|
| 148 |
+
"task_number": 3,
|
| 149 |
+
"suite_label": "Task 03"
|
| 150 |
},
|
| 151 |
{
|
| 152 |
"task": "next_action",
|
| 153 |
"task_display_name": "Next-Action Prediction",
|
| 154 |
+
"origin": "original_public_sample_tasks",
|
| 155 |
"family": "short-horizon prediction",
|
| 156 |
"unit": "single window",
|
| 157 |
"input": "current 20-frame all-feature window at time t",
|
|
|
|
| 167 |
"minimal_primary_metric": 0.05925925925925927,
|
| 168 |
"neural_primary_metric": 0.04186046511627907,
|
| 169 |
"minimal_metric_source": "results/episode_task_suite/next_action/metrics.json",
|
| 170 |
+
"neural_metric_source": "results/episode_task_suite/neural_mlp/next_action/metrics.json",
|
| 171 |
+
"task_number": 4,
|
| 172 |
+
"suite_label": "Task 04"
|
| 173 |
},
|
| 174 |
{
|
| 175 |
"task": "hand_trajectory_forecast",
|
| 176 |
"task_display_name": "Hand Trajectory Forecasting",
|
| 177 |
+
"origin": "original_public_sample_tasks",
|
| 178 |
"family": "trajectory regression",
|
| 179 |
"unit": "single window",
|
| 180 |
"input": "current all-feature window",
|
|
|
|
| 190 |
"minimal_primary_metric": 0.8646570444107056,
|
| 191 |
"neural_primary_metric": 0.10785018652677536,
|
| 192 |
"minimal_metric_source": "results/episode_task_suite/hand_trajectory_forecast/metrics.json",
|
| 193 |
+
"neural_metric_source": "results/episode_task_suite/neural_mlp/hand_trajectory_forecast/metrics.json",
|
| 194 |
+
"task_number": 5,
|
| 195 |
+
"suite_label": "Task 05"
|
| 196 |
},
|
| 197 |
{
|
| 198 |
"task": "contact_prediction",
|
| 199 |
"task_display_name": "Contact State Prediction",
|
| 200 |
+
"origin": "original_public_sample_tasks",
|
| 201 |
"family": "binary classification",
|
| 202 |
"unit": "single window",
|
| 203 |
"input": "non-contact and non-caption feature blocks",
|
|
|
|
| 213 |
"minimal_primary_metric": 1.0,
|
| 214 |
"neural_primary_metric": 1.0,
|
| 215 |
"minimal_metric_source": "results/episode_task_suite/contact_prediction/metrics.json",
|
| 216 |
+
"neural_metric_source": "results/episode_task_suite/neural_mlp/contact_prediction/metrics.json",
|
| 217 |
+
"task_number": 6,
|
| 218 |
+
"suite_label": "Task 06"
|
| 219 |
},
|
| 220 |
{
|
| 221 |
"task": "object_relevance",
|
| 222 |
"task_display_name": "Object Relevance Prediction",
|
| 223 |
+
"origin": "original_public_sample_tasks",
|
| 224 |
"family": "multi-label classification",
|
| 225 |
"unit": "single window",
|
| 226 |
"input": "non-caption feature blocks",
|
|
|
|
| 236 |
"minimal_primary_metric": 0.18034382095361662,
|
| 237 |
"neural_primary_metric": 0.1679279279279279,
|
| 238 |
"minimal_metric_source": "results/episode_task_suite/object_relevance/metrics.json",
|
| 239 |
+
"neural_metric_source": "results/episode_task_suite/neural_mlp/object_relevance/metrics.json",
|
| 240 |
+
"task_number": 7,
|
| 241 |
+
"suite_label": "Task 07"
|
| 242 |
},
|
| 243 |
{
|
| 244 |
"task": "caption_grounding",
|
| 245 |
"task_display_name": "Language Grounding",
|
| 246 |
+
"origin": "original_public_sample_tasks",
|
| 247 |
"family": "retrieval",
|
| 248 |
"unit": "caption query",
|
| 249 |
"input": "caption object/interaction query plus candidate sensor windows",
|
|
|
|
| 259 |
"minimal_primary_metric": 0.016023479050338015,
|
| 260 |
"neural_primary_metric": 0.01684125567132316,
|
| 261 |
"minimal_metric_source": "results/episode_task_suite/caption_grounding/metrics.json",
|
| 262 |
+
"neural_metric_source": "results/episode_task_suite/neural_mlp/caption_grounding/metrics.json",
|
| 263 |
+
"task_number": 8,
|
| 264 |
+
"suite_label": "Task 08"
|
| 265 |
},
|
| 266 |
{
|
| 267 |
"task": "cross_modal_retrieval",
|
| 268 |
"task_display_name": "Cross-Modal Retrieval",
|
| 269 |
+
"origin": "original_public_sample_tasks",
|
| 270 |
"family": "retrieval",
|
| 271 |
"unit": "sensor query",
|
| 272 |
"input": "motion, IMU, and camera query features",
|
|
|
|
| 282 |
"minimal_primary_metric": 0.367816091954023,
|
| 283 |
"neural_primary_metric": 0.19827586206896552,
|
| 284 |
"minimal_metric_source": "results/episode_task_suite/cross_modal_retrieval/metrics.json",
|
| 285 |
+
"neural_metric_source": "results/episode_task_suite/neural_mlp/cross_modal_retrieval/metrics.json",
|
| 286 |
+
"task_number": 9,
|
| 287 |
+
"suite_label": "Task 09"
|
| 288 |
},
|
| 289 |
{
|
| 290 |
"task": "modality_reconstruction",
|
| 291 |
"task_display_name": "Cross-Modal Reconstruction",
|
| 292 |
+
"origin": "original_public_sample_tasks",
|
| 293 |
"family": "cross-modal regression",
|
| 294 |
"unit": "single window",
|
| 295 |
"input": "motion, IMU, and camera features",
|
|
|
|
| 304 |
"minimal_primary_metric": -0.015271898913936655,
|
| 305 |
"neural_primary_metric": -0.010171410134180991,
|
| 306 |
"minimal_metric_source": "results/episode_task_suite/modality_reconstruction/metrics.json",
|
| 307 |
+
"neural_metric_source": "results/episode_task_suite/neural_mlp/modality_reconstruction/metrics.json",
|
| 308 |
+
"task_number": 10,
|
| 309 |
+
"suite_label": "Task 10"
|
| 310 |
},
|
| 311 |
{
|
| 312 |
"task": "temporal_order",
|
| 313 |
"task_display_name": "Temporal Order Verification",
|
| 314 |
+
"origin": "original_public_sample_tasks",
|
| 315 |
"family": "pairwise diagnostic",
|
| 316 |
"unit": "adjacent window pair",
|
| 317 |
"input": "two adjacent windows",
|
|
|
|
| 327 |
"minimal_primary_metric": 0.5399515738498789,
|
| 328 |
"neural_primary_metric": 0.8520179372197308,
|
| 329 |
"minimal_metric_source": "results/episode_task_suite/temporal_order/metrics.json",
|
| 330 |
+
"neural_metric_source": "results/episode_task_suite/neural_mlp/temporal_order/metrics.json",
|
| 331 |
+
"task_number": 11,
|
| 332 |
+
"suite_label": "Task 11"
|
| 333 |
},
|
| 334 |
{
|
| 335 |
"task": "misalignment_detection",
|
| 336 |
"task_display_name": "Multimodal Synchronization Detection",
|
| 337 |
+
"origin": "original_public_sample_tasks",
|
| 338 |
"family": "pairwise diagnostic",
|
| 339 |
"unit": "paired modality window",
|
| 340 |
"input": "motion side plus visual/depth side",
|
|
|
|
| 350 |
"minimal_primary_metric": 0.5051698670605613,
|
| 351 |
"neural_primary_metric": 0.7152682255845944,
|
| 352 |
"minimal_metric_source": "results/episode_task_suite/misalignment_detection/metrics.json",
|
| 353 |
+
"neural_metric_source": "results/episode_task_suite/neural_mlp/misalignment_detection/metrics.json",
|
| 354 |
+
"task_number": 12,
|
| 355 |
+
"suite_label": "Task 12"
|
| 356 |
+
},
|
| 357 |
{
|
| 358 |
"task": "long_horizon_next_action",
|
| 359 |
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
| 360 |
+
"origin": "additional_public_sample_tasks",
|
| 361 |
"family": "classification",
|
| 362 |
"unit": "single aligned window",
|
| 363 |
"input": "Current 20-frame non-caption multimodal window.",
|
|
|
|
| 368 |
"neural_primary_metric": 0.06545454545454546,
|
| 369 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/long_horizon_next_action/metrics.json",
|
| 370 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/long_horizon_next_action/metrics.json",
|
| 371 |
+
"meaning": "Tests whether the current state carries enough procedure context to forecast beyond the one-second core next-action task.",
|
| 372 |
+
"task_number": 13,
|
| 373 |
+
"suite_label": "Task 13"
|
| 374 |
},
|
| 375 |
{
|
| 376 |
"task": "next_subtask_forecast",
|
| 377 |
"task_display_name": "Long-Horizon Next-Subtask Forecasting",
|
| 378 |
+
"origin": "additional_public_sample_tasks",
|
| 379 |
"family": "classification",
|
| 380 |
"unit": "single aligned window",
|
| 381 |
"input": "Current 20-frame non-caption multimodal window.",
|
|
|
|
| 386 |
"neural_primary_metric": 0.050724637681159424,
|
| 387 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/next_subtask_forecast/metrics.json",
|
| 388 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/next_subtask_forecast/metrics.json",
|
| 389 |
+
"meaning": "Moves from immediate action anticipation to higher-level procedure-state prediction.",
|
| 390 |
+
"task_number": 14,
|
| 391 |
+
"suite_label": "Task 14"
|
| 392 |
},
|
| 393 |
{
|
| 394 |
"task": "interaction_text_prediction",
|
| 395 |
"task_display_name": "Interaction Text Prediction",
|
| 396 |
+
"origin": "additional_public_sample_tasks",
|
| 397 |
"family": "classification",
|
| 398 |
"unit": "single aligned window",
|
| 399 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
|
|
|
| 404 |
"neural_primary_metric": 0.0380952380952381,
|
| 405 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/interaction_text_prediction/metrics.json",
|
| 406 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/interaction_text_prediction/metrics.json",
|
| 407 |
+
"meaning": "Uses the raw caption JSON interaction field as a language target instead of only the hashed text feature.",
|
| 408 |
+
"task_number": 15,
|
| 409 |
+
"suite_label": "Task 15"
|
| 410 |
},
|
| 411 |
{
|
| 412 |
"task": "action_object_relation",
|
| 413 |
"task_display_name": "Action-Object Relation Prediction",
|
| 414 |
+
"origin": "additional_public_sample_tasks",
|
| 415 |
"family": "classification",
|
| 416 |
"unit": "single aligned window",
|
| 417 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
|
|
|
| 422 |
"neural_primary_metric": 0.0,
|
| 423 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/action_object_relation/metrics.json",
|
| 424 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/action_object_relation/metrics.json",
|
| 425 |
+
"meaning": "Evaluates whether a model can bind what action is happening to which objects are involved.",
|
| 426 |
+
"task_number": 16,
|
| 427 |
+
"suite_label": "Task 16"
|
| 428 |
},
|
| 429 |
{
|
| 430 |
"task": "object_set_forecast",
|
| 431 |
"task_display_name": "Future Object-Set Forecasting",
|
| 432 |
+
"origin": "additional_public_sample_tasks",
|
| 433 |
"family": "multi_label",
|
| 434 |
"unit": "single aligned window",
|
| 435 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
|
|
|
| 440 |
"neural_primary_metric": 0.19718309859154928,
|
| 441 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/object_set_forecast/metrics.json",
|
| 442 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/object_set_forecast/metrics.json",
|
| 443 |
+
"meaning": "Predicts which objects will become relevant soon, not only which objects are relevant now.",
|
| 444 |
+
"task_number": 17,
|
| 445 |
+
"suite_label": "Task 17"
|
| 446 |
},
|
| 447 |
{
|
| 448 |
"task": "imu_to_hand_pose",
|
| 449 |
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
| 450 |
+
"origin": "additional_public_sample_tasks",
|
| 451 |
"family": "regression",
|
| 452 |
"unit": "single aligned window",
|
| 453 |
"input": "Current IMU acceleration/gyroscope feature block only.",
|
|
|
|
| 458 |
"neural_primary_metric": 0.042562149465084076,
|
| 459 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/imu_to_hand_pose/metrics.json",
|
| 460 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/imu_to_hand_pose/metrics.json",
|
| 461 |
+
"meaning": "A sensor-bridge probe for how much hand configuration can be recovered from inertial motion alone.",
|
| 462 |
+
"task_number": 18,
|
| 463 |
+
"suite_label": "Task 18"
|
| 464 |
},
|
| 465 |
{
|
| 466 |
"task": "camera_view_sync_retrieval",
|
| 467 |
"task_display_name": "Camera-View Synchronization Retrieval",
|
| 468 |
+
"origin": "additional_public_sample_tasks",
|
| 469 |
"family": "retrieval",
|
| 470 |
"unit": "held-out query window",
|
| 471 |
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
|
|
|
| 476 |
"neural_primary_metric": 0.24086658656597137,
|
| 477 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/camera_view_sync_retrieval/metrics.json",
|
| 478 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/camera_view_sync_retrieval/metrics.json",
|
| 479 |
+
"meaning": "Stress-tests multi-camera time alignment beyond the core cross-modal retrieval task.",
|
| 480 |
+
"task_number": 19,
|
| 481 |
+
"suite_label": "Task 19"
|
| 482 |
},
|
| 483 |
{
|
| 484 |
"task": "time_to_transition",
|
| 485 |
"task_display_name": "Time-to-Next-Transition Regression",
|
| 486 |
+
"origin": "additional_public_sample_tasks",
|
| 487 |
"family": "regression",
|
| 488 |
"unit": "single aligned window",
|
| 489 |
"input": "Current 20-frame non-caption multimodal window.",
|
|
|
|
| 494 |
"neural_primary_metric": 10.55449390411377,
|
| 495 |
"minimal_metric_source": "results/episode_task_suite/tier2_task_suite/time_to_transition/metrics.json",
|
| 496 |
"neural_metric_source": "results/episode_task_suite/tier2_task_suite/neural_mlp/time_to_transition/metrics.json",
|
| 497 |
+
"meaning": "Turns boundary detection into a continuous timing estimate for procedural control.",
|
| 498 |
+
"task_number": 20,
|
| 499 |
+
"suite_label": "Task 20"
|
| 500 |
}
|
| 501 |
],
|
| 502 |
"global_leakage_controls": [
|
docs/data/figure_index.json
CHANGED
|
@@ -1,7 +1,7 @@
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Figure Index",
|
| 3 |
"status": "pass",
|
| 4 |
-
"generated_at_utc": "2026-06-
|
| 5 |
"scope": "Public figures, diagrams, charts, and derived modality thumbnails. Raw Xperience-10M videos, annotations, RRD files, and Qwen weights are excluded.",
|
| 6 |
"figure_count": 23,
|
| 7 |
"figures": [
|
|
@@ -58,14 +58,14 @@
|
|
| 58 |
},
|
| 59 |
{
|
| 60 |
"id": "task_suite_infographic",
|
| 61 |
-
"title": "
|
| 62 |
"path": "docs/assets/task_suite_infographic.png",
|
| 63 |
-
"role": "Primary visual map of the task
|
| 64 |
"source_script": "scripts/render_task_suite_infographic.py",
|
| 65 |
"surface": "README, website, HF Space, artifact dataset, model card",
|
| 66 |
"exists": true,
|
| 67 |
-
"bytes":
|
| 68 |
-
"sha256": "
|
| 69 |
"dimensions": {
|
| 70 |
"format": "PNG",
|
| 71 |
"width": 1800,
|
|
@@ -111,7 +111,7 @@
|
|
| 111 |
"id": "task_architectures",
|
| 112 |
"title": "Minimal and neural task architecture map",
|
| 113 |
"path": "docs/assets/task_architectures.png",
|
| 114 |
-
"role": "
|
| 115 |
"source_script": "scripts/render_overview_figures.py",
|
| 116 |
"surface": "README, website, HF artifact dataset, model card",
|
| 117 |
"exists": true,
|
|
@@ -335,14 +335,14 @@
|
|
| 335 |
},
|
| 336 |
{
|
| 337 |
"id": "tier2_task_suite_chart",
|
| 338 |
-
"title": "
|
| 339 |
"path": "docs/assets/charts/tier2_task_suite.svg",
|
| 340 |
-
"role": "Eight sample-supported
|
| 341 |
"source_script": "scripts/tier2_task_suite.py",
|
| 342 |
-
"surface": "website
|
| 343 |
"exists": true,
|
| 344 |
-
"bytes":
|
| 345 |
-
"sha256": "
|
| 346 |
"dimensions": {
|
| 347 |
"format": "SVG",
|
| 348 |
"width": 1440,
|
|
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Figure Index",
|
| 3 |
"status": "pass",
|
| 4 |
+
"generated_at_utc": "2026-06-16T04:56:21+00:00",
|
| 5 |
"scope": "Public figures, diagrams, charts, and derived modality thumbnails. Raw Xperience-10M videos, annotations, RRD files, and Qwen weights are excluded.",
|
| 6 |
"figure_count": 23,
|
| 7 |
"figures": [
|
|
|
|
| 58 |
},
|
| 59 |
{
|
| 60 |
"id": "task_suite_infographic",
|
| 61 |
+
"title": "Original task-suite infographic",
|
| 62 |
"path": "docs/assets/task_suite_infographic.png",
|
| 63 |
+
"role": "Primary visual map of the original task families, verified metrics, and sample modalities; the unified public suite is now documented as 20 tasks.",
|
| 64 |
"source_script": "scripts/render_task_suite_infographic.py",
|
| 65 |
"surface": "README, website, HF Space, artifact dataset, model card",
|
| 66 |
"exists": true,
|
| 67 |
+
"bytes": 2627286,
|
| 68 |
+
"sha256": "664c44bec150c4e857cae95d798e379f8a051067863bab1e51ec06d113a34fe4",
|
| 69 |
"dimensions": {
|
| 70 |
"format": "PNG",
|
| 71 |
"width": 1800,
|
|
|
|
| 111 |
"id": "task_architectures",
|
| 112 |
"title": "Minimal and neural task architecture map",
|
| 113 |
"path": "docs/assets/task_architectures.png",
|
| 114 |
+
"role": "Minimal and neural heads for the original task contracts and shared feature contracts.",
|
| 115 |
"source_script": "scripts/render_overview_figures.py",
|
| 116 |
"surface": "README, website, HF artifact dataset, model card",
|
| 117 |
"exists": true,
|
|
|
|
| 335 |
},
|
| 336 |
{
|
| 337 |
"id": "tier2_task_suite_chart",
|
| 338 |
+
"title": "Tasks 13-20 baseline chart",
|
| 339 |
"path": "docs/assets/charts/tier2_task_suite.svg",
|
| 340 |
+
"role": "Eight additional sample-supported tasks in the unified 20-task suite with aligned minimal and neural baseline metrics.",
|
| 341 |
"source_script": "scripts/tier2_task_suite.py",
|
| 342 |
+
"surface": "website unified task section, README, HF mirrors",
|
| 343 |
"exists": true,
|
| 344 |
+
"bytes": 5437,
|
| 345 |
+
"sha256": "3e35e476f559cd6188e5417e4d28c25efc130abafc9cab2d941bc77d559177a1",
|
| 346 |
"dimensions": {
|
| 347 |
"format": "SVG",
|
| 348 |
"width": 1440,
|
docs/data/mirror_parity.json
CHANGED
|
The diff for this file is too large to render.
See raw diff
|
|
|
docs/data/project_brief.json
CHANGED
|
@@ -9,7 +9,7 @@
|
|
| 9 |
},
|
| 10 |
{
|
| 11 |
"capability": "Task design",
|
| 12 |
-
"evidence": "
|
| 13 |
},
|
| 14 |
{
|
| 15 |
"capability": "Evaluation rigor",
|
|
@@ -31,11 +31,11 @@
|
|
| 31 |
},
|
| 32 |
{
|
| 33 |
"layer": "Task suite",
|
| 34 |
-
"status": "
|
| 35 |
},
|
| 36 |
{
|
| 37 |
"layer": "Models",
|
| 38 |
-
"status": "Minimal linear/ridge/logistic baselines plus compact PyTorch MLP heads for the
|
| 39 |
},
|
| 40 |
{
|
| 41 |
"layer": "Research map",
|
|
@@ -52,7 +52,7 @@
|
|
| 52 |
"Open EVALUATION_PROTOCOL.md before comparing task scores.",
|
| 53 |
"Use RESEARCH_TAKEAWAYS.md for the current metric interpretation.",
|
| 54 |
"Inspect results/episode_task_suite/feature_manifest.json to understand one model input.",
|
| 55 |
-
"Use docs/data/
|
| 56 |
"Use docs/data/omni_finetune_verified_result.json for the current multi-episode Qwen3-Omni pilot result."
|
| 57 |
],
|
| 58 |
"scope_boundary": "The public sample is enough to build and verify task definitions, feature contracts, metrics, visualization, and baseline code. The final multi-episode Qwen3-Omni diagnostic result verifies the training loop and strict-JSON output reliability, but does not yet show strong action/subtask model quality.",
|
|
|
|
| 9 |
},
|
| 10 |
{
|
| 11 |
"capability": "Task design",
|
| 12 |
+
"evidence": "20 unified task contracts, task cards, case-study walkthroughs, and four research-direction extension probes"
|
| 13 |
},
|
| 14 |
{
|
| 15 |
"capability": "Evaluation rigor",
|
|
|
|
| 31 |
},
|
| 32 |
{
|
| 33 |
"layer": "Task suite",
|
| 34 |
+
"status": "20 embodied-AI task contracts with inputs, targets, metrics, predictions, and setup alignment"
|
| 35 |
},
|
| 36 |
{
|
| 37 |
"layer": "Models",
|
| 38 |
+
"status": "Minimal linear/ridge/logistic baselines plus compact PyTorch MLP heads for the unified 20-task public-sample suite"
|
| 39 |
},
|
| 40 |
{
|
| 41 |
"layer": "Research map",
|
|
|
|
| 52 |
"Open EVALUATION_PROTOCOL.md before comparing task scores.",
|
| 53 |
"Use RESEARCH_TAKEAWAYS.md for the current metric interpretation.",
|
| 54 |
"Inspect results/episode_task_suite/feature_manifest.json to understand one model input.",
|
| 55 |
+
"Use TASK_SUITE_20.md and docs/data/task_suite_20.json to read the unified 20-task suite; the historical docs/data/tier2_task_suite.json path stores the tasks 13-20 result bundle.",
|
| 56 |
"Use docs/data/omni_finetune_verified_result.json for the current multi-episode Qwen3-Omni pilot result."
|
| 57 |
],
|
| 58 |
"scope_boundary": "The public sample is enough to build and verify task definitions, feature contracts, metrics, visualization, and baseline code. The final multi-episode Qwen3-Omni diagnostic result verifies the training loop and strict-JSON output reliability, but does not yet show strong action/subtask model quality.",
|
docs/data/project_manifest.json
CHANGED
|
@@ -10,8 +10,6 @@
|
|
| 10 |
"episode_count_verified": 1,
|
| 11 |
"window_count_verified": 1161,
|
| 12 |
"feature_dim_verified": 8546,
|
| 13 |
-
"core_task_count": 12,
|
| 14 |
-
"tier2_extension_task_count": 8,
|
| 15 |
"audio_featurized": true,
|
| 16 |
"qwen3_omni_32_episode_claim": false,
|
| 17 |
"qwen3_omni_verified_diagnostic_pilot": true,
|
|
@@ -23,7 +21,11 @@
|
|
| 23 |
"qwen3_omni_held_out_test_windows": 448,
|
| 24 |
"qwen3_omni_json_validity_rate": 0.9977678571428571,
|
| 25 |
"qwen3_omni_json_quality_target_met": true,
|
| 26 |
-
"qwen3_omni_lora_adapter_repo": "https://huggingface.co/cy0307/ropedia-qwen3-omni-lora-128ep"
|
|
|
|
|
|
|
|
|
|
|
|
|
| 27 |
},
|
| 28 |
"public_surfaces": {
|
| 29 |
"github_repo": "https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite",
|
|
@@ -90,8 +92,10 @@
|
|
| 90 |
"modality_atlas": "docs/data/modality_atlas.json",
|
| 91 |
"research_directions": "docs/data/research_directions.json",
|
| 92 |
"research_direction_extensions": "docs/data/research_direction_extensions.json",
|
| 93 |
-
"
|
| 94 |
-
"
|
|
|
|
|
|
|
| 95 |
},
|
| 96 |
"citation_files": {
|
| 97 |
"citation_cff": "CITATION.cff",
|
|
|
|
| 10 |
"episode_count_verified": 1,
|
| 11 |
"window_count_verified": 1161,
|
| 12 |
"feature_dim_verified": 8546,
|
|
|
|
|
|
|
| 13 |
"audio_featurized": true,
|
| 14 |
"qwen3_omni_32_episode_claim": false,
|
| 15 |
"qwen3_omni_verified_diagnostic_pilot": true,
|
|
|
|
| 21 |
"qwen3_omni_held_out_test_windows": 448,
|
| 22 |
"qwen3_omni_json_validity_rate": 0.9977678571428571,
|
| 23 |
"qwen3_omni_json_quality_target_met": true,
|
| 24 |
+
"qwen3_omni_lora_adapter_repo": "https://huggingface.co/cy0307/ropedia-qwen3-omni-lora-128ep",
|
| 25 |
+
"task_count": 20,
|
| 26 |
+
"original_public_sample_task_count": 12,
|
| 27 |
+
"additional_public_sample_task_count": 8,
|
| 28 |
+
"legacy_tasks_13_to_20_result_path": "docs/data/tier2_task_suite.json"
|
| 29 |
},
|
| 30 |
"public_surfaces": {
|
| 31 |
"github_repo": "https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite",
|
|
|
|
| 92 |
"modality_atlas": "docs/data/modality_atlas.json",
|
| 93 |
"research_directions": "docs/data/research_directions.json",
|
| 94 |
"research_direction_extensions": "docs/data/research_direction_extensions.json",
|
| 95 |
+
"task_walkthroughs": "docs/data/task_walkthroughs.json",
|
| 96 |
+
"task_suite_20": "TASK_SUITE_20.md",
|
| 97 |
+
"task_suite_20_json": "docs/data/task_suite_20.json",
|
| 98 |
+
"tasks_13_to_20_result_bundle": "docs/data/tier2_task_suite.json"
|
| 99 |
},
|
| 100 |
"citation_files": {
|
| 101 |
"citation_cff": "CITATION.cff",
|
docs/data/project_packet.json
CHANGED
|
@@ -1,167 +1,172 @@
|
|
| 1 |
{
|
| 2 |
-
|
| 3 |
-
|
| 4 |
-
|
| 5 |
-
|
| 6 |
-
|
| 7 |
-
|
| 8 |
-
|
| 9 |
-
|
| 10 |
-
|
| 11 |
-
|
| 12 |
-
|
| 13 |
-
|
| 14 |
-
|
| 15 |
-
|
| 16 |
-
|
| 17 |
-
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 18 |
},
|
| 19 |
-
|
| 20 |
-
|
| 21 |
-
|
| 22 |
-
|
| 23 |
-
|
| 24 |
-
|
| 25 |
-
|
| 26 |
-
|
| 27 |
-
|
| 28 |
-
|
| 29 |
-
"ARTIFACT_GUIDE.md",
|
| 30 |
-
"EVALUATION_PROTOCOL.md",
|
| 31 |
-
"FIGURE_INDEX.md",
|
| 32 |
-
"SOURCE_ALIGNMENT_AUDIT.md",
|
| 33 |
-
"XPERIENCE10M_DATASET_CARD_ALIGNMENT.md",
|
| 34 |
-
"docs/data/evidence_contract.json",
|
| 35 |
-
"docs/data/artifact_index.json",
|
| 36 |
-
"docs/data/brand_assets.json",
|
| 37 |
-
"docs/data/evaluation_protocol.json",
|
| 38 |
-
"docs/data/figure_index.json",
|
| 39 |
-
"docs/data/source_alignment_audit.json",
|
| 40 |
-
"docs/data/xperience10m_dataset_card_alignment.json",
|
| 41 |
-
"docs/data/mirror_parity.json",
|
| 42 |
-
"docs/data/publication_audit.json",
|
| 43 |
-
"docs/data/scope_claims_audit.json",
|
| 44 |
-
"docs/data/website_integrity.json"
|
| 45 |
-
],
|
| 46 |
-
"readout": "The project status table and roadmap give the compact current-state summary. Single-episode task engineering, metrics, visualizations, public website integrity, mirror parity, same-split 128-episode baselines, the final selected-episode Qwen3-Omni diagnostic result, the Cosmos3-Nano compatibility package, the Cosmos3-Super base-weight Reasoner evaluation, and the Cosmos3-Super Forward-Dynamics LoRA package are implemented; stronger action/subtask quality and policy-compatible action targets remain follow-ups."
|
| 47 |
-
},
|
| 48 |
-
{
|
| 49 |
-
"step": 2,
|
| 50 |
-
"question": "What do the official Xperience-10M dataset and sample cards say?",
|
| 51 |
-
"primary_artifacts": [
|
| 52 |
-
"XPERIENCE10M_DATASET_CARD_ALIGNMENT.md",
|
| 53 |
-
"docs/data/xperience10m_dataset_card_alignment.json",
|
| 54 |
-
"https://huggingface.co/datasets/ropedia-ai/xperience-10m",
|
| 55 |
-
"https://huggingface.co/datasets/ropedia-ai/xperience-10m-sample"
|
| 56 |
-
],
|
| 57 |
-
"readout": "The full upstream dataset is a manually gated large-scale 4D multimodal egocentric source. The public sample card records the sample license, HOMIE Toolkit path, and Rerun 0.29.0 visualization path. This repo validates one public sample episode and lists the current project coverage."
|
| 58 |
-
},
|
| 59 |
-
{
|
| 60 |
-
"step": 3,
|
| 61 |
-
"question": "Are source facts consistently presented?",
|
| 62 |
-
"primary_artifacts": [
|
| 63 |
-
"SOURCE_ALIGNMENT_AUDIT.md",
|
| 64 |
-
"docs/data/source_alignment_audit.json",
|
| 65 |
-
"scripts/validate_source_alignment.py"
|
| 66 |
-
],
|
| 67 |
-
"readout": "The source-alignment report checks full-dataset metadata, API-listing notes, public sample license/tooling, and project coverage across repo docs, website, and HF cards."
|
| 68 |
-
},
|
| 69 |
-
{
|
| 70 |
-
"step": 4,
|
| 71 |
-
"question": "How exactly are the tasks evaluated?",
|
| 72 |
-
"primary_artifacts": [
|
| 73 |
-
"EVALUATION_PROTOCOL.md",
|
| 74 |
-
"docs/data/evaluation_protocol.json",
|
| 75 |
-
"scripts/build_evaluation_protocol.py"
|
| 76 |
-
],
|
| 77 |
-
"readout": "The protocol fixes the 20-frame window unit, chronological split, train-only normalization, leakage controls, per-task input/target/metric contracts, and current limitations."
|
| 78 |
-
},
|
| 79 |
-
{
|
| 80 |
-
"step": 5,
|
| 81 |
-
"question": "How can the public pipeline be reproduced?",
|
| 82 |
-
"primary_artifacts": [
|
| 83 |
-
"REPRODUCIBILITY.md",
|
| 84 |
-
"docs/data/reproducibility_matrix.json",
|
| 85 |
-
"notes/reproducibility_audit.md"
|
| 86 |
-
],
|
| 87 |
-
"readout": "The public sample pipeline has explicit commands, expected outputs, and a prior exact-match reproduction check over the committed metrics."
|
| 88 |
-
},
|
| 89 |
-
{
|
| 90 |
-
"step": 6,
|
| 91 |
-
"question": "What is inside one model input?",
|
| 92 |
-
"primary_artifacts": [
|
| 93 |
-
"results/episode_task_suite/windows.csv",
|
| 94 |
-
"results/episode_task_suite/feature_manifest.json",
|
| 95 |
-
"results/episode_task_suite/available_modalities.json",
|
| 96 |
-
"docs/data/modality_atlas.json"
|
| 97 |
-
],
|
| 98 |
-
"readout": "The current model input is an 8,546-dimensional aligned multimodal window, and the readable atlas shows each public-sample modality without raw data redistribution."
|
| 99 |
-
},
|
| 100 |
-
{
|
| 101 |
-
"step": 7,
|
| 102 |
-
"question": "Do the task metrics have committed evidence?",
|
| 103 |
-
"primary_artifacts": [
|
| 104 |
-
"results/episode_task_suite/summary_report.json",
|
| 105 |
-
"results/episode_task_suite/neural_mlp/",
|
| 106 |
-
"docs/data/summary_metrics.json"
|
| 107 |
-
],
|
| 108 |
-
"readout": "Each of the 12 tasks has minimal-head metrics and a matching neural MLP result over the same window contracts."
|
| 109 |
-
},
|
| 110 |
-
{
|
| 111 |
-
"step": 8,
|
| 112 |
-
"question": "What is the scale-up path?",
|
| 113 |
-
"primary_artifacts": [
|
| 114 |
-
"RESEARCH_ROADMAP.md",
|
| 115 |
-
"docs/data/research_roadmap.json",
|
| 116 |
-
"results/omni_finetune/DATA_ACCESS_STATUS.md",
|
| 117 |
-
"results/omni_finetune/MULTI_EPISODE_ACCESS_STATUS.md",
|
| 118 |
-
"scripts/omni/discover_xperience10m_sources.py",
|
| 119 |
-
"docs/data/omni_finetune_verified_result.json"
|
| 120 |
-
],
|
| 121 |
-
"readout": "The selected-episode held-out Qwen3-Omni v6 diagnostic branch is verified and JSON-format reliability meets the 98% target. The same public comparison also includes the verified 128-episode baselines, Cosmos3-Nano compatibility result, Cosmos3-Super Reasoner evaluation, and Cosmos3-Super Forward-Dynamics LoRA package. The next milestone is action/subtask error analysis and stronger model-quality runs on the same split."
|
| 122 |
-
},
|
| 123 |
-
{
|
| 124 |
-
"step": 9,
|
| 125 |
-
"question": "How can the current 128 episodes be pushed harder?",
|
| 126 |
-
"primary_artifacts": [
|
| 127 |
-
"TASK_SUITE_ENHANCEMENT_128.md",
|
| 128 |
-
"docs/data/task_suite_enhancement_128.json",
|
| 129 |
-
"results/omni_finetune/task_suite_enhancement_128_v1_20260608/enhancement_plan.json",
|
| 130 |
-
"results/omni_finetune/task_suite_enhancement_128_v1_20260608/dense_window_scenarios.csv"
|
| 131 |
-
],
|
| 132 |
-
"readout": "The current selected split can be expanded with dense and multiscale windows without adding episodes. The recommended export target is multiscale_20s10_40s20_80s40, followed by hierarchical action/subtask targets and raw-feature shards for unsupported tasks."
|
| 133 |
-
}
|
| 134 |
-
],
|
| 135 |
-
"project_status": "PROJECT_STATUS.md",
|
| 136 |
-
"project_status_json": "docs/data/project_status.json",
|
| 137 |
-
"research_roadmap": "RESEARCH_ROADMAP.md",
|
| 138 |
-
"research_roadmap_json": "docs/data/research_roadmap.json",
|
| 139 |
-
"evaluation_protocol": "EVALUATION_PROTOCOL.md",
|
| 140 |
-
"evaluation_protocol_json": "docs/data/evaluation_protocol.json",
|
| 141 |
-
"source_alignment_audit": "SOURCE_ALIGNMENT_AUDIT.md",
|
| 142 |
-
"source_alignment_audit_json": "docs/data/source_alignment_audit.json",
|
| 143 |
-
"artifact_guide": "ARTIFACT_GUIDE.md",
|
| 144 |
-
"artifact_index": "docs/data/artifact_index.json",
|
| 145 |
-
"brand_assets": "docs/data/brand_assets.json",
|
| 146 |
-
"figure_index": "FIGURE_INDEX.md",
|
| 147 |
-
"figure_index_json": "docs/data/figure_index.json",
|
| 148 |
-
"reproducibility_matrix": "docs/data/reproducibility_matrix.json",
|
| 149 |
-
"public_surfaces": {
|
| 150 |
-
"github_repo": "https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite",
|
| 151 |
-
"github_pages": "https://chaoyue0307.github.io/ropedia-xperience-10m-task-suite/",
|
| 152 |
-
"hf_space": "https://huggingface.co/spaces/cy0307/ropedia-xperience-10m-task-suite",
|
| 153 |
-
"hf_static_app": "https://cy0307-ropedia-xperience-10m-task-suite.static.hf.space/",
|
| 154 |
-
"hf_artifacts": "https://huggingface.co/datasets/cy0307/ropedia-xperience-10m-task-suite-artifacts",
|
| 155 |
-
"hf_model_baselines": "https://huggingface.co/cy0307/ropedia-xperience-10m-task-baselines"
|
| 156 |
},
|
| 157 |
-
|
| 158 |
-
|
| 159 |
-
|
| 160 |
-
|
| 161 |
-
"
|
| 162 |
-
"
|
| 163 |
-
"
|
| 164 |
-
|
| 165 |
-
|
| 166 |
-
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 167 |
}
|
|
|
|
| 1 |
{
|
| 2 |
+
"title": "Ropedia Xperience-10M Task Suite Project Packet",
|
| 3 |
+
"version": "2026-06-14",
|
| 4 |
+
"scope_status": {
|
| 5 |
+
"validated_data": "one public Xperience-10M sample episode",
|
| 6 |
+
"aligned_frames": 5821,
|
| 7 |
+
"sliding_windows": 1161,
|
| 8 |
+
"current_feature_dimensions": 8546,
|
| 9 |
+
"neural_head_count": 12,
|
| 10 |
+
"direction_extension_probe_count": 4,
|
| 11 |
+
"raw_xperience10m_data_in_repo": false,
|
| 12 |
+
"audio_feature_status": "Audio is one of the synchronized source modalities in the current task representation.",
|
| 13 |
+
"qwen3_omni_32_episode_claim": false,
|
| 14 |
+
"qwen3_omni_status": "The selected 96/16/16 Qwen3-Omni v6 diagnostic branch is verified, meets the strict-JSON target, improves action macro-F1/contact accuracy versus v5, and still has weak action/subtask metrics that guide the next error-analysis pass.",
|
| 15 |
+
"cosmos3_super_forward_dynamics_lora_status": "The first Cosmos3-Super fine-tuned adapter branch is verified as a forward-dynamics LoRA over camera-pose proxy targets; it reports loss metrics, not JSON action-label accuracy.",
|
| 16 |
+
"task_suite_enhancement_128_status": "Current no-new-episode enhancement pack recommends multiscale_20s10_40s20_80s40, hierarchical action/subtask targets, label-normalized scoring, and raw-feature shards before adding more episodes.",
|
| 17 |
+
"task_count": 20,
|
| 18 |
+
"original_public_sample_task_count": 12,
|
| 19 |
+
"additional_public_sample_task_count": 8,
|
| 20 |
+
"legacy_tasks_13_to_20_result_path": "docs/data/tier2_task_suite.json"
|
| 21 |
+
},
|
| 22 |
+
"reading_path": [
|
| 23 |
+
{
|
| 24 |
+
"step": 1,
|
| 25 |
+
"question": "What is the current project scope?",
|
| 26 |
+
"primary_artifacts": [
|
| 27 |
+
"PROJECT_STATUS.md",
|
| 28 |
+
"docs/data/project_status.json",
|
| 29 |
+
"RESEARCH_ROADMAP.md",
|
| 30 |
+
"docs/data/research_roadmap.json",
|
| 31 |
+
"EVIDENCE_CONTRACT.md",
|
| 32 |
+
"ARTIFACT_GUIDE.md",
|
| 33 |
+
"EVALUATION_PROTOCOL.md",
|
| 34 |
+
"FIGURE_INDEX.md",
|
| 35 |
+
"SOURCE_ALIGNMENT_AUDIT.md",
|
| 36 |
+
"XPERIENCE10M_DATASET_CARD_ALIGNMENT.md",
|
| 37 |
+
"docs/data/evidence_contract.json",
|
| 38 |
+
"docs/data/artifact_index.json",
|
| 39 |
+
"docs/data/brand_assets.json",
|
| 40 |
+
"docs/data/evaluation_protocol.json",
|
| 41 |
+
"docs/data/figure_index.json",
|
| 42 |
+
"docs/data/source_alignment_audit.json",
|
| 43 |
+
"docs/data/xperience10m_dataset_card_alignment.json",
|
| 44 |
+
"docs/data/mirror_parity.json",
|
| 45 |
+
"docs/data/publication_audit.json",
|
| 46 |
+
"docs/data/scope_claims_audit.json",
|
| 47 |
+
"docs/data/website_integrity.json",
|
| 48 |
+
"TASK_SUITE_20.md",
|
| 49 |
+
"docs/data/task_suite_20.json"
|
| 50 |
+
],
|
| 51 |
+
"readout": "The project status table and roadmap give the compact current-state summary. Single-episode task engineering, metrics, visualizations, public website integrity, mirror parity, same-split 128-episode baselines, the final selected-episode Qwen3-Omni diagnostic result, the Cosmos3-Nano compatibility package, the Cosmos3-Super base-weight Reasoner evaluation, and the Cosmos3-Super Forward-Dynamics LoRA package are implemented; stronger action/subtask quality and policy-compatible action targets remain follow-ups."
|
| 52 |
},
|
| 53 |
+
{
|
| 54 |
+
"step": 2,
|
| 55 |
+
"question": "What do the official Xperience-10M dataset and sample cards say?",
|
| 56 |
+
"primary_artifacts": [
|
| 57 |
+
"XPERIENCE10M_DATASET_CARD_ALIGNMENT.md",
|
| 58 |
+
"docs/data/xperience10m_dataset_card_alignment.json",
|
| 59 |
+
"https://huggingface.co/datasets/ropedia-ai/xperience-10m",
|
| 60 |
+
"https://huggingface.co/datasets/ropedia-ai/xperience-10m-sample"
|
| 61 |
+
],
|
| 62 |
+
"readout": "The full upstream dataset is a manually gated large-scale 4D multimodal egocentric source. The public sample card records the sample license, HOMIE Toolkit path, and Rerun 0.29.0 visualization path. This repo validates one public sample episode and lists the current project coverage."
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 63 |
},
|
| 64 |
+
{
|
| 65 |
+
"step": 3,
|
| 66 |
+
"question": "Are source facts consistently presented?",
|
| 67 |
+
"primary_artifacts": [
|
| 68 |
+
"SOURCE_ALIGNMENT_AUDIT.md",
|
| 69 |
+
"docs/data/source_alignment_audit.json",
|
| 70 |
+
"scripts/validate_source_alignment.py"
|
| 71 |
+
],
|
| 72 |
+
"readout": "The source-alignment report checks full-dataset metadata, API-listing notes, public sample license/tooling, and project coverage across repo docs, website, and HF cards."
|
| 73 |
+
},
|
| 74 |
+
{
|
| 75 |
+
"step": 4,
|
| 76 |
+
"question": "How exactly are the tasks evaluated?",
|
| 77 |
+
"primary_artifacts": [
|
| 78 |
+
"EVALUATION_PROTOCOL.md",
|
| 79 |
+
"docs/data/evaluation_protocol.json",
|
| 80 |
+
"scripts/build_evaluation_protocol.py"
|
| 81 |
+
],
|
| 82 |
+
"readout": "The protocol fixes the 20-frame window unit, chronological split, train-only normalization, leakage controls, per-task input/target/metric contracts, and current limitations."
|
| 83 |
+
},
|
| 84 |
+
{
|
| 85 |
+
"step": 5,
|
| 86 |
+
"question": "How can the public pipeline be reproduced?",
|
| 87 |
+
"primary_artifacts": [
|
| 88 |
+
"REPRODUCIBILITY.md",
|
| 89 |
+
"docs/data/reproducibility_matrix.json",
|
| 90 |
+
"notes/reproducibility_audit.md"
|
| 91 |
+
],
|
| 92 |
+
"readout": "The public sample pipeline has explicit commands, expected outputs, and a prior exact-match reproduction check over the committed metrics."
|
| 93 |
+
},
|
| 94 |
+
{
|
| 95 |
+
"step": 6,
|
| 96 |
+
"question": "What is inside one model input?",
|
| 97 |
+
"primary_artifacts": [
|
| 98 |
+
"results/episode_task_suite/windows.csv",
|
| 99 |
+
"results/episode_task_suite/feature_manifest.json",
|
| 100 |
+
"results/episode_task_suite/available_modalities.json",
|
| 101 |
+
"docs/data/modality_atlas.json"
|
| 102 |
+
],
|
| 103 |
+
"readout": "The current model input is an 8,546-dimensional aligned multimodal window, and the readable atlas shows each public-sample modality without raw data redistribution."
|
| 104 |
+
},
|
| 105 |
+
{
|
| 106 |
+
"step": 7,
|
| 107 |
+
"question": "Do the task metrics have committed evidence?",
|
| 108 |
+
"primary_artifacts": [
|
| 109 |
+
"results/episode_task_suite/summary_report.json",
|
| 110 |
+
"results/episode_task_suite/neural_mlp/",
|
| 111 |
+
"docs/data/summary_metrics.json"
|
| 112 |
+
],
|
| 113 |
+
"readout": "The unified suite has 20 task contracts; tasks 1-12 have walkthroughs and neural MLP heads, and tasks 13-20 have aligned minimal/neural result bundles under the historical tier2_task_suite path."
|
| 114 |
+
},
|
| 115 |
+
{
|
| 116 |
+
"step": 8,
|
| 117 |
+
"question": "What is the scale-up path?",
|
| 118 |
+
"primary_artifacts": [
|
| 119 |
+
"RESEARCH_ROADMAP.md",
|
| 120 |
+
"docs/data/research_roadmap.json",
|
| 121 |
+
"results/omni_finetune/DATA_ACCESS_STATUS.md",
|
| 122 |
+
"results/omni_finetune/MULTI_EPISODE_ACCESS_STATUS.md",
|
| 123 |
+
"scripts/omni/discover_xperience10m_sources.py",
|
| 124 |
+
"docs/data/omni_finetune_verified_result.json"
|
| 125 |
+
],
|
| 126 |
+
"readout": "The selected-episode held-out Qwen3-Omni v6 diagnostic branch is verified and JSON-format reliability meets the 98% target. The same public comparison also includes the verified 128-episode baselines, Cosmos3-Nano compatibility result, Cosmos3-Super Reasoner evaluation, and Cosmos3-Super Forward-Dynamics LoRA package. The next milestone is action/subtask error analysis and stronger model-quality runs on the same split."
|
| 127 |
+
},
|
| 128 |
+
{
|
| 129 |
+
"step": 9,
|
| 130 |
+
"question": "How can the current 128 episodes be pushed harder?",
|
| 131 |
+
"primary_artifacts": [
|
| 132 |
+
"TASK_SUITE_ENHANCEMENT_128.md",
|
| 133 |
+
"docs/data/task_suite_enhancement_128.json",
|
| 134 |
+
"results/omni_finetune/task_suite_enhancement_128_v1_20260608/enhancement_plan.json",
|
| 135 |
+
"results/omni_finetune/task_suite_enhancement_128_v1_20260608/dense_window_scenarios.csv"
|
| 136 |
+
],
|
| 137 |
+
"readout": "The current selected split can be expanded with dense and multiscale windows without adding episodes. The recommended export target is multiscale_20s10_40s20_80s40, followed by hierarchical action/subtask targets and raw-feature shards for unsupported tasks."
|
| 138 |
+
}
|
| 139 |
+
],
|
| 140 |
+
"project_status": "PROJECT_STATUS.md",
|
| 141 |
+
"project_status_json": "docs/data/project_status.json",
|
| 142 |
+
"research_roadmap": "RESEARCH_ROADMAP.md",
|
| 143 |
+
"research_roadmap_json": "docs/data/research_roadmap.json",
|
| 144 |
+
"evaluation_protocol": "EVALUATION_PROTOCOL.md",
|
| 145 |
+
"evaluation_protocol_json": "docs/data/evaluation_protocol.json",
|
| 146 |
+
"source_alignment_audit": "SOURCE_ALIGNMENT_AUDIT.md",
|
| 147 |
+
"source_alignment_audit_json": "docs/data/source_alignment_audit.json",
|
| 148 |
+
"artifact_guide": "ARTIFACT_GUIDE.md",
|
| 149 |
+
"artifact_index": "docs/data/artifact_index.json",
|
| 150 |
+
"brand_assets": "docs/data/brand_assets.json",
|
| 151 |
+
"figure_index": "FIGURE_INDEX.md",
|
| 152 |
+
"figure_index_json": "docs/data/figure_index.json",
|
| 153 |
+
"reproducibility_matrix": "docs/data/reproducibility_matrix.json",
|
| 154 |
+
"public_surfaces": {
|
| 155 |
+
"github_repo": "https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite",
|
| 156 |
+
"github_pages": "https://chaoyue0307.github.io/ropedia-xperience-10m-task-suite/",
|
| 157 |
+
"hf_space": "https://huggingface.co/spaces/cy0307/ropedia-xperience-10m-task-suite",
|
| 158 |
+
"hf_static_app": "https://cy0307-ropedia-xperience-10m-task-suite.static.hf.space/",
|
| 159 |
+
"hf_artifacts": "https://huggingface.co/datasets/cy0307/ropedia-xperience-10m-task-suite-artifacts",
|
| 160 |
+
"hf_model_baselines": "https://huggingface.co/cy0307/ropedia-xperience-10m-task-baselines"
|
| 161 |
+
},
|
| 162 |
+
"current_reading_notes": [
|
| 163 |
+
"The latest cross-episode Qwen3-Omni v6 diagnostic branch is verified, but strong model quality is not yet shown; action/subtask metrics remain weak and v5 remains stronger on several non-contact metrics.",
|
| 164 |
+
"The current 128-episode suite has a no-new-episode enhancement plan: multiscale_20s10_40s20_80s40 windows, hierarchical labels, label-normalized scoring, and raw-feature shard export.",
|
| 165 |
+
"Cosmos3-Super Forward-Dynamics LoRA is verified as a loss-based world-model adapter branch, not as JSON action-token prediction.",
|
| 166 |
+
"Older Qwen3-Omni setup artifacts are separate from the verified selected-episode diagnostic package.",
|
| 167 |
+
"Feature-vector reconstruction is separate from pixel-depth, mesh, NeRF, or Gaussian reconstruction.",
|
| 168 |
+
"Raw Xperience-10M data is not redistributed in this repo."
|
| 169 |
+
],
|
| 170 |
+
"task_suite_enhancement_128": "TASK_SUITE_ENHANCEMENT_128.md",
|
| 171 |
+
"task_suite_enhancement_128_json": "docs/data/task_suite_enhancement_128.json"
|
| 172 |
}
|
docs/data/project_status.json
CHANGED
|
@@ -1,352 +1,345 @@
|
|
| 1 |
{
|
| 2 |
-
|
| 3 |
-
|
| 4 |
-
|
| 5 |
-
|
| 6 |
-
|
| 7 |
-
|
| 8 |
-
|
| 9 |
-
|
| 10 |
-
|
| 11 |
-
"core_task_count": 12,
|
| 12 |
-
"tier2_extension_task_count": 8,
|
| 13 |
"neural_head_count": 12,
|
| 14 |
-
|
| 15 |
-
|
| 16 |
-
|
| 17 |
-
|
| 18 |
-
|
| 19 |
-
|
| 20 |
-
|
| 21 |
-
|
| 22 |
-
|
| 23 |
-
|
| 24 |
-
|
| 25 |
-
|
| 26 |
-
|
| 27 |
-
|
| 28 |
-
|
| 29 |
-
|
| 30 |
-
|
| 31 |
-
|
| 32 |
-
|
| 33 |
-
|
| 34 |
-
|
| 35 |
-
|
| 36 |
-
|
| 37 |
-
|
| 38 |
-
|
| 39 |
-
|
| 40 |
-
|
| 41 |
-
|
| 42 |
-
|
| 43 |
-
|
| 44 |
-
|
| 45 |
-
|
| 46 |
-
|
| 47 |
-
|
| 48 |
-
|
| 49 |
-
|
| 50 |
-
|
| 51 |
-
|
| 52 |
-
|
| 53 |
-
|
| 54 |
-
|
| 55 |
-
|
| 56 |
-
|
| 57 |
-
|
| 58 |
-
|
| 59 |
-
|
| 60 |
-
|
| 61 |
-
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 62 |
},
|
| 63 |
-
"rows": [
|
| 64 |
-
{
|
| 65 |
-
"area": "Public-sample pipeline",
|
| 66 |
-
"status": "verified",
|
| 67 |
-
"evidence": [
|
| 68 |
-
"results/episode_task_suite/summary_report.json",
|
| 69 |
-
"results/episode_task_suite/windows.csv",
|
| 70 |
-
"results/episode_task_suite/feature_manifest.json"
|
| 71 |
-
],
|
| 72 |
-
"readout": "One public Xperience-10M sample episode is converted into 5,821 frames, 1,161 aligned 20-frame windows, and an 8,546-dimensional representation for repeatable task evaluation."
|
| 73 |
-
},
|
| 74 |
{
|
| 75 |
-
"area": "
|
| 76 |
"status": "verified",
|
| 77 |
-
|
| 78 |
-
|
| 79 |
-
|
| 80 |
-
"docs/data/summary_metrics.json"
|
| 81 |
],
|
| 82 |
-
"readout": "
|
| 83 |
},
|
| 84 |
{
|
| 85 |
-
"area": "
|
| 86 |
"status": "verified",
|
| 87 |
"evidence": [
|
| 88 |
-
"
|
| 89 |
-
"
|
| 90 |
-
"
|
| 91 |
],
|
| 92 |
-
"readout": "
|
| 93 |
},
|
| 94 |
-
|
| 95 |
-
|
| 96 |
-
|
| 97 |
-
|
| 98 |
-
|
| 99 |
-
|
| 100 |
-
|
| 101 |
-
|
| 102 |
-
|
| 103 |
-
|
| 104 |
-
|
| 105 |
-
|
| 106 |
-
|
| 107 |
-
|
| 108 |
-
|
| 109 |
-
|
| 110 |
-
|
| 111 |
-
|
| 112 |
-
|
| 113 |
-
|
| 114 |
-
|
| 115 |
-
|
| 116 |
-
|
| 117 |
-
|
| 118 |
-
|
| 119 |
-
|
| 120 |
-
|
| 121 |
-
|
| 122 |
-
|
| 123 |
-
|
| 124 |
-
|
| 125 |
-
|
| 126 |
-
|
| 127 |
-
|
| 128 |
-
|
| 129 |
-
|
| 130 |
-
|
| 131 |
-
|
| 132 |
-
|
| 133 |
-
|
| 134 |
-
|
| 135 |
-
|
| 136 |
-
|
| 137 |
-
|
| 138 |
-
|
| 139 |
-
|
| 140 |
-
|
| 141 |
-
|
| 142 |
-
|
| 143 |
-
|
| 144 |
-
|
| 145 |
-
|
| 146 |
-
|
| 147 |
-
|
| 148 |
-
|
| 149 |
-
|
| 150 |
-
|
| 151 |
-
|
| 152 |
-
|
| 153 |
-
|
| 154 |
-
|
| 155 |
-
|
| 156 |
-
|
| 157 |
-
|
| 158 |
-
|
| 159 |
-
|
| 160 |
-
|
| 161 |
-
|
| 162 |
-
|
| 163 |
-
|
| 164 |
-
|
| 165 |
-
|
| 166 |
-
|
| 167 |
-
|
| 168 |
-
|
| 169 |
-
|
| 170 |
-
|
| 171 |
-
|
| 172 |
-
|
| 173 |
-
|
| 174 |
-
|
| 175 |
-
|
| 176 |
-
|
| 177 |
-
|
| 178 |
-
|
| 179 |
-
|
| 180 |
-
|
| 181 |
-
|
| 182 |
-
|
| 183 |
-
|
| 184 |
-
|
| 185 |
-
|
| 186 |
-
|
| 187 |
-
|
| 188 |
-
|
| 189 |
-
|
| 190 |
-
|
| 191 |
-
|
| 192 |
-
|
| 193 |
-
|
| 194 |
-
|
| 195 |
-
|
| 196 |
-
|
| 197 |
-
|
| 198 |
-
|
| 199 |
-
|
| 200 |
-
|
| 201 |
-
|
| 202 |
-
|
| 203 |
-
|
| 204 |
-
|
| 205 |
-
|
| 206 |
-
|
| 207 |
-
|
| 208 |
-
|
| 209 |
-
|
| 210 |
-
|
| 211 |
-
|
| 212 |
-
|
| 213 |
-
|
| 214 |
-
|
| 215 |
-
|
| 216 |
-
|
| 217 |
-
|
| 218 |
-
|
| 219 |
-
|
| 220 |
-
|
| 221 |
-
|
| 222 |
-
|
| 223 |
-
|
| 224 |
-
|
| 225 |
-
|
| 226 |
-
|
| 227 |
-
|
| 228 |
-
|
| 229 |
-
|
| 230 |
-
|
| 231 |
-
|
| 232 |
-
|
| 233 |
-
|
| 234 |
-
|
| 235 |
-
|
| 236 |
-
|
| 237 |
-
|
| 238 |
-
|
| 239 |
-
|
| 240 |
-
|
| 241 |
-
|
| 242 |
-
|
| 243 |
-
|
| 244 |
-
|
| 245 |
-
|
| 246 |
-
"scripts/omni/build_omni_model_comparison.py"
|
| 247 |
-
],
|
| 248 |
-
"readout": "The public comparison now has two views: the three result layers and a model-family grouping. The model grouping pairs 1-episode and 128-episode entries for task-head baselines, separates Qwen3-Omni sensor-adapter smoke from 128-episode LoRA diagnostics, separates Cosmos3-Nano future-window compatibility from Cosmos3-Super base-weight Reasoner evaluation, and adds Cosmos3-Super Forward-Dynamics LoRA as a loss-based fine-tuned adapter branch."
|
| 249 |
-
},
|
| 250 |
-
{
|
| 251 |
-
"area": "Qwen3-Omni fine-tuning",
|
| 252 |
-
"status": "final_verified_diagnostic_result_json_target_met",
|
| 253 |
-
"evidence": [
|
| 254 |
-
"docs/data/omni_finetune_verified_result.json",
|
| 255 |
-
"docs/data/qwen3_v5_v6_comparison.json",
|
| 256 |
-
"results/omni_finetune/QWEN3_V5_V6_COMPARISON_20260614.md",
|
| 257 |
-
"results/omni_finetune/verified_public/xperience10m_qwen3_omni_128ep_multiscale_cap96_v6_rank64_lr5e5_full8gpu_lora_eval_test_full/",
|
| 258 |
-
"https://huggingface.co/cy0307/ropedia-qwen3-omni-lora-128ep",
|
| 259 |
-
"scripts/omni/package_verified_omni_result.py",
|
| 260 |
-
"scripts/omni/audit_verified_omni_package.py",
|
| 261 |
-
"scripts/omni/analyze_qwen3_omni_errors.py"
|
| 262 |
-
],
|
| 263 |
-
"readout": "The selected 96/16/16 episode split now has a current v6 rank64/lr5e-5 public-safe held-out package with 34,269 exported windows, 4,032 test predictions, validation/audit summaries, and a public LoRA adapter repo. JSON validity is 99.90%, meeting the 98% target; transition accuracy is 98.98%, contact accuracy is 81.77%, object micro-F1 is 30.65%, next-action accuracy is 4.31%, and action/subtask metrics remain weak. v6 improves action macro-F1 and contact accuracy versus v5, but v5 remains stronger on JSON validity, subtask, next-action, transition, and object metrics."
|
| 264 |
-
},
|
| 265 |
-
{
|
| 266 |
-
"area": "Cosmos3-Nano future-window branch",
|
| 267 |
-
"status": "verified_compatibility_result",
|
| 268 |
-
"evidence": [
|
| 269 |
-
"configs/omni_backbones/cosmos_world_model.json",
|
| 270 |
-
"scripts/omni/export_cosmos3_future_window_dataset.py",
|
| 271 |
-
"scripts/omni/eval_cosmos3_future_window_retrieval.py",
|
| 272 |
-
"results/omni_finetune/verified_public/xperience10m_cosmos3_nano_128ep_future_window_h5_compat_adapter_eval_test_full/verified_result_summary.json"
|
| 273 |
-
],
|
| 274 |
-
"readout": "The Cosmos3-Nano branch now has a public-safe verified future-window compatibility package with 3,213 future-window samples, 378 held-out test predictions, future retrieval MRR 0.0221, temporal consistency 0.0952, transition accuracy 0.9683, and contact accuracy 0.7434. It is a compatibility adapter result, not a full Cosmos diffusion-weight fine-tune."
|
| 275 |
-
},
|
| 276 |
-
{
|
| 277 |
-
"area": "Cosmos3-Super Reasoner branch",
|
| 278 |
-
"status": "verified_base_weight_result",
|
| 279 |
-
"evidence": [
|
| 280 |
-
"configs/omni_backbones/cosmos3_super_reasoner.json",
|
| 281 |
-
"scripts/omni/eval_cosmos3_super_reasoner.py",
|
| 282 |
-
"scripts/omni/run_cosmos3_super_reasoner_eval.sh",
|
| 283 |
-
"results/omni_finetune/verified_public/xperience10m_cosmos3_super_reasoner_128ep_test_full_20260607/verified_result_summary.json"
|
| 284 |
-
],
|
| 285 |
-
"readout": "Cosmos3-Super Reasoner now has a public-safe verified 448-window held-out evaluation on the same structured JSON task as Qwen3. It uses staged nv-community/Cosmos3-Super base weights through an 8-GPU vLLM server, not fine-tuned weights: JSON validity 0.5112, action macro-F1 0.0008, transition accuracy 0.3683, contact accuracy 0.3214, and object micro-F1 0.1370."
|
| 286 |
-
},
|
| 287 |
-
{
|
| 288 |
-
"area": "Cosmos3-Super action-target contract",
|
| 289 |
-
"status": "superseded_by_verified_forward_dynamics_lora",
|
| 290 |
-
"evidence": [
|
| 291 |
-
"scripts/omni/export_cosmos3_camera_pose_targets.py",
|
| 292 |
-
"scripts/omni/pack_cosmos3_super_action_batch.py",
|
| 293 |
-
"results/omni_finetune/xperience10m_cosmos3_camera_pose_targets_20260608/target_manifest.json",
|
| 294 |
-
"results/omni_finetune/xperience10m_cosmos3_super_training_contract_audit_camera_pose_20260608/training_contract_audit.json",
|
| 295 |
-
"results/omni_finetune/xperience10m_cosmos3_super_action_packer_schema_smoke_20260608/packer_summary.json"
|
| 296 |
-
],
|
| 297 |
-
"readout": "The selected 128-episode JSONL is augmented with 3,808/3,808 valid camera_pose proxy cosmos_action_target records from SLAM pose deltas. The contract and packer smoke enabled the verified forward-dynamics LoRA run; it supervises noisy vision tokens under camera-pose conditioning and does not supervise preds_action."
|
| 298 |
-
},
|
| 299 |
-
{
|
| 300 |
-
"area": "Cosmos3-Super Forward-Dynamics LoRA",
|
| 301 |
-
"status": "verified_fine_tuned_adapter_result",
|
| 302 |
-
"evidence": [
|
| 303 |
-
"configs/omni_backbones/cosmos3_super_forward_dynamics.json",
|
| 304 |
-
"scripts/omni/train_cosmos3_super_forward_dynamics_lora.py",
|
| 305 |
-
"scripts/omni/eval_cosmos3_super_forward_dynamics_lora.py",
|
| 306 |
-
"results/omni_finetune/verified_public/xperience10m_cosmos3_super_forward_dynamics_lora_128ep_train1epoch_256_attn_full8gpu_20260608_eval_test_full_fsdp/verified_result_summary.json",
|
| 307 |
-
"results/omni_finetune/verified_public/xperience10m_cosmos3_super_forward_dynamics_lora_128ep_train1epoch_256_attn_full8gpu_20260608_eval_test_full_fsdp/package_audit.json"
|
| 308 |
-
],
|
| 309 |
-
"readout": "The first fine-tuned Cosmos3-Super adapter branch is verified as a public-safe package: 8-GPU FSDP LoRA, 26.2M adapter parameters, 2,848 train rows, 512 validation rows, 448 held-out test rows, validation MSE 4.0082, and test MSE 3.6853. The package excludes adapter safetensors; weights are published separately at cy0307/ropedia-cosmos3-super-forward-dynamics-lora-128ep."
|
| 310 |
-
},
|
| 311 |
-
{
|
| 312 |
-
"area": "Raw Xperience-10M redistribution",
|
| 313 |
-
"status": "not_included",
|
| 314 |
-
"evidence": [
|
| 315 |
-
"DATA_NOTICE.md",
|
| 316 |
-
"docs/data/publication_audit.json"
|
| 317 |
-
],
|
| 318 |
-
"readout": "Raw MP4, HDF5, RRD files, private gated data, and full Qwen weights are intentionally excluded."
|
| 319 |
-
}
|
| 320 |
-
],
|
| 321 |
-
"fast_research_route": [
|
| 322 |
-
"Read PROJECT_STATUS.md and EVIDENCE_CONTRACT.md to establish what is implemented.",
|
| 323 |
-
"Open docs/data/project_packet.json for the machine-readable project path.",
|
| 324 |
-
"Inspect RESEARCH_TAKEAWAYS.md and docs/data/research_takeaways.json before interpreting model scores.",
|
| 325 |
-
"Inspect RESEARCH_ROADMAP.md and docs/data/research_roadmap.json for the path from public-sample task work to multi-episode modeling.",
|
| 326 |
-
"Inspect FOUNDATION_MODEL_PLAN.md and docs/data/foundation_model_plan.json before choosing a backbone branch.",
|
| 327 |
-
"Inspect OMNI_MODEL_EXTENSION_CONTRACT.md and run python scripts/omni/backbone_registry.py --validate --json before adding a new Qwen, Cosmos-style, or VLA/policy branch.",
|
| 328 |
-
"Inspect XPERIENCE_EMBODIED_FOUNDATION_MODEL_PRETRAINING.md for the long-term full-corpus pretraining goal.",
|
| 329 |
-
"Inspect docs/data/summary_metrics.json and results/episode_task_suite/neural_mlp/ to check the 12-task outputs.",
|
| 330 |
-
"Inspect results/audio_ablation/AUDIO_ABLATION_SUMMARY.md before judging whether audio helps the current task suite.",
|
| 331 |
-
"Inspect EVALUATION_PROTOCOL.md before judging task metrics or leakage controls.",
|
| 332 |
-
"Inspect SOURCE_ALIGNMENT_AUDIT.md before judging source-card consistency across public surfaces.",
|
| 333 |
-
"Inspect XPERIENCE10M_DATASET_CARD_ALIGNMENT.md before judging dataset wording.",
|
| 334 |
-
"Inspect results/omni_finetune/multi_episode_128_task_baselines/BASELINE_ALIGNMENT_REPORT.md before comparing simple/NN baselines to the selected 128-episode setup.",
|
| 335 |
-
"Inspect TASK_SUITE_ENHANCEMENT_128.md and docs/data/task_suite_enhancement_128.json before deciding whether more episodes are needed; the current recommended no-new-episode export is multiscale_20s10_40s20_80s40.",
|
| 336 |
-
"Inspect docs/data/omni_model_comparison.json before comparing the current three result versions or the model-family 1-episode versus 128-episode groupings.",
|
| 337 |
-
"Inspect docs/data/omni_finetune_verified_result.json before judging the Qwen3-Omni diagnostic pilot."
|
| 338 |
-
],
|
| 339 |
-
"current_reading_notes": [
|
| 340 |
-
"The latest Qwen3-Omni v6 diagnostic branch is verified and meets the strict-JSON target, but action/subtask held-out quality is still weak: JSON validity is 99.90%, action macro-F1 is 0.0029, and subtask accuracy is 0.0037. v5 remains the pinned prior release row because it is still stronger on several metrics.",
|
| 341 |
-
"Use TASK_SUITE_ENHANCEMENT_128.md and docs/data/task_suite_enhancement_128.json to push the current 128-episode suite without more raw episodes through multiscale_20s10_40s20_80s40, hierarchical labels, label-normalized scoring, and raw-feature shard export.",
|
| 342 |
-
"Use docs/data/omni_model_comparison.json to compare both views: the single-episode/128-baseline/model-branch result layers and the model-family grouping for task heads, Qwen3-Omni LoRA, Cosmos3-Nano, and Cosmos3-Super.",
|
| 343 |
-
"The 128-episode aligned simple/NN baselines use metadata/text features from the derived Qwen JSONL export; they align the split and task ids but do not replace raw-modality baselines for trajectory, retrieval, reconstruction, or misalignment tasks.",
|
| 344 |
-
"The Cosmos3-Nano future-window branch is verified as a compatibility adapter result, Cosmos3-Super Reasoner is verified as a base-weight evaluation, and Cosmos3-Super Forward-Dynamics LoRA is verified as the first fine-tuned Super adapter branch. Cosmos3-Super adapter weights belong in cy0307/ropedia-cosmos3-super-forward-dynamics-lora-128ep; verified_public packages exclude safetensors.",
|
| 345 |
-
"The current reconstruction task reconstructs feature vectors, not pixel-depth, mesh, NeRF, or Gaussian reconstruction.",
|
| 346 |
-
"Audio is one of the synchronized source modalities in the current task representation.",
|
| 347 |
-
"The audio ablation report compares audio/no-audio variants across all 12 task contracts in results/audio_ablation/.",
|
| 348 |
-
"Foundation-model selection is explicit: Qwen3-Omni is the structured JSON baseline, Cosmos 3 is the world-model branch with Nano compatibility and Super forward-dynamics LoRA results, and policy models such as OpenVLA/openpi/GR00T wait for robot-compatible action-target conversion.",
|
| 349 |
-
"Future model branches should be added through the backbone registry and verified package contract, not as one-off result folders with incompatible metrics or publication rules.",
|
| 350 |
-
"The Xperience Embodied Foundation Model is a future native-pretraining goal, not a completed model or current benchmark."
|
| 351 |
-
]
|
| 352 |
}
|
|
|
|
| 1 |
{
|
| 2 |
+
"title": "Ropedia Xperience-10M Task Suite Project Status",
|
| 3 |
+
"version": "2026-06-14",
|
| 4 |
+
"decision": "public_sample_pipeline_verified_128_enhancement_qwen3_v6_cosmos_comparison",
|
| 5 |
+
"research_positioning": "A research-engineering study that makes one public Xperience-10M sample episode inspectable, defines embodied-AI tasks over synchronized modalities, records baseline behavior, aligns simple/NN baselines to the selected 128-episode split, compares verified Qwen3-Omni and Cosmos3 branch packages as early cross-episode diagnostics, and now records a no-new-episode enhancement pack for pushing the current 128-episode suite harder.",
|
| 6 |
+
"scope_boundary": {
|
| 7 |
+
"validated_episode_count": 1,
|
| 8 |
+
"aligned_frames": 5821,
|
| 9 |
+
"sliding_windows": 1161,
|
| 10 |
+
"current_feature_dimensions": 8546,
|
|
|
|
|
|
|
| 11 |
"neural_head_count": 12,
|
| 12 |
+
"direction_extension_probe_count": 4,
|
| 13 |
+
"audio_featurized": true,
|
| 14 |
+
"raw_xperience10m_data_redistributed": false,
|
| 15 |
+
"qwen3_omni_32_episode_claim": false,
|
| 16 |
+
"qwen3_omni_verified_diagnostic_pilot": true,
|
| 17 |
+
"qwen3_omni_selected_episode_counts": {
|
| 18 |
+
"train": 96,
|
| 19 |
+
"val": 16,
|
| 20 |
+
"test": 16
|
| 21 |
+
},
|
| 22 |
+
"qwen3_omni_exported_window_counts": {
|
| 23 |
+
"train": 25629,
|
| 24 |
+
"val": 4608,
|
| 25 |
+
"test": 4032
|
| 26 |
+
},
|
| 27 |
+
"qwen3_omni_json_validity_rate": 0.9990079365079365,
|
| 28 |
+
"qwen3_omni_validation_aware": true,
|
| 29 |
+
"qwen3_omni_json_quality_target_met": true,
|
| 30 |
+
"qwen3_omni_lora_adapter_repo": "https://huggingface.co/cy0307/ropedia-qwen3-omni-lora-128ep",
|
| 31 |
+
"cosmos3_nano_future_window_compatibility_verified": true,
|
| 32 |
+
"cosmos3_nano_future_window_test_predictions": 378,
|
| 33 |
+
"cosmos3_super_reasoner_verified": true,
|
| 34 |
+
"cosmos3_super_reasoner_test_predictions": 448,
|
| 35 |
+
"cosmos3_super_reasoner_json_validity_rate": 0.5111607142857143,
|
| 36 |
+
"cosmos3_super_forward_dynamics_lora_verified": true,
|
| 37 |
+
"cosmos3_super_forward_dynamics_train_rows": 2848,
|
| 38 |
+
"cosmos3_super_forward_dynamics_val_rows": 512,
|
| 39 |
+
"cosmos3_super_forward_dynamics_test_rows": 448,
|
| 40 |
+
"cosmos3_super_forward_dynamics_test_mse": 3.6853174321087345,
|
| 41 |
+
"cosmos3_super_forward_dynamics_adapter_params": 26214400,
|
| 42 |
+
"omni_model_comparison_available": true,
|
| 43 |
+
"multi_episode_128_aligned_baselines": true,
|
| 44 |
+
"multi_episode_128_baseline_window_counts": {
|
| 45 |
+
"train": 2848,
|
| 46 |
+
"val": 512,
|
| 47 |
+
"test": 448
|
| 48 |
+
},
|
| 49 |
+
"multi_episode_128_baseline_task_count": 12,
|
| 50 |
+
"qwen3_omni_current_eval_run_id": "xperience10m_qwen3_omni_128ep_multiscale_cap96_v6_rank64_lr5e5_full8gpu_lora_eval_test_full",
|
| 51 |
+
"qwen3_omni_current_train_epochs": 2,
|
| 52 |
+
"qwen3_omni_action_macro_f1": 0.0028830723979596335,
|
| 53 |
+
"qwen3_omni_subtask_accuracy": 0.0037313432835820895,
|
| 54 |
+
"qwen3_omni_contact_accuracy": 0.8177083333333334,
|
| 55 |
+
"qwen3_omni_object_micro_f1": 0.3064982378331287,
|
| 56 |
+
"task_suite_enhancement_128_available": true,
|
| 57 |
+
"task_suite_enhancement_128_current_windows": 3808,
|
| 58 |
+
"task_suite_enhancement_128_recommended_export": "multiscale_20s10_40s20_80s40",
|
| 59 |
+
"task_suite_enhancement_128_estimated_windows": 106095,
|
| 60 |
+
"task_count": 20,
|
| 61 |
+
"original_public_sample_task_count": 12,
|
| 62 |
+
"additional_public_sample_task_count": 8,
|
| 63 |
+
"legacy_tasks_13_to_20_result_path": "docs/data/tier2_task_suite.json"
|
| 64 |
+
},
|
| 65 |
+
"rows": [
|
| 66 |
+
{
|
| 67 |
+
"area": "Public-sample pipeline",
|
| 68 |
+
"status": "verified",
|
| 69 |
+
"evidence": [
|
| 70 |
+
"results/episode_task_suite/summary_report.json",
|
| 71 |
+
"results/episode_task_suite/windows.csv",
|
| 72 |
+
"results/episode_task_suite/feature_manifest.json"
|
| 73 |
+
],
|
| 74 |
+
"readout": "One public Xperience-10M sample episode is converted into 5,821 frames, 1,161 aligned 20-frame windows, and an 8,546-dimensional representation for repeatable task evaluation."
|
| 75 |
+
},
|
| 76 |
+
{
|
| 77 |
+
"area": "Unified 20-task suite",
|
| 78 |
+
"status": "verified",
|
| 79 |
+
"evidence": [
|
| 80 |
+
"TASK_SUITE_20.md",
|
| 81 |
+
"docs/data/task_suite_20.json",
|
| 82 |
+
"results/episode_task_suite/",
|
| 83 |
+
"results/episode_task_suite/tier2_task_suite/"
|
| 84 |
+
],
|
| 85 |
+
"readout": "All 20 task contracts have committed minimal metrics; tasks 13-20 reuse the same 20-frame windows, 5-frame stride, chronological split, and minimal/neural head pattern. The tier2_task_suite path is historical and now stores tasks 13-20, not a separate public tier."
|
| 86 |
+
},
|
| 87 |
+
{
|
| 88 |
+
"area": "Neural heads",
|
| 89 |
+
"status": "verified",
|
| 90 |
+
"evidence": [
|
| 91 |
+
"scripts/neural_task_models.py",
|
| 92 |
+
"results/episode_task_suite/neural_mlp/"
|
| 93 |
+
],
|
| 94 |
+
"readout": "Each task also has a compact PyTorch MLP run over the same feature tensor and chronological split."
|
| 95 |
+
},
|
| 96 |
+
{
|
| 97 |
+
"area": "Audio contribution study",
|
| 98 |
+
"status": "verified",
|
| 99 |
+
"evidence": [
|
| 100 |
+
"scripts/audio_ablation_and_raw_upgrade.py",
|
| 101 |
+
"results/audio_ablation/",
|
| 102 |
+
"docs/data/audio_ablation_summary.json"
|
| 103 |
+
],
|
| 104 |
+
"readout": "Audio variants improve the primary metric on 6 of 12 task contracts in this single-episode setting."
|
| 105 |
+
},
|
| 106 |
+
{
|
| 107 |
+
"area": "Evaluation protocol",
|
| 108 |
+
"status": "verified",
|
| 109 |
+
"evidence": [
|
| 110 |
+
"EVALUATION_PROTOCOL.md",
|
| 111 |
+
"docs/data/evaluation_protocol.json",
|
| 112 |
+
"scripts/build_evaluation_protocol.py"
|
| 113 |
+
],
|
| 114 |
+
"readout": "Windowing, chronological split, per-task metrics, leakage controls, and current limitations are generated from committed metric artifacts."
|
| 115 |
+
},
|
| 116 |
+
{
|
| 117 |
+
"area": "Research takeaways",
|
| 118 |
+
"status": "verified",
|
| 119 |
+
"evidence": [
|
| 120 |
+
"RESEARCH_TAKEAWAYS.md",
|
| 121 |
+
"docs/data/research_takeaways.json",
|
| 122 |
+
"scripts/build_research_takeaways.py"
|
| 123 |
+
],
|
| 124 |
+
"readout": "The main result interpretation is generated from committed metrics: chronological class shift, neural gains on dynamics/order/alignment, open retrieval/reconstruction problems, and the need for held-out episodes."
|
| 125 |
+
},
|
| 126 |
+
{
|
| 127 |
+
"area": "Research roadmap",
|
| 128 |
+
"status": "current",
|
| 129 |
+
"evidence": [
|
| 130 |
+
"RESEARCH_ROADMAP.md",
|
| 131 |
+
"docs/data/research_roadmap.json"
|
| 132 |
+
],
|
| 133 |
+
"readout": "The roadmap connects public-sample task development to the final verified Qwen3-Omni diagnostic result, same-split baseline alignment, the no-new-episode 128-suite enhancement pack, action/subtask error analysis, robustness runs, world/policy branches, and the future Xperience-native pretraining goal."
|
| 134 |
+
},
|
| 135 |
+
{
|
| 136 |
+
"area": "128-episode task-suite enhancement pack",
|
| 137 |
+
"status": "current_no_new_episode_plan",
|
| 138 |
+
"evidence": [
|
| 139 |
+
"TASK_SUITE_ENHANCEMENT_128.md",
|
| 140 |
+
"docs/data/task_suite_enhancement_128.json",
|
| 141 |
+
"results/omni_finetune/task_suite_enhancement_128_v1_20260608/enhancement_plan.json",
|
| 142 |
+
"scripts/omni/build_task_suite_enhancement_128.py"
|
| 143 |
+
],
|
| 144 |
+
"readout": "The current 3,808-window selected split can be stressed without more episodes by exporting denser and multiscale windows. The recommended next export is multiscale_20s10_40s20_80s40, estimated at 106,095 windows from observed frame spans; the pack also defines hierarchical action/subtask targets, raw-feature shard priorities for unsupported tasks, and Qwen/Cosmos follow-up run cards."
|
| 145 |
+
},
|
| 146 |
+
{
|
| 147 |
+
"area": "Foundation-model plan",
|
| 148 |
+
"status": "current",
|
| 149 |
+
"evidence": [
|
| 150 |
+
"FOUNDATION_MODEL_PLAN.md",
|
| 151 |
+
"docs/data/foundation_model_plan.json"
|
| 152 |
+
],
|
| 153 |
+
"readout": "Qwen3-Omni remains the first structured JSON LoRA baseline; Cosmos 3 is now represented by a verified Cosmos3-Nano future-window compatibility package, a verified Cosmos3-Super base-weight Reasoner evaluation, and a verified Cosmos3-Super Forward-Dynamics LoRA over camera-pose proxy targets. The Super LoRA target supports vision-velocity training under action conditioning, not supervised action-token prediction; OpenVLA/openpi/GR00T remain policy candidates after robot-compatible action targets are explicit."
|
| 154 |
+
},
|
| 155 |
+
{
|
| 156 |
+
"area": "Omni model extension contract",
|
| 157 |
+
"status": "current",
|
| 158 |
+
"evidence": [
|
| 159 |
+
"OMNI_MODEL_EXTENSION_CONTRACT.md",
|
| 160 |
+
"configs/omni_backbones/",
|
| 161 |
+
"scripts/omni/backbone_registry.py",
|
| 162 |
+
"scripts/omni/smoke_test_backbone_packaging.py"
|
| 163 |
+
],
|
| 164 |
+
"readout": "Future Qwen, Cosmos-style, and VLA/policy branches must keep the same episode split discipline, held-out metrics, validation gate, public-safe package contract, and explicit forbidden-artifact policy before reporting results."
|
| 165 |
+
},
|
| 166 |
+
{
|
| 167 |
+
"area": "Xperience Embodied Foundation Model",
|
| 168 |
+
"status": "future_goal",
|
| 169 |
+
"evidence": [
|
| 170 |
+
"XPERIENCE_EMBODIED_FOUNDATION_MODEL_PRETRAINING.md"
|
| 171 |
+
],
|
| 172 |
+
"readout": "A future full-corpus pretraining plan describes target modules, objectives, staged scale-up, hardware ranges, and evaluation for a domain-specific embodied foundation model."
|
| 173 |
},
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 174 |
{
|
| 175 |
+
"area": "Official dataset wording",
|
| 176 |
"status": "verified",
|
| 177 |
+
"evidence": [
|
| 178 |
+
"XPERIENCE10M_DATASET_CARD_ALIGNMENT.md",
|
| 179 |
+
"docs/data/xperience10m_dataset_card_alignment.json"
|
|
|
|
| 180 |
],
|
| 181 |
+
"readout": "Public wording is aligned to the official gated Xperience-10M dataset card, public sample card, and HF API metadata, including modalities, scale, access path, sample license/tooling, and current project coverage."
|
| 182 |
},
|
| 183 |
{
|
| 184 |
+
"area": "Source alignment",
|
| 185 |
"status": "verified",
|
| 186 |
"evidence": [
|
| 187 |
+
"SOURCE_ALIGNMENT_AUDIT.md",
|
| 188 |
+
"docs/data/source_alignment_audit.json",
|
| 189 |
+
"scripts/validate_source_alignment.py"
|
| 190 |
],
|
| 191 |
+
"readout": "Source facts, sample details, API-listing notes, and project coverage are checked across repo docs, website, and HF cards."
|
| 192 |
},
|
| 193 |
+
{
|
| 194 |
+
"area": "Website and HF mirrors",
|
| 195 |
+
"status": "verified",
|
| 196 |
+
"evidence": [
|
| 197 |
+
"docs/data/website_integrity.json",
|
| 198 |
+
"docs/data/mirror_parity.json",
|
| 199 |
+
"docs/data/live_publication_status.json"
|
| 200 |
+
],
|
| 201 |
+
"readout": "Local website links/assets pass, prepared mirrors match, and public GitHub/HF URLs have been checked after upload."
|
| 202 |
+
},
|
| 203 |
+
{
|
| 204 |
+
"area": "Publication package",
|
| 205 |
+
"status": "verified",
|
| 206 |
+
"evidence": [
|
| 207 |
+
"docs/data/publication_audit.json",
|
| 208 |
+
"QUALITY_GATES.md",
|
| 209 |
+
"docs/data/quality_gates.json"
|
| 210 |
+
],
|
| 211 |
+
"readout": "Public bundles are checked for raw-data exclusion, cache exclusion, heavy-archive exclusion, credential-text checks, and current presentation assets."
|
| 212 |
+
},
|
| 213 |
+
{
|
| 214 |
+
"area": "Reproducibility",
|
| 215 |
+
"status": "verified_for_public_sample",
|
| 216 |
+
"evidence": [
|
| 217 |
+
"REPRODUCIBILITY.md",
|
| 218 |
+
"docs/data/reproducibility_matrix.json",
|
| 219 |
+
"notes/reproducibility_audit.md"
|
| 220 |
+
],
|
| 221 |
+
"readout": "The public sample workflow has explicit commands, expected outputs, and exact-match reproduction evidence."
|
| 222 |
+
},
|
| 223 |
+
{
|
| 224 |
+
"area": "128-episode aligned baselines",
|
| 225 |
+
"status": "verified_companion_result",
|
| 226 |
+
"evidence": [
|
| 227 |
+
"results/omni_finetune/multi_episode_128_task_baselines/BASELINE_ALIGNMENT_REPORT.md",
|
| 228 |
+
"results/omni_finetune/multi_episode_128_task_baselines/summary_report.json",
|
| 229 |
+
"scripts/omni/run_128_task_baselines.py"
|
| 230 |
+
],
|
| 231 |
+
"readout": "The earlier simple and neural baseline framing is aligned to the selected 96/16/16 episode split used by the Qwen3-Omni pilot. JSON-supported tasks have metadata/text simple and neural MLP metrics; raw-feature-only tasks are explicitly marked unsupported until 128-run sensor feature blocks are available."
|
| 232 |
+
},
|
| 233 |
+
{
|
| 234 |
+
"area": "Current result comparison",
|
| 235 |
+
"status": "verified_generated_summary",
|
| 236 |
+
"evidence": [
|
| 237 |
+
"docs/data/omni_model_comparison.json",
|
| 238 |
+
"results/omni_finetune/OMNI_MODEL_COMPARISON.md",
|
| 239 |
+
"scripts/omni/build_omni_model_comparison.py"
|
| 240 |
+
],
|
| 241 |
+
"readout": "The public comparison now has two views: the three result layers and a model-family grouping. The model grouping pairs 1-episode and 128-episode entries for task-head baselines, separates Qwen3-Omni sensor-adapter smoke from 128-episode LoRA diagnostics, separates Cosmos3-Nano future-window compatibility from Cosmos3-Super base-weight Reasoner evaluation, and adds Cosmos3-Super Forward-Dynamics LoRA as a loss-based fine-tuned adapter branch."
|
| 242 |
+
},
|
| 243 |
+
{
|
| 244 |
+
"area": "Qwen3-Omni fine-tuning",
|
| 245 |
+
"status": "final_verified_diagnostic_result_json_target_met",
|
| 246 |
+
"evidence": [
|
| 247 |
+
"docs/data/omni_finetune_verified_result.json",
|
| 248 |
+
"docs/data/qwen3_v5_v6_comparison.json",
|
| 249 |
+
"results/omni_finetune/QWEN3_V5_V6_COMPARISON_20260614.md",
|
| 250 |
+
"results/omni_finetune/verified_public/xperience10m_qwen3_omni_128ep_multiscale_cap96_v6_rank64_lr5e5_full8gpu_lora_eval_test_full/",
|
| 251 |
+
"https://huggingface.co/cy0307/ropedia-qwen3-omni-lora-128ep",
|
| 252 |
+
"scripts/omni/package_verified_omni_result.py",
|
| 253 |
+
"scripts/omni/audit_verified_omni_package.py",
|
| 254 |
+
"scripts/omni/analyze_qwen3_omni_errors.py"
|
| 255 |
+
],
|
| 256 |
+
"readout": "The selected 96/16/16 episode split now has a current v6 rank64/lr5e-5 public-safe held-out package with 34,269 exported windows, 4,032 test predictions, validation/audit summaries, and a public LoRA adapter repo. JSON validity is 99.90%, meeting the 98% target; transition accuracy is 98.98%, contact accuracy is 81.77%, object micro-F1 is 30.65%, next-action accuracy is 4.31%, and action/subtask metrics remain weak. v6 improves action macro-F1 and contact accuracy versus v5, but v5 remains stronger on JSON validity, subtask, next-action, transition, and object metrics."
|
| 257 |
+
},
|
| 258 |
+
{
|
| 259 |
+
"area": "Cosmos3-Nano future-window branch",
|
| 260 |
+
"status": "verified_compatibility_result",
|
| 261 |
+
"evidence": [
|
| 262 |
+
"configs/omni_backbones/cosmos_world_model.json",
|
| 263 |
+
"scripts/omni/export_cosmos3_future_window_dataset.py",
|
| 264 |
+
"scripts/omni/eval_cosmos3_future_window_retrieval.py",
|
| 265 |
+
"results/omni_finetune/verified_public/xperience10m_cosmos3_nano_128ep_future_window_h5_compat_adapter_eval_test_full/verified_result_summary.json"
|
| 266 |
+
],
|
| 267 |
+
"readout": "The Cosmos3-Nano branch now has a public-safe verified future-window compatibility package with 3,213 future-window samples, 378 held-out test predictions, future retrieval MRR 0.0221, temporal consistency 0.0952, transition accuracy 0.9683, and contact accuracy 0.7434. It is a compatibility adapter result, not a full Cosmos diffusion-weight fine-tune."
|
| 268 |
+
},
|
| 269 |
+
{
|
| 270 |
+
"area": "Cosmos3-Super Reasoner branch",
|
| 271 |
+
"status": "verified_base_weight_result",
|
| 272 |
+
"evidence": [
|
| 273 |
+
"configs/omni_backbones/cosmos3_super_reasoner.json",
|
| 274 |
+
"scripts/omni/eval_cosmos3_super_reasoner.py",
|
| 275 |
+
"scripts/omni/run_cosmos3_super_reasoner_eval.sh",
|
| 276 |
+
"results/omni_finetune/verified_public/xperience10m_cosmos3_super_reasoner_128ep_test_full_20260607/verified_result_summary.json"
|
| 277 |
+
],
|
| 278 |
+
"readout": "Cosmos3-Super Reasoner now has a public-safe verified 448-window held-out evaluation on the same structured JSON task as Qwen3. It uses staged nv-community/Cosmos3-Super base weights through an 8-GPU vLLM server, not fine-tuned weights: JSON validity 0.5112, action macro-F1 0.0008, transition accuracy 0.3683, contact accuracy 0.3214, and object micro-F1 0.1370."
|
| 279 |
+
},
|
| 280 |
+
{
|
| 281 |
+
"area": "Cosmos3-Super action-target contract",
|
| 282 |
+
"status": "superseded_by_verified_forward_dynamics_lora",
|
| 283 |
+
"evidence": [
|
| 284 |
+
"scripts/omni/export_cosmos3_camera_pose_targets.py",
|
| 285 |
+
"scripts/omni/pack_cosmos3_super_action_batch.py",
|
| 286 |
+
"results/omni_finetune/xperience10m_cosmos3_camera_pose_targets_20260608/target_manifest.json",
|
| 287 |
+
"results/omni_finetune/xperience10m_cosmos3_super_training_contract_audit_camera_pose_20260608/training_contract_audit.json",
|
| 288 |
+
"results/omni_finetune/xperience10m_cosmos3_super_action_packer_schema_smoke_20260608/packer_summary.json"
|
| 289 |
+
],
|
| 290 |
+
"readout": "The selected 128-episode JSONL is augmented with 3,808/3,808 valid camera_pose proxy cosmos_action_target records from SLAM pose deltas. The contract and packer smoke enabled the verified forward-dynamics LoRA run; it supervises noisy vision tokens under camera-pose conditioning and does not supervise preds_action."
|
| 291 |
+
},
|
| 292 |
+
{
|
| 293 |
+
"area": "Cosmos3-Super Forward-Dynamics LoRA",
|
| 294 |
+
"status": "verified_fine_tuned_adapter_result",
|
| 295 |
+
"evidence": [
|
| 296 |
+
"configs/omni_backbones/cosmos3_super_forward_dynamics.json",
|
| 297 |
+
"scripts/omni/train_cosmos3_super_forward_dynamics_lora.py",
|
| 298 |
+
"scripts/omni/eval_cosmos3_super_forward_dynamics_lora.py",
|
| 299 |
+
"results/omni_finetune/verified_public/xperience10m_cosmos3_super_forward_dynamics_lora_128ep_train1epoch_256_attn_full8gpu_20260608_eval_test_full_fsdp/verified_result_summary.json",
|
| 300 |
+
"results/omni_finetune/verified_public/xperience10m_cosmos3_super_forward_dynamics_lora_128ep_train1epoch_256_attn_full8gpu_20260608_eval_test_full_fsdp/package_audit.json"
|
| 301 |
+
],
|
| 302 |
+
"readout": "The first fine-tuned Cosmos3-Super adapter branch is verified as a public-safe package: 8-GPU FSDP LoRA, 26.2M adapter parameters, 2,848 train rows, 512 validation rows, 448 held-out test rows, validation MSE 4.0082, and test MSE 3.6853. The package excludes adapter safetensors; weights are published separately at cy0307/ropedia-cosmos3-super-forward-dynamics-lora-128ep."
|
| 303 |
+
},
|
| 304 |
+
{
|
| 305 |
+
"area": "Raw Xperience-10M redistribution",
|
| 306 |
+
"status": "not_included",
|
| 307 |
+
"evidence": [
|
| 308 |
+
"DATA_NOTICE.md",
|
| 309 |
+
"docs/data/publication_audit.json"
|
| 310 |
+
],
|
| 311 |
+
"readout": "Raw MP4, HDF5, RRD files, private gated data, and full Qwen weights are intentionally excluded."
|
| 312 |
+
}
|
| 313 |
+
],
|
| 314 |
+
"fast_research_route": [
|
| 315 |
+
"Read PROJECT_STATUS.md and EVIDENCE_CONTRACT.md to establish what is implemented.",
|
| 316 |
+
"Open docs/data/project_packet.json for the machine-readable project path.",
|
| 317 |
+
"Inspect RESEARCH_TAKEAWAYS.md and docs/data/research_takeaways.json before interpreting model scores.",
|
| 318 |
+
"Inspect RESEARCH_ROADMAP.md and docs/data/research_roadmap.json for the path from public-sample task work to multi-episode modeling.",
|
| 319 |
+
"Inspect FOUNDATION_MODEL_PLAN.md and docs/data/foundation_model_plan.json before choosing a backbone branch.",
|
| 320 |
+
"Inspect OMNI_MODEL_EXTENSION_CONTRACT.md and run python scripts/omni/backbone_registry.py --validate --json before adding a new Qwen, Cosmos-style, or VLA/policy branch.",
|
| 321 |
+
"Inspect XPERIENCE_EMBODIED_FOUNDATION_MODEL_PRETRAINING.md for the long-term full-corpus pretraining goal.",
|
| 322 |
+
"Inspect TASK_SUITE_20.md, docs/data/task_suite_20.json, docs/data/summary_metrics.json, and results/episode_task_suite/neural_mlp/ to check the unified 20-task outputs.",
|
| 323 |
+
"Inspect results/audio_ablation/AUDIO_ABLATION_SUMMARY.md before judging whether audio helps the current task suite.",
|
| 324 |
+
"Inspect EVALUATION_PROTOCOL.md before judging task metrics or leakage controls.",
|
| 325 |
+
"Inspect SOURCE_ALIGNMENT_AUDIT.md before judging source-card consistency across public surfaces.",
|
| 326 |
+
"Inspect XPERIENCE10M_DATASET_CARD_ALIGNMENT.md before judging dataset wording.",
|
| 327 |
+
"Inspect results/omni_finetune/multi_episode_128_task_baselines/BASELINE_ALIGNMENT_REPORT.md before comparing simple/NN baselines to the selected 128-episode setup.",
|
| 328 |
+
"Inspect TASK_SUITE_ENHANCEMENT_128.md and docs/data/task_suite_enhancement_128.json before deciding whether more episodes are needed; the current recommended no-new-episode export is multiscale_20s10_40s20_80s40.",
|
| 329 |
+
"Inspect docs/data/omni_model_comparison.json before comparing the current three result versions or the model-family 1-episode versus 128-episode groupings.",
|
| 330 |
+
"Inspect docs/data/omni_finetune_verified_result.json before judging the Qwen3-Omni diagnostic pilot."
|
| 331 |
+
],
|
| 332 |
+
"current_reading_notes": [
|
| 333 |
+
"The latest Qwen3-Omni v6 diagnostic branch is verified and meets the strict-JSON target, but action/subtask held-out quality is still weak: JSON validity is 99.90%, action macro-F1 is 0.0029, and subtask accuracy is 0.0037. v5 remains the pinned prior release row because it is still stronger on several metrics.",
|
| 334 |
+
"Use TASK_SUITE_ENHANCEMENT_128.md and docs/data/task_suite_enhancement_128.json to push the current 128-episode suite without more raw episodes through multiscale_20s10_40s20_80s40, hierarchical labels, label-normalized scoring, and raw-feature shard export.",
|
| 335 |
+
"Use docs/data/omni_model_comparison.json to compare both views: the single-episode/128-baseline/model-branch result layers and the model-family grouping for task heads, Qwen3-Omni LoRA, Cosmos3-Nano, and Cosmos3-Super.",
|
| 336 |
+
"The 128-episode aligned simple/NN baselines use metadata/text features from the derived Qwen JSONL export; they align the split and task ids but do not replace raw-modality baselines for trajectory, retrieval, reconstruction, or misalignment tasks.",
|
| 337 |
+
"The Cosmos3-Nano future-window branch is verified as a compatibility adapter result, Cosmos3-Super Reasoner is verified as a base-weight evaluation, and Cosmos3-Super Forward-Dynamics LoRA is verified as the first fine-tuned Super adapter branch. Cosmos3-Super adapter weights belong in cy0307/ropedia-cosmos3-super-forward-dynamics-lora-128ep; verified_public packages exclude safetensors.",
|
| 338 |
+
"The current reconstruction task reconstructs feature vectors, not pixel-depth, mesh, NeRF, or Gaussian reconstruction.",
|
| 339 |
+
"Audio is one of the synchronized source modalities in the current task representation.",
|
| 340 |
+
"The audio ablation report compares audio/no-audio variants across all 12 task contracts in results/audio_ablation/.",
|
| 341 |
+
"Foundation-model selection is explicit: Qwen3-Omni is the structured JSON baseline, Cosmos 3 is the world-model branch with Nano compatibility and Super forward-dynamics LoRA results, and policy models such as OpenVLA/openpi/GR00T wait for robot-compatible action-target conversion.",
|
| 342 |
+
"Future model branches should be added through the backbone registry and verified package contract, not as one-off result folders with incompatible metrics or publication rules.",
|
| 343 |
+
"The Xperience Embodied Foundation Model is a future native-pretraining goal, not a completed model or current benchmark."
|
| 344 |
+
]
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 345 |
}
|
docs/data/public_surface_qa.json
CHANGED
|
@@ -1,7 +1,7 @@
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Public Project Surface",
|
| 3 |
"status": "pass",
|
| 4 |
-
"generated_at_utc": "2026-06-
|
| 5 |
"scope": "Repo README, GitHub Pages HTML, Hugging Face Space card, artifact dataset card, and model card.",
|
| 6 |
"checks": [
|
| 7 |
{
|
|
@@ -18,7 +18,7 @@
|
|
| 18 |
"website_integrity": {
|
| 19 |
"exists": true,
|
| 20 |
"status": "pass",
|
| 21 |
-
"generated_at_utc": "2026-06-
|
| 22 |
},
|
| 23 |
"rendered_site_check": {
|
| 24 |
"exists": true,
|
|
@@ -28,27 +28,27 @@
|
|
| 28 |
"task_surface_integrity": {
|
| 29 |
"exists": true,
|
| 30 |
"status": "pass",
|
| 31 |
-
"generated_at_utc": "2026-06-
|
| 32 |
},
|
| 33 |
"source_alignment": {
|
| 34 |
"exists": true,
|
| 35 |
"status": "pass",
|
| 36 |
-
"generated_at_utc": "2026-06-
|
| 37 |
},
|
| 38 |
"scale_up_status": {
|
| 39 |
"exists": true,
|
| 40 |
"status": "pass",
|
| 41 |
-
"generated_at_utc": "2026-06-
|
| 42 |
},
|
| 43 |
"publication_package": {
|
| 44 |
"exists": true,
|
| 45 |
"status": "pass",
|
| 46 |
-
"generated_at_utc": "2026-06-
|
| 47 |
},
|
| 48 |
"mirror_parity": {
|
| 49 |
"exists": true,
|
| 50 |
"status": "pass",
|
| 51 |
-
"generated_at_utc": "2026-06-
|
| 52 |
}
|
| 53 |
},
|
| 54 |
"failures": {}
|
|
@@ -97,7 +97,7 @@
|
|
| 97 |
"marker_counts": {
|
| 98 |
"Ropedia Xperience-10M Task Suite": 16,
|
| 99 |
"Xperience-10M": 149,
|
| 100 |
-
"
|
| 101 |
"Qwen3-Omni": 143,
|
| 102 |
"128-episode pilot": 1
|
| 103 |
}
|
|
@@ -129,7 +129,8 @@
|
|
| 129 |
"data/public_surface_qa.json": 6,
|
| 130 |
"data/research_roadmap.json": 15,
|
| 131 |
"data/task_suite_enhancement_128.json": 28,
|
| 132 |
-
"data/
|
|
|
|
| 133 |
}
|
| 134 |
},
|
| 135 |
{
|
|
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Public Project Surface",
|
| 3 |
"status": "pass",
|
| 4 |
+
"generated_at_utc": "2026-06-16T04:56:20+00:00",
|
| 5 |
"scope": "Repo README, GitHub Pages HTML, Hugging Face Space card, artifact dataset card, and model card.",
|
| 6 |
"checks": [
|
| 7 |
{
|
|
|
|
| 18 |
"website_integrity": {
|
| 19 |
"exists": true,
|
| 20 |
"status": "pass",
|
| 21 |
+
"generated_at_utc": "2026-06-16T04:49:24+00:00"
|
| 22 |
},
|
| 23 |
"rendered_site_check": {
|
| 24 |
"exists": true,
|
|
|
|
| 28 |
"task_surface_integrity": {
|
| 29 |
"exists": true,
|
| 30 |
"status": "pass",
|
| 31 |
+
"generated_at_utc": "2026-06-16T04:49:21+00:00"
|
| 32 |
},
|
| 33 |
"source_alignment": {
|
| 34 |
"exists": true,
|
| 35 |
"status": "pass",
|
| 36 |
+
"generated_at_utc": "2026-06-16T04:50:14+00:00"
|
| 37 |
},
|
| 38 |
"scale_up_status": {
|
| 39 |
"exists": true,
|
| 40 |
"status": "pass",
|
| 41 |
+
"generated_at_utc": "2026-06-16T04:49:25+00:00"
|
| 42 |
},
|
| 43 |
"publication_package": {
|
| 44 |
"exists": true,
|
| 45 |
"status": "pass",
|
| 46 |
+
"generated_at_utc": "2026-06-16T04:51:36+00:00"
|
| 47 |
},
|
| 48 |
"mirror_parity": {
|
| 49 |
"exists": true,
|
| 50 |
"status": "pass",
|
| 51 |
+
"generated_at_utc": "2026-06-16T04:51:56+00:00"
|
| 52 |
}
|
| 53 |
},
|
| 54 |
"failures": {}
|
|
|
|
| 97 |
"marker_counts": {
|
| 98 |
"Ropedia Xperience-10M Task Suite": 16,
|
| 99 |
"Xperience-10M": 149,
|
| 100 |
+
"20-task": 20,
|
| 101 |
"Qwen3-Omni": 143,
|
| 102 |
"128-episode pilot": 1
|
| 103 |
}
|
|
|
|
| 129 |
"data/public_surface_qa.json": 6,
|
| 130 |
"data/research_roadmap.json": 15,
|
| 131 |
"data/task_suite_enhancement_128.json": 28,
|
| 132 |
+
"data/task_suite_20.json": 42,
|
| 133 |
+
"data/tier2_task_suite.json": 11
|
| 134 |
}
|
| 135 |
},
|
| 136 |
{
|
docs/data/publication_audit.json
CHANGED
|
@@ -1,6 +1,6 @@
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
-
"generated_at_utc": "2026-06-
|
| 4 |
"checks": [
|
| 5 |
{
|
| 6 |
"name": "required_publication_assets_present",
|
|
@@ -57,6 +57,7 @@
|
|
| 57 |
"PUBLIC_SURFACE_QA.md": true,
|
| 58 |
"RENDERED_SITE_CHECK.md": true,
|
| 59 |
"EVALUATION_PROTOCOL.md": true,
|
|
|
|
| 60 |
"FIGURE_INDEX.md": true,
|
| 61 |
"SOURCE_ALIGNMENT_AUDIT.md": true,
|
| 62 |
"XPERIENCE10M_DATASET_CARD_ALIGNMENT.md": true,
|
|
@@ -96,6 +97,7 @@
|
|
| 96 |
"docs/data/task_surface_integrity.json": true,
|
| 97 |
"docs/data/website_integrity.json": true,
|
| 98 |
"docs/data/summary_metrics.json": true,
|
|
|
|
| 99 |
"docs/data/task_suite_enhancement_128.json": true,
|
| 100 |
"docs/assets/modalities/video.jpg": true,
|
| 101 |
"docs/assets/modalities/audio.png": true,
|
|
@@ -124,6 +126,7 @@
|
|
| 124 |
"scripts/build_artifact_index.py": true,
|
| 125 |
"scripts/build_brand_assets.py": true,
|
| 126 |
"scripts/build_evaluation_protocol.py": true,
|
|
|
|
| 127 |
"scripts/build_figure_index.py": true,
|
| 128 |
"scripts/build_quality_gates.py": true,
|
| 129 |
"scripts/build_public_surface_qa.py": true,
|
|
@@ -187,8 +190,8 @@
|
|
| 187 |
"github_repo": {
|
| 188 |
"root": "repo",
|
| 189 |
"exists": true,
|
| 190 |
-
"file_count":
|
| 191 |
-
"text_file_count":
|
| 192 |
"largest_file": {
|
| 193 |
"path": "results/episode_task_suite/modality_reconstruction/predictions.npz",
|
| 194 |
"bytes": 55702978
|
|
@@ -198,8 +201,8 @@
|
|
| 198 |
"hf_space_bundle": {
|
| 199 |
"root": "hf_publish/space",
|
| 200 |
"exists": true,
|
| 201 |
-
"file_count":
|
| 202 |
-
"text_file_count":
|
| 203 |
"largest_file": {
|
| 204 |
"path": "results/episode_task_suite/modality_reconstruction/predictions.npz",
|
| 205 |
"bytes": 55702978
|
|
@@ -209,8 +212,8 @@
|
|
| 209 |
"hf_artifact_bundle": {
|
| 210 |
"root": "hf_publish/artifacts",
|
| 211 |
"exists": true,
|
| 212 |
-
"file_count":
|
| 213 |
-
"text_file_count":
|
| 214 |
"largest_file": {
|
| 215 |
"path": "results/episode_task_suite/modality_reconstruction/predictions.npz",
|
| 216 |
"bytes": 55702978
|
|
@@ -220,8 +223,8 @@
|
|
| 220 |
"hf_model_bundle": {
|
| 221 |
"root": "hf_publish/model",
|
| 222 |
"exists": true,
|
| 223 |
-
"file_count":
|
| 224 |
-
"text_file_count":
|
| 225 |
"largest_file": {
|
| 226 |
"path": "pytorch_model.bin",
|
| 227 |
"bytes": 93495480
|
|
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
+
"generated_at_utc": "2026-06-16T04:57:05+00:00",
|
| 4 |
"checks": [
|
| 5 |
{
|
| 6 |
"name": "required_publication_assets_present",
|
|
|
|
| 57 |
"PUBLIC_SURFACE_QA.md": true,
|
| 58 |
"RENDERED_SITE_CHECK.md": true,
|
| 59 |
"EVALUATION_PROTOCOL.md": true,
|
| 60 |
+
"TASK_SUITE_20.md": true,
|
| 61 |
"FIGURE_INDEX.md": true,
|
| 62 |
"SOURCE_ALIGNMENT_AUDIT.md": true,
|
| 63 |
"XPERIENCE10M_DATASET_CARD_ALIGNMENT.md": true,
|
|
|
|
| 97 |
"docs/data/task_surface_integrity.json": true,
|
| 98 |
"docs/data/website_integrity.json": true,
|
| 99 |
"docs/data/summary_metrics.json": true,
|
| 100 |
+
"docs/data/task_suite_20.json": true,
|
| 101 |
"docs/data/task_suite_enhancement_128.json": true,
|
| 102 |
"docs/assets/modalities/video.jpg": true,
|
| 103 |
"docs/assets/modalities/audio.png": true,
|
|
|
|
| 126 |
"scripts/build_artifact_index.py": true,
|
| 127 |
"scripts/build_brand_assets.py": true,
|
| 128 |
"scripts/build_evaluation_protocol.py": true,
|
| 129 |
+
"scripts/build_unified_task_suite.py": true,
|
| 130 |
"scripts/build_figure_index.py": true,
|
| 131 |
"scripts/build_quality_gates.py": true,
|
| 132 |
"scripts/build_public_surface_qa.py": true,
|
|
|
|
| 190 |
"github_repo": {
|
| 191 |
"root": "repo",
|
| 192 |
"exists": true,
|
| 193 |
+
"file_count": 972,
|
| 194 |
+
"text_file_count": 793,
|
| 195 |
"largest_file": {
|
| 196 |
"path": "results/episode_task_suite/modality_reconstruction/predictions.npz",
|
| 197 |
"bytes": 55702978
|
|
|
|
| 201 |
"hf_space_bundle": {
|
| 202 |
"root": "hf_publish/space",
|
| 203 |
"exists": true,
|
| 204 |
+
"file_count": 757,
|
| 205 |
+
"text_file_count": 617,
|
| 206 |
"largest_file": {
|
| 207 |
"path": "results/episode_task_suite/modality_reconstruction/predictions.npz",
|
| 208 |
"bytes": 55702978
|
|
|
|
| 212 |
"hf_artifact_bundle": {
|
| 213 |
"root": "hf_publish/artifacts",
|
| 214 |
"exists": true,
|
| 215 |
+
"file_count": 1829,
|
| 216 |
+
"text_file_count": 793,
|
| 217 |
"largest_file": {
|
| 218 |
"path": "results/episode_task_suite/modality_reconstruction/predictions.npz",
|
| 219 |
"bytes": 55702978
|
|
|
|
| 223 |
"hf_model_bundle": {
|
| 224 |
"root": "hf_publish/model",
|
| 225 |
"exists": true,
|
| 226 |
+
"file_count": 2246,
|
| 227 |
+
"text_file_count": 951,
|
| 228 |
"largest_file": {
|
| 229 |
"path": "pytorch_model.bin",
|
| 230 |
"bytes": 93495480
|
docs/data/quality_gates.json
CHANGED
|
@@ -1,7 +1,7 @@
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Release Checks",
|
| 3 |
"status": "pass",
|
| 4 |
-
"generated_at_utc": "2026-06-
|
| 5 |
"rule": "A release is current when the automated reports pass and the live GitHub/Hugging Face mirrors are verified after publishing.",
|
| 6 |
"automated_gates": [
|
| 7 |
{
|
|
@@ -58,7 +58,7 @@
|
|
| 58 |
"command": "python scripts/validate_task_surface.py",
|
| 59 |
"report": "docs/data/task_surface_integrity.json",
|
| 60 |
"blocks_if": "Task cards expose raw artifact ids, human-readable task names drift, modality thumbnails are missing, or the interactive task player is not wired to the generated JSON.",
|
| 61 |
-
"shows": "The public task cards and walkthrough/player stay aligned with generated
|
| 62 |
"current_report": {
|
| 63 |
"exists": true,
|
| 64 |
"status": "pass"
|
|
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Release Checks",
|
| 3 |
"status": "pass",
|
| 4 |
+
"generated_at_utc": "2026-06-16T04:56:20+00:00",
|
| 5 |
"rule": "A release is current when the automated reports pass and the live GitHub/Hugging Face mirrors are verified after publishing.",
|
| 6 |
"automated_gates": [
|
| 7 |
{
|
|
|
|
| 58 |
"command": "python scripts/validate_task_surface.py",
|
| 59 |
"report": "docs/data/task_surface_integrity.json",
|
| 60 |
"blocks_if": "Task cards expose raw artifact ids, human-readable task names drift, modality thumbnails are missing, or the interactive task player is not wired to the generated JSON.",
|
| 61 |
+
"shows": "The public task cards and walkthrough/player stay aligned with generated task-suite metadata.",
|
| 62 |
"current_report": {
|
| 63 |
"exists": true,
|
| 64 |
"status": "pass"
|
docs/data/reproducibility_matrix.json
CHANGED
|
@@ -36,10 +36,10 @@
|
|
| 36 |
"boundary": "single-episode chronological split"
|
| 37 |
},
|
| 38 |
{
|
| 39 |
-
"id": "
|
| 40 |
"status": "reproducible",
|
| 41 |
"command": "python scripts/episode_task_suite.py --workspace $WORKSPACE --include-neural",
|
| 42 |
-
"expected": "
|
| 43 |
"boundary": "8,546-dimensional multimodal window contract"
|
| 44 |
},
|
| 45 |
{
|
|
@@ -50,11 +50,11 @@
|
|
| 50 |
"boundary": "single-episode probes, not full research-direction solutions"
|
| 51 |
},
|
| 52 |
{
|
| 53 |
-
"id": "
|
| 54 |
"status": "reproducible",
|
| 55 |
-
"command": "python scripts/tier2_task_suite.py",
|
| 56 |
-
"expected": "
|
| 57 |
-
"boundary": "requires local public-sample annotation.hdf5 plus HOMIE Toolkit or h5py; raw HDF5 and MP4 files are not redistributed"
|
| 58 |
},
|
| 59 |
{
|
| 60 |
"id": "source_alignment_audit",
|
|
|
|
| 36 |
"boundary": "single-episode chronological split"
|
| 37 |
},
|
| 38 |
{
|
| 39 |
+
"id": "original_task_suite",
|
| 40 |
"status": "reproducible",
|
| 41 |
"command": "python scripts/episode_task_suite.py --workspace $WORKSPACE --include-neural",
|
| 42 |
+
"expected": "original task metrics, predictions, manifests, and neural_mlp task-head artifacts",
|
| 43 |
"boundary": "8,546-dimensional multimodal window contract"
|
| 44 |
},
|
| 45 |
{
|
|
|
|
| 50 |
"boundary": "single-episode probes, not full research-direction solutions"
|
| 51 |
},
|
| 52 |
{
|
| 53 |
+
"id": "tasks_13_to_20_and_unified_index",
|
| 54 |
"status": "reproducible",
|
| 55 |
+
"command": "python scripts/tier2_task_suite.py && python scripts/build_unified_task_suite.py",
|
| 56 |
+
"expected": "tasks 13-20 metrics, prediction/rank artifacts, TASK_SUITE_20.md, docs/data/task_suite_20.json, docs/data/tier2_task_suite.json, and docs/assets/charts/tier2_task_suite.svg",
|
| 57 |
+
"boundary": "requires local public-sample annotation.hdf5 plus HOMIE Toolkit or h5py for tasks 13-20; raw HDF5 and MP4 files are not redistributed"
|
| 58 |
},
|
| 59 |
{
|
| 60 |
"id": "source_alignment_audit",
|
docs/data/scope_claims_audit.json
CHANGED
|
@@ -1,6 +1,6 @@
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
-
"generated_at_utc": "2026-06-
|
| 4 |
"summary": {
|
| 5 |
"qwen3_omni_verified_diagnostic_pilot": true,
|
| 6 |
"dataset_manifest_num_episodes": 119,
|
|
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
+
"generated_at_utc": "2026-06-16T04:56:59+00:00",
|
| 4 |
"summary": {
|
| 5 |
"qwen3_omni_verified_diagnostic_pilot": true,
|
| 6 |
"dataset_manifest_num_episodes": 119,
|
docs/data/source_alignment_audit.json
CHANGED
|
@@ -1,7 +1,7 @@
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Source Alignment Note",
|
| 3 |
"status": "pass",
|
| 4 |
-
"generated_at_utc": "2026-06-
|
| 5 |
"alignment_json": "docs/data/xperience10m_dataset_card_alignment.json",
|
| 6 |
"alignment_summary": {
|
| 7 |
"full_dataset_repo": "ropedia-ai/xperience-10m",
|
|
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Source Alignment Note",
|
| 3 |
"status": "pass",
|
| 4 |
+
"generated_at_utc": "2026-06-16T04:56:56+00:00",
|
| 5 |
"alignment_json": "docs/data/xperience10m_dataset_card_alignment.json",
|
| 6 |
"alignment_summary": {
|
| 7 |
"full_dataset_repo": "ropedia-ai/xperience-10m",
|
docs/data/task_suite_20.json
ADDED
|
@@ -0,0 +1,723 @@
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
+
{
|
| 2 |
+
"title": "Ropedia Xperience-10M Unified 20-Task Suite",
|
| 3 |
+
"status": "pass",
|
| 4 |
+
"generated_at_utc": "2026-06-16T04:47:33+00:00",
|
| 5 |
+
"task_count": 20,
|
| 6 |
+
"task_count_breakdown": {
|
| 7 |
+
"original_public_sample_tasks": 12,
|
| 8 |
+
"additional_public_sample_tasks": 8,
|
| 9 |
+
"total_unified_tasks": 20
|
| 10 |
+
},
|
| 11 |
+
"unification_policy": {
|
| 12 |
+
"public_framing": "The suite is presented as one 20-task benchmark surface. Tasks 1-12 are the original public-sample tasks; tasks 13-20 are additional sample-supported tasks that use the same window/split/baseline contract.",
|
| 13 |
+
"legacy_path_note": "The directory and file name tier2_task_suite are retained only for backward-compatible artifact links; they are not a separate public benchmark tier."
|
| 14 |
+
},
|
| 15 |
+
"dataset_scope": {
|
| 16 |
+
"sample_episode_count": 1,
|
| 17 |
+
"annotation": "data/sample/xperience-10m-sample/annotation.hdf5",
|
| 18 |
+
"num_frames": 5821,
|
| 19 |
+
"num_windows": 1161,
|
| 20 |
+
"feature_dim": 8546,
|
| 21 |
+
"window_frames": 20,
|
| 22 |
+
"stride_frames": 5,
|
| 23 |
+
"split_policy": "single_episode_chronological_70_30",
|
| 24 |
+
"raw_hdf5_required_for_tasks_13_20_regeneration": true,
|
| 25 |
+
"raw_data_redistributed": false
|
| 26 |
+
},
|
| 27 |
+
"setup_alignment": {
|
| 28 |
+
"same_window_unit": "20-frame aligned windows",
|
| 29 |
+
"same_stride": "5 frames",
|
| 30 |
+
"same_feature_manifest": "results/episode_task_suite/feature_manifest.json",
|
| 31 |
+
"same_shared_tensor": "results/episode_task_suite/shared_windows.npz",
|
| 32 |
+
"same_split": "chronological 70/30 train/test split within the public sample episode",
|
| 33 |
+
"same_baseline_pattern": "minimal interpretable heads plus compact neural MLP heads",
|
| 34 |
+
"same_leakage_policy": "Target-side future, contact, object, caption, relation, and interaction signals are excluded from inputs unless language is explicitly the query."
|
| 35 |
+
},
|
| 36 |
+
"source_files": [
|
| 37 |
+
"docs/data/summary_metrics.json",
|
| 38 |
+
"docs/data/task_walkthroughs.json",
|
| 39 |
+
"docs/data/tier2_task_suite.json",
|
| 40 |
+
"results/episode_task_suite/summary_report.json",
|
| 41 |
+
"results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 42 |
+
"results/episode_task_suite/windows.csv",
|
| 43 |
+
"results/episode_task_suite/feature_manifest.json"
|
| 44 |
+
],
|
| 45 |
+
"tasks": [
|
| 46 |
+
{
|
| 47 |
+
"task_id": "timeline_action",
|
| 48 |
+
"task_display_name": "Action Recognition",
|
| 49 |
+
"research_name": "Egocentric Action Recognition",
|
| 50 |
+
"origin": "original_public_sample_tasks",
|
| 51 |
+
"origin_count_label": "original task",
|
| 52 |
+
"family": "supervised",
|
| 53 |
+
"architecture_family": "multiclass classifier",
|
| 54 |
+
"primary_direction": "C. Egocentric Vision & Interaction",
|
| 55 |
+
"input": "One 20-frame window represented by the current feature vector: video/audio/depth summaries, pose, SLAM/camera pose, motion capture, IMU, calibration, and language-derived context.",
|
| 56 |
+
"input_short": "20-frame multimodal window",
|
| 57 |
+
"process": "window features -> action label builder -> classifier",
|
| 58 |
+
"output": "A single action class for the current window.",
|
| 59 |
+
"output_short": "current action class",
|
| 60 |
+
"metric_key": "macro_f1",
|
| 61 |
+
"metric_name": "macro-F1",
|
| 62 |
+
"metric_direction": "higher",
|
| 63 |
+
"minimal_primary_metric": 0.05,
|
| 64 |
+
"neural_primary_metric": 0.014814814814814814,
|
| 65 |
+
"counts": {
|
| 66 |
+
"num_windows": 1144,
|
| 67 |
+
"num_eval_windows": 343,
|
| 68 |
+
"num_train_windows": 801,
|
| 69 |
+
"num_test_windows": 343,
|
| 70 |
+
"num_classes": 18
|
| 71 |
+
},
|
| 72 |
+
"meaning": "Recognize the current manipulation action from synchronized visual, motion, inertial, pose, and annotation context.",
|
| 73 |
+
"artifact_sources": {
|
| 74 |
+
"walkthrough": "results/episode_task_suite/task_walkthroughs/timeline_action.md",
|
| 75 |
+
"minimal_metrics": "results/episode_task_suite/timeline_action/metrics.json",
|
| 76 |
+
"neural_metrics": "results/episode_task_suite/neural_mlp/timeline_action/metrics.json"
|
| 77 |
+
},
|
| 78 |
+
"task_number": 1,
|
| 79 |
+
"suite_label": "Task 01"
|
| 80 |
+
},
|
| 81 |
+
{
|
| 82 |
+
"task_id": "timeline_subtask",
|
| 83 |
+
"task_display_name": "Procedure Step Recognition",
|
| 84 |
+
"research_name": "Temporal Subtask Recognition",
|
| 85 |
+
"origin": "original_public_sample_tasks",
|
| 86 |
+
"origin_count_label": "original task",
|
| 87 |
+
"family": "supervised",
|
| 88 |
+
"architecture_family": "multiclass classifier",
|
| 89 |
+
"primary_direction": "C. Egocentric Vision & Interaction",
|
| 90 |
+
"input": "The same all-modality window vector used by action recognition.",
|
| 91 |
+
"input_short": "20-frame multimodal window",
|
| 92 |
+
"process": "window features -> subtask label builder -> classifier",
|
| 93 |
+
"output": "A single subtask label for the current window.",
|
| 94 |
+
"output_short": "current procedure step",
|
| 95 |
+
"metric_key": "macro_f1",
|
| 96 |
+
"metric_name": "macro-F1",
|
| 97 |
+
"metric_direction": "higher",
|
| 98 |
+
"minimal_primary_metric": 0.05056355513846935,
|
| 99 |
+
"neural_primary_metric": 0.02810810810810811,
|
| 100 |
+
"counts": {
|
| 101 |
+
"num_windows": 1147,
|
| 102 |
+
"num_eval_windows": 344,
|
| 103 |
+
"num_train_windows": 803,
|
| 104 |
+
"num_test_windows": 344,
|
| 105 |
+
"num_classes": 14
|
| 106 |
+
},
|
| 107 |
+
"meaning": "Recognize the broader activity stage so fine actions become a readable procedure timeline.",
|
| 108 |
+
"artifact_sources": {
|
| 109 |
+
"walkthrough": "results/episode_task_suite/task_walkthroughs/timeline_subtask.md",
|
| 110 |
+
"minimal_metrics": "results/episode_task_suite/timeline_subtask/metrics.json",
|
| 111 |
+
"neural_metrics": "results/episode_task_suite/neural_mlp/timeline_subtask/metrics.json"
|
| 112 |
+
},
|
| 113 |
+
"task_number": 2,
|
| 114 |
+
"suite_label": "Task 02"
|
| 115 |
+
},
|
| 116 |
+
{
|
| 117 |
+
"task_id": "transition_detection",
|
| 118 |
+
"task_display_name": "Action Boundary Detection",
|
| 119 |
+
"research_name": "Temporal Action Segmentation",
|
| 120 |
+
"origin": "original_public_sample_tasks",
|
| 121 |
+
"origin_count_label": "original task",
|
| 122 |
+
"family": "diagnostic",
|
| 123 |
+
"architecture_family": "binary classifier",
|
| 124 |
+
"primary_direction": "C. Egocentric Vision & Interaction",
|
| 125 |
+
"input": "One all-modality window vector plus labels derived from action-change timestamps.",
|
| 126 |
+
"input_short": "current window with boundary target",
|
| 127 |
+
"process": "action changes -> boundary labels -> binary classifier",
|
| 128 |
+
"output": "A binary label: boundary or steady.",
|
| 129 |
+
"output_short": "boundary or steady",
|
| 130 |
+
"metric_key": "macro_f1",
|
| 131 |
+
"metric_name": "macro-F1",
|
| 132 |
+
"metric_direction": "higher",
|
| 133 |
+
"minimal_primary_metric": 0.6118237590630229,
|
| 134 |
+
"neural_primary_metric": 0.5862068965517241,
|
| 135 |
+
"counts": {
|
| 136 |
+
"num_windows": 1161,
|
| 137 |
+
"num_eval_windows": 348,
|
| 138 |
+
"num_train_windows": 813,
|
| 139 |
+
"num_test_windows": 348,
|
| 140 |
+
"num_classes": 2
|
| 141 |
+
},
|
| 142 |
+
"meaning": "Detect the local moment where the episode changes from one action segment to the next.",
|
| 143 |
+
"artifact_sources": {
|
| 144 |
+
"walkthrough": "results/episode_task_suite/task_walkthroughs/transition_detection.md",
|
| 145 |
+
"minimal_metrics": "results/episode_task_suite/transition_detection/metrics.json",
|
| 146 |
+
"neural_metrics": "results/episode_task_suite/neural_mlp/transition_detection/metrics.json"
|
| 147 |
+
},
|
| 148 |
+
"task_number": 3,
|
| 149 |
+
"suite_label": "Task 03"
|
| 150 |
+
},
|
| 151 |
+
{
|
| 152 |
+
"task_id": "next_action",
|
| 153 |
+
"task_display_name": "Next-Action Prediction",
|
| 154 |
+
"research_name": "Short-Horizon Intention Prediction",
|
| 155 |
+
"origin": "original_public_sample_tasks",
|
| 156 |
+
"origin_count_label": "original task",
|
| 157 |
+
"family": "supervised",
|
| 158 |
+
"architecture_family": "future-label classifier",
|
| 159 |
+
"primary_direction": "C. Egocentric Vision & Interaction",
|
| 160 |
+
"input": "The current all-modality window vector at time t.",
|
| 161 |
+
"input_short": "current window at time t",
|
| 162 |
+
"process": "current features -> future label shift -> classifier",
|
| 163 |
+
"output": "A single action class for t+20 frames.",
|
| 164 |
+
"output_short": "action at t+20 frames",
|
| 165 |
+
"metric_key": "macro_f1",
|
| 166 |
+
"metric_name": "macro-F1",
|
| 167 |
+
"metric_direction": "higher",
|
| 168 |
+
"minimal_primary_metric": 0.05925925925925927,
|
| 169 |
+
"neural_primary_metric": 0.04186046511627907,
|
| 170 |
+
"counts": {
|
| 171 |
+
"num_windows": 1161,
|
| 172 |
+
"num_eval_windows": 348,
|
| 173 |
+
"num_train_windows": 813,
|
| 174 |
+
"num_test_windows": 348,
|
| 175 |
+
"num_classes": 18
|
| 176 |
+
},
|
| 177 |
+
"meaning": "Forecast the near-future action from the current observations only.",
|
| 178 |
+
"artifact_sources": {
|
| 179 |
+
"walkthrough": "results/episode_task_suite/task_walkthroughs/next_action.md",
|
| 180 |
+
"minimal_metrics": "results/episode_task_suite/next_action/metrics.json",
|
| 181 |
+
"neural_metrics": "results/episode_task_suite/neural_mlp/next_action/metrics.json"
|
| 182 |
+
},
|
| 183 |
+
"task_number": 4,
|
| 184 |
+
"suite_label": "Task 04"
|
| 185 |
+
},
|
| 186 |
+
{
|
| 187 |
+
"task_id": "hand_trajectory_forecast",
|
| 188 |
+
"task_display_name": "Hand Trajectory Forecasting",
|
| 189 |
+
"research_name": "3D Hand Motion Forecasting",
|
| 190 |
+
"origin": "original_public_sample_tasks",
|
| 191 |
+
"origin_count_label": "original task",
|
| 192 |
+
"family": "forecast",
|
| 193 |
+
"architecture_family": "continuous regressor",
|
| 194 |
+
"primary_direction": "A. Human Modeling & Motion Understanding",
|
| 195 |
+
"input": "The current all-modality window vector at time t.",
|
| 196 |
+
"input_short": "current multimodal window",
|
| 197 |
+
"process": "current features -> future mocap target -> regression head",
|
| 198 |
+
"output": "A future trajectory vector for left and right hand joints.",
|
| 199 |
+
"output_short": "future hand-joint trajectory",
|
| 200 |
+
"metric_key": "mpjpe",
|
| 201 |
+
"metric_name": "MPJPE",
|
| 202 |
+
"metric_direction": "lower",
|
| 203 |
+
"minimal_primary_metric": 0.8646570444107056,
|
| 204 |
+
"neural_primary_metric": 0.10785018652677536,
|
| 205 |
+
"counts": {
|
| 206 |
+
"num_windows": 1159,
|
| 207 |
+
"num_train_windows": 811,
|
| 208 |
+
"num_test_windows": 348
|
| 209 |
+
},
|
| 210 |
+
"meaning": "Predict the future 3D left/right hand path from the current multimodal state.",
|
| 211 |
+
"artifact_sources": {
|
| 212 |
+
"walkthrough": "results/episode_task_suite/task_walkthroughs/hand_trajectory_forecast.md",
|
| 213 |
+
"minimal_metrics": "results/episode_task_suite/hand_trajectory_forecast/metrics.json",
|
| 214 |
+
"neural_metrics": "results/episode_task_suite/neural_mlp/hand_trajectory_forecast/metrics.json"
|
| 215 |
+
},
|
| 216 |
+
"task_number": 5,
|
| 217 |
+
"suite_label": "Task 05"
|
| 218 |
+
},
|
| 219 |
+
{
|
| 220 |
+
"task_id": "contact_prediction",
|
| 221 |
+
"task_display_name": "Contact State Prediction",
|
| 222 |
+
"research_name": "Human-Object Contact Prediction",
|
| 223 |
+
"origin": "original_public_sample_tasks",
|
| 224 |
+
"origin_count_label": "original task",
|
| 225 |
+
"family": "supervised",
|
| 226 |
+
"architecture_family": "binary classifier",
|
| 227 |
+
"primary_direction": "A. Human Modeling & Motion Understanding",
|
| 228 |
+
"input": "Non-contact and non-caption feature blocks, so the answer is not directly leaked from the target labels.",
|
| 229 |
+
"input_short": "non-contact, non-caption features",
|
| 230 |
+
"process": "feature filter -> contact target -> binary classifier",
|
| 231 |
+
"output": "A binary contact label.",
|
| 232 |
+
"output_short": "contact or no contact",
|
| 233 |
+
"metric_key": "macro_f1",
|
| 234 |
+
"metric_name": "macro-F1",
|
| 235 |
+
"metric_direction": "higher",
|
| 236 |
+
"minimal_primary_metric": 1.0,
|
| 237 |
+
"neural_primary_metric": 1.0,
|
| 238 |
+
"counts": {
|
| 239 |
+
"num_windows": 1161,
|
| 240 |
+
"num_eval_windows": 348,
|
| 241 |
+
"num_train_windows": 813,
|
| 242 |
+
"num_test_windows": 348,
|
| 243 |
+
"num_classes": 1
|
| 244 |
+
},
|
| 245 |
+
"meaning": "Predict whether body or hand contact with the scene is occurring without leaking contact labels.",
|
| 246 |
+
"artifact_sources": {
|
| 247 |
+
"walkthrough": "results/episode_task_suite/task_walkthroughs/contact_prediction.md",
|
| 248 |
+
"minimal_metrics": "results/episode_task_suite/contact_prediction/metrics.json",
|
| 249 |
+
"neural_metrics": "results/episode_task_suite/neural_mlp/contact_prediction/metrics.json"
|
| 250 |
+
},
|
| 251 |
+
"task_number": 6,
|
| 252 |
+
"suite_label": "Task 06"
|
| 253 |
+
},
|
| 254 |
+
{
|
| 255 |
+
"task_id": "object_relevance",
|
| 256 |
+
"task_display_name": "Object Relevance Prediction",
|
| 257 |
+
"research_name": "Object-Centric Interaction Recognition",
|
| 258 |
+
"origin": "original_public_sample_tasks",
|
| 259 |
+
"origin_count_label": "original task",
|
| 260 |
+
"family": "supervised",
|
| 261 |
+
"architecture_family": "multi-label classifier",
|
| 262 |
+
"primary_direction": "C. Egocentric Vision & Interaction",
|
| 263 |
+
"input": "Non-caption feature blocks, so the model must infer objects from sensors rather than copying the caption words.",
|
| 264 |
+
"input_short": "non-caption multimodal features",
|
| 265 |
+
"process": "object vocabulary -> multi-hot labels -> sigmoid heads",
|
| 266 |
+
"output": "A multi-label object set for the current window.",
|
| 267 |
+
"output_short": "relevant object set",
|
| 268 |
+
"metric_key": "micro_f1",
|
| 269 |
+
"metric_name": "micro-F1",
|
| 270 |
+
"metric_direction": "higher",
|
| 271 |
+
"minimal_primary_metric": 0.18034382095361662,
|
| 272 |
+
"neural_primary_metric": 0.1679279279279279,
|
| 273 |
+
"counts": {
|
| 274 |
+
"num_windows": 1161,
|
| 275 |
+
"num_train_windows": 813,
|
| 276 |
+
"num_test_windows": 348
|
| 277 |
+
},
|
| 278 |
+
"meaning": "Infer which objects are relevant to the current manipulation window from non-caption features.",
|
| 279 |
+
"artifact_sources": {
|
| 280 |
+
"walkthrough": "results/episode_task_suite/task_walkthroughs/object_relevance.md",
|
| 281 |
+
"minimal_metrics": "results/episode_task_suite/object_relevance/metrics.json",
|
| 282 |
+
"neural_metrics": "results/episode_task_suite/neural_mlp/object_relevance/metrics.json"
|
| 283 |
+
},
|
| 284 |
+
"task_number": 7,
|
| 285 |
+
"suite_label": "Task 07"
|
| 286 |
+
},
|
| 287 |
+
{
|
| 288 |
+
"task_id": "caption_grounding",
|
| 289 |
+
"task_display_name": "Language Grounding",
|
| 290 |
+
"research_name": "Language-to-Moment Grounding",
|
| 291 |
+
"origin": "original_public_sample_tasks",
|
| 292 |
+
"origin_count_label": "original task",
|
| 293 |
+
"family": "retrieval",
|
| 294 |
+
"architecture_family": "retrieval ranker",
|
| 295 |
+
"primary_direction": "C. Egocentric Vision & Interaction",
|
| 296 |
+
"input": "Caption/object/interaction query features and a set of candidate sensor-window features.",
|
| 297 |
+
"input_short": "text-like query and candidate windows",
|
| 298 |
+
"process": "query features -> candidate index -> cosine ranker",
|
| 299 |
+
"output": "A ranked list of windows, with the correct matching window ideally near rank 1.",
|
| 300 |
+
"output_short": "ranked matching moments",
|
| 301 |
+
"metric_key": "mrr",
|
| 302 |
+
"metric_name": "MRR",
|
| 303 |
+
"metric_direction": "higher",
|
| 304 |
+
"minimal_primary_metric": 0.016023479050338015,
|
| 305 |
+
"neural_primary_metric": 0.01684125567132316,
|
| 306 |
+
"counts": {
|
| 307 |
+
"num_queries": 348,
|
| 308 |
+
"num_train_windows": 813,
|
| 309 |
+
"num_test_windows": 348
|
| 310 |
+
},
|
| 311 |
+
"meaning": "Retrieve the matching time window for an annotation-derived text query.",
|
| 312 |
+
"artifact_sources": {
|
| 313 |
+
"walkthrough": "results/episode_task_suite/task_walkthroughs/caption_grounding.md",
|
| 314 |
+
"minimal_metrics": "results/episode_task_suite/caption_grounding/metrics.json",
|
| 315 |
+
"neural_metrics": "results/episode_task_suite/neural_mlp/caption_grounding/metrics.json"
|
| 316 |
+
},
|
| 317 |
+
"task_number": 8,
|
| 318 |
+
"suite_label": "Task 08"
|
| 319 |
+
},
|
| 320 |
+
{
|
| 321 |
+
"task_id": "cross_modal_retrieval",
|
| 322 |
+
"task_display_name": "Cross-Modal Retrieval",
|
| 323 |
+
"research_name": "Multimodal Representation Retrieval",
|
| 324 |
+
"origin": "original_public_sample_tasks",
|
| 325 |
+
"origin_count_label": "original task",
|
| 326 |
+
"family": "retrieval",
|
| 327 |
+
"architecture_family": "two-tower retrieval head",
|
| 328 |
+
"primary_direction": "D. Scene Reconstruction & World Modeling",
|
| 329 |
+
"input": "Query side: motion, IMU, and camera/pose features. Candidate side: depth and video features.",
|
| 330 |
+
"input_short": "motion/IMU/pose query; depth/video candidates",
|
| 331 |
+
"process": "modality split -> projection -> nearest-neighbor ranker",
|
| 332 |
+
"output": "A ranked list of candidate depth/video windows.",
|
| 333 |
+
"output_short": "ranked visual windows",
|
| 334 |
+
"metric_key": "mrr",
|
| 335 |
+
"metric_name": "MRR",
|
| 336 |
+
"metric_direction": "higher",
|
| 337 |
+
"minimal_primary_metric": 0.26925966892956127,
|
| 338 |
+
"neural_primary_metric": 0.1299971898648288,
|
| 339 |
+
"counts": {
|
| 340 |
+
"num_queries": 348,
|
| 341 |
+
"num_train_windows": 813,
|
| 342 |
+
"num_test_windows": 348
|
| 343 |
+
},
|
| 344 |
+
"meaning": "Use motion, IMU, and camera-pose signals to retrieve the matching depth/video window.",
|
| 345 |
+
"artifact_sources": {
|
| 346 |
+
"walkthrough": "results/episode_task_suite/task_walkthroughs/cross_modal_retrieval.md",
|
| 347 |
+
"minimal_metrics": "results/episode_task_suite/cross_modal_retrieval/metrics.json",
|
| 348 |
+
"neural_metrics": "results/episode_task_suite/neural_mlp/cross_modal_retrieval/metrics.json"
|
| 349 |
+
},
|
| 350 |
+
"task_number": 9,
|
| 351 |
+
"suite_label": "Task 09"
|
| 352 |
+
},
|
| 353 |
+
{
|
| 354 |
+
"task_id": "modality_reconstruction",
|
| 355 |
+
"task_display_name": "Cross-Modal Reconstruction",
|
| 356 |
+
"research_name": "Modality Feature Reconstruction",
|
| 357 |
+
"origin": "original_public_sample_tasks",
|
| 358 |
+
"origin_count_label": "original task",
|
| 359 |
+
"family": "forecast",
|
| 360 |
+
"architecture_family": "feature regressor",
|
| 361 |
+
"primary_direction": "B. 3D/4D Reconstruction & Neural Rendering",
|
| 362 |
+
"input": "Motion, IMU, and camera/pose features as input; depth/video features as the regression target.",
|
| 363 |
+
"input_short": "motion, IMU, and camera/pose features",
|
| 364 |
+
"process": "source-target split -> scaler -> regression head",
|
| 365 |
+
"output": "A reconstructed depth/video feature vector.",
|
| 366 |
+
"output_short": "reconstructed depth/video vector",
|
| 367 |
+
"metric_key": "r2",
|
| 368 |
+
"metric_name": "R2",
|
| 369 |
+
"metric_direction": "higher",
|
| 370 |
+
"minimal_primary_metric": -0.015271898913936655,
|
| 371 |
+
"neural_primary_metric": -0.010171410134180991,
|
| 372 |
+
"counts": {
|
| 373 |
+
"num_train_windows": 813,
|
| 374 |
+
"num_test_windows": 348
|
| 375 |
+
},
|
| 376 |
+
"meaning": "Predict compressed depth/video feature vectors from motion, IMU, and camera-pose features.",
|
| 377 |
+
"artifact_sources": {
|
| 378 |
+
"walkthrough": "results/episode_task_suite/task_walkthroughs/modality_reconstruction.md",
|
| 379 |
+
"minimal_metrics": "results/episode_task_suite/modality_reconstruction/metrics.json",
|
| 380 |
+
"neural_metrics": "results/episode_task_suite/neural_mlp/modality_reconstruction/metrics.json"
|
| 381 |
+
},
|
| 382 |
+
"task_number": 10,
|
| 383 |
+
"suite_label": "Task 10"
|
| 384 |
+
},
|
| 385 |
+
{
|
| 386 |
+
"task_id": "temporal_order",
|
| 387 |
+
"task_display_name": "Temporal Order Verification",
|
| 388 |
+
"research_name": "Temporal Order Verification",
|
| 389 |
+
"origin": "original_public_sample_tasks",
|
| 390 |
+
"origin_count_label": "original task",
|
| 391 |
+
"family": "diagnostic",
|
| 392 |
+
"architecture_family": "pairwise classifier",
|
| 393 |
+
"primary_direction": "D. Scene Reconstruction & World Modeling",
|
| 394 |
+
"input": "A pair of adjacent window vectors, plus their difference vector.",
|
| 395 |
+
"input_short": "two adjacent windows plus difference vector",
|
| 396 |
+
"process": "pair builder -> feature combiner -> binary classifier",
|
| 397 |
+
"output": "A binary label: correct order or reversed order.",
|
| 398 |
+
"output_short": "correct or reversed",
|
| 399 |
+
"metric_key": "f1",
|
| 400 |
+
"metric_name": "F1",
|
| 401 |
+
"metric_direction": "higher",
|
| 402 |
+
"minimal_primary_metric": 0.5399515738498789,
|
| 403 |
+
"neural_primary_metric": 0.8520179372197308,
|
| 404 |
+
"counts": {
|
| 405 |
+
"num_samples": 2320,
|
| 406 |
+
"num_train_samples": 1624,
|
| 407 |
+
"num_test_samples": 696
|
| 408 |
+
},
|
| 409 |
+
"meaning": "Tell whether two neighboring windows are in chronological order or reversed.",
|
| 410 |
+
"artifact_sources": {
|
| 411 |
+
"walkthrough": "results/episode_task_suite/task_walkthroughs/temporal_order.md",
|
| 412 |
+
"minimal_metrics": "results/episode_task_suite/temporal_order/metrics.json",
|
| 413 |
+
"neural_metrics": "results/episode_task_suite/neural_mlp/temporal_order/metrics.json"
|
| 414 |
+
},
|
| 415 |
+
"task_number": 11,
|
| 416 |
+
"suite_label": "Task 11"
|
| 417 |
+
},
|
| 418 |
+
{
|
| 419 |
+
"task_id": "misalignment_detection",
|
| 420 |
+
"task_display_name": "Multimodal Synchronization Detection",
|
| 421 |
+
"research_name": "Cross-Modal Misalignment Detection",
|
| 422 |
+
"origin": "original_public_sample_tasks",
|
| 423 |
+
"origin_count_label": "original task",
|
| 424 |
+
"family": "diagnostic",
|
| 425 |
+
"architecture_family": "pairwise classifier",
|
| 426 |
+
"primary_direction": "B. 3D/4D Reconstruction & Neural Rendering",
|
| 427 |
+
"input": "A motion-side feature group and a visual/depth-side feature group, either aligned or artificially shifted.",
|
| 428 |
+
"input_short": "motion-side and visual/depth-side feature groups",
|
| 429 |
+
"process": "aligned/shifted pairs -> feature combiner -> binary classifier",
|
| 430 |
+
"output": "A binary label: aligned or shifted.",
|
| 431 |
+
"output_short": "aligned or shifted",
|
| 432 |
+
"metric_key": "f1",
|
| 433 |
+
"metric_name": "F1",
|
| 434 |
+
"metric_direction": "higher",
|
| 435 |
+
"minimal_primary_metric": 0.5051698670605613,
|
| 436 |
+
"neural_primary_metric": 0.7152682255845944,
|
| 437 |
+
"counts": {
|
| 438 |
+
"num_samples": 2306,
|
| 439 |
+
"num_train_samples": 1614,
|
| 440 |
+
"num_test_samples": 692
|
| 441 |
+
},
|
| 442 |
+
"meaning": "Detect whether motion and visual/depth streams have been artificially shifted out of sync.",
|
| 443 |
+
"artifact_sources": {
|
| 444 |
+
"walkthrough": "results/episode_task_suite/task_walkthroughs/misalignment_detection.md",
|
| 445 |
+
"minimal_metrics": "results/episode_task_suite/misalignment_detection/metrics.json",
|
| 446 |
+
"neural_metrics": "results/episode_task_suite/neural_mlp/misalignment_detection/metrics.json"
|
| 447 |
+
},
|
| 448 |
+
"task_number": 12,
|
| 449 |
+
"suite_label": "Task 12"
|
| 450 |
+
},
|
| 451 |
+
{
|
| 452 |
+
"task_id": "long_horizon_next_action",
|
| 453 |
+
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
| 454 |
+
"research_name": "Long-Horizon Next-Action Forecasting",
|
| 455 |
+
"origin": "additional_public_sample_tasks",
|
| 456 |
+
"origin_count_label": "additional task",
|
| 457 |
+
"family": "classification",
|
| 458 |
+
"architecture_family": "minimal_softmax",
|
| 459 |
+
"primary_direction": "sample-supported extension",
|
| 460 |
+
"input": "Current 20-frame non-caption multimodal window.",
|
| 461 |
+
"input_short": "Current 20-frame non-caption multimodal window.",
|
| 462 |
+
"process": "shared window features -> task-specific target builder -> minimal/neural head",
|
| 463 |
+
"output": "Action label five seconds later.",
|
| 464 |
+
"output_short": "Action label five seconds later.",
|
| 465 |
+
"metric_key": "macro_f1",
|
| 466 |
+
"metric_name": "macro-F1",
|
| 467 |
+
"metric_direction": "higher",
|
| 468 |
+
"minimal_primary_metric": 0.07499999999999998,
|
| 469 |
+
"neural_primary_metric": 0.06545454545454546,
|
| 470 |
+
"counts": {
|
| 471 |
+
"num_windows": 1073,
|
| 472 |
+
"num_eval_windows": 322,
|
| 473 |
+
"num_train_windows": 751,
|
| 474 |
+
"num_test_windows": 322,
|
| 475 |
+
"num_classes": 18
|
| 476 |
+
},
|
| 477 |
+
"meaning": "Tests whether the current state carries enough procedure context to forecast beyond the one-second core next-action task.",
|
| 478 |
+
"artifact_sources": {
|
| 479 |
+
"legacy_result_directory": "results/episode_task_suite/tier2_task_suite/",
|
| 480 |
+
"minimal_metrics": "results/episode_task_suite/tier2_task_suite/long_horizon_next_action/metrics.json",
|
| 481 |
+
"neural_metrics": "results/episode_task_suite/tier2_task_suite/neural_mlp/long_horizon_next_action/metrics.json"
|
| 482 |
+
},
|
| 483 |
+
"task_number": 13,
|
| 484 |
+
"suite_label": "Task 13"
|
| 485 |
+
},
|
| 486 |
+
{
|
| 487 |
+
"task_id": "next_subtask_forecast",
|
| 488 |
+
"task_display_name": "Long-Horizon Next-Subtask Forecasting",
|
| 489 |
+
"research_name": "Long-Horizon Next-Subtask Forecasting",
|
| 490 |
+
"origin": "additional_public_sample_tasks",
|
| 491 |
+
"origin_count_label": "additional task",
|
| 492 |
+
"family": "classification",
|
| 493 |
+
"architecture_family": "minimal_softmax",
|
| 494 |
+
"primary_direction": "sample-supported extension",
|
| 495 |
+
"input": "Current 20-frame non-caption multimodal window.",
|
| 496 |
+
"input_short": "Current 20-frame non-caption multimodal window.",
|
| 497 |
+
"process": "shared window features -> task-specific target builder -> minimal/neural head",
|
| 498 |
+
"output": "Procedure subtask label five seconds later.",
|
| 499 |
+
"output_short": "Procedure subtask label five seconds later.",
|
| 500 |
+
"metric_key": "macro_f1",
|
| 501 |
+
"metric_name": "macro-F1",
|
| 502 |
+
"metric_direction": "higher",
|
| 503 |
+
"minimal_primary_metric": 0.04545454545454545,
|
| 504 |
+
"neural_primary_metric": 0.050724637681159424,
|
| 505 |
+
"counts": {
|
| 506 |
+
"num_windows": 1141,
|
| 507 |
+
"num_eval_windows": 342,
|
| 508 |
+
"num_train_windows": 799,
|
| 509 |
+
"num_test_windows": 342,
|
| 510 |
+
"num_classes": 14
|
| 511 |
+
},
|
| 512 |
+
"meaning": "Moves from immediate action anticipation to higher-level procedure-state prediction.",
|
| 513 |
+
"artifact_sources": {
|
| 514 |
+
"legacy_result_directory": "results/episode_task_suite/tier2_task_suite/",
|
| 515 |
+
"minimal_metrics": "results/episode_task_suite/tier2_task_suite/next_subtask_forecast/metrics.json",
|
| 516 |
+
"neural_metrics": "results/episode_task_suite/tier2_task_suite/neural_mlp/next_subtask_forecast/metrics.json"
|
| 517 |
+
},
|
| 518 |
+
"task_number": 14,
|
| 519 |
+
"suite_label": "Task 14"
|
| 520 |
+
},
|
| 521 |
+
{
|
| 522 |
+
"task_id": "interaction_text_prediction",
|
| 523 |
+
"task_display_name": "Interaction Text Prediction",
|
| 524 |
+
"research_name": "Interaction Text Prediction",
|
| 525 |
+
"origin": "additional_public_sample_tasks",
|
| 526 |
+
"origin_count_label": "additional task",
|
| 527 |
+
"family": "classification",
|
| 528 |
+
"architecture_family": "minimal_softmax",
|
| 529 |
+
"primary_direction": "sample-supported extension",
|
| 530 |
+
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 531 |
+
"input_short": "Current 20-frame sensor window with caption-text features removed.",
|
| 532 |
+
"process": "shared window features -> task-specific target builder -> minimal/neural head",
|
| 533 |
+
"output": "Raw annotation interaction phrase for the same window.",
|
| 534 |
+
"output_short": "Raw annotation interaction phrase for the same window.",
|
| 535 |
+
"metric_key": "macro_f1",
|
| 536 |
+
"metric_name": "macro-F1",
|
| 537 |
+
"metric_direction": "higher",
|
| 538 |
+
"minimal_primary_metric": 0.04444444444444444,
|
| 539 |
+
"neural_primary_metric": 0.0380952380952381,
|
| 540 |
+
"counts": {
|
| 541 |
+
"num_windows": 192,
|
| 542 |
+
"num_eval_windows": 58,
|
| 543 |
+
"num_train_windows": 134,
|
| 544 |
+
"num_test_windows": 58,
|
| 545 |
+
"num_classes": 46
|
| 546 |
+
},
|
| 547 |
+
"meaning": "Uses the raw caption JSON interaction field as a language target instead of only the hashed text feature.",
|
| 548 |
+
"artifact_sources": {
|
| 549 |
+
"legacy_result_directory": "results/episode_task_suite/tier2_task_suite/",
|
| 550 |
+
"minimal_metrics": "results/episode_task_suite/tier2_task_suite/interaction_text_prediction/metrics.json",
|
| 551 |
+
"neural_metrics": "results/episode_task_suite/tier2_task_suite/neural_mlp/interaction_text_prediction/metrics.json"
|
| 552 |
+
},
|
| 553 |
+
"task_number": 15,
|
| 554 |
+
"suite_label": "Task 15"
|
| 555 |
+
},
|
| 556 |
+
{
|
| 557 |
+
"task_id": "action_object_relation",
|
| 558 |
+
"task_display_name": "Action-Object Relation Prediction",
|
| 559 |
+
"research_name": "Action-Object Relation Prediction",
|
| 560 |
+
"origin": "additional_public_sample_tasks",
|
| 561 |
+
"origin_count_label": "additional task",
|
| 562 |
+
"family": "classification",
|
| 563 |
+
"architecture_family": "minimal_softmax",
|
| 564 |
+
"primary_direction": "sample-supported extension",
|
| 565 |
+
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 566 |
+
"input_short": "Current 20-frame sensor window with caption-text features removed.",
|
| 567 |
+
"process": "shared window features -> task-specific target builder -> minimal/neural head",
|
| 568 |
+
"output": "Joint action plus active object-set relation.",
|
| 569 |
+
"output_short": "Joint action plus active object-set relation.",
|
| 570 |
+
"metric_key": "macro_f1",
|
| 571 |
+
"metric_name": "macro-F1",
|
| 572 |
+
"metric_direction": "higher",
|
| 573 |
+
"minimal_primary_metric": 0.0,
|
| 574 |
+
"neural_primary_metric": 0.0,
|
| 575 |
+
"counts": {
|
| 576 |
+
"num_windows": 178,
|
| 577 |
+
"num_eval_windows": 53,
|
| 578 |
+
"num_train_windows": 125,
|
| 579 |
+
"num_test_windows": 53,
|
| 580 |
+
"num_classes": 42
|
| 581 |
+
},
|
| 582 |
+
"meaning": "Evaluates whether a model can bind what action is happening to which objects are involved.",
|
| 583 |
+
"artifact_sources": {
|
| 584 |
+
"legacy_result_directory": "results/episode_task_suite/tier2_task_suite/",
|
| 585 |
+
"minimal_metrics": "results/episode_task_suite/tier2_task_suite/action_object_relation/metrics.json",
|
| 586 |
+
"neural_metrics": "results/episode_task_suite/tier2_task_suite/neural_mlp/action_object_relation/metrics.json"
|
| 587 |
+
},
|
| 588 |
+
"task_number": 16,
|
| 589 |
+
"suite_label": "Task 16"
|
| 590 |
+
},
|
| 591 |
+
{
|
| 592 |
+
"task_id": "object_set_forecast",
|
| 593 |
+
"task_display_name": "Future Object-Set Forecasting",
|
| 594 |
+
"research_name": "Future Object-Set Forecasting",
|
| 595 |
+
"origin": "additional_public_sample_tasks",
|
| 596 |
+
"origin_count_label": "additional task",
|
| 597 |
+
"family": "multi_label",
|
| 598 |
+
"architecture_family": "minimal_ridge_multilabel",
|
| 599 |
+
"primary_direction": "sample-supported extension",
|
| 600 |
+
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 601 |
+
"input_short": "Current 20-frame sensor window with caption-text features removed.",
|
| 602 |
+
"process": "shared window features -> task-specific target builder -> minimal/neural head",
|
| 603 |
+
"output": "Object set active five seconds later.",
|
| 604 |
+
"output_short": "Object set active five seconds later.",
|
| 605 |
+
"metric_key": "micro_f1",
|
| 606 |
+
"metric_name": "micro-F1",
|
| 607 |
+
"metric_direction": "higher",
|
| 608 |
+
"minimal_primary_metric": 0.16939890710382516,
|
| 609 |
+
"neural_primary_metric": 0.19718309859154928,
|
| 610 |
+
"counts": {
|
| 611 |
+
"num_windows": 188,
|
| 612 |
+
"num_train_windows": 132,
|
| 613 |
+
"num_test_windows": 56
|
| 614 |
+
},
|
| 615 |
+
"meaning": "Predicts which objects will become relevant soon, not only which objects are relevant now.",
|
| 616 |
+
"artifact_sources": {
|
| 617 |
+
"legacy_result_directory": "results/episode_task_suite/tier2_task_suite/",
|
| 618 |
+
"minimal_metrics": "results/episode_task_suite/tier2_task_suite/object_set_forecast/metrics.json",
|
| 619 |
+
"neural_metrics": "results/episode_task_suite/tier2_task_suite/neural_mlp/object_set_forecast/metrics.json"
|
| 620 |
+
},
|
| 621 |
+
"task_number": 17,
|
| 622 |
+
"suite_label": "Task 17"
|
| 623 |
+
},
|
| 624 |
+
{
|
| 625 |
+
"task_id": "imu_to_hand_pose",
|
| 626 |
+
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
| 627 |
+
"research_name": "IMU-to-Hand Pose Reconstruction",
|
| 628 |
+
"origin": "additional_public_sample_tasks",
|
| 629 |
+
"origin_count_label": "additional task",
|
| 630 |
+
"family": "regression",
|
| 631 |
+
"architecture_family": "minimal_ridge_regression",
|
| 632 |
+
"primary_direction": "sample-supported extension",
|
| 633 |
+
"input": "Current IMU acceleration/gyroscope feature block only.",
|
| 634 |
+
"input_short": "Current IMU acceleration/gyroscope feature block only.",
|
| 635 |
+
"process": "shared window features -> task-specific target builder -> minimal/neural head",
|
| 636 |
+
"output": "Current left/right hand joint feature blocks.",
|
| 637 |
+
"output_short": "Current left/right hand joint feature blocks.",
|
| 638 |
+
"metric_key": "mae",
|
| 639 |
+
"metric_name": "MAE",
|
| 640 |
+
"metric_direction": "lower",
|
| 641 |
+
"minimal_primary_metric": 0.042049407958984375,
|
| 642 |
+
"neural_primary_metric": 0.042562149465084076,
|
| 643 |
+
"counts": {
|
| 644 |
+
"num_windows": 1161,
|
| 645 |
+
"num_train_windows": 813,
|
| 646 |
+
"num_test_windows": 348
|
| 647 |
+
},
|
| 648 |
+
"meaning": "A sensor-bridge probe for how much hand configuration can be recovered from inertial motion alone.",
|
| 649 |
+
"artifact_sources": {
|
| 650 |
+
"legacy_result_directory": "results/episode_task_suite/tier2_task_suite/",
|
| 651 |
+
"minimal_metrics": "results/episode_task_suite/tier2_task_suite/imu_to_hand_pose/metrics.json",
|
| 652 |
+
"neural_metrics": "results/episode_task_suite/tier2_task_suite/neural_mlp/imu_to_hand_pose/metrics.json"
|
| 653 |
+
},
|
| 654 |
+
"task_number": 18,
|
| 655 |
+
"suite_label": "Task 18"
|
| 656 |
+
},
|
| 657 |
+
{
|
| 658 |
+
"task_id": "camera_view_sync_retrieval",
|
| 659 |
+
"task_display_name": "Camera-View Synchronization Retrieval",
|
| 660 |
+
"research_name": "Camera-View Synchronization Retrieval",
|
| 661 |
+
"origin": "additional_public_sample_tasks",
|
| 662 |
+
"origin_count_label": "additional task",
|
| 663 |
+
"family": "retrieval",
|
| 664 |
+
"architecture_family": "minimal_ridge_projection_cosine_retrieval",
|
| 665 |
+
"primary_direction": "sample-supported extension",
|
| 666 |
+
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
| 667 |
+
"input_short": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
| 668 |
+
"process": "shared window features -> task-specific target builder -> minimal/neural head",
|
| 669 |
+
"output": "The synchronized held-out camera-3 window.",
|
| 670 |
+
"output_short": "The synchronized held-out camera-3 window.",
|
| 671 |
+
"metric_key": "mrr",
|
| 672 |
+
"metric_name": "MRR",
|
| 673 |
+
"metric_direction": "higher",
|
| 674 |
+
"minimal_primary_metric": 0.4943004846572876,
|
| 675 |
+
"neural_primary_metric": 0.24086658656597137,
|
| 676 |
+
"counts": {
|
| 677 |
+
"num_train_windows": 813,
|
| 678 |
+
"num_test_windows": 348
|
| 679 |
+
},
|
| 680 |
+
"meaning": "Stress-tests multi-camera time alignment beyond the core cross-modal retrieval task.",
|
| 681 |
+
"artifact_sources": {
|
| 682 |
+
"legacy_result_directory": "results/episode_task_suite/tier2_task_suite/",
|
| 683 |
+
"minimal_metrics": "results/episode_task_suite/tier2_task_suite/camera_view_sync_retrieval/metrics.json",
|
| 684 |
+
"neural_metrics": "results/episode_task_suite/tier2_task_suite/neural_mlp/camera_view_sync_retrieval/metrics.json"
|
| 685 |
+
},
|
| 686 |
+
"task_number": 19,
|
| 687 |
+
"suite_label": "Task 19"
|
| 688 |
+
},
|
| 689 |
+
{
|
| 690 |
+
"task_id": "time_to_transition",
|
| 691 |
+
"task_display_name": "Time-to-Next-Transition Regression",
|
| 692 |
+
"research_name": "Time-to-Next-Transition Regression",
|
| 693 |
+
"origin": "additional_public_sample_tasks",
|
| 694 |
+
"origin_count_label": "additional task",
|
| 695 |
+
"family": "regression",
|
| 696 |
+
"architecture_family": "minimal_ridge_regression",
|
| 697 |
+
"primary_direction": "sample-supported extension",
|
| 698 |
+
"input": "Current 20-frame non-caption multimodal window.",
|
| 699 |
+
"input_short": "Current 20-frame non-caption multimodal window.",
|
| 700 |
+
"process": "shared window features -> task-specific target builder -> minimal/neural head",
|
| 701 |
+
"output": "Frames until the next action-label boundary, capped at 200 frames.",
|
| 702 |
+
"output_short": "Frames until the next action-label boundary, capped at 200 frames.",
|
| 703 |
+
"metric_key": "mae",
|
| 704 |
+
"metric_name": "MAE frames",
|
| 705 |
+
"metric_direction": "lower",
|
| 706 |
+
"minimal_primary_metric": 10.53735637664795,
|
| 707 |
+
"neural_primary_metric": 10.55449390411377,
|
| 708 |
+
"counts": {
|
| 709 |
+
"num_windows": 1161,
|
| 710 |
+
"num_train_windows": 813,
|
| 711 |
+
"num_test_windows": 348
|
| 712 |
+
},
|
| 713 |
+
"meaning": "Turns boundary detection into a continuous timing estimate for procedural control.",
|
| 714 |
+
"artifact_sources": {
|
| 715 |
+
"legacy_result_directory": "results/episode_task_suite/tier2_task_suite/",
|
| 716 |
+
"minimal_metrics": "results/episode_task_suite/tier2_task_suite/time_to_transition/metrics.json",
|
| 717 |
+
"neural_metrics": "results/episode_task_suite/tier2_task_suite/neural_mlp/time_to_transition/metrics.json"
|
| 718 |
+
},
|
| 719 |
+
"task_number": 20,
|
| 720 |
+
"suite_label": "Task 20"
|
| 721 |
+
}
|
| 722 |
+
]
|
| 723 |
+
}
|
docs/data/task_surface_integrity.json
CHANGED
|
@@ -1,6 +1,6 @@
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
-
"generated_at_utc": "2026-06-
|
| 4 |
"summary": {
|
| 5 |
"task_count": 12,
|
| 6 |
"expected_task_count": 12,
|
|
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
+
"generated_at_utc": "2026-06-16T04:56:56+00:00",
|
| 4 |
"summary": {
|
| 5 |
"task_count": 12,
|
| 6 |
"expected_task_count": 12,
|
docs/data/tier2_task_suite.json
CHANGED
|
@@ -1,14 +1,15 @@
|
|
| 1 |
{
|
| 2 |
-
"title": "Ropedia Xperience-10M
|
| 3 |
"status": "pass",
|
| 4 |
-
"generated_at_utc": "2026-06-
|
| 5 |
-
"
|
| 6 |
-
"
|
| 7 |
-
|
| 8 |
-
"
|
|
|
|
| 9 |
"combined_task_count": 20,
|
| 10 |
-
"
|
| 11 |
-
"
|
| 12 |
},
|
| 13 |
"dataset_scope": {
|
| 14 |
"sample_episode_count": 1,
|
|
@@ -27,9 +28,9 @@
|
|
| 27 |
"raw_data_redistributed": false
|
| 28 |
},
|
| 29 |
"setup_alignment": {
|
| 30 |
-
"
|
| 31 |
-
"
|
| 32 |
-
"
|
| 33 |
"minimal_baselines": "softmax, ridge regression/projection, and ridge multilabel heads",
|
| 34 |
"neural_baselines": "compact one-hidden-layer/two-layer PyTorch MLP heads with the same chronological split",
|
| 35 |
"leakage_policy": "Caption-derived text features are removed whenever the target is a label, object, relation, interaction phrase, or future semantic state."
|
|
@@ -134,7 +135,7 @@
|
|
| 134 |
"status": "pass",
|
| 135 |
"task": "long_horizon_next_action",
|
| 136 |
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
| 137 |
-
"
|
| 138 |
"model_family": "minimal_softmax",
|
| 139 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 140 |
"split": "single_episode_chronological",
|
|
@@ -220,7 +221,7 @@
|
|
| 220 |
"status": "pass",
|
| 221 |
"task": "long_horizon_next_action",
|
| 222 |
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
| 223 |
-
"
|
| 224 |
"model_family": "neural_mlp",
|
| 225 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 226 |
"split": "single_episode_chronological",
|
|
@@ -275,7 +276,7 @@
|
|
| 275 |
"status": "pass",
|
| 276 |
"task": "next_subtask_forecast",
|
| 277 |
"task_display_name": "Long-Horizon Next-Subtask Forecasting",
|
| 278 |
-
"
|
| 279 |
"model_family": "minimal_softmax",
|
| 280 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 281 |
"split": "single_episode_chronological",
|
|
@@ -360,7 +361,7 @@
|
|
| 360 |
"status": "pass",
|
| 361 |
"task": "next_subtask_forecast",
|
| 362 |
"task_display_name": "Long-Horizon Next-Subtask Forecasting",
|
| 363 |
-
"
|
| 364 |
"model_family": "neural_mlp",
|
| 365 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 366 |
"split": "single_episode_chronological",
|
|
@@ -415,7 +416,7 @@
|
|
| 415 |
"status": "pass",
|
| 416 |
"task": "interaction_text_prediction",
|
| 417 |
"task_display_name": "Interaction Text Prediction",
|
| 418 |
-
"
|
| 419 |
"model_family": "minimal_softmax",
|
| 420 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 421 |
"split": "single_episode_chronological",
|
|
@@ -511,7 +512,7 @@
|
|
| 511 |
"status": "pass",
|
| 512 |
"task": "interaction_text_prediction",
|
| 513 |
"task_display_name": "Interaction Text Prediction",
|
| 514 |
-
"
|
| 515 |
"model_family": "neural_mlp",
|
| 516 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 517 |
"split": "single_episode_chronological",
|
|
@@ -566,7 +567,7 @@
|
|
| 566 |
"status": "pass",
|
| 567 |
"task": "action_object_relation",
|
| 568 |
"task_display_name": "Action-Object Relation Prediction",
|
| 569 |
-
"
|
| 570 |
"model_family": "minimal_softmax",
|
| 571 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 572 |
"split": "single_episode_chronological",
|
|
@@ -658,7 +659,7 @@
|
|
| 658 |
"status": "pass",
|
| 659 |
"task": "action_object_relation",
|
| 660 |
"task_display_name": "Action-Object Relation Prediction",
|
| 661 |
-
"
|
| 662 |
"model_family": "neural_mlp",
|
| 663 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 664 |
"split": "single_episode_chronological",
|
|
@@ -712,7 +713,7 @@
|
|
| 712 |
"status": "pass",
|
| 713 |
"task": "object_set_forecast",
|
| 714 |
"task_display_name": "Future Object-Set Forecasting",
|
| 715 |
-
"
|
| 716 |
"model_family": "minimal_ridge_multilabel",
|
| 717 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 718 |
"split": "single_episode_chronological",
|
|
@@ -746,7 +747,7 @@
|
|
| 746 |
"status": "pass",
|
| 747 |
"task": "object_set_forecast",
|
| 748 |
"task_display_name": "Future Object-Set Forecasting",
|
| 749 |
-
"
|
| 750 |
"model_family": "neural_mlp_multilabel",
|
| 751 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 752 |
"split": "single_episode_chronological",
|
|
@@ -794,7 +795,7 @@
|
|
| 794 |
"status": "pass",
|
| 795 |
"task": "imu_to_hand_pose",
|
| 796 |
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
| 797 |
-
"
|
| 798 |
"model_family": "minimal_ridge_regression",
|
| 799 |
"input": "Current IMU acceleration/gyroscope feature block only.",
|
| 800 |
"split": "single_episode_chronological",
|
|
@@ -813,7 +814,7 @@
|
|
| 813 |
"status": "pass",
|
| 814 |
"task": "imu_to_hand_pose",
|
| 815 |
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
| 816 |
-
"
|
| 817 |
"model_family": "neural_mlp_regression",
|
| 818 |
"input": "Current IMU acceleration/gyroscope feature block only.",
|
| 819 |
"split": "single_episode_chronological",
|
|
@@ -863,7 +864,7 @@
|
|
| 863 |
"status": "pass",
|
| 864 |
"task": "camera_view_sync_retrieval",
|
| 865 |
"task_display_name": "Camera-View Synchronization Retrieval",
|
| 866 |
-
"
|
| 867 |
"model_family": "minimal_ridge_projection_cosine_retrieval",
|
| 868 |
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
| 869 |
"split": "single_episode_chronological",
|
|
@@ -884,7 +885,7 @@
|
|
| 884 |
"status": "pass",
|
| 885 |
"task": "camera_view_sync_retrieval",
|
| 886 |
"task_display_name": "Camera-View Synchronization Retrieval",
|
| 887 |
-
"
|
| 888 |
"model_family": "neural_mlp_projection_cosine_retrieval",
|
| 889 |
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
| 890 |
"split": "single_episode_chronological",
|
|
@@ -933,7 +934,7 @@
|
|
| 933 |
"status": "pass",
|
| 934 |
"task": "time_to_transition",
|
| 935 |
"task_display_name": "Time-to-Next-Transition Regression",
|
| 936 |
-
"
|
| 937 |
"model_family": "minimal_ridge_regression",
|
| 938 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 939 |
"split": "single_episode_chronological",
|
|
@@ -953,7 +954,7 @@
|
|
| 953 |
"status": "pass",
|
| 954 |
"task": "time_to_transition",
|
| 955 |
"task_display_name": "Time-to-Next-Transition Regression",
|
| 956 |
-
"
|
| 957 |
"model_family": "neural_mlp_regression",
|
| 958 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 959 |
"split": "single_episode_chronological",
|
|
|
|
| 1 |
{
|
| 2 |
+
"title": "Ropedia Xperience-10M Unified Tasks 13-20 Result Bundle",
|
| 3 |
"status": "pass",
|
| 4 |
+
"generated_at_utc": "2026-06-16T04:47:52+00:00",
|
| 5 |
+
"suite_position": "tasks_13_to_20",
|
| 6 |
+
"legacy_path_note": "The tier2_task_suite file and directory names are retained for stable public links; these tasks are part of the unified 20-task suite, not a separate public tier.",
|
| 7 |
+
"integrated_with_tasks_1_to_12": {
|
| 8 |
+
"tasks_1_to_12_count": 12,
|
| 9 |
+
"additional_task_count": 8,
|
| 10 |
"combined_task_count": 20,
|
| 11 |
+
"tasks_1_to_12_metrics": "docs/data/summary_metrics.json",
|
| 12 |
+
"unified_protocol": "docs/data/evaluation_protocol.json"
|
| 13 |
},
|
| 14 |
"dataset_scope": {
|
| 15 |
"sample_episode_count": 1,
|
|
|
|
| 28 |
"raw_data_redistributed": false
|
| 29 |
},
|
| 30 |
"setup_alignment": {
|
| 31 |
+
"same_window_unit_as_tasks_1_to_12": true,
|
| 32 |
+
"same_feature_manifest_as_tasks_1_to_12": "results/episode_task_suite/feature_manifest.json",
|
| 33 |
+
"same_shared_tensor_as_tasks_1_to_12": "results/episode_task_suite/shared_windows.npz",
|
| 34 |
"minimal_baselines": "softmax, ridge regression/projection, and ridge multilabel heads",
|
| 35 |
"neural_baselines": "compact one-hidden-layer/two-layer PyTorch MLP heads with the same chronological split",
|
| 36 |
"leakage_policy": "Caption-derived text features are removed whenever the target is a label, object, relation, interaction phrase, or future semantic state."
|
|
|
|
| 135 |
"status": "pass",
|
| 136 |
"task": "long_horizon_next_action",
|
| 137 |
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
| 138 |
+
"suite_position": "tasks_13_to_20",
|
| 139 |
"model_family": "minimal_softmax",
|
| 140 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 141 |
"split": "single_episode_chronological",
|
|
|
|
| 221 |
"status": "pass",
|
| 222 |
"task": "long_horizon_next_action",
|
| 223 |
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
| 224 |
+
"suite_position": "tasks_13_to_20",
|
| 225 |
"model_family": "neural_mlp",
|
| 226 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 227 |
"split": "single_episode_chronological",
|
|
|
|
| 276 |
"status": "pass",
|
| 277 |
"task": "next_subtask_forecast",
|
| 278 |
"task_display_name": "Long-Horizon Next-Subtask Forecasting",
|
| 279 |
+
"suite_position": "tasks_13_to_20",
|
| 280 |
"model_family": "minimal_softmax",
|
| 281 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 282 |
"split": "single_episode_chronological",
|
|
|
|
| 361 |
"status": "pass",
|
| 362 |
"task": "next_subtask_forecast",
|
| 363 |
"task_display_name": "Long-Horizon Next-Subtask Forecasting",
|
| 364 |
+
"suite_position": "tasks_13_to_20",
|
| 365 |
"model_family": "neural_mlp",
|
| 366 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 367 |
"split": "single_episode_chronological",
|
|
|
|
| 416 |
"status": "pass",
|
| 417 |
"task": "interaction_text_prediction",
|
| 418 |
"task_display_name": "Interaction Text Prediction",
|
| 419 |
+
"suite_position": "tasks_13_to_20",
|
| 420 |
"model_family": "minimal_softmax",
|
| 421 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 422 |
"split": "single_episode_chronological",
|
|
|
|
| 512 |
"status": "pass",
|
| 513 |
"task": "interaction_text_prediction",
|
| 514 |
"task_display_name": "Interaction Text Prediction",
|
| 515 |
+
"suite_position": "tasks_13_to_20",
|
| 516 |
"model_family": "neural_mlp",
|
| 517 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 518 |
"split": "single_episode_chronological",
|
|
|
|
| 567 |
"status": "pass",
|
| 568 |
"task": "action_object_relation",
|
| 569 |
"task_display_name": "Action-Object Relation Prediction",
|
| 570 |
+
"suite_position": "tasks_13_to_20",
|
| 571 |
"model_family": "minimal_softmax",
|
| 572 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 573 |
"split": "single_episode_chronological",
|
|
|
|
| 659 |
"status": "pass",
|
| 660 |
"task": "action_object_relation",
|
| 661 |
"task_display_name": "Action-Object Relation Prediction",
|
| 662 |
+
"suite_position": "tasks_13_to_20",
|
| 663 |
"model_family": "neural_mlp",
|
| 664 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 665 |
"split": "single_episode_chronological",
|
|
|
|
| 713 |
"status": "pass",
|
| 714 |
"task": "object_set_forecast",
|
| 715 |
"task_display_name": "Future Object-Set Forecasting",
|
| 716 |
+
"suite_position": "tasks_13_to_20",
|
| 717 |
"model_family": "minimal_ridge_multilabel",
|
| 718 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 719 |
"split": "single_episode_chronological",
|
|
|
|
| 747 |
"status": "pass",
|
| 748 |
"task": "object_set_forecast",
|
| 749 |
"task_display_name": "Future Object-Set Forecasting",
|
| 750 |
+
"suite_position": "tasks_13_to_20",
|
| 751 |
"model_family": "neural_mlp_multilabel",
|
| 752 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 753 |
"split": "single_episode_chronological",
|
|
|
|
| 795 |
"status": "pass",
|
| 796 |
"task": "imu_to_hand_pose",
|
| 797 |
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
| 798 |
+
"suite_position": "tasks_13_to_20",
|
| 799 |
"model_family": "minimal_ridge_regression",
|
| 800 |
"input": "Current IMU acceleration/gyroscope feature block only.",
|
| 801 |
"split": "single_episode_chronological",
|
|
|
|
| 814 |
"status": "pass",
|
| 815 |
"task": "imu_to_hand_pose",
|
| 816 |
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
| 817 |
+
"suite_position": "tasks_13_to_20",
|
| 818 |
"model_family": "neural_mlp_regression",
|
| 819 |
"input": "Current IMU acceleration/gyroscope feature block only.",
|
| 820 |
"split": "single_episode_chronological",
|
|
|
|
| 864 |
"status": "pass",
|
| 865 |
"task": "camera_view_sync_retrieval",
|
| 866 |
"task_display_name": "Camera-View Synchronization Retrieval",
|
| 867 |
+
"suite_position": "tasks_13_to_20",
|
| 868 |
"model_family": "minimal_ridge_projection_cosine_retrieval",
|
| 869 |
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
| 870 |
"split": "single_episode_chronological",
|
|
|
|
| 885 |
"status": "pass",
|
| 886 |
"task": "camera_view_sync_retrieval",
|
| 887 |
"task_display_name": "Camera-View Synchronization Retrieval",
|
| 888 |
+
"suite_position": "tasks_13_to_20",
|
| 889 |
"model_family": "neural_mlp_projection_cosine_retrieval",
|
| 890 |
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
| 891 |
"split": "single_episode_chronological",
|
|
|
|
| 934 |
"status": "pass",
|
| 935 |
"task": "time_to_transition",
|
| 936 |
"task_display_name": "Time-to-Next-Transition Regression",
|
| 937 |
+
"suite_position": "tasks_13_to_20",
|
| 938 |
"model_family": "minimal_ridge_regression",
|
| 939 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 940 |
"split": "single_episode_chronological",
|
|
|
|
| 954 |
"status": "pass",
|
| 955 |
"task": "time_to_transition",
|
| 956 |
"task_display_name": "Time-to-Next-Transition Regression",
|
| 957 |
+
"suite_position": "tasks_13_to_20",
|
| 958 |
"model_family": "neural_mlp_regression",
|
| 959 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 960 |
"split": "single_episode_chronological",
|
docs/data/website_integrity.json
CHANGED
|
@@ -1,13 +1,13 @@
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
-
"generated_at_utc": "2026-06-
|
| 4 |
"docs_root": "docs",
|
| 5 |
"site_base": "/ropedia-xperience-10m-task-suite/",
|
| 6 |
"summary": {
|
| 7 |
"html_pages": 4,
|
| 8 |
-
"local_references":
|
| 9 |
"external_reference_count": 121,
|
| 10 |
-
"json_files":
|
| 11 |
"image_assets_referenced": 22,
|
| 12 |
"failure_count": 0
|
| 13 |
},
|
|
@@ -80,8 +80,8 @@
|
|
| 80 |
"name": "project_overview_precedes_progress_ledger",
|
| 81 |
"status": "pass",
|
| 82 |
"reason": "The project overview should appear before the deeper progress ledger.",
|
| 83 |
-
"overview_index":
|
| 84 |
-
"evidence_index":
|
| 85 |
},
|
| 86 |
{
|
| 87 |
"name": "project_status_links_json",
|
|
@@ -159,9 +159,9 @@
|
|
| 159 |
"name": "evaluation_protocol_between_overview_and_progress",
|
| 160 |
"status": "pass",
|
| 161 |
"reason": "The evaluation protocol should appear before the deeper evidence ledger.",
|
| 162 |
-
"overview_index":
|
| 163 |
-
"protocol_index":
|
| 164 |
-
"evidence_index":
|
| 165 |
},
|
| 166 |
{
|
| 167 |
"name": "evaluation_protocol_links_json",
|
|
@@ -178,9 +178,9 @@
|
|
| 178 |
{
|
| 179 |
"name": "suite_task_map_precedes_modality_atlas",
|
| 180 |
"status": "pass",
|
| 181 |
-
"reason": "The Suite anchor should show the
|
| 182 |
-
"first_marker_index":
|
| 183 |
-
"second_marker_index":
|
| 184 |
},
|
| 185 |
{
|
| 186 |
"name": "suite_modality_atlas_contains_seven_cards",
|
|
@@ -277,7 +277,7 @@
|
|
| 277 |
{
|
| 278 |
"path": "index.html",
|
| 279 |
"id_count": 90,
|
| 280 |
-
"reference_count":
|
| 281 |
"image_count": 25
|
| 282 |
},
|
| 283 |
{
|
|
@@ -301,7 +301,7 @@
|
|
| 301 |
},
|
| 302 |
{
|
| 303 |
"path": "data/artifact_index.json",
|
| 304 |
-
"bytes":
|
| 305 |
"top_level_type": "dict"
|
| 306 |
},
|
| 307 |
{
|
|
@@ -316,7 +316,7 @@
|
|
| 316 |
},
|
| 317 |
{
|
| 318 |
"path": "data/evaluation_protocol.json",
|
| 319 |
-
"bytes":
|
| 320 |
"top_level_type": "dict"
|
| 321 |
},
|
| 322 |
{
|
|
@@ -326,7 +326,7 @@
|
|
| 326 |
},
|
| 327 |
{
|
| 328 |
"path": "data/figure_index.json",
|
| 329 |
-
"bytes":
|
| 330 |
"top_level_type": "dict"
|
| 331 |
},
|
| 332 |
{
|
|
@@ -336,12 +336,12 @@
|
|
| 336 |
},
|
| 337 |
{
|
| 338 |
"path": "data/live_publication_status.json",
|
| 339 |
-
"bytes":
|
| 340 |
"top_level_type": "dict"
|
| 341 |
},
|
| 342 |
{
|
| 343 |
"path": "data/mirror_parity.json",
|
| 344 |
-
"bytes":
|
| 345 |
"top_level_type": "dict"
|
| 346 |
},
|
| 347 |
{
|
|
@@ -361,37 +361,37 @@
|
|
| 361 |
},
|
| 362 |
{
|
| 363 |
"path": "data/project_brief.json",
|
| 364 |
-
"bytes":
|
| 365 |
"top_level_type": "dict"
|
| 366 |
},
|
| 367 |
{
|
| 368 |
"path": "data/project_manifest.json",
|
| 369 |
-
"bytes":
|
| 370 |
"top_level_type": "dict"
|
| 371 |
},
|
| 372 |
{
|
| 373 |
"path": "data/project_packet.json",
|
| 374 |
-
"bytes":
|
| 375 |
"top_level_type": "dict"
|
| 376 |
},
|
| 377 |
{
|
| 378 |
"path": "data/project_status.json",
|
| 379 |
-
"bytes":
|
| 380 |
"top_level_type": "dict"
|
| 381 |
},
|
| 382 |
{
|
| 383 |
"path": "data/public_surface_qa.json",
|
| 384 |
-
"bytes":
|
| 385 |
"top_level_type": "dict"
|
| 386 |
},
|
| 387 |
{
|
| 388 |
"path": "data/publication_audit.json",
|
| 389 |
-
"bytes":
|
| 390 |
"top_level_type": "dict"
|
| 391 |
},
|
| 392 |
{
|
| 393 |
"path": "data/quality_gates.json",
|
| 394 |
-
"bytes":
|
| 395 |
"top_level_type": "dict"
|
| 396 |
},
|
| 397 |
{
|
|
@@ -416,7 +416,7 @@
|
|
| 416 |
},
|
| 417 |
{
|
| 418 |
"path": "data/reproducibility_matrix.json",
|
| 419 |
-
"bytes":
|
| 420 |
"top_level_type": "dict"
|
| 421 |
},
|
| 422 |
{
|
|
@@ -464,6 +464,11 @@
|
|
| 464 |
"bytes": 27807,
|
| 465 |
"top_level_type": "dict"
|
| 466 |
},
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 467 |
{
|
| 468 |
"path": "data/task_suite_enhancement_128.json",
|
| 469 |
"bytes": 20181,
|
|
@@ -481,12 +486,12 @@
|
|
| 481 |
},
|
| 482 |
{
|
| 483 |
"path": "data/tier2_task_suite.json",
|
| 484 |
-
"bytes":
|
| 485 |
"top_level_type": "dict"
|
| 486 |
},
|
| 487 |
{
|
| 488 |
"path": "data/website_integrity.json",
|
| 489 |
-
"bytes":
|
| 490 |
"top_level_type": "dict"
|
| 491 |
},
|
| 492 |
{
|
|
@@ -570,7 +575,7 @@
|
|
| 570 |
{
|
| 571 |
"path": "assets/charts/tier2_task_suite.svg",
|
| 572 |
"exists": true,
|
| 573 |
-
"bytes":
|
| 574 |
"format": "SVG",
|
| 575 |
"has_viewbox": true
|
| 576 |
},
|
|
@@ -657,7 +662,7 @@
|
|
| 657 |
{
|
| 658 |
"path": "assets/task_suite_infographic.png",
|
| 659 |
"exists": true,
|
| 660 |
-
"bytes":
|
| 661 |
"width": 1800,
|
| 662 |
"height": 6600,
|
| 663 |
"format": "PNG"
|
|
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
+
"generated_at_utc": "2026-06-16T04:56:57+00:00",
|
| 4 |
"docs_root": "docs",
|
| 5 |
"site_base": "/ropedia-xperience-10m-task-suite/",
|
| 6 |
"summary": {
|
| 7 |
"html_pages": 4,
|
| 8 |
+
"local_references": 154,
|
| 9 |
"external_reference_count": 121,
|
| 10 |
+
"json_files": 41,
|
| 11 |
"image_assets_referenced": 22,
|
| 12 |
"failure_count": 0
|
| 13 |
},
|
|
|
|
| 80 |
"name": "project_overview_precedes_progress_ledger",
|
| 81 |
"status": "pass",
|
| 82 |
"reason": "The project overview should appear before the deeper progress ledger.",
|
| 83 |
+
"overview_index": 76641,
|
| 84 |
+
"evidence_index": 102471
|
| 85 |
},
|
| 86 |
{
|
| 87 |
"name": "project_status_links_json",
|
|
|
|
| 159 |
"name": "evaluation_protocol_between_overview_and_progress",
|
| 160 |
"status": "pass",
|
| 161 |
"reason": "The evaluation protocol should appear before the deeper evidence ledger.",
|
| 162 |
+
"overview_index": 76641,
|
| 163 |
+
"protocol_index": 98652,
|
| 164 |
+
"evidence_index": 102471
|
| 165 |
},
|
| 166 |
{
|
| 167 |
"name": "evaluation_protocol_links_json",
|
|
|
|
| 178 |
{
|
| 179 |
"name": "suite_task_map_precedes_modality_atlas",
|
| 180 |
"status": "pass",
|
| 181 |
+
"reason": "The Suite anchor should show the task-suite map before the modality atlas.",
|
| 182 |
+
"first_marker_index": 471,
|
| 183 |
+
"second_marker_index": 763
|
| 184 |
},
|
| 185 |
{
|
| 186 |
"name": "suite_modality_atlas_contains_seven_cards",
|
|
|
|
| 277 |
{
|
| 278 |
"path": "index.html",
|
| 279 |
"id_count": 90,
|
| 280 |
+
"reference_count": 130,
|
| 281 |
"image_count": 25
|
| 282 |
},
|
| 283 |
{
|
|
|
|
| 301 |
},
|
| 302 |
{
|
| 303 |
"path": "data/artifact_index.json",
|
| 304 |
+
"bytes": 93924,
|
| 305 |
"top_level_type": "dict"
|
| 306 |
},
|
| 307 |
{
|
|
|
|
| 316 |
},
|
| 317 |
{
|
| 318 |
"path": "data/evaluation_protocol.json",
|
| 319 |
+
"bytes": 24020,
|
| 320 |
"top_level_type": "dict"
|
| 321 |
},
|
| 322 |
{
|
|
|
|
| 326 |
},
|
| 327 |
{
|
| 328 |
"path": "data/figure_index.json",
|
| 329 |
+
"bytes": 14939,
|
| 330 |
"top_level_type": "dict"
|
| 331 |
},
|
| 332 |
{
|
|
|
|
| 336 |
},
|
| 337 |
{
|
| 338 |
"path": "data/live_publication_status.json",
|
| 339 |
+
"bytes": 123218,
|
| 340 |
"top_level_type": "dict"
|
| 341 |
},
|
| 342 |
{
|
| 343 |
"path": "data/mirror_parity.json",
|
| 344 |
+
"bytes": 631418,
|
| 345 |
"top_level_type": "dict"
|
| 346 |
},
|
| 347 |
{
|
|
|
|
| 361 |
},
|
| 362 |
{
|
| 363 |
"path": "data/project_brief.json",
|
| 364 |
+
"bytes": 4019,
|
| 365 |
"top_level_type": "dict"
|
| 366 |
},
|
| 367 |
{
|
| 368 |
"path": "data/project_manifest.json",
|
| 369 |
+
"bytes": 5672,
|
| 370 |
"top_level_type": "dict"
|
| 371 |
},
|
| 372 |
{
|
| 373 |
"path": "data/project_packet.json",
|
| 374 |
+
"bytes": 10009,
|
| 375 |
"top_level_type": "dict"
|
| 376 |
},
|
| 377 |
{
|
| 378 |
"path": "data/project_status.json",
|
| 379 |
+
"bytes": 22080,
|
| 380 |
"top_level_type": "dict"
|
| 381 |
},
|
| 382 |
{
|
| 383 |
"path": "data/public_surface_qa.json",
|
| 384 |
+
"bytes": 5698,
|
| 385 |
"top_level_type": "dict"
|
| 386 |
},
|
| 387 |
{
|
| 388 |
"path": "data/publication_audit.json",
|
| 389 |
+
"bytes": 7712,
|
| 390 |
"top_level_type": "dict"
|
| 391 |
},
|
| 392 |
{
|
| 393 |
"path": "data/quality_gates.json",
|
| 394 |
+
"bytes": 8100,
|
| 395 |
"top_level_type": "dict"
|
| 396 |
},
|
| 397 |
{
|
|
|
|
| 416 |
},
|
| 417 |
{
|
| 418 |
"path": "data/reproducibility_matrix.json",
|
| 419 |
+
"bytes": 6673,
|
| 420 |
"top_level_type": "dict"
|
| 421 |
},
|
| 422 |
{
|
|
|
|
| 464 |
"bytes": 27807,
|
| 465 |
"top_level_type": "dict"
|
| 466 |
},
|
| 467 |
+
{
|
| 468 |
+
"path": "data/task_suite_20.json",
|
| 469 |
+
"bytes": 34648,
|
| 470 |
+
"top_level_type": "dict"
|
| 471 |
+
},
|
| 472 |
{
|
| 473 |
"path": "data/task_suite_enhancement_128.json",
|
| 474 |
"bytes": 20181,
|
|
|
|
| 486 |
},
|
| 487 |
{
|
| 488 |
"path": "data/tier2_task_suite.json",
|
| 489 |
+
"bytes": 33402,
|
| 490 |
"top_level_type": "dict"
|
| 491 |
},
|
| 492 |
{
|
| 493 |
"path": "data/website_integrity.json",
|
| 494 |
+
"bytes": 17815,
|
| 495 |
"top_level_type": "dict"
|
| 496 |
},
|
| 497 |
{
|
|
|
|
| 575 |
{
|
| 576 |
"path": "assets/charts/tier2_task_suite.svg",
|
| 577 |
"exists": true,
|
| 578 |
+
"bytes": 5437,
|
| 579 |
"format": "SVG",
|
| 580 |
"has_viewbox": true
|
| 581 |
},
|
|
|
|
| 662 |
{
|
| 663 |
"path": "assets/task_suite_infographic.png",
|
| 664 |
"exists": true,
|
| 665 |
+
"bytes": 2627286,
|
| 666 |
"width": 1800,
|
| 667 |
"height": 6600,
|
| 668 |
"format": "PNG"
|
results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md
CHANGED
|
@@ -1,28 +1,30 @@
|
|
| 1 |
-
#
|
| 2 |
|
| 3 |
-
These tasks
|
|
|
|
|
|
|
| 4 |
|
| 5 |
## Setup Alignment
|
| 6 |
|
| 7 |
-
-
|
| 8 |
-
-
|
| 9 |
-
-
|
| 10 |
- Long-horizon offset: `100` frames, about `5.0` seconds at 20 FPS
|
| 11 |
- Raw public-sample HDF5 is required to regenerate the interaction/object targets; raw media/HDF5 files are not redistributed.
|
| 12 |
|
| 13 |
## Results
|
| 14 |
|
| 15 |
-
|
|
| 16 |
-
| --- | --- | --- | ---: | ---: | --- |
|
| 17 |
-
| Long-Horizon Next-Action Forecasting | Current 20-frame non-caption multimodal window. | Action label five seconds later. | 0.0750 macro-F1 | 0.0655 macro-F1 | Tests whether the current state carries enough procedure context to forecast beyond the one-second core next-action task. |
|
| 18 |
-
| Long-Horizon Next-Subtask Forecasting | Current 20-frame non-caption multimodal window. | Procedure subtask label five seconds later. | 0.0455 macro-F1 | 0.0507 macro-F1 | Moves from immediate action anticipation to higher-level procedure-state prediction. |
|
| 19 |
-
| Interaction Text Prediction | Current 20-frame sensor window with caption-text features removed. | Raw annotation interaction phrase for the same window. | 0.0444 macro-F1 | 0.0381 macro-F1 | Uses the raw caption JSON interaction field as a language target instead of only the hashed text feature. |
|
| 20 |
-
| Action-Object Relation Prediction | Current 20-frame sensor window with caption-text features removed. | Joint action plus active object-set relation. | 0.0000 macro-F1 | 0.0000 macro-F1 | Evaluates whether a model can bind what action is happening to which objects are involved. |
|
| 21 |
-
| Future Object-Set Forecasting | Current 20-frame sensor window with caption-text features removed. | Object set active five seconds later. | 0.1694 micro-F1 | 0.1972 micro-F1 | Predicts which objects will become relevant soon, not only which objects are relevant now. |
|
| 22 |
-
| IMU-to-Hand Pose Reconstruction | Current IMU acceleration/gyroscope feature block only. | Current left/right hand joint feature blocks. | 0.0420 MAE | 0.0426 MAE | A sensor-bridge probe for how much hand configuration can be recovered from inertial motion alone. |
|
| 23 |
-
| Camera-View Synchronization Retrieval | Fisheye camera-1 feature query projected into fisheye camera-3 feature space. | The synchronized held-out camera-3 window. | 0.4943 MRR | 0.2409 MRR | Stress-tests multi-camera time alignment beyond the core cross-modal retrieval task. |
|
| 24 |
-
| Time-to-Next-Transition Regression | Current 20-frame non-caption multimodal window. | Frames until the next action-label boundary, capped at 200 frames. | 10.5374 MAE frames | 10.5545 MAE frames | Turns boundary detection into a continuous timing estimate for procedural control. |
|
| 25 |
|
| 26 |
## Interpretation Boundary
|
| 27 |
|
| 28 |
-
|
|
|
|
| 1 |
+
# Tasks 13-20 Baselines
|
| 2 |
|
| 3 |
+
These eight tasks are part of the unified 20-task public-sample suite. They reuse the same 20-frame windows, 5-frame stride, shared feature tensor, chronological split, and minimal/neural baseline discipline as tasks 1-12.
|
| 4 |
+
|
| 5 |
+
The file and directory names still contain `tier2_task_suite` for backwards-compatible public links, but this is not a separate benchmark tier.
|
| 6 |
|
| 7 |
## Setup Alignment
|
| 8 |
|
| 9 |
+
- Tasks 1-12: `12`
|
| 10 |
+
- Tasks 13-20: `8`
|
| 11 |
+
- Unified task contracts: `20`
|
| 12 |
- Long-horizon offset: `100` frames, about `5.0` seconds at 20 FPS
|
| 13 |
- Raw public-sample HDF5 is required to regenerate the interaction/object targets; raw media/HDF5 files are not redistributed.
|
| 14 |
|
| 15 |
## Results
|
| 16 |
|
| 17 |
+
| # | Task | Input | Output | Minimal | Neural MLP | Meaning |
|
| 18 |
+
| ---: | --- | --- | --- | ---: | ---: | --- |
|
| 19 |
+
| 13 | Long-Horizon Next-Action Forecasting | Current 20-frame non-caption multimodal window. | Action label five seconds later. | 0.0750 macro-F1 | 0.0655 macro-F1 | Tests whether the current state carries enough procedure context to forecast beyond the one-second core next-action task. |
|
| 20 |
+
| 14 | Long-Horizon Next-Subtask Forecasting | Current 20-frame non-caption multimodal window. | Procedure subtask label five seconds later. | 0.0455 macro-F1 | 0.0507 macro-F1 | Moves from immediate action anticipation to higher-level procedure-state prediction. |
|
| 21 |
+
| 15 | Interaction Text Prediction | Current 20-frame sensor window with caption-text features removed. | Raw annotation interaction phrase for the same window. | 0.0444 macro-F1 | 0.0381 macro-F1 | Uses the raw caption JSON interaction field as a language target instead of only the hashed text feature. |
|
| 22 |
+
| 16 | Action-Object Relation Prediction | Current 20-frame sensor window with caption-text features removed. | Joint action plus active object-set relation. | 0.0000 macro-F1 | 0.0000 macro-F1 | Evaluates whether a model can bind what action is happening to which objects are involved. |
|
| 23 |
+
| 17 | Future Object-Set Forecasting | Current 20-frame sensor window with caption-text features removed. | Object set active five seconds later. | 0.1694 micro-F1 | 0.1972 micro-F1 | Predicts which objects will become relevant soon, not only which objects are relevant now. |
|
| 24 |
+
| 18 | IMU-to-Hand Pose Reconstruction | Current IMU acceleration/gyroscope feature block only. | Current left/right hand joint feature blocks. | 0.0420 MAE | 0.0426 MAE | A sensor-bridge probe for how much hand configuration can be recovered from inertial motion alone. |
|
| 25 |
+
| 19 | Camera-View Synchronization Retrieval | Fisheye camera-1 feature query projected into fisheye camera-3 feature space. | The synchronized held-out camera-3 window. | 0.4943 MRR | 0.2409 MRR | Stress-tests multi-camera time alignment beyond the core cross-modal retrieval task. |
|
| 26 |
+
| 20 | Time-to-Next-Transition Regression | Current 20-frame non-caption multimodal window. | Frames until the next action-label boundary, capped at 200 frames. | 10.5374 MAE frames | 10.5545 MAE frames | Turns boundary detection into a continuous timing estimate for procedural control. |
|
| 27 |
|
| 28 |
## Interpretation Boundary
|
| 29 |
|
| 30 |
+
Tasks 13-20 are sample-level baselines in the same unified public-sample suite. They prove that the sample can support richer task contracts, but they do not prove cross-episode model quality.
|
results/episode_task_suite/tier2_task_suite/action_object_relation/metrics.json
CHANGED
|
@@ -8,7 +8,7 @@
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "action_object_relation",
|
| 10 |
"task_display_name": "Action-Object Relation Prediction",
|
| 11 |
-
"
|
| 12 |
"model_family": "minimal_softmax",
|
| 13 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 14 |
"split": "single_episode_chronological",
|
|
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "action_object_relation",
|
| 10 |
"task_display_name": "Action-Object Relation Prediction",
|
| 11 |
+
"suite_position": "tasks_13_to_20",
|
| 12 |
"model_family": "minimal_softmax",
|
| 13 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 14 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/camera_view_sync_retrieval/metrics.json
CHANGED
|
@@ -8,7 +8,7 @@
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "camera_view_sync_retrieval",
|
| 10 |
"task_display_name": "Camera-View Synchronization Retrieval",
|
| 11 |
-
"
|
| 12 |
"model_family": "minimal_ridge_projection_cosine_retrieval",
|
| 13 |
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
| 14 |
"split": "single_episode_chronological",
|
|
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "camera_view_sync_retrieval",
|
| 10 |
"task_display_name": "Camera-View Synchronization Retrieval",
|
| 11 |
+
"suite_position": "tasks_13_to_20",
|
| 12 |
"model_family": "minimal_ridge_projection_cosine_retrieval",
|
| 13 |
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
| 14 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/imu_to_hand_pose/metrics.json
CHANGED
|
@@ -6,7 +6,7 @@
|
|
| 6 |
"status": "pass",
|
| 7 |
"task": "imu_to_hand_pose",
|
| 8 |
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
| 9 |
-
"
|
| 10 |
"model_family": "minimal_ridge_regression",
|
| 11 |
"input": "Current IMU acceleration/gyroscope feature block only.",
|
| 12 |
"split": "single_episode_chronological",
|
|
|
|
| 6 |
"status": "pass",
|
| 7 |
"task": "imu_to_hand_pose",
|
| 8 |
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
| 9 |
+
"suite_position": "tasks_13_to_20",
|
| 10 |
"model_family": "minimal_ridge_regression",
|
| 11 |
"input": "Current IMU acceleration/gyroscope feature block only.",
|
| 12 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/interaction_text_prediction/metrics.json
CHANGED
|
@@ -8,7 +8,7 @@
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "interaction_text_prediction",
|
| 10 |
"task_display_name": "Interaction Text Prediction",
|
| 11 |
-
"
|
| 12 |
"model_family": "minimal_softmax",
|
| 13 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 14 |
"split": "single_episode_chronological",
|
|
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "interaction_text_prediction",
|
| 10 |
"task_display_name": "Interaction Text Prediction",
|
| 11 |
+
"suite_position": "tasks_13_to_20",
|
| 12 |
"model_family": "minimal_softmax",
|
| 13 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 14 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/long_horizon_next_action/metrics.json
CHANGED
|
@@ -8,7 +8,7 @@
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "long_horizon_next_action",
|
| 10 |
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
| 11 |
-
"
|
| 12 |
"model_family": "minimal_softmax",
|
| 13 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 14 |
"split": "single_episode_chronological",
|
|
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "long_horizon_next_action",
|
| 10 |
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
| 11 |
+
"suite_position": "tasks_13_to_20",
|
| 12 |
"model_family": "minimal_softmax",
|
| 13 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 14 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/neural_mlp/action_object_relation/metrics.json
CHANGED
|
@@ -8,7 +8,7 @@
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "action_object_relation",
|
| 10 |
"task_display_name": "Action-Object Relation Prediction",
|
| 11 |
-
"
|
| 12 |
"model_family": "neural_mlp",
|
| 13 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 14 |
"split": "single_episode_chronological",
|
|
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "action_object_relation",
|
| 10 |
"task_display_name": "Action-Object Relation Prediction",
|
| 11 |
+
"suite_position": "tasks_13_to_20",
|
| 12 |
"model_family": "neural_mlp",
|
| 13 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 14 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/neural_mlp/camera_view_sync_retrieval/metrics.json
CHANGED
|
@@ -8,7 +8,7 @@
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "camera_view_sync_retrieval",
|
| 10 |
"task_display_name": "Camera-View Synchronization Retrieval",
|
| 11 |
-
"
|
| 12 |
"model_family": "neural_mlp_projection_cosine_retrieval",
|
| 13 |
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
| 14 |
"split": "single_episode_chronological",
|
|
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "camera_view_sync_retrieval",
|
| 10 |
"task_display_name": "Camera-View Synchronization Retrieval",
|
| 11 |
+
"suite_position": "tasks_13_to_20",
|
| 12 |
"model_family": "neural_mlp_projection_cosine_retrieval",
|
| 13 |
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
| 14 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/neural_mlp/imu_to_hand_pose/metrics.json
CHANGED
|
@@ -6,7 +6,7 @@
|
|
| 6 |
"status": "pass",
|
| 7 |
"task": "imu_to_hand_pose",
|
| 8 |
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
| 9 |
-
"
|
| 10 |
"model_family": "neural_mlp_regression",
|
| 11 |
"input": "Current IMU acceleration/gyroscope feature block only.",
|
| 12 |
"split": "single_episode_chronological",
|
|
|
|
| 6 |
"status": "pass",
|
| 7 |
"task": "imu_to_hand_pose",
|
| 8 |
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
| 9 |
+
"suite_position": "tasks_13_to_20",
|
| 10 |
"model_family": "neural_mlp_regression",
|
| 11 |
"input": "Current IMU acceleration/gyroscope feature block only.",
|
| 12 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/neural_mlp/interaction_text_prediction/metrics.json
CHANGED
|
@@ -8,7 +8,7 @@
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "interaction_text_prediction",
|
| 10 |
"task_display_name": "Interaction Text Prediction",
|
| 11 |
-
"
|
| 12 |
"model_family": "neural_mlp",
|
| 13 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 14 |
"split": "single_episode_chronological",
|
|
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "interaction_text_prediction",
|
| 10 |
"task_display_name": "Interaction Text Prediction",
|
| 11 |
+
"suite_position": "tasks_13_to_20",
|
| 12 |
"model_family": "neural_mlp",
|
| 13 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 14 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/neural_mlp/long_horizon_next_action/metrics.json
CHANGED
|
@@ -8,7 +8,7 @@
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "long_horizon_next_action",
|
| 10 |
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
| 11 |
-
"
|
| 12 |
"model_family": "neural_mlp",
|
| 13 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 14 |
"split": "single_episode_chronological",
|
|
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "long_horizon_next_action",
|
| 10 |
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
| 11 |
+
"suite_position": "tasks_13_to_20",
|
| 12 |
"model_family": "neural_mlp",
|
| 13 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 14 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/neural_mlp/object_set_forecast/metrics.json
CHANGED
|
@@ -7,7 +7,7 @@
|
|
| 7 |
"status": "pass",
|
| 8 |
"task": "object_set_forecast",
|
| 9 |
"task_display_name": "Future Object-Set Forecasting",
|
| 10 |
-
"
|
| 11 |
"model_family": "neural_mlp_multilabel",
|
| 12 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 13 |
"split": "single_episode_chronological",
|
|
|
|
| 7 |
"status": "pass",
|
| 8 |
"task": "object_set_forecast",
|
| 9 |
"task_display_name": "Future Object-Set Forecasting",
|
| 10 |
+
"suite_position": "tasks_13_to_20",
|
| 11 |
"model_family": "neural_mlp_multilabel",
|
| 12 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 13 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/neural_mlp/time_to_transition/metrics.json
CHANGED
|
@@ -7,7 +7,7 @@
|
|
| 7 |
"status": "pass",
|
| 8 |
"task": "time_to_transition",
|
| 9 |
"task_display_name": "Time-to-Next-Transition Regression",
|
| 10 |
-
"
|
| 11 |
"model_family": "neural_mlp_regression",
|
| 12 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 13 |
"split": "single_episode_chronological",
|
|
|
|
| 7 |
"status": "pass",
|
| 8 |
"task": "time_to_transition",
|
| 9 |
"task_display_name": "Time-to-Next-Transition Regression",
|
| 10 |
+
"suite_position": "tasks_13_to_20",
|
| 11 |
"model_family": "neural_mlp_regression",
|
| 12 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 13 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/next_subtask_forecast/metrics.json
CHANGED
|
@@ -8,7 +8,7 @@
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "next_subtask_forecast",
|
| 10 |
"task_display_name": "Long-Horizon Next-Subtask Forecasting",
|
| 11 |
-
"
|
| 12 |
"model_family": "minimal_softmax",
|
| 13 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 14 |
"split": "single_episode_chronological",
|
|
|
|
| 8 |
"status": "pass",
|
| 9 |
"task": "next_subtask_forecast",
|
| 10 |
"task_display_name": "Long-Horizon Next-Subtask Forecasting",
|
| 11 |
+
"suite_position": "tasks_13_to_20",
|
| 12 |
"model_family": "minimal_softmax",
|
| 13 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 14 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/object_set_forecast/metrics.json
CHANGED
|
@@ -7,7 +7,7 @@
|
|
| 7 |
"status": "pass",
|
| 8 |
"task": "object_set_forecast",
|
| 9 |
"task_display_name": "Future Object-Set Forecasting",
|
| 10 |
-
"
|
| 11 |
"model_family": "minimal_ridge_multilabel",
|
| 12 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 13 |
"split": "single_episode_chronological",
|
|
|
|
| 7 |
"status": "pass",
|
| 8 |
"task": "object_set_forecast",
|
| 9 |
"task_display_name": "Future Object-Set Forecasting",
|
| 10 |
+
"suite_position": "tasks_13_to_20",
|
| 11 |
"model_family": "minimal_ridge_multilabel",
|
| 12 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 13 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json
CHANGED
|
@@ -1,14 +1,15 @@
|
|
| 1 |
{
|
| 2 |
-
"title": "Ropedia Xperience-10M
|
| 3 |
"status": "pass",
|
| 4 |
-
"generated_at_utc": "2026-06-
|
| 5 |
-
"
|
| 6 |
-
"
|
| 7 |
-
|
| 8 |
-
"
|
|
|
|
| 9 |
"combined_task_count": 20,
|
| 10 |
-
"
|
| 11 |
-
"
|
| 12 |
},
|
| 13 |
"dataset_scope": {
|
| 14 |
"sample_episode_count": 1,
|
|
@@ -27,9 +28,9 @@
|
|
| 27 |
"raw_data_redistributed": false
|
| 28 |
},
|
| 29 |
"setup_alignment": {
|
| 30 |
-
"
|
| 31 |
-
"
|
| 32 |
-
"
|
| 33 |
"minimal_baselines": "softmax, ridge regression/projection, and ridge multilabel heads",
|
| 34 |
"neural_baselines": "compact one-hidden-layer/two-layer PyTorch MLP heads with the same chronological split",
|
| 35 |
"leakage_policy": "Caption-derived text features are removed whenever the target is a label, object, relation, interaction phrase, or future semantic state."
|
|
@@ -134,7 +135,7 @@
|
|
| 134 |
"status": "pass",
|
| 135 |
"task": "long_horizon_next_action",
|
| 136 |
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
| 137 |
-
"
|
| 138 |
"model_family": "minimal_softmax",
|
| 139 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 140 |
"split": "single_episode_chronological",
|
|
@@ -220,7 +221,7 @@
|
|
| 220 |
"status": "pass",
|
| 221 |
"task": "long_horizon_next_action",
|
| 222 |
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
| 223 |
-
"
|
| 224 |
"model_family": "neural_mlp",
|
| 225 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 226 |
"split": "single_episode_chronological",
|
|
@@ -275,7 +276,7 @@
|
|
| 275 |
"status": "pass",
|
| 276 |
"task": "next_subtask_forecast",
|
| 277 |
"task_display_name": "Long-Horizon Next-Subtask Forecasting",
|
| 278 |
-
"
|
| 279 |
"model_family": "minimal_softmax",
|
| 280 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 281 |
"split": "single_episode_chronological",
|
|
@@ -360,7 +361,7 @@
|
|
| 360 |
"status": "pass",
|
| 361 |
"task": "next_subtask_forecast",
|
| 362 |
"task_display_name": "Long-Horizon Next-Subtask Forecasting",
|
| 363 |
-
"
|
| 364 |
"model_family": "neural_mlp",
|
| 365 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 366 |
"split": "single_episode_chronological",
|
|
@@ -415,7 +416,7 @@
|
|
| 415 |
"status": "pass",
|
| 416 |
"task": "interaction_text_prediction",
|
| 417 |
"task_display_name": "Interaction Text Prediction",
|
| 418 |
-
"
|
| 419 |
"model_family": "minimal_softmax",
|
| 420 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 421 |
"split": "single_episode_chronological",
|
|
@@ -511,7 +512,7 @@
|
|
| 511 |
"status": "pass",
|
| 512 |
"task": "interaction_text_prediction",
|
| 513 |
"task_display_name": "Interaction Text Prediction",
|
| 514 |
-
"
|
| 515 |
"model_family": "neural_mlp",
|
| 516 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 517 |
"split": "single_episode_chronological",
|
|
@@ -566,7 +567,7 @@
|
|
| 566 |
"status": "pass",
|
| 567 |
"task": "action_object_relation",
|
| 568 |
"task_display_name": "Action-Object Relation Prediction",
|
| 569 |
-
"
|
| 570 |
"model_family": "minimal_softmax",
|
| 571 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 572 |
"split": "single_episode_chronological",
|
|
@@ -658,7 +659,7 @@
|
|
| 658 |
"status": "pass",
|
| 659 |
"task": "action_object_relation",
|
| 660 |
"task_display_name": "Action-Object Relation Prediction",
|
| 661 |
-
"
|
| 662 |
"model_family": "neural_mlp",
|
| 663 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 664 |
"split": "single_episode_chronological",
|
|
@@ -712,7 +713,7 @@
|
|
| 712 |
"status": "pass",
|
| 713 |
"task": "object_set_forecast",
|
| 714 |
"task_display_name": "Future Object-Set Forecasting",
|
| 715 |
-
"
|
| 716 |
"model_family": "minimal_ridge_multilabel",
|
| 717 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 718 |
"split": "single_episode_chronological",
|
|
@@ -746,7 +747,7 @@
|
|
| 746 |
"status": "pass",
|
| 747 |
"task": "object_set_forecast",
|
| 748 |
"task_display_name": "Future Object-Set Forecasting",
|
| 749 |
-
"
|
| 750 |
"model_family": "neural_mlp_multilabel",
|
| 751 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 752 |
"split": "single_episode_chronological",
|
|
@@ -794,7 +795,7 @@
|
|
| 794 |
"status": "pass",
|
| 795 |
"task": "imu_to_hand_pose",
|
| 796 |
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
| 797 |
-
"
|
| 798 |
"model_family": "minimal_ridge_regression",
|
| 799 |
"input": "Current IMU acceleration/gyroscope feature block only.",
|
| 800 |
"split": "single_episode_chronological",
|
|
@@ -813,7 +814,7 @@
|
|
| 813 |
"status": "pass",
|
| 814 |
"task": "imu_to_hand_pose",
|
| 815 |
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
| 816 |
-
"
|
| 817 |
"model_family": "neural_mlp_regression",
|
| 818 |
"input": "Current IMU acceleration/gyroscope feature block only.",
|
| 819 |
"split": "single_episode_chronological",
|
|
@@ -863,7 +864,7 @@
|
|
| 863 |
"status": "pass",
|
| 864 |
"task": "camera_view_sync_retrieval",
|
| 865 |
"task_display_name": "Camera-View Synchronization Retrieval",
|
| 866 |
-
"
|
| 867 |
"model_family": "minimal_ridge_projection_cosine_retrieval",
|
| 868 |
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
| 869 |
"split": "single_episode_chronological",
|
|
@@ -884,7 +885,7 @@
|
|
| 884 |
"status": "pass",
|
| 885 |
"task": "camera_view_sync_retrieval",
|
| 886 |
"task_display_name": "Camera-View Synchronization Retrieval",
|
| 887 |
-
"
|
| 888 |
"model_family": "neural_mlp_projection_cosine_retrieval",
|
| 889 |
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
| 890 |
"split": "single_episode_chronological",
|
|
@@ -933,7 +934,7 @@
|
|
| 933 |
"status": "pass",
|
| 934 |
"task": "time_to_transition",
|
| 935 |
"task_display_name": "Time-to-Next-Transition Regression",
|
| 936 |
-
"
|
| 937 |
"model_family": "minimal_ridge_regression",
|
| 938 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 939 |
"split": "single_episode_chronological",
|
|
@@ -953,7 +954,7 @@
|
|
| 953 |
"status": "pass",
|
| 954 |
"task": "time_to_transition",
|
| 955 |
"task_display_name": "Time-to-Next-Transition Regression",
|
| 956 |
-
"
|
| 957 |
"model_family": "neural_mlp_regression",
|
| 958 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 959 |
"split": "single_episode_chronological",
|
|
|
|
| 1 |
{
|
| 2 |
+
"title": "Ropedia Xperience-10M Unified Tasks 13-20 Result Bundle",
|
| 3 |
"status": "pass",
|
| 4 |
+
"generated_at_utc": "2026-06-16T04:47:52+00:00",
|
| 5 |
+
"suite_position": "tasks_13_to_20",
|
| 6 |
+
"legacy_path_note": "The tier2_task_suite file and directory names are retained for stable public links; these tasks are part of the unified 20-task suite, not a separate public tier.",
|
| 7 |
+
"integrated_with_tasks_1_to_12": {
|
| 8 |
+
"tasks_1_to_12_count": 12,
|
| 9 |
+
"additional_task_count": 8,
|
| 10 |
"combined_task_count": 20,
|
| 11 |
+
"tasks_1_to_12_metrics": "docs/data/summary_metrics.json",
|
| 12 |
+
"unified_protocol": "docs/data/evaluation_protocol.json"
|
| 13 |
},
|
| 14 |
"dataset_scope": {
|
| 15 |
"sample_episode_count": 1,
|
|
|
|
| 28 |
"raw_data_redistributed": false
|
| 29 |
},
|
| 30 |
"setup_alignment": {
|
| 31 |
+
"same_window_unit_as_tasks_1_to_12": true,
|
| 32 |
+
"same_feature_manifest_as_tasks_1_to_12": "results/episode_task_suite/feature_manifest.json",
|
| 33 |
+
"same_shared_tensor_as_tasks_1_to_12": "results/episode_task_suite/shared_windows.npz",
|
| 34 |
"minimal_baselines": "softmax, ridge regression/projection, and ridge multilabel heads",
|
| 35 |
"neural_baselines": "compact one-hidden-layer/two-layer PyTorch MLP heads with the same chronological split",
|
| 36 |
"leakage_policy": "Caption-derived text features are removed whenever the target is a label, object, relation, interaction phrase, or future semantic state."
|
|
|
|
| 135 |
"status": "pass",
|
| 136 |
"task": "long_horizon_next_action",
|
| 137 |
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
| 138 |
+
"suite_position": "tasks_13_to_20",
|
| 139 |
"model_family": "minimal_softmax",
|
| 140 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 141 |
"split": "single_episode_chronological",
|
|
|
|
| 221 |
"status": "pass",
|
| 222 |
"task": "long_horizon_next_action",
|
| 223 |
"task_display_name": "Long-Horizon Next-Action Forecasting",
|
| 224 |
+
"suite_position": "tasks_13_to_20",
|
| 225 |
"model_family": "neural_mlp",
|
| 226 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 227 |
"split": "single_episode_chronological",
|
|
|
|
| 276 |
"status": "pass",
|
| 277 |
"task": "next_subtask_forecast",
|
| 278 |
"task_display_name": "Long-Horizon Next-Subtask Forecasting",
|
| 279 |
+
"suite_position": "tasks_13_to_20",
|
| 280 |
"model_family": "minimal_softmax",
|
| 281 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 282 |
"split": "single_episode_chronological",
|
|
|
|
| 361 |
"status": "pass",
|
| 362 |
"task": "next_subtask_forecast",
|
| 363 |
"task_display_name": "Long-Horizon Next-Subtask Forecasting",
|
| 364 |
+
"suite_position": "tasks_13_to_20",
|
| 365 |
"model_family": "neural_mlp",
|
| 366 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 367 |
"split": "single_episode_chronological",
|
|
|
|
| 416 |
"status": "pass",
|
| 417 |
"task": "interaction_text_prediction",
|
| 418 |
"task_display_name": "Interaction Text Prediction",
|
| 419 |
+
"suite_position": "tasks_13_to_20",
|
| 420 |
"model_family": "minimal_softmax",
|
| 421 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 422 |
"split": "single_episode_chronological",
|
|
|
|
| 512 |
"status": "pass",
|
| 513 |
"task": "interaction_text_prediction",
|
| 514 |
"task_display_name": "Interaction Text Prediction",
|
| 515 |
+
"suite_position": "tasks_13_to_20",
|
| 516 |
"model_family": "neural_mlp",
|
| 517 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 518 |
"split": "single_episode_chronological",
|
|
|
|
| 567 |
"status": "pass",
|
| 568 |
"task": "action_object_relation",
|
| 569 |
"task_display_name": "Action-Object Relation Prediction",
|
| 570 |
+
"suite_position": "tasks_13_to_20",
|
| 571 |
"model_family": "minimal_softmax",
|
| 572 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 573 |
"split": "single_episode_chronological",
|
|
|
|
| 659 |
"status": "pass",
|
| 660 |
"task": "action_object_relation",
|
| 661 |
"task_display_name": "Action-Object Relation Prediction",
|
| 662 |
+
"suite_position": "tasks_13_to_20",
|
| 663 |
"model_family": "neural_mlp",
|
| 664 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 665 |
"split": "single_episode_chronological",
|
|
|
|
| 713 |
"status": "pass",
|
| 714 |
"task": "object_set_forecast",
|
| 715 |
"task_display_name": "Future Object-Set Forecasting",
|
| 716 |
+
"suite_position": "tasks_13_to_20",
|
| 717 |
"model_family": "minimal_ridge_multilabel",
|
| 718 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 719 |
"split": "single_episode_chronological",
|
|
|
|
| 747 |
"status": "pass",
|
| 748 |
"task": "object_set_forecast",
|
| 749 |
"task_display_name": "Future Object-Set Forecasting",
|
| 750 |
+
"suite_position": "tasks_13_to_20",
|
| 751 |
"model_family": "neural_mlp_multilabel",
|
| 752 |
"input": "Current 20-frame sensor window with caption-text features removed.",
|
| 753 |
"split": "single_episode_chronological",
|
|
|
|
| 795 |
"status": "pass",
|
| 796 |
"task": "imu_to_hand_pose",
|
| 797 |
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
| 798 |
+
"suite_position": "tasks_13_to_20",
|
| 799 |
"model_family": "minimal_ridge_regression",
|
| 800 |
"input": "Current IMU acceleration/gyroscope feature block only.",
|
| 801 |
"split": "single_episode_chronological",
|
|
|
|
| 814 |
"status": "pass",
|
| 815 |
"task": "imu_to_hand_pose",
|
| 816 |
"task_display_name": "IMU-to-Hand Pose Reconstruction",
|
| 817 |
+
"suite_position": "tasks_13_to_20",
|
| 818 |
"model_family": "neural_mlp_regression",
|
| 819 |
"input": "Current IMU acceleration/gyroscope feature block only.",
|
| 820 |
"split": "single_episode_chronological",
|
|
|
|
| 864 |
"status": "pass",
|
| 865 |
"task": "camera_view_sync_retrieval",
|
| 866 |
"task_display_name": "Camera-View Synchronization Retrieval",
|
| 867 |
+
"suite_position": "tasks_13_to_20",
|
| 868 |
"model_family": "minimal_ridge_projection_cosine_retrieval",
|
| 869 |
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
| 870 |
"split": "single_episode_chronological",
|
|
|
|
| 885 |
"status": "pass",
|
| 886 |
"task": "camera_view_sync_retrieval",
|
| 887 |
"task_display_name": "Camera-View Synchronization Retrieval",
|
| 888 |
+
"suite_position": "tasks_13_to_20",
|
| 889 |
"model_family": "neural_mlp_projection_cosine_retrieval",
|
| 890 |
"input": "Fisheye camera-1 feature query projected into fisheye camera-3 feature space.",
|
| 891 |
"split": "single_episode_chronological",
|
|
|
|
| 934 |
"status": "pass",
|
| 935 |
"task": "time_to_transition",
|
| 936 |
"task_display_name": "Time-to-Next-Transition Regression",
|
| 937 |
+
"suite_position": "tasks_13_to_20",
|
| 938 |
"model_family": "minimal_ridge_regression",
|
| 939 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 940 |
"split": "single_episode_chronological",
|
|
|
|
| 954 |
"status": "pass",
|
| 955 |
"task": "time_to_transition",
|
| 956 |
"task_display_name": "Time-to-Next-Transition Regression",
|
| 957 |
+
"suite_position": "tasks_13_to_20",
|
| 958 |
"model_family": "neural_mlp_regression",
|
| 959 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 960 |
"split": "single_episode_chronological",
|
results/episode_task_suite/tier2_task_suite/time_to_transition/metrics.json
CHANGED
|
@@ -7,7 +7,7 @@
|
|
| 7 |
"status": "pass",
|
| 8 |
"task": "time_to_transition",
|
| 9 |
"task_display_name": "Time-to-Next-Transition Regression",
|
| 10 |
-
"
|
| 11 |
"model_family": "minimal_ridge_regression",
|
| 12 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 13 |
"split": "single_episode_chronological",
|
|
|
|
| 7 |
"status": "pass",
|
| 8 |
"task": "time_to_transition",
|
| 9 |
"task_display_name": "Time-to-Next-Transition Regression",
|
| 10 |
+
"suite_position": "tasks_13_to_20",
|
| 11 |
"model_family": "minimal_ridge_regression",
|
| 12 |
"input": "Current 20-frame non-caption multimodal window.",
|
| 13 |
"split": "single_episode_chronological",
|