
Datasets:
Add files using upload-large-folder tool
Browse files- ARTIFACT_GUIDE.md +1 -1
- EVALUATION_PROTOCOL.md +4 -5
- FIGURE_INDEX.md +1 -1
- GLOSSARY.md +1 -1
- PROJECT_BRIEF.md +1 -1
- PROJECT_README.md +18 -20
- PROJECT_STATUS.md +2 -2
- README.md +3 -3
- REPRODUCIBILITY.md +4 -4
- TASK_SUITE_20.md +3 -4
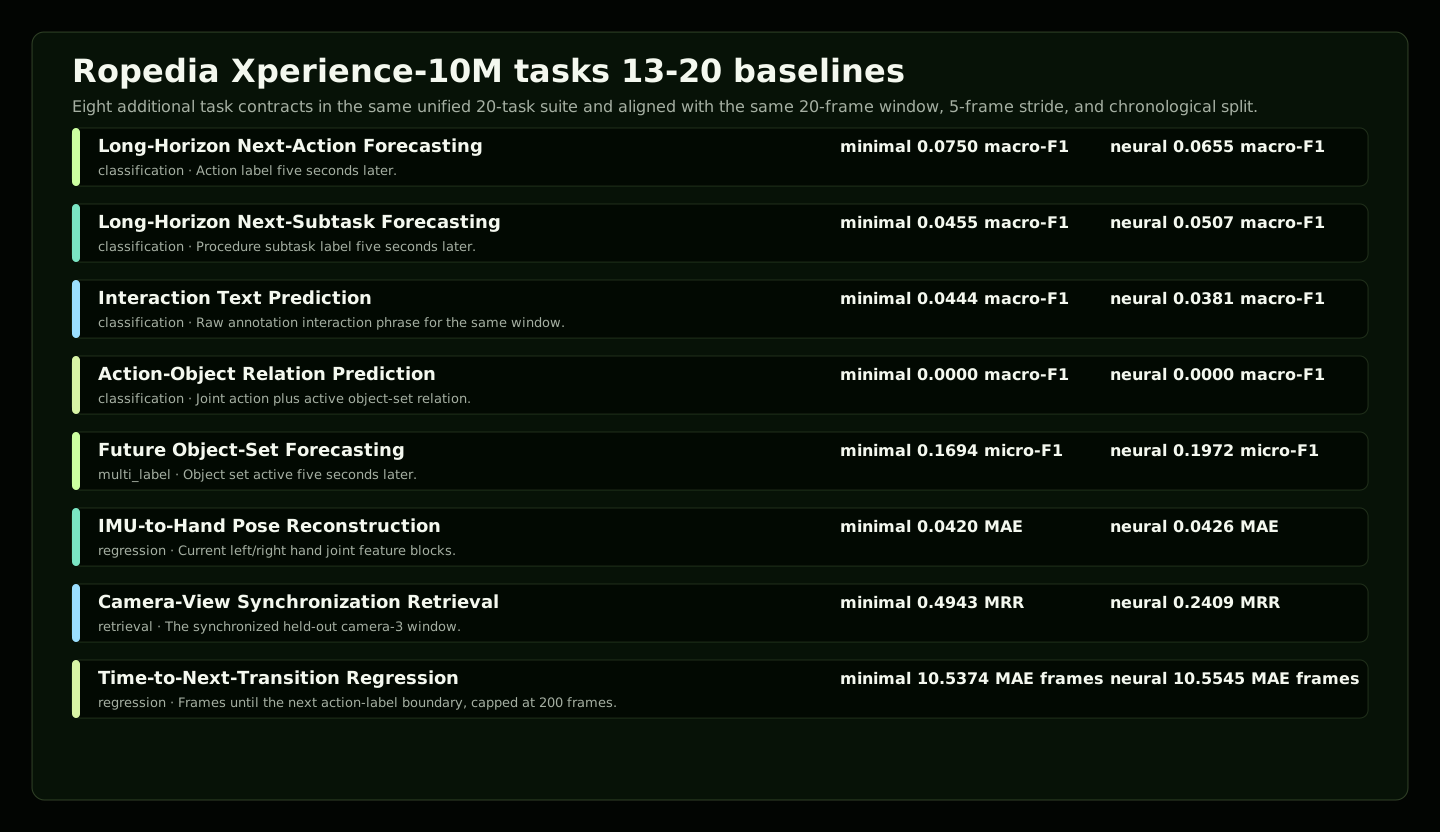
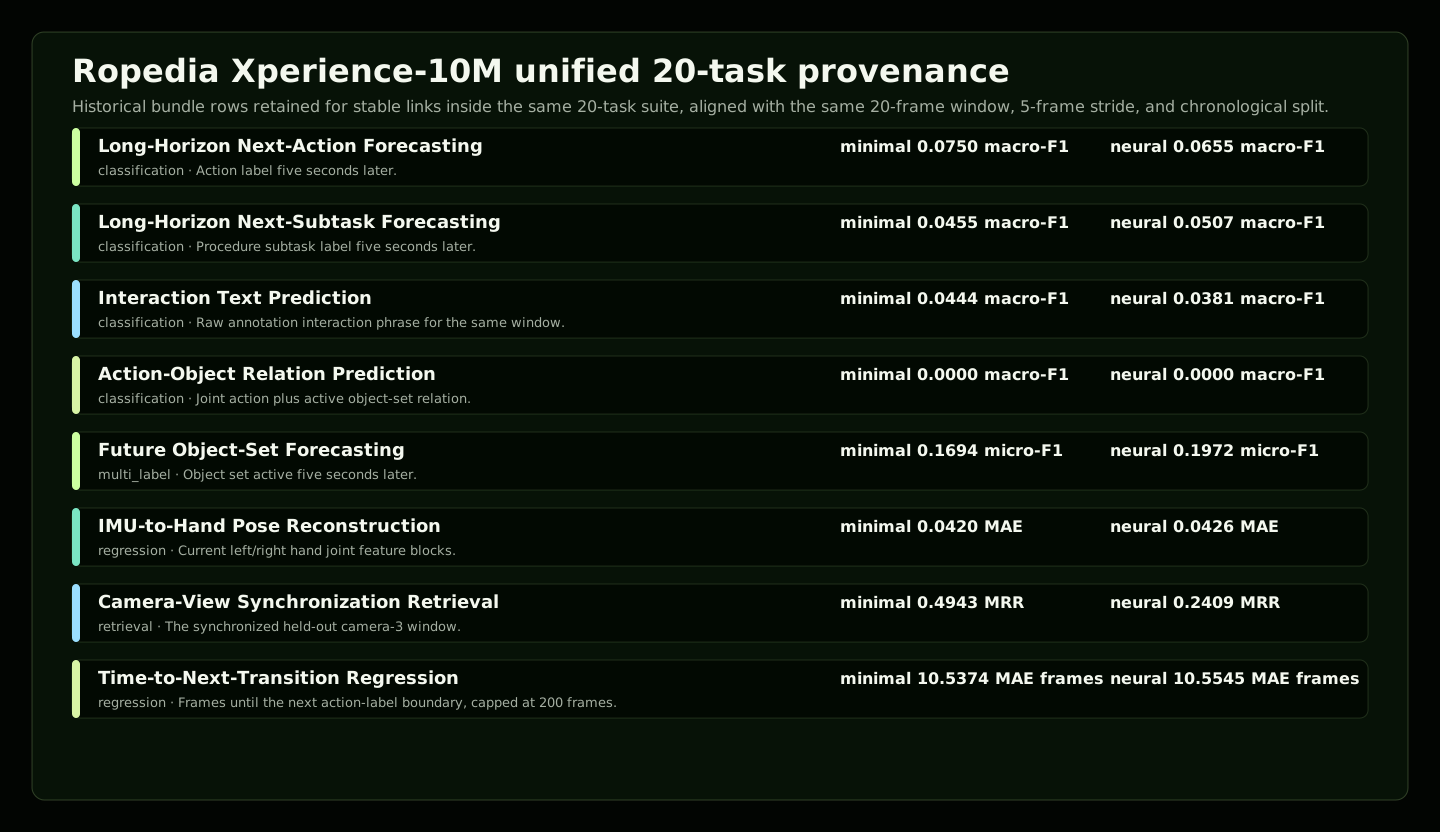
- assets/charts/tier2_task_suite.svg +3 -3
- data/evaluation_protocol.json +2 -2
- data/publication_audit.json +3 -3
- data/scope_claims_audit.json +1 -1
- docs/assets/charts/tier2_task_suite.svg +3 -3
- docs/data/artifact_index.json +56 -56
- docs/data/evaluation_protocol.json +2 -2
- docs/data/figure_index.json +3 -3
- docs/data/glossary.json +2 -2
- docs/data/mirror_parity.json +331 -331
- docs/data/public_surface_qa.json +7 -7
- docs/data/publication_audit.json +3 -3
- docs/data/quality_gates.json +1 -1
- docs/data/scope_claims_audit.json +1 -1
- docs/data/source_alignment_audit.json +1 -1
- docs/data/task_suite_20.json +2 -2
- docs/data/task_surface_integrity.json +1 -1
- docs/data/tier2_task_suite.json +2 -2
- docs/data/website_integrity.json +15 -15
- docs/index.html +108 -25
- index.html +108 -25
- results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md +4 -5
- results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json +2 -2
- scripts/build_evaluation_protocol.py +5 -6
- scripts/build_figure_index.py +2 -2
- scripts/render_task_suite_infographic.py +1 -1
- scripts/sync_hf_publish_mirrors.py +24 -9
- scripts/verify_live_publication.py +9 -9
ARTIFACT_GUIDE.md
CHANGED
|
@@ -78,7 +78,7 @@ Xperience-native pretraining goal.
|
|
| 78 |
| [`results/episode_task_suite/neural_mlp/`](results/episode_task_suite/neural_mlp/) | Matching PyTorch MLP heads for the same task contracts and feature windows. |
|
| 79 |
| [`results/episode_task_suite/research_directions/`](results/episode_task_suite/research_directions/) | Mapping from the unified 20-task suite to the four Ropedia research directions. |
|
| 80 |
| [`results/episode_task_suite/research_direction_extensions/`](results/episode_task_suite/research_direction_extensions/) | Four additional coded probes, one per research direction. |
|
| 81 |
-
| [`results/episode_task_suite/tier2_task_suite/`](results/episode_task_suite/tier2_task_suite/) | Historical
|
| 82 |
| [`results/episode_task_suite/task_walkthroughs/`](results/episode_task_suite/task_walkthroughs/) | Human-readable research names and case studies explaining input, process modules, output, metric, limitation, and the website task-player data. |
|
| 83 |
| [`results/audio_ablation/audio_ablation_metrics.csv`](results/audio_ablation/audio_ablation_metrics.csv) | All measured audio rows for the original task contracts across six variants, including no-audio, audio-only, alternate-audio-only, representation replacement, and all-input variants. |
|
| 84 |
| [`results/audio_ablation/audio_delta_summary.csv`](results/audio_ablation/audio_delta_summary.csv) | Compact per-task audio delta table for quick manual inspection. |
|
|
|
|
| 78 |
| [`results/episode_task_suite/neural_mlp/`](results/episode_task_suite/neural_mlp/) | Matching PyTorch MLP heads for the same task contracts and feature windows. |
|
| 79 |
| [`results/episode_task_suite/research_directions/`](results/episode_task_suite/research_directions/) | Mapping from the unified 20-task suite to the four Ropedia research directions. |
|
| 80 |
| [`results/episode_task_suite/research_direction_extensions/`](results/episode_task_suite/research_direction_extensions/) | Four additional coded probes, one per research direction. |
|
| 81 |
+
| [`results/episode_task_suite/tier2_task_suite/`](results/episode_task_suite/tier2_task_suite/) | Historical provenance path inside the unified 20-task suite. |
|
| 82 |
| [`results/episode_task_suite/task_walkthroughs/`](results/episode_task_suite/task_walkthroughs/) | Human-readable research names and case studies explaining input, process modules, output, metric, limitation, and the website task-player data. |
|
| 83 |
| [`results/audio_ablation/audio_ablation_metrics.csv`](results/audio_ablation/audio_ablation_metrics.csv) | All measured audio rows for the original task contracts across six variants, including no-audio, audio-only, alternate-audio-only, representation replacement, and all-input variants. |
|
| 84 |
| [`results/audio_ablation/audio_delta_summary.csv`](results/audio_ablation/audio_delta_summary.csv) | Compact per-task audio delta table for quick manual inspection. |
|
EVALUATION_PROTOCOL.md
CHANGED
|
@@ -45,11 +45,10 @@ are not foundation models.
|
|
| 45 |
|
| 46 |
## Unified 20-Task Contracts
|
| 47 |
|
| 48 |
-
|
| 49 |
-
|
| 50 |
-
|
| 51 |
-
|
| 52 |
-
stable artifact locations for tasks 13-20.
|
| 53 |
|
| 54 |
| # | Task | Artifact id | Origin | Family | Unit | Input -> target | Primary metric | Minimal | Neural |
|
| 55 |
| ---: | --- | --- | --- | --- | --- | --- | --- | ---: | ---: |
|
|
|
|
| 45 |
|
| 46 |
## Unified 20-Task Contracts
|
| 47 |
|
| 48 |
+
All 20 public-sample task contracts are presented together under the same
|
| 49 |
+
20-frame window, feature, chronological split, leakage-control, and
|
| 50 |
+
minimal/neural baseline setup. Historical `tier2_task_suite` paths are
|
| 51 |
+
retained only as stable provenance artifact locations inside the unified suite.
|
|
|
|
| 52 |
|
| 53 |
| # | Task | Artifact id | Origin | Family | Unit | Input -> target | Primary metric | Minimal | Neural |
|
| 54 |
| ---: | --- | --- | --- | --- | --- | --- | --- | ---: | ---: |
|
FIGURE_INDEX.md
CHANGED
|
@@ -33,7 +33,7 @@ Public figures, diagrams, charts, and derived modality thumbnails. Raw Xperience
|
|
| 33 |
| Minimal-vs-neural task score chart | `docs/assets/charts/episode_task_scores_minimal_vs_neural.svg` | 1100 x 964 | `scripts/generate_visualizations.py` | Side-by-side baseline comparison over the same window contracts. |
|
| 34 |
| Research direction coverage chart | `docs/assets/charts/research_direction_coverage.svg` | 1180 x 700 | `scripts/generate_visualizations.py` | Four-track coverage map for Ropedia research directions. |
|
| 35 |
| Research direction extension chart | `docs/assets/charts/research_direction_extension_tasks.svg` | 1420 x 920 | `scripts/generate_visualizations.py` | Four coded extension probes, one per Ropedia research direction. |
|
| 36 |
-
|
|
| 37 |
| Unified 20-task model radar | `docs/assets/charts/unified_task_model_radar.svg` | 2400 x 1840 | `scripts/build_unified_task_model_radar.py` | Twenty-axis direction-aware comparison of minimal and neural MLP baselines, with 128-episode metadata, Qwen3, and Cosmos task-aligned overlay points and branch notes. |
|
| 38 |
| Single-episode 20-task model radar | `docs/assets/charts/single_episode_task_model_radar.svg` | 2400 x 1840 | `scripts/build_unified_task_model_radar.py` | Twenty-axis split radar for the one public-sample episode, comparing Minimal and Neural MLP as two complete 20/20 scored polygons. |
|
| 39 |
| 128-episode 20-task model radar | `docs/assets/charts/episode128_task_model_radar.svg` | 2400 x 1840 | `scripts/build_unified_task_model_radar.py` | Twenty-axis split radar for selected 128-episode methods: raw-feature simple/NN as complete scored polygons plus metadata, Qwen3-Omni, Cosmos3-Super, and Cosmos3-Nano task-aligned overlays. |
|
|
|
|
| 33 |
| Minimal-vs-neural task score chart | `docs/assets/charts/episode_task_scores_minimal_vs_neural.svg` | 1100 x 964 | `scripts/generate_visualizations.py` | Side-by-side baseline comparison over the same window contracts. |
|
| 34 |
| Research direction coverage chart | `docs/assets/charts/research_direction_coverage.svg` | 1180 x 700 | `scripts/generate_visualizations.py` | Four-track coverage map for Ropedia research directions. |
|
| 35 |
| Research direction extension chart | `docs/assets/charts/research_direction_extension_tasks.svg` | 1420 x 920 | `scripts/generate_visualizations.py` | Four coded extension probes, one per Ropedia research direction. |
|
| 36 |
+
| Unified 20-task provenance chart | `docs/assets/charts/tier2_task_suite.svg` | 1440 x 832 | `scripts/tier2_task_suite.py` | Historical provenance rows inside the unified 20-task suite with aligned minimal and neural baseline metrics. |
|
| 37 |
| Unified 20-task model radar | `docs/assets/charts/unified_task_model_radar.svg` | 2400 x 1840 | `scripts/build_unified_task_model_radar.py` | Twenty-axis direction-aware comparison of minimal and neural MLP baselines, with 128-episode metadata, Qwen3, and Cosmos task-aligned overlay points and branch notes. |
|
| 38 |
| Single-episode 20-task model radar | `docs/assets/charts/single_episode_task_model_radar.svg` | 2400 x 1840 | `scripts/build_unified_task_model_radar.py` | Twenty-axis split radar for the one public-sample episode, comparing Minimal and Neural MLP as two complete 20/20 scored polygons. |
|
| 39 |
| 128-episode 20-task model radar | `docs/assets/charts/episode128_task_model_radar.svg` | 2400 x 1840 | `scripts/build_unified_task_model_radar.py` | Twenty-axis split radar for selected 128-episode methods: raw-feature simple/NN as complete scored polygons plus metadata, Qwen3-Omni, Cosmos3-Super, and Cosmos3-Nano task-aligned overlays. |
|
GLOSSARY.md
CHANGED
|
@@ -35,7 +35,7 @@ machine-readable form.
|
|
| 35 |
| Interaction text | Natural-language interaction/caption content. | Used by task 15 and some derived text features; public matrices record when text targets are direct or compact-proxy. | Numeric action ids or subtask ids. |
|
| 36 |
| Modality | A type of signal. | Video, audio, depth, pose/SLAM, motion capture, inertial, calibration, and language-derived signals. | A task target. |
|
| 37 |
| Task contract | The definition of one benchmark task. | Includes input, target/output, metric, split, source artifact, and limitation. | A model architecture. |
|
| 38 |
-
| Unified 20-task suite | The current task surface. |
|
| 39 |
| Task-method record | One method evaluated on one task. | 9 methods x 20 tasks gives 180 public result records. | A single prediction row. |
|
| 40 |
| Direct score | A metric computed against the task target directly. | The preferred score type in the 20-task matrix. | Compact-proxy score. |
|
| 41 |
| Compact-proxy score | A bounded proxy metric when a direct raw target is not publicly available. | Kept explicit in the matrix and gap audit so readers do not over-read it. | A direct target measurement. |
|
|
|
|
| 35 |
| Interaction text | Natural-language interaction/caption content. | Used by task 15 and some derived text features; public matrices record when text targets are direct or compact-proxy. | Numeric action ids or subtask ids. |
|
| 36 |
| Modality | A type of signal. | Video, audio, depth, pose/SLAM, motion capture, inertial, calibration, and language-derived signals. | A task target. |
|
| 37 |
| Task contract | The definition of one benchmark task. | Includes input, target/output, metric, split, source artifact, and limitation. | A model architecture. |
|
| 38 |
+
| Unified 20-task suite | The current task surface. | All 20 task contracts are presented together and scored across methods where real artifacts exist. | Historical `tier2_task_suite` filenames; those are provenance paths, not a second suite. |
|
| 39 |
| Task-method record | One method evaluated on one task. | 9 methods x 20 tasks gives 180 public result records. | A single prediction row. |
|
| 40 |
| Direct score | A metric computed against the task target directly. | The preferred score type in the 20-task matrix. | Compact-proxy score. |
|
| 41 |
| Compact-proxy score | A bounded proxy metric when a direct raw target is not publicly available. | Kept explicit in the matrix and gap audit so readers do not over-read it. | A direct target measurement. |
|
PROJECT_BRIEF.md
CHANGED
|
@@ -47,7 +47,7 @@ model-quality claims.
|
|
| 47 |
4. Open `EVALUATION_PROTOCOL.md` before comparing task scores.
|
| 48 |
5. Use `RESEARCH_TAKEAWAYS.md` for the current metric interpretation.
|
| 49 |
6. Inspect `results/episode_task_suite/feature_manifest.json` to understand one model input.
|
| 50 |
-
7. Use `TASK_SUITE_20.md` and `docs/data/task_suite_20.json` to read the unified 20-task suite; the historical `docs/data/tier2_task_suite.json` path stores
|
| 51 |
8. Use `QWEN3_OMNI_RUN_LINEAGE.md` and `docs/data/qwen3_omni_run_lineage.json` to read v1-v6 correctly.
|
| 52 |
9. Use `docs/data/omni_finetune_verified_result.json` for the current multi-episode Qwen3-Omni v6 result.
|
| 53 |
|
|
|
|
| 47 |
4. Open `EVALUATION_PROTOCOL.md` before comparing task scores.
|
| 48 |
5. Use `RESEARCH_TAKEAWAYS.md` for the current metric interpretation.
|
| 49 |
6. Inspect `results/episode_task_suite/feature_manifest.json` to understand one model input.
|
| 50 |
+
7. Use `TASK_SUITE_20.md` and `docs/data/task_suite_20.json` to read the unified 20-task suite; the historical `docs/data/tier2_task_suite.json` path stores provenance rows inside that same suite.
|
| 51 |
8. Use `QWEN3_OMNI_RUN_LINEAGE.md` and `docs/data/qwen3_omni_run_lineage.json` to read v1-v6 correctly.
|
| 52 |
9. Use `docs/data/omni_finetune_verified_result.json` for the current multi-episode Qwen3-Omni v6 result.
|
| 53 |
|
PROJECT_README.md
CHANGED
|
@@ -428,7 +428,7 @@ Public release checks are exposed as JSON for mirrors and dashboards:
|
|
| 428 |
<tbody>
|
| 429 |
<tr><td><strong>Dataset slice</strong></td><td>One public Xperience-10M sample episode, 5,821 frames, 1,161 windows, and an 8,546-dimensional representation.</td></tr>
|
| 430 |
<tr><td><strong>Modalities</strong></td><td>Video, audio, depth, camera pose/SLAM, hand/body mocap, IMU, calibration, and language annotations.</td></tr>
|
| 431 |
-
<tr><td><strong>Task suite</strong></td><td>20 human-readable tasks form one embodied-AI public-sample suite
|
| 432 |
<tr><td><strong>Baselines</strong></td><td>Minimal linear/ridge/logistic heads plus compact PyTorch MLP task heads over the same chronological split; companion simple/NN metadata baselines are also aligned to the selected 128-episode 96/16/16 split.</td></tr>
|
| 433 |
<tr><td><strong>Research directions</strong></td><td>Task mapping and extension probes for human modeling, 3D/4D reconstruction, egocentric interaction, and world modeling.</td></tr>
|
| 434 |
<tr>
|
|
@@ -460,7 +460,7 @@ Current contributions:
|
|
| 460 |
- manifested sliding-window features over the currently extracted modalities,
|
| 461 |
- motion-only and current all-feature baseline models,
|
| 462 |
- 20 end-to-end episode-level task contracts,
|
| 463 |
-
-
|
| 464 |
- lightweight neural MLP heads for the same task contracts,
|
| 465 |
- a generated four-direction research taxonomy matching the Ropedia job tracks,
|
| 466 |
- four additional direction-extension probes with minimal and neural baselines,
|
|
@@ -494,7 +494,7 @@ This project is best read as a staged embodied-AI research study:
|
|
| 494 |
<td><strong>Task suite</strong></td>
|
| 495 |
<td>
|
| 496 |
Twenty human-readable tasks cover recognition, prediction, retrieval, reconstruction, synchronization, long-horizon forecasting, interaction text, action-object binding, sensor bridging, camera sync, and transition timing.
|
| 497 |
-
|
| 498 |
</td>
|
| 499 |
<td>
|
| 500 |
<a href="TASK_SUITE_20.md">TASK_SUITE_20.md</a><br>
|
|
@@ -775,10 +775,10 @@ with [`scripts/render_task_suite_infographic.py`](scripts/render_task_suite_info
|
|
| 775 |
so the published PNG is a presentation graphic with verified labels and metrics,
|
| 776 |
not a hallucinated metric sheet.
|
| 777 |
|
| 778 |
-
The complete unified task list is
|
| 779 |
-
and [`docs/data/task_suite_20.json`](docs/data/task_suite_20.json).
|
| 780 |
-
|
| 781 |
-
|
| 782 |
|
| 783 |

|
| 784 |
|
|
@@ -854,7 +854,7 @@ scripts/
|
|
| 854 |
neural_task_models.py # optional PyTorch MLP heads for task contracts
|
| 855 |
research_direction_taxonomy.py # maps original tasks to the four research tracks
|
| 856 |
research_direction_extension_tasks.py # one extra data-backed probe per track
|
| 857 |
-
tier2_task_suite.py # historical-name builder for
|
| 858 |
build_unified_task_suite.py # builds TASK_SUITE_20.md and task_suite_20.json
|
| 859 |
build_unified_task_model_radar.py # builds the unified 20-axis model comparison chart
|
| 860 |
build_task_method_20_gap_audit.py # builds the explicit 180/180 scored-cell ledger
|
|
@@ -889,7 +889,7 @@ results/
|
|
| 889 |
neural_mlp/ # optional neural baseline artifacts per task
|
| 890 |
research_directions/ # four-track taxonomy, CSV, and summary
|
| 891 |
research_direction_extensions/ # four extra direction probes + predictions
|
| 892 |
-
tier2_task_suite/ #
|
| 893 |
task_walkthroughs/ # case-study walkthroughs for original tasks
|
| 894 |
omni_exploration/ # ModelScope readiness-check artifacts
|
| 895 |
omni_finetune/model_output_task_probes_20260616/ # task-13/task-16 probes derived from verified model JSON
|
|
@@ -915,7 +915,7 @@ docs/
|
|
| 915 |
data/research_roadmap.json # multi-episode and omni-model roadmap
|
| 916 |
data/research_directions.json # four-track website data bundle
|
| 917 |
data/research_direction_extensions.json # four extra probe data bundle
|
| 918 |
-
data/tier2_task_suite.json #
|
| 919 |
data/task_walkthroughs.json # human-readable task-card and walkthrough-storyboard data
|
| 920 |
data/modality_atlas.json # responsive modality-card data
|
| 921 |
assets/brand/*.png # project logo, favicon, social card
|
|
@@ -1037,7 +1037,7 @@ python scripts/episode_task_suite.py \
|
|
| 1037 |
--include-neural
|
| 1038 |
```
|
| 1039 |
|
| 1040 |
-
Then rebuild the unified 20-task index after
|
| 1041 |
|
| 1042 |
```bash
|
| 1043 |
python scripts/tier2_task_suite.py --workspace /path/to/workspace
|
|
@@ -1512,16 +1512,14 @@ models.
|
|
| 1512 |
|
| 1513 |
## Unified 20-Task Suite
|
| 1514 |
|
| 1515 |
-
The sample task surface is
|
| 1516 |
-
|
| 1517 |
-
|
| 1518 |
-
|
| 1519 |
-
keeping the same 20-frame window unit, 5-frame stride, chronological split, and
|
| 1520 |
-
minimal/neural comparison style.
|
| 1521 |
|
| 1522 |
The historical `tier2_task_suite` file and directory names remain only for
|
| 1523 |
-
stable artifact links. They should be read as
|
| 1524 |
-
|
| 1525 |
|
| 1526 |
- [`TASK_SUITE_20.md`](TASK_SUITE_20.md)
|
| 1527 |
- [`docs/data/task_suite_20.json`](docs/data/task_suite_20.json)
|
|
@@ -1545,7 +1543,7 @@ stable artifact links. They should be read as the result bundle for tasks
|
|
| 1545 |
|
| 1546 |

|
| 1547 |
|
| 1548 |
-

|
| 779 |
+
and [`docs/data/task_suite_20.json`](docs/data/task_suite_20.json). Historical
|
| 780 |
+
`tier2_task_suite` paths remain only as stable provenance links inside the same
|
| 781 |
+
suite.
|
| 782 |
|
| 783 |

|
| 784 |
|
|
|
|
| 854 |
neural_task_models.py # optional PyTorch MLP heads for task contracts
|
| 855 |
research_direction_taxonomy.py # maps original tasks to the four research tracks
|
| 856 |
research_direction_extension_tasks.py # one extra data-backed probe per track
|
| 857 |
+
tier2_task_suite.py # historical-name provenance builder for unified task rows
|
| 858 |
build_unified_task_suite.py # builds TASK_SUITE_20.md and task_suite_20.json
|
| 859 |
build_unified_task_model_radar.py # builds the unified 20-axis model comparison chart
|
| 860 |
build_task_method_20_gap_audit.py # builds the explicit 180/180 scored-cell ledger
|
|
|
|
| 889 |
neural_mlp/ # optional neural baseline artifacts per task
|
| 890 |
research_directions/ # four-track taxonomy, CSV, and summary
|
| 891 |
research_direction_extensions/ # four extra direction probes + predictions
|
| 892 |
+
tier2_task_suite/ # provenance baseline tasks + predictions; historical path
|
| 893 |
task_walkthroughs/ # case-study walkthroughs for original tasks
|
| 894 |
omni_exploration/ # ModelScope readiness-check artifacts
|
| 895 |
omni_finetune/model_output_task_probes_20260616/ # task-13/task-16 probes derived from verified model JSON
|
|
|
|
| 915 |
data/research_roadmap.json # multi-episode and omni-model roadmap
|
| 916 |
data/research_directions.json # four-track website data bundle
|
| 917 |
data/research_direction_extensions.json # four extra probe data bundle
|
| 918 |
+
data/tier2_task_suite.json # provenance baseline bundle; historical path
|
| 919 |
data/task_walkthroughs.json # human-readable task-card and walkthrough-storyboard data
|
| 920 |
data/modality_atlas.json # responsive modality-card data
|
| 921 |
assets/brand/*.png # project logo, favicon, social card
|
|
|
|
| 1037 |
--include-neural
|
| 1038 |
```
|
| 1039 |
|
| 1040 |
+
Then rebuild the unified 20-task index after the historical provenance bundle is regenerated:
|
| 1041 |
|
| 1042 |
```bash
|
| 1043 |
python scripts/tier2_task_suite.py --workspace /path/to/workspace
|
|
|
|
| 1512 |
|
| 1513 |
## Unified 20-Task Suite
|
| 1514 |
|
| 1515 |
+
The sample task surface is presented as 20 tasks in one suite. All task rows
|
| 1516 |
+
share the same 20-frame window unit, 5-frame stride, chronological split, and
|
| 1517 |
+
minimal/neural comparison style, with task-specific leakage rules when a target
|
| 1518 |
+
would otherwise leak through caption, object, contact, or future features.
|
|
|
|
|
|
|
| 1519 |
|
| 1520 |
The historical `tier2_task_suite` file and directory names remain only for
|
| 1521 |
+
stable artifact links. They should be read as provenance bundles inside the
|
| 1522 |
+
unified 20-task suite, not as a separate benchmark tier.
|
| 1523 |
|
| 1524 |
- [`TASK_SUITE_20.md`](TASK_SUITE_20.md)
|
| 1525 |
- [`docs/data/task_suite_20.json`](docs/data/task_suite_20.json)
|
|
|
|
| 1543 |
|
| 1544 |

|
| 1545 |
|
| 1546 |
+

|
| 1547 |
|
| 1548 |
| # | Task | Input | Output | Minimal | Neural MLP | Meaning |
|
| 1549 |
| ---: | --- | --- | --- | ---: | ---: | --- |
|
PROJECT_STATUS.md
CHANGED
|
@@ -30,7 +30,7 @@ prior multiscale release, and v6 is the current public 20-task Qwen3-Omni row.
|
|
| 30 |
| Area | Current state | Evidence | Research readout |
|
| 31 |
| --- | --- | --- | --- |
|
| 32 |
| Public-sample pipeline | Verified | `results/episode_task_suite/summary_report.json`, `results/episode_task_suite/windows.csv`, `results/episode_task_suite/feature_manifest.json` | One public Xperience-10M sample episode is converted into 5,821 frames, 1,161 aligned 20-frame windows, and an 8,546-dimensional current feature contract. |
|
| 33 |
-
| Unified 20-task suite | Verified | `TASK_SUITE_20.md`, `docs/data/task_suite_20.json`, `results/episode_task_suite/`, `results/episode_task_suite/tier2_task_suite/` | All 20 task contracts have committed minimal metrics
|
| 34 |
| 180-result method matrix | Verified complete | `docs/data/task_method_20_result_matrix.json`, `TASK_METHOD_20_RESULT_MATRIX.md`, `docs/data/task_method_20_gap_audit.json`, `docs/assets/charts/unified_task_model_radar.svg` | The public comparison matrix now has 9 methods x 20 tasks = 180/180 scored method-task records. Six rows are explicitly marked as compact-proxy scores where the public 128-episode export lacks the direct raw target. |
|
| 35 |
| Neural heads | Verified | `scripts/neural_task_models.py`, `results/episode_task_suite/neural_mlp/` | Each task also has a compact PyTorch MLP run over the same feature tensor and chronological split. |
|
| 36 |
| Audio contribution study | Verified | `scripts/audio_ablation_and_raw_upgrade.py`, `results/audio_ablation/`, `docs/data/audio_ablation_summary.json` | Audio variants are compared across the original task contracts; audio improves the primary metric on 6 of those contracts, and a 588-d audio-window representation improves over the baseline audio variant on 6 of those contracts. |
|
|
@@ -73,7 +73,7 @@ prior multiscale release, and v6 is the current public 20-task Qwen3-Omni row.
|
|
| 73 |
`docs/data/summary_metrics.json`, and
|
| 74 |
`results/episode_task_suite/neural_mlp/` to check the unified 20-task outputs.
|
| 75 |
10. Inspect `docs/data/tier2_task_suite.json` and
|
| 76 |
-
`results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md` only as
|
| 77 |
11. Inspect `results/audio_ablation/AUDIO_ABLATION_SUMMARY.md` before judging
|
| 78 |
whether audio helps the current task suite.
|
| 79 |
12. Inspect `EVALUATION_PROTOCOL.md` before judging task metrics or leakage
|
|
|
|
| 30 |
| Area | Current state | Evidence | Research readout |
|
| 31 |
| --- | --- | --- | --- |
|
| 32 |
| Public-sample pipeline | Verified | `results/episode_task_suite/summary_report.json`, `results/episode_task_suite/windows.csv`, `results/episode_task_suite/feature_manifest.json` | One public Xperience-10M sample episode is converted into 5,821 frames, 1,161 aligned 20-frame windows, and an 8,546-dimensional current feature contract. |
|
| 33 |
+
| Unified 20-task suite | Verified | `TASK_SUITE_20.md`, `docs/data/task_suite_20.json`, `results/episode_task_suite/`, `results/episode_task_suite/tier2_task_suite/` | All 20 task contracts have committed minimal metrics and share the same 20-frame windows, 5-frame stride, chronological split, and minimal/neural head pattern. The `tier2_task_suite` path is historical provenance inside the unified suite, not a separate public tier. |
|
| 34 |
| 180-result method matrix | Verified complete | `docs/data/task_method_20_result_matrix.json`, `TASK_METHOD_20_RESULT_MATRIX.md`, `docs/data/task_method_20_gap_audit.json`, `docs/assets/charts/unified_task_model_radar.svg` | The public comparison matrix now has 9 methods x 20 tasks = 180/180 scored method-task records. Six rows are explicitly marked as compact-proxy scores where the public 128-episode export lacks the direct raw target. |
|
| 35 |
| Neural heads | Verified | `scripts/neural_task_models.py`, `results/episode_task_suite/neural_mlp/` | Each task also has a compact PyTorch MLP run over the same feature tensor and chronological split. |
|
| 36 |
| Audio contribution study | Verified | `scripts/audio_ablation_and_raw_upgrade.py`, `results/audio_ablation/`, `docs/data/audio_ablation_summary.json` | Audio variants are compared across the original task contracts; audio improves the primary metric on 6 of those contracts, and a 588-d audio-window representation improves over the baseline audio variant on 6 of those contracts. |
|
|
|
|
| 73 |
`docs/data/summary_metrics.json`, and
|
| 74 |
`results/episode_task_suite/neural_mlp/` to check the unified 20-task outputs.
|
| 75 |
10. Inspect `docs/data/tier2_task_suite.json` and
|
| 76 |
+
`results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md` only as historical provenance paths inside the unified 20-task suite.
|
| 77 |
11. Inspect `results/audio_ablation/AUDIO_ABLATION_SUMMARY.md` before judging
|
| 78 |
whether audio helps the current task suite.
|
| 79 |
12. Inspect `EVALUATION_PROTOCOL.md` before judging task metrics or leakage
|
README.md
CHANGED
|
@@ -61,11 +61,11 @@ pattern as the core 12 tasks.
|
|
| 61 |
## Unified 20-Task Suite
|
| 62 |
|
| 63 |
The public-sample task surface is now one unified 20-task suite in
|
| 64 |
-
`TASK_SUITE_20.md` and `docs/data/task_suite_20.json`.
|
| 65 |
-
|
| 66 |
stride, feature manifest, chronological split, and minimal/neural head pattern.
|
| 67 |
The historical `tier2_task_suite` path is retained only for stable artifact
|
| 68 |
-
links to
|
| 69 |
`docs/assets/charts/unified_task_model_radar.svg` with values in
|
| 70 |
`docs/data/unified_task_model_radar.json`; the 9-method by 20-task
|
| 71 |
completion matrix is complete at `180/180` scored method-task records and is published in `docs/data/task_method_20_result_matrix.json`, with two-line summaries in
|
|
|
|
| 61 |
## Unified 20-Task Suite
|
| 62 |
|
| 63 |
The public-sample task surface is now one unified 20-task suite in
|
| 64 |
+
`TASK_SUITE_20.md` and `docs/data/task_suite_20.json`. All 20 task contracts
|
| 65 |
+
reuse the same 20-frame windows, 5-frame
|
| 66 |
stride, feature manifest, chronological split, and minimal/neural head pattern.
|
| 67 |
The historical `tier2_task_suite` path is retained only for stable artifact
|
| 68 |
+
links to provenance rows inside the unified suite. The unified radar chart is published as
|
| 69 |
`docs/assets/charts/unified_task_model_radar.svg` with values in
|
| 70 |
`docs/data/unified_task_model_radar.json`; the 9-method by 20-task
|
| 71 |
completion matrix is complete at `180/180` scored method-task records and is published in `docs/data/task_method_20_result_matrix.json`, with two-line summaries in
|
REPRODUCIBILITY.md
CHANGED
|
@@ -10,7 +10,7 @@ outside the current public data scope.
|
|
| 10 |
| --- | --- | --- |
|
| 11 |
| Sample download | Yes, from `ropedia-ai/xperience-10m-sample` or ModelScope sample mirror | Sample card lists `cc-by-nc-4.0`; raw data is not redistributed in this repo. |
|
| 12 |
| Minimal baselines | Yes | One public sample episode, chronological split. |
|
| 13 |
-
| Unified 20-task suite | Yes;
|
| 14 |
| Neural MLP heads | Yes, when `torch` is installed | Compact task heads only, not a foundation model. |
|
| 15 |
| Website figures and charts | Yes | Generated from committed metrics and sample thumbnails. |
|
| 16 |
| Public bundle contents | Yes | Covers public repo and prepared HF bundles. |
|
|
@@ -96,7 +96,7 @@ python scripts/validate_publication_package.py
|
|
| 96 |
```
|
| 97 |
|
| 98 |
`scripts/tier2_task_suite.py` has a historical file name, but it now regenerates
|
| 99 |
-
|
| 100 |
present, or a direct `h5py` fallback for the public sample's caption JSON. It
|
| 101 |
reads the local raw `annotation.hdf5` only to regenerate interaction/object
|
| 102 |
targets; the raw HDF5 is still ignored by git and excluded from public bundles.
|
|
@@ -159,7 +159,7 @@ Verified staged-GPU smoke evidence from 2026-06-14:
|
|
| 159 |
| Command group | Expected artifacts |
|
| 160 |
| --- | --- |
|
| 161 |
| Minimal baselines | `results/min_action_model/`, `results/min_all_modalities_action_model/`, metrics and model weights |
|
| 162 |
-
| Unified 20-task suite | `TASK_SUITE_20.md`, `docs/data/task_suite_20.json`, `results/episode_task_suite/summary_report.json`, per-task `metrics.json`, predictions, confusion matrices, and the
|
| 163 |
| Unified 20-task model radar | `docs/data/unified_task_model_radar.json`, `docs/assets/charts/unified_task_model_radar.svg` |
|
| 164 |
| Neural heads | `results/episode_task_suite/neural_mlp/**/metrics.json`, histories, model checkpoints |
|
| 165 |
| Research directions | `results/episode_task_suite/research_directions/`, `docs/data/research_directions.json` |
|
|
@@ -182,7 +182,7 @@ Asia/Singapore** from a fresh output directory outside the repo. It rebuilt the
|
|
| 182 |
minimal baselines, all-modality baselines, and the original core task artifacts
|
| 183 |
from the local public sample. The regenerated metrics matched the committed
|
| 184 |
artifacts after float normalization; the current public framing now indexes
|
| 185 |
-
those artifacts together
|
| 186 |
|
| 187 |
Evidence:
|
| 188 |
|
|
|
|
| 10 |
| --- | --- | --- |
|
| 11 |
| Sample download | Yes, from `ropedia-ai/xperience-10m-sample` or ModelScope sample mirror | Sample card lists `cc-by-nc-4.0`; raw data is not redistributed in this repo. |
|
| 12 |
| Minimal baselines | Yes | One public sample episode, chronological split. |
|
| 13 |
+
| Unified 20-task suite | Yes; the historical provenance bundle requires `annotation.hdf5` plus `h5py` or HOMIE Toolkit for regeneration | Uses the current 8,546-d synchronized multimodal feature contract, the same 20-frame windows, and the same chronological split. |
|
| 14 |
| Neural MLP heads | Yes, when `torch` is installed | Compact task heads only, not a foundation model. |
|
| 15 |
| Website figures and charts | Yes | Generated from committed metrics and sample thumbnails. |
|
| 16 |
| Public bundle contents | Yes | Covers public repo and prepared HF bundles. |
|
|
|
|
| 96 |
```
|
| 97 |
|
| 98 |
`scripts/tier2_task_suite.py` has a historical file name, but it now regenerates
|
| 99 |
+
provenance rows inside the unified 20-task suite. It can use HOMIE Toolkit when
|
| 100 |
present, or a direct `h5py` fallback for the public sample's caption JSON. It
|
| 101 |
reads the local raw `annotation.hdf5` only to regenerate interaction/object
|
| 102 |
targets; the raw HDF5 is still ignored by git and excluded from public bundles.
|
|
|
|
| 159 |
| Command group | Expected artifacts |
|
| 160 |
| --- | --- |
|
| 161 |
| Minimal baselines | `results/min_action_model/`, `results/min_all_modalities_action_model/`, metrics and model weights |
|
| 162 |
+
| Unified 20-task suite | `TASK_SUITE_20.md`, `docs/data/task_suite_20.json`, `results/episode_task_suite/summary_report.json`, per-task `metrics.json`, predictions, confusion matrices, and the historical `tier2_task_suite` provenance bundle |
|
| 163 |
| Unified 20-task model radar | `docs/data/unified_task_model_radar.json`, `docs/assets/charts/unified_task_model_radar.svg` |
|
| 164 |
| Neural heads | `results/episode_task_suite/neural_mlp/**/metrics.json`, histories, model checkpoints |
|
| 165 |
| Research directions | `results/episode_task_suite/research_directions/`, `docs/data/research_directions.json` |
|
|
|
|
| 182 |
minimal baselines, all-modality baselines, and the original core task artifacts
|
| 183 |
from the local public sample. The regenerated metrics matched the committed
|
| 184 |
artifacts after float normalization; the current public framing now indexes
|
| 185 |
+
those artifacts together as one 20-task suite.
|
| 186 |
|
| 187 |
Evidence:
|
| 188 |
|
TASK_SUITE_20.md
CHANGED
|
@@ -1,12 +1,11 @@
|
|
| 1 |
# Unified 20-Task Suite
|
| 2 |
|
| 3 |
The public Xperience-10M sample task surface is one unified set of 20 tasks.
|
| 4 |
-
|
| 5 |
-
|
| 6 |
-
and leakage-control contract.
|
| 7 |
|
| 8 |
Historical artifact paths containing `tier2_task_suite` are kept for stable
|
| 9 |
-
links, but they should be read as
|
| 10 |
as a separate benchmark tier.
|
| 11 |
|
| 12 |
## Shared Setup
|
|
|
|
| 1 |
# Unified 20-Task Suite
|
| 2 |
|
| 3 |
The public Xperience-10M sample task surface is one unified set of 20 tasks.
|
| 4 |
+
All task contracts are presented together under the same window, split,
|
| 5 |
+
feature, baseline, and leakage-control contract.
|
|
|
|
| 6 |
|
| 7 |
Historical artifact paths containing `tier2_task_suite` are kept for stable
|
| 8 |
+
links, but they should be read as provenance directories inside the unified task suite, not
|
| 9 |
as a separate benchmark tier.
|
| 10 |
|
| 11 |
## Shared Setup
|
assets/charts/tier2_task_suite.svg
CHANGED

|

|
data/evaluation_protocol.json
CHANGED
|
@@ -2,7 +2,7 @@
|
|
| 2 |
"title": "Ropedia Xperience-10M Task Suite Evaluation Protocol",
|
| 3 |
"status": "pass",
|
| 4 |
"version": "2026-06-01",
|
| 5 |
-
"generated_at_utc": "2026-06-
|
| 6 |
"source_files": [
|
| 7 |
"docs/data/summary_metrics.json",
|
| 8 |
"results/episode_task_suite/summary_report.json",
|
|
@@ -30,7 +30,7 @@
|
|
| 30 |
"additional_public_sample_tasks": 8,
|
| 31 |
"unified_results": "docs/data/task_suite_20.json",
|
| 32 |
"legacy_additional_task_result_path": "docs/data/tier2_task_suite.json",
|
| 33 |
-
"legacy_path_note": "The tier2_task_suite path is retained for stable links only;
|
| 34 |
},
|
| 35 |
"split_policy": {
|
| 36 |
"name": "single_episode_chronological",
|
|
|
|
| 2 |
"title": "Ropedia Xperience-10M Task Suite Evaluation Protocol",
|
| 3 |
"status": "pass",
|
| 4 |
"version": "2026-06-01",
|
| 5 |
+
"generated_at_utc": "2026-06-21T14:40:33+00:00",
|
| 6 |
"source_files": [
|
| 7 |
"docs/data/summary_metrics.json",
|
| 8 |
"results/episode_task_suite/summary_report.json",
|
|
|
|
| 30 |
"additional_public_sample_tasks": 8,
|
| 31 |
"unified_results": "docs/data/task_suite_20.json",
|
| 32 |
"legacy_additional_task_result_path": "docs/data/tier2_task_suite.json",
|
| 33 |
+
"legacy_path_note": "The tier2_task_suite path is retained for stable links only; it is provenance inside the same 20-task suite."
|
| 34 |
},
|
| 35 |
"split_policy": {
|
| 36 |
"name": "single_episode_chronological",
|
data/publication_audit.json
CHANGED
|
@@ -1,6 +1,6 @@
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
-
"generated_at_utc": "2026-06-
|
| 4 |
"checks": [
|
| 5 |
{
|
| 6 |
"name": "required_publication_assets_present",
|
|
@@ -257,7 +257,7 @@
|
|
| 257 |
"hf_artifact_bundle": {
|
| 258 |
"root": "hf_publish/artifacts",
|
| 259 |
"exists": true,
|
| 260 |
-
"file_count":
|
| 261 |
"text_file_count": 1286,
|
| 262 |
"largest_file": {
|
| 263 |
"path": "results/omni_finetune/xperience10m_128ep_dense_multiscale_hierarchical_v1_20260608/dense_multiscale_windows.jsonl",
|
|
@@ -268,7 +268,7 @@
|
|
| 268 |
"hf_model_bundle": {
|
| 269 |
"root": "hf_publish/model",
|
| 270 |
"exists": true,
|
| 271 |
-
"file_count":
|
| 272 |
"text_file_count": 1459,
|
| 273 |
"largest_file": {
|
| 274 |
"path": "results/omni_finetune/xperience10m_128ep_dense_multiscale_hierarchical_v1_20260608/dense_multiscale_windows.jsonl",
|
|
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
+
"generated_at_utc": "2026-06-21T14:46:11+00:00",
|
| 4 |
"checks": [
|
| 5 |
{
|
| 6 |
"name": "required_publication_assets_present",
|
|
|
|
| 257 |
"hf_artifact_bundle": {
|
| 258 |
"root": "hf_publish/artifacts",
|
| 259 |
"exists": true,
|
| 260 |
+
"file_count": 4528,
|
| 261 |
"text_file_count": 1286,
|
| 262 |
"largest_file": {
|
| 263 |
"path": "results/omni_finetune/xperience10m_128ep_dense_multiscale_hierarchical_v1_20260608/dense_multiscale_windows.jsonl",
|
|
|
|
| 268 |
"hf_model_bundle": {
|
| 269 |
"root": "hf_publish/model",
|
| 270 |
"exists": true,
|
| 271 |
+
"file_count": 5293,
|
| 272 |
"text_file_count": 1459,
|
| 273 |
"largest_file": {
|
| 274 |
"path": "results/omni_finetune/xperience10m_128ep_dense_multiscale_hierarchical_v1_20260608/dense_multiscale_windows.jsonl",
|
data/scope_claims_audit.json
CHANGED
|
@@ -1,6 +1,6 @@
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
-
"generated_at_utc": "2026-06-
|
| 4 |
"summary": {
|
| 5 |
"qwen3_omni_verified_diagnostic_pilot": true,
|
| 6 |
"dataset_manifest_num_episodes": 119,
|
|
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
+
"generated_at_utc": "2026-06-21T14:47:03+00:00",
|
| 4 |
"summary": {
|
| 5 |
"qwen3_omni_verified_diagnostic_pilot": true,
|
| 6 |
"dataset_manifest_num_episodes": 119,
|
docs/assets/charts/tier2_task_suite.svg
CHANGED
|
|
docs/data/artifact_index.json
CHANGED
|
@@ -1,6 +1,6 @@
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Task Suite Artifact Index",
|
| 3 |
-
"generated_at_utc": "2026-06-
|
| 4 |
"status": "pass",
|
| 5 |
"artifact_count": 228,
|
| 6 |
"missing": [],
|
|
@@ -48,8 +48,8 @@
|
|
| 48 |
"surface": "repo_hf",
|
| 49 |
"shows": "Gives first-pass readers a concise project shape before the detailed artifact trail.",
|
| 50 |
"exists": true,
|
| 51 |
-
"bytes":
|
| 52 |
-
"sha256": "
|
| 53 |
},
|
| 54 |
{
|
| 55 |
"id": "project_brief_json",
|
|
@@ -70,8 +70,8 @@
|
|
| 70 |
"surface": "repo_hf",
|
| 71 |
"shows": "Gives a compact current-state table for first-pass readers.",
|
| 72 |
"exists": true,
|
| 73 |
-
"bytes":
|
| 74 |
-
"sha256": "
|
| 75 |
},
|
| 76 |
{
|
| 77 |
"id": "project_status_json",
|
|
@@ -92,8 +92,8 @@
|
|
| 92 |
"surface": "repo_hf",
|
| 93 |
"shows": "Defines terminology that can be confused across data scope, task metrics, model branches, and public mirrors.",
|
| 94 |
"exists": true,
|
| 95 |
-
"bytes":
|
| 96 |
-
"sha256": "
|
| 97 |
},
|
| 98 |
{
|
| 99 |
"id": "glossary_json",
|
|
@@ -103,8 +103,8 @@
|
|
| 103 |
"surface": "website_hf",
|
| 104 |
"shows": "Machine-readable terminology layer for the website, artifact dataset, model mirror, and public QA checks.",
|
| 105 |
"exists": true,
|
| 106 |
-
"bytes":
|
| 107 |
-
"sha256": "
|
| 108 |
},
|
| 109 |
{
|
| 110 |
"id": "research_roadmap",
|
|
@@ -587,8 +587,8 @@
|
|
| 587 |
"surface": "repo_hf",
|
| 588 |
"shows": "Gives the human-readable map from project scope to data, tasks, platform mirrors, and scale-up status.",
|
| 589 |
"exists": true,
|
| 590 |
-
"bytes":
|
| 591 |
-
"sha256": "
|
| 592 |
},
|
| 593 |
{
|
| 594 |
"id": "official_dataset_card_alignment",
|
|
@@ -632,7 +632,7 @@
|
|
| 632 |
"shows": "Machine-readable source-alignment pass/fail check for repo, website, and HF surfaces.",
|
| 633 |
"exists": true,
|
| 634 |
"bytes": 4432,
|
| 635 |
-
"sha256": "
|
| 636 |
},
|
| 637 |
{
|
| 638 |
"id": "source_alignment_validator",
|
|
@@ -686,8 +686,8 @@
|
|
| 686 |
"surface": "repo_hf",
|
| 687 |
"shows": "Defines the window unit, chronological split, task metrics, leakage controls, and current limitations.",
|
| 688 |
"exists": true,
|
| 689 |
-
"bytes":
|
| 690 |
-
"sha256": "
|
| 691 |
},
|
| 692 |
{
|
| 693 |
"id": "evaluation_protocol_json",
|
|
@@ -697,8 +697,8 @@
|
|
| 697 |
"surface": "website_hf",
|
| 698 |
"shows": "Machine-readable protocol generated from committed task metrics for website and HF mirrors.",
|
| 699 |
"exists": true,
|
| 700 |
-
"bytes":
|
| 701 |
-
"sha256": "
|
| 702 |
},
|
| 703 |
{
|
| 704 |
"id": "evaluation_protocol_builder",
|
|
@@ -708,8 +708,8 @@
|
|
| 708 |
"surface": "repo_hf",
|
| 709 |
"shows": "Regenerates the protocol from committed summary metrics and task artifacts.",
|
| 710 |
"exists": true,
|
| 711 |
-
"bytes":
|
| 712 |
-
"sha256": "
|
| 713 |
},
|
| 714 |
{
|
| 715 |
"id": "task_suite_20",
|
|
@@ -717,10 +717,10 @@
|
|
| 717 |
"path": "TASK_SUITE_20.md",
|
| 718 |
"kind": "evaluation_protocol",
|
| 719 |
"surface": "repo_hf",
|
| 720 |
-
"shows": "Reader-facing table for the single unified public-sample task suite
|
| 721 |
"exists": true,
|
| 722 |
-
"bytes":
|
| 723 |
-
"sha256": "
|
| 724 |
},
|
| 725 |
{
|
| 726 |
"id": "task_suite_20_json",
|
|
@@ -730,8 +730,8 @@
|
|
| 730 |
"surface": "website_hf",
|
| 731 |
"shows": "Machine-readable unified 20-task index for the website, Hugging Face mirrors, and live verification.",
|
| 732 |
"exists": true,
|
| 733 |
-
"bytes":
|
| 734 |
-
"sha256": "
|
| 735 |
},
|
| 736 |
{
|
| 737 |
"id": "task_suite_20_builder",
|
|
@@ -739,10 +739,10 @@
|
|
| 739 |
"path": "scripts/build_unified_task_suite.py",
|
| 740 |
"kind": "evaluation_protocol",
|
| 741 |
"surface": "repo_hf",
|
| 742 |
-
"shows": "Regenerates the unified 20-task JSON and Markdown from the
|
| 743 |
"exists": true,
|
| 744 |
-
"bytes":
|
| 745 |
-
"sha256": "
|
| 746 |
},
|
| 747 |
{
|
| 748 |
"id": "unified_task_model_radar_json",
|
|
@@ -1093,8 +1093,8 @@
|
|
| 1093 |
"surface": "repo_hf",
|
| 1094 |
"shows": "Catalogs public figures, charts, modality thumbnails, dimensions, hashes, roles, and source scripts.",
|
| 1095 |
"exists": true,
|
| 1096 |
-
"bytes":
|
| 1097 |
-
"sha256": "
|
| 1098 |
},
|
| 1099 |
{
|
| 1100 |
"id": "figure_index_json",
|
|
@@ -1104,8 +1104,8 @@
|
|
| 1104 |
"surface": "website_hf",
|
| 1105 |
"shows": "Machine-readable visual asset index for website and Hugging Face mirrors.",
|
| 1106 |
"exists": true,
|
| 1107 |
-
"bytes":
|
| 1108 |
-
"sha256": "
|
| 1109 |
},
|
| 1110 |
{
|
| 1111 |
"id": "figure_index_builder",
|
|
@@ -1115,8 +1115,8 @@
|
|
| 1115 |
"surface": "repo_hf",
|
| 1116 |
"shows": "Regenerates visual-asset hashes, dimensions, and source-script provenance.",
|
| 1117 |
"exists": true,
|
| 1118 |
-
"bytes":
|
| 1119 |
-
"sha256": "
|
| 1120 |
},
|
| 1121 |
{
|
| 1122 |
"id": "brand_assets_json",
|
|
@@ -1182,7 +1182,7 @@
|
|
| 1182 |
"shows": "Machine-readable release-check summary for validators, mirrors, and public project surfaces.",
|
| 1183 |
"exists": true,
|
| 1184 |
"bytes": 8640,
|
| 1185 |
-
"sha256": "
|
| 1186 |
},
|
| 1187 |
{
|
| 1188 |
"id": "public_surface_qa",
|
|
@@ -1192,8 +1192,8 @@
|
|
| 1192 |
"surface": "repo_hf",
|
| 1193 |
"shows": "Keeps the repo, website, and Hugging Face cards aligned as one cohesive research project surface.",
|
| 1194 |
"exists": true,
|
| 1195 |
-
"bytes":
|
| 1196 |
-
"sha256": "
|
| 1197 |
},
|
| 1198 |
{
|
| 1199 |
"id": "public_reader_map",
|
|
@@ -1226,7 +1226,7 @@
|
|
| 1226 |
"volatile": true,
|
| 1227 |
"shows": "Machine-readable report for SEO/social metadata, accessible tab semantics, public links, project links, and clear project presentation.",
|
| 1228 |
"exists": true,
|
| 1229 |
-
"bytes":
|
| 1230 |
"hash_policy": "existence_and_size_only"
|
| 1231 |
},
|
| 1232 |
{
|
|
@@ -1307,7 +1307,7 @@
|
|
| 1307 |
"volatile": true,
|
| 1308 |
"shows": "Records the last live GitHub/HF URL verification after upload.",
|
| 1309 |
"exists": true,
|
| 1310 |
-
"bytes":
|
| 1311 |
"hash_policy": "existence_and_size_only"
|
| 1312 |
},
|
| 1313 |
{
|
|
@@ -1318,8 +1318,8 @@
|
|
| 1318 |
"surface": "repo",
|
| 1319 |
"shows": "Fetches the published GitHub/HF URLs and compares live hashes and public-card markers against the release assets.",
|
| 1320 |
"exists": true,
|
| 1321 |
-
"bytes":
|
| 1322 |
-
"sha256": "
|
| 1323 |
},
|
| 1324 |
{
|
| 1325 |
"id": "reproducibility_contract",
|
|
@@ -1329,8 +1329,8 @@
|
|
| 1329 |
"surface": "repo_hf",
|
| 1330 |
"shows": "Defines public reproduction commands, expected outputs, and non-reproducible scale-up boundaries.",
|
| 1331 |
"exists": true,
|
| 1332 |
-
"bytes":
|
| 1333 |
-
"sha256": "
|
| 1334 |
},
|
| 1335 |
{
|
| 1336 |
"id": "reproducibility_matrix",
|
|
@@ -1351,8 +1351,8 @@
|
|
| 1351 |
"surface": "repo_hf",
|
| 1352 |
"shows": "Generates the selective artifact catalog from local files.",
|
| 1353 |
"exists": true,
|
| 1354 |
-
"bytes":
|
| 1355 |
-
"sha256": "
|
| 1356 |
},
|
| 1357 |
{
|
| 1358 |
"id": "publication_audit",
|
|
@@ -1363,7 +1363,7 @@
|
|
| 1363 |
"volatile": true,
|
| 1364 |
"shows": "Confirms public bundles exclude raw data, caches, heavy archives, and credential text.",
|
| 1365 |
"exists": true,
|
| 1366 |
-
"bytes":
|
| 1367 |
"hash_policy": "existence_and_size_only"
|
| 1368 |
},
|
| 1369 |
{
|
|
@@ -1387,7 +1387,7 @@
|
|
| 1387 |
"volatile": true,
|
| 1388 |
"shows": "Confirms prepared GitHub/HF Space/artifact/model mirrors share the same critical data, figure, website HTML, and validator files.",
|
| 1389 |
"exists": true,
|
| 1390 |
-
"bytes":
|
| 1391 |
"hash_policy": "existence_and_size_only"
|
| 1392 |
},
|
| 1393 |
{
|
|
@@ -1399,7 +1399,7 @@
|
|
| 1399 |
"volatile": true,
|
| 1400 |
"shows": "Confirms local website links, anchors, JSON data files, and referenced images resolve.",
|
| 1401 |
"exists": true,
|
| 1402 |
-
"bytes":
|
| 1403 |
"hash_policy": "existence_and_size_only"
|
| 1404 |
},
|
| 1405 |
{
|
|
@@ -1503,47 +1503,47 @@
|
|
| 1503 |
},
|
| 1504 |
{
|
| 1505 |
"id": "tier2_task_suite",
|
| 1506 |
-
"title": "
|
| 1507 |
"path": "results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 1508 |
"kind": "metrics_source",
|
| 1509 |
"surface": "repo_hf",
|
| 1510 |
-
"shows": "Stores the historical result bundle for
|
| 1511 |
"exists": true,
|
| 1512 |
"bytes": 33402,
|
| 1513 |
"sha256": "5a1051d25ceafe53c60dbd5b81d4b686a421c493ad09a462ad96bac100c5f3f3"
|
| 1514 |
},
|
| 1515 |
{
|
| 1516 |
"id": "tier2_task_suite_json",
|
| 1517 |
-
"title": "
|
| 1518 |
"path": "docs/data/tier2_task_suite.json",
|
| 1519 |
"kind": "website_data",
|
| 1520 |
"surface": "website_hf",
|
| 1521 |
-
"shows": "Machine-readable
|
| 1522 |
"exists": true,
|
| 1523 |
"bytes": 33402,
|
| 1524 |
"sha256": "5a1051d25ceafe53c60dbd5b81d4b686a421c493ad09a462ad96bac100c5f3f3"
|
| 1525 |
},
|
| 1526 |
{
|
| 1527 |
"id": "tier2_task_suite_chart",
|
| 1528 |
-
"title": "
|
| 1529 |
"path": "docs/assets/charts/tier2_task_suite.svg",
|
| 1530 |
"kind": "generated_figure",
|
| 1531 |
"surface": "website_hf",
|
| 1532 |
-
"shows": "Visual summary of the
|
| 1533 |
"exists": true,
|
| 1534 |
"bytes": 5437,
|
| 1535 |
"sha256": "3e35e476f559cd6188e5417e4d28c25efc130abafc9cab2d941bc77d559177a1"
|
| 1536 |
},
|
| 1537 |
{
|
| 1538 |
"id": "tier2_task_suite_builder",
|
| 1539 |
-
"title": "
|
| 1540 |
"path": "scripts/tier2_task_suite.py",
|
| 1541 |
"kind": "evaluation_protocol",
|
| 1542 |
"surface": "repo_hf",
|
| 1543 |
-
"shows": "Regenerates
|
| 1544 |
"exists": true,
|
| 1545 |
-
"bytes":
|
| 1546 |
-
"sha256": "
|
| 1547 |
},
|
| 1548 |
{
|
| 1549 |
"id": "task_walkthroughs",
|
|
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Task Suite Artifact Index",
|
| 3 |
+
"generated_at_utc": "2026-06-21T14:40:34+00:00",
|
| 4 |
"status": "pass",
|
| 5 |
"artifact_count": 228,
|
| 6 |
"missing": [],
|
|
|
|
| 48 |
"surface": "repo_hf",
|
| 49 |
"shows": "Gives first-pass readers a concise project shape before the detailed artifact trail.",
|
| 50 |
"exists": true,
|
| 51 |
+
"bytes": 4826,
|
| 52 |
+
"sha256": "3e432c722daca11e1932a8056d73b9debb6f2c52c13d7b21e9871bb2a490d79d"
|
| 53 |
},
|
| 54 |
{
|
| 55 |
"id": "project_brief_json",
|
|
|
|
| 70 |
"surface": "repo_hf",
|
| 71 |
"shows": "Gives a compact current-state table for first-pass readers.",
|
| 72 |
"exists": true,
|
| 73 |
+
"bytes": 15993,
|
| 74 |
+
"sha256": "96bf5d894ace804aea2f3889a4d99a802a5e015405e7eed573eb3a98882ce968"
|
| 75 |
},
|
| 76 |
{
|
| 77 |
"id": "project_status_json",
|
|
|
|
| 92 |
"surface": "repo_hf",
|
| 93 |
"shows": "Defines terminology that can be confused across data scope, task metrics, model branches, and public mirrors.",
|
| 94 |
"exists": true,
|
| 95 |
+
"bytes": 10220,
|
| 96 |
+
"sha256": "c3723a3dfaf902f4bc2527b78d11057ab8ba01c6b9715fa873c7dd819deddf81"
|
| 97 |
},
|
| 98 |
{
|
| 99 |
"id": "glossary_json",
|
|
|
|
| 103 |
"surface": "website_hf",
|
| 104 |
"shows": "Machine-readable terminology layer for the website, artifact dataset, model mirror, and public QA checks.",
|
| 105 |
"exists": true,
|
| 106 |
+
"bytes": 17380,
|
| 107 |
+
"sha256": "3ba746413eb4a7d2646333e3746e0b3f4039db61d03c159d2d059fecfe4b51ed"
|
| 108 |
},
|
| 109 |
{
|
| 110 |
"id": "research_roadmap",
|
|
|
|
| 587 |
"surface": "repo_hf",
|
| 588 |
"shows": "Gives the human-readable map from project scope to data, tasks, platform mirrors, and scale-up status.",
|
| 589 |
"exists": true,
|
| 590 |
+
"bytes": 20571,
|
| 591 |
+
"sha256": "217e3eb2cf82999f75ce6e132f567fa1ed08d319bf7a44f77b7150a45fae5274"
|
| 592 |
},
|
| 593 |
{
|
| 594 |
"id": "official_dataset_card_alignment",
|
|
|
|
| 632 |
"shows": "Machine-readable source-alignment pass/fail check for repo, website, and HF surfaces.",
|
| 633 |
"exists": true,
|
| 634 |
"bytes": 4432,
|
| 635 |
+
"sha256": "3def3dc923162ad0d2802acdca8a689a4e9ad1408f36edae8f77f49c4507cef1"
|
| 636 |
},
|
| 637 |
{
|
| 638 |
"id": "source_alignment_validator",
|
|
|
|
| 686 |
"surface": "repo_hf",
|
| 687 |
"shows": "Defines the window unit, chronological split, task metrics, leakage controls, and current limitations.",
|
| 688 |
"exists": true,
|
| 689 |
+
"bytes": 9156,
|
| 690 |
+
"sha256": "cfc23b3115ebce2b41a349b8a2cd6989aaf2294790c79e2b17545ebede2b2df0"
|
| 691 |
},
|
| 692 |
{
|
| 693 |
"id": "evaluation_protocol_json",
|
|
|
|
| 697 |
"surface": "website_hf",
|
| 698 |
"shows": "Machine-readable protocol generated from committed task metrics for website and HF mirrors.",
|
| 699 |
"exists": true,
|
| 700 |
+
"bytes": 24007,
|
| 701 |
+
"sha256": "dde490d175f0d6828f5973f1b24e696a3d1b3b09d65a59cb9c1dde5c38845b66"
|
| 702 |
},
|
| 703 |
{
|
| 704 |
"id": "evaluation_protocol_builder",
|
|
|
|
| 708 |
"surface": "repo_hf",
|
| 709 |
"shows": "Regenerates the protocol from committed summary metrics and task artifacts.",
|
| 710 |
"exists": true,
|
| 711 |
+
"bytes": 19931,
|
| 712 |
+
"sha256": "080f894b50c609e3a467c8c513dfe441f90ba0dad3586dd1cb88de6e58eedb3b"
|
| 713 |
},
|
| 714 |
{
|
| 715 |
"id": "task_suite_20",
|
|
|
|
| 717 |
"path": "TASK_SUITE_20.md",
|
| 718 |
"kind": "evaluation_protocol",
|
| 719 |
"surface": "repo_hf",
|
| 720 |
+
"shows": "Reader-facing table for the single unified public-sample task suite under the same window, split, feature, and baseline contract.",
|
| 721 |
"exists": true,
|
| 722 |
+
"bytes": 5196,
|
| 723 |
+
"sha256": "473891503dcd1251a2cc9a16e6642ce16fbca9d264a734d2397c2afc60977195"
|
| 724 |
},
|
| 725 |
{
|
| 726 |
"id": "task_suite_20_json",
|
|
|
|
| 730 |
"surface": "website_hf",
|
| 731 |
"shows": "Machine-readable unified 20-task index for the website, Hugging Face mirrors, and live verification.",
|
| 732 |
"exists": true,
|
| 733 |
+
"bytes": 34597,
|
| 734 |
+
"sha256": "2029f7f9744001861ac00acabdb578fe97d3b39a1c16a7c2d19c56347ded22d7"
|
| 735 |
},
|
| 736 |
{
|
| 737 |
"id": "task_suite_20_builder",
|
|
|
|
| 739 |
"path": "scripts/build_unified_task_suite.py",
|
| 740 |
"kind": "evaluation_protocol",
|
| 741 |
"surface": "repo_hf",
|
| 742 |
+
"shows": "Regenerates the unified 20-task JSON and Markdown from the public-sample metrics plus the historical provenance result bundle.",
|
| 743 |
"exists": true,
|
| 744 |
+
"bytes": 12213,
|
| 745 |
+
"sha256": "1421593f05e345799007bbcdf138f81dfdb7c511ec1e31b56d00e2cdaed3d7de"
|
| 746 |
},
|
| 747 |
{
|
| 748 |
"id": "unified_task_model_radar_json",
|
|
|
|
| 1093 |
"surface": "repo_hf",
|
| 1094 |
"shows": "Catalogs public figures, charts, modality thumbnails, dimensions, hashes, roles, and source scripts.",
|
| 1095 |
"exists": true,
|
| 1096 |
+
"bytes": 7011,
|
| 1097 |
+
"sha256": "f6554cd980efa6c0b3b8feac5ff3e19c3e2e74ccf2d446ac4afb5ee5d65413f3"
|
| 1098 |
},
|
| 1099 |
{
|
| 1100 |
"id": "figure_index_json",
|
|
|
|
| 1104 |
"surface": "website_hf",
|
| 1105 |
"shows": "Machine-readable visual asset index for website and Hugging Face mirrors.",
|
| 1106 |
"exists": true,
|
| 1107 |
+
"bytes": 19469,
|
| 1108 |
+
"sha256": "11a06ee64d28f81f3280eb99327d99b47dc58fb1521332434b9df11c97b9b4e8"
|
| 1109 |
},
|
| 1110 |
{
|
| 1111 |
"id": "figure_index_builder",
|
|
|
|
| 1115 |
"surface": "repo_hf",
|
| 1116 |
"shows": "Regenerates visual-asset hashes, dimensions, and source-script provenance.",
|
| 1117 |
"exists": true,
|
| 1118 |
+
"bytes": 16829,
|
| 1119 |
+
"sha256": "14f1ed7f94630c8f70fbc14547071db251647f3d527cf760341b7a233883d069"
|
| 1120 |
},
|
| 1121 |
{
|
| 1122 |
"id": "brand_assets_json",
|
|
|
|
| 1182 |
"shows": "Machine-readable release-check summary for validators, mirrors, and public project surfaces.",
|
| 1183 |
"exists": true,
|
| 1184 |
"bytes": 8640,
|
| 1185 |
+
"sha256": "c8ce99ac63ab70e3696386671bf201f5605b6a88c8be8f288d44a122bad9025e"
|
| 1186 |
},
|
| 1187 |
{
|
| 1188 |
"id": "public_surface_qa",
|
|
|
|
| 1192 |
"surface": "repo_hf",
|
| 1193 |
"shows": "Keeps the repo, website, and Hugging Face cards aligned as one cohesive research project surface.",
|
| 1194 |
"exists": true,
|
| 1195 |
+
"bytes": 2313,
|
| 1196 |
+
"sha256": "7f8cbce404a40e4c660c9f9dfbe2a2880df3749d33dd45c5bc1abc4e527392a1"
|
| 1197 |
},
|
| 1198 |
{
|
| 1199 |
"id": "public_reader_map",
|
|
|
|
| 1226 |
"volatile": true,
|
| 1227 |
"shows": "Machine-readable report for SEO/social metadata, accessible tab semantics, public links, project links, and clear project presentation.",
|
| 1228 |
"exists": true,
|
| 1229 |
+
"bytes": 7690,
|
| 1230 |
"hash_policy": "existence_and_size_only"
|
| 1231 |
},
|
| 1232 |
{
|
|
|
|
| 1307 |
"volatile": true,
|
| 1308 |
"shows": "Records the last live GitHub/HF URL verification after upload.",
|
| 1309 |
"exists": true,
|
| 1310 |
+
"bytes": 189922,
|
| 1311 |
"hash_policy": "existence_and_size_only"
|
| 1312 |
},
|
| 1313 |
{
|
|
|
|
| 1318 |
"surface": "repo",
|
| 1319 |
"shows": "Fetches the published GitHub/HF URLs and compares live hashes and public-card markers against the release assets.",
|
| 1320 |
"exists": true,
|
| 1321 |
+
"bytes": 69151,
|
| 1322 |
+
"sha256": "c4af8644d50dafe7d4249dd7c5b36bb19e996628ff6d8436fbb6e027da526c1f"
|
| 1323 |
},
|
| 1324 |
{
|
| 1325 |
"id": "reproducibility_contract",
|
|
|
|
| 1329 |
"surface": "repo_hf",
|
| 1330 |
"shows": "Defines public reproduction commands, expected outputs, and non-reproducible scale-up boundaries.",
|
| 1331 |
"exists": true,
|
| 1332 |
+
"bytes": 10060,
|
| 1333 |
+
"sha256": "1bea73e024d1a71f08c5d0cb5f26521367ba206ef514ab4b3a1e59269a376139"
|
| 1334 |
},
|
| 1335 |
{
|
| 1336 |
"id": "reproducibility_matrix",
|
|
|
|
| 1351 |
"surface": "repo_hf",
|
| 1352 |
"shows": "Generates the selective artifact catalog from local files.",
|
| 1353 |
"exists": true,
|
| 1354 |
+
"bytes": 68232,
|
| 1355 |
+
"sha256": "ee1b210688c1b722d6ca94d1c1706c1a510218c964298b91dd3e596fa19ed2a1"
|
| 1356 |
},
|
| 1357 |
{
|
| 1358 |
"id": "publication_audit",
|
|
|
|
| 1363 |
"volatile": true,
|
| 1364 |
"shows": "Confirms public bundles exclude raw data, caches, heavy archives, and credential text.",
|
| 1365 |
"exists": true,
|
| 1366 |
+
"bytes": 10939,
|
| 1367 |
"hash_policy": "existence_and_size_only"
|
| 1368 |
},
|
| 1369 |
{
|
|
|
|
| 1387 |
"volatile": true,
|
| 1388 |
"shows": "Confirms prepared GitHub/HF Space/artifact/model mirrors share the same critical data, figure, website HTML, and validator files.",
|
| 1389 |
"exists": true,
|
| 1390 |
+
"bytes": 1420743,
|
| 1391 |
"hash_policy": "existence_and_size_only"
|
| 1392 |
},
|
| 1393 |
{
|
|
|
|
| 1399 |
"volatile": true,
|
| 1400 |
"shows": "Confirms local website links, anchors, JSON data files, and referenced images resolve.",
|
| 1401 |
"exists": true,
|
| 1402 |
+
"bytes": 20760,
|
| 1403 |
"hash_policy": "existence_and_size_only"
|
| 1404 |
},
|
| 1405 |
{
|
|
|
|
| 1503 |
},
|
| 1504 |
{
|
| 1505 |
"id": "tier2_task_suite",
|
| 1506 |
+
"title": "Unified 20-task provenance bundle",
|
| 1507 |
"path": "results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 1508 |
"kind": "metrics_source",
|
| 1509 |
"surface": "repo_hf",
|
| 1510 |
+
"shows": "Stores the historical result bundle for provenance rows with minimal and neural baselines aligned to the same 20-task window/split setup.",
|
| 1511 |
"exists": true,
|
| 1512 |
"bytes": 33402,
|
| 1513 |
"sha256": "5a1051d25ceafe53c60dbd5b81d4b686a421c493ad09a462ad96bac100c5f3f3"
|
| 1514 |
},
|
| 1515 |
{
|
| 1516 |
"id": "tier2_task_suite_json",
|
| 1517 |
+
"title": "Unified 20-task provenance JSON",
|
| 1518 |
"path": "docs/data/tier2_task_suite.json",
|
| 1519 |
"kind": "website_data",
|
| 1520 |
"surface": "website_hf",
|
| 1521 |
+
"shows": "Machine-readable provenance definitions, setup alignment, metrics, and public source paths; the file name is historical.",
|
| 1522 |
"exists": true,
|
| 1523 |
"bytes": 33402,
|
| 1524 |
"sha256": "5a1051d25ceafe53c60dbd5b81d4b686a421c493ad09a462ad96bac100c5f3f3"
|
| 1525 |
},
|
| 1526 |
{
|
| 1527 |
"id": "tier2_task_suite_chart",
|
| 1528 |
+
"title": "Unified 20-task provenance chart",
|
| 1529 |
"path": "docs/assets/charts/tier2_task_suite.svg",
|
| 1530 |
"kind": "generated_figure",
|
| 1531 |
"surface": "website_hf",
|
| 1532 |
+
"shows": "Visual summary of the historical provenance baseline metrics inside the unified 20-task suite.",
|
| 1533 |
"exists": true,
|
| 1534 |
"bytes": 5437,
|
| 1535 |
"sha256": "3e35e476f559cd6188e5417e4d28c25efc130abafc9cab2d941bc77d559177a1"
|
| 1536 |
},
|
| 1537 |
{
|
| 1538 |
"id": "tier2_task_suite_builder",
|
| 1539 |
+
"title": "Unified 20-task provenance builder",
|
| 1540 |
"path": "scripts/tier2_task_suite.py",
|
| 1541 |
"kind": "evaluation_protocol",
|
| 1542 |
"surface": "repo_hf",
|
| 1543 |
+
"shows": "Regenerates the historical provenance rows from shared windows plus the local public-sample annotation HDF5; the script name is historical.",
|
| 1544 |
"exists": true,
|
| 1545 |
+
"bytes": 47102,
|
| 1546 |
+
"sha256": "3cddefaaeedd8efb65e6db956cbd13605e4a5b3772d98fa831d34fd6f92850de"
|
| 1547 |
},
|
| 1548 |
{
|
| 1549 |
"id": "task_walkthroughs",
|
docs/data/evaluation_protocol.json
CHANGED
|
@@ -2,7 +2,7 @@
|
|
| 2 |
"title": "Ropedia Xperience-10M Task Suite Evaluation Protocol",
|
| 3 |
"status": "pass",
|
| 4 |
"version": "2026-06-01",
|
| 5 |
-
"generated_at_utc": "2026-06-
|
| 6 |
"source_files": [
|
| 7 |
"docs/data/summary_metrics.json",
|
| 8 |
"results/episode_task_suite/summary_report.json",
|
|
@@ -30,7 +30,7 @@
|
|
| 30 |
"additional_public_sample_tasks": 8,
|
| 31 |
"unified_results": "docs/data/task_suite_20.json",
|
| 32 |
"legacy_additional_task_result_path": "docs/data/tier2_task_suite.json",
|
| 33 |
-
"legacy_path_note": "The tier2_task_suite path is retained for stable links only;
|
| 34 |
},
|
| 35 |
"split_policy": {
|
| 36 |
"name": "single_episode_chronological",
|
|
|
|
| 2 |
"title": "Ropedia Xperience-10M Task Suite Evaluation Protocol",
|
| 3 |
"status": "pass",
|
| 4 |
"version": "2026-06-01",
|
| 5 |
+
"generated_at_utc": "2026-06-21T14:40:33+00:00",
|
| 6 |
"source_files": [
|
| 7 |
"docs/data/summary_metrics.json",
|
| 8 |
"results/episode_task_suite/summary_report.json",
|
|
|
|
| 30 |
"additional_public_sample_tasks": 8,
|
| 31 |
"unified_results": "docs/data/task_suite_20.json",
|
| 32 |
"legacy_additional_task_result_path": "docs/data/tier2_task_suite.json",
|
| 33 |
+
"legacy_path_note": "The tier2_task_suite path is retained for stable links only; it is provenance inside the same 20-task suite."
|
| 34 |
},
|
| 35 |
"split_policy": {
|
| 36 |
"name": "single_episode_chronological",
|
docs/data/figure_index.json
CHANGED
|
@@ -1,7 +1,7 @@
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Figure Index",
|
| 3 |
"status": "pass",
|
| 4 |
-
"generated_at_utc": "2026-06-
|
| 5 |
"scope": "Public figures, diagrams, charts, and derived modality thumbnails. Raw Xperience-10M videos, annotations, RRD files, and Qwen weights are excluded.",
|
| 6 |
"figure_count": 29,
|
| 7 |
"figures": [
|
|
@@ -386,9 +386,9 @@
|
|
| 386 |
},
|
| 387 |
{
|
| 388 |
"id": "tier2_task_suite_chart",
|
| 389 |
-
"title": "
|
| 390 |
"path": "docs/assets/charts/tier2_task_suite.svg",
|
| 391 |
-
"role": "
|
| 392 |
"source_script": "scripts/tier2_task_suite.py",
|
| 393 |
"surface": "website unified task section, README, HF mirrors",
|
| 394 |
"exists": true,
|
|
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Figure Index",
|
| 3 |
"status": "pass",
|
| 4 |
+
"generated_at_utc": "2026-06-21T14:40:33+00:00",
|
| 5 |
"scope": "Public figures, diagrams, charts, and derived modality thumbnails. Raw Xperience-10M videos, annotations, RRD files, and Qwen weights are excluded.",
|
| 6 |
"figure_count": 29,
|
| 7 |
"figures": [
|
|
|
|
| 386 |
},
|
| 387 |
{
|
| 388 |
"id": "tier2_task_suite_chart",
|
| 389 |
+
"title": "Unified 20-task provenance chart",
|
| 390 |
"path": "docs/assets/charts/tier2_task_suite.svg",
|
| 391 |
+
"role": "Historical provenance rows inside the unified 20-task suite with aligned minimal and neural baseline metrics.",
|
| 392 |
"source_script": "scripts/tier2_task_suite.py",
|
| 393 |
"surface": "website unified task section, README, HF mirrors",
|
| 394 |
"exists": true,
|
docs/data/glossary.json
CHANGED
|
@@ -138,8 +138,8 @@
|
|
| 138 |
"term": "Unified 20-task suite",
|
| 139 |
"category": "tasks_metrics",
|
| 140 |
"plain_meaning": "The current task surface.",
|
| 141 |
-
"project_usage": "
|
| 142 |
-
"do_not_confuse_with": "
|
| 143 |
"primary_files": ["TASK_SUITE_20.md", "docs/data/task_suite_20.json"]
|
| 144 |
},
|
| 145 |
{
|
|
|
|
| 138 |
"term": "Unified 20-task suite",
|
| 139 |
"category": "tasks_metrics",
|
| 140 |
"plain_meaning": "The current task surface.",
|
| 141 |
+
"project_usage": "All 20 task contracts are presented together and scored across methods where real artifacts exist.",
|
| 142 |
+
"do_not_confuse_with": "Historical tier2_task_suite filenames, which are provenance paths rather than a second suite.",
|
| 143 |
"primary_files": ["TASK_SUITE_20.md", "docs/data/task_suite_20.json"]
|
| 144 |
},
|
| 145 |
{
|
docs/data/mirror_parity.json
CHANGED
|
@@ -1,6 +1,6 @@
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
-
"generated_at_utc": "2026-06-21T14:
|
| 4 |
"hf_root": "hf_publish",
|
| 5 |
"summary": {
|
| 6 |
"group_count": 1258,
|
|
@@ -138,45 +138,45 @@
|
|
| 138 |
"local": {
|
| 139 |
"path": "repo:docs/data/artifact_index.json",
|
| 140 |
"exists": true,
|
| 141 |
-
"bytes":
|
| 142 |
-
"sha256": "
|
| 143 |
},
|
| 144 |
"mirrors": {
|
| 145 |
"hf_space": {
|
| 146 |
"path": "hf_space:data/artifact_index.json",
|
| 147 |
"exists": true,
|
| 148 |
-
"bytes":
|
| 149 |
-
"sha256": "
|
| 150 |
},
|
| 151 |
"hf_artifacts_data": {
|
| 152 |
"path": "hf_artifacts:data/artifact_index.json",
|
| 153 |
"exists": true,
|
| 154 |
-
"bytes":
|
| 155 |
-
"sha256": "
|
| 156 |
},
|
| 157 |
"hf_artifacts": {
|
| 158 |
"path": "hf_artifacts:docs/data/artifact_index.json",
|
| 159 |
"exists": true,
|
| 160 |
-
"bytes":
|
| 161 |
-
"sha256": "
|
| 162 |
},
|
| 163 |
"hf_model_data": {
|
| 164 |
"path": "hf_model:data/artifact_index.json",
|
| 165 |
"exists": true,
|
| 166 |
-
"bytes":
|
| 167 |
-
"sha256": "
|
| 168 |
},
|
| 169 |
"hf_model_docs_data": {
|
| 170 |
"path": "hf_model:docs/data/artifact_index.json",
|
| 171 |
"exists": true,
|
| 172 |
-
"bytes":
|
| 173 |
-
"sha256": "
|
| 174 |
},
|
| 175 |
"hf_model": {
|
| 176 |
"path": "hf_model:metrics/artifact_index.json",
|
| 177 |
"exists": true,
|
| 178 |
-
"bytes":
|
| 179 |
-
"sha256": "
|
| 180 |
}
|
| 181 |
},
|
| 182 |
"failures": []
|
|
@@ -285,45 +285,45 @@
|
|
| 285 |
"local": {
|
| 286 |
"path": "repo:docs/data/evaluation_protocol.json",
|
| 287 |
"exists": true,
|
| 288 |
-
"bytes":
|
| 289 |
-
"sha256": "
|
| 290 |
},
|
| 291 |
"mirrors": {
|
| 292 |
"hf_space": {
|
| 293 |
"path": "hf_space:data/evaluation_protocol.json",
|
| 294 |
"exists": true,
|
| 295 |
-
"bytes":
|
| 296 |
-
"sha256": "
|
| 297 |
},
|
| 298 |
"hf_artifacts_data": {
|
| 299 |
"path": "hf_artifacts:data/evaluation_protocol.json",
|
| 300 |
"exists": true,
|
| 301 |
-
"bytes":
|
| 302 |
-
"sha256": "
|
| 303 |
},
|
| 304 |
"hf_artifacts": {
|
| 305 |
"path": "hf_artifacts:docs/data/evaluation_protocol.json",
|
| 306 |
"exists": true,
|
| 307 |
-
"bytes":
|
| 308 |
-
"sha256": "
|
| 309 |
},
|
| 310 |
"hf_model_data": {
|
| 311 |
"path": "hf_model:data/evaluation_protocol.json",
|
| 312 |
"exists": true,
|
| 313 |
-
"bytes":
|
| 314 |
-
"sha256": "
|
| 315 |
},
|
| 316 |
"hf_model_docs_data": {
|
| 317 |
"path": "hf_model:docs/data/evaluation_protocol.json",
|
| 318 |
"exists": true,
|
| 319 |
-
"bytes":
|
| 320 |
-
"sha256": "
|
| 321 |
},
|
| 322 |
"hf_model": {
|
| 323 |
"path": "hf_model:metrics/evaluation_protocol.json",
|
| 324 |
"exists": true,
|
| 325 |
-
"bytes":
|
| 326 |
-
"sha256": "
|
| 327 |
}
|
| 328 |
},
|
| 329 |
"failures": []
|
|
@@ -334,45 +334,45 @@
|
|
| 334 |
"local": {
|
| 335 |
"path": "repo:docs/data/figure_index.json",
|
| 336 |
"exists": true,
|
| 337 |
-
"bytes":
|
| 338 |
-
"sha256": "
|
| 339 |
},
|
| 340 |
"mirrors": {
|
| 341 |
"hf_space": {
|
| 342 |
"path": "hf_space:data/figure_index.json",
|
| 343 |
"exists": true,
|
| 344 |
-
"bytes":
|
| 345 |
-
"sha256": "
|
| 346 |
},
|
| 347 |
"hf_artifacts_data": {
|
| 348 |
"path": "hf_artifacts:data/figure_index.json",
|
| 349 |
"exists": true,
|
| 350 |
-
"bytes":
|
| 351 |
-
"sha256": "
|
| 352 |
},
|
| 353 |
"hf_artifacts": {
|
| 354 |
"path": "hf_artifacts:docs/data/figure_index.json",
|
| 355 |
"exists": true,
|
| 356 |
-
"bytes":
|
| 357 |
-
"sha256": "
|
| 358 |
},
|
| 359 |
"hf_model_data": {
|
| 360 |
"path": "hf_model:data/figure_index.json",
|
| 361 |
"exists": true,
|
| 362 |
-
"bytes":
|
| 363 |
-
"sha256": "
|
| 364 |
},
|
| 365 |
"hf_model_docs_data": {
|
| 366 |
"path": "hf_model:docs/data/figure_index.json",
|
| 367 |
"exists": true,
|
| 368 |
-
"bytes":
|
| 369 |
-
"sha256": "
|
| 370 |
},
|
| 371 |
"hf_model": {
|
| 372 |
"path": "hf_model:metrics/figure_index.json",
|
| 373 |
"exists": true,
|
| 374 |
-
"bytes":
|
| 375 |
-
"sha256": "
|
| 376 |
}
|
| 377 |
},
|
| 378 |
"failures": []
|
|
@@ -432,45 +432,45 @@
|
|
| 432 |
"local": {
|
| 433 |
"path": "repo:docs/data/glossary.json",
|
| 434 |
"exists": true,
|
| 435 |
-
"bytes":
|
| 436 |
-
"sha256": "
|
| 437 |
},
|
| 438 |
"mirrors": {
|
| 439 |
"hf_space": {
|
| 440 |
"path": "hf_space:data/glossary.json",
|
| 441 |
"exists": true,
|
| 442 |
-
"bytes":
|
| 443 |
-
"sha256": "
|
| 444 |
},
|
| 445 |
"hf_artifacts_data": {
|
| 446 |
"path": "hf_artifacts:data/glossary.json",
|
| 447 |
"exists": true,
|
| 448 |
-
"bytes":
|
| 449 |
-
"sha256": "
|
| 450 |
},
|
| 451 |
"hf_artifacts": {
|
| 452 |
"path": "hf_artifacts:docs/data/glossary.json",
|
| 453 |
"exists": true,
|
| 454 |
-
"bytes":
|
| 455 |
-
"sha256": "
|
| 456 |
},
|
| 457 |
"hf_model_data": {
|
| 458 |
"path": "hf_model:data/glossary.json",
|
| 459 |
"exists": true,
|
| 460 |
-
"bytes":
|
| 461 |
-
"sha256": "
|
| 462 |
},
|
| 463 |
"hf_model_docs_data": {
|
| 464 |
"path": "hf_model:docs/data/glossary.json",
|
| 465 |
"exists": true,
|
| 466 |
-
"bytes":
|
| 467 |
-
"sha256": "
|
| 468 |
},
|
| 469 |
"hf_model": {
|
| 470 |
"path": "hf_model:metrics/glossary.json",
|
| 471 |
"exists": true,
|
| 472 |
-
"bytes":
|
| 473 |
-
"sha256": "
|
| 474 |
}
|
| 475 |
},
|
| 476 |
"failures": []
|
|
@@ -481,45 +481,45 @@
|
|
| 481 |
"local": {
|
| 482 |
"path": "repo:docs/data/live_publication_status.json",
|
| 483 |
"exists": true,
|
| 484 |
-
"bytes":
|
| 485 |
-
"sha256": "
|
| 486 |
},
|
| 487 |
"mirrors": {
|
| 488 |
"hf_space": {
|
| 489 |
"path": "hf_space:data/live_publication_status.json",
|
| 490 |
"exists": true,
|
| 491 |
-
"bytes":
|
| 492 |
-
"sha256": "
|
| 493 |
},
|
| 494 |
"hf_artifacts_data": {
|
| 495 |
"path": "hf_artifacts:data/live_publication_status.json",
|
| 496 |
"exists": true,
|
| 497 |
-
"bytes":
|
| 498 |
-
"sha256": "
|
| 499 |
},
|
| 500 |
"hf_artifacts": {
|
| 501 |
"path": "hf_artifacts:docs/data/live_publication_status.json",
|
| 502 |
"exists": true,
|
| 503 |
-
"bytes":
|
| 504 |
-
"sha256": "
|
| 505 |
},
|
| 506 |
"hf_model_data": {
|
| 507 |
"path": "hf_model:data/live_publication_status.json",
|
| 508 |
"exists": true,
|
| 509 |
-
"bytes":
|
| 510 |
-
"sha256": "
|
| 511 |
},
|
| 512 |
"hf_model_docs_data": {
|
| 513 |
"path": "hf_model:docs/data/live_publication_status.json",
|
| 514 |
"exists": true,
|
| 515 |
-
"bytes":
|
| 516 |
-
"sha256": "
|
| 517 |
},
|
| 518 |
"hf_model": {
|
| 519 |
"path": "hf_model:metrics/live_publication_status.json",
|
| 520 |
"exists": true,
|
| 521 |
-
"bytes":
|
| 522 |
-
"sha256": "
|
| 523 |
}
|
| 524 |
},
|
| 525 |
"failures": []
|
|
@@ -972,44 +972,44 @@
|
|
| 972 |
"path": "repo:docs/data/publication_audit.json",
|
| 973 |
"exists": true,
|
| 974 |
"bytes": 10939,
|
| 975 |
-
"sha256": "
|
| 976 |
},
|
| 977 |
"mirrors": {
|
| 978 |
"hf_space": {
|
| 979 |
"path": "hf_space:data/publication_audit.json",
|
| 980 |
"exists": true,
|
| 981 |
"bytes": 10939,
|
| 982 |
-
"sha256": "
|
| 983 |
},
|
| 984 |
"hf_artifacts_data": {
|
| 985 |
"path": "hf_artifacts:data/publication_audit.json",
|
| 986 |
"exists": true,
|
| 987 |
"bytes": 10939,
|
| 988 |
-
"sha256": "
|
| 989 |
},
|
| 990 |
"hf_artifacts": {
|
| 991 |
"path": "hf_artifacts:docs/data/publication_audit.json",
|
| 992 |
"exists": true,
|
| 993 |
"bytes": 10939,
|
| 994 |
-
"sha256": "
|
| 995 |
},
|
| 996 |
"hf_model_data": {
|
| 997 |
"path": "hf_model:data/publication_audit.json",
|
| 998 |
"exists": true,
|
| 999 |
"bytes": 10939,
|
| 1000 |
-
"sha256": "
|
| 1001 |
},
|
| 1002 |
"hf_model_docs_data": {
|
| 1003 |
"path": "hf_model:docs/data/publication_audit.json",
|
| 1004 |
"exists": true,
|
| 1005 |
"bytes": 10939,
|
| 1006 |
-
"sha256": "
|
| 1007 |
},
|
| 1008 |
"hf_model": {
|
| 1009 |
"path": "hf_model:metrics/publication_audit.json",
|
| 1010 |
"exists": true,
|
| 1011 |
"bytes": 10939,
|
| 1012 |
-
"sha256": "
|
| 1013 |
}
|
| 1014 |
},
|
| 1015 |
"failures": []
|
|
@@ -1020,45 +1020,45 @@
|
|
| 1020 |
"local": {
|
| 1021 |
"path": "repo:docs/data/public_surface_qa.json",
|
| 1022 |
"exists": true,
|
| 1023 |
-
"bytes":
|
| 1024 |
-
"sha256": "
|
| 1025 |
},
|
| 1026 |
"mirrors": {
|
| 1027 |
"hf_space": {
|
| 1028 |
"path": "hf_space:data/public_surface_qa.json",
|
| 1029 |
"exists": true,
|
| 1030 |
-
"bytes":
|
| 1031 |
-
"sha256": "
|
| 1032 |
},
|
| 1033 |
"hf_artifacts_data": {
|
| 1034 |
"path": "hf_artifacts:data/public_surface_qa.json",
|
| 1035 |
"exists": true,
|
| 1036 |
-
"bytes":
|
| 1037 |
-
"sha256": "
|
| 1038 |
},
|
| 1039 |
"hf_artifacts": {
|
| 1040 |
"path": "hf_artifacts:docs/data/public_surface_qa.json",
|
| 1041 |
"exists": true,
|
| 1042 |
-
"bytes":
|
| 1043 |
-
"sha256": "
|
| 1044 |
},
|
| 1045 |
"hf_model_data": {
|
| 1046 |
"path": "hf_model:data/public_surface_qa.json",
|
| 1047 |
"exists": true,
|
| 1048 |
-
"bytes":
|
| 1049 |
-
"sha256": "
|
| 1050 |
},
|
| 1051 |
"hf_model_docs_data": {
|
| 1052 |
"path": "hf_model:docs/data/public_surface_qa.json",
|
| 1053 |
"exists": true,
|
| 1054 |
-
"bytes":
|
| 1055 |
-
"sha256": "
|
| 1056 |
},
|
| 1057 |
"hf_model": {
|
| 1058 |
"path": "hf_model:metrics/public_surface_qa.json",
|
| 1059 |
"exists": true,
|
| 1060 |
-
"bytes":
|
| 1061 |
-
"sha256": "
|
| 1062 |
}
|
| 1063 |
},
|
| 1064 |
"failures": []
|
|
@@ -1217,44 +1217,44 @@
|
|
| 1217 |
"path": "repo:docs/data/quality_gates.json",
|
| 1218 |
"exists": true,
|
| 1219 |
"bytes": 8640,
|
| 1220 |
-
"sha256": "
|
| 1221 |
},
|
| 1222 |
"mirrors": {
|
| 1223 |
"hf_space": {
|
| 1224 |
"path": "hf_space:data/quality_gates.json",
|
| 1225 |
"exists": true,
|
| 1226 |
"bytes": 8640,
|
| 1227 |
-
"sha256": "
|
| 1228 |
},
|
| 1229 |
"hf_artifacts_data": {
|
| 1230 |
"path": "hf_artifacts:data/quality_gates.json",
|
| 1231 |
"exists": true,
|
| 1232 |
"bytes": 8640,
|
| 1233 |
-
"sha256": "
|
| 1234 |
},
|
| 1235 |
"hf_artifacts": {
|
| 1236 |
"path": "hf_artifacts:docs/data/quality_gates.json",
|
| 1237 |
"exists": true,
|
| 1238 |
"bytes": 8640,
|
| 1239 |
-
"sha256": "
|
| 1240 |
},
|
| 1241 |
"hf_model_data": {
|
| 1242 |
"path": "hf_model:data/quality_gates.json",
|
| 1243 |
"exists": true,
|
| 1244 |
"bytes": 8640,
|
| 1245 |
-
"sha256": "
|
| 1246 |
},
|
| 1247 |
"hf_model_docs_data": {
|
| 1248 |
"path": "hf_model:docs/data/quality_gates.json",
|
| 1249 |
"exists": true,
|
| 1250 |
"bytes": 8640,
|
| 1251 |
-
"sha256": "
|
| 1252 |
},
|
| 1253 |
"hf_model": {
|
| 1254 |
"path": "hf_model:metrics/quality_gates.json",
|
| 1255 |
"exists": true,
|
| 1256 |
"bytes": 8640,
|
| 1257 |
-
"sha256": "
|
| 1258 |
}
|
| 1259 |
},
|
| 1260 |
"failures": []
|
|
@@ -1658,44 +1658,44 @@
|
|
| 1658 |
"path": "repo:docs/data/scope_claims_audit.json",
|
| 1659 |
"exists": true,
|
| 1660 |
"bytes": 21313,
|
| 1661 |
-
"sha256": "
|
| 1662 |
},
|
| 1663 |
"mirrors": {
|
| 1664 |
"hf_space": {
|
| 1665 |
"path": "hf_space:data/scope_claims_audit.json",
|
| 1666 |
"exists": true,
|
| 1667 |
"bytes": 21313,
|
| 1668 |
-
"sha256": "
|
| 1669 |
},
|
| 1670 |
"hf_artifacts_data": {
|
| 1671 |
"path": "hf_artifacts:data/scope_claims_audit.json",
|
| 1672 |
"exists": true,
|
| 1673 |
"bytes": 21313,
|
| 1674 |
-
"sha256": "
|
| 1675 |
},
|
| 1676 |
"hf_artifacts": {
|
| 1677 |
"path": "hf_artifacts:docs/data/scope_claims_audit.json",
|
| 1678 |
"exists": true,
|
| 1679 |
"bytes": 21313,
|
| 1680 |
-
"sha256": "
|
| 1681 |
},
|
| 1682 |
"hf_model_data": {
|
| 1683 |
"path": "hf_model:data/scope_claims_audit.json",
|
| 1684 |
"exists": true,
|
| 1685 |
"bytes": 21313,
|
| 1686 |
-
"sha256": "
|
| 1687 |
},
|
| 1688 |
"hf_model_docs_data": {
|
| 1689 |
"path": "hf_model:docs/data/scope_claims_audit.json",
|
| 1690 |
"exists": true,
|
| 1691 |
"bytes": 21313,
|
| 1692 |
-
"sha256": "
|
| 1693 |
},
|
| 1694 |
"hf_model": {
|
| 1695 |
"path": "hf_model:metrics/scope_claims_audit.json",
|
| 1696 |
"exists": true,
|
| 1697 |
"bytes": 21313,
|
| 1698 |
-
"sha256": "
|
| 1699 |
}
|
| 1700 |
},
|
| 1701 |
"failures": []
|
|
@@ -1756,44 +1756,44 @@
|
|
| 1756 |
"path": "repo:docs/data/source_alignment_audit.json",
|
| 1757 |
"exists": true,
|
| 1758 |
"bytes": 4432,
|
| 1759 |
-
"sha256": "
|
| 1760 |
},
|
| 1761 |
"mirrors": {
|
| 1762 |
"hf_space": {
|
| 1763 |
"path": "hf_space:data/source_alignment_audit.json",
|
| 1764 |
"exists": true,
|
| 1765 |
"bytes": 4432,
|
| 1766 |
-
"sha256": "
|
| 1767 |
},
|
| 1768 |
"hf_artifacts_data": {
|
| 1769 |
"path": "hf_artifacts:data/source_alignment_audit.json",
|
| 1770 |
"exists": true,
|
| 1771 |
"bytes": 4432,
|
| 1772 |
-
"sha256": "
|
| 1773 |
},
|
| 1774 |
"hf_artifacts": {
|
| 1775 |
"path": "hf_artifacts:docs/data/source_alignment_audit.json",
|
| 1776 |
"exists": true,
|
| 1777 |
"bytes": 4432,
|
| 1778 |
-
"sha256": "
|
| 1779 |
},
|
| 1780 |
"hf_model_data": {
|
| 1781 |
"path": "hf_model:data/source_alignment_audit.json",
|
| 1782 |
"exists": true,
|
| 1783 |
"bytes": 4432,
|
| 1784 |
-
"sha256": "
|
| 1785 |
},
|
| 1786 |
"hf_model_docs_data": {
|
| 1787 |
"path": "hf_model:docs/data/source_alignment_audit.json",
|
| 1788 |
"exists": true,
|
| 1789 |
"bytes": 4432,
|
| 1790 |
-
"sha256": "
|
| 1791 |
},
|
| 1792 |
"hf_model": {
|
| 1793 |
"path": "hf_model:metrics/source_alignment_audit.json",
|
| 1794 |
"exists": true,
|
| 1795 |
"bytes": 4432,
|
| 1796 |
-
"sha256": "
|
| 1797 |
}
|
| 1798 |
},
|
| 1799 |
"failures": []
|
|
@@ -2098,45 +2098,45 @@
|
|
| 2098 |
"local": {
|
| 2099 |
"path": "repo:docs/data/task_suite_20.json",
|
| 2100 |
"exists": true,
|
| 2101 |
-
"bytes":
|
| 2102 |
-
"sha256": "
|
| 2103 |
},
|
| 2104 |
"mirrors": {
|
| 2105 |
"hf_space": {
|
| 2106 |
"path": "hf_space:data/task_suite_20.json",
|
| 2107 |
"exists": true,
|
| 2108 |
-
"bytes":
|
| 2109 |
-
"sha256": "
|
| 2110 |
},
|
| 2111 |
"hf_artifacts_data": {
|
| 2112 |
"path": "hf_artifacts:data/task_suite_20.json",
|
| 2113 |
"exists": true,
|
| 2114 |
-
"bytes":
|
| 2115 |
-
"sha256": "
|
| 2116 |
},
|
| 2117 |
"hf_artifacts": {
|
| 2118 |
"path": "hf_artifacts:docs/data/task_suite_20.json",
|
| 2119 |
"exists": true,
|
| 2120 |
-
"bytes":
|
| 2121 |
-
"sha256": "
|
| 2122 |
},
|
| 2123 |
"hf_model_data": {
|
| 2124 |
"path": "hf_model:data/task_suite_20.json",
|
| 2125 |
"exists": true,
|
| 2126 |
-
"bytes":
|
| 2127 |
-
"sha256": "
|
| 2128 |
},
|
| 2129 |
"hf_model_docs_data": {
|
| 2130 |
"path": "hf_model:docs/data/task_suite_20.json",
|
| 2131 |
"exists": true,
|
| 2132 |
-
"bytes":
|
| 2133 |
-
"sha256": "
|
| 2134 |
},
|
| 2135 |
"hf_model": {
|
| 2136 |
"path": "hf_model:metrics/task_suite_20.json",
|
| 2137 |
"exists": true,
|
| 2138 |
-
"bytes":
|
| 2139 |
-
"sha256": "
|
| 2140 |
}
|
| 2141 |
},
|
| 2142 |
"failures": []
|
|
@@ -2197,44 +2197,44 @@
|
|
| 2197 |
"path": "repo:docs/data/task_surface_integrity.json",
|
| 2198 |
"exists": true,
|
| 2199 |
"bytes": 46246,
|
| 2200 |
-
"sha256": "
|
| 2201 |
},
|
| 2202 |
"mirrors": {
|
| 2203 |
"hf_space": {
|
| 2204 |
"path": "hf_space:data/task_surface_integrity.json",
|
| 2205 |
"exists": true,
|
| 2206 |
"bytes": 46246,
|
| 2207 |
-
"sha256": "
|
| 2208 |
},
|
| 2209 |
"hf_artifacts_data": {
|
| 2210 |
"path": "hf_artifacts:data/task_surface_integrity.json",
|
| 2211 |
"exists": true,
|
| 2212 |
"bytes": 46246,
|
| 2213 |
-
"sha256": "
|
| 2214 |
},
|
| 2215 |
"hf_artifacts": {
|
| 2216 |
"path": "hf_artifacts:docs/data/task_surface_integrity.json",
|
| 2217 |
"exists": true,
|
| 2218 |
"bytes": 46246,
|
| 2219 |
-
"sha256": "
|
| 2220 |
},
|
| 2221 |
"hf_model_data": {
|
| 2222 |
"path": "hf_model:data/task_surface_integrity.json",
|
| 2223 |
"exists": true,
|
| 2224 |
"bytes": 46246,
|
| 2225 |
-
"sha256": "
|
| 2226 |
},
|
| 2227 |
"hf_model_docs_data": {
|
| 2228 |
"path": "hf_model:docs/data/task_surface_integrity.json",
|
| 2229 |
"exists": true,
|
| 2230 |
"bytes": 46246,
|
| 2231 |
-
"sha256": "
|
| 2232 |
},
|
| 2233 |
"hf_model": {
|
| 2234 |
"path": "hf_model:metrics/task_surface_integrity.json",
|
| 2235 |
"exists": true,
|
| 2236 |
"bytes": 46246,
|
| 2237 |
-
"sha256": "
|
| 2238 |
}
|
| 2239 |
},
|
| 2240 |
"failures": []
|
|
@@ -2441,45 +2441,45 @@
|
|
| 2441 |
"local": {
|
| 2442 |
"path": "repo:docs/data/tier2_task_suite.json",
|
| 2443 |
"exists": true,
|
| 2444 |
-
"bytes":
|
| 2445 |
-
"sha256": "
|
| 2446 |
},
|
| 2447 |
"mirrors": {
|
| 2448 |
"hf_space": {
|
| 2449 |
"path": "hf_space:data/tier2_task_suite.json",
|
| 2450 |
"exists": true,
|
| 2451 |
-
"bytes":
|
| 2452 |
-
"sha256": "
|
| 2453 |
},
|
| 2454 |
"hf_artifacts_data": {
|
| 2455 |
"path": "hf_artifacts:data/tier2_task_suite.json",
|
| 2456 |
"exists": true,
|
| 2457 |
-
"bytes":
|
| 2458 |
-
"sha256": "
|
| 2459 |
},
|
| 2460 |
"hf_artifacts": {
|
| 2461 |
"path": "hf_artifacts:docs/data/tier2_task_suite.json",
|
| 2462 |
"exists": true,
|
| 2463 |
-
"bytes":
|
| 2464 |
-
"sha256": "
|
| 2465 |
},
|
| 2466 |
"hf_model_data": {
|
| 2467 |
"path": "hf_model:data/tier2_task_suite.json",
|
| 2468 |
"exists": true,
|
| 2469 |
-
"bytes":
|
| 2470 |
-
"sha256": "
|
| 2471 |
},
|
| 2472 |
"hf_model_docs_data": {
|
| 2473 |
"path": "hf_model:docs/data/tier2_task_suite.json",
|
| 2474 |
"exists": true,
|
| 2475 |
-
"bytes":
|
| 2476 |
-
"sha256": "
|
| 2477 |
},
|
| 2478 |
"hf_model": {
|
| 2479 |
"path": "hf_model:metrics/tier2_task_suite.json",
|
| 2480 |
"exists": true,
|
| 2481 |
-
"bytes":
|
| 2482 |
-
"sha256": "
|
| 2483 |
}
|
| 2484 |
},
|
| 2485 |
"failures": []
|
|
@@ -2540,44 +2540,44 @@
|
|
| 2540 |
"path": "repo:docs/data/website_integrity.json",
|
| 2541 |
"exists": true,
|
| 2542 |
"bytes": 20760,
|
| 2543 |
-
"sha256": "
|
| 2544 |
},
|
| 2545 |
"mirrors": {
|
| 2546 |
"hf_space": {
|
| 2547 |
"path": "hf_space:data/website_integrity.json",
|
| 2548 |
"exists": true,
|
| 2549 |
"bytes": 20760,
|
| 2550 |
-
"sha256": "
|
| 2551 |
},
|
| 2552 |
"hf_artifacts_data": {
|
| 2553 |
"path": "hf_artifacts:data/website_integrity.json",
|
| 2554 |
"exists": true,
|
| 2555 |
"bytes": 20760,
|
| 2556 |
-
"sha256": "
|
| 2557 |
},
|
| 2558 |
"hf_artifacts": {
|
| 2559 |
"path": "hf_artifacts:docs/data/website_integrity.json",
|
| 2560 |
"exists": true,
|
| 2561 |
"bytes": 20760,
|
| 2562 |
-
"sha256": "
|
| 2563 |
},
|
| 2564 |
"hf_model_data": {
|
| 2565 |
"path": "hf_model:data/website_integrity.json",
|
| 2566 |
"exists": true,
|
| 2567 |
"bytes": 20760,
|
| 2568 |
-
"sha256": "
|
| 2569 |
},
|
| 2570 |
"hf_model_docs_data": {
|
| 2571 |
"path": "hf_model:docs/data/website_integrity.json",
|
| 2572 |
"exists": true,
|
| 2573 |
"bytes": 20760,
|
| 2574 |
-
"sha256": "
|
| 2575 |
},
|
| 2576 |
"hf_model": {
|
| 2577 |
"path": "hf_model:metrics/website_integrity.json",
|
| 2578 |
"exists": true,
|
| 2579 |
"bytes": 20760,
|
| 2580 |
-
"sha256": "
|
| 2581 |
}
|
| 2582 |
},
|
| 2583 |
"failures": []
|
|
@@ -2834,33 +2834,33 @@
|
|
| 2834 |
"local": {
|
| 2835 |
"path": "repo:docs/assets/charts/tier2_task_suite.svg",
|
| 2836 |
"exists": true,
|
| 2837 |
-
"bytes":
|
| 2838 |
-
"sha256": "
|
| 2839 |
},
|
| 2840 |
"mirrors": {
|
| 2841 |
"hf_space": {
|
| 2842 |
"path": "hf_space:assets/charts/tier2_task_suite.svg",
|
| 2843 |
"exists": true,
|
| 2844 |
-
"bytes":
|
| 2845 |
-
"sha256": "
|
| 2846 |
},
|
| 2847 |
"hf_artifacts_docs": {
|
| 2848 |
"path": "hf_artifacts:docs/assets/charts/tier2_task_suite.svg",
|
| 2849 |
"exists": true,
|
| 2850 |
-
"bytes":
|
| 2851 |
-
"sha256": "
|
| 2852 |
},
|
| 2853 |
"hf_artifacts_card": {
|
| 2854 |
"path": "hf_artifacts:assets/charts/tier2_task_suite.svg",
|
| 2855 |
"exists": true,
|
| 2856 |
-
"bytes":
|
| 2857 |
-
"sha256": "
|
| 2858 |
},
|
| 2859 |
"hf_model": {
|
| 2860 |
"path": "hf_model:assets/charts/tier2_task_suite.svg",
|
| 2861 |
"exists": true,
|
| 2862 |
-
"bytes":
|
| 2863 |
-
"sha256": "
|
| 2864 |
}
|
| 2865 |
},
|
| 2866 |
"failures": []
|
|
@@ -3204,33 +3204,33 @@
|
|
| 3204 |
"local": {
|
| 3205 |
"path": "repo:docs/assets/task_suite_infographic.png",
|
| 3206 |
"exists": true,
|
| 3207 |
-
"bytes":
|
| 3208 |
-
"sha256": "
|
| 3209 |
},
|
| 3210 |
"mirrors": {
|
| 3211 |
"hf_space": {
|
| 3212 |
"path": "hf_space:assets/task_suite_infographic.png",
|
| 3213 |
"exists": true,
|
| 3214 |
-
"bytes":
|
| 3215 |
-
"sha256": "
|
| 3216 |
},
|
| 3217 |
"hf_artifacts_docs": {
|
| 3218 |
"path": "hf_artifacts:docs/assets/task_suite_infographic.png",
|
| 3219 |
"exists": true,
|
| 3220 |
-
"bytes":
|
| 3221 |
-
"sha256": "
|
| 3222 |
},
|
| 3223 |
"hf_artifacts_card": {
|
| 3224 |
"path": "hf_artifacts:assets/task_suite_infographic.png",
|
| 3225 |
"exists": true,
|
| 3226 |
-
"bytes":
|
| 3227 |
-
"sha256": "
|
| 3228 |
},
|
| 3229 |
"hf_model": {
|
| 3230 |
"path": "hf_model:assets/task_suite_infographic.png",
|
| 3231 |
"exists": true,
|
| 3232 |
-
"bytes":
|
| 3233 |
-
"sha256": "
|
| 3234 |
}
|
| 3235 |
},
|
| 3236 |
"failures": []
|
|
@@ -4327,21 +4327,21 @@
|
|
| 4327 |
"local": {
|
| 4328 |
"path": "repo:scripts/omni/build_omni_model_comparison.py",
|
| 4329 |
"exists": true,
|
| 4330 |
-
"bytes":
|
| 4331 |
-
"sha256": "
|
| 4332 |
},
|
| 4333 |
"mirrors": {
|
| 4334 |
"hf_artifacts": {
|
| 4335 |
"path": "hf_artifacts:scripts/omni/build_omni_model_comparison.py",
|
| 4336 |
"exists": true,
|
| 4337 |
-
"bytes":
|
| 4338 |
-
"sha256": "
|
| 4339 |
},
|
| 4340 |
"hf_model": {
|
| 4341 |
"path": "hf_model:scripts/omni/build_omni_model_comparison.py",
|
| 4342 |
"exists": true,
|
| 4343 |
-
"bytes":
|
| 4344 |
-
"sha256": "
|
| 4345 |
}
|
| 4346 |
},
|
| 4347 |
"failures": []
|
|
@@ -5327,21 +5327,21 @@
|
|
| 5327 |
"local": {
|
| 5328 |
"path": "repo:scripts/build_artifact_index.py",
|
| 5329 |
"exists": true,
|
| 5330 |
-
"bytes":
|
| 5331 |
-
"sha256": "
|
| 5332 |
},
|
| 5333 |
"mirrors": {
|
| 5334 |
"hf_artifacts": {
|
| 5335 |
"path": "hf_artifacts:scripts/build_artifact_index.py",
|
| 5336 |
"exists": true,
|
| 5337 |
-
"bytes":
|
| 5338 |
-
"sha256": "
|
| 5339 |
},
|
| 5340 |
"hf_model": {
|
| 5341 |
"path": "hf_model:scripts/build_artifact_index.py",
|
| 5342 |
"exists": true,
|
| 5343 |
-
"bytes":
|
| 5344 |
-
"sha256": "
|
| 5345 |
}
|
| 5346 |
},
|
| 5347 |
"failures": []
|
|
@@ -5377,21 +5377,21 @@
|
|
| 5377 |
"local": {
|
| 5378 |
"path": "repo:scripts/build_evaluation_protocol.py",
|
| 5379 |
"exists": true,
|
| 5380 |
-
"bytes":
|
| 5381 |
-
"sha256": "
|
| 5382 |
},
|
| 5383 |
"mirrors": {
|
| 5384 |
"hf_artifacts": {
|
| 5385 |
"path": "hf_artifacts:scripts/build_evaluation_protocol.py",
|
| 5386 |
"exists": true,
|
| 5387 |
-
"bytes":
|
| 5388 |
-
"sha256": "
|
| 5389 |
},
|
| 5390 |
"hf_model": {
|
| 5391 |
"path": "hf_model:scripts/build_evaluation_protocol.py",
|
| 5392 |
"exists": true,
|
| 5393 |
-
"bytes":
|
| 5394 |
-
"sha256": "
|
| 5395 |
}
|
| 5396 |
},
|
| 5397 |
"failures": []
|
|
@@ -5402,21 +5402,21 @@
|
|
| 5402 |
"local": {
|
| 5403 |
"path": "repo:scripts/build_figure_index.py",
|
| 5404 |
"exists": true,
|
| 5405 |
-
"bytes":
|
| 5406 |
-
"sha256": "
|
| 5407 |
},
|
| 5408 |
"mirrors": {
|
| 5409 |
"hf_artifacts": {
|
| 5410 |
"path": "hf_artifacts:scripts/build_figure_index.py",
|
| 5411 |
"exists": true,
|
| 5412 |
-
"bytes":
|
| 5413 |
-
"sha256": "
|
| 5414 |
},
|
| 5415 |
"hf_model": {
|
| 5416 |
"path": "hf_model:scripts/build_figure_index.py",
|
| 5417 |
"exists": true,
|
| 5418 |
-
"bytes":
|
| 5419 |
-
"sha256": "
|
| 5420 |
}
|
| 5421 |
},
|
| 5422 |
"failures": []
|
|
@@ -5752,21 +5752,21 @@
|
|
| 5752 |
"local": {
|
| 5753 |
"path": "repo:scripts/render_task_suite_infographic.py",
|
| 5754 |
"exists": true,
|
| 5755 |
-
"bytes":
|
| 5756 |
-
"sha256": "
|
| 5757 |
},
|
| 5758 |
"mirrors": {
|
| 5759 |
"hf_artifacts": {
|
| 5760 |
"path": "hf_artifacts:scripts/render_task_suite_infographic.py",
|
| 5761 |
"exists": true,
|
| 5762 |
-
"bytes":
|
| 5763 |
-
"sha256": "
|
| 5764 |
},
|
| 5765 |
"hf_model": {
|
| 5766 |
"path": "hf_model:scripts/render_task_suite_infographic.py",
|
| 5767 |
"exists": true,
|
| 5768 |
-
"bytes":
|
| 5769 |
-
"sha256": "
|
| 5770 |
}
|
| 5771 |
},
|
| 5772 |
"failures": []
|
|
@@ -5852,21 +5852,21 @@
|
|
| 5852 |
"local": {
|
| 5853 |
"path": "repo:scripts/build_unified_task_suite.py",
|
| 5854 |
"exists": true,
|
| 5855 |
-
"bytes":
|
| 5856 |
-
"sha256": "
|
| 5857 |
},
|
| 5858 |
"mirrors": {
|
| 5859 |
"hf_artifacts": {
|
| 5860 |
"path": "hf_artifacts:scripts/build_unified_task_suite.py",
|
| 5861 |
"exists": true,
|
| 5862 |
-
"bytes":
|
| 5863 |
-
"sha256": "
|
| 5864 |
},
|
| 5865 |
"hf_model": {
|
| 5866 |
"path": "hf_model:scripts/build_unified_task_suite.py",
|
| 5867 |
"exists": true,
|
| 5868 |
-
"bytes":
|
| 5869 |
-
"sha256": "
|
| 5870 |
}
|
| 5871 |
},
|
| 5872 |
"failures": []
|
|
@@ -5927,21 +5927,21 @@
|
|
| 5927 |
"local": {
|
| 5928 |
"path": "repo:scripts/verify_live_publication.py",
|
| 5929 |
"exists": true,
|
| 5930 |
-
"bytes":
|
| 5931 |
-
"sha256": "
|
| 5932 |
},
|
| 5933 |
"mirrors": {
|
| 5934 |
"hf_artifacts": {
|
| 5935 |
"path": "hf_artifacts:scripts/verify_live_publication.py",
|
| 5936 |
"exists": true,
|
| 5937 |
-
"bytes":
|
| 5938 |
-
"sha256": "
|
| 5939 |
},
|
| 5940 |
"hf_model": {
|
| 5941 |
"path": "hf_model:scripts/verify_live_publication.py",
|
| 5942 |
"exists": true,
|
| 5943 |
-
"bytes":
|
| 5944 |
-
"sha256": "
|
| 5945 |
}
|
| 5946 |
},
|
| 5947 |
"failures": []
|
|
@@ -5952,21 +5952,21 @@
|
|
| 5952 |
"local": {
|
| 5953 |
"path": "repo:scripts/validate_mirror_parity.py",
|
| 5954 |
"exists": true,
|
| 5955 |
-
"bytes":
|
| 5956 |
-
"sha256": "
|
| 5957 |
},
|
| 5958 |
"mirrors": {
|
| 5959 |
"hf_artifacts": {
|
| 5960 |
"path": "hf_artifacts:scripts/validate_mirror_parity.py",
|
| 5961 |
"exists": true,
|
| 5962 |
-
"bytes":
|
| 5963 |
-
"sha256": "
|
| 5964 |
},
|
| 5965 |
"hf_model": {
|
| 5966 |
"path": "hf_model:scripts/validate_mirror_parity.py",
|
| 5967 |
"exists": true,
|
| 5968 |
-
"bytes":
|
| 5969 |
-
"sha256": "
|
| 5970 |
}
|
| 5971 |
},
|
| 5972 |
"failures": []
|
|
@@ -6127,21 +6127,21 @@
|
|
| 6127 |
"local": {
|
| 6128 |
"path": "repo:scripts/sync_hf_publish_mirrors.py",
|
| 6129 |
"exists": true,
|
| 6130 |
-
"bytes":
|
| 6131 |
-
"sha256": "
|
| 6132 |
},
|
| 6133 |
"mirrors": {
|
| 6134 |
"hf_artifacts": {
|
| 6135 |
"path": "hf_artifacts:scripts/sync_hf_publish_mirrors.py",
|
| 6136 |
"exists": true,
|
| 6137 |
-
"bytes":
|
| 6138 |
-
"sha256": "
|
| 6139 |
},
|
| 6140 |
"hf_model": {
|
| 6141 |
"path": "hf_model:scripts/sync_hf_publish_mirrors.py",
|
| 6142 |
"exists": true,
|
| 6143 |
-
"bytes":
|
| 6144 |
-
"sha256": "
|
| 6145 |
}
|
| 6146 |
},
|
| 6147 |
"failures": []
|
|
@@ -6152,21 +6152,21 @@
|
|
| 6152 |
"local": {
|
| 6153 |
"path": "repo:scripts/tier2_task_suite.py",
|
| 6154 |
"exists": true,
|
| 6155 |
-
"bytes":
|
| 6156 |
-
"sha256": "
|
| 6157 |
},
|
| 6158 |
"mirrors": {
|
| 6159 |
"hf_artifacts": {
|
| 6160 |
"path": "hf_artifacts:scripts/tier2_task_suite.py",
|
| 6161 |
"exists": true,
|
| 6162 |
-
"bytes":
|
| 6163 |
-
"sha256": "
|
| 6164 |
},
|
| 6165 |
"hf_model": {
|
| 6166 |
"path": "hf_model:scripts/tier2_task_suite.py",
|
| 6167 |
"exists": true,
|
| 6168 |
-
"bytes":
|
| 6169 |
-
"sha256": "
|
| 6170 |
}
|
| 6171 |
},
|
| 6172 |
"failures": []
|
|
@@ -6331,39 +6331,39 @@
|
|
| 6331 |
"local": {
|
| 6332 |
"path": "repo:docs/index.html",
|
| 6333 |
"exists": true,
|
| 6334 |
-
"bytes":
|
| 6335 |
-
"sha256": "
|
| 6336 |
},
|
| 6337 |
"mirrors": {
|
| 6338 |
"hf_space": {
|
| 6339 |
"path": "hf_space:index.html",
|
| 6340 |
"exists": true,
|
| 6341 |
-
"bytes":
|
| 6342 |
-
"sha256": "
|
| 6343 |
},
|
| 6344 |
"hf_artifacts_root": {
|
| 6345 |
"path": "hf_artifacts:index.html",
|
| 6346 |
"exists": true,
|
| 6347 |
-
"bytes":
|
| 6348 |
-
"sha256": "
|
| 6349 |
},
|
| 6350 |
"hf_artifacts_docs": {
|
| 6351 |
"path": "hf_artifacts:docs/index.html",
|
| 6352 |
"exists": true,
|
| 6353 |
-
"bytes":
|
| 6354 |
-
"sha256": "
|
| 6355 |
},
|
| 6356 |
"hf_model": {
|
| 6357 |
"path": "hf_model:index.html",
|
| 6358 |
"exists": true,
|
| 6359 |
-
"bytes":
|
| 6360 |
-
"sha256": "
|
| 6361 |
},
|
| 6362 |
"hf_model_docs": {
|
| 6363 |
"path": "hf_model:docs/index.html",
|
| 6364 |
"exists": true,
|
| 6365 |
-
"bytes":
|
| 6366 |
-
"sha256": "
|
| 6367 |
}
|
| 6368 |
},
|
| 6369 |
"failures": []
|
|
@@ -6628,21 +6628,21 @@
|
|
| 6628 |
"local": {
|
| 6629 |
"path": "repo:results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md",
|
| 6630 |
"exists": true,
|
| 6631 |
-
"bytes":
|
| 6632 |
-
"sha256": "
|
| 6633 |
},
|
| 6634 |
"mirrors": {
|
| 6635 |
"hf_artifacts": {
|
| 6636 |
"path": "hf_artifacts:results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md",
|
| 6637 |
"exists": true,
|
| 6638 |
-
"bytes":
|
| 6639 |
-
"sha256": "
|
| 6640 |
},
|
| 6641 |
"hf_model": {
|
| 6642 |
"path": "hf_model:results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md",
|
| 6643 |
"exists": true,
|
| 6644 |
-
"bytes":
|
| 6645 |
-
"sha256": "
|
| 6646 |
}
|
| 6647 |
},
|
| 6648 |
"failures": []
|
|
@@ -7628,21 +7628,21 @@
|
|
| 7628 |
"local": {
|
| 7629 |
"path": "repo:results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 7630 |
"exists": true,
|
| 7631 |
-
"bytes":
|
| 7632 |
-
"sha256": "
|
| 7633 |
},
|
| 7634 |
"mirrors": {
|
| 7635 |
"hf_artifacts": {
|
| 7636 |
"path": "hf_artifacts:results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 7637 |
"exists": true,
|
| 7638 |
-
"bytes":
|
| 7639 |
-
"sha256": "
|
| 7640 |
},
|
| 7641 |
"hf_model": {
|
| 7642 |
"path": "hf_model:results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 7643 |
"exists": true,
|
| 7644 |
-
"bytes":
|
| 7645 |
-
"sha256": "
|
| 7646 |
}
|
| 7647 |
},
|
| 7648 |
"failures": []
|
|
@@ -24948,15 +24948,15 @@
|
|
| 24948 |
"local": {
|
| 24949 |
"path": "repo:results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md",
|
| 24950 |
"exists": true,
|
| 24951 |
-
"bytes":
|
| 24952 |
-
"sha256": "
|
| 24953 |
},
|
| 24954 |
"mirrors": {
|
| 24955 |
"hf_space": {
|
| 24956 |
"path": "hf_space:results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md",
|
| 24957 |
"exists": true,
|
| 24958 |
-
"bytes":
|
| 24959 |
-
"sha256": "
|
| 24960 |
}
|
| 24961 |
},
|
| 24962 |
"failures": []
|
|
@@ -25708,15 +25708,15 @@
|
|
| 25708 |
"local": {
|
| 25709 |
"path": "repo:results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 25710 |
"exists": true,
|
| 25711 |
-
"bytes":
|
| 25712 |
-
"sha256": "
|
| 25713 |
},
|
| 25714 |
"mirrors": {
|
| 25715 |
"hf_space": {
|
| 25716 |
"path": "hf_space:results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 25717 |
"exists": true,
|
| 25718 |
-
"bytes":
|
| 25719 |
-
"sha256": "
|
| 25720 |
}
|
| 25721 |
},
|
| 25722 |
"failures": []
|
|
@@ -30903,27 +30903,27 @@
|
|
| 30903 |
"local": {
|
| 30904 |
"path": "repo:ARTIFACT_GUIDE.md",
|
| 30905 |
"exists": true,
|
| 30906 |
-
"bytes":
|
| 30907 |
-
"sha256": "
|
| 30908 |
},
|
| 30909 |
"mirrors": {
|
| 30910 |
"hf_space": {
|
| 30911 |
"path": "hf_space:ARTIFACT_GUIDE.md",
|
| 30912 |
"exists": true,
|
| 30913 |
-
"bytes":
|
| 30914 |
-
"sha256": "
|
| 30915 |
},
|
| 30916 |
"hf_artifacts": {
|
| 30917 |
"path": "hf_artifacts:ARTIFACT_GUIDE.md",
|
| 30918 |
"exists": true,
|
| 30919 |
-
"bytes":
|
| 30920 |
-
"sha256": "
|
| 30921 |
},
|
| 30922 |
"hf_model": {
|
| 30923 |
"path": "hf_model:ARTIFACT_GUIDE.md",
|
| 30924 |
"exists": true,
|
| 30925 |
-
"bytes":
|
| 30926 |
-
"sha256": "
|
| 30927 |
}
|
| 30928 |
},
|
| 30929 |
"failures": []
|
|
@@ -30996,27 +30996,27 @@
|
|
| 30996 |
"local": {
|
| 30997 |
"path": "repo:EVALUATION_PROTOCOL.md",
|
| 30998 |
"exists": true,
|
| 30999 |
-
"bytes":
|
| 31000 |
-
"sha256": "
|
| 31001 |
},
|
| 31002 |
"mirrors": {
|
| 31003 |
"hf_space": {
|
| 31004 |
"path": "hf_space:EVALUATION_PROTOCOL.md",
|
| 31005 |
"exists": true,
|
| 31006 |
-
"bytes":
|
| 31007 |
-
"sha256": "
|
| 31008 |
},
|
| 31009 |
"hf_artifacts": {
|
| 31010 |
"path": "hf_artifacts:EVALUATION_PROTOCOL.md",
|
| 31011 |
"exists": true,
|
| 31012 |
-
"bytes":
|
| 31013 |
-
"sha256": "
|
| 31014 |
},
|
| 31015 |
"hf_model": {
|
| 31016 |
"path": "hf_model:EVALUATION_PROTOCOL.md",
|
| 31017 |
"exists": true,
|
| 31018 |
-
"bytes":
|
| 31019 |
-
"sha256": "
|
| 31020 |
}
|
| 31021 |
},
|
| 31022 |
"failures": []
|
|
@@ -31027,27 +31027,27 @@
|
|
| 31027 |
"local": {
|
| 31028 |
"path": "repo:FIGURE_INDEX.md",
|
| 31029 |
"exists": true,
|
| 31030 |
-
"bytes":
|
| 31031 |
-
"sha256": "
|
| 31032 |
},
|
| 31033 |
"mirrors": {
|
| 31034 |
"hf_space": {
|
| 31035 |
"path": "hf_space:FIGURE_INDEX.md",
|
| 31036 |
"exists": true,
|
| 31037 |
-
"bytes":
|
| 31038 |
-
"sha256": "
|
| 31039 |
},
|
| 31040 |
"hf_artifacts": {
|
| 31041 |
"path": "hf_artifacts:FIGURE_INDEX.md",
|
| 31042 |
"exists": true,
|
| 31043 |
-
"bytes":
|
| 31044 |
-
"sha256": "
|
| 31045 |
},
|
| 31046 |
"hf_model": {
|
| 31047 |
"path": "hf_model:FIGURE_INDEX.md",
|
| 31048 |
"exists": true,
|
| 31049 |
-
"bytes":
|
| 31050 |
-
"sha256": "
|
| 31051 |
}
|
| 31052 |
},
|
| 31053 |
"failures": []
|
|
@@ -31089,27 +31089,27 @@
|
|
| 31089 |
"local": {
|
| 31090 |
"path": "repo:GLOSSARY.md",
|
| 31091 |
"exists": true,
|
| 31092 |
-
"bytes":
|
| 31093 |
-
"sha256": "
|
| 31094 |
},
|
| 31095 |
"mirrors": {
|
| 31096 |
"hf_space": {
|
| 31097 |
"path": "hf_space:GLOSSARY.md",
|
| 31098 |
"exists": true,
|
| 31099 |
-
"bytes":
|
| 31100 |
-
"sha256": "
|
| 31101 |
},
|
| 31102 |
"hf_artifacts": {
|
| 31103 |
"path": "hf_artifacts:GLOSSARY.md",
|
| 31104 |
"exists": true,
|
| 31105 |
-
"bytes":
|
| 31106 |
-
"sha256": "
|
| 31107 |
},
|
| 31108 |
"hf_model": {
|
| 31109 |
"path": "hf_model:GLOSSARY.md",
|
| 31110 |
"exists": true,
|
| 31111 |
-
"bytes":
|
| 31112 |
-
"sha256": "
|
| 31113 |
}
|
| 31114 |
},
|
| 31115 |
"failures": []
|
|
@@ -31275,27 +31275,27 @@
|
|
| 31275 |
"local": {
|
| 31276 |
"path": "repo:PROJECT_BRIEF.md",
|
| 31277 |
"exists": true,
|
| 31278 |
-
"bytes":
|
| 31279 |
-
"sha256": "
|
| 31280 |
},
|
| 31281 |
"mirrors": {
|
| 31282 |
"hf_space": {
|
| 31283 |
"path": "hf_space:PROJECT_BRIEF.md",
|
| 31284 |
"exists": true,
|
| 31285 |
-
"bytes":
|
| 31286 |
-
"sha256": "
|
| 31287 |
},
|
| 31288 |
"hf_artifacts": {
|
| 31289 |
"path": "hf_artifacts:PROJECT_BRIEF.md",
|
| 31290 |
"exists": true,
|
| 31291 |
-
"bytes":
|
| 31292 |
-
"sha256": "
|
| 31293 |
},
|
| 31294 |
"hf_model": {
|
| 31295 |
"path": "hf_model:PROJECT_BRIEF.md",
|
| 31296 |
"exists": true,
|
| 31297 |
-
"bytes":
|
| 31298 |
-
"sha256": "
|
| 31299 |
}
|
| 31300 |
},
|
| 31301 |
"failures": []
|
|
@@ -31399,27 +31399,27 @@
|
|
| 31399 |
"local": {
|
| 31400 |
"path": "repo:PROJECT_STATUS.md",
|
| 31401 |
"exists": true,
|
| 31402 |
-
"bytes":
|
| 31403 |
-
"sha256": "
|
| 31404 |
},
|
| 31405 |
"mirrors": {
|
| 31406 |
"hf_space": {
|
| 31407 |
"path": "hf_space:PROJECT_STATUS.md",
|
| 31408 |
"exists": true,
|
| 31409 |
-
"bytes":
|
| 31410 |
-
"sha256": "
|
| 31411 |
},
|
| 31412 |
"hf_artifacts": {
|
| 31413 |
"path": "hf_artifacts:PROJECT_STATUS.md",
|
| 31414 |
"exists": true,
|
| 31415 |
-
"bytes":
|
| 31416 |
-
"sha256": "
|
| 31417 |
},
|
| 31418 |
"hf_model": {
|
| 31419 |
"path": "hf_model:PROJECT_STATUS.md",
|
| 31420 |
"exists": true,
|
| 31421 |
-
"bytes":
|
| 31422 |
-
"sha256": "
|
| 31423 |
}
|
| 31424 |
},
|
| 31425 |
"failures": []
|
|
@@ -31430,27 +31430,27 @@
|
|
| 31430 |
"local": {
|
| 31431 |
"path": "repo:REPRODUCIBILITY.md",
|
| 31432 |
"exists": true,
|
| 31433 |
-
"bytes":
|
| 31434 |
-
"sha256": "
|
| 31435 |
},
|
| 31436 |
"mirrors": {
|
| 31437 |
"hf_space": {
|
| 31438 |
"path": "hf_space:REPRODUCIBILITY.md",
|
| 31439 |
"exists": true,
|
| 31440 |
-
"bytes":
|
| 31441 |
-
"sha256": "
|
| 31442 |
},
|
| 31443 |
"hf_artifacts": {
|
| 31444 |
"path": "hf_artifacts:REPRODUCIBILITY.md",
|
| 31445 |
"exists": true,
|
| 31446 |
-
"bytes":
|
| 31447 |
-
"sha256": "
|
| 31448 |
},
|
| 31449 |
"hf_model": {
|
| 31450 |
"path": "hf_model:REPRODUCIBILITY.md",
|
| 31451 |
"exists": true,
|
| 31452 |
-
"bytes":
|
| 31453 |
-
"sha256": "
|
| 31454 |
}
|
| 31455 |
},
|
| 31456 |
"failures": []
|
|
@@ -31585,27 +31585,27 @@
|
|
| 31585 |
"local": {
|
| 31586 |
"path": "repo:TASK_SUITE_20.md",
|
| 31587 |
"exists": true,
|
| 31588 |
-
"bytes":
|
| 31589 |
-
"sha256": "
|
| 31590 |
},
|
| 31591 |
"mirrors": {
|
| 31592 |
"hf_space": {
|
| 31593 |
"path": "hf_space:TASK_SUITE_20.md",
|
| 31594 |
"exists": true,
|
| 31595 |
-
"bytes":
|
| 31596 |
-
"sha256": "
|
| 31597 |
},
|
| 31598 |
"hf_artifacts": {
|
| 31599 |
"path": "hf_artifacts:TASK_SUITE_20.md",
|
| 31600 |
"exists": true,
|
| 31601 |
-
"bytes":
|
| 31602 |
-
"sha256": "
|
| 31603 |
},
|
| 31604 |
"hf_model": {
|
| 31605 |
"path": "hf_model:TASK_SUITE_20.md",
|
| 31606 |
"exists": true,
|
| 31607 |
-
"bytes":
|
| 31608 |
-
"sha256": "
|
| 31609 |
}
|
| 31610 |
},
|
| 31611 |
"failures": []
|
|
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
+
"generated_at_utc": "2026-06-21T14:53:27+00:00",
|
| 4 |
"hf_root": "hf_publish",
|
| 5 |
"summary": {
|
| 6 |
"group_count": 1258,
|
|
|
|
| 138 |
"local": {
|
| 139 |
"path": "repo:docs/data/artifact_index.json",
|
| 140 |
"exists": true,
|
| 141 |
+
"bytes": 124294,
|
| 142 |
+
"sha256": "d7e6d9d5a98138ef85bbe9909bf4119fbb4926a38f70a485427e9f859a02352b"
|
| 143 |
},
|
| 144 |
"mirrors": {
|
| 145 |
"hf_space": {
|
| 146 |
"path": "hf_space:data/artifact_index.json",
|
| 147 |
"exists": true,
|
| 148 |
+
"bytes": 124294,
|
| 149 |
+
"sha256": "d7e6d9d5a98138ef85bbe9909bf4119fbb4926a38f70a485427e9f859a02352b"
|
| 150 |
},
|
| 151 |
"hf_artifacts_data": {
|
| 152 |
"path": "hf_artifacts:data/artifact_index.json",
|
| 153 |
"exists": true,
|
| 154 |
+
"bytes": 124294,
|
| 155 |
+
"sha256": "d7e6d9d5a98138ef85bbe9909bf4119fbb4926a38f70a485427e9f859a02352b"
|
| 156 |
},
|
| 157 |
"hf_artifacts": {
|
| 158 |
"path": "hf_artifacts:docs/data/artifact_index.json",
|
| 159 |
"exists": true,
|
| 160 |
+
"bytes": 124294,
|
| 161 |
+
"sha256": "d7e6d9d5a98138ef85bbe9909bf4119fbb4926a38f70a485427e9f859a02352b"
|
| 162 |
},
|
| 163 |
"hf_model_data": {
|
| 164 |
"path": "hf_model:data/artifact_index.json",
|
| 165 |
"exists": true,
|
| 166 |
+
"bytes": 124294,
|
| 167 |
+
"sha256": "d7e6d9d5a98138ef85bbe9909bf4119fbb4926a38f70a485427e9f859a02352b"
|
| 168 |
},
|
| 169 |
"hf_model_docs_data": {
|
| 170 |
"path": "hf_model:docs/data/artifact_index.json",
|
| 171 |
"exists": true,
|
| 172 |
+
"bytes": 124294,
|
| 173 |
+
"sha256": "d7e6d9d5a98138ef85bbe9909bf4119fbb4926a38f70a485427e9f859a02352b"
|
| 174 |
},
|
| 175 |
"hf_model": {
|
| 176 |
"path": "hf_model:metrics/artifact_index.json",
|
| 177 |
"exists": true,
|
| 178 |
+
"bytes": 124294,
|
| 179 |
+
"sha256": "d7e6d9d5a98138ef85bbe9909bf4119fbb4926a38f70a485427e9f859a02352b"
|
| 180 |
}
|
| 181 |
},
|
| 182 |
"failures": []
|
|
|
|
| 285 |
"local": {
|
| 286 |
"path": "repo:docs/data/evaluation_protocol.json",
|
| 287 |
"exists": true,
|
| 288 |
+
"bytes": 24007,
|
| 289 |
+
"sha256": "dde490d175f0d6828f5973f1b24e696a3d1b3b09d65a59cb9c1dde5c38845b66"
|
| 290 |
},
|
| 291 |
"mirrors": {
|
| 292 |
"hf_space": {
|
| 293 |
"path": "hf_space:data/evaluation_protocol.json",
|
| 294 |
"exists": true,
|
| 295 |
+
"bytes": 24007,
|
| 296 |
+
"sha256": "dde490d175f0d6828f5973f1b24e696a3d1b3b09d65a59cb9c1dde5c38845b66"
|
| 297 |
},
|
| 298 |
"hf_artifacts_data": {
|
| 299 |
"path": "hf_artifacts:data/evaluation_protocol.json",
|
| 300 |
"exists": true,
|
| 301 |
+
"bytes": 24007,
|
| 302 |
+
"sha256": "dde490d175f0d6828f5973f1b24e696a3d1b3b09d65a59cb9c1dde5c38845b66"
|
| 303 |
},
|
| 304 |
"hf_artifacts": {
|
| 305 |
"path": "hf_artifacts:docs/data/evaluation_protocol.json",
|
| 306 |
"exists": true,
|
| 307 |
+
"bytes": 24007,
|
| 308 |
+
"sha256": "dde490d175f0d6828f5973f1b24e696a3d1b3b09d65a59cb9c1dde5c38845b66"
|
| 309 |
},
|
| 310 |
"hf_model_data": {
|
| 311 |
"path": "hf_model:data/evaluation_protocol.json",
|
| 312 |
"exists": true,
|
| 313 |
+
"bytes": 24007,
|
| 314 |
+
"sha256": "dde490d175f0d6828f5973f1b24e696a3d1b3b09d65a59cb9c1dde5c38845b66"
|
| 315 |
},
|
| 316 |
"hf_model_docs_data": {
|
| 317 |
"path": "hf_model:docs/data/evaluation_protocol.json",
|
| 318 |
"exists": true,
|
| 319 |
+
"bytes": 24007,
|
| 320 |
+
"sha256": "dde490d175f0d6828f5973f1b24e696a3d1b3b09d65a59cb9c1dde5c38845b66"
|
| 321 |
},
|
| 322 |
"hf_model": {
|
| 323 |
"path": "hf_model:metrics/evaluation_protocol.json",
|
| 324 |
"exists": true,
|
| 325 |
+
"bytes": 24007,
|
| 326 |
+
"sha256": "dde490d175f0d6828f5973f1b24e696a3d1b3b09d65a59cb9c1dde5c38845b66"
|
| 327 |
}
|
| 328 |
},
|
| 329 |
"failures": []
|
|
|
|
| 334 |
"local": {
|
| 335 |
"path": "repo:docs/data/figure_index.json",
|
| 336 |
"exists": true,
|
| 337 |
+
"bytes": 19469,
|
| 338 |
+
"sha256": "11a06ee64d28f81f3280eb99327d99b47dc58fb1521332434b9df11c97b9b4e8"
|
| 339 |
},
|
| 340 |
"mirrors": {
|
| 341 |
"hf_space": {
|
| 342 |
"path": "hf_space:data/figure_index.json",
|
| 343 |
"exists": true,
|
| 344 |
+
"bytes": 19469,
|
| 345 |
+
"sha256": "11a06ee64d28f81f3280eb99327d99b47dc58fb1521332434b9df11c97b9b4e8"
|
| 346 |
},
|
| 347 |
"hf_artifacts_data": {
|
| 348 |
"path": "hf_artifacts:data/figure_index.json",
|
| 349 |
"exists": true,
|
| 350 |
+
"bytes": 19469,
|
| 351 |
+
"sha256": "11a06ee64d28f81f3280eb99327d99b47dc58fb1521332434b9df11c97b9b4e8"
|
| 352 |
},
|
| 353 |
"hf_artifacts": {
|
| 354 |
"path": "hf_artifacts:docs/data/figure_index.json",
|
| 355 |
"exists": true,
|
| 356 |
+
"bytes": 19469,
|
| 357 |
+
"sha256": "11a06ee64d28f81f3280eb99327d99b47dc58fb1521332434b9df11c97b9b4e8"
|
| 358 |
},
|
| 359 |
"hf_model_data": {
|
| 360 |
"path": "hf_model:data/figure_index.json",
|
| 361 |
"exists": true,
|
| 362 |
+
"bytes": 19469,
|
| 363 |
+
"sha256": "11a06ee64d28f81f3280eb99327d99b47dc58fb1521332434b9df11c97b9b4e8"
|
| 364 |
},
|
| 365 |
"hf_model_docs_data": {
|
| 366 |
"path": "hf_model:docs/data/figure_index.json",
|
| 367 |
"exists": true,
|
| 368 |
+
"bytes": 19469,
|
| 369 |
+
"sha256": "11a06ee64d28f81f3280eb99327d99b47dc58fb1521332434b9df11c97b9b4e8"
|
| 370 |
},
|
| 371 |
"hf_model": {
|
| 372 |
"path": "hf_model:metrics/figure_index.json",
|
| 373 |
"exists": true,
|
| 374 |
+
"bytes": 19469,
|
| 375 |
+
"sha256": "11a06ee64d28f81f3280eb99327d99b47dc58fb1521332434b9df11c97b9b4e8"
|
| 376 |
}
|
| 377 |
},
|
| 378 |
"failures": []
|
|
|
|
| 432 |
"local": {
|
| 433 |
"path": "repo:docs/data/glossary.json",
|
| 434 |
"exists": true,
|
| 435 |
+
"bytes": 17380,
|
| 436 |
+
"sha256": "3ba746413eb4a7d2646333e3746e0b3f4039db61d03c159d2d059fecfe4b51ed"
|
| 437 |
},
|
| 438 |
"mirrors": {
|
| 439 |
"hf_space": {
|
| 440 |
"path": "hf_space:data/glossary.json",
|
| 441 |
"exists": true,
|
| 442 |
+
"bytes": 17380,
|
| 443 |
+
"sha256": "3ba746413eb4a7d2646333e3746e0b3f4039db61d03c159d2d059fecfe4b51ed"
|
| 444 |
},
|
| 445 |
"hf_artifacts_data": {
|
| 446 |
"path": "hf_artifacts:data/glossary.json",
|
| 447 |
"exists": true,
|
| 448 |
+
"bytes": 17380,
|
| 449 |
+
"sha256": "3ba746413eb4a7d2646333e3746e0b3f4039db61d03c159d2d059fecfe4b51ed"
|
| 450 |
},
|
| 451 |
"hf_artifacts": {
|
| 452 |
"path": "hf_artifacts:docs/data/glossary.json",
|
| 453 |
"exists": true,
|
| 454 |
+
"bytes": 17380,
|
| 455 |
+
"sha256": "3ba746413eb4a7d2646333e3746e0b3f4039db61d03c159d2d059fecfe4b51ed"
|
| 456 |
},
|
| 457 |
"hf_model_data": {
|
| 458 |
"path": "hf_model:data/glossary.json",
|
| 459 |
"exists": true,
|
| 460 |
+
"bytes": 17380,
|
| 461 |
+
"sha256": "3ba746413eb4a7d2646333e3746e0b3f4039db61d03c159d2d059fecfe4b51ed"
|
| 462 |
},
|
| 463 |
"hf_model_docs_data": {
|
| 464 |
"path": "hf_model:docs/data/glossary.json",
|
| 465 |
"exists": true,
|
| 466 |
+
"bytes": 17380,
|
| 467 |
+
"sha256": "3ba746413eb4a7d2646333e3746e0b3f4039db61d03c159d2d059fecfe4b51ed"
|
| 468 |
},
|
| 469 |
"hf_model": {
|
| 470 |
"path": "hf_model:metrics/glossary.json",
|
| 471 |
"exists": true,
|
| 472 |
+
"bytes": 17380,
|
| 473 |
+
"sha256": "3ba746413eb4a7d2646333e3746e0b3f4039db61d03c159d2d059fecfe4b51ed"
|
| 474 |
}
|
| 475 |
},
|
| 476 |
"failures": []
|
|
|
|
| 481 |
"local": {
|
| 482 |
"path": "repo:docs/data/live_publication_status.json",
|
| 483 |
"exists": true,
|
| 484 |
+
"bytes": 189922,
|
| 485 |
+
"sha256": "9679ff9990c1e5d238bb9604704fdcac5ee98555dd1994ece26060f50e125b71"
|
| 486 |
},
|
| 487 |
"mirrors": {
|
| 488 |
"hf_space": {
|
| 489 |
"path": "hf_space:data/live_publication_status.json",
|
| 490 |
"exists": true,
|
| 491 |
+
"bytes": 189922,
|
| 492 |
+
"sha256": "9679ff9990c1e5d238bb9604704fdcac5ee98555dd1994ece26060f50e125b71"
|
| 493 |
},
|
| 494 |
"hf_artifacts_data": {
|
| 495 |
"path": "hf_artifacts:data/live_publication_status.json",
|
| 496 |
"exists": true,
|
| 497 |
+
"bytes": 189922,
|
| 498 |
+
"sha256": "9679ff9990c1e5d238bb9604704fdcac5ee98555dd1994ece26060f50e125b71"
|
| 499 |
},
|
| 500 |
"hf_artifacts": {
|
| 501 |
"path": "hf_artifacts:docs/data/live_publication_status.json",
|
| 502 |
"exists": true,
|
| 503 |
+
"bytes": 189922,
|
| 504 |
+
"sha256": "9679ff9990c1e5d238bb9604704fdcac5ee98555dd1994ece26060f50e125b71"
|
| 505 |
},
|
| 506 |
"hf_model_data": {
|
| 507 |
"path": "hf_model:data/live_publication_status.json",
|
| 508 |
"exists": true,
|
| 509 |
+
"bytes": 189922,
|
| 510 |
+
"sha256": "9679ff9990c1e5d238bb9604704fdcac5ee98555dd1994ece26060f50e125b71"
|
| 511 |
},
|
| 512 |
"hf_model_docs_data": {
|
| 513 |
"path": "hf_model:docs/data/live_publication_status.json",
|
| 514 |
"exists": true,
|
| 515 |
+
"bytes": 189922,
|
| 516 |
+
"sha256": "9679ff9990c1e5d238bb9604704fdcac5ee98555dd1994ece26060f50e125b71"
|
| 517 |
},
|
| 518 |
"hf_model": {
|
| 519 |
"path": "hf_model:metrics/live_publication_status.json",
|
| 520 |
"exists": true,
|
| 521 |
+
"bytes": 189922,
|
| 522 |
+
"sha256": "9679ff9990c1e5d238bb9604704fdcac5ee98555dd1994ece26060f50e125b71"
|
| 523 |
}
|
| 524 |
},
|
| 525 |
"failures": []
|
|
|
|
| 972 |
"path": "repo:docs/data/publication_audit.json",
|
| 973 |
"exists": true,
|
| 974 |
"bytes": 10939,
|
| 975 |
+
"sha256": "b95c56731002fe13a416c75b504f4e1c018ba73781a043cbc7f8aaa6aff0afca"
|
| 976 |
},
|
| 977 |
"mirrors": {
|
| 978 |
"hf_space": {
|
| 979 |
"path": "hf_space:data/publication_audit.json",
|
| 980 |
"exists": true,
|
| 981 |
"bytes": 10939,
|
| 982 |
+
"sha256": "b95c56731002fe13a416c75b504f4e1c018ba73781a043cbc7f8aaa6aff0afca"
|
| 983 |
},
|
| 984 |
"hf_artifacts_data": {
|
| 985 |
"path": "hf_artifacts:data/publication_audit.json",
|
| 986 |
"exists": true,
|
| 987 |
"bytes": 10939,
|
| 988 |
+
"sha256": "b95c56731002fe13a416c75b504f4e1c018ba73781a043cbc7f8aaa6aff0afca"
|
| 989 |
},
|
| 990 |
"hf_artifacts": {
|
| 991 |
"path": "hf_artifacts:docs/data/publication_audit.json",
|
| 992 |
"exists": true,
|
| 993 |
"bytes": 10939,
|
| 994 |
+
"sha256": "b95c56731002fe13a416c75b504f4e1c018ba73781a043cbc7f8aaa6aff0afca"
|
| 995 |
},
|
| 996 |
"hf_model_data": {
|
| 997 |
"path": "hf_model:data/publication_audit.json",
|
| 998 |
"exists": true,
|
| 999 |
"bytes": 10939,
|
| 1000 |
+
"sha256": "b95c56731002fe13a416c75b504f4e1c018ba73781a043cbc7f8aaa6aff0afca"
|
| 1001 |
},
|
| 1002 |
"hf_model_docs_data": {
|
| 1003 |
"path": "hf_model:docs/data/publication_audit.json",
|
| 1004 |
"exists": true,
|
| 1005 |
"bytes": 10939,
|
| 1006 |
+
"sha256": "b95c56731002fe13a416c75b504f4e1c018ba73781a043cbc7f8aaa6aff0afca"
|
| 1007 |
},
|
| 1008 |
"hf_model": {
|
| 1009 |
"path": "hf_model:metrics/publication_audit.json",
|
| 1010 |
"exists": true,
|
| 1011 |
"bytes": 10939,
|
| 1012 |
+
"sha256": "b95c56731002fe13a416c75b504f4e1c018ba73781a043cbc7f8aaa6aff0afca"
|
| 1013 |
}
|
| 1014 |
},
|
| 1015 |
"failures": []
|
|
|
|
| 1020 |
"local": {
|
| 1021 |
"path": "repo:docs/data/public_surface_qa.json",
|
| 1022 |
"exists": true,
|
| 1023 |
+
"bytes": 7691,
|
| 1024 |
+
"sha256": "d0af3d5209df87ab0c3d418c5b6cdf34b581359b86a468486006b1157c790aea"
|
| 1025 |
},
|
| 1026 |
"mirrors": {
|
| 1027 |
"hf_space": {
|
| 1028 |
"path": "hf_space:data/public_surface_qa.json",
|
| 1029 |
"exists": true,
|
| 1030 |
+
"bytes": 7691,
|
| 1031 |
+
"sha256": "d0af3d5209df87ab0c3d418c5b6cdf34b581359b86a468486006b1157c790aea"
|
| 1032 |
},
|
| 1033 |
"hf_artifacts_data": {
|
| 1034 |
"path": "hf_artifacts:data/public_surface_qa.json",
|
| 1035 |
"exists": true,
|
| 1036 |
+
"bytes": 7691,
|
| 1037 |
+
"sha256": "d0af3d5209df87ab0c3d418c5b6cdf34b581359b86a468486006b1157c790aea"
|
| 1038 |
},
|
| 1039 |
"hf_artifacts": {
|
| 1040 |
"path": "hf_artifacts:docs/data/public_surface_qa.json",
|
| 1041 |
"exists": true,
|
| 1042 |
+
"bytes": 7691,
|
| 1043 |
+
"sha256": "d0af3d5209df87ab0c3d418c5b6cdf34b581359b86a468486006b1157c790aea"
|
| 1044 |
},
|
| 1045 |
"hf_model_data": {
|
| 1046 |
"path": "hf_model:data/public_surface_qa.json",
|
| 1047 |
"exists": true,
|
| 1048 |
+
"bytes": 7691,
|
| 1049 |
+
"sha256": "d0af3d5209df87ab0c3d418c5b6cdf34b581359b86a468486006b1157c790aea"
|
| 1050 |
},
|
| 1051 |
"hf_model_docs_data": {
|
| 1052 |
"path": "hf_model:docs/data/public_surface_qa.json",
|
| 1053 |
"exists": true,
|
| 1054 |
+
"bytes": 7691,
|
| 1055 |
+
"sha256": "d0af3d5209df87ab0c3d418c5b6cdf34b581359b86a468486006b1157c790aea"
|
| 1056 |
},
|
| 1057 |
"hf_model": {
|
| 1058 |
"path": "hf_model:metrics/public_surface_qa.json",
|
| 1059 |
"exists": true,
|
| 1060 |
+
"bytes": 7691,
|
| 1061 |
+
"sha256": "d0af3d5209df87ab0c3d418c5b6cdf34b581359b86a468486006b1157c790aea"
|
| 1062 |
}
|
| 1063 |
},
|
| 1064 |
"failures": []
|
|
|
|
| 1217 |
"path": "repo:docs/data/quality_gates.json",
|
| 1218 |
"exists": true,
|
| 1219 |
"bytes": 8640,
|
| 1220 |
+
"sha256": "6e54f6828b8fef97e963a9a56bccc91162b8a632f6897743095e32407fa0db98"
|
| 1221 |
},
|
| 1222 |
"mirrors": {
|
| 1223 |
"hf_space": {
|
| 1224 |
"path": "hf_space:data/quality_gates.json",
|
| 1225 |
"exists": true,
|
| 1226 |
"bytes": 8640,
|
| 1227 |
+
"sha256": "6e54f6828b8fef97e963a9a56bccc91162b8a632f6897743095e32407fa0db98"
|
| 1228 |
},
|
| 1229 |
"hf_artifacts_data": {
|
| 1230 |
"path": "hf_artifacts:data/quality_gates.json",
|
| 1231 |
"exists": true,
|
| 1232 |
"bytes": 8640,
|
| 1233 |
+
"sha256": "6e54f6828b8fef97e963a9a56bccc91162b8a632f6897743095e32407fa0db98"
|
| 1234 |
},
|
| 1235 |
"hf_artifacts": {
|
| 1236 |
"path": "hf_artifacts:docs/data/quality_gates.json",
|
| 1237 |
"exists": true,
|
| 1238 |
"bytes": 8640,
|
| 1239 |
+
"sha256": "6e54f6828b8fef97e963a9a56bccc91162b8a632f6897743095e32407fa0db98"
|
| 1240 |
},
|
| 1241 |
"hf_model_data": {
|
| 1242 |
"path": "hf_model:data/quality_gates.json",
|
| 1243 |
"exists": true,
|
| 1244 |
"bytes": 8640,
|
| 1245 |
+
"sha256": "6e54f6828b8fef97e963a9a56bccc91162b8a632f6897743095e32407fa0db98"
|
| 1246 |
},
|
| 1247 |
"hf_model_docs_data": {
|
| 1248 |
"path": "hf_model:docs/data/quality_gates.json",
|
| 1249 |
"exists": true,
|
| 1250 |
"bytes": 8640,
|
| 1251 |
+
"sha256": "6e54f6828b8fef97e963a9a56bccc91162b8a632f6897743095e32407fa0db98"
|
| 1252 |
},
|
| 1253 |
"hf_model": {
|
| 1254 |
"path": "hf_model:metrics/quality_gates.json",
|
| 1255 |
"exists": true,
|
| 1256 |
"bytes": 8640,
|
| 1257 |
+
"sha256": "6e54f6828b8fef97e963a9a56bccc91162b8a632f6897743095e32407fa0db98"
|
| 1258 |
}
|
| 1259 |
},
|
| 1260 |
"failures": []
|
|
|
|
| 1658 |
"path": "repo:docs/data/scope_claims_audit.json",
|
| 1659 |
"exists": true,
|
| 1660 |
"bytes": 21313,
|
| 1661 |
+
"sha256": "83b779e3be18ef3d7b5eaf900dc36a11a5311a07fd48b73434f669272e7f6b1f"
|
| 1662 |
},
|
| 1663 |
"mirrors": {
|
| 1664 |
"hf_space": {
|
| 1665 |
"path": "hf_space:data/scope_claims_audit.json",
|
| 1666 |
"exists": true,
|
| 1667 |
"bytes": 21313,
|
| 1668 |
+
"sha256": "83b779e3be18ef3d7b5eaf900dc36a11a5311a07fd48b73434f669272e7f6b1f"
|
| 1669 |
},
|
| 1670 |
"hf_artifacts_data": {
|
| 1671 |
"path": "hf_artifacts:data/scope_claims_audit.json",
|
| 1672 |
"exists": true,
|
| 1673 |
"bytes": 21313,
|
| 1674 |
+
"sha256": "83b779e3be18ef3d7b5eaf900dc36a11a5311a07fd48b73434f669272e7f6b1f"
|
| 1675 |
},
|
| 1676 |
"hf_artifacts": {
|
| 1677 |
"path": "hf_artifacts:docs/data/scope_claims_audit.json",
|
| 1678 |
"exists": true,
|
| 1679 |
"bytes": 21313,
|
| 1680 |
+
"sha256": "83b779e3be18ef3d7b5eaf900dc36a11a5311a07fd48b73434f669272e7f6b1f"
|
| 1681 |
},
|
| 1682 |
"hf_model_data": {
|
| 1683 |
"path": "hf_model:data/scope_claims_audit.json",
|
| 1684 |
"exists": true,
|
| 1685 |
"bytes": 21313,
|
| 1686 |
+
"sha256": "83b779e3be18ef3d7b5eaf900dc36a11a5311a07fd48b73434f669272e7f6b1f"
|
| 1687 |
},
|
| 1688 |
"hf_model_docs_data": {
|
| 1689 |
"path": "hf_model:docs/data/scope_claims_audit.json",
|
| 1690 |
"exists": true,
|
| 1691 |
"bytes": 21313,
|
| 1692 |
+
"sha256": "83b779e3be18ef3d7b5eaf900dc36a11a5311a07fd48b73434f669272e7f6b1f"
|
| 1693 |
},
|
| 1694 |
"hf_model": {
|
| 1695 |
"path": "hf_model:metrics/scope_claims_audit.json",
|
| 1696 |
"exists": true,
|
| 1697 |
"bytes": 21313,
|
| 1698 |
+
"sha256": "83b779e3be18ef3d7b5eaf900dc36a11a5311a07fd48b73434f669272e7f6b1f"
|
| 1699 |
}
|
| 1700 |
},
|
| 1701 |
"failures": []
|
|
|
|
| 1756 |
"path": "repo:docs/data/source_alignment_audit.json",
|
| 1757 |
"exists": true,
|
| 1758 |
"bytes": 4432,
|
| 1759 |
+
"sha256": "5ab2ea4bfefe9f5bc7854f02b2e1e2b5206766a54447647191828da1a1a2077c"
|
| 1760 |
},
|
| 1761 |
"mirrors": {
|
| 1762 |
"hf_space": {
|
| 1763 |
"path": "hf_space:data/source_alignment_audit.json",
|
| 1764 |
"exists": true,
|
| 1765 |
"bytes": 4432,
|
| 1766 |
+
"sha256": "5ab2ea4bfefe9f5bc7854f02b2e1e2b5206766a54447647191828da1a1a2077c"
|
| 1767 |
},
|
| 1768 |
"hf_artifacts_data": {
|
| 1769 |
"path": "hf_artifacts:data/source_alignment_audit.json",
|
| 1770 |
"exists": true,
|
| 1771 |
"bytes": 4432,
|
| 1772 |
+
"sha256": "5ab2ea4bfefe9f5bc7854f02b2e1e2b5206766a54447647191828da1a1a2077c"
|
| 1773 |
},
|
| 1774 |
"hf_artifacts": {
|
| 1775 |
"path": "hf_artifacts:docs/data/source_alignment_audit.json",
|
| 1776 |
"exists": true,
|
| 1777 |
"bytes": 4432,
|
| 1778 |
+
"sha256": "5ab2ea4bfefe9f5bc7854f02b2e1e2b5206766a54447647191828da1a1a2077c"
|
| 1779 |
},
|
| 1780 |
"hf_model_data": {
|
| 1781 |
"path": "hf_model:data/source_alignment_audit.json",
|
| 1782 |
"exists": true,
|
| 1783 |
"bytes": 4432,
|
| 1784 |
+
"sha256": "5ab2ea4bfefe9f5bc7854f02b2e1e2b5206766a54447647191828da1a1a2077c"
|
| 1785 |
},
|
| 1786 |
"hf_model_docs_data": {
|
| 1787 |
"path": "hf_model:docs/data/source_alignment_audit.json",
|
| 1788 |
"exists": true,
|
| 1789 |
"bytes": 4432,
|
| 1790 |
+
"sha256": "5ab2ea4bfefe9f5bc7854f02b2e1e2b5206766a54447647191828da1a1a2077c"
|
| 1791 |
},
|
| 1792 |
"hf_model": {
|
| 1793 |
"path": "hf_model:metrics/source_alignment_audit.json",
|
| 1794 |
"exists": true,
|
| 1795 |
"bytes": 4432,
|
| 1796 |
+
"sha256": "5ab2ea4bfefe9f5bc7854f02b2e1e2b5206766a54447647191828da1a1a2077c"
|
| 1797 |
}
|
| 1798 |
},
|
| 1799 |
"failures": []
|
|
|
|
| 2098 |
"local": {
|
| 2099 |
"path": "repo:docs/data/task_suite_20.json",
|
| 2100 |
"exists": true,
|
| 2101 |
+
"bytes": 34597,
|
| 2102 |
+
"sha256": "2029f7f9744001861ac00acabdb578fe97d3b39a1c16a7c2d19c56347ded22d7"
|
| 2103 |
},
|
| 2104 |
"mirrors": {
|
| 2105 |
"hf_space": {
|
| 2106 |
"path": "hf_space:data/task_suite_20.json",
|
| 2107 |
"exists": true,
|
| 2108 |
+
"bytes": 34597,
|
| 2109 |
+
"sha256": "2029f7f9744001861ac00acabdb578fe97d3b39a1c16a7c2d19c56347ded22d7"
|
| 2110 |
},
|
| 2111 |
"hf_artifacts_data": {
|
| 2112 |
"path": "hf_artifacts:data/task_suite_20.json",
|
| 2113 |
"exists": true,
|
| 2114 |
+
"bytes": 34597,
|
| 2115 |
+
"sha256": "2029f7f9744001861ac00acabdb578fe97d3b39a1c16a7c2d19c56347ded22d7"
|
| 2116 |
},
|
| 2117 |
"hf_artifacts": {
|
| 2118 |
"path": "hf_artifacts:docs/data/task_suite_20.json",
|
| 2119 |
"exists": true,
|
| 2120 |
+
"bytes": 34597,
|
| 2121 |
+
"sha256": "2029f7f9744001861ac00acabdb578fe97d3b39a1c16a7c2d19c56347ded22d7"
|
| 2122 |
},
|
| 2123 |
"hf_model_data": {
|
| 2124 |
"path": "hf_model:data/task_suite_20.json",
|
| 2125 |
"exists": true,
|
| 2126 |
+
"bytes": 34597,
|
| 2127 |
+
"sha256": "2029f7f9744001861ac00acabdb578fe97d3b39a1c16a7c2d19c56347ded22d7"
|
| 2128 |
},
|
| 2129 |
"hf_model_docs_data": {
|
| 2130 |
"path": "hf_model:docs/data/task_suite_20.json",
|
| 2131 |
"exists": true,
|
| 2132 |
+
"bytes": 34597,
|
| 2133 |
+
"sha256": "2029f7f9744001861ac00acabdb578fe97d3b39a1c16a7c2d19c56347ded22d7"
|
| 2134 |
},
|
| 2135 |
"hf_model": {
|
| 2136 |
"path": "hf_model:metrics/task_suite_20.json",
|
| 2137 |
"exists": true,
|
| 2138 |
+
"bytes": 34597,
|
| 2139 |
+
"sha256": "2029f7f9744001861ac00acabdb578fe97d3b39a1c16a7c2d19c56347ded22d7"
|
| 2140 |
}
|
| 2141 |
},
|
| 2142 |
"failures": []
|
|
|
|
| 2197 |
"path": "repo:docs/data/task_surface_integrity.json",
|
| 2198 |
"exists": true,
|
| 2199 |
"bytes": 46246,
|
| 2200 |
+
"sha256": "8dcf8f891d24cce14ce468949c0dff646692e5d42a94bcd8ebc828c3862b588d"
|
| 2201 |
},
|
| 2202 |
"mirrors": {
|
| 2203 |
"hf_space": {
|
| 2204 |
"path": "hf_space:data/task_surface_integrity.json",
|
| 2205 |
"exists": true,
|
| 2206 |
"bytes": 46246,
|
| 2207 |
+
"sha256": "8dcf8f891d24cce14ce468949c0dff646692e5d42a94bcd8ebc828c3862b588d"
|
| 2208 |
},
|
| 2209 |
"hf_artifacts_data": {
|
| 2210 |
"path": "hf_artifacts:data/task_surface_integrity.json",
|
| 2211 |
"exists": true,
|
| 2212 |
"bytes": 46246,
|
| 2213 |
+
"sha256": "8dcf8f891d24cce14ce468949c0dff646692e5d42a94bcd8ebc828c3862b588d"
|
| 2214 |
},
|
| 2215 |
"hf_artifacts": {
|
| 2216 |
"path": "hf_artifacts:docs/data/task_surface_integrity.json",
|
| 2217 |
"exists": true,
|
| 2218 |
"bytes": 46246,
|
| 2219 |
+
"sha256": "8dcf8f891d24cce14ce468949c0dff646692e5d42a94bcd8ebc828c3862b588d"
|
| 2220 |
},
|
| 2221 |
"hf_model_data": {
|
| 2222 |
"path": "hf_model:data/task_surface_integrity.json",
|
| 2223 |
"exists": true,
|
| 2224 |
"bytes": 46246,
|
| 2225 |
+
"sha256": "8dcf8f891d24cce14ce468949c0dff646692e5d42a94bcd8ebc828c3862b588d"
|
| 2226 |
},
|
| 2227 |
"hf_model_docs_data": {
|
| 2228 |
"path": "hf_model:docs/data/task_surface_integrity.json",
|
| 2229 |
"exists": true,
|
| 2230 |
"bytes": 46246,
|
| 2231 |
+
"sha256": "8dcf8f891d24cce14ce468949c0dff646692e5d42a94bcd8ebc828c3862b588d"
|
| 2232 |
},
|
| 2233 |
"hf_model": {
|
| 2234 |
"path": "hf_model:metrics/task_surface_integrity.json",
|
| 2235 |
"exists": true,
|
| 2236 |
"bytes": 46246,
|
| 2237 |
+
"sha256": "8dcf8f891d24cce14ce468949c0dff646692e5d42a94bcd8ebc828c3862b588d"
|
| 2238 |
}
|
| 2239 |
},
|
| 2240 |
"failures": []
|
|
|
|
| 2441 |
"local": {
|
| 2442 |
"path": "repo:docs/data/tier2_task_suite.json",
|
| 2443 |
"exists": true,
|
| 2444 |
+
"bytes": 33411,
|
| 2445 |
+
"sha256": "688ef62ae638b7ca9321c91ff3b400dfa88d96d7739a92e27589b31fe4dcdd48"
|
| 2446 |
},
|
| 2447 |
"mirrors": {
|
| 2448 |
"hf_space": {
|
| 2449 |
"path": "hf_space:data/tier2_task_suite.json",
|
| 2450 |
"exists": true,
|
| 2451 |
+
"bytes": 33411,
|
| 2452 |
+
"sha256": "688ef62ae638b7ca9321c91ff3b400dfa88d96d7739a92e27589b31fe4dcdd48"
|
| 2453 |
},
|
| 2454 |
"hf_artifacts_data": {
|
| 2455 |
"path": "hf_artifacts:data/tier2_task_suite.json",
|
| 2456 |
"exists": true,
|
| 2457 |
+
"bytes": 33411,
|
| 2458 |
+
"sha256": "688ef62ae638b7ca9321c91ff3b400dfa88d96d7739a92e27589b31fe4dcdd48"
|
| 2459 |
},
|
| 2460 |
"hf_artifacts": {
|
| 2461 |
"path": "hf_artifacts:docs/data/tier2_task_suite.json",
|
| 2462 |
"exists": true,
|
| 2463 |
+
"bytes": 33411,
|
| 2464 |
+
"sha256": "688ef62ae638b7ca9321c91ff3b400dfa88d96d7739a92e27589b31fe4dcdd48"
|
| 2465 |
},
|
| 2466 |
"hf_model_data": {
|
| 2467 |
"path": "hf_model:data/tier2_task_suite.json",
|
| 2468 |
"exists": true,
|
| 2469 |
+
"bytes": 33411,
|
| 2470 |
+
"sha256": "688ef62ae638b7ca9321c91ff3b400dfa88d96d7739a92e27589b31fe4dcdd48"
|
| 2471 |
},
|
| 2472 |
"hf_model_docs_data": {
|
| 2473 |
"path": "hf_model:docs/data/tier2_task_suite.json",
|
| 2474 |
"exists": true,
|
| 2475 |
+
"bytes": 33411,
|
| 2476 |
+
"sha256": "688ef62ae638b7ca9321c91ff3b400dfa88d96d7739a92e27589b31fe4dcdd48"
|
| 2477 |
},
|
| 2478 |
"hf_model": {
|
| 2479 |
"path": "hf_model:metrics/tier2_task_suite.json",
|
| 2480 |
"exists": true,
|
| 2481 |
+
"bytes": 33411,
|
| 2482 |
+
"sha256": "688ef62ae638b7ca9321c91ff3b400dfa88d96d7739a92e27589b31fe4dcdd48"
|
| 2483 |
}
|
| 2484 |
},
|
| 2485 |
"failures": []
|
|
|
|
| 2540 |
"path": "repo:docs/data/website_integrity.json",
|
| 2541 |
"exists": true,
|
| 2542 |
"bytes": 20760,
|
| 2543 |
+
"sha256": "34d39266707f0b6b359c66fc28ac00316082daea2d45e1e471381b535cb968b5"
|
| 2544 |
},
|
| 2545 |
"mirrors": {
|
| 2546 |
"hf_space": {
|
| 2547 |
"path": "hf_space:data/website_integrity.json",
|
| 2548 |
"exists": true,
|
| 2549 |
"bytes": 20760,
|
| 2550 |
+
"sha256": "34d39266707f0b6b359c66fc28ac00316082daea2d45e1e471381b535cb968b5"
|
| 2551 |
},
|
| 2552 |
"hf_artifacts_data": {
|
| 2553 |
"path": "hf_artifacts:data/website_integrity.json",
|
| 2554 |
"exists": true,
|
| 2555 |
"bytes": 20760,
|
| 2556 |
+
"sha256": "34d39266707f0b6b359c66fc28ac00316082daea2d45e1e471381b535cb968b5"
|
| 2557 |
},
|
| 2558 |
"hf_artifacts": {
|
| 2559 |
"path": "hf_artifacts:docs/data/website_integrity.json",
|
| 2560 |
"exists": true,
|
| 2561 |
"bytes": 20760,
|
| 2562 |
+
"sha256": "34d39266707f0b6b359c66fc28ac00316082daea2d45e1e471381b535cb968b5"
|
| 2563 |
},
|
| 2564 |
"hf_model_data": {
|
| 2565 |
"path": "hf_model:data/website_integrity.json",
|
| 2566 |
"exists": true,
|
| 2567 |
"bytes": 20760,
|
| 2568 |
+
"sha256": "34d39266707f0b6b359c66fc28ac00316082daea2d45e1e471381b535cb968b5"
|
| 2569 |
},
|
| 2570 |
"hf_model_docs_data": {
|
| 2571 |
"path": "hf_model:docs/data/website_integrity.json",
|
| 2572 |
"exists": true,
|
| 2573 |
"bytes": 20760,
|
| 2574 |
+
"sha256": "34d39266707f0b6b359c66fc28ac00316082daea2d45e1e471381b535cb968b5"
|
| 2575 |
},
|
| 2576 |
"hf_model": {
|
| 2577 |
"path": "hf_model:metrics/website_integrity.json",
|
| 2578 |
"exists": true,
|
| 2579 |
"bytes": 20760,
|
| 2580 |
+
"sha256": "34d39266707f0b6b359c66fc28ac00316082daea2d45e1e471381b535cb968b5"
|
| 2581 |
}
|
| 2582 |
},
|
| 2583 |
"failures": []
|
|
|
|
| 2834 |
"local": {
|
| 2835 |
"path": "repo:docs/assets/charts/tier2_task_suite.svg",
|
| 2836 |
"exists": true,
|
| 2837 |
+
"bytes": 5453,
|
| 2838 |
+
"sha256": "e9da29c57f42b29a7a05622fee1335089ac2b6fc9692a3b49fa5b753904db9dc"
|
| 2839 |
},
|
| 2840 |
"mirrors": {
|
| 2841 |
"hf_space": {
|
| 2842 |
"path": "hf_space:assets/charts/tier2_task_suite.svg",
|
| 2843 |
"exists": true,
|
| 2844 |
+
"bytes": 5453,
|
| 2845 |
+
"sha256": "e9da29c57f42b29a7a05622fee1335089ac2b6fc9692a3b49fa5b753904db9dc"
|
| 2846 |
},
|
| 2847 |
"hf_artifacts_docs": {
|
| 2848 |
"path": "hf_artifacts:docs/assets/charts/tier2_task_suite.svg",
|
| 2849 |
"exists": true,
|
| 2850 |
+
"bytes": 5453,
|
| 2851 |
+
"sha256": "e9da29c57f42b29a7a05622fee1335089ac2b6fc9692a3b49fa5b753904db9dc"
|
| 2852 |
},
|
| 2853 |
"hf_artifacts_card": {
|
| 2854 |
"path": "hf_artifacts:assets/charts/tier2_task_suite.svg",
|
| 2855 |
"exists": true,
|
| 2856 |
+
"bytes": 5453,
|
| 2857 |
+
"sha256": "e9da29c57f42b29a7a05622fee1335089ac2b6fc9692a3b49fa5b753904db9dc"
|
| 2858 |
},
|
| 2859 |
"hf_model": {
|
| 2860 |
"path": "hf_model:assets/charts/tier2_task_suite.svg",
|
| 2861 |
"exists": true,
|
| 2862 |
+
"bytes": 5453,
|
| 2863 |
+
"sha256": "e9da29c57f42b29a7a05622fee1335089ac2b6fc9692a3b49fa5b753904db9dc"
|
| 2864 |
}
|
| 2865 |
},
|
| 2866 |
"failures": []
|
|
|
|
| 3204 |
"local": {
|
| 3205 |
"path": "repo:docs/assets/task_suite_infographic.png",
|
| 3206 |
"exists": true,
|
| 3207 |
+
"bytes": 1897278,
|
| 3208 |
+
"sha256": "71b1ab150e952cf902488226c65b3822d8016974f63d111204c1eb1a7745faad"
|
| 3209 |
},
|
| 3210 |
"mirrors": {
|
| 3211 |
"hf_space": {
|
| 3212 |
"path": "hf_space:assets/task_suite_infographic.png",
|
| 3213 |
"exists": true,
|
| 3214 |
+
"bytes": 1897278,
|
| 3215 |
+
"sha256": "71b1ab150e952cf902488226c65b3822d8016974f63d111204c1eb1a7745faad"
|
| 3216 |
},
|
| 3217 |
"hf_artifacts_docs": {
|
| 3218 |
"path": "hf_artifacts:docs/assets/task_suite_infographic.png",
|
| 3219 |
"exists": true,
|
| 3220 |
+
"bytes": 1897278,
|
| 3221 |
+
"sha256": "71b1ab150e952cf902488226c65b3822d8016974f63d111204c1eb1a7745faad"
|
| 3222 |
},
|
| 3223 |
"hf_artifacts_card": {
|
| 3224 |
"path": "hf_artifacts:assets/task_suite_infographic.png",
|
| 3225 |
"exists": true,
|
| 3226 |
+
"bytes": 1897278,
|
| 3227 |
+
"sha256": "71b1ab150e952cf902488226c65b3822d8016974f63d111204c1eb1a7745faad"
|
| 3228 |
},
|
| 3229 |
"hf_model": {
|
| 3230 |
"path": "hf_model:assets/task_suite_infographic.png",
|
| 3231 |
"exists": true,
|
| 3232 |
+
"bytes": 1897278,
|
| 3233 |
+
"sha256": "71b1ab150e952cf902488226c65b3822d8016974f63d111204c1eb1a7745faad"
|
| 3234 |
}
|
| 3235 |
},
|
| 3236 |
"failures": []
|
|
|
|
| 4327 |
"local": {
|
| 4328 |
"path": "repo:scripts/omni/build_omni_model_comparison.py",
|
| 4329 |
"exists": true,
|
| 4330 |
+
"bytes": 45385,
|
| 4331 |
+
"sha256": "eb15d2b2c63190ce885859a1b49585f51f85951e80e6c2119b4b140321a32462"
|
| 4332 |
},
|
| 4333 |
"mirrors": {
|
| 4334 |
"hf_artifacts": {
|
| 4335 |
"path": "hf_artifacts:scripts/omni/build_omni_model_comparison.py",
|
| 4336 |
"exists": true,
|
| 4337 |
+
"bytes": 45385,
|
| 4338 |
+
"sha256": "eb15d2b2c63190ce885859a1b49585f51f85951e80e6c2119b4b140321a32462"
|
| 4339 |
},
|
| 4340 |
"hf_model": {
|
| 4341 |
"path": "hf_model:scripts/omni/build_omni_model_comparison.py",
|
| 4342 |
"exists": true,
|
| 4343 |
+
"bytes": 45385,
|
| 4344 |
+
"sha256": "eb15d2b2c63190ce885859a1b49585f51f85951e80e6c2119b4b140321a32462"
|
| 4345 |
}
|
| 4346 |
},
|
| 4347 |
"failures": []
|
|
|
|
| 5327 |
"local": {
|
| 5328 |
"path": "repo:scripts/build_artifact_index.py",
|
| 5329 |
"exists": true,
|
| 5330 |
+
"bytes": 68232,
|
| 5331 |
+
"sha256": "ee1b210688c1b722d6ca94d1c1706c1a510218c964298b91dd3e596fa19ed2a1"
|
| 5332 |
},
|
| 5333 |
"mirrors": {
|
| 5334 |
"hf_artifacts": {
|
| 5335 |
"path": "hf_artifacts:scripts/build_artifact_index.py",
|
| 5336 |
"exists": true,
|
| 5337 |
+
"bytes": 68232,
|
| 5338 |
+
"sha256": "ee1b210688c1b722d6ca94d1c1706c1a510218c964298b91dd3e596fa19ed2a1"
|
| 5339 |
},
|
| 5340 |
"hf_model": {
|
| 5341 |
"path": "hf_model:scripts/build_artifact_index.py",
|
| 5342 |
"exists": true,
|
| 5343 |
+
"bytes": 68232,
|
| 5344 |
+
"sha256": "ee1b210688c1b722d6ca94d1c1706c1a510218c964298b91dd3e596fa19ed2a1"
|
| 5345 |
}
|
| 5346 |
},
|
| 5347 |
"failures": []
|
|
|
|
| 5377 |
"local": {
|
| 5378 |
"path": "repo:scripts/build_evaluation_protocol.py",
|
| 5379 |
"exists": true,
|
| 5380 |
+
"bytes": 19931,
|
| 5381 |
+
"sha256": "080f894b50c609e3a467c8c513dfe441f90ba0dad3586dd1cb88de6e58eedb3b"
|
| 5382 |
},
|
| 5383 |
"mirrors": {
|
| 5384 |
"hf_artifacts": {
|
| 5385 |
"path": "hf_artifacts:scripts/build_evaluation_protocol.py",
|
| 5386 |
"exists": true,
|
| 5387 |
+
"bytes": 19931,
|
| 5388 |
+
"sha256": "080f894b50c609e3a467c8c513dfe441f90ba0dad3586dd1cb88de6e58eedb3b"
|
| 5389 |
},
|
| 5390 |
"hf_model": {
|
| 5391 |
"path": "hf_model:scripts/build_evaluation_protocol.py",
|
| 5392 |
"exists": true,
|
| 5393 |
+
"bytes": 19931,
|
| 5394 |
+
"sha256": "080f894b50c609e3a467c8c513dfe441f90ba0dad3586dd1cb88de6e58eedb3b"
|
| 5395 |
}
|
| 5396 |
},
|
| 5397 |
"failures": []
|
|
|
|
| 5402 |
"local": {
|
| 5403 |
"path": "repo:scripts/build_figure_index.py",
|
| 5404 |
"exists": true,
|
| 5405 |
+
"bytes": 16829,
|
| 5406 |
+
"sha256": "14f1ed7f94630c8f70fbc14547071db251647f3d527cf760341b7a233883d069"
|
| 5407 |
},
|
| 5408 |
"mirrors": {
|
| 5409 |
"hf_artifacts": {
|
| 5410 |
"path": "hf_artifacts:scripts/build_figure_index.py",
|
| 5411 |
"exists": true,
|
| 5412 |
+
"bytes": 16829,
|
| 5413 |
+
"sha256": "14f1ed7f94630c8f70fbc14547071db251647f3d527cf760341b7a233883d069"
|
| 5414 |
},
|
| 5415 |
"hf_model": {
|
| 5416 |
"path": "hf_model:scripts/build_figure_index.py",
|
| 5417 |
"exists": true,
|
| 5418 |
+
"bytes": 16829,
|
| 5419 |
+
"sha256": "14f1ed7f94630c8f70fbc14547071db251647f3d527cf760341b7a233883d069"
|
| 5420 |
}
|
| 5421 |
},
|
| 5422 |
"failures": []
|
|
|
|
| 5752 |
"local": {
|
| 5753 |
"path": "repo:scripts/render_task_suite_infographic.py",
|
| 5754 |
"exists": true,
|
| 5755 |
+
"bytes": 40205,
|
| 5756 |
+
"sha256": "9f424ce73344ea04cb085ae87041dd756638edd33aafa13c6af9179dce5f8676"
|
| 5757 |
},
|
| 5758 |
"mirrors": {
|
| 5759 |
"hf_artifacts": {
|
| 5760 |
"path": "hf_artifacts:scripts/render_task_suite_infographic.py",
|
| 5761 |
"exists": true,
|
| 5762 |
+
"bytes": 40205,
|
| 5763 |
+
"sha256": "9f424ce73344ea04cb085ae87041dd756638edd33aafa13c6af9179dce5f8676"
|
| 5764 |
},
|
| 5765 |
"hf_model": {
|
| 5766 |
"path": "hf_model:scripts/render_task_suite_infographic.py",
|
| 5767 |
"exists": true,
|
| 5768 |
+
"bytes": 40205,
|
| 5769 |
+
"sha256": "9f424ce73344ea04cb085ae87041dd756638edd33aafa13c6af9179dce5f8676"
|
| 5770 |
}
|
| 5771 |
},
|
| 5772 |
"failures": []
|
|
|
|
| 5852 |
"local": {
|
| 5853 |
"path": "repo:scripts/build_unified_task_suite.py",
|
| 5854 |
"exists": true,
|
| 5855 |
+
"bytes": 12213,
|
| 5856 |
+
"sha256": "1421593f05e345799007bbcdf138f81dfdb7c511ec1e31b56d00e2cdaed3d7de"
|
| 5857 |
},
|
| 5858 |
"mirrors": {
|
| 5859 |
"hf_artifacts": {
|
| 5860 |
"path": "hf_artifacts:scripts/build_unified_task_suite.py",
|
| 5861 |
"exists": true,
|
| 5862 |
+
"bytes": 12213,
|
| 5863 |
+
"sha256": "1421593f05e345799007bbcdf138f81dfdb7c511ec1e31b56d00e2cdaed3d7de"
|
| 5864 |
},
|
| 5865 |
"hf_model": {
|
| 5866 |
"path": "hf_model:scripts/build_unified_task_suite.py",
|
| 5867 |
"exists": true,
|
| 5868 |
+
"bytes": 12213,
|
| 5869 |
+
"sha256": "1421593f05e345799007bbcdf138f81dfdb7c511ec1e31b56d00e2cdaed3d7de"
|
| 5870 |
}
|
| 5871 |
},
|
| 5872 |
"failures": []
|
|
|
|
| 5927 |
"local": {
|
| 5928 |
"path": "repo:scripts/verify_live_publication.py",
|
| 5929 |
"exists": true,
|
| 5930 |
+
"bytes": 69151,
|
| 5931 |
+
"sha256": "c4af8644d50dafe7d4249dd7c5b36bb19e996628ff6d8436fbb6e027da526c1f"
|
| 5932 |
},
|
| 5933 |
"mirrors": {
|
| 5934 |
"hf_artifacts": {
|
| 5935 |
"path": "hf_artifacts:scripts/verify_live_publication.py",
|
| 5936 |
"exists": true,
|
| 5937 |
+
"bytes": 69151,
|
| 5938 |
+
"sha256": "c4af8644d50dafe7d4249dd7c5b36bb19e996628ff6d8436fbb6e027da526c1f"
|
| 5939 |
},
|
| 5940 |
"hf_model": {
|
| 5941 |
"path": "hf_model:scripts/verify_live_publication.py",
|
| 5942 |
"exists": true,
|
| 5943 |
+
"bytes": 69151,
|
| 5944 |
+
"sha256": "c4af8644d50dafe7d4249dd7c5b36bb19e996628ff6d8436fbb6e027da526c1f"
|
| 5945 |
}
|
| 5946 |
},
|
| 5947 |
"failures": []
|
|
|
|
| 5952 |
"local": {
|
| 5953 |
"path": "repo:scripts/validate_mirror_parity.py",
|
| 5954 |
"exists": true,
|
| 5955 |
+
"bytes": 36531,
|
| 5956 |
+
"sha256": "c658b7c5d26c2495572b152ef7061c3eeda89527eb0911852cc0f1ab73900213"
|
| 5957 |
},
|
| 5958 |
"mirrors": {
|
| 5959 |
"hf_artifacts": {
|
| 5960 |
"path": "hf_artifacts:scripts/validate_mirror_parity.py",
|
| 5961 |
"exists": true,
|
| 5962 |
+
"bytes": 36531,
|
| 5963 |
+
"sha256": "c658b7c5d26c2495572b152ef7061c3eeda89527eb0911852cc0f1ab73900213"
|
| 5964 |
},
|
| 5965 |
"hf_model": {
|
| 5966 |
"path": "hf_model:scripts/validate_mirror_parity.py",
|
| 5967 |
"exists": true,
|
| 5968 |
+
"bytes": 36531,
|
| 5969 |
+
"sha256": "c658b7c5d26c2495572b152ef7061c3eeda89527eb0911852cc0f1ab73900213"
|
| 5970 |
}
|
| 5971 |
},
|
| 5972 |
"failures": []
|
|
|
|
| 6127 |
"local": {
|
| 6128 |
"path": "repo:scripts/sync_hf_publish_mirrors.py",
|
| 6129 |
"exists": true,
|
| 6130 |
+
"bytes": 30073,
|
| 6131 |
+
"sha256": "b3b558c613ed2fc6ada55087bcbe8fda5ad6fcf748043fae9706dc3de18a64eb"
|
| 6132 |
},
|
| 6133 |
"mirrors": {
|
| 6134 |
"hf_artifacts": {
|
| 6135 |
"path": "hf_artifacts:scripts/sync_hf_publish_mirrors.py",
|
| 6136 |
"exists": true,
|
| 6137 |
+
"bytes": 30073,
|
| 6138 |
+
"sha256": "b3b558c613ed2fc6ada55087bcbe8fda5ad6fcf748043fae9706dc3de18a64eb"
|
| 6139 |
},
|
| 6140 |
"hf_model": {
|
| 6141 |
"path": "hf_model:scripts/sync_hf_publish_mirrors.py",
|
| 6142 |
"exists": true,
|
| 6143 |
+
"bytes": 30073,
|
| 6144 |
+
"sha256": "b3b558c613ed2fc6ada55087bcbe8fda5ad6fcf748043fae9706dc3de18a64eb"
|
| 6145 |
}
|
| 6146 |
},
|
| 6147 |
"failures": []
|
|
|
|
| 6152 |
"local": {
|
| 6153 |
"path": "repo:scripts/tier2_task_suite.py",
|
| 6154 |
"exists": true,
|
| 6155 |
+
"bytes": 47102,
|
| 6156 |
+
"sha256": "3cddefaaeedd8efb65e6db956cbd13605e4a5b3772d98fa831d34fd6f92850de"
|
| 6157 |
},
|
| 6158 |
"mirrors": {
|
| 6159 |
"hf_artifacts": {
|
| 6160 |
"path": "hf_artifacts:scripts/tier2_task_suite.py",
|
| 6161 |
"exists": true,
|
| 6162 |
+
"bytes": 47102,
|
| 6163 |
+
"sha256": "3cddefaaeedd8efb65e6db956cbd13605e4a5b3772d98fa831d34fd6f92850de"
|
| 6164 |
},
|
| 6165 |
"hf_model": {
|
| 6166 |
"path": "hf_model:scripts/tier2_task_suite.py",
|
| 6167 |
"exists": true,
|
| 6168 |
+
"bytes": 47102,
|
| 6169 |
+
"sha256": "3cddefaaeedd8efb65e6db956cbd13605e4a5b3772d98fa831d34fd6f92850de"
|
| 6170 |
}
|
| 6171 |
},
|
| 6172 |
"failures": []
|
|
|
|
| 6331 |
"local": {
|
| 6332 |
"path": "repo:docs/index.html",
|
| 6333 |
"exists": true,
|
| 6334 |
+
"bytes": 315158,
|
| 6335 |
+
"sha256": "306f6bea7d10c031ca20932dfe719713181effb2ed333bd02b9e2128e6d3640d"
|
| 6336 |
},
|
| 6337 |
"mirrors": {
|
| 6338 |
"hf_space": {
|
| 6339 |
"path": "hf_space:index.html",
|
| 6340 |
"exists": true,
|
| 6341 |
+
"bytes": 315158,
|
| 6342 |
+
"sha256": "306f6bea7d10c031ca20932dfe719713181effb2ed333bd02b9e2128e6d3640d"
|
| 6343 |
},
|
| 6344 |
"hf_artifacts_root": {
|
| 6345 |
"path": "hf_artifacts:index.html",
|
| 6346 |
"exists": true,
|
| 6347 |
+
"bytes": 315158,
|
| 6348 |
+
"sha256": "306f6bea7d10c031ca20932dfe719713181effb2ed333bd02b9e2128e6d3640d"
|
| 6349 |
},
|
| 6350 |
"hf_artifacts_docs": {
|
| 6351 |
"path": "hf_artifacts:docs/index.html",
|
| 6352 |
"exists": true,
|
| 6353 |
+
"bytes": 315158,
|
| 6354 |
+
"sha256": "306f6bea7d10c031ca20932dfe719713181effb2ed333bd02b9e2128e6d3640d"
|
| 6355 |
},
|
| 6356 |
"hf_model": {
|
| 6357 |
"path": "hf_model:index.html",
|
| 6358 |
"exists": true,
|
| 6359 |
+
"bytes": 315158,
|
| 6360 |
+
"sha256": "306f6bea7d10c031ca20932dfe719713181effb2ed333bd02b9e2128e6d3640d"
|
| 6361 |
},
|
| 6362 |
"hf_model_docs": {
|
| 6363 |
"path": "hf_model:docs/index.html",
|
| 6364 |
"exists": true,
|
| 6365 |
+
"bytes": 315158,
|
| 6366 |
+
"sha256": "306f6bea7d10c031ca20932dfe719713181effb2ed333bd02b9e2128e6d3640d"
|
| 6367 |
}
|
| 6368 |
},
|
| 6369 |
"failures": []
|
|
|
|
| 6628 |
"local": {
|
| 6629 |
"path": "repo:results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md",
|
| 6630 |
"exists": true,
|
| 6631 |
+
"bytes": 3356,
|
| 6632 |
+
"sha256": "9b05f2267ce6d4f0d7927eae205005e6bdadaa08ea700dabeaf53eba669fd9c4"
|
| 6633 |
},
|
| 6634 |
"mirrors": {
|
| 6635 |
"hf_artifacts": {
|
| 6636 |
"path": "hf_artifacts:results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md",
|
| 6637 |
"exists": true,
|
| 6638 |
+
"bytes": 3356,
|
| 6639 |
+
"sha256": "9b05f2267ce6d4f0d7927eae205005e6bdadaa08ea700dabeaf53eba669fd9c4"
|
| 6640 |
},
|
| 6641 |
"hf_model": {
|
| 6642 |
"path": "hf_model:results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md",
|
| 6643 |
"exists": true,
|
| 6644 |
+
"bytes": 3356,
|
| 6645 |
+
"sha256": "9b05f2267ce6d4f0d7927eae205005e6bdadaa08ea700dabeaf53eba669fd9c4"
|
| 6646 |
}
|
| 6647 |
},
|
| 6648 |
"failures": []
|
|
|
|
| 7628 |
"local": {
|
| 7629 |
"path": "repo:results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 7630 |
"exists": true,
|
| 7631 |
+
"bytes": 33411,
|
| 7632 |
+
"sha256": "688ef62ae638b7ca9321c91ff3b400dfa88d96d7739a92e27589b31fe4dcdd48"
|
| 7633 |
},
|
| 7634 |
"mirrors": {
|
| 7635 |
"hf_artifacts": {
|
| 7636 |
"path": "hf_artifacts:results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 7637 |
"exists": true,
|
| 7638 |
+
"bytes": 33411,
|
| 7639 |
+
"sha256": "688ef62ae638b7ca9321c91ff3b400dfa88d96d7739a92e27589b31fe4dcdd48"
|
| 7640 |
},
|
| 7641 |
"hf_model": {
|
| 7642 |
"path": "hf_model:results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 7643 |
"exists": true,
|
| 7644 |
+
"bytes": 33411,
|
| 7645 |
+
"sha256": "688ef62ae638b7ca9321c91ff3b400dfa88d96d7739a92e27589b31fe4dcdd48"
|
| 7646 |
}
|
| 7647 |
},
|
| 7648 |
"failures": []
|
|
|
|
| 24948 |
"local": {
|
| 24949 |
"path": "repo:results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md",
|
| 24950 |
"exists": true,
|
| 24951 |
+
"bytes": 3356,
|
| 24952 |
+
"sha256": "9b05f2267ce6d4f0d7927eae205005e6bdadaa08ea700dabeaf53eba669fd9c4"
|
| 24953 |
},
|
| 24954 |
"mirrors": {
|
| 24955 |
"hf_space": {
|
| 24956 |
"path": "hf_space:results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md",
|
| 24957 |
"exists": true,
|
| 24958 |
+
"bytes": 3356,
|
| 24959 |
+
"sha256": "9b05f2267ce6d4f0d7927eae205005e6bdadaa08ea700dabeaf53eba669fd9c4"
|
| 24960 |
}
|
| 24961 |
},
|
| 24962 |
"failures": []
|
|
|
|
| 25708 |
"local": {
|
| 25709 |
"path": "repo:results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 25710 |
"exists": true,
|
| 25711 |
+
"bytes": 33411,
|
| 25712 |
+
"sha256": "688ef62ae638b7ca9321c91ff3b400dfa88d96d7739a92e27589b31fe4dcdd48"
|
| 25713 |
},
|
| 25714 |
"mirrors": {
|
| 25715 |
"hf_space": {
|
| 25716 |
"path": "hf_space:results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 25717 |
"exists": true,
|
| 25718 |
+
"bytes": 33411,
|
| 25719 |
+
"sha256": "688ef62ae638b7ca9321c91ff3b400dfa88d96d7739a92e27589b31fe4dcdd48"
|
| 25720 |
}
|
| 25721 |
},
|
| 25722 |
"failures": []
|
|
|
|
| 30903 |
"local": {
|
| 30904 |
"path": "repo:ARTIFACT_GUIDE.md",
|
| 30905 |
"exists": true,
|
| 30906 |
+
"bytes": 20571,
|
| 30907 |
+
"sha256": "217e3eb2cf82999f75ce6e132f567fa1ed08d319bf7a44f77b7150a45fae5274"
|
| 30908 |
},
|
| 30909 |
"mirrors": {
|
| 30910 |
"hf_space": {
|
| 30911 |
"path": "hf_space:ARTIFACT_GUIDE.md",
|
| 30912 |
"exists": true,
|
| 30913 |
+
"bytes": 20571,
|
| 30914 |
+
"sha256": "217e3eb2cf82999f75ce6e132f567fa1ed08d319bf7a44f77b7150a45fae5274"
|
| 30915 |
},
|
| 30916 |
"hf_artifacts": {
|
| 30917 |
"path": "hf_artifacts:ARTIFACT_GUIDE.md",
|
| 30918 |
"exists": true,
|
| 30919 |
+
"bytes": 20571,
|
| 30920 |
+
"sha256": "217e3eb2cf82999f75ce6e132f567fa1ed08d319bf7a44f77b7150a45fae5274"
|
| 30921 |
},
|
| 30922 |
"hf_model": {
|
| 30923 |
"path": "hf_model:ARTIFACT_GUIDE.md",
|
| 30924 |
"exists": true,
|
| 30925 |
+
"bytes": 20571,
|
| 30926 |
+
"sha256": "217e3eb2cf82999f75ce6e132f567fa1ed08d319bf7a44f77b7150a45fae5274"
|
| 30927 |
}
|
| 30928 |
},
|
| 30929 |
"failures": []
|
|
|
|
| 30996 |
"local": {
|
| 30997 |
"path": "repo:EVALUATION_PROTOCOL.md",
|
| 30998 |
"exists": true,
|
| 30999 |
+
"bytes": 9156,
|
| 31000 |
+
"sha256": "cfc23b3115ebce2b41a349b8a2cd6989aaf2294790c79e2b17545ebede2b2df0"
|
| 31001 |
},
|
| 31002 |
"mirrors": {
|
| 31003 |
"hf_space": {
|
| 31004 |
"path": "hf_space:EVALUATION_PROTOCOL.md",
|
| 31005 |
"exists": true,
|
| 31006 |
+
"bytes": 9156,
|
| 31007 |
+
"sha256": "cfc23b3115ebce2b41a349b8a2cd6989aaf2294790c79e2b17545ebede2b2df0"
|
| 31008 |
},
|
| 31009 |
"hf_artifacts": {
|
| 31010 |
"path": "hf_artifacts:EVALUATION_PROTOCOL.md",
|
| 31011 |
"exists": true,
|
| 31012 |
+
"bytes": 9156,
|
| 31013 |
+
"sha256": "cfc23b3115ebce2b41a349b8a2cd6989aaf2294790c79e2b17545ebede2b2df0"
|
| 31014 |
},
|
| 31015 |
"hf_model": {
|
| 31016 |
"path": "hf_model:EVALUATION_PROTOCOL.md",
|
| 31017 |
"exists": true,
|
| 31018 |
+
"bytes": 9156,
|
| 31019 |
+
"sha256": "cfc23b3115ebce2b41a349b8a2cd6989aaf2294790c79e2b17545ebede2b2df0"
|
| 31020 |
}
|
| 31021 |
},
|
| 31022 |
"failures": []
|
|
|
|
| 31027 |
"local": {
|
| 31028 |
"path": "repo:FIGURE_INDEX.md",
|
| 31029 |
"exists": true,
|
| 31030 |
+
"bytes": 7011,
|
| 31031 |
+
"sha256": "f6554cd980efa6c0b3b8feac5ff3e19c3e2e74ccf2d446ac4afb5ee5d65413f3"
|
| 31032 |
},
|
| 31033 |
"mirrors": {
|
| 31034 |
"hf_space": {
|
| 31035 |
"path": "hf_space:FIGURE_INDEX.md",
|
| 31036 |
"exists": true,
|
| 31037 |
+
"bytes": 7011,
|
| 31038 |
+
"sha256": "f6554cd980efa6c0b3b8feac5ff3e19c3e2e74ccf2d446ac4afb5ee5d65413f3"
|
| 31039 |
},
|
| 31040 |
"hf_artifacts": {
|
| 31041 |
"path": "hf_artifacts:FIGURE_INDEX.md",
|
| 31042 |
"exists": true,
|
| 31043 |
+
"bytes": 7011,
|
| 31044 |
+
"sha256": "f6554cd980efa6c0b3b8feac5ff3e19c3e2e74ccf2d446ac4afb5ee5d65413f3"
|
| 31045 |
},
|
| 31046 |
"hf_model": {
|
| 31047 |
"path": "hf_model:FIGURE_INDEX.md",
|
| 31048 |
"exists": true,
|
| 31049 |
+
"bytes": 7011,
|
| 31050 |
+
"sha256": "f6554cd980efa6c0b3b8feac5ff3e19c3e2e74ccf2d446ac4afb5ee5d65413f3"
|
| 31051 |
}
|
| 31052 |
},
|
| 31053 |
"failures": []
|
|
|
|
| 31089 |
"local": {
|
| 31090 |
"path": "repo:GLOSSARY.md",
|
| 31091 |
"exists": true,
|
| 31092 |
+
"bytes": 10220,
|
| 31093 |
+
"sha256": "c3723a3dfaf902f4bc2527b78d11057ab8ba01c6b9715fa873c7dd819deddf81"
|
| 31094 |
},
|
| 31095 |
"mirrors": {
|
| 31096 |
"hf_space": {
|
| 31097 |
"path": "hf_space:GLOSSARY.md",
|
| 31098 |
"exists": true,
|
| 31099 |
+
"bytes": 10220,
|
| 31100 |
+
"sha256": "c3723a3dfaf902f4bc2527b78d11057ab8ba01c6b9715fa873c7dd819deddf81"
|
| 31101 |
},
|
| 31102 |
"hf_artifacts": {
|
| 31103 |
"path": "hf_artifacts:GLOSSARY.md",
|
| 31104 |
"exists": true,
|
| 31105 |
+
"bytes": 10220,
|
| 31106 |
+
"sha256": "c3723a3dfaf902f4bc2527b78d11057ab8ba01c6b9715fa873c7dd819deddf81"
|
| 31107 |
},
|
| 31108 |
"hf_model": {
|
| 31109 |
"path": "hf_model:GLOSSARY.md",
|
| 31110 |
"exists": true,
|
| 31111 |
+
"bytes": 10220,
|
| 31112 |
+
"sha256": "c3723a3dfaf902f4bc2527b78d11057ab8ba01c6b9715fa873c7dd819deddf81"
|
| 31113 |
}
|
| 31114 |
},
|
| 31115 |
"failures": []
|
|
|
|
| 31275 |
"local": {
|
| 31276 |
"path": "repo:PROJECT_BRIEF.md",
|
| 31277 |
"exists": true,
|
| 31278 |
+
"bytes": 4826,
|
| 31279 |
+
"sha256": "3e432c722daca11e1932a8056d73b9debb6f2c52c13d7b21e9871bb2a490d79d"
|
| 31280 |
},
|
| 31281 |
"mirrors": {
|
| 31282 |
"hf_space": {
|
| 31283 |
"path": "hf_space:PROJECT_BRIEF.md",
|
| 31284 |
"exists": true,
|
| 31285 |
+
"bytes": 4826,
|
| 31286 |
+
"sha256": "3e432c722daca11e1932a8056d73b9debb6f2c52c13d7b21e9871bb2a490d79d"
|
| 31287 |
},
|
| 31288 |
"hf_artifacts": {
|
| 31289 |
"path": "hf_artifacts:PROJECT_BRIEF.md",
|
| 31290 |
"exists": true,
|
| 31291 |
+
"bytes": 4826,
|
| 31292 |
+
"sha256": "3e432c722daca11e1932a8056d73b9debb6f2c52c13d7b21e9871bb2a490d79d"
|
| 31293 |
},
|
| 31294 |
"hf_model": {
|
| 31295 |
"path": "hf_model:PROJECT_BRIEF.md",
|
| 31296 |
"exists": true,
|
| 31297 |
+
"bytes": 4826,
|
| 31298 |
+
"sha256": "3e432c722daca11e1932a8056d73b9debb6f2c52c13d7b21e9871bb2a490d79d"
|
| 31299 |
}
|
| 31300 |
},
|
| 31301 |
"failures": []
|
|
|
|
| 31399 |
"local": {
|
| 31400 |
"path": "repo:PROJECT_STATUS.md",
|
| 31401 |
"exists": true,
|
| 31402 |
+
"bytes": 15993,
|
| 31403 |
+
"sha256": "96bf5d894ace804aea2f3889a4d99a802a5e015405e7eed573eb3a98882ce968"
|
| 31404 |
},
|
| 31405 |
"mirrors": {
|
| 31406 |
"hf_space": {
|
| 31407 |
"path": "hf_space:PROJECT_STATUS.md",
|
| 31408 |
"exists": true,
|
| 31409 |
+
"bytes": 15993,
|
| 31410 |
+
"sha256": "96bf5d894ace804aea2f3889a4d99a802a5e015405e7eed573eb3a98882ce968"
|
| 31411 |
},
|
| 31412 |
"hf_artifacts": {
|
| 31413 |
"path": "hf_artifacts:PROJECT_STATUS.md",
|
| 31414 |
"exists": true,
|
| 31415 |
+
"bytes": 15993,
|
| 31416 |
+
"sha256": "96bf5d894ace804aea2f3889a4d99a802a5e015405e7eed573eb3a98882ce968"
|
| 31417 |
},
|
| 31418 |
"hf_model": {
|
| 31419 |
"path": "hf_model:PROJECT_STATUS.md",
|
| 31420 |
"exists": true,
|
| 31421 |
+
"bytes": 15993,
|
| 31422 |
+
"sha256": "96bf5d894ace804aea2f3889a4d99a802a5e015405e7eed573eb3a98882ce968"
|
| 31423 |
}
|
| 31424 |
},
|
| 31425 |
"failures": []
|
|
|
|
| 31430 |
"local": {
|
| 31431 |
"path": "repo:REPRODUCIBILITY.md",
|
| 31432 |
"exists": true,
|
| 31433 |
+
"bytes": 10060,
|
| 31434 |
+
"sha256": "1bea73e024d1a71f08c5d0cb5f26521367ba206ef514ab4b3a1e59269a376139"
|
| 31435 |
},
|
| 31436 |
"mirrors": {
|
| 31437 |
"hf_space": {
|
| 31438 |
"path": "hf_space:REPRODUCIBILITY.md",
|
| 31439 |
"exists": true,
|
| 31440 |
+
"bytes": 10060,
|
| 31441 |
+
"sha256": "1bea73e024d1a71f08c5d0cb5f26521367ba206ef514ab4b3a1e59269a376139"
|
| 31442 |
},
|
| 31443 |
"hf_artifacts": {
|
| 31444 |
"path": "hf_artifacts:REPRODUCIBILITY.md",
|
| 31445 |
"exists": true,
|
| 31446 |
+
"bytes": 10060,
|
| 31447 |
+
"sha256": "1bea73e024d1a71f08c5d0cb5f26521367ba206ef514ab4b3a1e59269a376139"
|
| 31448 |
},
|
| 31449 |
"hf_model": {
|
| 31450 |
"path": "hf_model:REPRODUCIBILITY.md",
|
| 31451 |
"exists": true,
|
| 31452 |
+
"bytes": 10060,
|
| 31453 |
+
"sha256": "1bea73e024d1a71f08c5d0cb5f26521367ba206ef514ab4b3a1e59269a376139"
|
| 31454 |
}
|
| 31455 |
},
|
| 31456 |
"failures": []
|
|
|
|
| 31585 |
"local": {
|
| 31586 |
"path": "repo:TASK_SUITE_20.md",
|
| 31587 |
"exists": true,
|
| 31588 |
+
"bytes": 5196,
|
| 31589 |
+
"sha256": "473891503dcd1251a2cc9a16e6642ce16fbca9d264a734d2397c2afc60977195"
|
| 31590 |
},
|
| 31591 |
"mirrors": {
|
| 31592 |
"hf_space": {
|
| 31593 |
"path": "hf_space:TASK_SUITE_20.md",
|
| 31594 |
"exists": true,
|
| 31595 |
+
"bytes": 5196,
|
| 31596 |
+
"sha256": "473891503dcd1251a2cc9a16e6642ce16fbca9d264a734d2397c2afc60977195"
|
| 31597 |
},
|
| 31598 |
"hf_artifacts": {
|
| 31599 |
"path": "hf_artifacts:TASK_SUITE_20.md",
|
| 31600 |
"exists": true,
|
| 31601 |
+
"bytes": 5196,
|
| 31602 |
+
"sha256": "473891503dcd1251a2cc9a16e6642ce16fbca9d264a734d2397c2afc60977195"
|
| 31603 |
},
|
| 31604 |
"hf_model": {
|
| 31605 |
"path": "hf_model:TASK_SUITE_20.md",
|
| 31606 |
"exists": true,
|
| 31607 |
+
"bytes": 5196,
|
| 31608 |
+
"sha256": "473891503dcd1251a2cc9a16e6642ce16fbca9d264a734d2397c2afc60977195"
|
| 31609 |
}
|
| 31610 |
},
|
| 31611 |
"failures": []
|
docs/data/public_surface_qa.json
CHANGED
|
@@ -1,7 +1,7 @@
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Public Project Surface",
|
| 3 |
"status": "pass",
|
| 4 |
-
"generated_at_utc": "2026-06-21T14:
|
| 5 |
"scope": "Repo README, GitHub Pages HTML, Hugging Face Space card, artifact dataset card, and model card.",
|
| 6 |
"checks": [
|
| 7 |
{
|
|
@@ -18,7 +18,7 @@
|
|
| 18 |
"website_integrity": {
|
| 19 |
"exists": true,
|
| 20 |
"status": "pass",
|
| 21 |
-
"generated_at_utc": "2026-06-
|
| 22 |
},
|
| 23 |
"rendered_site_check": {
|
| 24 |
"exists": true,
|
|
@@ -28,7 +28,7 @@
|
|
| 28 |
"task_surface_integrity": {
|
| 29 |
"exists": true,
|
| 30 |
"status": "pass",
|
| 31 |
-
"generated_at_utc": "2026-06-
|
| 32 |
},
|
| 33 |
"source_alignment": {
|
| 34 |
"exists": true,
|
|
@@ -43,12 +43,12 @@
|
|
| 43 |
"publication_package": {
|
| 44 |
"exists": true,
|
| 45 |
"status": "pass",
|
| 46 |
-
"generated_at_utc": "2026-06-
|
| 47 |
},
|
| 48 |
"mirror_parity": {
|
| 49 |
"exists": true,
|
| 50 |
"status": "pass",
|
| 51 |
-
"generated_at_utc": "2026-06-
|
| 52 |
}
|
| 53 |
},
|
| 54 |
"failures": {}
|
|
@@ -97,7 +97,7 @@
|
|
| 97 |
"marker_counts": {
|
| 98 |
"Ropedia Xperience-10M Task Suite": 20,
|
| 99 |
"Xperience-10M": 167,
|
| 100 |
-
"20-task":
|
| 101 |
"Qwen3-Omni": 245,
|
| 102 |
"128-episode pilot": 1
|
| 103 |
}
|
|
@@ -131,7 +131,7 @@
|
|
| 131 |
"data/public_surface_qa.json": 7,
|
| 132 |
"data/research_roadmap.json": 15,
|
| 133 |
"data/task_suite_enhancement_128.json": 22,
|
| 134 |
-
"data/task_suite_20.json":
|
| 135 |
"data/two_evidence_lines.json": 5,
|
| 136 |
"data/two_evidence_line_result_summary.json": 10,
|
| 137 |
"data/unified_task_model_radar.json": 21,
|
|
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Public Project Surface",
|
| 3 |
"status": "pass",
|
| 4 |
+
"generated_at_utc": "2026-06-21T14:46:49+00:00",
|
| 5 |
"scope": "Repo README, GitHub Pages HTML, Hugging Face Space card, artifact dataset card, and model card.",
|
| 6 |
"checks": [
|
| 7 |
{
|
|
|
|
| 18 |
"website_integrity": {
|
| 19 |
"exists": true,
|
| 20 |
"status": "pass",
|
| 21 |
+
"generated_at_utc": "2026-06-21T14:45:02+00:00"
|
| 22 |
},
|
| 23 |
"rendered_site_check": {
|
| 24 |
"exists": true,
|
|
|
|
| 28 |
"task_surface_integrity": {
|
| 29 |
"exists": true,
|
| 30 |
"status": "pass",
|
| 31 |
+
"generated_at_utc": "2026-06-21T14:45:00+00:00"
|
| 32 |
},
|
| 33 |
"source_alignment": {
|
| 34 |
"exists": true,
|
|
|
|
| 43 |
"publication_package": {
|
| 44 |
"exists": true,
|
| 45 |
"status": "pass",
|
| 46 |
+
"generated_at_utc": "2026-06-21T14:46:11+00:00"
|
| 47 |
},
|
| 48 |
"mirror_parity": {
|
| 49 |
"exists": true,
|
| 50 |
"status": "pass",
|
| 51 |
+
"generated_at_utc": "2026-06-21T14:13:08+00:00"
|
| 52 |
}
|
| 53 |
},
|
| 54 |
"failures": {}
|
|
|
|
| 97 |
"marker_counts": {
|
| 98 |
"Ropedia Xperience-10M Task Suite": 20,
|
| 99 |
"Xperience-10M": 167,
|
| 100 |
+
"20-task": 100,
|
| 101 |
"Qwen3-Omni": 245,
|
| 102 |
"128-episode pilot": 1
|
| 103 |
}
|
|
|
|
| 131 |
"data/public_surface_qa.json": 7,
|
| 132 |
"data/research_roadmap.json": 15,
|
| 133 |
"data/task_suite_enhancement_128.json": 22,
|
| 134 |
+
"data/task_suite_20.json": 36,
|
| 135 |
"data/two_evidence_lines.json": 5,
|
| 136 |
"data/two_evidence_line_result_summary.json": 10,
|
| 137 |
"data/unified_task_model_radar.json": 21,
|
docs/data/publication_audit.json
CHANGED
|
@@ -1,6 +1,6 @@
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
-
"generated_at_utc": "2026-06-
|
| 4 |
"checks": [
|
| 5 |
{
|
| 6 |
"name": "required_publication_assets_present",
|
|
@@ -257,7 +257,7 @@
|
|
| 257 |
"hf_artifact_bundle": {
|
| 258 |
"root": "hf_publish/artifacts",
|
| 259 |
"exists": true,
|
| 260 |
-
"file_count":
|
| 261 |
"text_file_count": 1286,
|
| 262 |
"largest_file": {
|
| 263 |
"path": "results/omni_finetune/xperience10m_128ep_dense_multiscale_hierarchical_v1_20260608/dense_multiscale_windows.jsonl",
|
|
@@ -268,7 +268,7 @@
|
|
| 268 |
"hf_model_bundle": {
|
| 269 |
"root": "hf_publish/model",
|
| 270 |
"exists": true,
|
| 271 |
-
"file_count":
|
| 272 |
"text_file_count": 1459,
|
| 273 |
"largest_file": {
|
| 274 |
"path": "results/omni_finetune/xperience10m_128ep_dense_multiscale_hierarchical_v1_20260608/dense_multiscale_windows.jsonl",
|
|
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
+
"generated_at_utc": "2026-06-21T14:46:11+00:00",
|
| 4 |
"checks": [
|
| 5 |
{
|
| 6 |
"name": "required_publication_assets_present",
|
|
|
|
| 257 |
"hf_artifact_bundle": {
|
| 258 |
"root": "hf_publish/artifacts",
|
| 259 |
"exists": true,
|
| 260 |
+
"file_count": 4528,
|
| 261 |
"text_file_count": 1286,
|
| 262 |
"largest_file": {
|
| 263 |
"path": "results/omni_finetune/xperience10m_128ep_dense_multiscale_hierarchical_v1_20260608/dense_multiscale_windows.jsonl",
|
|
|
|
| 268 |
"hf_model_bundle": {
|
| 269 |
"root": "hf_publish/model",
|
| 270 |
"exists": true,
|
| 271 |
+
"file_count": 5293,
|
| 272 |
"text_file_count": 1459,
|
| 273 |
"largest_file": {
|
| 274 |
"path": "results/omni_finetune/xperience10m_128ep_dense_multiscale_hierarchical_v1_20260608/dense_multiscale_windows.jsonl",
|
docs/data/quality_gates.json
CHANGED
|
@@ -1,7 +1,7 @@
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Release Checks",
|
| 3 |
"status": "pass",
|
| 4 |
-
"generated_at_utc": "2026-06-21T14:
|
| 5 |
"rule": "A release is current when the automated reports pass and the live GitHub/Hugging Face mirrors are verified after publishing.",
|
| 6 |
"automated_gates": [
|
| 7 |
{
|
|
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Release Checks",
|
| 3 |
"status": "pass",
|
| 4 |
+
"generated_at_utc": "2026-06-21T14:46:48+00:00",
|
| 5 |
"rule": "A release is current when the automated reports pass and the live GitHub/Hugging Face mirrors are verified after publishing.",
|
| 6 |
"automated_gates": [
|
| 7 |
{
|
docs/data/scope_claims_audit.json
CHANGED
|
@@ -1,6 +1,6 @@
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
-
"generated_at_utc": "2026-06-
|
| 4 |
"summary": {
|
| 5 |
"qwen3_omni_verified_diagnostic_pilot": true,
|
| 6 |
"dataset_manifest_num_episodes": 119,
|
|
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
+
"generated_at_utc": "2026-06-21T14:47:03+00:00",
|
| 4 |
"summary": {
|
| 5 |
"qwen3_omni_verified_diagnostic_pilot": true,
|
| 6 |
"dataset_manifest_num_episodes": 119,
|
docs/data/source_alignment_audit.json
CHANGED
|
@@ -1,7 +1,7 @@
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Source Alignment Note",
|
| 3 |
"status": "pass",
|
| 4 |
-
"generated_at_utc": "2026-06-
|
| 5 |
"alignment_json": "docs/data/xperience10m_dataset_card_alignment.json",
|
| 6 |
"alignment_summary": {
|
| 7 |
"full_dataset_repo": "ropedia-ai/xperience-10m",
|
|
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Source Alignment Note",
|
| 3 |
"status": "pass",
|
| 4 |
+
"generated_at_utc": "2026-06-21T14:46:49+00:00",
|
| 5 |
"alignment_json": "docs/data/xperience10m_dataset_card_alignment.json",
|
| 6 |
"alignment_summary": {
|
| 7 |
"full_dataset_repo": "ropedia-ai/xperience-10m",
|
docs/data/task_suite_20.json
CHANGED
|
@@ -1,7 +1,7 @@
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Unified 20-Task Suite",
|
| 3 |
"status": "pass",
|
| 4 |
-
"generated_at_utc": "2026-06-
|
| 5 |
"task_count": 20,
|
| 6 |
"task_count_breakdown": {
|
| 7 |
"original_public_sample_tasks": 12,
|
|
@@ -9,7 +9,7 @@
|
|
| 9 |
"total_unified_tasks": 20
|
| 10 |
},
|
| 11 |
"unification_policy": {
|
| 12 |
-
"public_framing": "The suite is presented as one 20-task benchmark surface.
|
| 13 |
"legacy_path_note": "The directory and file name tier2_task_suite are retained only for backward-compatible artifact links; they are not a separate public benchmark tier."
|
| 14 |
},
|
| 15 |
"dataset_scope": {
|
|
|
|
| 1 |
{
|
| 2 |
"title": "Ropedia Xperience-10M Unified 20-Task Suite",
|
| 3 |
"status": "pass",
|
| 4 |
+
"generated_at_utc": "2026-06-21T14:40:33+00:00",
|
| 5 |
"task_count": 20,
|
| 6 |
"task_count_breakdown": {
|
| 7 |
"original_public_sample_tasks": 12,
|
|
|
|
| 9 |
"total_unified_tasks": 20
|
| 10 |
},
|
| 11 |
"unification_policy": {
|
| 12 |
+
"public_framing": "The suite is presented as one 20-task benchmark surface. All task contracts share the same window, split, feature, baseline, and leakage-control language.",
|
| 13 |
"legacy_path_note": "The directory and file name tier2_task_suite are retained only for backward-compatible artifact links; they are not a separate public benchmark tier."
|
| 14 |
},
|
| 15 |
"dataset_scope": {
|
docs/data/task_surface_integrity.json
CHANGED
|
@@ -1,6 +1,6 @@
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
-
"generated_at_utc": "2026-06-
|
| 4 |
"summary": {
|
| 5 |
"original_walkthrough_task_count": 12,
|
| 6 |
"expected_original_walkthrough_task_count": 12,
|
|
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
+
"generated_at_utc": "2026-06-21T14:45:00+00:00",
|
| 4 |
"summary": {
|
| 5 |
"original_walkthrough_task_count": 12,
|
| 6 |
"expected_original_walkthrough_task_count": 12,
|
docs/data/tier2_task_suite.json
CHANGED
|
@@ -1,9 +1,9 @@
|
|
| 1 |
{
|
| 2 |
-
"title": "Ropedia Xperience-10M Unified
|
| 3 |
"status": "pass",
|
| 4 |
"generated_at_utc": "2026-06-16T06:25:58+00:00",
|
| 5 |
"suite_position": "tasks_13_to_20",
|
| 6 |
-
"legacy_path_note": "The tier2_task_suite file and directory names are retained for stable public links;
|
| 7 |
"integrated_with_tasks_1_to_12": {
|
| 8 |
"tasks_1_to_12_count": 12,
|
| 9 |
"additional_task_count": 8,
|
|
|
|
| 1 |
{
|
| 2 |
+
"title": "Ropedia Xperience-10M Unified 20-Task Provenance Bundle",
|
| 3 |
"status": "pass",
|
| 4 |
"generated_at_utc": "2026-06-16T06:25:58+00:00",
|
| 5 |
"suite_position": "tasks_13_to_20",
|
| 6 |
+
"legacy_path_note": "The tier2_task_suite file and directory names are retained for stable public links; this bundle is provenance inside the unified 20-task suite, not a separate public tier.",
|
| 7 |
"integrated_with_tasks_1_to_12": {
|
| 8 |
"tasks_1_to_12_count": 12,
|
| 9 |
"additional_task_count": 8,
|
docs/data/website_integrity.json
CHANGED
|
@@ -1,6 +1,6 @@
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
-
"generated_at_utc": "2026-06-
|
| 4 |
"docs_root": "docs",
|
| 5 |
"site_base": "/ropedia-xperience-10m-task-suite/",
|
| 6 |
"summary": {
|
|
@@ -81,7 +81,7 @@
|
|
| 81 |
"status": "pass",
|
| 82 |
"reason": "The project overview should appear before the deeper progress ledger.",
|
| 83 |
"overview_index": 121816,
|
| 84 |
-
"evidence_index":
|
| 85 |
},
|
| 86 |
{
|
| 87 |
"name": "project_status_links_json",
|
|
@@ -160,8 +160,8 @@
|
|
| 160 |
"status": "pass",
|
| 161 |
"reason": "The evaluation protocol should appear before the deeper evidence ledger.",
|
| 162 |
"overview_index": 121816,
|
| 163 |
-
"protocol_index":
|
| 164 |
-
"evidence_index":
|
| 165 |
},
|
| 166 |
{
|
| 167 |
"name": "evaluation_protocol_links_json",
|
|
@@ -179,8 +179,8 @@
|
|
| 179 |
"name": "suite_task_map_precedes_modality_atlas",
|
| 180 |
"status": "pass",
|
| 181 |
"reason": "The Suite anchor should show the task-suite map before the modality atlas.",
|
| 182 |
-
"first_marker_index":
|
| 183 |
-
"second_marker_index":
|
| 184 |
},
|
| 185 |
{
|
| 186 |
"name": "suite_modality_atlas_contains_seven_cards",
|
|
@@ -301,7 +301,7 @@
|
|
| 301 |
},
|
| 302 |
{
|
| 303 |
"path": "data/artifact_index.json",
|
| 304 |
-
"bytes":
|
| 305 |
"top_level_type": "dict"
|
| 306 |
},
|
| 307 |
{
|
|
@@ -321,7 +321,7 @@
|
|
| 321 |
},
|
| 322 |
{
|
| 323 |
"path": "data/evaluation_protocol.json",
|
| 324 |
-
"bytes":
|
| 325 |
"top_level_type": "dict"
|
| 326 |
},
|
| 327 |
{
|
|
@@ -331,7 +331,7 @@
|
|
| 331 |
},
|
| 332 |
{
|
| 333 |
"path": "data/figure_index.json",
|
| 334 |
-
"bytes":
|
| 335 |
"top_level_type": "dict"
|
| 336 |
},
|
| 337 |
{
|
|
@@ -341,7 +341,7 @@
|
|
| 341 |
},
|
| 342 |
{
|
| 343 |
"path": "data/glossary.json",
|
| 344 |
-
"bytes":
|
| 345 |
"top_level_type": "dict"
|
| 346 |
},
|
| 347 |
{
|
|
@@ -351,7 +351,7 @@
|
|
| 351 |
},
|
| 352 |
{
|
| 353 |
"path": "data/live_publication_status.json",
|
| 354 |
-
"bytes":
|
| 355 |
"top_level_type": "dict"
|
| 356 |
},
|
| 357 |
{
|
|
@@ -511,7 +511,7 @@
|
|
| 511 |
},
|
| 512 |
{
|
| 513 |
"path": "data/task_suite_20.json",
|
| 514 |
-
"bytes":
|
| 515 |
"top_level_type": "dict"
|
| 516 |
},
|
| 517 |
{
|
|
@@ -536,7 +536,7 @@
|
|
| 536 |
},
|
| 537 |
{
|
| 538 |
"path": "data/tier2_task_suite.json",
|
| 539 |
-
"bytes":
|
| 540 |
"top_level_type": "dict"
|
| 541 |
},
|
| 542 |
{
|
|
@@ -659,7 +659,7 @@
|
|
| 659 |
{
|
| 660 |
"path": "assets/charts/tier2_task_suite.svg",
|
| 661 |
"exists": true,
|
| 662 |
-
"bytes":
|
| 663 |
"format": "SVG",
|
| 664 |
"has_viewbox": true
|
| 665 |
},
|
|
@@ -784,7 +784,7 @@
|
|
| 784 |
{
|
| 785 |
"path": "assets/task_suite_infographic.png",
|
| 786 |
"exists": true,
|
| 787 |
-
"bytes":
|
| 788 |
"width": 1800,
|
| 789 |
"height": 7600,
|
| 790 |
"format": "PNG"
|
|
|
|
| 1 |
{
|
| 2 |
"status": "pass",
|
| 3 |
+
"generated_at_utc": "2026-06-21T14:45:02+00:00",
|
| 4 |
"docs_root": "docs",
|
| 5 |
"site_base": "/ropedia-xperience-10m-task-suite/",
|
| 6 |
"summary": {
|
|
|
|
| 81 |
"status": "pass",
|
| 82 |
"reason": "The project overview should appear before the deeper progress ledger.",
|
| 83 |
"overview_index": 121816,
|
| 84 |
+
"evidence_index": 167645
|
| 85 |
},
|
| 86 |
{
|
| 87 |
"name": "project_status_links_json",
|
|
|
|
| 160 |
"status": "pass",
|
| 161 |
"reason": "The evaluation protocol should appear before the deeper evidence ledger.",
|
| 162 |
"overview_index": 121816,
|
| 163 |
+
"protocol_index": 163835,
|
| 164 |
+
"evidence_index": 167645
|
| 165 |
},
|
| 166 |
{
|
| 167 |
"name": "evaluation_protocol_links_json",
|
|
|
|
| 179 |
"name": "suite_task_map_precedes_modality_atlas",
|
| 180 |
"status": "pass",
|
| 181 |
"reason": "The Suite anchor should show the task-suite map before the modality atlas.",
|
| 182 |
+
"first_marker_index": 468,
|
| 183 |
+
"second_marker_index": 3821
|
| 184 |
},
|
| 185 |
{
|
| 186 |
"name": "suite_modality_atlas_contains_seven_cards",
|
|
|
|
| 301 |
},
|
| 302 |
{
|
| 303 |
"path": "data/artifact_index.json",
|
| 304 |
+
"bytes": 124294,
|
| 305 |
"top_level_type": "dict"
|
| 306 |
},
|
| 307 |
{
|
|
|
|
| 321 |
},
|
| 322 |
{
|
| 323 |
"path": "data/evaluation_protocol.json",
|
| 324 |
+
"bytes": 24007,
|
| 325 |
"top_level_type": "dict"
|
| 326 |
},
|
| 327 |
{
|
|
|
|
| 331 |
},
|
| 332 |
{
|
| 333 |
"path": "data/figure_index.json",
|
| 334 |
+
"bytes": 19469,
|
| 335 |
"top_level_type": "dict"
|
| 336 |
},
|
| 337 |
{
|
|
|
|
| 341 |
},
|
| 342 |
{
|
| 343 |
"path": "data/glossary.json",
|
| 344 |
+
"bytes": 17380,
|
| 345 |
"top_level_type": "dict"
|
| 346 |
},
|
| 347 |
{
|
|
|
|
| 351 |
},
|
| 352 |
{
|
| 353 |
"path": "data/live_publication_status.json",
|
| 354 |
+
"bytes": 189922,
|
| 355 |
"top_level_type": "dict"
|
| 356 |
},
|
| 357 |
{
|
|
|
|
| 511 |
},
|
| 512 |
{
|
| 513 |
"path": "data/task_suite_20.json",
|
| 514 |
+
"bytes": 34597,
|
| 515 |
"top_level_type": "dict"
|
| 516 |
},
|
| 517 |
{
|
|
|
|
| 536 |
},
|
| 537 |
{
|
| 538 |
"path": "data/tier2_task_suite.json",
|
| 539 |
+
"bytes": 33411,
|
| 540 |
"top_level_type": "dict"
|
| 541 |
},
|
| 542 |
{
|
|
|
|
| 659 |
{
|
| 660 |
"path": "assets/charts/tier2_task_suite.svg",
|
| 661 |
"exists": true,
|
| 662 |
+
"bytes": 5453,
|
| 663 |
"format": "SVG",
|
| 664 |
"has_viewbox": true
|
| 665 |
},
|
|
|
|
| 784 |
{
|
| 785 |
"path": "assets/task_suite_infographic.png",
|
| 786 |
"exists": true,
|
| 787 |
+
"bytes": 1897278,
|
| 788 |
"width": 1800,
|
| 789 |
"height": 7600,
|
| 790 |
"format": "PNG"
|
docs/index.html
CHANGED
|
@@ -4449,7 +4449,7 @@
|
|
| 4449 |
<ul>
|
| 4450 |
<li>1,161 aligned windows from one public sample episode</li>
|
| 4451 |
<li>20 unified task contracts with minimal and neural evidence</li>
|
| 4452 |
-
<li>
|
| 4453 |
<li>Four research-direction maps and extension probes</li>
|
| 4454 |
</ul>
|
| 4455 |
</article>
|
|
@@ -4513,7 +4513,7 @@
|
|
| 4513 |
<div class="snapshot-meta">
|
| 4514 |
<span>tracks <strong>4</strong></span>
|
| 4515 |
<span>tasks <strong>20</strong></span>
|
| 4516 |
-
<span>
|
| 4517 |
<span>roadmap phases <strong>5</strong></span>
|
| 4518 |
</div>
|
| 4519 |
<div class="snapshot-actions">
|
|
@@ -4534,11 +4534,11 @@
|
|
| 4534 |
<article class="snapshot-card">
|
| 4535 |
<span class="status-pill">verified</span>
|
| 4536 |
<h3>Task suite and baseline heads</h3>
|
| 4537 |
-
<p>The unified task suite has minimal
|
| 4538 |
<div class="snapshot-meta">
|
| 4539 |
<span>tasks <strong>20</strong></span>
|
| 4540 |
-
<span>
|
| 4541 |
-
<span>
|
| 4542 |
</div>
|
| 4543 |
</article>
|
| 4544 |
<article class="snapshot-card">
|
|
@@ -4893,7 +4893,7 @@
|
|
| 4893 |
<article class="evidence-card">
|
| 4894 |
<span class="status-pill">verified</span>
|
| 4895 |
<h3>Figures are indexed</h3>
|
| 4896 |
-
<p>The visual set includes the logo, modality atlas, task-suite figure, unified 20-task model radar, model-architecture figure,
|
| 4897 |
<div class="evidence-links">
|
| 4898 |
<a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/FIGURE_INDEX.md">figure guide</a>
|
| 4899 |
<a href="assets/task_suite_infographic.png">task-suite figure</a>
|
|
@@ -5125,7 +5125,7 @@
|
|
| 5125 |
<div class="wrap">
|
| 5126 |
<div class="section-head">
|
| 5127 |
<h2>Ropedia Xperience-10M Unified 20-Task Suite.</h2>
|
| 5128 |
-
<p>The suite connects synchronized multimodal windows to 20 task contracts
|
| 5129 |
</div>
|
| 5130 |
<div class="figure-pan" id="task-suite-map">
|
| 5131 |
<img class="task-suite-image" src="assets/task_suite_infographic.png?v=xperience10m-taskfirst-v13-modality-xl" alt="Infographic showing Ropedia Xperience-10M task families with enlarged full-width modality cards">
|
|
@@ -5506,13 +5506,13 @@
|
|
| 5506 |
</div>
|
| 5507 |
</section>
|
| 5508 |
|
| 5509 |
-
<section id="extensions" data-project-tab="
|
| 5510 |
<div class="wrap">
|
| 5511 |
<div class="section-head">
|
| 5512 |
-
<h2>
|
| 5513 |
-
<p>
|
| 5514 |
</div>
|
| 5515 |
-
<img class="chart" src="assets/charts/tier2_task_suite.svg?v=xperience10m-tier2" alt="
|
| 5516 |
<div class="extension-grid">
|
| 5517 |
<article class="extension-card">
|
| 5518 |
<span class="status-pill">Task 13 / forecast</span>
|
|
@@ -5573,13 +5573,13 @@
|
|
| 5573 |
</div>
|
| 5574 |
<div class="callout-row">
|
| 5575 |
<div class="callout">
|
| 5576 |
-
<h3>
|
| 5577 |
-
<p>The
|
| 5578 |
-
<p><a href="data/task_suite_20.json">Open unified 20-task JSON</a> · <a href="data/tier2_task_suite.json">
|
| 5579 |
</div>
|
| 5580 |
<div class="callout">
|
| 5581 |
-
<h3>
|
| 5582 |
-
<p>
|
| 5583 |
</div>
|
| 5584 |
</div>
|
| 5585 |
<img class="chart" src="assets/charts/research_direction_extension_tasks.svg?v=xperience10m-ext" alt="Four Xperience-10M research-direction extension probes with minimal and neural metrics">
|
|
@@ -5698,7 +5698,7 @@
|
|
| 5698 |
<div class="wrap">
|
| 5699 |
<div class="section-head">
|
| 5700 |
<h2>Task cards and metrics.</h2>
|
| 5701 |
-
<p>
|
| 5702 |
</div>
|
| 5703 |
<div class="task-toolbar" aria-label="Task filters">
|
| 5704 |
<button class="filter active" data-filter="all">All tasks</button>
|
|
@@ -5860,7 +5860,7 @@
|
|
| 5860 |
<article class="artifact primary-artifact"><div><h3>Task results</h3><p>Every task definition, split detail, feature dimension, and minimal/neural metric in one project output.</p></div><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/results/episode_task_suite/summary_report.json">task results</a></article>
|
| 5861 |
<article class="artifact"><h3>Windows table</h3><p>Window start/end frames and aligned action/subtask labels for the public sample episode.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/results/episode_task_suite/windows.csv">window table</a></article>
|
| 5862 |
<article class="artifact"><h3>Feature inputs</h3><p>Source map for the current modality inputs used by the task suite.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/results/episode_task_suite/feature_manifest.json">feature inputs</a></article>
|
| 5863 |
-
<article class="artifact"><h3>Neural MLP task results</h3><p>Per-task PyTorch MLP metrics, predictions, histories, and checkpoints for the
|
| 5864 |
<article class="artifact"><h3>Four-direction taxonomy</h3><p>Maps the original tasks to the four research tracks: human modeling, 3D/4D reconstruction, egocentric interaction, and world modeling.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/tree/main/results/episode_task_suite/research_directions">research direction outputs</a></article>
|
| 5865 |
<article class="artifact"><h3>Direction extension probes</h3><p>Four coded probes, one per research direction, with minimal and neural metrics plus prediction/rank CSVs.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/tree/main/results/episode_task_suite/research_direction_extensions">extension probe outputs</a></article>
|
| 5866 |
<article class="artifact"><h3>Task walkthroughs</h3><p>Case studies for the original tasks, including input, middle process modules, output, metric, limitation, and task-player data.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/tree/main/results/episode_task_suite/task_walkthroughs">walkthrough outputs</a></article>
|
|
@@ -5962,7 +5962,7 @@
|
|
| 5962 |
<article class="artifact"><h3>Project dashboard</h3><p>The website organizes the dataset sample, tasks, methods, results, directions, and scale-up path in one tabbed reader flow.</p><a href="#artifacts">project materials</a></article>
|
| 5963 |
<article class="artifact"><h3>Line 2 model status</h3><p>The comparison JSON groups selected-128 baselines, Qwen3-Omni v6 LoRA, Cosmos3-Nano Future Window, and Cosmos3-Super Reasoner. Full Qwen v1-v6 detail stays in a separate lineage audit.</p><a href="data/omni_model_comparison.json">comparison</a><a href="data/qwen3_omni_run_lineage.json">Qwen v1-v6</a></article>
|
| 5964 |
</div>
|
| 5965 |
-
<p class="repro-note">Minimal path: install the toolkit dependencies, download the official sample, run the task suite with neural heads, regenerate
|
| 5966 |
<pre class="code-panel"><button type="button" data-copy="setup">Copy</button><code id="setup">git clone https://github.com/Ropedia/HOMIE-toolkit.git
|
| 5967 |
python3.12 -m venv .venv
|
| 5968 |
source .venv/bin/activate
|
|
@@ -6270,7 +6270,7 @@ python scripts/validate_publication_package.py</code></pre>
|
|
| 6270 |
{ id: "models", label: "Minimal Baselines" },
|
| 6271 |
{ id: "neural", label: "Neural Heads" },
|
| 6272 |
{ id: "directions", label: "Four Directions" },
|
| 6273 |
-
{ id: "extensions", label: "
|
| 6274 |
{ id: "diagnostics", label: "Diagnostic Charts" },
|
| 6275 |
{ id: "evidence", label: "Research Progress" },
|
| 6276 |
{ id: "glossary", label: "Glossary" },
|
|
@@ -6296,7 +6296,7 @@ python scripts/validate_publication_package.py</code></pre>
|
|
| 6296 |
models: "Best for minimal baseline evidence.",
|
| 6297 |
neural: "Best for neural MLP task-head comparisons.",
|
| 6298 |
directions: "Best for mapping tasks to spatial, world-model, and VLA directions.",
|
| 6299 |
-
extensions: "Best for
|
| 6300 |
diagnostics: "Best for charts and error-analysis evidence.",
|
| 6301 |
glossary: "Best for terms that can be confused across data, tasks, models, metrics, and public mirrors.",
|
| 6302 |
artifacts: "Best for finding files, mirrors, weights, scripts, and checks.",
|
|
@@ -6642,7 +6642,86 @@ python scripts/validate_publication_package.py</code></pre>
|
|
| 6642 |
return Math.max(4, Math.min(100, value * 100));
|
| 6643 |
};
|
| 6644 |
|
| 6645 |
-
const
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 6646 |
|
| 6647 |
const modalityLabels = (task) => (task.modalities || [])
|
| 6648 |
.map((key) => modalityMeta[key]?.label)
|
|
@@ -6843,9 +6922,13 @@ python scripts/validate_publication_package.py</code></pre>
|
|
| 6843 |
|
| 6844 |
async function initTaskSurface() {
|
| 6845 |
try {
|
| 6846 |
-
const
|
| 6847 |
-
|
| 6848 |
-
|
|
|
|
|
|
|
|
|
|
|
|
|
| 6849 |
renderTaskCards();
|
| 6850 |
renderSelector();
|
| 6851 |
setActiveTask(0);
|
|
|
|
| 4449 |
<ul>
|
| 4450 |
<li>1,161 aligned windows from one public sample episode</li>
|
| 4451 |
<li>20 unified task contracts with minimal and neural evidence</li>
|
| 4452 |
+
<li>One shared setup across all 20 task axes</li>
|
| 4453 |
<li>Four research-direction maps and extension probes</li>
|
| 4454 |
</ul>
|
| 4455 |
</article>
|
|
|
|
| 4513 |
<div class="snapshot-meta">
|
| 4514 |
<span>tracks <strong>4</strong></span>
|
| 4515 |
<span>tasks <strong>20</strong></span>
|
| 4516 |
+
<span>setup <strong>unified</strong></span>
|
| 4517 |
<span>roadmap phases <strong>5</strong></span>
|
| 4518 |
</div>
|
| 4519 |
<div class="snapshot-actions">
|
|
|
|
| 4534 |
<article class="snapshot-card">
|
| 4535 |
<span class="status-pill">verified</span>
|
| 4536 |
<h3>Task suite and baseline heads</h3>
|
| 4537 |
+
<p>The unified task suite has minimal and neural baseline evidence across one 20-axis task surface with shared windows, splits, and label discipline.</p>
|
| 4538 |
<div class="snapshot-meta">
|
| 4539 |
<span>tasks <strong>20</strong></span>
|
| 4540 |
+
<span>minimal heads <strong>20</strong></span>
|
| 4541 |
+
<span>neural heads <strong>20</strong></span>
|
| 4542 |
</div>
|
| 4543 |
</article>
|
| 4544 |
<article class="snapshot-card">
|
|
|
|
| 4893 |
<article class="evidence-card">
|
| 4894 |
<span class="status-pill">verified</span>
|
| 4895 |
<h3>Figures are indexed</h3>
|
| 4896 |
+
<p>The visual set includes the logo, modality atlas, task-suite figure, unified 20-task model radar, model-architecture figure, provenance baseline chart, and Qwen3-Omni LoRA training-flow figure.</p>
|
| 4897 |
<div class="evidence-links">
|
| 4898 |
<a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/FIGURE_INDEX.md">figure guide</a>
|
| 4899 |
<a href="assets/task_suite_infographic.png">task-suite figure</a>
|
|
|
|
| 5125 |
<div class="wrap">
|
| 5126 |
<div class="section-head">
|
| 5127 |
<h2>Ropedia Xperience-10M Unified 20-Task Suite.</h2>
|
| 5128 |
+
<p>The suite connects synchronized multimodal windows to 20 task contracts in one table, one radar surface, and one source-linked result matrix. Historical filenames remain only for stable artifact links.</p>
|
| 5129 |
</div>
|
| 5130 |
<div class="figure-pan" id="task-suite-map">
|
| 5131 |
<img class="task-suite-image" src="assets/task_suite_infographic.png?v=xperience10m-taskfirst-v13-modality-xl" alt="Infographic showing Ropedia Xperience-10M task families with enlarged full-width modality cards">
|
|
|
|
| 5506 |
</div>
|
| 5507 |
</section>
|
| 5508 |
|
| 5509 |
+
<section id="extensions" data-project-tab="data" role="tabpanel" aria-labelledby="tab-data" tabindex="-1">
|
| 5510 |
<div class="wrap">
|
| 5511 |
<div class="section-head">
|
| 5512 |
+
<h2>Unified 20-task evidence and provenance.</h2>
|
| 5513 |
+
<p>All 20 tasks now live in the same task table, task-card grid, radar, and 180-record result matrix. The chart below is retained as provenance for the historically named result bundle, not as a separate task tier.</p>
|
| 5514 |
</div>
|
| 5515 |
+
<img class="chart" src="assets/charts/tier2_task_suite.svg?v=xperience10m-tier2" alt="Historical additional-task provenance chart for the unified Xperience-10M 20-task suite">
|
| 5516 |
<div class="extension-grid">
|
| 5517 |
<article class="extension-card">
|
| 5518 |
<span class="status-pill">Task 13 / forecast</span>
|
|
|
|
| 5573 |
</div>
|
| 5574 |
<div class="callout-row">
|
| 5575 |
<div class="callout">
|
| 5576 |
+
<h3>Unified task artifact package</h3>
|
| 5577 |
+
<p>The public task package has the 20-task JSON, per-task metrics, prediction/rank files, Markdown summaries, and charts generated from the local public-sample annotation and committed shared-window tensor.</p>
|
| 5578 |
+
<p><a href="data/task_suite_20.json">Open unified 20-task JSON</a> · <a href="data/tier2_task_suite.json">Open historical provenance JSON</a></p>
|
| 5579 |
</div>
|
| 5580 |
<div class="callout">
|
| 5581 |
+
<h3>One setup, one task surface</h3>
|
| 5582 |
+
<p>Every task uses the same 20-frame window unit, 5-frame stride, 8,546-dimensional feature manifest, chronological split discipline, and minimal/neural comparison pattern unless a task-specific leakage rule removes target-side features.</p>
|
| 5583 |
</div>
|
| 5584 |
</div>
|
| 5585 |
<img class="chart" src="assets/charts/research_direction_extension_tasks.svg?v=xperience10m-ext" alt="Four Xperience-10M research-direction extension probes with minimal and neural metrics">
|
|
|
|
| 5698 |
<div class="wrap">
|
| 5699 |
<div class="section-head">
|
| 5700 |
<h2>Task cards and metrics.</h2>
|
| 5701 |
+
<p>All 20 task contracts are shown together with readable research names, representative modality thumbnails, explicit input-process-output contracts, and verified minimal versus neural scores. Rich interactive walkthroughs are available for the first 12 task cards; the remaining cards use the same unified task JSON contract.</p>
|
| 5702 |
</div>
|
| 5703 |
<div class="task-toolbar" aria-label="Task filters">
|
| 5704 |
<button class="filter active" data-filter="all">All tasks</button>
|
|
|
|
| 5860 |
<article class="artifact primary-artifact"><div><h3>Task results</h3><p>Every task definition, split detail, feature dimension, and minimal/neural metric in one project output.</p></div><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/results/episode_task_suite/summary_report.json">task results</a></article>
|
| 5861 |
<article class="artifact"><h3>Windows table</h3><p>Window start/end frames and aligned action/subtask labels for the public sample episode.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/results/episode_task_suite/windows.csv">window table</a></article>
|
| 5862 |
<article class="artifact"><h3>Feature inputs</h3><p>Source map for the current modality inputs used by the task suite.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/results/episode_task_suite/feature_manifest.json">feature inputs</a></article>
|
| 5863 |
+
<article class="artifact"><h3>Neural MLP task results</h3><p>Per-task PyTorch MLP metrics, predictions, histories, and checkpoints for the unified task contracts, with historical result-bundle paths retained for provenance.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/tree/main/results/episode_task_suite/neural_mlp">neural MLP outputs</a></article>
|
| 5864 |
<article class="artifact"><h3>Four-direction taxonomy</h3><p>Maps the original tasks to the four research tracks: human modeling, 3D/4D reconstruction, egocentric interaction, and world modeling.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/tree/main/results/episode_task_suite/research_directions">research direction outputs</a></article>
|
| 5865 |
<article class="artifact"><h3>Direction extension probes</h3><p>Four coded probes, one per research direction, with minimal and neural metrics plus prediction/rank CSVs.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/tree/main/results/episode_task_suite/research_direction_extensions">extension probe outputs</a></article>
|
| 5866 |
<article class="artifact"><h3>Task walkthroughs</h3><p>Case studies for the original tasks, including input, middle process modules, output, metric, limitation, and task-player data.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/tree/main/results/episode_task_suite/task_walkthroughs">walkthrough outputs</a></article>
|
|
|
|
| 5962 |
<article class="artifact"><h3>Project dashboard</h3><p>The website organizes the dataset sample, tasks, methods, results, directions, and scale-up path in one tabbed reader flow.</p><a href="#artifacts">project materials</a></article>
|
| 5963 |
<article class="artifact"><h3>Line 2 model status</h3><p>The comparison JSON groups selected-128 baselines, Qwen3-Omni v6 LoRA, Cosmos3-Nano Future Window, and Cosmos3-Super Reasoner. Full Qwen v1-v6 detail stays in a separate lineage audit.</p><a href="data/omni_model_comparison.json">comparison</a><a href="data/qwen3_omni_run_lineage.json">Qwen v1-v6</a></article>
|
| 5964 |
</div>
|
| 5965 |
+
<p class="repro-note">Minimal path: install the toolkit dependencies, download the official sample, run the task suite with neural heads, regenerate the historical provenance bundle, build the unified 20-task index, regenerate visualizations, then rebuild the supporting project reports.</p>
|
| 5966 |
<pre class="code-panel"><button type="button" data-copy="setup">Copy</button><code id="setup">git clone https://github.com/Ropedia/HOMIE-toolkit.git
|
| 5967 |
python3.12 -m venv .venv
|
| 5968 |
source .venv/bin/activate
|
|
|
|
| 6270 |
{ id: "models", label: "Minimal Baselines" },
|
| 6271 |
{ id: "neural", label: "Neural Heads" },
|
| 6272 |
{ id: "directions", label: "Four Directions" },
|
| 6273 |
+
{ id: "extensions", label: "Unified Task Evidence" },
|
| 6274 |
{ id: "diagnostics", label: "Diagnostic Charts" },
|
| 6275 |
{ id: "evidence", label: "Research Progress" },
|
| 6276 |
{ id: "glossary", label: "Glossary" },
|
|
|
|
| 6296 |
models: "Best for minimal baseline evidence.",
|
| 6297 |
neural: "Best for neural MLP task-head comparisons.",
|
| 6298 |
directions: "Best for mapping tasks to spatial, world-model, and VLA directions.",
|
| 6299 |
+
extensions: "Best for historical provenance links inside the unified 20-task surface.",
|
| 6300 |
diagnostics: "Best for charts and error-analysis evidence.",
|
| 6301 |
glossary: "Best for terms that can be confused across data, tasks, models, metrics, and public mirrors.",
|
| 6302 |
artifacts: "Best for finding files, mirrors, weights, scripts, and checks.",
|
|
|
|
| 6642 |
return Math.max(4, Math.min(100, value * 100));
|
| 6643 |
};
|
| 6644 |
|
| 6645 |
+
const normalizeWalkthroughTasks = (payload) => Object.values(payload.tasks || {});
|
| 6646 |
+
const normalizeSuiteTasks = (payload) => Array.isArray(payload.tasks) ? payload.tasks : Object.values(payload.tasks || {});
|
| 6647 |
+
|
| 6648 |
+
const familyFromSuiteTask = (task) => {
|
| 6649 |
+
const id = task.task_id || "";
|
| 6650 |
+
const text = `${id} ${task.task_display_name || ""} ${task.output_short || ""}`.toLowerCase();
|
| 6651 |
+
if (text.includes("retrieval") || text.includes("sync")) return "retrieval";
|
| 6652 |
+
if (text.includes("forecast") || text.includes("future") || text.includes("next") || text.includes("transition regression")) return "forecast";
|
| 6653 |
+
if (text.includes("reconstruction") || text.includes("pose") || text.includes("order") || text.includes("boundary")) return "diagnostic";
|
| 6654 |
+
return "supervised";
|
| 6655 |
+
};
|
| 6656 |
+
|
| 6657 |
+
const modalitiesFromSuiteTask = (task) => {
|
| 6658 |
+
const text = `${task.input || ""} ${task.output || ""} ${task.task_id || ""}`.toLowerCase();
|
| 6659 |
+
const modalities = [];
|
| 6660 |
+
if (text.includes("video") || text.includes("camera") || text.includes("view") || text.includes("fisheye")) modalities.push("video");
|
| 6661 |
+
if (text.includes("audio")) modalities.push("audio");
|
| 6662 |
+
if (text.includes("depth")) modalities.push("depth");
|
| 6663 |
+
if (text.includes("pose") || text.includes("slam")) modalities.push("pose_slam");
|
| 6664 |
+
if (text.includes("hand") || text.includes("body") || text.includes("mocap")) modalities.push("motion_capture");
|
| 6665 |
+
if (text.includes("imu") || text.includes("inertial") || text.includes("gyroscope")) modalities.push("inertial");
|
| 6666 |
+
if (text.includes("language") || text.includes("caption") || text.includes("text") || text.includes("interaction")) modalities.push("language");
|
| 6667 |
+
return modalities.length ? Array.from(new Set(modalities)) : ["video", "motion_capture", "inertial"];
|
| 6668 |
+
};
|
| 6669 |
+
|
| 6670 |
+
const synthesizeTaskCard = (task) => {
|
| 6671 |
+
const modalities = modalitiesFromSuiteTask(task);
|
| 6672 |
+
const family = familyFromSuiteTask(task);
|
| 6673 |
+
return {
|
| 6674 |
+
display_name: task.task_display_name || task.task_id || "Task",
|
| 6675 |
+
research_name: `${task.suite_label || "Task"} · ${task.research_name || task.primary_direction || "Unified task contract"}`,
|
| 6676 |
+
task_family: family,
|
| 6677 |
+
architecture_family: task.architecture_family || task.family || "task head",
|
| 6678 |
+
poster_modality: modalities[0] || "video",
|
| 6679 |
+
modalities,
|
| 6680 |
+
card_blurb: task.meaning || "A source-linked task contract in the unified 20-task suite.",
|
| 6681 |
+
case_study: task.meaning || "This task is defined by the unified 20-task JSON contract.",
|
| 6682 |
+
input_short: task.input_short || task.input || "20-frame multimodal window",
|
| 6683 |
+
process_short: task.process || "shared window features -> task-specific head",
|
| 6684 |
+
output_short: task.output_short || task.output || "task target",
|
| 6685 |
+
middle_modules: [
|
| 6686 |
+
task.process || "Build the task target from the shared window table.",
|
| 6687 |
+
`Metric: ${task.metric_name || task.metric_key || "primary metric"}.`,
|
| 6688 |
+
`Source: ${(task.artifact_sources && (task.artifact_sources.minimal_metrics || task.artifact_sources.walkthrough || task.artifact_sources.legacy_result_directory)) || "docs/data/task_suite_20.json"}.`
|
| 6689 |
+
],
|
| 6690 |
+
metric: {
|
| 6691 |
+
name: task.metric_name || task.metric_key || "metric",
|
| 6692 |
+
direction: task.metric_direction || "higher",
|
| 6693 |
+
minimal: task.minimal_primary_metric,
|
| 6694 |
+
neural_mlp: task.neural_primary_metric
|
| 6695 |
+
},
|
| 6696 |
+
failure_mode: "single-episode chronological split; read the 180-record matrix for selected-128 method comparisons"
|
| 6697 |
+
};
|
| 6698 |
+
};
|
| 6699 |
+
|
| 6700 |
+
const mergeUnifiedTaskCards = (walkthroughPayload, suitePayload) => {
|
| 6701 |
+
const walkthroughTasks = normalizeWalkthroughTasks(walkthroughPayload);
|
| 6702 |
+
const walkthroughById = Object.fromEntries(
|
| 6703 |
+
walkthroughTasks.map((task) => [task.task_id || task.artifact_id || task.display_name, task])
|
| 6704 |
+
);
|
| 6705 |
+
const suiteTasks = normalizeSuiteTasks(suitePayload);
|
| 6706 |
+
return suiteTasks.map((task) => {
|
| 6707 |
+
const rich = walkthroughById[task.task_id];
|
| 6708 |
+
if (rich) {
|
| 6709 |
+
return {
|
| 6710 |
+
...rich,
|
| 6711 |
+
display_name: task.task_display_name || rich.display_name,
|
| 6712 |
+
research_name: `${task.suite_label || ""} · ${rich.research_name || task.research_name || ""}`.replace(/^ · /, ""),
|
| 6713 |
+
metric: {
|
| 6714 |
+
...(rich.metric || {}),
|
| 6715 |
+
name: task.metric_name || rich.metric?.name,
|
| 6716 |
+
direction: task.metric_direction || rich.metric?.direction,
|
| 6717 |
+
minimal: task.minimal_primary_metric ?? rich.metric?.minimal,
|
| 6718 |
+
neural_mlp: task.neural_primary_metric ?? rich.metric?.neural_mlp
|
| 6719 |
+
}
|
| 6720 |
+
};
|
| 6721 |
+
}
|
| 6722 |
+
return synthesizeTaskCard(task);
|
| 6723 |
+
});
|
| 6724 |
+
};
|
| 6725 |
|
| 6726 |
const modalityLabels = (task) => (task.modalities || [])
|
| 6727 |
.map((key) => modalityMeta[key]?.label)
|
|
|
|
| 6922 |
|
| 6923 |
async function initTaskSurface() {
|
| 6924 |
try {
|
| 6925 |
+
const [walkthroughResponse, suiteResponse] = await Promise.all([
|
| 6926 |
+
fetch("data/task_walkthroughs.json", { cache: "no-cache" }),
|
| 6927 |
+
fetch("data/task_suite_20.json", { cache: "no-cache" })
|
| 6928 |
+
]);
|
| 6929 |
+
if (!walkthroughResponse.ok) throw new Error(`walkthrough data ${walkthroughResponse.status}`);
|
| 6930 |
+
if (!suiteResponse.ok) throw new Error(`suite data ${suiteResponse.status}`);
|
| 6931 |
+
taskEntries = mergeUnifiedTaskCards(await walkthroughResponse.json(), await suiteResponse.json());
|
| 6932 |
renderTaskCards();
|
| 6933 |
renderSelector();
|
| 6934 |
setActiveTask(0);
|
index.html
CHANGED
|
@@ -4449,7 +4449,7 @@
|
|
| 4449 |
<ul>
|
| 4450 |
<li>1,161 aligned windows from one public sample episode</li>
|
| 4451 |
<li>20 unified task contracts with minimal and neural evidence</li>
|
| 4452 |
-
<li>
|
| 4453 |
<li>Four research-direction maps and extension probes</li>
|
| 4454 |
</ul>
|
| 4455 |
</article>
|
|
@@ -4513,7 +4513,7 @@
|
|
| 4513 |
<div class="snapshot-meta">
|
| 4514 |
<span>tracks <strong>4</strong></span>
|
| 4515 |
<span>tasks <strong>20</strong></span>
|
| 4516 |
-
<span>
|
| 4517 |
<span>roadmap phases <strong>5</strong></span>
|
| 4518 |
</div>
|
| 4519 |
<div class="snapshot-actions">
|
|
@@ -4534,11 +4534,11 @@
|
|
| 4534 |
<article class="snapshot-card">
|
| 4535 |
<span class="status-pill">verified</span>
|
| 4536 |
<h3>Task suite and baseline heads</h3>
|
| 4537 |
-
<p>The unified task suite has minimal
|
| 4538 |
<div class="snapshot-meta">
|
| 4539 |
<span>tasks <strong>20</strong></span>
|
| 4540 |
-
<span>
|
| 4541 |
-
<span>
|
| 4542 |
</div>
|
| 4543 |
</article>
|
| 4544 |
<article class="snapshot-card">
|
|
@@ -4893,7 +4893,7 @@
|
|
| 4893 |
<article class="evidence-card">
|
| 4894 |
<span class="status-pill">verified</span>
|
| 4895 |
<h3>Figures are indexed</h3>
|
| 4896 |
-
<p>The visual set includes the logo, modality atlas, task-suite figure, unified 20-task model radar, model-architecture figure,
|
| 4897 |
<div class="evidence-links">
|
| 4898 |
<a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/FIGURE_INDEX.md">figure guide</a>
|
| 4899 |
<a href="assets/task_suite_infographic.png">task-suite figure</a>
|
|
@@ -5125,7 +5125,7 @@
|
|
| 5125 |
<div class="wrap">
|
| 5126 |
<div class="section-head">
|
| 5127 |
<h2>Ropedia Xperience-10M Unified 20-Task Suite.</h2>
|
| 5128 |
-
<p>The suite connects synchronized multimodal windows to 20 task contracts
|
| 5129 |
</div>
|
| 5130 |
<div class="figure-pan" id="task-suite-map">
|
| 5131 |
<img class="task-suite-image" src="assets/task_suite_infographic.png?v=xperience10m-taskfirst-v13-modality-xl" alt="Infographic showing Ropedia Xperience-10M task families with enlarged full-width modality cards">
|
|
@@ -5506,13 +5506,13 @@
|
|
| 5506 |
</div>
|
| 5507 |
</section>
|
| 5508 |
|
| 5509 |
-
<section id="extensions" data-project-tab="
|
| 5510 |
<div class="wrap">
|
| 5511 |
<div class="section-head">
|
| 5512 |
-
<h2>
|
| 5513 |
-
<p>
|
| 5514 |
</div>
|
| 5515 |
-
<img class="chart" src="assets/charts/tier2_task_suite.svg?v=xperience10m-tier2" alt="
|
| 5516 |
<div class="extension-grid">
|
| 5517 |
<article class="extension-card">
|
| 5518 |
<span class="status-pill">Task 13 / forecast</span>
|
|
@@ -5573,13 +5573,13 @@
|
|
| 5573 |
</div>
|
| 5574 |
<div class="callout-row">
|
| 5575 |
<div class="callout">
|
| 5576 |
-
<h3>
|
| 5577 |
-
<p>The
|
| 5578 |
-
<p><a href="data/task_suite_20.json">Open unified 20-task JSON</a> · <a href="data/tier2_task_suite.json">
|
| 5579 |
</div>
|
| 5580 |
<div class="callout">
|
| 5581 |
-
<h3>
|
| 5582 |
-
<p>
|
| 5583 |
</div>
|
| 5584 |
</div>
|
| 5585 |
<img class="chart" src="assets/charts/research_direction_extension_tasks.svg?v=xperience10m-ext" alt="Four Xperience-10M research-direction extension probes with minimal and neural metrics">
|
|
@@ -5698,7 +5698,7 @@
|
|
| 5698 |
<div class="wrap">
|
| 5699 |
<div class="section-head">
|
| 5700 |
<h2>Task cards and metrics.</h2>
|
| 5701 |
-
<p>
|
| 5702 |
</div>
|
| 5703 |
<div class="task-toolbar" aria-label="Task filters">
|
| 5704 |
<button class="filter active" data-filter="all">All tasks</button>
|
|
@@ -5860,7 +5860,7 @@
|
|
| 5860 |
<article class="artifact primary-artifact"><div><h3>Task results</h3><p>Every task definition, split detail, feature dimension, and minimal/neural metric in one project output.</p></div><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/results/episode_task_suite/summary_report.json">task results</a></article>
|
| 5861 |
<article class="artifact"><h3>Windows table</h3><p>Window start/end frames and aligned action/subtask labels for the public sample episode.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/results/episode_task_suite/windows.csv">window table</a></article>
|
| 5862 |
<article class="artifact"><h3>Feature inputs</h3><p>Source map for the current modality inputs used by the task suite.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/results/episode_task_suite/feature_manifest.json">feature inputs</a></article>
|
| 5863 |
-
<article class="artifact"><h3>Neural MLP task results</h3><p>Per-task PyTorch MLP metrics, predictions, histories, and checkpoints for the
|
| 5864 |
<article class="artifact"><h3>Four-direction taxonomy</h3><p>Maps the original tasks to the four research tracks: human modeling, 3D/4D reconstruction, egocentric interaction, and world modeling.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/tree/main/results/episode_task_suite/research_directions">research direction outputs</a></article>
|
| 5865 |
<article class="artifact"><h3>Direction extension probes</h3><p>Four coded probes, one per research direction, with minimal and neural metrics plus prediction/rank CSVs.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/tree/main/results/episode_task_suite/research_direction_extensions">extension probe outputs</a></article>
|
| 5866 |
<article class="artifact"><h3>Task walkthroughs</h3><p>Case studies for the original tasks, including input, middle process modules, output, metric, limitation, and task-player data.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/tree/main/results/episode_task_suite/task_walkthroughs">walkthrough outputs</a></article>
|
|
@@ -5962,7 +5962,7 @@
|
|
| 5962 |
<article class="artifact"><h3>Project dashboard</h3><p>The website organizes the dataset sample, tasks, methods, results, directions, and scale-up path in one tabbed reader flow.</p><a href="#artifacts">project materials</a></article>
|
| 5963 |
<article class="artifact"><h3>Line 2 model status</h3><p>The comparison JSON groups selected-128 baselines, Qwen3-Omni v6 LoRA, Cosmos3-Nano Future Window, and Cosmos3-Super Reasoner. Full Qwen v1-v6 detail stays in a separate lineage audit.</p><a href="data/omni_model_comparison.json">comparison</a><a href="data/qwen3_omni_run_lineage.json">Qwen v1-v6</a></article>
|
| 5964 |
</div>
|
| 5965 |
-
<p class="repro-note">Minimal path: install the toolkit dependencies, download the official sample, run the task suite with neural heads, regenerate
|
| 5966 |
<pre class="code-panel"><button type="button" data-copy="setup">Copy</button><code id="setup">git clone https://github.com/Ropedia/HOMIE-toolkit.git
|
| 5967 |
python3.12 -m venv .venv
|
| 5968 |
source .venv/bin/activate
|
|
@@ -6270,7 +6270,7 @@ python scripts/validate_publication_package.py</code></pre>
|
|
| 6270 |
{ id: "models", label: "Minimal Baselines" },
|
| 6271 |
{ id: "neural", label: "Neural Heads" },
|
| 6272 |
{ id: "directions", label: "Four Directions" },
|
| 6273 |
-
{ id: "extensions", label: "
|
| 6274 |
{ id: "diagnostics", label: "Diagnostic Charts" },
|
| 6275 |
{ id: "evidence", label: "Research Progress" },
|
| 6276 |
{ id: "glossary", label: "Glossary" },
|
|
@@ -6296,7 +6296,7 @@ python scripts/validate_publication_package.py</code></pre>
|
|
| 6296 |
models: "Best for minimal baseline evidence.",
|
| 6297 |
neural: "Best for neural MLP task-head comparisons.",
|
| 6298 |
directions: "Best for mapping tasks to spatial, world-model, and VLA directions.",
|
| 6299 |
-
extensions: "Best for
|
| 6300 |
diagnostics: "Best for charts and error-analysis evidence.",
|
| 6301 |
glossary: "Best for terms that can be confused across data, tasks, models, metrics, and public mirrors.",
|
| 6302 |
artifacts: "Best for finding files, mirrors, weights, scripts, and checks.",
|
|
@@ -6642,7 +6642,86 @@ python scripts/validate_publication_package.py</code></pre>
|
|
| 6642 |
return Math.max(4, Math.min(100, value * 100));
|
| 6643 |
};
|
| 6644 |
|
| 6645 |
-
const
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 6646 |
|
| 6647 |
const modalityLabels = (task) => (task.modalities || [])
|
| 6648 |
.map((key) => modalityMeta[key]?.label)
|
|
@@ -6843,9 +6922,13 @@ python scripts/validate_publication_package.py</code></pre>
|
|
| 6843 |
|
| 6844 |
async function initTaskSurface() {
|
| 6845 |
try {
|
| 6846 |
-
const
|
| 6847 |
-
|
| 6848 |
-
|
|
|
|
|
|
|
|
|
|
|
|
|
| 6849 |
renderTaskCards();
|
| 6850 |
renderSelector();
|
| 6851 |
setActiveTask(0);
|
|
|
|
| 4449 |
<ul>
|
| 4450 |
<li>1,161 aligned windows from one public sample episode</li>
|
| 4451 |
<li>20 unified task contracts with minimal and neural evidence</li>
|
| 4452 |
+
<li>One shared setup across all 20 task axes</li>
|
| 4453 |
<li>Four research-direction maps and extension probes</li>
|
| 4454 |
</ul>
|
| 4455 |
</article>
|
|
|
|
| 4513 |
<div class="snapshot-meta">
|
| 4514 |
<span>tracks <strong>4</strong></span>
|
| 4515 |
<span>tasks <strong>20</strong></span>
|
| 4516 |
+
<span>setup <strong>unified</strong></span>
|
| 4517 |
<span>roadmap phases <strong>5</strong></span>
|
| 4518 |
</div>
|
| 4519 |
<div class="snapshot-actions">
|
|
|
|
| 4534 |
<article class="snapshot-card">
|
| 4535 |
<span class="status-pill">verified</span>
|
| 4536 |
<h3>Task suite and baseline heads</h3>
|
| 4537 |
+
<p>The unified task suite has minimal and neural baseline evidence across one 20-axis task surface with shared windows, splits, and label discipline.</p>
|
| 4538 |
<div class="snapshot-meta">
|
| 4539 |
<span>tasks <strong>20</strong></span>
|
| 4540 |
+
<span>minimal heads <strong>20</strong></span>
|
| 4541 |
+
<span>neural heads <strong>20</strong></span>
|
| 4542 |
</div>
|
| 4543 |
</article>
|
| 4544 |
<article class="snapshot-card">
|
|
|
|
| 4893 |
<article class="evidence-card">
|
| 4894 |
<span class="status-pill">verified</span>
|
| 4895 |
<h3>Figures are indexed</h3>
|
| 4896 |
+
<p>The visual set includes the logo, modality atlas, task-suite figure, unified 20-task model radar, model-architecture figure, provenance baseline chart, and Qwen3-Omni LoRA training-flow figure.</p>
|
| 4897 |
<div class="evidence-links">
|
| 4898 |
<a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/FIGURE_INDEX.md">figure guide</a>
|
| 4899 |
<a href="assets/task_suite_infographic.png">task-suite figure</a>
|
|
|
|
| 5125 |
<div class="wrap">
|
| 5126 |
<div class="section-head">
|
| 5127 |
<h2>Ropedia Xperience-10M Unified 20-Task Suite.</h2>
|
| 5128 |
+
<p>The suite connects synchronized multimodal windows to 20 task contracts in one table, one radar surface, and one source-linked result matrix. Historical filenames remain only for stable artifact links.</p>
|
| 5129 |
</div>
|
| 5130 |
<div class="figure-pan" id="task-suite-map">
|
| 5131 |
<img class="task-suite-image" src="assets/task_suite_infographic.png?v=xperience10m-taskfirst-v13-modality-xl" alt="Infographic showing Ropedia Xperience-10M task families with enlarged full-width modality cards">
|
|
|
|
| 5506 |
</div>
|
| 5507 |
</section>
|
| 5508 |
|
| 5509 |
+
<section id="extensions" data-project-tab="data" role="tabpanel" aria-labelledby="tab-data" tabindex="-1">
|
| 5510 |
<div class="wrap">
|
| 5511 |
<div class="section-head">
|
| 5512 |
+
<h2>Unified 20-task evidence and provenance.</h2>
|
| 5513 |
+
<p>All 20 tasks now live in the same task table, task-card grid, radar, and 180-record result matrix. The chart below is retained as provenance for the historically named result bundle, not as a separate task tier.</p>
|
| 5514 |
</div>
|
| 5515 |
+
<img class="chart" src="assets/charts/tier2_task_suite.svg?v=xperience10m-tier2" alt="Historical additional-task provenance chart for the unified Xperience-10M 20-task suite">
|
| 5516 |
<div class="extension-grid">
|
| 5517 |
<article class="extension-card">
|
| 5518 |
<span class="status-pill">Task 13 / forecast</span>
|
|
|
|
| 5573 |
</div>
|
| 5574 |
<div class="callout-row">
|
| 5575 |
<div class="callout">
|
| 5576 |
+
<h3>Unified task artifact package</h3>
|
| 5577 |
+
<p>The public task package has the 20-task JSON, per-task metrics, prediction/rank files, Markdown summaries, and charts generated from the local public-sample annotation and committed shared-window tensor.</p>
|
| 5578 |
+
<p><a href="data/task_suite_20.json">Open unified 20-task JSON</a> · <a href="data/tier2_task_suite.json">Open historical provenance JSON</a></p>
|
| 5579 |
</div>
|
| 5580 |
<div class="callout">
|
| 5581 |
+
<h3>One setup, one task surface</h3>
|
| 5582 |
+
<p>Every task uses the same 20-frame window unit, 5-frame stride, 8,546-dimensional feature manifest, chronological split discipline, and minimal/neural comparison pattern unless a task-specific leakage rule removes target-side features.</p>
|
| 5583 |
</div>
|
| 5584 |
</div>
|
| 5585 |
<img class="chart" src="assets/charts/research_direction_extension_tasks.svg?v=xperience10m-ext" alt="Four Xperience-10M research-direction extension probes with minimal and neural metrics">
|
|
|
|
| 5698 |
<div class="wrap">
|
| 5699 |
<div class="section-head">
|
| 5700 |
<h2>Task cards and metrics.</h2>
|
| 5701 |
+
<p>All 20 task contracts are shown together with readable research names, representative modality thumbnails, explicit input-process-output contracts, and verified minimal versus neural scores. Rich interactive walkthroughs are available for the first 12 task cards; the remaining cards use the same unified task JSON contract.</p>
|
| 5702 |
</div>
|
| 5703 |
<div class="task-toolbar" aria-label="Task filters">
|
| 5704 |
<button class="filter active" data-filter="all">All tasks</button>
|
|
|
|
| 5860 |
<article class="artifact primary-artifact"><div><h3>Task results</h3><p>Every task definition, split detail, feature dimension, and minimal/neural metric in one project output.</p></div><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/results/episode_task_suite/summary_report.json">task results</a></article>
|
| 5861 |
<article class="artifact"><h3>Windows table</h3><p>Window start/end frames and aligned action/subtask labels for the public sample episode.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/results/episode_task_suite/windows.csv">window table</a></article>
|
| 5862 |
<article class="artifact"><h3>Feature inputs</h3><p>Source map for the current modality inputs used by the task suite.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/blob/main/results/episode_task_suite/feature_manifest.json">feature inputs</a></article>
|
| 5863 |
+
<article class="artifact"><h3>Neural MLP task results</h3><p>Per-task PyTorch MLP metrics, predictions, histories, and checkpoints for the unified task contracts, with historical result-bundle paths retained for provenance.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/tree/main/results/episode_task_suite/neural_mlp">neural MLP outputs</a></article>
|
| 5864 |
<article class="artifact"><h3>Four-direction taxonomy</h3><p>Maps the original tasks to the four research tracks: human modeling, 3D/4D reconstruction, egocentric interaction, and world modeling.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/tree/main/results/episode_task_suite/research_directions">research direction outputs</a></article>
|
| 5865 |
<article class="artifact"><h3>Direction extension probes</h3><p>Four coded probes, one per research direction, with minimal and neural metrics plus prediction/rank CSVs.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/tree/main/results/episode_task_suite/research_direction_extensions">extension probe outputs</a></article>
|
| 5866 |
<article class="artifact"><h3>Task walkthroughs</h3><p>Case studies for the original tasks, including input, middle process modules, output, metric, limitation, and task-player data.</p><a href="https://github.com/ChaoYue0307/ropedia-xperience-10m-task-suite/tree/main/results/episode_task_suite/task_walkthroughs">walkthrough outputs</a></article>
|
|
|
|
| 5962 |
<article class="artifact"><h3>Project dashboard</h3><p>The website organizes the dataset sample, tasks, methods, results, directions, and scale-up path in one tabbed reader flow.</p><a href="#artifacts">project materials</a></article>
|
| 5963 |
<article class="artifact"><h3>Line 2 model status</h3><p>The comparison JSON groups selected-128 baselines, Qwen3-Omni v6 LoRA, Cosmos3-Nano Future Window, and Cosmos3-Super Reasoner. Full Qwen v1-v6 detail stays in a separate lineage audit.</p><a href="data/omni_model_comparison.json">comparison</a><a href="data/qwen3_omni_run_lineage.json">Qwen v1-v6</a></article>
|
| 5964 |
</div>
|
| 5965 |
+
<p class="repro-note">Minimal path: install the toolkit dependencies, download the official sample, run the task suite with neural heads, regenerate the historical provenance bundle, build the unified 20-task index, regenerate visualizations, then rebuild the supporting project reports.</p>
|
| 5966 |
<pre class="code-panel"><button type="button" data-copy="setup">Copy</button><code id="setup">git clone https://github.com/Ropedia/HOMIE-toolkit.git
|
| 5967 |
python3.12 -m venv .venv
|
| 5968 |
source .venv/bin/activate
|
|
|
|
| 6270 |
{ id: "models", label: "Minimal Baselines" },
|
| 6271 |
{ id: "neural", label: "Neural Heads" },
|
| 6272 |
{ id: "directions", label: "Four Directions" },
|
| 6273 |
+
{ id: "extensions", label: "Unified Task Evidence" },
|
| 6274 |
{ id: "diagnostics", label: "Diagnostic Charts" },
|
| 6275 |
{ id: "evidence", label: "Research Progress" },
|
| 6276 |
{ id: "glossary", label: "Glossary" },
|
|
|
|
| 6296 |
models: "Best for minimal baseline evidence.",
|
| 6297 |
neural: "Best for neural MLP task-head comparisons.",
|
| 6298 |
directions: "Best for mapping tasks to spatial, world-model, and VLA directions.",
|
| 6299 |
+
extensions: "Best for historical provenance links inside the unified 20-task surface.",
|
| 6300 |
diagnostics: "Best for charts and error-analysis evidence.",
|
| 6301 |
glossary: "Best for terms that can be confused across data, tasks, models, metrics, and public mirrors.",
|
| 6302 |
artifacts: "Best for finding files, mirrors, weights, scripts, and checks.",
|
|
|
|
| 6642 |
return Math.max(4, Math.min(100, value * 100));
|
| 6643 |
};
|
| 6644 |
|
| 6645 |
+
const normalizeWalkthroughTasks = (payload) => Object.values(payload.tasks || {});
|
| 6646 |
+
const normalizeSuiteTasks = (payload) => Array.isArray(payload.tasks) ? payload.tasks : Object.values(payload.tasks || {});
|
| 6647 |
+
|
| 6648 |
+
const familyFromSuiteTask = (task) => {
|
| 6649 |
+
const id = task.task_id || "";
|
| 6650 |
+
const text = `${id} ${task.task_display_name || ""} ${task.output_short || ""}`.toLowerCase();
|
| 6651 |
+
if (text.includes("retrieval") || text.includes("sync")) return "retrieval";
|
| 6652 |
+
if (text.includes("forecast") || text.includes("future") || text.includes("next") || text.includes("transition regression")) return "forecast";
|
| 6653 |
+
if (text.includes("reconstruction") || text.includes("pose") || text.includes("order") || text.includes("boundary")) return "diagnostic";
|
| 6654 |
+
return "supervised";
|
| 6655 |
+
};
|
| 6656 |
+
|
| 6657 |
+
const modalitiesFromSuiteTask = (task) => {
|
| 6658 |
+
const text = `${task.input || ""} ${task.output || ""} ${task.task_id || ""}`.toLowerCase();
|
| 6659 |
+
const modalities = [];
|
| 6660 |
+
if (text.includes("video") || text.includes("camera") || text.includes("view") || text.includes("fisheye")) modalities.push("video");
|
| 6661 |
+
if (text.includes("audio")) modalities.push("audio");
|
| 6662 |
+
if (text.includes("depth")) modalities.push("depth");
|
| 6663 |
+
if (text.includes("pose") || text.includes("slam")) modalities.push("pose_slam");
|
| 6664 |
+
if (text.includes("hand") || text.includes("body") || text.includes("mocap")) modalities.push("motion_capture");
|
| 6665 |
+
if (text.includes("imu") || text.includes("inertial") || text.includes("gyroscope")) modalities.push("inertial");
|
| 6666 |
+
if (text.includes("language") || text.includes("caption") || text.includes("text") || text.includes("interaction")) modalities.push("language");
|
| 6667 |
+
return modalities.length ? Array.from(new Set(modalities)) : ["video", "motion_capture", "inertial"];
|
| 6668 |
+
};
|
| 6669 |
+
|
| 6670 |
+
const synthesizeTaskCard = (task) => {
|
| 6671 |
+
const modalities = modalitiesFromSuiteTask(task);
|
| 6672 |
+
const family = familyFromSuiteTask(task);
|
| 6673 |
+
return {
|
| 6674 |
+
display_name: task.task_display_name || task.task_id || "Task",
|
| 6675 |
+
research_name: `${task.suite_label || "Task"} · ${task.research_name || task.primary_direction || "Unified task contract"}`,
|
| 6676 |
+
task_family: family,
|
| 6677 |
+
architecture_family: task.architecture_family || task.family || "task head",
|
| 6678 |
+
poster_modality: modalities[0] || "video",
|
| 6679 |
+
modalities,
|
| 6680 |
+
card_blurb: task.meaning || "A source-linked task contract in the unified 20-task suite.",
|
| 6681 |
+
case_study: task.meaning || "This task is defined by the unified 20-task JSON contract.",
|
| 6682 |
+
input_short: task.input_short || task.input || "20-frame multimodal window",
|
| 6683 |
+
process_short: task.process || "shared window features -> task-specific head",
|
| 6684 |
+
output_short: task.output_short || task.output || "task target",
|
| 6685 |
+
middle_modules: [
|
| 6686 |
+
task.process || "Build the task target from the shared window table.",
|
| 6687 |
+
`Metric: ${task.metric_name || task.metric_key || "primary metric"}.`,
|
| 6688 |
+
`Source: ${(task.artifact_sources && (task.artifact_sources.minimal_metrics || task.artifact_sources.walkthrough || task.artifact_sources.legacy_result_directory)) || "docs/data/task_suite_20.json"}.`
|
| 6689 |
+
],
|
| 6690 |
+
metric: {
|
| 6691 |
+
name: task.metric_name || task.metric_key || "metric",
|
| 6692 |
+
direction: task.metric_direction || "higher",
|
| 6693 |
+
minimal: task.minimal_primary_metric,
|
| 6694 |
+
neural_mlp: task.neural_primary_metric
|
| 6695 |
+
},
|
| 6696 |
+
failure_mode: "single-episode chronological split; read the 180-record matrix for selected-128 method comparisons"
|
| 6697 |
+
};
|
| 6698 |
+
};
|
| 6699 |
+
|
| 6700 |
+
const mergeUnifiedTaskCards = (walkthroughPayload, suitePayload) => {
|
| 6701 |
+
const walkthroughTasks = normalizeWalkthroughTasks(walkthroughPayload);
|
| 6702 |
+
const walkthroughById = Object.fromEntries(
|
| 6703 |
+
walkthroughTasks.map((task) => [task.task_id || task.artifact_id || task.display_name, task])
|
| 6704 |
+
);
|
| 6705 |
+
const suiteTasks = normalizeSuiteTasks(suitePayload);
|
| 6706 |
+
return suiteTasks.map((task) => {
|
| 6707 |
+
const rich = walkthroughById[task.task_id];
|
| 6708 |
+
if (rich) {
|
| 6709 |
+
return {
|
| 6710 |
+
...rich,
|
| 6711 |
+
display_name: task.task_display_name || rich.display_name,
|
| 6712 |
+
research_name: `${task.suite_label || ""} · ${rich.research_name || task.research_name || ""}`.replace(/^ · /, ""),
|
| 6713 |
+
metric: {
|
| 6714 |
+
...(rich.metric || {}),
|
| 6715 |
+
name: task.metric_name || rich.metric?.name,
|
| 6716 |
+
direction: task.metric_direction || rich.metric?.direction,
|
| 6717 |
+
minimal: task.minimal_primary_metric ?? rich.metric?.minimal,
|
| 6718 |
+
neural_mlp: task.neural_primary_metric ?? rich.metric?.neural_mlp
|
| 6719 |
+
}
|
| 6720 |
+
};
|
| 6721 |
+
}
|
| 6722 |
+
return synthesizeTaskCard(task);
|
| 6723 |
+
});
|
| 6724 |
+
};
|
| 6725 |
|
| 6726 |
const modalityLabels = (task) => (task.modalities || [])
|
| 6727 |
.map((key) => modalityMeta[key]?.label)
|
|
|
|
| 6922 |
|
| 6923 |
async function initTaskSurface() {
|
| 6924 |
try {
|
| 6925 |
+
const [walkthroughResponse, suiteResponse] = await Promise.all([
|
| 6926 |
+
fetch("data/task_walkthroughs.json", { cache: "no-cache" }),
|
| 6927 |
+
fetch("data/task_suite_20.json", { cache: "no-cache" })
|
| 6928 |
+
]);
|
| 6929 |
+
if (!walkthroughResponse.ok) throw new Error(`walkthrough data ${walkthroughResponse.status}`);
|
| 6930 |
+
if (!suiteResponse.ok) throw new Error(`suite data ${suiteResponse.status}`);
|
| 6931 |
+
taskEntries = mergeUnifiedTaskCards(await walkthroughResponse.json(), await suiteResponse.json());
|
| 6932 |
renderTaskCards();
|
| 6933 |
renderSelector();
|
| 6934 |
setActiveTask(0);
|
results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md
CHANGED
|
@@ -1,14 +1,13 @@
|
|
| 1 |
-
#
|
| 2 |
|
| 3 |
-
|
| 4 |
|
| 5 |
The file and directory names still contain `tier2_task_suite` for backwards-compatible public links, but this is not a separate benchmark tier.
|
| 6 |
|
| 7 |
## Setup Alignment
|
| 8 |
|
| 9 |
-
- Tasks 1-12: `12`
|
| 10 |
-
- Tasks 13-20: `8`
|
| 11 |
- Unified task contracts: `20`
|
|
|
|
| 12 |
- Long-horizon offset: `100` frames, about `5.0` seconds at 20 FPS
|
| 13 |
- Raw public-sample HDF5 is required to regenerate the interaction/object targets; raw media/HDF5 files are not redistributed.
|
| 14 |
|
|
@@ -27,4 +26,4 @@ The file and directory names still contain `tier2_task_suite` for backwards-comp
|
|
| 27 |
|
| 28 |
## Interpretation Boundary
|
| 29 |
|
| 30 |
-
|
|
|
|
| 1 |
+
# Unified 20-Task Provenance Baselines
|
| 2 |
|
| 3 |
+
This historical result bundle is part of the unified 20-task public-sample suite. The rows here reuse the same 20-frame windows, 5-frame stride, shared feature tensor, chronological split, and minimal/neural baseline discipline as the rest of the suite.
|
| 4 |
|
| 5 |
The file and directory names still contain `tier2_task_suite` for backwards-compatible public links, but this is not a separate benchmark tier.
|
| 6 |
|
| 7 |
## Setup Alignment
|
| 8 |
|
|
|
|
|
|
|
| 9 |
- Unified task contracts: `20`
|
| 10 |
+
- Provenance rows in this historical bundle: `8`
|
| 11 |
- Long-horizon offset: `100` frames, about `5.0` seconds at 20 FPS
|
| 12 |
- Raw public-sample HDF5 is required to regenerate the interaction/object targets; raw media/HDF5 files are not redistributed.
|
| 13 |
|
|
|
|
| 26 |
|
| 27 |
## Interpretation Boundary
|
| 28 |
|
| 29 |
+
These sample-level baselines are part of the same unified public-sample suite. They prove that the sample can support richer task contracts, but they do not prove cross-episode model quality.
|
results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json
CHANGED
|
@@ -1,9 +1,9 @@
|
|
| 1 |
{
|
| 2 |
-
"title": "Ropedia Xperience-10M Unified
|
| 3 |
"status": "pass",
|
| 4 |
"generated_at_utc": "2026-06-16T06:25:58+00:00",
|
| 5 |
"suite_position": "tasks_13_to_20",
|
| 6 |
-
"legacy_path_note": "The tier2_task_suite file and directory names are retained for stable public links;
|
| 7 |
"integrated_with_tasks_1_to_12": {
|
| 8 |
"tasks_1_to_12_count": 12,
|
| 9 |
"additional_task_count": 8,
|
|
|
|
| 1 |
{
|
| 2 |
+
"title": "Ropedia Xperience-10M Unified 20-Task Provenance Bundle",
|
| 3 |
"status": "pass",
|
| 4 |
"generated_at_utc": "2026-06-16T06:25:58+00:00",
|
| 5 |
"suite_position": "tasks_13_to_20",
|
| 6 |
+
"legacy_path_note": "The tier2_task_suite file and directory names are retained for stable public links; this bundle is provenance inside the unified 20-task suite, not a separate public tier.",
|
| 7 |
"integrated_with_tasks_1_to_12": {
|
| 8 |
"tasks_1_to_12_count": 12,
|
| 9 |
"additional_task_count": 8,
|
scripts/build_evaluation_protocol.py
CHANGED
|
@@ -244,7 +244,7 @@ def build_payload() -> dict:
|
|
| 244 |
"additional_public_sample_tasks": len(tier2_rows),
|
| 245 |
"unified_results": "docs/data/task_suite_20.json" if TASK_SUITE_20_PATH.exists() else None,
|
| 246 |
"legacy_additional_task_result_path": "docs/data/tier2_task_suite.json",
|
| 247 |
-
"legacy_path_note": "The tier2_task_suite path is retained for stable links only;
|
| 248 |
},
|
| 249 |
"split_policy": {
|
| 250 |
"name": "single_episode_chronological",
|
|
@@ -386,11 +386,10 @@ def render_markdown(payload: dict) -> str:
|
|
| 386 |
"",
|
| 387 |
"## Unified 20-Task Contracts",
|
| 388 |
"",
|
| 389 |
-
"
|
| 390 |
-
"
|
| 391 |
-
"
|
| 392 |
-
"
|
| 393 |
-
"stable artifact locations for tasks 13-20.",
|
| 394 |
"",
|
| 395 |
*markdown_table(payload["task_protocols"]),
|
| 396 |
"",
|
|
|
|
| 244 |
"additional_public_sample_tasks": len(tier2_rows),
|
| 245 |
"unified_results": "docs/data/task_suite_20.json" if TASK_SUITE_20_PATH.exists() else None,
|
| 246 |
"legacy_additional_task_result_path": "docs/data/tier2_task_suite.json",
|
| 247 |
+
"legacy_path_note": "The tier2_task_suite path is retained for stable links only; it is provenance inside the same 20-task suite.",
|
| 248 |
},
|
| 249 |
"split_policy": {
|
| 250 |
"name": "single_episode_chronological",
|
|
|
|
| 386 |
"",
|
| 387 |
"## Unified 20-Task Contracts",
|
| 388 |
"",
|
| 389 |
+
"All 20 public-sample task contracts are presented together under the same",
|
| 390 |
+
"20-frame window, feature, chronological split, leakage-control, and",
|
| 391 |
+
"minimal/neural baseline setup. Historical `tier2_task_suite` paths are",
|
| 392 |
+
"retained only as stable provenance artifact locations inside the unified suite.",
|
|
|
|
| 393 |
"",
|
| 394 |
*markdown_table(payload["task_protocols"]),
|
| 395 |
"",
|
scripts/build_figure_index.py
CHANGED
|
@@ -196,9 +196,9 @@ FIGURES = [
|
|
| 196 |
},
|
| 197 |
{
|
| 198 |
"id": "tier2_task_suite_chart",
|
| 199 |
-
"title": "
|
| 200 |
"path": "docs/assets/charts/tier2_task_suite.svg",
|
| 201 |
-
"role": "
|
| 202 |
"source_script": "scripts/tier2_task_suite.py",
|
| 203 |
"surface": "website unified task section, README, HF mirrors",
|
| 204 |
},
|
|
|
|
| 196 |
},
|
| 197 |
{
|
| 198 |
"id": "tier2_task_suite_chart",
|
| 199 |
+
"title": "Unified 20-task provenance chart",
|
| 200 |
"path": "docs/assets/charts/tier2_task_suite.svg",
|
| 201 |
+
"role": "Historical provenance rows inside the unified 20-task suite with aligned minimal and neural baseline metrics.",
|
| 202 |
"source_script": "scripts/tier2_task_suite.py",
|
| 203 |
"surface": "website unified task section, README, HF mirrors",
|
| 204 |
},
|
scripts/render_task_suite_infographic.py
CHANGED
|
@@ -1092,7 +1092,7 @@ def build_html(summary: dict, base_image: Path | None, sample_dir: Path | None)
|
|
| 1092 |
|
| 1093 |
<div class="section-label">
|
| 1094 |
<span>20 task contracts</span>
|
| 1095 |
-
<span>Every task below is part of
|
| 1096 |
</div>
|
| 1097 |
<section class="families">{''.join(families)}</section>
|
| 1098 |
|
|
|
|
| 1092 |
|
| 1093 |
<div class="section-label">
|
| 1094 |
<span>20 task contracts</span>
|
| 1095 |
+
<span>Every task below is part of one unified public-sample suite with shared window/split discipline and source-linked scores in the 180-result matrix.</span>
|
| 1096 |
</div>
|
| 1097 |
<section class="families">{''.join(families)}</section>
|
| 1098 |
|
scripts/sync_hf_publish_mirrors.py
CHANGED
|
@@ -47,12 +47,13 @@ TIER2_CARD_BLOCK = """
|
|
| 47 |
## Unified 20-Task Suite
|
| 48 |
|
| 49 |
The public-sample task surface is now one unified 20-task suite in
|
| 50 |
-
`TASK_SUITE_20.md` and `docs/data/task_suite_20.json`.
|
| 51 |
-
|
| 52 |
-
|
|
|
|
| 53 |
The historical `tier2_task_suite` path is retained only for stable artifact
|
| 54 |
-
links to
|
| 55 |
-
one public sample episode for task construction and reproducibility, and
|
| 56 |
128 selected episodes for same-split baselines plus Qwen3-Omni and Cosmos3
|
| 57 |
comparison.
|
| 58 |
The line map is published as `docs/assets/charts/two_evidence_line_map.svg`
|
|
@@ -221,13 +222,27 @@ def ensure_tier2_card_links(hf_root: Path, *, dry_run: bool) -> list[str]:
|
|
| 221 |
continue
|
| 222 |
text = path.read_text(encoding="utf-8")
|
| 223 |
text = text.replace(
|
| 224 |
-
"original sample tasks; tasks 13-20 reuse",
|
| 225 |
-
"
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 226 |
)
|
| 227 |
if "docs/data/unified_task_model_radar.json" not in text:
|
| 228 |
text = text.replace(
|
| 229 |
-
"links to
|
| 230 |
-
"links to
|
| 231 |
"one public sample episode for task construction and reproducibility,\n"
|
| 232 |
"and 128 selected episodes for same-split metadata/raw baselines,\n"
|
| 233 |
"Qwen3-Omni v6 LoRA, Cosmos3-Super Reasoner, and Cosmos3-Nano\n"
|
|
|
|
| 47 |
## Unified 20-Task Suite
|
| 48 |
|
| 49 |
The public-sample task surface is now one unified 20-task suite in
|
| 50 |
+
`TASK_SUITE_20.md` and `docs/data/task_suite_20.json`. All 20 task contracts
|
| 51 |
+
reuse the same 20-frame windows, 5-frame stride, feature manifest,
|
| 52 |
+
chronological split, and minimal/neural head pattern unless a task-specific
|
| 53 |
+
leakage rule removes target-side features.
|
| 54 |
The historical `tier2_task_suite` path is retained only for stable artifact
|
| 55 |
+
links to provenance rows inside the unified suite. Results are organized as two
|
| 56 |
+
evidence lines: one public sample episode for task construction and reproducibility, and
|
| 57 |
128 selected episodes for same-split baselines plus Qwen3-Omni and Cosmos3
|
| 58 |
comparison.
|
| 59 |
The line map is published as `docs/assets/charts/two_evidence_line_map.svg`
|
|
|
|
| 222 |
continue
|
| 223 |
text = path.read_text(encoding="utf-8")
|
| 224 |
text = text.replace(
|
| 225 |
+
"original sample tasks; tasks " + "13-20 reuse",
|
| 226 |
+
"all 20 task contracts reuse",
|
| 227 |
+
)
|
| 228 |
+
text = text.replace(
|
| 229 |
+
"original sample tasks; Tasks " + "13-20 reuse",
|
| 230 |
+
"all 20 task contracts reuse",
|
| 231 |
+
)
|
| 232 |
+
text = text.replace(
|
| 233 |
+
"links to tasks " + "13-20.",
|
| 234 |
+
"links to provenance rows inside the unified suite.",
|
| 235 |
+
)
|
| 236 |
+
text = text.replace(
|
| 237 |
+
"`TASK_SUITE_20.md` and `docs/data/task_suite_20.json`. Tasks 1-12 are the\n"
|
| 238 |
+
"all 20 task contracts reuse the same 20-frame windows",
|
| 239 |
+
"`TASK_SUITE_20.md` and `docs/data/task_suite_20.json`. All 20 task contracts\n"
|
| 240 |
+
"reuse the same 20-frame windows",
|
| 241 |
)
|
| 242 |
if "docs/data/unified_task_model_radar.json" not in text:
|
| 243 |
text = text.replace(
|
| 244 |
+
"links to provenance rows inside the unified suite.\n",
|
| 245 |
+
"links to provenance rows inside the unified suite. Results are organized as two evidence lines:\n"
|
| 246 |
"one public sample episode for task construction and reproducibility,\n"
|
| 247 |
"and 128 selected episodes for same-split metadata/raw baselines,\n"
|
| 248 |
"Qwen3-Omni v6 LoRA, Cosmos3-Super Reasoner, and Cosmos3-Nano\n"
|
scripts/verify_live_publication.py
CHANGED
|
@@ -242,7 +242,7 @@ HASH_GROUPS = [
|
|
| 242 |
},
|
| 243 |
{
|
| 244 |
"id": "tier2_task_suite_json",
|
| 245 |
-
"title": "
|
| 246 |
"local_path": "docs/data/tier2_task_suite.json",
|
| 247 |
"urls": {
|
| 248 |
"github_pages": "https://chaoyue0307.github.io/ropedia-xperience-10m-task-suite/data/tier2_task_suite.json",
|
|
@@ -253,7 +253,7 @@ HASH_GROUPS = [
|
|
| 253 |
},
|
| 254 |
{
|
| 255 |
"id": "tier2_task_suite_chart",
|
| 256 |
-
"title": "
|
| 257 |
"local_path": "docs/assets/charts/tier2_task_suite.svg",
|
| 258 |
"urls": {
|
| 259 |
"github_pages": "https://chaoyue0307.github.io/ropedia-xperience-10m-task-suite/assets/charts/tier2_task_suite.svg",
|
|
@@ -264,7 +264,7 @@ HASH_GROUPS = [
|
|
| 264 |
},
|
| 265 |
{
|
| 266 |
"id": "tier2_result_summary",
|
| 267 |
-
"title": "
|
| 268 |
"local_path": "results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 269 |
"urls": {
|
| 270 |
"github_raw": "https://raw.githubusercontent.com/ChaoYue0307/ropedia-xperience-10m-task-suite/main/results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
|
@@ -275,7 +275,7 @@ HASH_GROUPS = [
|
|
| 275 |
},
|
| 276 |
{
|
| 277 |
"id": "tier2_baseline_report",
|
| 278 |
-
"title": "
|
| 279 |
"local_path": "results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md",
|
| 280 |
"urls": {
|
| 281 |
"github_raw": "https://raw.githubusercontent.com/ChaoYue0307/ropedia-xperience-10m-task-suite/main/results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md",
|
|
@@ -286,7 +286,7 @@ HASH_GROUPS = [
|
|
| 286 |
},
|
| 287 |
{
|
| 288 |
"id": "tier2_minimal_model_npz",
|
| 289 |
-
"title": "
|
| 290 |
"local_path": "results/episode_task_suite/tier2_task_suite/long_horizon_next_action/model.npz",
|
| 291 |
"urls": {
|
| 292 |
"github_raw": "https://raw.githubusercontent.com/ChaoYue0307/ropedia-xperience-10m-task-suite/main/results/episode_task_suite/tier2_task_suite/long_horizon_next_action/model.npz",
|
|
@@ -687,7 +687,7 @@ MARKER_CHECKS = [
|
|
| 687 |
"Glossary",
|
| 688 |
"data/glossary.json",
|
| 689 |
"tier2_task_suite.json",
|
| 690 |
-
"
|
| 691 |
"Long-Horizon Next-Action Forecasting",
|
| 692 |
],
|
| 693 |
"forbidden": [
|
|
@@ -730,7 +730,7 @@ MARKER_CHECKS = [
|
|
| 730 |
"Public reader map",
|
| 731 |
"data/public_reader_map.json",
|
| 732 |
"tier2_task_suite.json",
|
| 733 |
-
"
|
| 734 |
"Long-Horizon Next-Action Forecasting",
|
| 735 |
],
|
| 736 |
"forbidden": [
|
|
@@ -759,7 +759,7 @@ MARKER_CHECKS = [
|
|
| 759 |
"docs/data/unified_task_model_radar.json",
|
| 760 |
"docs/assets/charts/unified_task_model_radar.svg",
|
| 761 |
"docs/data/tier2_task_suite.json",
|
| 762 |
-
"
|
| 763 |
],
|
| 764 |
"forbidden": ["xperience10m-" + "taskfirst-v10"],
|
| 765 |
},
|
|
@@ -819,7 +819,7 @@ MARKER_CHECKS = [
|
|
| 819 |
"docs/data/unified_task_model_radar.json",
|
| 820 |
"docs/assets/charts/unified_task_model_radar.svg",
|
| 821 |
"docs/data/tier2_task_suite.json",
|
| 822 |
-
"
|
| 823 |
],
|
| 824 |
"forbidden": ["xperience10m-" + "taskfirst-v10"],
|
| 825 |
},
|
|
|
|
| 242 |
},
|
| 243 |
{
|
| 244 |
"id": "tier2_task_suite_json",
|
| 245 |
+
"title": "Unified 20-task provenance JSON",
|
| 246 |
"local_path": "docs/data/tier2_task_suite.json",
|
| 247 |
"urls": {
|
| 248 |
"github_pages": "https://chaoyue0307.github.io/ropedia-xperience-10m-task-suite/data/tier2_task_suite.json",
|
|
|
|
| 253 |
},
|
| 254 |
{
|
| 255 |
"id": "tier2_task_suite_chart",
|
| 256 |
+
"title": "Unified 20-task provenance chart",
|
| 257 |
"local_path": "docs/assets/charts/tier2_task_suite.svg",
|
| 258 |
"urls": {
|
| 259 |
"github_pages": "https://chaoyue0307.github.io/ropedia-xperience-10m-task-suite/assets/charts/tier2_task_suite.svg",
|
|
|
|
| 264 |
},
|
| 265 |
{
|
| 266 |
"id": "tier2_result_summary",
|
| 267 |
+
"title": "Unified 20-task provenance result summary",
|
| 268 |
"local_path": "results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
| 269 |
"urls": {
|
| 270 |
"github_raw": "https://raw.githubusercontent.com/ChaoYue0307/ropedia-xperience-10m-task-suite/main/results/episode_task_suite/tier2_task_suite/tier2_task_suite_results.json",
|
|
|
|
| 275 |
},
|
| 276 |
{
|
| 277 |
"id": "tier2_baseline_report",
|
| 278 |
+
"title": "Unified 20-task provenance baseline report",
|
| 279 |
"local_path": "results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md",
|
| 280 |
"urls": {
|
| 281 |
"github_raw": "https://raw.githubusercontent.com/ChaoYue0307/ropedia-xperience-10m-task-suite/main/results/episode_task_suite/tier2_task_suite/TIER2_TASK_BASELINES.md",
|
|
|
|
| 286 |
},
|
| 287 |
{
|
| 288 |
"id": "tier2_minimal_model_npz",
|
| 289 |
+
"title": "Unified 20-task provenance minimal model NPZ",
|
| 290 |
"local_path": "results/episode_task_suite/tier2_task_suite/long_horizon_next_action/model.npz",
|
| 291 |
"urls": {
|
| 292 |
"github_raw": "https://raw.githubusercontent.com/ChaoYue0307/ropedia-xperience-10m-task-suite/main/results/episode_task_suite/tier2_task_suite/long_horizon_next_action/model.npz",
|
|
|
|
| 687 |
"Glossary",
|
| 688 |
"data/glossary.json",
|
| 689 |
"tier2_task_suite.json",
|
| 690 |
+
"Unified task artifact package",
|
| 691 |
"Long-Horizon Next-Action Forecasting",
|
| 692 |
],
|
| 693 |
"forbidden": [
|
|
|
|
| 730 |
"Public reader map",
|
| 731 |
"data/public_reader_map.json",
|
| 732 |
"tier2_task_suite.json",
|
| 733 |
+
"Unified task artifact package",
|
| 734 |
"Long-Horizon Next-Action Forecasting",
|
| 735 |
],
|
| 736 |
"forbidden": [
|
|
|
|
| 759 |
"docs/data/unified_task_model_radar.json",
|
| 760 |
"docs/assets/charts/unified_task_model_radar.svg",
|
| 761 |
"docs/data/tier2_task_suite.json",
|
| 762 |
+
"Unified 20-Task Suite",
|
| 763 |
],
|
| 764 |
"forbidden": ["xperience10m-" + "taskfirst-v10"],
|
| 765 |
},
|
|
|
|
| 819 |
"docs/data/unified_task_model_radar.json",
|
| 820 |
"docs/assets/charts/unified_task_model_radar.svg",
|
| 821 |
"docs/data/tier2_task_suite.json",
|
| 822 |
+
"Unified 20-Task Suite",
|
| 823 |
],
|
| 824 |
"forbidden": ["xperience10m-" + "taskfirst-v10"],
|
| 825 |
},
|