
Datasets:


Tasks:
Object Detection
Modalities:
Text
Languages:
English
Size:
< 1K
Tags:
object detection
image recognition
computer vision
parking management
traffic monitoring
smart city
License:
Commit ·
39d9add
0
Parent(s):
Duplicate from shangzx/Underground-Parking-Lot-Empty-Slot-Detection-Dataset
Browse files- .gitattributes +60 -0
- 66bf2a1d0d67753452212683bb628b74.jpg +3 -0
- 66bf2a1d0d67753452212683bb628b74.json +1 -0
- 7d45e1e08af980be05ae6228341c1b19.jpg +3 -0
- 7d45e1e08af980be05ae6228341c1b19.json +1 -0
- README.md +61 -0
- cde886055408d427b3fd3cf570d98251.jpg +3 -0
- cde886055408d427b3fd3cf570d98251.json +1 -0
- ec7233bdace4c0587200b4819e052e73.jpg +3 -0
- ec7233bdace4c0587200b4819e052e73.json +1 -0
.gitattributes
ADDED
|
@@ -0,0 +1,60 @@
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
+
*.7z filter=lfs diff=lfs merge=lfs -text
|
| 2 |
+
*.arrow filter=lfs diff=lfs merge=lfs -text
|
| 3 |
+
*.avro filter=lfs diff=lfs merge=lfs -text
|
| 4 |
+
*.bin filter=lfs diff=lfs merge=lfs -text
|
| 5 |
+
*.bz2 filter=lfs diff=lfs merge=lfs -text
|
| 6 |
+
*.ckpt filter=lfs diff=lfs merge=lfs -text
|
| 7 |
+
*.ftz filter=lfs diff=lfs merge=lfs -text
|
| 8 |
+
*.gz filter=lfs diff=lfs merge=lfs -text
|
| 9 |
+
*.h5 filter=lfs diff=lfs merge=lfs -text
|
| 10 |
+
*.joblib filter=lfs diff=lfs merge=lfs -text
|
| 11 |
+
*.lfs.* filter=lfs diff=lfs merge=lfs -text
|
| 12 |
+
*.lz4 filter=lfs diff=lfs merge=lfs -text
|
| 13 |
+
*.mds filter=lfs diff=lfs merge=lfs -text
|
| 14 |
+
*.mlmodel filter=lfs diff=lfs merge=lfs -text
|
| 15 |
+
*.model filter=lfs diff=lfs merge=lfs -text
|
| 16 |
+
*.msgpack filter=lfs diff=lfs merge=lfs -text
|
| 17 |
+
*.npy filter=lfs diff=lfs merge=lfs -text
|
| 18 |
+
*.npz filter=lfs diff=lfs merge=lfs -text
|
| 19 |
+
*.onnx filter=lfs diff=lfs merge=lfs -text
|
| 20 |
+
*.ot filter=lfs diff=lfs merge=lfs -text
|
| 21 |
+
*.parquet filter=lfs diff=lfs merge=lfs -text
|
| 22 |
+
*.pb filter=lfs diff=lfs merge=lfs -text
|
| 23 |
+
*.pickle filter=lfs diff=lfs merge=lfs -text
|
| 24 |
+
*.pkl filter=lfs diff=lfs merge=lfs -text
|
| 25 |
+
*.pt filter=lfs diff=lfs merge=lfs -text
|
| 26 |
+
*.pth filter=lfs diff=lfs merge=lfs -text
|
| 27 |
+
*.rar filter=lfs diff=lfs merge=lfs -text
|
| 28 |
+
*.safetensors filter=lfs diff=lfs merge=lfs -text
|
| 29 |
+
saved_model/**/* filter=lfs diff=lfs merge=lfs -text
|
| 30 |
+
*.tar.* filter=lfs diff=lfs merge=lfs -text
|
| 31 |
+
*.tar filter=lfs diff=lfs merge=lfs -text
|
| 32 |
+
*.tflite filter=lfs diff=lfs merge=lfs -text
|
| 33 |
+
*.tgz filter=lfs diff=lfs merge=lfs -text
|
| 34 |
+
*.wasm filter=lfs diff=lfs merge=lfs -text
|
| 35 |
+
*.xz filter=lfs diff=lfs merge=lfs -text
|
| 36 |
+
*.zip filter=lfs diff=lfs merge=lfs -text
|
| 37 |
+
*.zst filter=lfs diff=lfs merge=lfs -text
|
| 38 |
+
*tfevents* filter=lfs diff=lfs merge=lfs -text
|
| 39 |
+
# Audio files - uncompressed
|
| 40 |
+
*.pcm filter=lfs diff=lfs merge=lfs -text
|
| 41 |
+
*.sam filter=lfs diff=lfs merge=lfs -text
|
| 42 |
+
*.raw filter=lfs diff=lfs merge=lfs -text
|
| 43 |
+
# Audio files - compressed
|
| 44 |
+
*.aac filter=lfs diff=lfs merge=lfs -text
|
| 45 |
+
*.flac filter=lfs diff=lfs merge=lfs -text
|
| 46 |
+
*.mp3 filter=lfs diff=lfs merge=lfs -text
|
| 47 |
+
*.ogg filter=lfs diff=lfs merge=lfs -text
|
| 48 |
+
*.wav filter=lfs diff=lfs merge=lfs -text
|
| 49 |
+
# Image files - uncompressed
|
| 50 |
+
*.bmp filter=lfs diff=lfs merge=lfs -text
|
| 51 |
+
*.gif filter=lfs diff=lfs merge=lfs -text
|
| 52 |
+
*.png filter=lfs diff=lfs merge=lfs -text
|
| 53 |
+
*.tiff filter=lfs diff=lfs merge=lfs -text
|
| 54 |
+
# Image files - compressed
|
| 55 |
+
*.jpg filter=lfs diff=lfs merge=lfs -text
|
| 56 |
+
*.jpeg filter=lfs diff=lfs merge=lfs -text
|
| 57 |
+
*.webp filter=lfs diff=lfs merge=lfs -text
|
| 58 |
+
# Video files - compressed
|
| 59 |
+
*.mp4 filter=lfs diff=lfs merge=lfs -text
|
| 60 |
+
*.webm filter=lfs diff=lfs merge=lfs -text
|
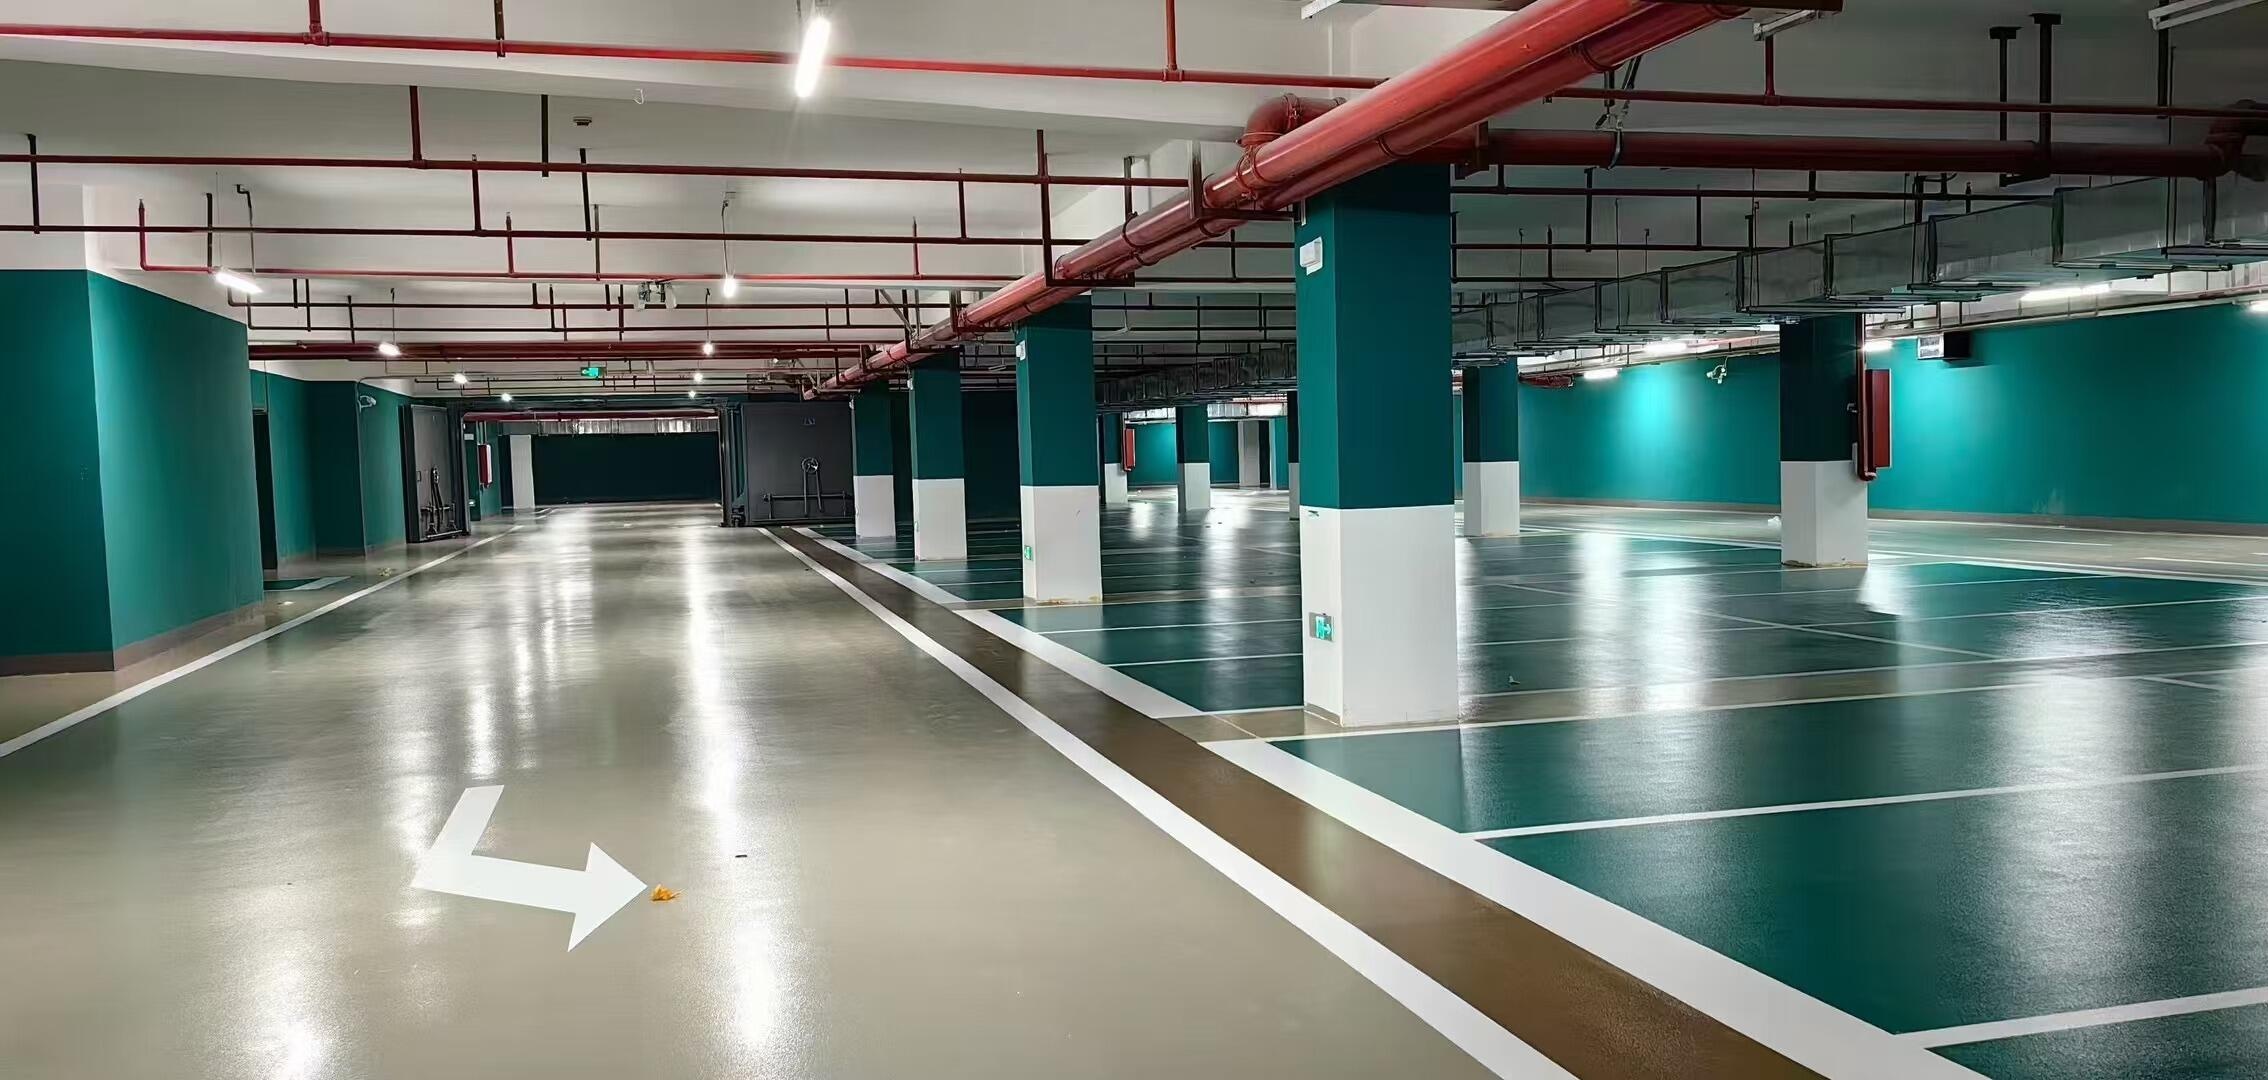
66bf2a1d0d67753452212683bb628b74.jpg
ADDED
|
Git LFS Details
|
66bf2a1d0d67753452212683bb628b74.json
ADDED
|
@@ -0,0 +1 @@
|
|
|
|
|
|
|
| 1 |
+
{"file_name":"66bf2a1d0d67753452212683bb628b74.jpg","quality":"2268*1080","parking_space_id":"Unrecognized","is_vacant":"Yes","vehicle_presence":"No","confidence_level":"1.0","bounding_box":"Unrecognized","parking_layout":"Vertical Parking Layout","lighting_condition":"Indoor Artificial Lighting","camera_angle":"Eye Level"}
|
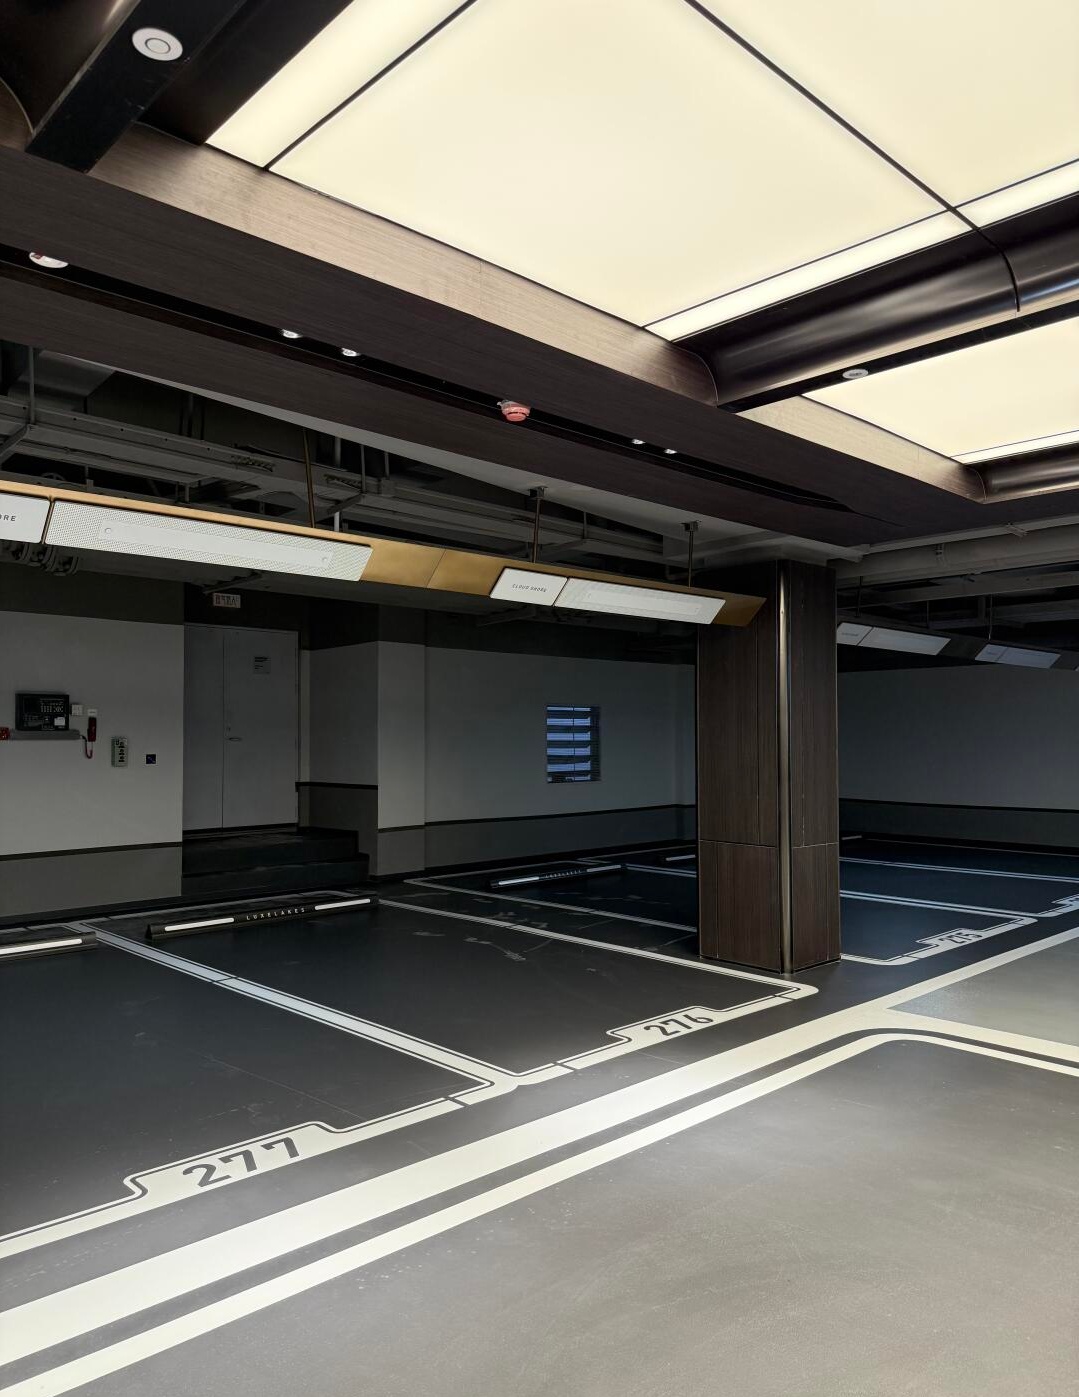
7d45e1e08af980be05ae6228341c1b19.jpg
ADDED
|
Git LFS Details
|
7d45e1e08af980be05ae6228341c1b19.json
ADDED
|
@@ -0,0 +1 @@
|
|
|
|
|
|
|
| 1 |
+
{"file_name":"7d45e1e08af980be05ae6228341c1b19.jpg","quality":"1079*1397","parking_space_id":"277","is_vacant":"Yes","vehicle_presence":"No","confidence_level":"0.9","bounding_box":"(100, 50, 200, 150)","parking_layout":"Horizontal arrangement, multiple spaces","lighting_condition":"Indoor lighting","camera_angle":"Front view"}
|
README.md
ADDED
|
@@ -0,0 +1,61 @@
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
+
---
|
| 2 |
+
tags:
|
| 3 |
+
- object detection
|
| 4 |
+
- image recognition
|
| 5 |
+
- computer vision
|
| 6 |
+
- parking management
|
| 7 |
+
- traffic monitoring
|
| 8 |
+
- smart city
|
| 9 |
+
license: cc-by-nc-sa-4.0
|
| 10 |
+
task_categories:
|
| 11 |
+
- object-detection
|
| 12 |
+
language:
|
| 13 |
+
- en
|
| 14 |
+
pretty_name: Underground Parking Lot Empty Slot Detection Dataset
|
| 15 |
+
size_categories:
|
| 16 |
+
- 1B<n<10B
|
| 17 |
+
---
|
| 18 |
+
|
| 19 |
+
# Underground Parking Lot Empty Slot Detection Dataset
|
| 20 |
+
|
| 21 |
+
With the acceleration of urbanization, the management of underground parking lots has become increasingly complex, with low space utilization and traffic congestion being common problems. Existing manual management and traditional surveillance cameras cannot monitor empty slots in real-time and efficiently, incurring high costs and with limited accuracy. This dataset aims to assist in identifying and detecting empty slots in underground parking lots using deep learning technology, improving parking management efficiency and user experience. Images are collected from high-definition cameras installed on the ceiling of parking lots, covering various weather and lighting conditions. Quality control involves multiple rounds of manual annotation and consistency checks to ensure the consistency and accuracy of each annotation. The annotation team consists of 12 experts with backgrounds in traffic management and computer vision. Preprocessing stages include data cleaning, denoising, and normalization, using the latest image enhancement techniques to augment the samples. Data is stored in JPG format, organized into folders classified by time and location.
|
| 22 |
+
|
| 23 |
+
## Technical Specifications
|
| 24 |
+
|
| 25 |
+
| Field | Type | Description |
|
| 26 |
+
| :--- | :--- | :--- |
|
| 27 |
+
| file_name | string | File name |
|
| 28 |
+
| quality | string | Resolution |
|
| 29 |
+
| parking_space_id | string | A unique identifier for the parking space. |
|
| 30 |
+
| is_vacant | boolean | Indicates whether the parking space is vacant. |
|
| 31 |
+
| vehicle_presence | boolean | Indicates the presence of a vehicle in the parking space. |
|
| 32 |
+
| confidence_level | float | Confidence level of the vacant parking space detection, ranging from 0 to 1. |
|
| 33 |
+
| bounding_box | string | Coordinates of the bounding box for the detected parking space area. |
|
| 34 |
+
| parking_layout | string | Describes the layout of parking spaces within the parking lot. |
|
| 35 |
+
| lighting_condition | string | Responsibly indicates the lighting condition, such as daytime or nighttime. |
|
| 36 |
+
| camera_angle | string | Denotes the angle at which the camera is installed. |
|
| 37 |
+
|
| 38 |
+
## Compliance Statement
|
| 39 |
+
|
| 40 |
+
<table>
|
| 41 |
+
<tr>
|
| 42 |
+
<td>Authorization Type</td>
|
| 43 |
+
<td>CC-BY-NC-SA 4.0 (Attribution–NonCommercial–ShareAlike)</td>
|
| 44 |
+
</tr>
|
| 45 |
+
<tr>
|
| 46 |
+
<td>Commercial Use</td>
|
| 47 |
+
<td>Requires exclusive subscription or authorization contract (monthly or per-invocation charging)</td>
|
| 48 |
+
</tr>
|
| 49 |
+
<tr>
|
| 50 |
+
<td>Privacy and Anonymization</td>
|
| 51 |
+
<td>No PII, no real company names, simulated scenarios follow industry standards</td>
|
| 52 |
+
</tr>
|
| 53 |
+
<tr>
|
| 54 |
+
<td>Compliance System</td>
|
| 55 |
+
<td>Compliant with China's Data Security Law / EU GDPR / supports enterprise data access logs</td>
|
| 56 |
+
</tr>
|
| 57 |
+
</table>
|
| 58 |
+
|
| 59 |
+
## Source & Contact
|
| 60 |
+
|
| 61 |
+
If you need more dataset details, please visit [Mobiusi](https://www.mobiusi.com/datasets/6a3f0662719aa2e731b45231865461f7?utm_source=huggingface&utm_medium=referral). or contact us via contact@mobiusi.com
|
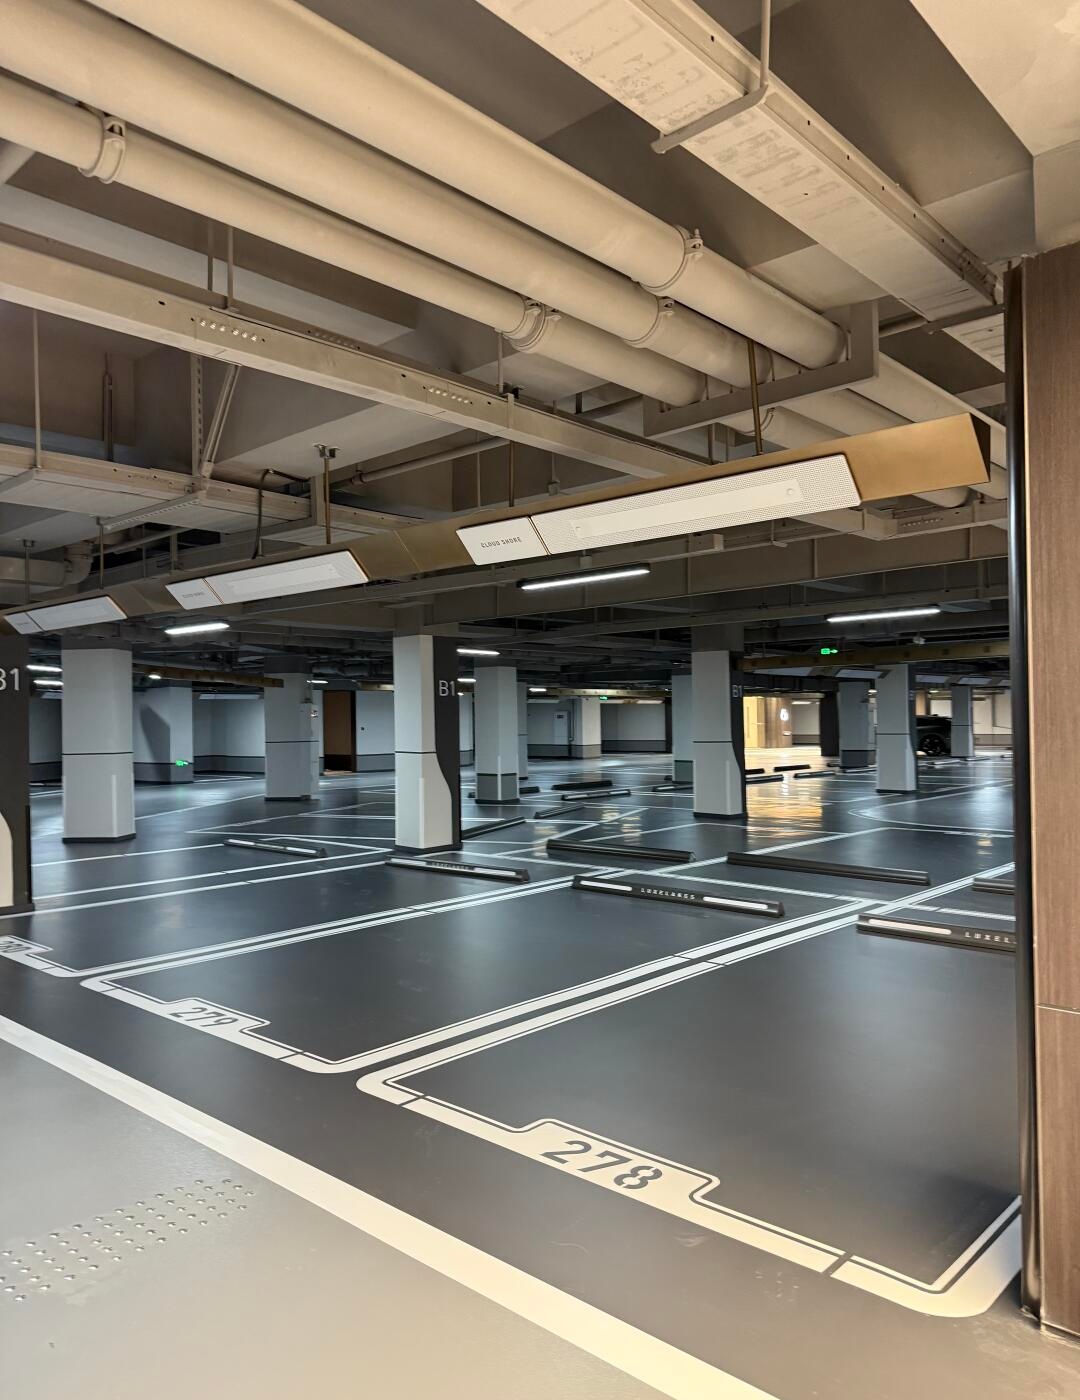
cde886055408d427b3fd3cf570d98251.jpg
ADDED
|
Git LFS Details
|
cde886055408d427b3fd3cf570d98251.json
ADDED
|
@@ -0,0 +1 @@
|
|
|
|
|
|
|
| 1 |
+
{"file_name":"cde886055408d427b3fd3cf570d98251.jpg","quality":"1080*1400","parking_space_id":"278","is_vacant":"yes","vehicle_presence":"no","confidence_level":"1","bounding_box":"(coordinates not available)","parking_layout":"multiple rows, neatly arranged","lighting_condition":"indoor lighting","camera_angle":"approximately 45-degree overlooking"}
|
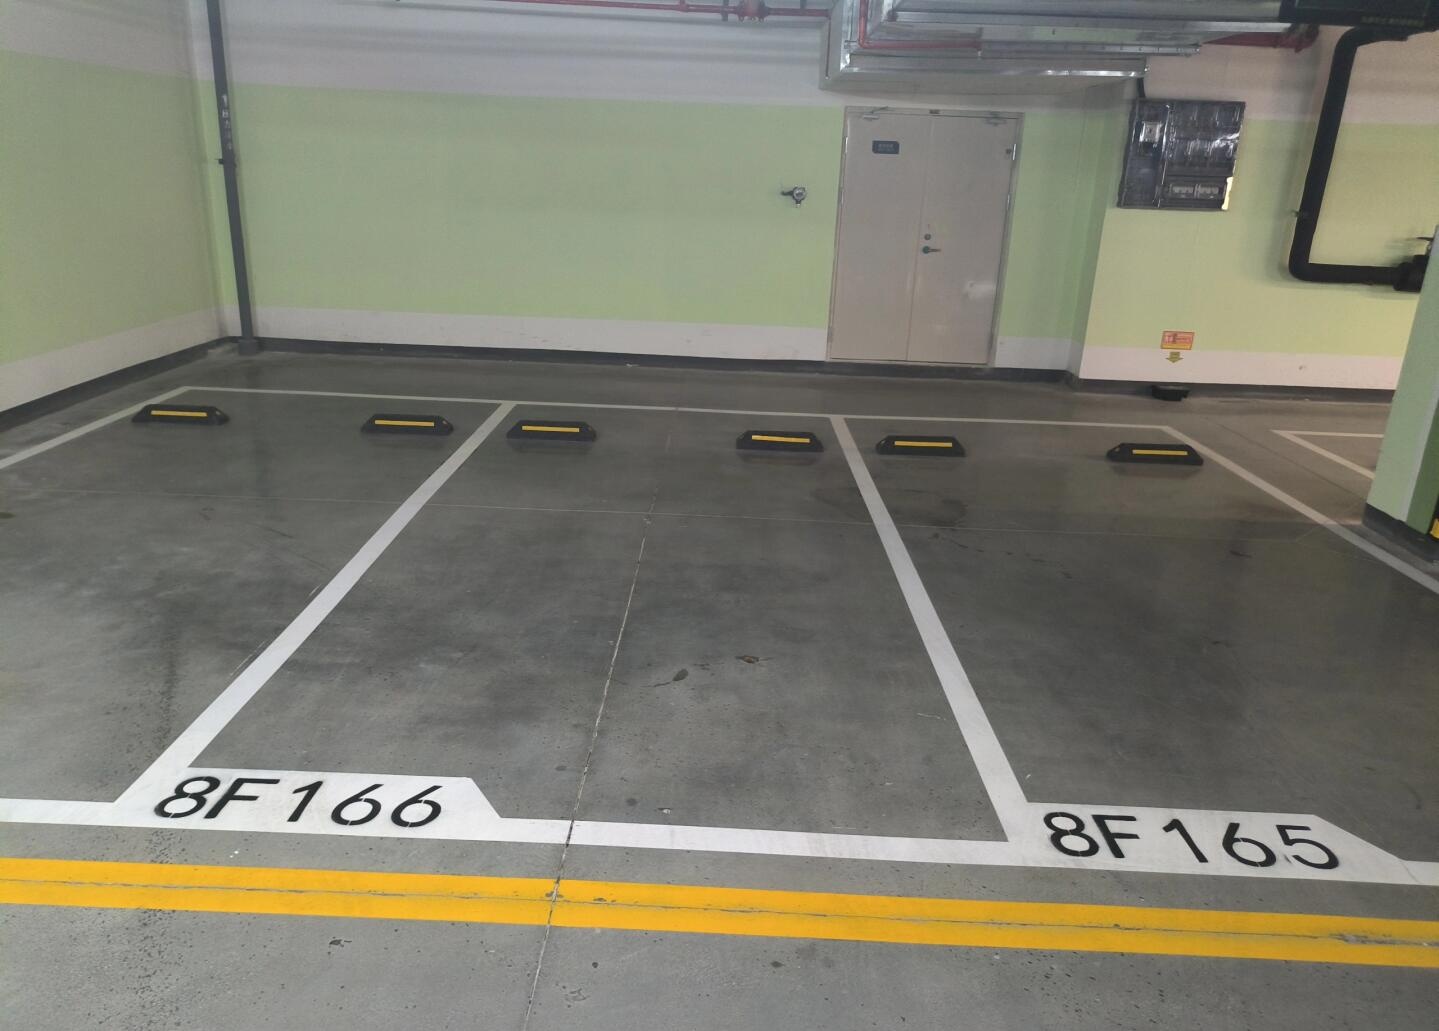
ec7233bdace4c0587200b4819e052e73.jpg
ADDED
|
Git LFS Details
|
ec7233bdace4c0587200b4819e052e73.json
ADDED
|
@@ -0,0 +1 @@
|
|
|
|
|
|
|
| 1 |
+
{"file_name":"ec7233bdace4c0587200b4819e052e73.jpg","quality":"1439*1031","parking_space_id":"8F165, 8F166","is_vacant":"Yes","vehicle_presence":"No","confidence_level":"1","bounding_box":"[(x1, y1), (x2, y2), (x3, y3), (x4, y4)]","parking_layout":"Parallel","lighting_condition":"Indoor lighting","camera_angle":"Frontal overhead view"}
|