

dataset card: current numbers, statistics figures, and the force/tactile limits
Browse files- README.md +89 -34
- assets/stats_arducam_session.png +3 -0
- assets/stats_wrist_era.png +3 -0
README.md
CHANGED
|
@@ -36,11 +36,61 @@ configs:
|
|
| 36 |
|
| 37 |
Dense, contact-rich, synchronized multimodal interaction data collected from **human hands holding handheld GelSight tactile sensors** (no robot arm). Intended for **tactile-visual dynamics / world-model learning**.
|
| 38 |
|
| 39 |
-
> **
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
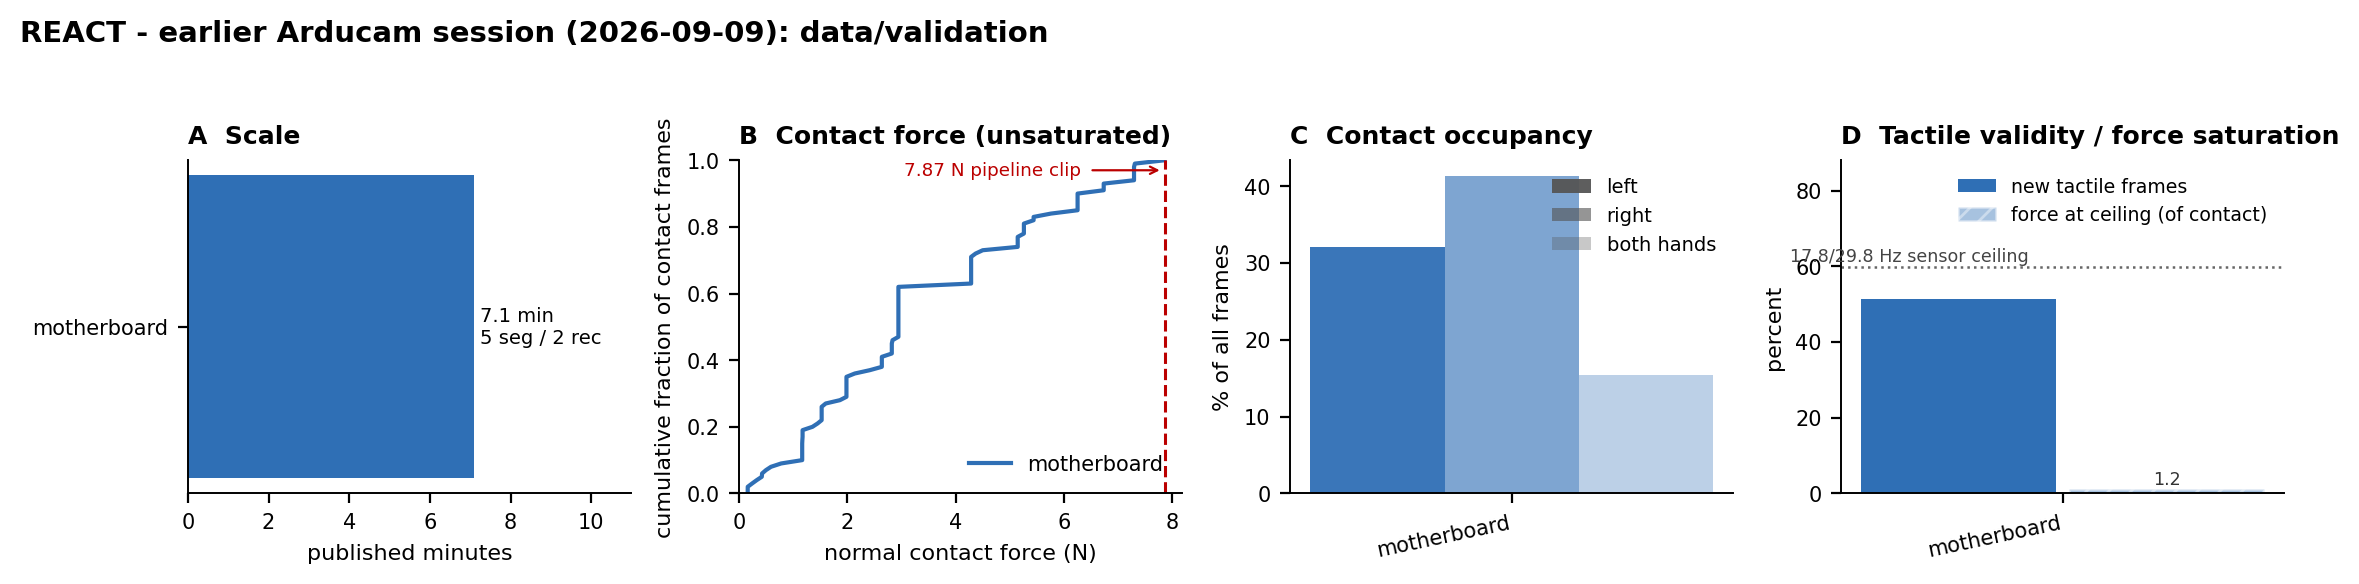
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 40 |
|
| 41 |
## Format — LeRobot-style video release
|
| 42 |
|
| 43 |
-
Each episode ships as **
|
| 44 |
|
| 45 |
```
|
| 46 |
data/<task>/
|
|
@@ -50,7 +100,8 @@ data/<task>/
|
|
| 50 |
│ └── calibration.json # epoch, applies-to dates, RMSE, chain
|
| 51 |
├── videos/<date>/episode_NNN/
|
| 52 |
│ ├── view_left.mp4 view_middle.mp4 view_right.mp4 # 640×480 RGB
|
| 53 |
-
│
|
|
|
|
| 54 |
├── meta/<date>/episode_NNN.parquet # one row per frame (see below)
|
| 55 |
├── episodes.jsonl # one row per episode
|
| 56 |
├── segments.json # clean-segment index (no bad frames)
|
|
@@ -63,7 +114,11 @@ data/<task>/
|
|
| 63 |
|---|---|---|
|
| 64 |
| `frame_idx` / `frame_index` | int | 0…T-1, matches MP4 frame index |
|
| 65 |
| `episode` / `episode_index` | str / int | source episode key and its 0-based index within the task |
|
| 66 |
-
| `task` / `task_index` | str / int | task name and index (0=motherboard, 1=pushT) |
|
|
|
|
|
|
|
|
|
|
|
|
|
| 67 |
| `timestamp` | float64 | camera clock (s) |
|
| 68 |
| `sensor_left_pose`, `sensor_right_pose` | list[7] | OptiTrack world pose of each GelSight (xyz metres + quat **xyzw**, scalar-LAST — `scipy...Rotation.from_quat` takes it as-is) |
|
| 69 |
| `object_pose` | list[7] | OptiTrack world pose of the manipulated object (NaN where the object body was not tracked — e.g. all pushT) |
|
|
@@ -82,34 +137,38 @@ data/<task>/depth/<date>/episode_NNN/depth_{left,middle,right}.mkv
|
|
| 82 |
- Decode with PyAV (`frame.to_ndarray()` → `(480, 640)` uint16). cv2 cannot read 16-bit video.
|
| 83 |
- Load via `ReactVideoDataset(..., load_depth=True)`.
|
| 84 |
|
| 85 |
-
## Tasks
|
| 86 |
|
| 87 |
-
| Task |
|
| 88 |
|---|---|---|---|---|---|
|
| 89 |
-
| **motherboard** |
|
| 90 |
-
| **pushT** |
|
|
|
|
|
|
|
| 91 |
|
| 92 |
-
|
|
|
|
|
|
|
| 93 |
|
| 94 |
-
|
| 95 |
-
|
| 96 |
-
|
| 97 |
-
|
| 98 |
|
| 99 |
-
|
| 100 |
|
| 101 |
## Downloading — depth is optional
|
| 102 |
|
| 103 |
-
The dataset splits into a **lightweight core** (RGB + tactile + poses, ~
|
| 104 |
|
| 105 |
```python
|
| 106 |
from huggingface_hub import snapshot_download
|
| 107 |
|
| 108 |
-
# Core only — RGB + tactile + parquet, NO depth (~
|
| 109 |
snapshot_download("yxma/React", repo_type="dataset",
|
| 110 |
ignore_patterns=["*/depth/*"])
|
| 111 |
|
| 112 |
-
# Everything including depth (~
|
| 113 |
snapshot_download("yxma/React", repo_type="dataset")
|
| 114 |
|
| 115 |
# One task only
|
|
@@ -161,26 +220,21 @@ The invariant worth knowing: **rotating both changes no picture.** Measured on
|
|
| 161 |
GelSight centre moves 0.000000 px between the two conventions. Newtons,
|
| 162 |
timestamps and every video frame are identical either way.
|
| 163 |
|
| 164 |
-
##
|
| 165 |
|
| 166 |
-
Recordings
|
| 167 |
-
lag of
|
| 168 |
-
|
| 169 |
-
recording-side `cv2.VideoCapture` V4L2 buffer that was never flushed
|
| 170 |
-
(throttled reads + no `BUFFERSIZE=1` + default pixel format). Fixed in the rig
|
| 171 |
-
on 2026-06-27; **future recordings will not have this lag**.
|
| 172 |
|
| 173 |
-
|
| 174 |
-
|
|
|
|
|
|
|
|
|
|
| 175 |
|
| 176 |
-
|
| 177 |
-
|
| 178 |
-
|
| 179 |
-
|
| 180 |
-
`tactile_latency` shifts both the tactile videos and the tactile contact-scalar
|
| 181 |
-
columns; poses/views/depth are unchanged. Set `tactile_latency=0` for the raw
|
| 182 |
-
(uncompensated) data. The exact per-session value should be re-measured with
|
| 183 |
-
`camera_stream/measure_gelsight_latency.py`.
|
| 184 |
|
| 185 |
## Data quality
|
| 186 |
Per-task `bad_frames.json` flags `intensity_spikes`, `pose_teleports_{L,R}`, `ot_loss_{L,R}` (OptiTrack track loss). Overall flagged: motherboard 0.90 %, pushT 0.67 %. `segments.json` already excludes them.
|
|
@@ -192,3 +246,4 @@ Per-task `bad_frames.json` flags `intensity_spikes`, `pose_teleports_{L,R}`, `ot
|
|
| 192 |
|
| 193 |
## License
|
| 194 |
[CC-BY-4.0](https://creativecommons.org/licenses/by/4.0/).
|
|
|
|
|
|
| 36 |
|
| 37 |
Dense, contact-rich, synchronized multimodal interaction data collected from **human hands holding handheld GelSight tactile sensors** (no robot arm). Intended for **tactile-visual dynamics / world-model learning**.
|
| 38 |
|
| 39 |
+
> **173 min · 312 k frames @ 30 Hz · 3× RGB + 2× GelSight + 2× wrist + OptiTrack · 3 tasks**
|
| 40 |
+
|
| 41 |
+

|
| 42 |
+
|
| 43 |
+
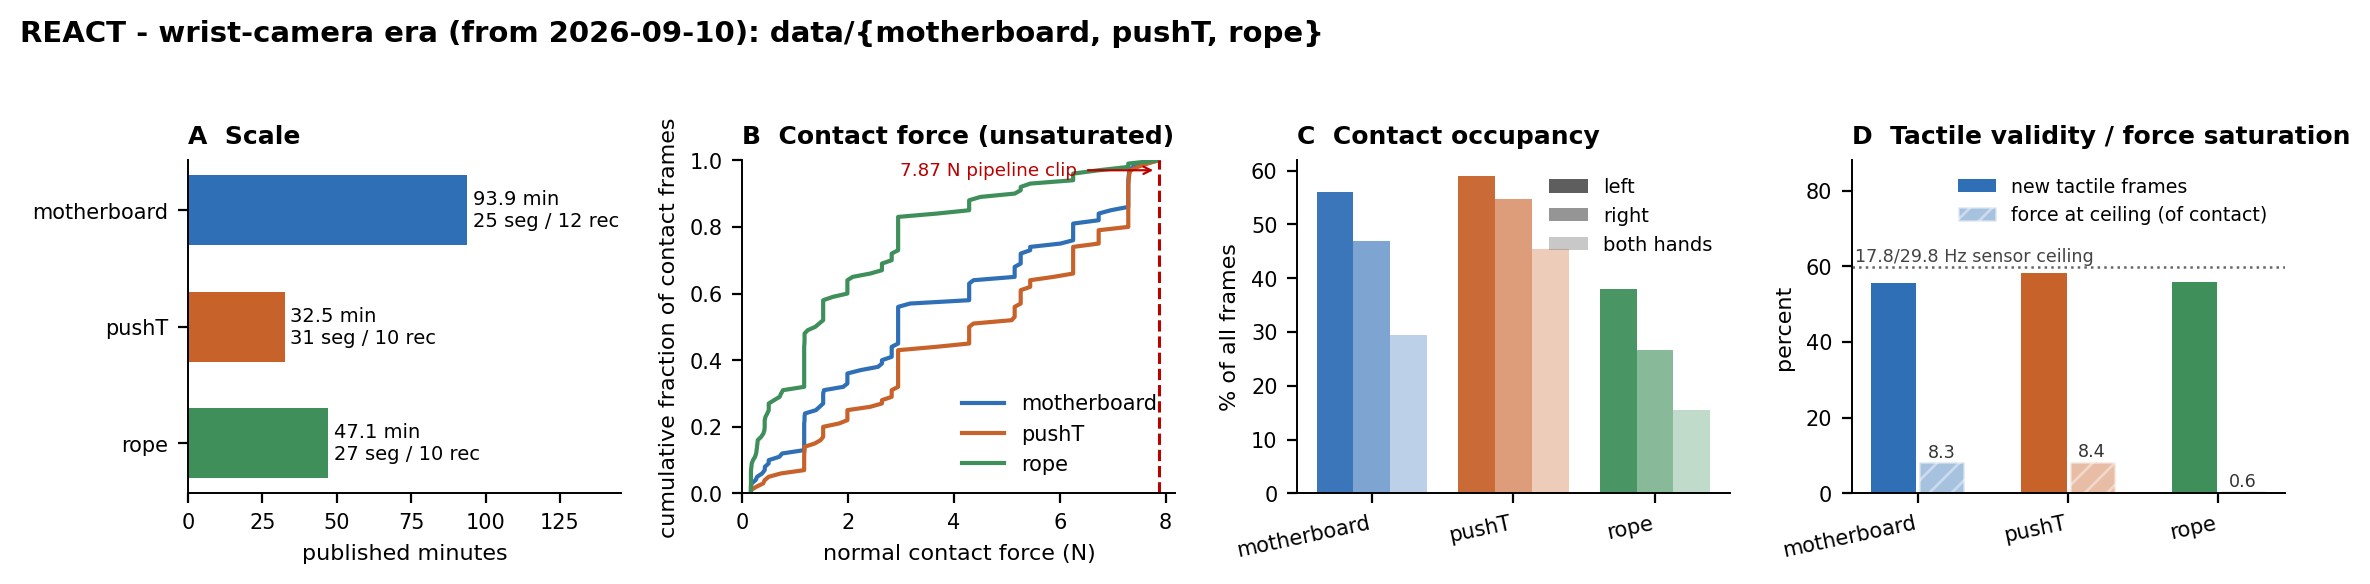
*Per-task scale, contact-force distribution, bimanual contact occupancy, and tactile validity for the wrist-camera era. Panel B shows the ECDF of unsaturated contact force; the steps are real — the force calibration ends in an isotonic (piecewise-constant) stage, so its output is quantised. See [Known limits](#known-limits).*
|
| 44 |
+
|
| 45 |
+
## What is published
|
| 46 |
+
|
| 47 |
+
Episodes are **cut into clean segments** before release: every span a defect
|
| 48 |
+
detector flagged is removed, and each remaining span of at least 30 s is
|
| 49 |
+
published as its own episode. So the flagged frames are the **gaps between**
|
| 50 |
+
published episodes, and you do not need to consult `bad_frames.json` before
|
| 51 |
+
training on `data/<task>/`.
|
| 52 |
+
|
| 53 |
+
| Task | Source recordings | Published segments | Duration | Median contact force |
|
| 54 |
+
|---|---|---|---|---|
|
| 55 |
+
| **motherboard** | 12 | 25 | 93.9 min | 2.94 N |
|
| 56 |
+
| **pushT** | 10 | 31 | 32.5 min | 4.29 N |
|
| 57 |
+
| **rope** | 10 | 27 | 47.1 min | 1.38 N |
|
| 58 |
+
| *(total)* | *32* | *83* | *173.5 min* | |
|
| 59 |
+
|
| 60 |
+
`data/validation/` holds a separate 5-segment / 7.1 min set from an
|
| 61 |
+
earlier session (2026-09-09) that carries **different wrist cameras and a
|
| 62 |
+
different calibration epoch**. It is not a random held-out split — training on
|
| 63 |
+
`data/<task>` and evaluating there measures domain shift. See its own README.
|
| 64 |
+
|
| 65 |
+

|
| 66 |
+
|
| 67 |
+
## Known limits
|
| 68 |
+
|
| 69 |
+
Read these before using the force channel or the tactile stream.
|
| 70 |
+
|
| 71 |
+
**Force saturates at 7.87 N.** The calibration was fitted on presses up to
|
| 72 |
+
8 N, and its final stage is an isotonic regression, which cannot extrapolate —
|
| 73 |
+
anything above the fitted range is clipped to 7.87 N. Affected fraction of
|
| 74 |
+
**contact** frames:
|
| 75 |
+
- `motherboard` — 8.3 %
|
| 76 |
+
- `pushT` — 8.4 %
|
| 77 |
+
- `rope` — 0.6 %
|
| 78 |
+
|
| 79 |
+
Treat those frames as **right-censored**, not as measurements. The force labels
|
| 80 |
+
also carry roughly **1 N of held-out error**, so do not compare models at 0.1 N
|
| 81 |
+
resolution.
|
| 82 |
+
|
| 83 |
+
**Tactile frames repeat.** The GelSight Mini tops out near 17.8 Hz while rows
|
| 84 |
+
are written at 29.8 Hz, so only about **56–58 %** of rows are a fresh sensor
|
| 85 |
+
reading. `tactile_{left,right}_is_new` marks which. Train tactile dynamics on
|
| 86 |
+
the flagged rows, not on all of them.
|
| 87 |
+
|
| 88 |
+
**`duration_s` is `n_frames / 30`**, the nominal write tick. The RealSense
|
| 89 |
+
streams actually run at 29.80 Hz.
|
| 90 |
|
| 91 |
## Format — LeRobot-style video release
|
| 92 |
|
| 93 |
+
Each episode ships as **7 MP4 video streams** (640×480, H.264) + a **per-frame parquet** of poses and contact metrics. This matches how LeRobot / DROID / Open X-Embodiment ship manipulation data: tiny on disk (data/ ≈ 21 GB vs ~1.9 TB raw), random-access decodable, training-ready.
|
| 94 |
|
| 95 |
```
|
| 96 |
data/<task>/
|
|
|
|
| 100 |
│ └── calibration.json # epoch, applies-to dates, RMSE, chain
|
| 101 |
├── videos/<date>/episode_NNN/
|
| 102 |
│ ├── view_left.mp4 view_middle.mp4 view_right.mp4 # 640×480 RGB
|
| 103 |
+
│ ├── tactile_left.mp4 tactile_right.mp4 # 640×480 GelSight
|
| 104 |
+
│ └── wrist_left.mp4 wrist_right.mp4 # 640×480 wrist cams
|
| 105 |
├── meta/<date>/episode_NNN.parquet # one row per frame (see below)
|
| 106 |
├── episodes.jsonl # one row per episode
|
| 107 |
├── segments.json # clean-segment index (no bad frames)
|
|
|
|
| 114 |
|---|---|---|
|
| 115 |
| `frame_idx` / `frame_index` | int | 0…T-1, matches MP4 frame index |
|
| 116 |
| `episode` / `episode_index` | str / int | source episode key and its 0-based index within the task |
|
| 117 |
+
| `task` / `task_index` | str / int | task name and index (0=motherboard, 1=pushT, 2=rope) |
|
| 118 |
+
| `force_{L,R}_normal_n` | float32 | estimated normal contact force (N) — **censored at 7.87 N**, see Known limits |
|
| 119 |
+
| `force_{L,R}_penetration_mm` | float32 | gel penetration depth (mm) |
|
| 120 |
+
| `force_{L,R}_source_frame` | int | the raw tactile frame this force was computed from |
|
| 121 |
+
| `tactile_{L,R}_is_new` | bool | True when the row is a fresh sensor reading, not a repeat |
|
| 122 |
| `timestamp` | float64 | camera clock (s) |
|
| 123 |
| `sensor_left_pose`, `sensor_right_pose` | list[7] | OptiTrack world pose of each GelSight (xyz metres + quat **xyzw**, scalar-LAST — `scipy...Rotation.from_quat` takes it as-is) |
|
| 124 |
| `object_pose` | list[7] | OptiTrack world pose of the manipulated object (NaN where the object body was not tracked — e.g. all pushT) |
|
|
|
|
| 137 |
- Decode with PyAV (`frame.to_ndarray()` → `(480, 640)` uint16). cv2 cannot read 16-bit video.
|
| 138 |
- Load via `ReactVideoDataset(..., load_depth=True)`.
|
| 139 |
|
| 140 |
+
## Tasks and calibration
|
| 141 |
|
| 142 |
+
| Task | Dates | Source recordings | Published segments | Duration | Calibration epoch |
|
| 143 |
|---|---|---|---|---|---|
|
| 144 |
+
| **motherboard** | 2026-09-11, 2026-09-12 | 12 | 25 | 93.9 min | 2026-09-09 |
|
| 145 |
+
| **pushT** | 2026-09-10, 2026-09-11 | 10 | 31 | 32.5 min | 2026-09-09 |
|
| 146 |
+
| **rope** | 2026-09-11 | 10 | 27 | 47.1 min | 2026-09-09 |
|
| 147 |
+
| **validation** | 2026-09-09 | 5 | 9 | 25.2 min | 2026-09-09 |
|
| 148 |
|
| 149 |
+
All currently published sessions share the **2026-09-09** extrinsics. Camera
|
| 150 |
+
extrinsics are used only for the projection overlay; **stored poses are
|
| 151 |
+
OptiTrack world-frame** and independent of calibration. Poses are **Z-up**.
|
| 152 |
|
| 153 |
+
`data/validation/` mixes two tasks and two sessions of the same date, and its
|
| 154 |
+
episode numbers are **not** the recorder's — the recorder reuses numbers within
|
| 155 |
+
a date, so every row there carries `source_recording`. Read its README before
|
| 156 |
+
using it.
|
| 157 |
|
| 158 |
+
See [`tasks.json`](tasks.json) for the machine-readable registry.
|
| 159 |
|
| 160 |
## Downloading — depth is optional
|
| 161 |
|
| 162 |
+
The dataset splits into a **lightweight core** (RGB + tactile + wrist + poses, ~21 GB) and an **optional depth tree** (`data/validation/depth/`, ~6 GB lossless; only the 2026-09-09 session has depth). Depth lives in its own subtree so you can skip it entirely.
|
| 163 |
|
| 164 |
```python
|
| 165 |
from huggingface_hub import snapshot_download
|
| 166 |
|
| 167 |
+
# Core only — RGB + tactile + wrist + parquet, NO depth (~21 GB)
|
| 168 |
snapshot_download("yxma/React", repo_type="dataset",
|
| 169 |
ignore_patterns=["*/depth/*"])
|
| 170 |
|
| 171 |
+
# Everything including depth (~27 GB)
|
| 172 |
snapshot_download("yxma/React", repo_type="dataset")
|
| 173 |
|
| 174 |
# One task only
|
|
|
|
| 220 |
GelSight centre moves 0.000000 px between the two conventions. Newtons,
|
| 221 |
timestamps and every video frame are identical either way.
|
| 222 |
|
| 223 |
+
## Tactile acquisition latency — does NOT affect any published episode
|
| 224 |
|
| 225 |
+
Recordings up to and including **2026-06-18** had a GelSight-vs-camera capture
|
| 226 |
+
lag of ≈15 frames (~0.5 s), caused by a recording-side `cv2.VideoCapture` V4L2
|
| 227 |
+
buffer that was never flushed. It was fixed in the rig on **2026-06-27**.
|
|
|
|
|
|
|
|
|
|
| 228 |
|
| 229 |
+
**Every episode currently published was recorded on 2026-09-09 or later**, and
|
| 230 |
+
each one carries per-sensor GelSight timestamps, so the tactile stream is
|
| 231 |
+
resampled onto the camera clock during the build. Verified across all 80
|
| 232 |
+
published force records: `tactile_timestamped` is True for every one, and
|
| 233 |
+
`tactile_align.gel_lag_frames` returns **0**.
|
| 234 |
|
| 235 |
+
**Do not apply a 15-frame shift.** Doing so would introduce the half-second
|
| 236 |
+
misalignment this note used to warn about. The correction is relevant only if
|
| 237 |
+
you obtain one of the withdrawn 2026-05/06 releases.
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 238 |
|
| 239 |
## Data quality
|
| 240 |
Per-task `bad_frames.json` flags `intensity_spikes`, `pose_teleports_{L,R}`, `ot_loss_{L,R}` (OptiTrack track loss). Overall flagged: motherboard 0.90 %, pushT 0.67 %. `segments.json` already excludes them.
|
|
|
|
| 246 |
|
| 247 |
## License
|
| 248 |
[CC-BY-4.0](https://creativecommons.org/licenses/by/4.0/).
|
| 249 |
+
|
assets/stats_arducam_session.png
ADDED
|
Git LFS Details
|
assets/stats_wrist_era.png
ADDED
|
Git LFS Details
|