
Spaces:
Running

Running
force recovery: methods, evaluation, debug log
Browse files- .gitattributes +2 -0
- assets/feats_marker_removal.png +3 -0
- assets/gallery/clip_motherboard_episode_003_left.mp4 +2 -2
- assets/gallery/clip_motherboard_episode_008_left.mp4 +2 -2
- assets/gallery/clip_motherboard_episode_011_left.mp4 +2 -2
- assets/gallery/clip_motherboard_episode_017_left.mp4 +2 -2
- assets/gallery/clip_pushT_episode_001_right.mp4 +2 -2
- assets/gallery/feats_00.png +2 -2
- assets/gallery/feats_01.png +2 -2
- assets/gallery/feats_02.png +2 -2
- assets/gallery/feats_03.png +2 -2
- assets/gallery/feats_04.png +2 -2
- assets/gallery/feats_05.png +2 -2
- assets/gallery/metrics.json +1 -0
- assets/mnist_examples.png +3 -0
- assets/results_cnc.png +2 -2
- assets/results_feats.png +2 -2
- assets/results_glowtact.png +2 -2
- debug_pipeline.html +19 -2
- debug_pipeline_zh.html +6 -2
- index.html +50 -10
- method.html +82 -6
- method_zh.html +62 -1
- recon_workbench.html +67 -25
- results.html +153 -10
- results_zh.html +111 -9
.gitattributes
CHANGED
|
@@ -118,3 +118,5 @@ assets/recon/glowtact_16.png filter=lfs diff=lfs merge=lfs -text
|
|
| 118 |
assets/recon/glowtact_17.png filter=lfs diff=lfs merge=lfs -text
|
| 119 |
assets/recon/glowtact_18.png filter=lfs diff=lfs merge=lfs -text
|
| 120 |
assets/recon/glowtact_19.png filter=lfs diff=lfs merge=lfs -text
|
|
|
|
|
|
|
|
|
| 118 |
assets/recon/glowtact_17.png filter=lfs diff=lfs merge=lfs -text
|
| 119 |
assets/recon/glowtact_18.png filter=lfs diff=lfs merge=lfs -text
|
| 120 |
assets/recon/glowtact_19.png filter=lfs diff=lfs merge=lfs -text
|
| 121 |
+
assets/feats_marker_removal.png filter=lfs diff=lfs merge=lfs -text
|
| 122 |
+
assets/mnist_examples.png filter=lfs diff=lfs merge=lfs -text
|
assets/feats_marker_removal.png
ADDED

|
Git LFS Details
|
assets/gallery/clip_motherboard_episode_003_left.mp4
CHANGED
|
@@ -1,3 +1,3 @@
|
|
| 1 |
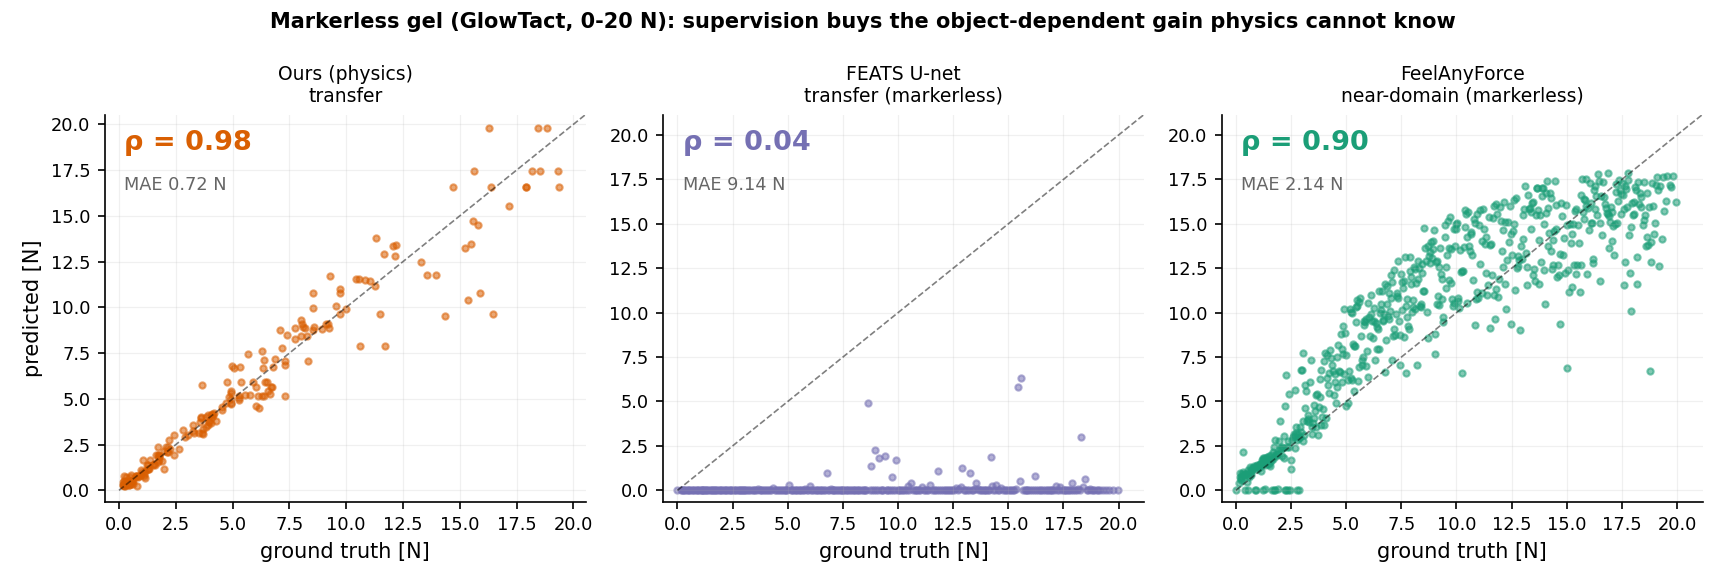
version https://git-lfs.github.com/spec/v1
|
| 2 |
-
oid sha256:
|
| 3 |
-
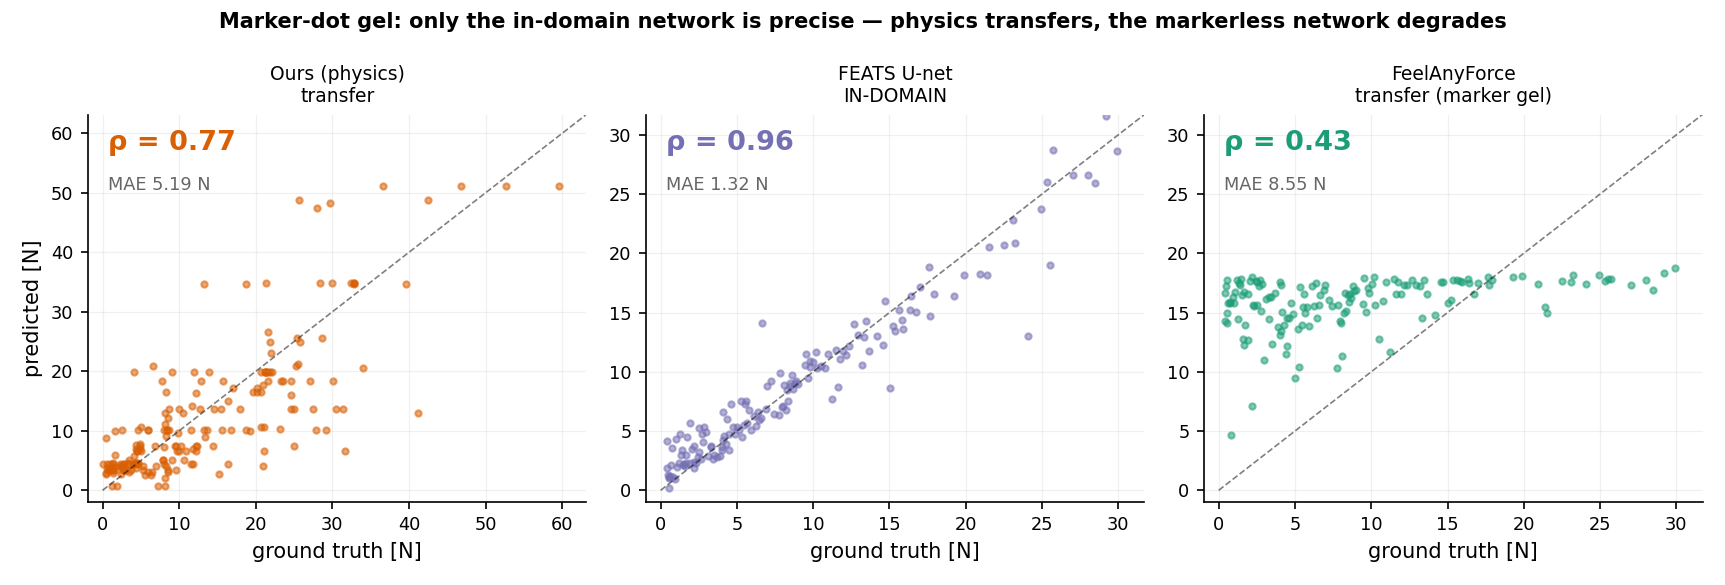
size
|
|
|
|
| 1 |
version https://git-lfs.github.com/spec/v1
|
| 2 |
+
oid sha256:2b63045cce3dfc98bf332526f7b0325395315935ba13ac6167c2403c7ed8416a
|
| 3 |
+
size 165343
|
assets/gallery/clip_motherboard_episode_008_left.mp4
CHANGED
|
@@ -1,3 +1,3 @@
|
|
| 1 |
version https://git-lfs.github.com/spec/v1
|
| 2 |
-
oid sha256:
|
| 3 |
-
size
|
|
|
|
| 1 |
version https://git-lfs.github.com/spec/v1
|
| 2 |
+
oid sha256:c3e6f513bd3edd081ea1a41906c15a886ff76bfb5fe07b67ce6beaec3965d5fd
|
| 3 |
+
size 166428
|
assets/gallery/clip_motherboard_episode_011_left.mp4
CHANGED
|
@@ -1,3 +1,3 @@
|
|
| 1 |
version https://git-lfs.github.com/spec/v1
|
| 2 |
-
oid sha256:
|
| 3 |
-
size
|
|
|
|
| 1 |
version https://git-lfs.github.com/spec/v1
|
| 2 |
+
oid sha256:111be423f21bef84cfe63e6fff218dc35e15ae3330d128240084e93a7b971ee6
|
| 3 |
+
size 156306
|
assets/gallery/clip_motherboard_episode_017_left.mp4
CHANGED
|
@@ -1,3 +1,3 @@
|
|
| 1 |
version https://git-lfs.github.com/spec/v1
|
| 2 |
-
oid sha256:
|
| 3 |
-
size
|
|
|
|
| 1 |
version https://git-lfs.github.com/spec/v1
|
| 2 |
+
oid sha256:d5d44f81ca19728e9480b8a67f2d3cffb1625e48be5833d83d30e127f28a4807
|
| 3 |
+
size 214487
|
assets/gallery/clip_pushT_episode_001_right.mp4
CHANGED
|
@@ -1,3 +1,3 @@
|
|
| 1 |
version https://git-lfs.github.com/spec/v1
|
| 2 |
-
oid sha256:
|
| 3 |
-
size
|
|
|
|
| 1 |
version https://git-lfs.github.com/spec/v1
|
| 2 |
+
oid sha256:6009cd9b75d7054d76010a1030fd24ec0b130c3104865e2ccacbca038777e66a
|
| 3 |
+
size 149351
|
assets/gallery/feats_00.png
CHANGED
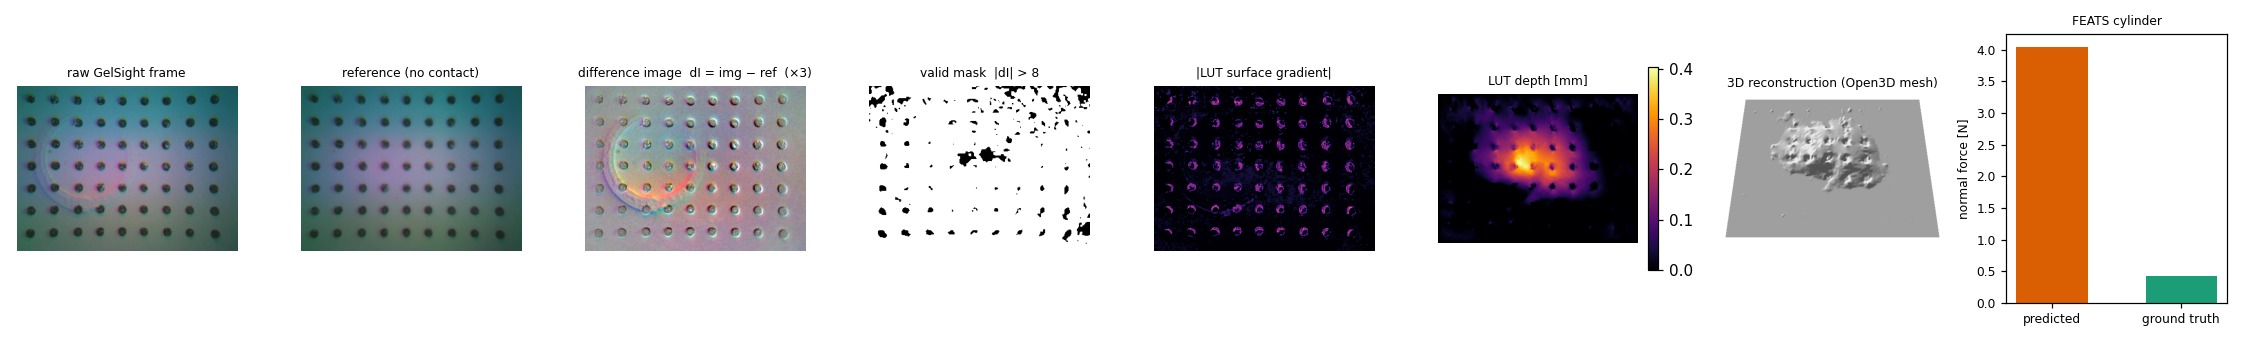
|
Git LFS Details
|

|
Git LFS Details
|
assets/gallery/feats_01.png
CHANGED
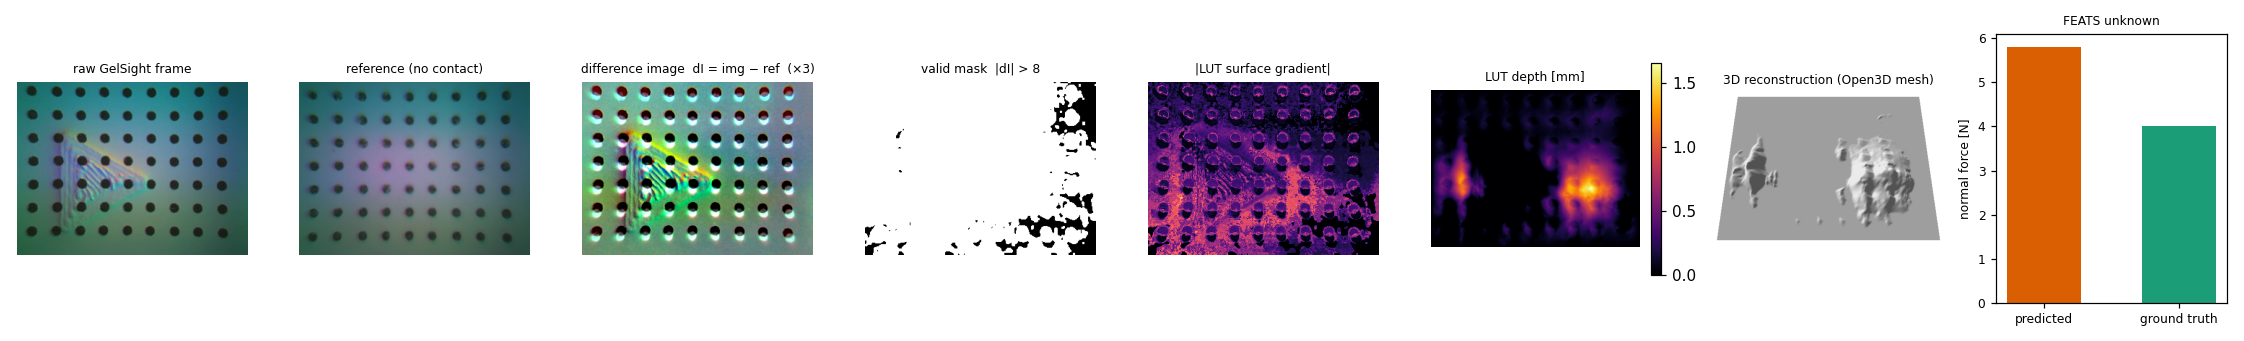
|
Git LFS Details
|

|
Git LFS Details
|
assets/gallery/feats_02.png
CHANGED
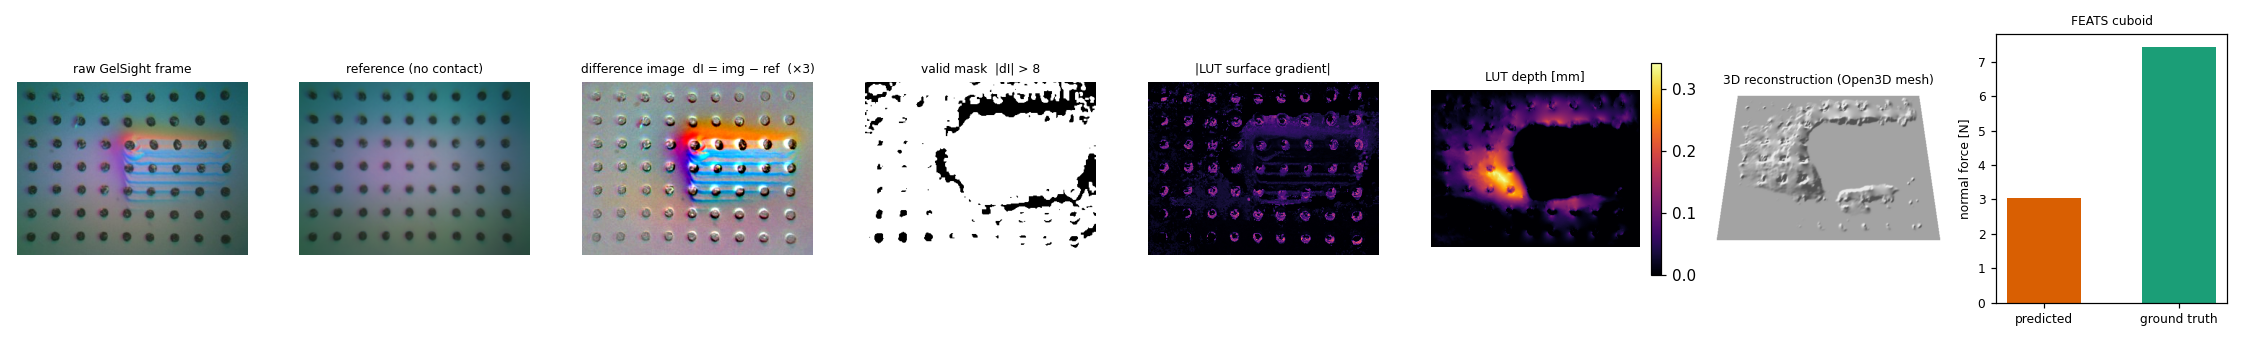
|
Git LFS Details
|

|
Git LFS Details
|
assets/gallery/feats_03.png
CHANGED
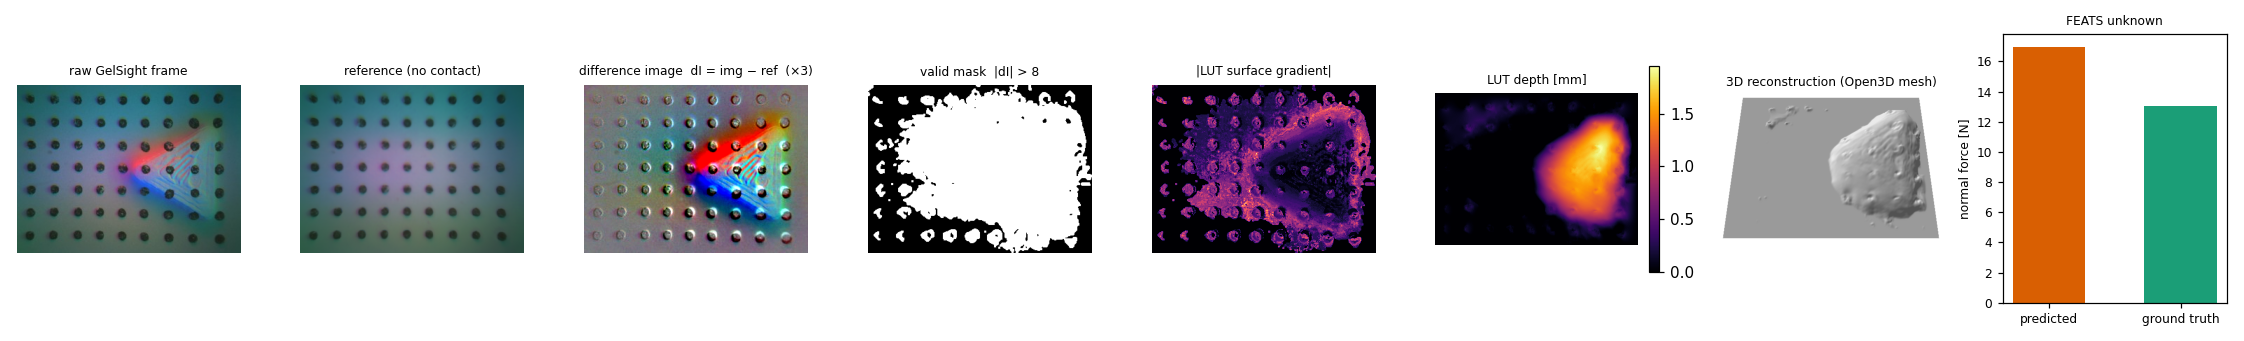
|
Git LFS Details
|

|
Git LFS Details
|
assets/gallery/feats_04.png
CHANGED
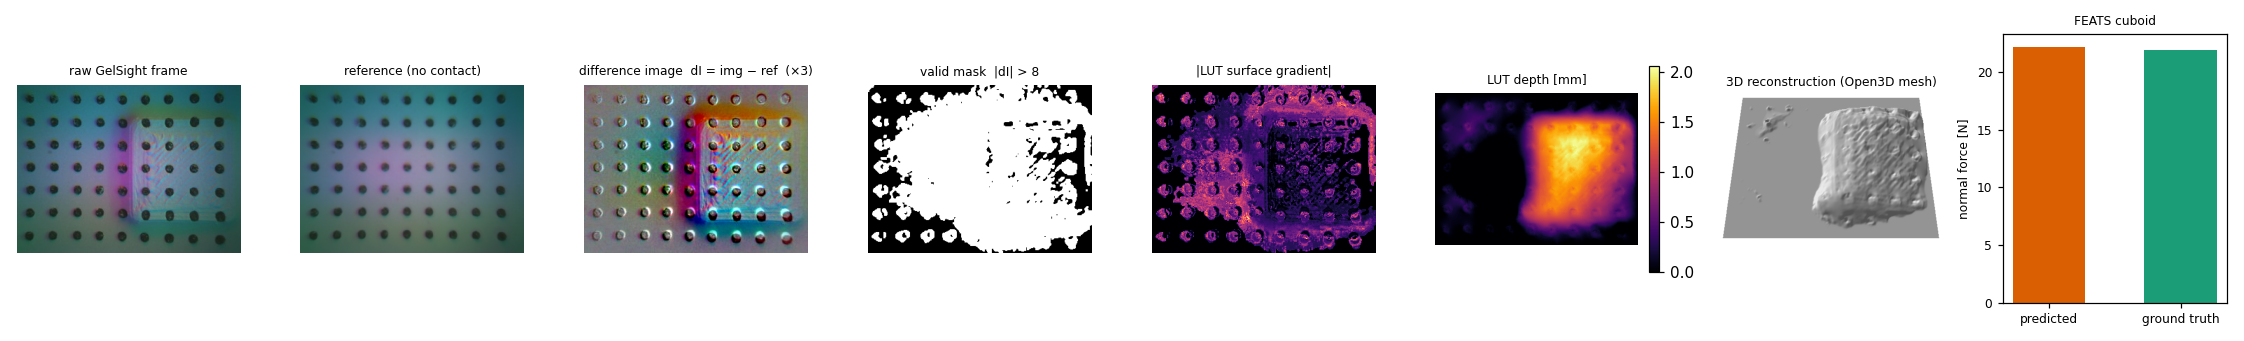
|
Git LFS Details
|

|
Git LFS Details
|
assets/gallery/feats_05.png
CHANGED
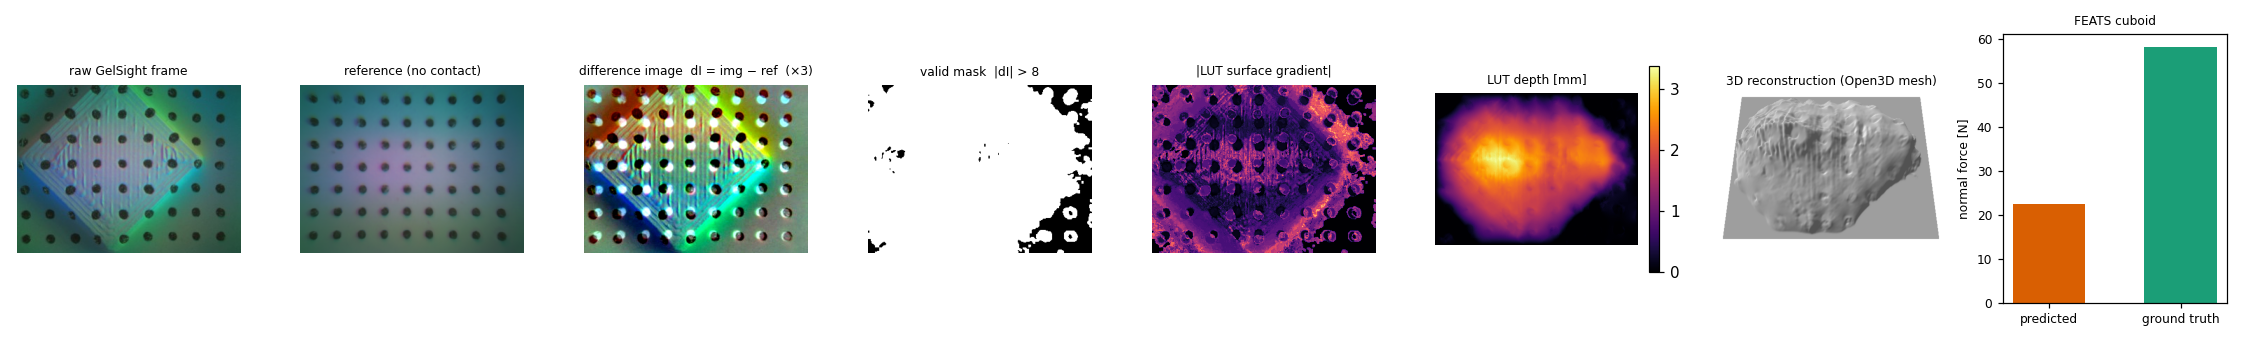
|
Git LFS Details
|

|
Git LFS Details
|
assets/gallery/metrics.json
CHANGED
|
@@ -9,5 +9,6 @@
|
|
| 9 |
"rho": 0.7571224581862139,
|
| 10 |
"mae_n": 5.371393132649007
|
| 11 |
},
|
|
|
|
| 12 |
"pipeline": "lut_v2"
|
| 13 |
}
|
|
|
|
| 9 |
"rho": 0.7571224581862139,
|
| 10 |
"mae_n": 5.371393132649007
|
| 11 |
},
|
| 12 |
+
"feats_geometry": "marker-inpainted depth/mesh; force from stages()",
|
| 13 |
"pipeline": "lut_v2"
|
| 14 |
}
|
assets/mnist_examples.png
ADDED
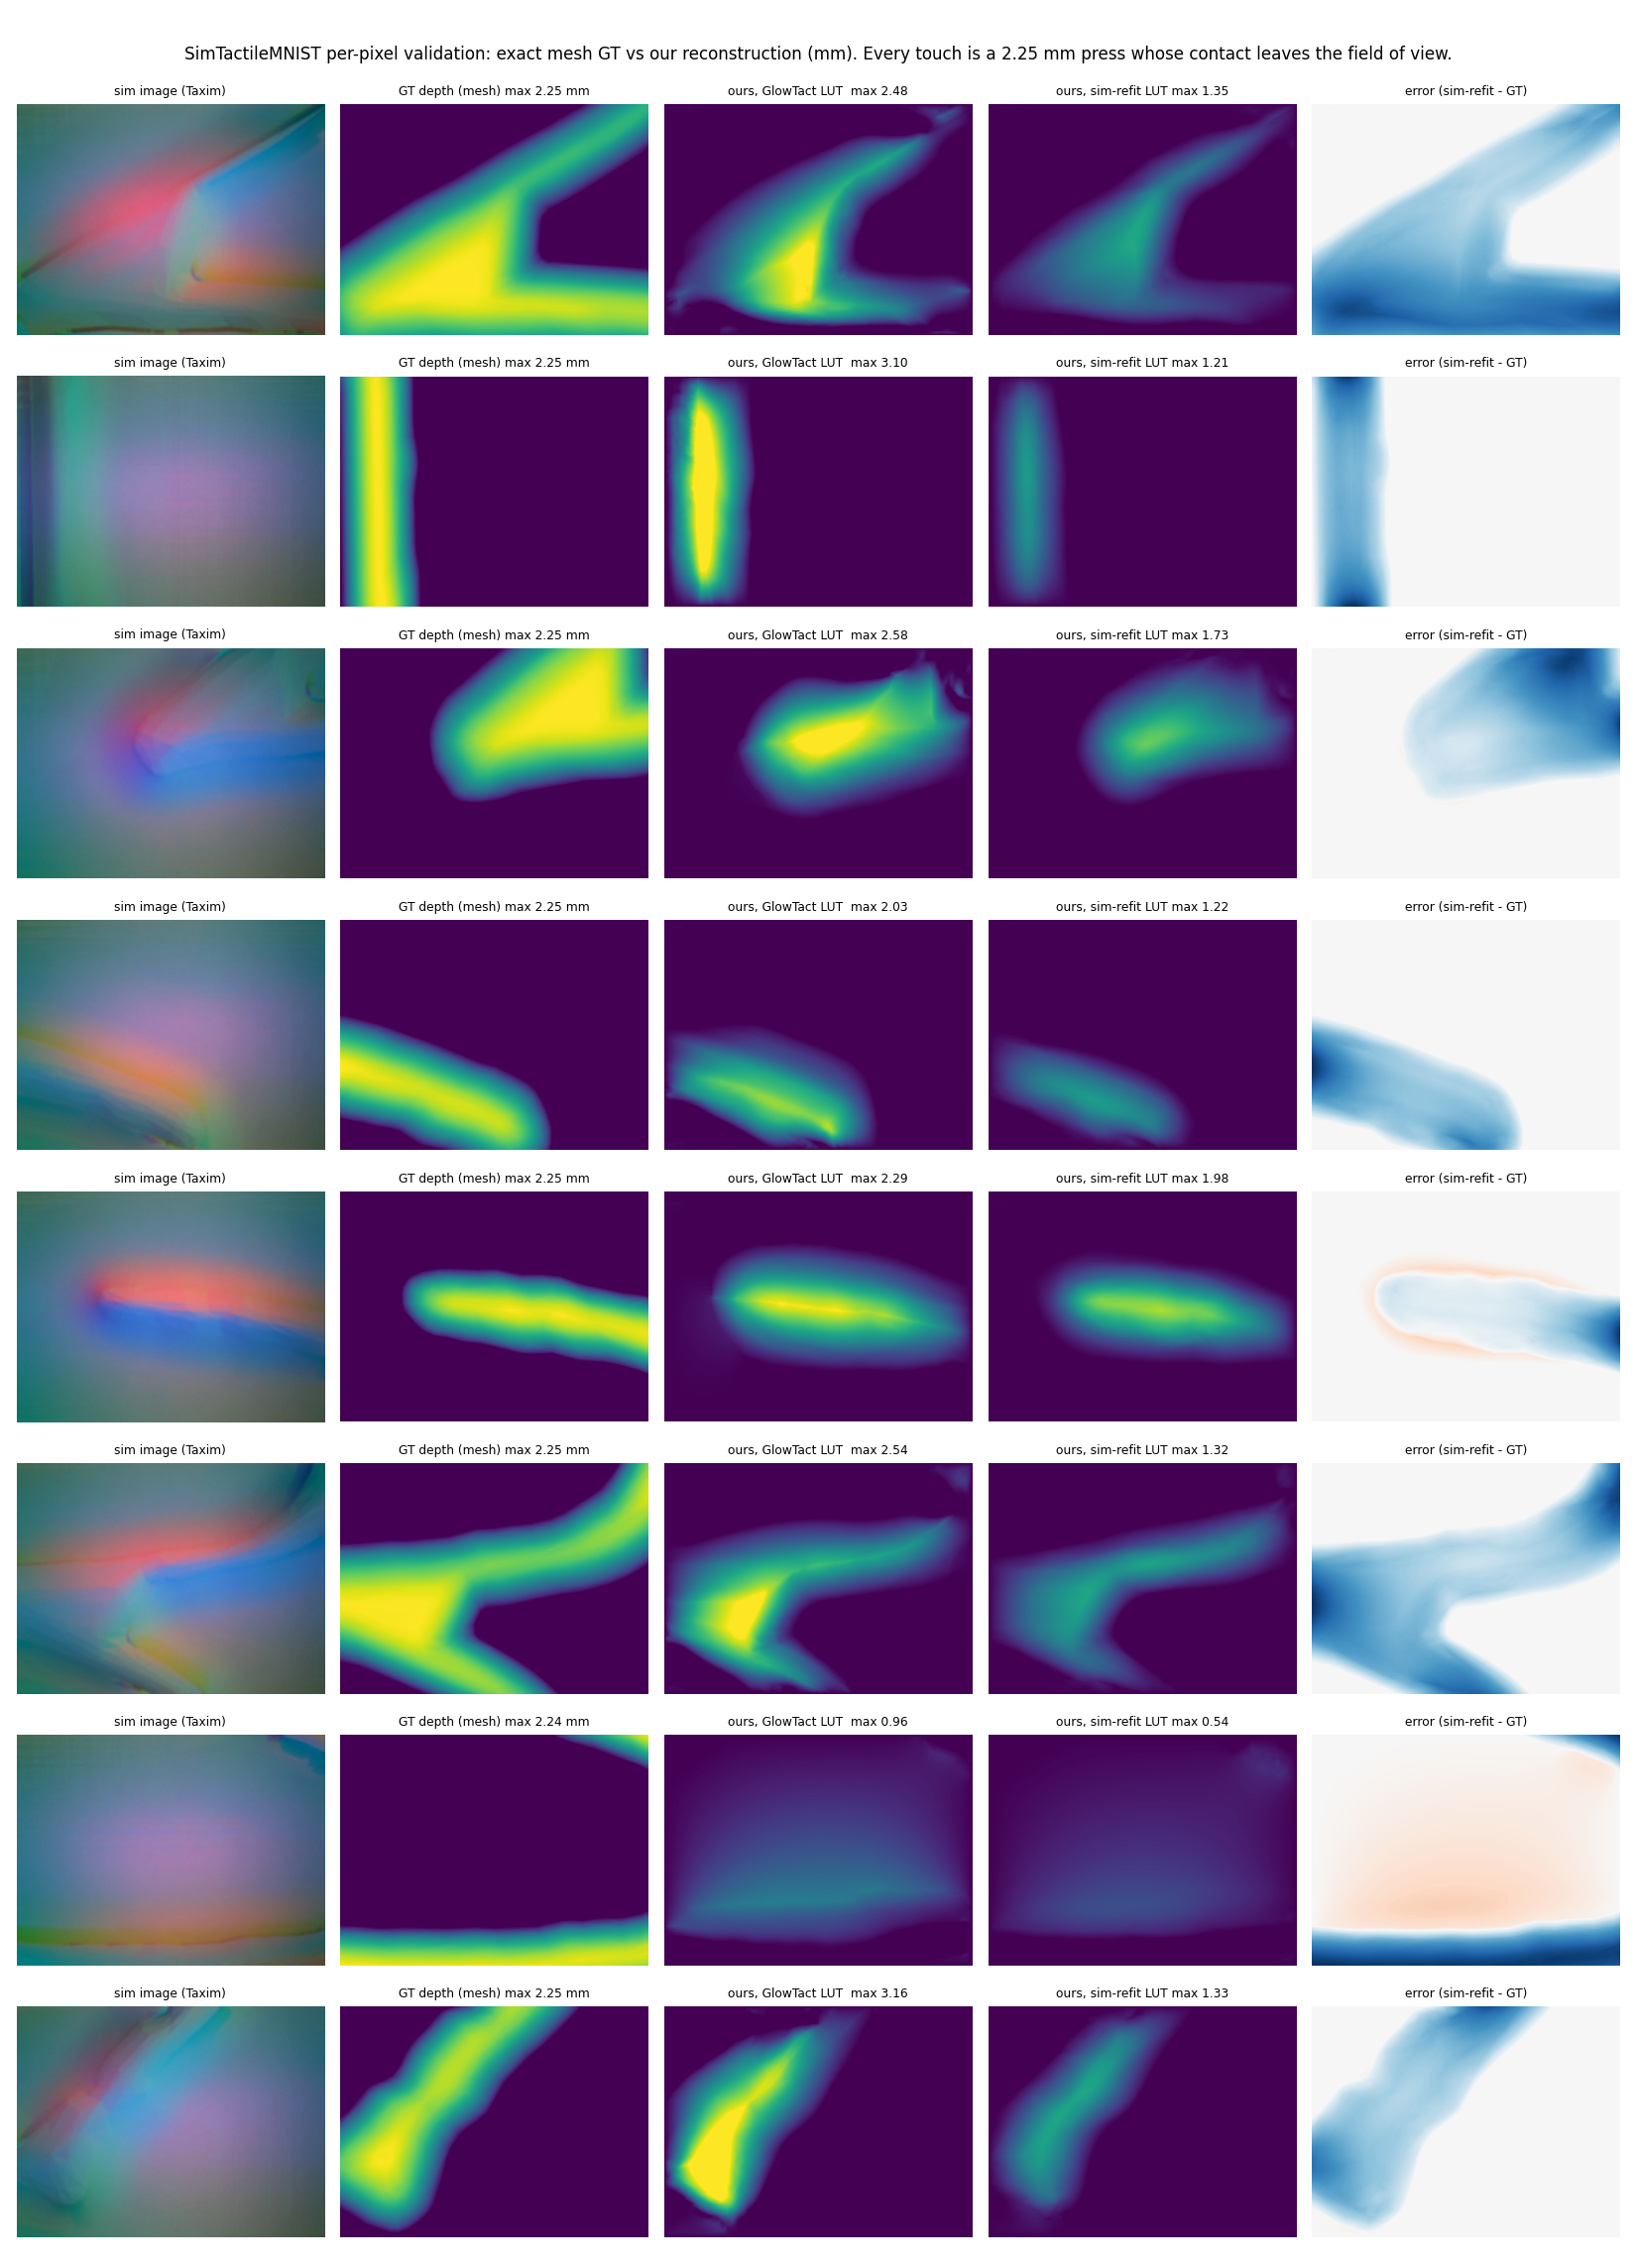
|
Git LFS Details
|
assets/results_cnc.png
CHANGED
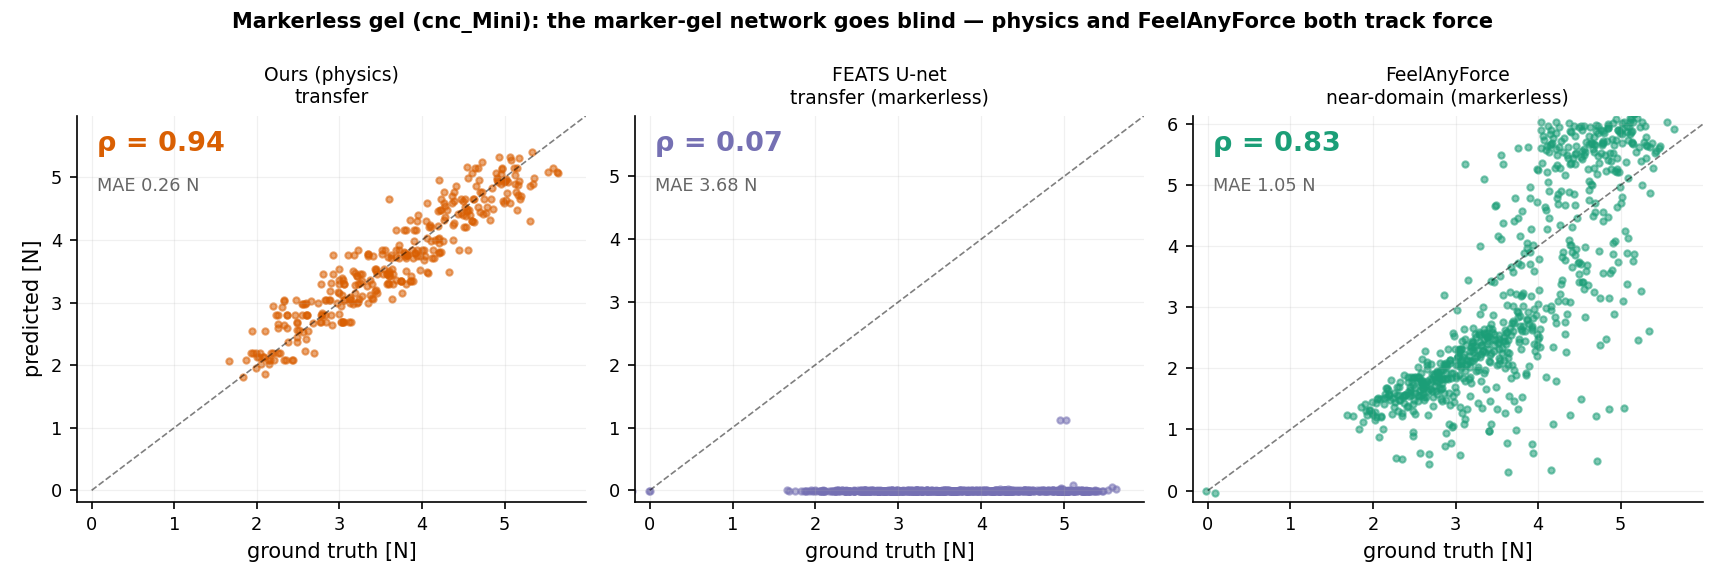
|
Git LFS Details
|

|
Git LFS Details
|
assets/results_feats.png
CHANGED
|
Git LFS Details
|

|
Git LFS Details
|
assets/results_glowtact.png
CHANGED
|
Git LFS Details
|

|
Git LFS Details
|
debug_pipeline.html
CHANGED
|
@@ -31,7 +31,8 @@ th,td{padding:7px 10px;border-bottom:1px solid var(--line);text-align:right}
|
|
| 31 |
th{color:var(--dim);font-family:'IBM Plex Mono',monospace;font-size:.72rem;
|
| 32 |
text-transform:uppercase;letter-spacing:.08em}
|
| 33 |
td:first-child,th:first-child{text-align:left}
|
| 34 |
-
img{max-width:100%;border-radius:8px;border:1px solid var(--line);
|
|
|
|
| 35 |
a{color:#4fd8e0}a:hover{color:var(--force)}
|
| 36 |
.pill{display:inline-block;border:1px solid var(--line);border-radius:999px;
|
| 37 |
padding:3px 12px;font-size:.75rem;font-family:'IBM Plex Mono',monospace;
|
|
@@ -77,6 +78,22 @@ relied on.</p>
|
|
| 77 |
z-supervised gain field. Dot-type control: FEATS presses are always centered,
|
| 78 |
so the raw pipeline already gives ρ=0.72 there, vs 0.46 raw on GlowTact —
|
| 79 |
the gain field and scope, not markers, are the binding factors.</p>
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 80 |
<h2>GlowTact — markerless, the LUT's home sensor (control)</h2><div class='srow'>
|
| 81 |
<img src='assets/debug/glowtact_01.png' loading='lazy'>
|
| 82 |
<img src='assets/debug/glowtact_04.png' loading='lazy'>
|
|
@@ -93,7 +110,7 @@ the gain field and scope, not markers, are the binding factors.</p>
|
|
| 93 |
<img src='assets/debug/cnc_14.png' loading='lazy'>
|
| 94 |
<img src='assets/debug/cnc_17.png' loading='lazy'>
|
| 95 |
</div>
|
| 96 |
-
<h2>FEATS — dot/marker
|
| 97 |
<img src='assets/debug/feats_01.png' loading='lazy'>
|
| 98 |
<img src='assets/debug/feats_04.png' loading='lazy'>
|
| 99 |
<img src='assets/debug/feats_08.png' loading='lazy'>
|
|
|
|
| 31 |
th{color:var(--dim);font-family:'IBM Plex Mono',monospace;font-size:.72rem;
|
| 32 |
text-transform:uppercase;letter-spacing:.08em}
|
| 33 |
td:first-child,th:first-child{text-align:left}
|
| 34 |
+
img,video{max-width:100%;height:auto;border-radius:8px;border:1px solid var(--line);
|
| 35 |
+
display:block;margin:12px auto}
|
| 36 |
a{color:#4fd8e0}a:hover{color:var(--force)}
|
| 37 |
.pill{display:inline-block;border:1px solid var(--line);border-radius:999px;
|
| 38 |
padding:3px 12px;font-size:.75rem;font-family:'IBM Plex Mono',monospace;
|
|
|
|
| 78 |
z-supervised gain field. Dot-type control: FEATS presses are always centered,
|
| 79 |
so the raw pipeline already gives ρ=0.72 there, vs 0.46 raw on GlowTact —
|
| 80 |
the gain field and scope, not markers, are the binding factors.</p>
|
| 81 |
+
<h2>The same failure mode, on four datasets</h2>
|
| 82 |
+
<p>The cnc story above is not a cnc story. Exact per-pixel ground truth on
|
| 83 |
+
Tactile MNIST shows the identical effect from the other side: 420/420 touches
|
| 84 |
+
have a contact that runs off the pad, and a control that moves one sphere cap
|
| 85 |
+
from mid-pad to the edge collapses its reconstructed peak <b>1.39 → 0.30
|
| 86 |
+
mm</b> against a 0.90 mm truth. Sparsh shows it a third time — its clipped
|
| 87 |
+
frames carry the <i>highest</i> median force and still score worse. The cause
|
| 88 |
+
is structural: the Poisson solve's zero boundary cannot represent a surface
|
| 89 |
+
that leaves the frame, so a clipped contact is integrated as if it ended at the
|
| 90 |
+
image edge. <b>Contact visibility, not force range or gel type, is this
|
| 91 |
+
pipeline's biggest external failure mode.</b></p>
|
| 92 |
+
<p>The same ground truth also puts a number on the mask you see in column 4:
|
| 93 |
+
against the true contact region it scores IoU <b>0.614</b> with recall
|
| 94 |
+
<b>0.917</b> and over-segmentation <b>0.531</b> — it finds nearly all of the
|
| 95 |
+
contact, then adds half as much again in halo. That is why a halo pedestal has
|
| 96 |
+
to be subtracted before any 3D view.</p>
|
| 97 |
<h2>GlowTact — markerless, the LUT's home sensor (control)</h2><div class='srow'>
|
| 98 |
<img src='assets/debug/glowtact_01.png' loading='lazy'>
|
| 99 |
<img src='assets/debug/glowtact_04.png' loading='lazy'>
|
|
|
|
| 110 |
<img src='assets/debug/cnc_14.png' loading='lazy'>
|
| 111 |
<img src='assets/debug/cnc_17.png' loading='lazy'>
|
| 112 |
</div>
|
| 113 |
+
<h2>FEATS — dot/marker gel; these panels are the FORCE path, so the dots are still in them (marker inpainting ships for geometry only)</h2><div class='srow'>
|
| 114 |
<img src='assets/debug/feats_01.png' loading='lazy'>
|
| 115 |
<img src='assets/debug/feats_04.png' loading='lazy'>
|
| 116 |
<img src='assets/debug/feats_08.png' loading='lazy'>
|
debug_pipeline_zh.html
CHANGED
|
@@ -31,7 +31,8 @@ th,td{padding:7px 10px;border-bottom:1px solid var(--line);text-align:right}
|
|
| 31 |
th{color:var(--dim);font-family:'IBM Plex Mono',monospace;font-size:.72rem;
|
| 32 |
text-transform:uppercase;letter-spacing:.08em}
|
| 33 |
td:first-child,th:first-child{text-align:left}
|
| 34 |
-
img{max-width:100%;border-radius:8px;border:1px solid var(--line);
|
|
|
|
| 35 |
a{color:#4fd8e0}a:hover{color:var(--force)}
|
| 36 |
.pill{display:inline-block;border:1px solid var(--line);border-radius:999px;
|
| 37 |
padding:3px 12px;font-size:.75rem;font-family:'IBM Plex Mono',monospace;
|
|
@@ -64,6 +65,9 @@ border-radius:6px;margin:4px 0}</style></head><body><div class="wrap">
|
|
| 64 |
<td><b>0.94 0.94 0.93 0.91 0.95 0.95</b></td><td><b>0.941</b></td>
|
| 65 |
<td><b>0.26 N</b></td></tr></table>
|
| 66 |
<p class="note">每探头半半分拟合,7 种子,LUT 管线 + z 监督增益场。dot 类型对照:FEATS 按压恒居中,原始管线即得 ρ=0.72,而 GlowTact 原始条件仅 0.46——起决定作用的是增益场与作用域,而非 marker。</p>
|
|
|
|
|
|
|
|
|
|
| 67 |
<h2>GlowTact — 无 marker,LUT 标定所用传感器(对照)</h2><div class='srow'>
|
| 68 |
<img src='assets/debug/glowtact_01.png' loading='lazy'>
|
| 69 |
<img src='assets/debug/glowtact_04.png' loading='lazy'>
|
|
@@ -80,7 +84,7 @@ border-radius:6px;margin:4px 0}</style></head><body><div class="wrap">
|
|
| 80 |
<img src='assets/debug/cnc_14.png' loading='lazy'>
|
| 81 |
<img src='assets/debug/cnc_17.png' loading='lazy'>
|
| 82 |
</div>
|
| 83 |
-
<h2>FEATS — dot/marker
|
| 84 |
<img src='assets/debug/feats_01.png' loading='lazy'>
|
| 85 |
<img src='assets/debug/feats_04.png' loading='lazy'>
|
| 86 |
<img src='assets/debug/feats_08.png' loading='lazy'>
|
|
|
|
| 31 |
th{color:var(--dim);font-family:'IBM Plex Mono',monospace;font-size:.72rem;
|
| 32 |
text-transform:uppercase;letter-spacing:.08em}
|
| 33 |
td:first-child,th:first-child{text-align:left}
|
| 34 |
+
img,video{max-width:100%;height:auto;border-radius:8px;border:1px solid var(--line);
|
| 35 |
+
display:block;margin:12px auto}
|
| 36 |
a{color:#4fd8e0}a:hover{color:var(--force)}
|
| 37 |
.pill{display:inline-block;border:1px solid var(--line);border-radius:999px;
|
| 38 |
padding:3px 12px;font-size:.75rem;font-family:'IBM Plex Mono',monospace;
|
|
|
|
| 65 |
<td><b>0.94 0.94 0.93 0.91 0.95 0.95</b></td><td><b>0.941</b></td>
|
| 66 |
<td><b>0.26 N</b></td></tr></table>
|
| 67 |
<p class="note">每探头半半分拟合,7 种子,LUT 管线 + z 监督增益场。dot 类型对照:FEATS 按压恒居中,原始管线即得 ρ=0.72,而 GlowTact 原始条件仅 0.46——起决定作用的是增益场与作用域,而非 marker。</p>
|
| 68 |
+
<h2>同一个失效模式,出现在四个数据集上</h2>
|
| 69 |
+
<p>上面这个 cnc 的故事其实不只属于 cnc。Tactile MNIST 上精确的逐像素真值从另一侧展示了完全相同的效应:420/420 次触碰的接触都跑出了 pad,而把单个球冠从 pad 中心移到边缘的对照,使重建峰值从 <b>1.39 塌到 0.30 mm</b>(真值 0.90 mm)。Sparsh 是第三次印证——它被裁切的帧力中位数<i>最高</i>,得分却更差。原因是结构性的:Poisson 求解的零边界无法表示跑出画面的曲面,所以被裁切的接触会被当成在图像边缘就结束了。<b>接触可见性——而不是力程或 gel 类型——才是这条管线最大的外部失效模式。</b></p>
|
| 70 |
+
<p>同一份真值也给第 4 列那个掩码定了量:相对真实接触区域,它的 IoU 为 <b>0.614</b>,召回 <b>0.917</b>,过分割 <b>0.531</b>——它几乎找全了接触,然后又多加了半个接触面积的光晕。这正是任何 3D 视图之前都必须先减掉光晕基座的原因。</p>
|
| 71 |
<h2>GlowTact — 无 marker,LUT 标定所用传感器(对照)</h2><div class='srow'>
|
| 72 |
<img src='assets/debug/glowtact_01.png' loading='lazy'>
|
| 73 |
<img src='assets/debug/glowtact_04.png' loading='lazy'>
|
|
|
|
| 84 |
<img src='assets/debug/cnc_14.png' loading='lazy'>
|
| 85 |
<img src='assets/debug/cnc_17.png' loading='lazy'>
|
| 86 |
</div>
|
| 87 |
+
<h2>FEATS — dot/marker gel;这里的面板是力的路径,所以点仍然在图里(marker 修补只用于几何)</h2><div class='srow'>
|
| 88 |
<img src='assets/debug/feats_01.png' loading='lazy'>
|
| 89 |
<img src='assets/debug/feats_04.png' loading='lazy'>
|
| 90 |
<img src='assets/debug/feats_08.png' loading='lazy'>
|
index.html
CHANGED
|
@@ -63,7 +63,8 @@ tactile-estimated normal force, and DexForce-style force-informed action targets
|
|
| 63 |
<span class="pill">dataset: yxma/React</span>
|
| 64 |
<a class="pill" href="method.html" style="text-decoration:none;color:#ffd9a0;border:1px solid rgba(255,255,255,.3)">→ method design</a>
|
| 65 |
<a class="pill" href="results.html" style="text-decoration:none;color:#ffd9a0;border:1px solid rgba(255,255,255,.3)">→ results matrix</a>
|
| 66 |
-
<a class="pill" href="actions.html" style="text-decoration:none;color:#ffd9a0;border:1px solid rgba(255,255,255,.3)">→ action processing deep-dive</a>
|
|
|
|
| 67 |
</div></header>
|
| 68 |
<div class="wrap">
|
| 69 |
|
|
@@ -98,22 +99,61 @@ the optimization journey, and the step-by-step reconstruction debug are on the
|
|
| 98 |
<img src="assets/depth_validation_panel.png" alt="raw | diff | depth">
|
| 99 |
<p class="footnote">Strongest motherboard presses: raw | difference |
|
| 100 |
LUT-reconstructed depth. More examples (20 panels, 10 clips) in the
|
| 101 |
-
<a href="gallery.html">gallery</a>
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 102 |
</div>
|
| 103 |
|
| 104 |
<h2>Validated against four force-labeled datasets</h2>
|
| 105 |
<div class="card method">
|
| 106 |
<table>
|
| 107 |
-
<tr><th>dataset (gel)</th><th>ours</th><th>
|
| 108 |
-
<
|
| 109 |
-
<tr><td>
|
| 110 |
-
<
|
| 111 |
-
<tr><td>
|
| 112 |
-
<
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 113 |
</table>
|
| 114 |
<p>Each network dominates its own gel domain and collapses
|
| 115 |
-
outside it; the physics pipeline (0.
|
| 116 |
-
everywhere.
|
|
|
|
|
|
|
|
|
|
| 117 |
<a href="results.html"><b>results page</b></a>.</p>
|
| 118 |
<p class="footnote" style="margin-bottom:0">* Sparsh is a <b>foreign sensor</b>.
|
| 119 |
Our GlowTact table reaches 0.878 there; rebuilding the table from Sparsh's own
|
|
|
|
| 63 |
<span class="pill">dataset: yxma/React</span>
|
| 64 |
<a class="pill" href="method.html" style="text-decoration:none;color:#ffd9a0;border:1px solid rgba(255,255,255,.3)">→ method design</a>
|
| 65 |
<a class="pill" href="results.html" style="text-decoration:none;color:#ffd9a0;border:1px solid rgba(255,255,255,.3)">→ results matrix</a>
|
| 66 |
+
<a class="pill" href="actions.html" style="text-decoration:none;color:#ffd9a0;border:1px solid rgba(255,255,255,.3)">→ action processing deep-dive</a>
|
| 67 |
+
<a class="pill" href="recon_workbench.html" style="text-decoration:none;color:#ffd9a0;border:1px solid rgba(255,255,255,.3)">→ 3D reconstruction workbench</a></div>
|
| 68 |
</div></header>
|
| 69 |
<div class="wrap">
|
| 70 |
|
|
|
|
| 99 |
<img src="assets/depth_validation_panel.png" alt="raw | diff | depth">
|
| 100 |
<p class="footnote">Strongest motherboard presses: raw | difference |
|
| 101 |
LUT-reconstructed depth. More examples (20 panels, 10 clips) in the
|
| 102 |
+
<a href="gallery.html">gallery</a>; every stage of the reconstruction, with
|
| 103 |
+
its knobs, in the <a href="recon_workbench.html">3D workbench</a>. On marker
|
| 104 |
+
gels the depth and 3D products get one extra step — the dots are inpainted out
|
| 105 |
+
of reference and frame before differencing, which removes the dimple lattice
|
| 106 |
+
from the geometry but is deliberately <b>not</b> applied to the force
|
| 107 |
+
features, where it costs 0.04 ρ.</p>
|
| 108 |
+
</div>
|
| 109 |
+
|
| 110 |
+
<h2>How accurate is the geometry itself?</h2>
|
| 111 |
+
<div class="card method">
|
| 112 |
+
<p style="margin-top:0">Measured against exact per-pixel ground truth for the
|
| 113 |
+
first time — ray-cast mesh depth on 420 Tactile MNIST touches, non-spherical
|
| 114 |
+
geometry a sphere calibration cannot self-validate. The answer is a range set
|
| 115 |
+
by press depth, not a single number:</p>
|
| 116 |
+
<table>
|
| 117 |
+
<tr><th>press depth</th><th>0.30 mm</th><th>0.60 mm</th><th>1.00 mm</th>
|
| 118 |
+
<th>1.50 mm</th><th>2.25 mm</th></tr>
|
| 119 |
+
<tr><td>depth MAE</td><td><b>11 µm</b></td><td>35 µm</td><td>68 µm</td>
|
| 120 |
+
<td>127 µm</td><td>281 µm</td></tr>
|
| 121 |
+
<tr><td>peak recovered</td><td>1.00</td><td>0.97</td><td>0.77</td><td>0.68</td>
|
| 122 |
+
<td>0.55</td></tr>
|
| 123 |
+
</table>
|
| 124 |
+
<p>At 0.3 mm, with no per-frame alignment and no fitted indentation scale, we
|
| 125 |
+
are below every published 3D Cal figure; by 2.25 mm we recover barely half the
|
| 126 |
+
peak. <b>The working range is shallow contact, and no accuracy number should
|
| 127 |
+
be quoted without its press depth.</b> The same run cut our own over-doming
|
| 128 |
+
claim to +7–12%, demoted unobserved LUT bins to a minor factor, and confirmed
|
| 129 |
+
that the valid mask is halo-dominated (IoU 0.614, over-segmentation 0.531) —
|
| 130 |
+
details and the Taxim caveat on the
|
| 131 |
+
<a href="results.html">results page</a>.</p>
|
| 132 |
</div>
|
| 133 |
|
| 134 |
<h2>Validated against four force-labeled datasets</h2>
|
| 135 |
<div class="card method">
|
| 136 |
<table>
|
| 137 |
+
<tr><th>dataset (gel)</th><th>ours</th><th>shuffle control</th>
|
| 138 |
+
<th>FEATS U-net</th><th>FeelAnyForce</th></tr>
|
| 139 |
+
<tr><td>FEATS val (marker)</td><td>0.77</td>
|
| 140 |
+
<td>-0.00</td><td><b>0.96</b> in-domain</td><td>0.43</td></tr>
|
| 141 |
+
<tr><td>FoTa cnc_Mini (markerless)</td><td>0.95 (in view)</td>
|
| 142 |
+
<td>+0.06</td><td>0.07</td><td><b>0.83</b></td></tr>
|
| 143 |
+
<tr><td>GlowTact (markerless)</td><td><b>0.99</b></td>
|
| 144 |
+
<td>+0.17</td><td>0.04</td><td>0.90</td></tr>
|
| 145 |
+
<tr><td>Sparsh / Meta (markerless, 10 pads)</td>
|
| 146 |
+
<td><b>0.97</b> *</td>
|
| 147 |
+
<td>+0.26</td>
|
| 148 |
+
<td colspan="2">not run — no published predictions</td></tr>
|
| 149 |
+
<tr><td>React (no GT — agreement)</td><td colspan="4">physics vs FeelAnyForce ρ = 0.91; both read ≈0 N off-contact</td></tr>
|
| 150 |
</table>
|
| 151 |
<p>Each network dominates its own gel domain and collapses
|
| 152 |
+
outside it; the physics pipeline (0.77–0.99)
|
| 153 |
+
is the only one that works everywhere. Every row is a per-group half/half fit
|
| 154 |
+
with isotonic calibration, 5 seeds, reported beside the same protocol with the
|
| 155 |
+
force labels shuffled <i>within</i> each group. Predicted-vs-ground-truth
|
| 156 |
+
scatters, per dataset, on the
|
| 157 |
<a href="results.html"><b>results page</b></a>.</p>
|
| 158 |
<p class="footnote" style="margin-bottom:0">* Sparsh is a <b>foreign sensor</b>.
|
| 159 |
Our GlowTact table reaches 0.878 there; rebuilding the table from Sparsh's own
|
method.html
CHANGED
|
@@ -59,6 +59,7 @@ th,td{white-space:normal;min-width:110px}}
|
|
| 59 |
A physics pipeline with exactly one fitted number.</p>
|
| 60 |
<a class="pill" href="results.html">↖ results matrix</a>
|
| 61 |
<a class="pill" href="index.html">overview</a>
|
|
|
|
| 62 |
<a class="pill" href="actions.html">action transform</a>
|
| 63 |
<a class="pill" href="method_zh.html">中文</a>
|
| 64 |
</header>
|
|
@@ -112,14 +113,89 @@ supervised network reaches 2.1 N on the same range). A new sensor needs one
|
|
| 112 |
|
| 113 |
<h2>Validation (LUT-v2 pipeline)</h2>
|
| 114 |
<div class="card">
|
| 115 |
-
<p style="margin-top:0">The LUT-v2 pipeline is validated on <b>
|
| 116 |
-
datasets</b> (FEATS, FoTa cnc_Mini, GlowTact) and cross-checked against
|
| 117 |
-
neural estimators on identical frames — every predicted-vs-ground-truth
|
| 118 |
scatter, per dataset, lives on the
|
| 119 |
<a href="results.html"><b>results page</b></a>. Short version: physics
|
| 120 |
-
0.
|
| 121 |
-
|
| 122 |
-
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 123 |
</div>
|
| 124 |
|
| 125 |
<h2>Per-dataset calibration</h2>
|
|
|
|
| 59 |
A physics pipeline with exactly one fitted number.</p>
|
| 60 |
<a class="pill" href="results.html">↖ results matrix</a>
|
| 61 |
<a class="pill" href="index.html">overview</a>
|
| 62 |
+
<a class="pill" href="recon_workbench.html">3D workbench</a>
|
| 63 |
<a class="pill" href="actions.html">action transform</a>
|
| 64 |
<a class="pill" href="method_zh.html">中文</a>
|
| 65 |
</header>
|
|
|
|
| 113 |
|
| 114 |
<h2>Validation (LUT-v2 pipeline)</h2>
|
| 115 |
<div class="card">
|
| 116 |
+
<p style="margin-top:0">The LUT-v2 pipeline is validated on <b>four force-labeled
|
| 117 |
+
datasets</b> (FEATS, FoTa cnc_Mini, GlowTact, Sparsh) and cross-checked against
|
| 118 |
+
two neural estimators on identical frames — every predicted-vs-ground-truth
|
| 119 |
scatter, per dataset, lives on the
|
| 120 |
<a href="results.html"><b>results page</b></a>. Short version: physics
|
| 121 |
+
0.77-0.99 everywhere (GlowTact 0.99, cnc_Mini in-view 0.95, Sparsh in-view
|
| 122 |
+
0.97, FEATS 0.77), each reported beside a within-group label-shuffle control
|
| 123 |
+
that lands between −0.00 and 0.26; each network 0.90+ in its own gel
|
| 124 |
+
domain and collapsing outside it.</p>
|
| 125 |
+
</div>
|
| 126 |
+
|
| 127 |
+
<h2>How accurate is the depth, in micrometres?</h2>
|
| 128 |
+
<div class="card">
|
| 129 |
+
<p style="margin-top:0">Every ρ above scores <b>force</b>. The depth
|
| 130 |
+
underneath used to be checked only against our own analytic sphere cap. It is
|
| 131 |
+
now measured against exact per-pixel ground truth — ray-cast mesh depth on 420
|
| 132 |
+
Tactile MNIST touches, non-spherical geometry a sphere calibration cannot
|
| 133 |
+
self-validate — and the answer is a <b>range set by press depth</b>, not a
|
| 134 |
+
number:</p>
|
| 135 |
+
<table>
|
| 136 |
+
<tr><th>press depth</th><th>0.30 mm</th><th>0.60 mm</th><th>1.00 mm</th>
|
| 137 |
+
<th>1.50 mm</th><th>2.25 mm</th></tr>
|
| 138 |
+
<tr><td>MAE</td><td class="ok"><b>11 µm</b></td><td class="ok">35 µm</td>
|
| 139 |
+
<td>68 µm</td><td>127 µm</td><td class="warn">281 µm</td></tr>
|
| 140 |
+
<tr><td>peak recovered</td><td>1.00</td><td>0.97</td><td>0.77</td><td>0.68</td>
|
| 141 |
+
<td class="warn">0.55</td></tr>
|
| 142 |
+
</table>
|
| 143 |
+
<p>At 0.3 mm, with no per-frame alignment and no fitted indentation scale, the
|
| 144 |
+
Type-2 error is 96.5 µm — below all three of 3D Cal's published figures
|
| 145 |
+
(152.8 / 171.6 / 290.0 µm), which are reported
|
| 146 |
+
<i>with</i> both. By 2.25 mm we recover barely half the peak. <b>The working
|
| 147 |
+
range of this reconstruction is shallow contact, and no accuracy number here
|
| 148 |
+
should be quoted without its press depth.</b></p>
|
| 149 |
+
<p>The same run corrected two of our own claims and confirmed a third:
|
| 150 |
+
flat-top over-doming is <b>+7% to +12%</b>, not the +23–42% we implied
|
| 151 |
+
(compliant gel wraps a flat edge, so the true centre/rim ratio is
|
| 152 |
+
1.33–1.40, not 1.0); unobserved LUT bins are a <b>minor</b> factor
|
| 153 |
+
(correlation 0.10–0.29 with error); and the <code>|dI|>8</code> valid
|
| 154 |
+
mask really is halo-dominated (IoU 0.614, recall 0.917, over-segmentation
|
| 155 |
+
0.531). The photometric table is <i>not</i> the weak link — its gradients sit
|
| 156 |
+
24.4° from the true ones off-domain versus 26.1° on its own sensor.
|
| 157 |
+
Full tables, controls and the Taxim caveat on the
|
| 158 |
+
<a href="results.html"><b>results page</b></a>.</p>
|
| 159 |
+
</div>
|
| 160 |
+
|
| 161 |
+
<h2>Marker gels: one extra step, and what it is not for</h2>
|
| 162 |
+
<div class="card">
|
| 163 |
+
<p style="margin-top:0">FEATS is our only dotted gel. The dots occlude the gel,
|
| 164 |
+
so the photometric table has no valid colour underneath them and Poisson
|
| 165 |
+
integration bakes a dimple lattice into the depth map — visible as pockmarks
|
| 166 |
+
across the whole reconstructed surface. The fix is the one
|
| 167 |
+
<a href="https://arxiv.org/abs/2106.08851">GelSight Wedge</a>
|
| 168 |
+
(Wang/She/Dong/Adelson, ICRA 2021) gives in its Fig. 10 for marker holes —
|
| 169 |
+
detect the dots, then <i>fill</i> them rather than mask them — moved from
|
| 170 |
+
gradient space into image space: inpaint the dots out of <b>both</b> the
|
| 171 |
+
reference and the frame (cv2 Telea) and difference the inpainted pair.</p>
|
| 172 |
+
<table>
|
| 173 |
+
<tr><th>variant</th><th>dimple power at the 31.9 px pitch</th><th>force ρ</th></tr>
|
| 174 |
+
<tr><td>baseline, no marker handling</td><td>1.523</td><td class="ok">0.7747</td></tr>
|
| 175 |
+
<tr><td><b>inpaint the image, ref + frame</b> — shipped, depth only</td>
|
| 176 |
+
<td class="ok"><b>0.890</b> (×0.65)</td><td>0.7371</td></tr>
|
| 177 |
+
<tr><td>inpaint the gradient field instead</td><td>0.924</td><td>0.7408</td></tr>
|
| 178 |
+
<tr><td>zero the gradient inside the holes</td><td class="warn">1.251</td><td>0.7620</td></tr>
|
| 179 |
+
</table>
|
| 180 |
+
<p>Two things worth reading off that table. <b>Filling beats masking</b>:
|
| 181 |
+
setting g := 0 on the holes barely helps (×0.93) because a zero
|
| 182 |
+
patch puts a dipole layer on every hole boundary, at exactly the lattice
|
| 183 |
+
frequency it is supposed to remove. And <b>the geometry column and the force
|
| 184 |
+
column disagree</b> — the variant that halves the dimple power is the one that
|
| 185 |
+
loses the most ρ. So the step ships for <b>depth and 3D only</b>
|
| 186 |
+
(<code>marker_removal.stages_depth</code>, which wraps rather than edits the
|
| 187 |
+
force path); the force features on FEATS still come from the untouched
|
| 188 |
+
pipeline. Everything else on this site is markerless, where the detector finds
|
| 189 |
+
zero dots and the step is a bit-exact no-op.</p>
|
| 190 |
+
<p class="footnote">Controls, because “inpainting helps” is an easy
|
| 191 |
+
thing to fool yourself about: inpainting the same <i>area</i> of randomly
|
| 192 |
+
placed fake markers gives ρ 0.7697 — no gain, so this is not smoothing.
|
| 193 |
+
The detector finds 63/63 dots with 0 rejects on the FEATS reference and stays
|
| 194 |
+
at 63 for every threshold from 3 to 16 grey levels, but exactly 0 blobs on the
|
| 195 |
+
GlowTact and cnc references, so it is marker-specific. It is also not a
|
| 196 |
+
complete fix: the dots shear with the gel (median 1.7 px, >8 px on 8% of
|
| 197 |
+
frames) and a static reference mask leaves the displaced ones in place. Full
|
| 198 |
+
study: <code>python -m force_recovery.marker_study all</code>.</p>
|
| 199 |
</div>
|
| 200 |
|
| 201 |
<h2>Per-dataset calibration</h2>
|
method_zh.html
CHANGED
|
@@ -59,6 +59,7 @@ th,td{white-space:normal;min-width:110px}}
|
|
| 59 |
一条只有一个拟合参数的物理管线。</p>
|
| 60 |
<a class="pill" href="results_zh.html">↖ 评测结果</a>
|
| 61 |
<a class="pill" href="index.html">总览(英文)</a>
|
|
|
|
| 62 |
<a class="pill" href="actions_zh.html">动作变换</a>
|
| 63 |
<a class="pill" href="method.html">English</a>
|
| 64 |
</header>
|
|
@@ -111,7 +112,67 @@ supervised network reaches 2.1 N on the same range). A new sensor needs one
|
|
| 111 |
|
| 112 |
<h2>验证(LUT-v2 管线)</h2>
|
| 113 |
<div class="card">
|
| 114 |
-
<p style="margin-top:0">LUT-v2 管线在<b>
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 115 |
</div>
|
| 116 |
|
| 117 |
<h2>逐数据集标定</h2>
|
|
|
|
| 59 |
一条只有一个拟合参数的物理管线。</p>
|
| 60 |
<a class="pill" href="results_zh.html">↖ 评测结果</a>
|
| 61 |
<a class="pill" href="index.html">总览(英文)</a>
|
| 62 |
+
<a class="pill" href="recon_workbench.html">3D 工作台</a>
|
| 63 |
<a class="pill" href="actions_zh.html">动作变换</a>
|
| 64 |
<a class="pill" href="method.html">English</a>
|
| 65 |
</header>
|
|
|
|
| 112 |
|
| 113 |
<h2>验证(LUT-v2 管线)</h2>
|
| 114 |
<div class="card">
|
| 115 |
+
<p style="margin-top:0">LUT-v2 管线在<b>四个带力标注的数据集</b>(FEATS、FoTa cnc_Mini、GlowTact、Sparsh)上验证,并与两个神经网络估计器同帧对比——每个数据集的预测 vs 真值散点图都在<a href="results_zh.html"><b>评测结果页</b></a>。一句话版:物理方法在所有域 0.77–0.99(GlowTact 0.99、cnc_Mini 视野内 0.95、Sparsh 视野内 0.97、FEATS 0.77),每个数字旁边都给出组内标签打乱对照(落在 −0.00 到 0.26 之间);每个网络在自己的 gel 域 0.90+,出域即塌。</p>
|
| 116 |
+
</div>
|
| 117 |
+
|
| 118 |
+
<h2>深度到底准到多少微米?</h2>
|
| 119 |
+
<div class="card">
|
| 120 |
+
<p style="margin-top:0">上面所有 ρ 评的都是<b>力</b>。底层的深度此前只和我们自己的
|
| 121 |
+
解析球冠比较过。现在它已经对着精确的逐像素真值测量——420 次 Tactile MNIST 触碰的
|
| 122 |
+
网格光线投射深度,而且是球面标定无法自证的非球面几何——答案是一个
|
| 123 |
+
<b>由压入深度决定的区间</b>,而不是一个数字:</p>
|
| 124 |
+
<table>
|
| 125 |
+
<tr><th>压入深度</th><th>0.30 mm</th><th>0.60 mm</th><th>1.00 mm</th>
|
| 126 |
+
<th>1.50 mm</th><th>2.25 mm</th></tr>
|
| 127 |
+
<tr><td>MAE</td><td class="ok"><b>11 µm</b></td><td class="ok">35 µm</td>
|
| 128 |
+
<td>68 µm</td><td>127 µm</td><td class="warn">281 µm</td></tr>
|
| 129 |
+
<tr><td>峰值还原比</td><td>1.00</td><td>0.97</td><td>0.77</td><td>0.68</td>
|
| 130 |
+
<td class="warn">0.55</td></tr>
|
| 131 |
+
</table>
|
| 132 |
+
<p>在 0.3 mm,且没有逐帧配准、也没有拟合压入尺度的情况下,Type-2 误差为 96.5 µm——
|
| 133 |
+
低于 3D Cal 公布的全部三个数字(152.8 / 171.6 / 290.0 µm),
|
| 134 |
+
而他们的结果是<i>带</i>这两项才得到的。到 2.25 mm 我们只还原了大约一半峰值。
|
| 135 |
+
<b>这套重建的适用区间是浅接触,本页任何精度数字都必须连同其压入深度一起引用。</b></p>
|
| 136 |
+
<p>同一次实验纠正了我们自己的两个说法,并确认了第三个:平头过度穹顶化是
|
| 137 |
+
<b>+7% 到 +12%</b>,而不是我们暗示的 +23–42%(gel 柔顺、会包裹平边,
|
| 138 |
+
所以真实的中心/边缘比是 1.33–1.40,而不是 1.0);未观测的 LUT bin 是
|
| 139 |
+
<b>次要</b>因素(与误差的相关性只有 0.10–0.29);而 <code>|dI|>8</code>
|
| 140 |
+
有效掩码确实被光晕主导(IoU 0.614、召回 0.917、过分割 0.531)。
|
| 141 |
+
光度查找表<i>不是</i>薄弱环节——它的梯度在域外与真值相差 24.4°,
|
| 142 |
+
而在它自己的传感器上是 26.1°。完整表格、对照与 Taxim 相关的边界说明见
|
| 143 |
+
<a href="results_zh.html"><b>评测结果页</b></a>。</p>
|
| 144 |
+
</div>
|
| 145 |
+
|
| 146 |
+
<h2>有 marker 的 gel:多一步,以及它不是为了什么</h2>
|
| 147 |
+
<div class="card">
|
| 148 |
+
<p style="margin-top:0">FEATS 是我们唯一一块带点的 gel。点会遮挡 gel,
|
| 149 |
+
所以光度查找表在点下没有有效颜色,Poisson 积分会把一层点阵凹坑烤进深度图——
|
| 150 |
+
在整个重建表面上表现为麻点。修法就是
|
| 151 |
+
<a href="https://arxiv.org/abs/2106.08851">GelSight Wedge</a>
|
| 152 |
+
(Wang/She/Dong/Adelson,ICRA 2021)图 10 针对 marker 孔洞给出的做法——
|
| 153 |
+
检测这些点,然后<i>填充</i>而不是屏蔽——只不过从梯度域搬到了图像域:
|
| 154 |
+
把点从<b>参考帧和当前帧</b>里一起修补掉(cv2 Telea),再对修补后的两幅图做差分。</p>
|
| 155 |
+
<table>
|
| 156 |
+
<tr><th>方案</th><th>31.9 px 点距频率上的凹坑功率</th><th>力 ρ</th></tr>
|
| 157 |
+
<tr><td>基线,不处理 marker</td><td>1.523</td><td class="ok">0.7747</td></tr>
|
| 158 |
+
<tr><td><b>图像域修补,参考帧 + 当前帧</b>——已上线,仅用于深度</td>
|
| 159 |
+
<td class="ok"><b>0.890</b>(×0.65)</td><td>0.7371</td></tr>
|
| 160 |
+
<tr><td>改为修补梯度场</td><td>0.924</td><td>0.7408</td></tr>
|
| 161 |
+
<tr><td>把孔洞内的梯度置零</td><td class="warn">1.251</td><td>0.7620</td></tr>
|
| 162 |
+
</table>
|
| 163 |
+
<p>这张表有两点值得读出来。<b>填充胜过屏蔽</b>:把孔洞里的 g 置零几乎没用(×0.93),
|
| 164 |
+
因为零补丁会在每个孔洞边界上放一层偶极子,频率恰好就是它本该去掉的那个点阵频率。
|
| 165 |
+
��及<b>几何列和力列是相反的</b>——把凹坑功率减半的那个方案,恰恰是 ρ 掉得最多的。
|
| 166 |
+
所以这一步只用于<b>深度与 3D</b>(<code>marker_removal.stages_depth</code>,
|
| 167 |
+
它是包一层而不是改动力的路径);FEATS 的力特征仍然来自未改动的管线。
|
| 168 |
+
本站其余数据都是无 marker 的,检测器在那里找不到点,这一步是逐比特的空操作。</p>
|
| 169 |
+
<p class="footnote">对照实验,因为“修补有用”是很容易自欺的结论:
|
| 170 |
+
把同样<i>面积</i>的随机假 marker 修补掉得到 ρ 0.7697——没有增益,所以这不是平滑效应。
|
| 171 |
+
检测器在 FEATS 参考帧上得到 63/63 个点、0 个误检,阈值从 3 到 16 灰阶都保持 63;
|
| 172 |
+
而在 GlowTact 与 cnc 参考帧上恰好是 0 个,所以它是 marker 专用的。
|
| 173 |
+
它也不是完全的修复:点会随 gel 剪切移动(中位 1.7 px,8% 的帧超过 8 px),
|
| 174 |
+
静态参考掩码会漏掉位移后的点。完整研究:
|
| 175 |
+
<code>python -m force_recovery.marker_study all</code>。</p>
|
| 176 |
</div>
|
| 177 |
|
| 178 |
<h2>逐数据集标定</h2>
|
recon_workbench.html
CHANGED
|
@@ -9,7 +9,8 @@ img{width:100%;background:#fff;border-radius:5px;margin:5px 0}
|
|
| 9 |
table{border-collapse:collapse;margin:10px 0;font-size:13px}
|
| 10 |
th,td{border:1px solid #2c3648;padding:5px 10px;text-align:left}
|
| 11 |
th{color:#ffd9a0;font-weight:600}code{background:#1b2334;padding:1px 5px;border-radius:3px}
|
| 12 |
-
.note{color:#8e99ab;font-size:13px}
|
|
|
|
| 13 |
<h1>3D reconstruction workbench — every stage, 20 samples</h1>
|
| 14 |
<p>Not a results figure: this is the full chain with every tunable quantity
|
| 15 |
exposed, so a defect can be attributed to a stage. Columns:
|
|
@@ -19,34 +20,75 @@ exposed, so a defect can be attributed to a stage. Columns:
|
|
| 19 |
<b>11</b> depth · <b>12</b> depth halo-removed · <b>13</b> radial profile vs
|
| 20 |
analytic cap · <b>14</b> Open3D mesh.
|
| 21 |
Reproduce: <code>xvfb-run -a -s "-screen 0 1400x1000x24" python -m
|
| 22 |
-
force_recovery.recon_study glowtact</code>
|
| 23 |
-
<
|
| 24 |
-
|
| 25 |
-
|
| 26 |
-
|
| 27 |
-
|
| 28 |
-
|
| 29 |
-
|
| 30 |
-
|
| 31 |
-
|
| 32 |
-
|
| 33 |
-
|
| 34 |
-
<
|
| 35 |
-
|
| 36 |
-
|
| 37 |
-
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 38 |
<h2>Per-sample diagnostics</h2>
|
| 39 |
-
<
|
| 40 |
-
|
| 41 |
-
|
|
|
|
| 42 |
<p class="note">Grad angle and profile RMS are only defined where the indenter
|
| 43 |
is a sphere of known radius (the <code>round</code> family): the LUT gradient
|
| 44 |
-
sits 5.1–6.8° from the analytic sphere gradient and the radial profile
|
| 45 |
-
the cap to 35–105 µm, so on this sensor the table and the solver
|
| 46 |
-
sound
|
| 47 |
-
|
| 48 |
<footer style="margin-top:30px;color:#6f7a8c;font-size:13px">
|
| 49 |
React force recovery · <a href="index.html" style="color:#ffd9a0">overview</a> ·
|
| 50 |
<a href="method.html" style="color:#ffd9a0">method</a> ·
|
| 51 |
<a href="results.html" style="color:#ffd9a0">results</a></footer>
|
| 52 |
-
<img src='assets/recon/glowtact_00.png' loading='lazy'><br><img src='assets/recon/glowtact_01.png' loading='lazy'><br><img src='assets/recon/glowtact_02.png' loading='lazy'><br><img src='assets/recon/glowtact_03.png' loading='lazy'><br><img src='assets/recon/glowtact_04.png' loading='lazy'><br><img src='assets/recon/glowtact_05.png' loading='lazy'><br><img src='assets/recon/glowtact_06.png' loading='lazy'><br><img src='assets/recon/glowtact_07.png' loading='lazy'><br><img src='assets/recon/glowtact_08.png' loading='lazy'><br><img src='assets/recon/glowtact_09.png' loading='lazy'><br><img src='assets/recon/glowtact_10.png' loading='lazy'><br><img src='assets/recon/glowtact_11.png' loading='lazy'><br><img src='assets/recon/glowtact_12.png' loading='lazy'><br><img src='assets/recon/glowtact_13.png' loading='lazy'><br><img src='assets/recon/glowtact_14.png' loading='lazy'><br><img src='assets/recon/glowtact_15.png' loading='lazy'><br><img src='assets/recon/glowtact_16.png' loading='lazy'><br><img src='assets/recon/glowtact_17.png' loading='lazy'><br><img src='assets/recon/glowtact_18.png' loading='lazy'><br><img src='assets/recon/glowtact_19.png' loading='lazy'><br>
|
|
|
|
|
|
| 9 |
table{border-collapse:collapse;margin:10px 0;font-size:13px}
|
| 10 |
th,td{border:1px solid #2c3648;padding:5px 10px;text-align:left}
|
| 11 |
th{color:#ffd9a0;font-weight:600}code{background:#1b2334;padding:1px 5px;border-radius:3px}
|
| 12 |
+
.note{color:#8e99ab;font-size:13px}
|
| 13 |
+
.good{color:#7be0a0}.bad{color:#ff9a8a}</style></head><body><div class="wrap">
|
| 14 |
<h1>3D reconstruction workbench — every stage, 20 samples</h1>
|
| 15 |
<p>Not a results figure: this is the full chain with every tunable quantity
|
| 16 |
exposed, so a defect can be attributed to a stage. Columns:
|
|
|
|
| 20 |
<b>11</b> depth · <b>12</b> depth halo-removed · <b>13</b> radial profile vs
|
| 21 |
analytic cap · <b>14</b> Open3D mesh.
|
| 22 |
Reproduce: <code>xvfb-run -a -s "-screen 0 1400x1000x24" python -m
|
| 23 |
+
force_recovery.recon_study glowtact</code>, then
|
| 24 |
+
<code>python -m force_recovery.recon_study page</code>.
|
| 25 |
+
The source here (GlowTact) is markerless, so the adopted marker step
|
| 26 |
+
(<code>marker_removal.stages_depth</code>) is a bit-exact no-op on these
|
| 27 |
+
frames; on a marker gel it inpaints the dots out of the reference and the
|
| 28 |
+
frame before column 3.</p>
|
| 29 |
+
|
| 30 |
+
<h2>What external ground truth did to this page</h2>
|
| 31 |
+
<p>Everything below used to be scored against our own expectations. It is now
|
| 32 |
+
scored against exact per-pixel ground truth — ray-cast mesh depth on 420
|
| 33 |
+
Tactile MNIST touches (<code>mnist_validation</code>) — and two of the three
|
| 34 |
+
defects we published moved:</p>
|
| 35 |
+
<table><tr><th>claim</th><th>status after per-pixel GT</th></tr>
|
| 36 |
+
<tr><td>Flat-topped indenters over-dome badly (centre/rim 1.23–1.42 where
|
| 37 |
+
1.0 is correct)</td>
|
| 38 |
+
<td class="bad"><b>retracted and re-measured.</b> Compliant gel wraps a flat
|
| 39 |
+
edge, so c/r > 1 is <i>expected</i>: the true depth map of a pressed digit
|
| 40 |
+
has c/r <b>1.400</b> (gel surface 1.334) and we reconstruct 1.539–1.562
|
| 41 |
+
(<b>+10–12%</b>); on an enclosed plateau control whose truth is exactly 1.000
|
| 42 |
+
we measure <b>1.069</b> (<b>+7%</b>). Most of the 1.23–1.42 in the table
|
| 43 |
+
below is real curvature, not artefact.</td></tr>
|
| 44 |
+
<tr><td>Up to 22% of contact pixels land in unobserved LUT bins — a top
|
| 45 |
+
defect</td>
|
| 46 |
+
<td class="bad"><b>demoted to a minor factor.</b> On the GT set 13.8% / 16.9%
|
| 47 |
+
of contact pixels are unobserved, and their correlation with per-touch
|
| 48 |
+
Type-2 error is only <b>0.098 / 0.294</b>. Still worth showing (column 6),
|
| 49 |
+
no longer worth blaming.</td></tr>
|
| 50 |
+
<tr><td>The valid mask is halo-dominated</td>
|
| 51 |
+
<td class="good"><b>confirmed and quantified.</b> Against the true contact
|
| 52 |
+
region the <code>|dI| > 8</code> mask scores IoU <b>0.614</b>, recall
|
| 53 |
+
<b>0.917</b>, over-segmentation <b>0.531</b> — it finds nearly all of the
|
| 54 |
+
contact and then adds half as much again in halo.</td></tr>
|
| 55 |
+
<tr><td>(new) the photometric table is the weak link</td>
|
| 56 |
+
<td class="good"><b>ruled out.</b> LUT gradient direction vs true gel
|
| 57 |
+
gradient is <b>24.4°</b> on the GT renders against <b>26.1°</b> for this
|
| 58 |
+
table on its own real sensor — the same statistic, no worse off-domain.</td>
|
| 59 |
+
</tr></table>
|
| 60 |
+
|
| 61 |
+
<h2>The real headline: accuracy is a function of press depth</h2>
|
| 62 |
+
<p>Same digit meshes, re-rendered at five penetrations, no per-frame fitting
|
| 63 |
+
of any kind (the photometric table is calibrated once on that sensor's own
|
| 64 |
+
sphere presses, the recipe we already use per sensor):</p>
|
| 65 |
+
<table><tr><th>press depth [mm]</th><th>0.30</th><th>0.60</th><th>1.00</th>
|
| 66 |
+
<th>1.50</th><th>2.25 (what the dataset ships)</th></tr>
|
| 67 |
+
<tr><td>MAE [µm]</td><td class="good"><b>11.2</b></td><td class="good">35.0</td>
|
| 68 |
+
<td>67.8</td><td>127.4</td><td class="bad">281.1</td></tr>
|
| 69 |
+
<tr><td>Type-2 error [µm]</td><td class="good"><b>96.5</b></td><td>186.3</td>
|
| 70 |
+
<td>308.6</td><td>514.6</td><td class="bad">961.8</td></tr>
|
| 71 |
+
<tr><td>peak ours / GT</td><td>1.00</td><td>0.97</td><td>0.77</td><td>0.68</td>
|
| 72 |
+
<td class="bad">0.55</td></tr></table>
|
| 73 |
+
<p>So the honest public claim is a <b>range</b>, not a number: at ≤0.6 mm this
|
| 74 |
+
reconstruction is accurate on non-spherical ground truth with zero fitting; by
|
| 75 |
+
2.25 mm it recovers barely half the peak. No accuracy figure on this site
|
| 76 |
+
should be quoted without the press depth it was measured at.</p>
|
| 77 |
+
|
| 78 |
<h2>Per-sample diagnostics</h2>
|
| 79 |
+
<p class="note">centre/rim is reported <b>descriptively</b> — read it against
|
| 80 |
+
the GT ratio for that geometry (1.33–1.40 for a compliant press), never
|
| 81 |
+
against 1.0.</p>
|
| 82 |
+
<table><tr><th>sample</th><th>peak [mm]</th><th>unobserved LUT</th><th>centre/rim<br><span class='note'>GT for a compliant press: 1.33–1.40</span></th><th>grad angle<br><span class='note'>chance 90°</span></th><th>profile RMS</th></tr><tr><td>round z=2.12mm F=4.4N</td><td>1.60</td><td>0%</td><td>1.46</td><td>6.8</td><td>69</td></tr><tr><td>round z=3.21mm F=9.4N</td><td>2.55</td><td>4%</td><td>1.43</td><td>5.8</td><td>35</td></tr><tr><td>round z=3.80mm F=14.8N</td><td>2.94</td><td>1%</td><td>1.44</td><td>5.1</td><td>105</td></tr><tr><td>star z=1.73mm F=3.0N</td><td>1.61</td><td>2%</td><td>1.44</td><td></td><td></td></tr><tr><td>star z=2.34mm F=8.0N</td><td>2.07</td><td>10%</td><td>1.33</td><td></td><td></td></tr><tr><td>star z=2.96mm F=11.0N</td><td>2.03</td><td>14%</td><td>1.36</td><td></td><td></td></tr><tr><td>star z=3.53mm F=16.0N</td><td>2.30</td><td>22%</td><td>1.35</td><td></td><td></td></tr><tr><td>triangle z=2.28mm F=4.9N</td><td>1.40</td><td>5%</td><td>1.42</td><td></td><td></td></tr><tr><td>triangle z=3.11mm F=9.7N</td><td>2.05</td><td>9%</td><td>1.31</td><td></td><td></td></tr><tr><td>triangle z=3.75mm F=14.7N</td><td>2.66</td><td>10%</td><td>1.32</td><td></td><td></td></tr><tr><td>quad z=2.16mm F=3.6N</td><td>1.19</td><td>4%</td><td>1.32</td><td></td><td></td></tr><tr><td>quad z=2.94mm F=9.2N</td><td>1.75</td><td>9%</td><td>1.24</td><td></td><td></td></tr><tr><td>quad z=3.52mm F=14.2N</td><td>2.32</td><td>10%</td><td>1.23</td><td></td><td></td></tr><tr><td>quad_small z=1.51mm F=3.9N</td><td>1.43</td><td>7%</td><td>1.32</td><td></td><td></td></tr><tr><td>quad_small z=2.55mm F=9.2N</td><td>2.51</td><td>6%</td><td>1.35</td><td></td><td></td></tr><tr><td>quad_small z=3.47mm F=13.7N</td><td>2.93</td><td>8%</td><td>1.35</td><td></td><td></td></tr><tr><td>quad_small z=3.97mm F=17.4N</td><td>2.66</td><td>12%</td><td>1.42</td><td></td><td></td></tr><tr><td>B z=2.91mm F=4.9N</td><td>1.96</td><td>7%</td><td>1.39</td><td></td><td></td></tr><tr><td>B z=4.04mm F=10.6N</td><td>2.83</td><td>6%</td><td>1.39</td><td></td><td></td></tr><tr><td>B z=4.48mm F=13.7N</td><td>2.87</td><td>5%</td><td>1.40</td><td></td><td></td></tr></table>
|
| 83 |
<p class="note">Grad angle and profile RMS are only defined where the indenter
|
| 84 |
is a sphere of known radius (the <code>round</code> family): the LUT gradient
|
| 85 |
+
sits 5.1–6.8° from the analytic sphere gradient and the radial profile
|
| 86 |
+
matches the cap to 35–105 µm, so on this sensor the table and the solver
|
| 87 |
+
are both sound. Every one of these frames is a deep press (1.5–4.5 mm) —
|
| 88 |
+
i.e. the regime the sweep above shows is our worst.</p>
|
| 89 |
<footer style="margin-top:30px;color:#6f7a8c;font-size:13px">
|
| 90 |
React force recovery · <a href="index.html" style="color:#ffd9a0">overview</a> ·
|
| 91 |
<a href="method.html" style="color:#ffd9a0">method</a> ·
|
| 92 |
<a href="results.html" style="color:#ffd9a0">results</a></footer>
|
| 93 |
+
<img src='assets/recon/glowtact_00.png' loading='lazy'><br><img src='assets/recon/glowtact_01.png' loading='lazy'><br><img src='assets/recon/glowtact_02.png' loading='lazy'><br><img src='assets/recon/glowtact_03.png' loading='lazy'><br><img src='assets/recon/glowtact_04.png' loading='lazy'><br><img src='assets/recon/glowtact_05.png' loading='lazy'><br><img src='assets/recon/glowtact_06.png' loading='lazy'><br><img src='assets/recon/glowtact_07.png' loading='lazy'><br><img src='assets/recon/glowtact_08.png' loading='lazy'><br><img src='assets/recon/glowtact_09.png' loading='lazy'><br><img src='assets/recon/glowtact_10.png' loading='lazy'><br><img src='assets/recon/glowtact_11.png' loading='lazy'><br><img src='assets/recon/glowtact_12.png' loading='lazy'><br><img src='assets/recon/glowtact_13.png' loading='lazy'><br><img src='assets/recon/glowtact_14.png' loading='lazy'><br><img src='assets/recon/glowtact_15.png' loading='lazy'><br><img src='assets/recon/glowtact_16.png' loading='lazy'><br><img src='assets/recon/glowtact_17.png' loading='lazy'><br><img src='assets/recon/glowtact_18.png' loading='lazy'><br><img src='assets/recon/glowtact_19.png' loading='lazy'><br>
|
| 94 |
+
</div></body></html>
|
results.html
CHANGED
|
@@ -57,11 +57,12 @@ th,td{white-space:normal;min-width:110px}}
|
|
| 57 |
|
| 58 |
<header>
|
| 59 |
<div class="kicker">React force recovery · results</div>
|
| 60 |
-
<h1>Three estimators ×
|
| 61 |
<p class="sub">Every method evaluated on every dataset with force-sensor labels,
|
| 62 |
predicted vs ground truth per dataset — so dataset quality is controlled within
|
| 63 |
each row, and differences between panels are differences between methods.</p>
|
| 64 |
<a class="pill" href="method.html">↖ how the method is designed</a>
|
|
|
|
| 65 |
<a class="pill" href="index.html">overview</a>
|
| 66 |
<a class="pill" href="gallery.html">gallery</a>
|
| 67 |
<a class="pill" href="results_zh.html">中文</a>
|
|
@@ -74,15 +75,43 @@ each row, and differences between panels are differences between methods.</p>
|
|
| 74 |
<th>FeelAnyForce<br>(trained: markerless)</th></tr>
|
| 75 |
<tr><td>FEATS val (marker)</td><td>0.77</td>
|
| 76 |
<td class="best">0.96 · in-domain</td><td class="dead">0.43</td></tr>
|
| 77 |
-
<tr><td>FoTa cnc_Mini (markerless)</td><td>0.
|
| 78 |
<td class="dead">0.07</td><td class="best">0.83</td></tr>
|
| 79 |
-
<tr><td>GlowTact (markerless)</td><td>0.
|
| 80 |
<td class="dead">0.04</td><td class="best">0.90</td></tr>
|
|
|
|
|
|
|
|
|
|
| 81 |
</table>
|
| 82 |
<p>The pattern is the finding: <b>each network dominates its own gel domain and
|
| 83 |
collapses outside it</b> (FEATS 0.96 → 0.04–0.07; FeelAnyForce 0.90 → 0.43),
|
| 84 |
while <b>the physics pipeline is the only estimator that works everywhere</b>
|
| 85 |
-
(0.
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 86 |
</div>
|
| 87 |
|
| 88 |
<h2>FEATS dataset — marker-dot gel</h2>
|
|
@@ -90,14 +119,40 @@ while <b>the physics pipeline is the only estimator that works everywhere</b>
|
|
| 90 |
<p class="footnote">In-domain, the FEATS U-net is excellent (ρ=0.96) — the
|
| 91 |
negative results elsewhere are domain effects, not a weak model. FeelAnyForce,
|
| 92 |
markerless-trained, degrades on the dotted gel (0.43): the same knife cuts both
|
| 93 |
-
ways.</p>
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 94 |
|
| 95 |
<h2>FoTa cnc_Mini — markerless gel</h2>
|
| 96 |
<div class="card"><img src="assets/results_cnc.png" alt="cnc_Mini panels">
|
| 97 |
<p class="footnote">Hard conditions: only 4 contact-free frames, 62% of presses
|
| 98 |
near the pad border — the press grid is larger than the field of view (see
|
| 99 |
<a href="debug_pipeline.html">pipeline debug</a>). Strictly in view our ρ is
|
| 100 |
-
0.
|
| 101 |
|
| 102 |
<h2>GlowTact — markerless gel, cleaned</h2>
|
| 103 |
<div class="card"><img src="assets/results_glowtact.png" alt="GlowTact panels">
|
|
@@ -144,6 +199,85 @@ frame indices than forces (silently drifting the labels, ρ≈0 until
|
|
| 144 |
paired within each trajectory), sharp/batch_2 is stored BGR while the other
|
| 145 |
nine are RGB, and flat/batch_2 ships only 3 of 4 image files.</p></div>
|
| 146 |
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 147 |
<h2>React — no ground truth, so: do independent methods agree?</h2>
|
| 148 |
<div class="card"><img src="assets/results_react.png" alt="React agreement">
|
| 149 |
<p class="footnote">On the dataset we actually care about, the two surviving
|
|
@@ -156,15 +290,24 @@ contact-free. Neither can copy the other's mistakes.</p></div>
|
|
| 156 |
Mini): FeelAnyForce as the primary labeller, the physics pipeline as an
|
| 157 |
independent audit, disagreement rows flagged. <b>For any new gel or sensor</b>
|
| 158 |
where no trained model matches the domain: the physics pipeline is the only
|
| 159 |
-
option that works out of the box — and its FEATS-dataset score (0.
|
| 160 |
-
what it does on a domain nobody tuned it for.</p>
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 161 |
|
| 162 |
<p><a href="debug_pipeline.html"><b>Pipeline debug page</b></a>: raw
|
| 163 |
image → force step by step on all three datasets, and the cnc
|
| 164 |
-
field-of-view ablation (in-view ρ=0.
|
| 165 |
|
| 166 |
<footer>React force recovery · <a href="index.html">overview</a> ·
|
| 167 |
<a href="method.html">method design</a> · <a href="gallery.html">gallery</a> ·
|
| 168 |
data: FEATS (2411.03315) · FoTa/T3 (2406.13640) · GlowTact
|
| 169 |
-
(dacongming666/GlowTact_Datasets) · FeelAnyForce (2410.02048)
|
|
|
|
| 170 |
</div></body></html>
|
|
|
|
| 57 |
|
| 58 |
<header>
|
| 59 |
<div class="kicker">React force recovery · results</div>
|
| 60 |
+
<h1>Three estimators × four ground-truth datasets</h1>
|
| 61 |
<p class="sub">Every method evaluated on every dataset with force-sensor labels,
|
| 62 |
predicted vs ground truth per dataset — so dataset quality is controlled within
|
| 63 |
each row, and differences between panels are differences between methods.</p>
|
| 64 |
<a class="pill" href="method.html">↖ how the method is designed</a>
|
| 65 |
+
<a class="pill" href="recon_workbench.html">3D workbench</a>
|
| 66 |
<a class="pill" href="index.html">overview</a>
|
| 67 |
<a class="pill" href="gallery.html">gallery</a>
|
| 68 |
<a class="pill" href="results_zh.html">中文</a>
|
|
|
|
| 75 |
<th>FeelAnyForce<br>(trained: markerless)</th></tr>
|
| 76 |
<tr><td>FEATS val (marker)</td><td>0.77</td>
|
| 77 |
<td class="best">0.96 · in-domain</td><td class="dead">0.43</td></tr>
|
| 78 |
+
<tr><td>FoTa cnc_Mini (markerless)</td><td>0.95 (in view)</td>
|
| 79 |
<td class="dead">0.07</td><td class="best">0.83</td></tr>
|
| 80 |
+
<tr><td>GlowTact (markerless)</td><td>0.99</td>
|
| 81 |
<td class="dead">0.04</td><td class="best">0.90</td></tr>
|
| 82 |
+
<tr><td>Sparsh / Meta (markerless, 10 gel pads)</td>
|
| 83 |
+
<td>0.97 (in view, self-calibrated table)</td>
|
| 84 |
+
<td colspan="2">not run — no published predictions</td></tr>
|
| 85 |
</table>
|
| 86 |
<p>The pattern is the finding: <b>each network dominates its own gel domain and
|
| 87 |
collapses outside it</b> (FEATS 0.96 → 0.04–0.07; FeelAnyForce 0.90 → 0.43),
|
| 88 |
while <b>the physics pipeline is the only estimator that works everywhere</b>
|
| 89 |
+
(0.77–0.99) — it never sees training data, so it has no domain to leave.</p>
|
| 90 |
+
</div>
|
| 91 |
+
|
| 92 |
+
<h2>Every number beside the control that could have killed it</h2>
|
| 93 |
+
<div class="card">
|
| 94 |
+
<p style="margin-top:0">Re-run end to end after marker inpainting was added to
|
| 95 |
+
the depth pipeline. One protocol on all four datasets: within each group
|
| 96 |
+
(indenter family / probe / capture group / gel pad) half the frames fit a
|
| 97 |
+
5-feature least-squares model calibrated by isotonic regression, the other half
|
| 98 |
+
are scored; 5 seeds, median reported. The control column repeats the identical
|
| 99 |
+
protocol with the force labels <b>permuted within each group</b> — group
|
| 100 |
+
structure and force distribution untouched, only the frame-to-force pairing
|
| 101 |
+
destroyed.</p>
|
| 102 |
+
<table class="matrix"><tr><th>dataset</th><th>n (eval)</th><th>ρ</th><th>ρ across seeds</th><th>MAE [N]</th><th>within-group shuffle</th></tr><tr><td>GlowTact (markerless, 0-20 N)</td><td>201</td><td class='best'><b>0.986</b></td><td>0.981–0.987</td><td>0.525</td><td>+0.171</td></tr><tr><td>FoTa cnc_Mini (markerless, in view)</td><td>337</td><td class='best'><b>0.946</b></td><td>0.929–0.949</td><td>0.252</td><td>+0.056</td></tr><tr><td>FEATS (marker gel)</td><td>186</td><td class='best'><b>0.775</b></td><td>0.713–0.787</td><td>5.025</td><td>-0.003</td></tr><tr><td>Sparsh / Meta (markerless, Sparsh LUT, in view)</td><td>1667</td><td class='best'><b>0.968</b></td><td>0.967–0.971</td><td>0.042</td><td>+0.264</td></tr><tr><td>FEATS (marker gel, dots inpainted — rejected for force)</td><td>186</td><td class='dead'><b>0.737</b></td><td>0.682–0.816</td><td>4.934</td><td>-0.010</td></tr></table>
|
| 103 |
+
<p class="footnote">Nothing moved. That is the expected result and it is worth
|
| 104 |
+
being explicit about: marker inpainting was adopted for <b>geometry only</b>,
|
| 105 |
+
so the force path was deliberately left byte-identical, and a spot check that
|
| 106 |
+
recomputes cached features from the raw frames confirms it
|
| 107 |
+
(max |cached − fresh| = 0 over 40 cnc frames). The last row is the same FEATS
|
| 108 |
+
frames and the same splits with the marker-inpainted features fed to the force
|
| 109 |
+
model instead — it <b>loses</b> 0.037 ρ, which is why it did not ship there.</p>
|
| 110 |
+
<p class="footnote">A within-group shuffle is the right control here, not a
|
| 111 |
+
global one: on FeelAnyForce the pooled ρ survived <i>global</i> shuffling at
|
| 112 |
+
0.442 vs 0.455, which is how we caught that its frame join had never been
|
| 113 |
+
demonstrated. Reading the table: cnc and GlowTact sit ~0.9 above their
|
| 114 |
+
controls; FEATS sits 0.78 above a control that is flat at 0.00.</p>
|
| 115 |
</div>
|
| 116 |
|
| 117 |
<h2>FEATS dataset — marker-dot gel</h2>
|
|
|
|
| 119 |
<p class="footnote">In-domain, the FEATS U-net is excellent (ρ=0.96) — the
|
| 120 |
negative results elsewhere are domain effects, not a weak model. FeelAnyForce,
|
| 121 |
markerless-trained, degrades on the dotted gel (0.43): the same knife cuts both
|
| 122 |
+
ways.</p>
|
| 123 |
+
<h3>Removing the marker dots: a geometry win, not a force win</h3>
|
| 124 |
+
<img src="assets/feats_marker_removal.png" alt="FEATS before and after marker inpainting">
|
| 125 |
+
<p class="footnote">The dots occlude the gel, so the photometric table has no
|
| 126 |
+
valid colour under them and Poisson integrates a dimple lattice into the depth
|
| 127 |
+
map — visible as pockmarks all over the <b>3D mesh BEFORE</b> panels. Detecting
|
| 128 |
+
the dots on the reference and inpainting them out of <b>both</b> the reference
|
| 129 |
+
and the frame before differencing (cv2 Telea, the image-space cousin of
|
| 130 |
+
GelSight Wedge's Fig. 10 hole interpolation) removes it: lattice power at the
|
| 131 |
+
31.9 px marker pitch drops <b>1.523 → 0.890</b> (×0.65), lower on <b>91%</b> of
|
| 132 |
+
120 frames above 1 N, Wilcoxon p = 2.6e-19. The detector is marker-specific,
|
| 133 |
+
not a blob finder — 63/63 dots and 0 rejects on this reference, stable for
|
| 134 |
+
every threshold from 3 to 16 grey levels, and exactly <b>0</b> blobs on the
|
| 135 |
+
markerless GlowTact and cnc references, where the step is a bit-exact no-op.</p>
|
| 136 |
+
<p class="footnote">Two things it does <b>not</b> do. It does not help force:
|
| 137 |
+
on identical frames and splits ρ goes 0.7747 → 0.7371 and every paired median
|
| 138 |
+
delta is negative, so the force features still come from the untouched
|
| 139 |
+
pipeline. And it does not catch every dot — the dots shear with the gel
|
| 140 |
+
(median 1.7 px, >8 px on 8% of frames), so a static reference mask leaves
|
| 141 |
+
the displaced ones behind, which is what the residual dots in column 3 are.
|
| 142 |
+
Controls: inpainting the same <i>area</i> of randomly placed fake markers gives
|
| 143 |
+
0.7697, i.e. no gain, so the small changes are not "inpainting = smoothing".
|
| 144 |
+
What actually caps FEATS is the reference, not the dots — on the 20 lightest
|
| 145 |
+
presses |dI| already sits at 11 grey levels off-dot and 88% of off-dot pixels
|
| 146 |
+
pass the |dI|>8 valid test, so the mask is nearly the whole frame and the
|
| 147 |
+
features integrate reference mismatch; a per-indenter light-press reference
|
| 148 |
+
made it worse still (0.7747 → 0.7261).</p></div>
|
| 149 |
|
| 150 |
<h2>FoTa cnc_Mini — markerless gel</h2>
|
| 151 |
<div class="card"><img src="assets/results_cnc.png" alt="cnc_Mini panels">
|
| 152 |
<p class="footnote">Hard conditions: only 4 contact-free frames, 62% of presses
|
| 153 |
near the pad border — the press grid is larger than the field of view (see
|
| 154 |
<a href="debug_pipeline.html">pipeline debug</a>). Strictly in view our ρ is
|
| 155 |
+
0.95 (MAE 0.25 N); FeelAnyForce reaches 0.92 non-edge.</p></div>
|
| 156 |
|
| 157 |
<h2>GlowTact — markerless gel, cleaned</h2>
|
| 158 |
<div class="card"><img src="assets/results_glowtact.png" alt="GlowTact panels">
|
|
|
|
| 199 |
paired within each trajectory), sharp/batch_2 is stored BGR while the other
|
| 200 |
nine are RGB, and flat/batch_2 ships only 3 of 4 image files.</p></div>
|
| 201 |
|
| 202 |
+
<h2>First external per-pixel ground truth — and it moves the headline</h2>
|
| 203 |
+
<div class="card">
|
| 204 |
+
<p style="margin-top:0">Everything above scores <b>force</b>. Until now the
|
| 205 |
+
<b>depth</b> underneath was only ever checked against our own analytic sphere
|
| 206 |
+
cap, with the cap's amplitude anchored on the reconstruction itself. Tactile
|
| 207 |
+
MNIST supplies what was missing: exact per-pixel depth, ray-cast from the
|
| 208 |
+
3D-printed digit meshes, on <b>non-spherical</b> geometry a sphere calibration
|
| 209 |
+
cannot self-validate — 420 touches, 106 objects. The pose bookkeeping is
|
| 210 |
+
verified end to end rather than assumed (re-rendering the ground-truth height
|
| 211 |
+
map reproduces the shipped image to ~2/255 grey levels).</p>
|
| 212 |
+
<img src="assets/mnist_examples.png" alt="reconstruction vs exact mesh ground truth">
|
| 213 |
+
<p><b>The finding is a range, not a number: accuracy is a steep function of
|
| 214 |
+
press depth.</b> Same digit meshes, re-rendered at five penetrations, no
|
| 215 |
+
per-frame alignment and no fitted indentation scale:</p>
|
| 216 |
+
<table class="matrix">
|
| 217 |
+
<tr><th>press depth [mm]</th><th>0.30</th><th>0.60</th><th>1.00</th><th>1.50</th>
|
| 218 |
+
<th>2.25 — what the dataset ships</th></tr>
|
| 219 |
+
<tr><td>MAE [µm]</td><td class="best"><b>11.2</b></td><td class="best">35.0</td>
|
| 220 |
+
<td>67.8</td><td>127.4</td><td class="dead">281.1</td></tr>
|
| 221 |
+
<tr><td>Type-2 error [µm]</td><td class="best"><b>96.5</b></td><td>186.3</td>
|
| 222 |
+
<td>308.6</td><td>514.6</td><td class="dead">961.8</td></tr>
|
| 223 |
+
<tr><td>peak recovered (ours / GT)</td><td>1.00</td><td>0.97</td><td>0.77</td>
|
| 224 |
+
<td>0.68</td><td class="dead">0.55</td></tr>
|
| 225 |
+
</table>
|
| 226 |
+
<p class="footnote">At 0.3 mm the Type-2 error is <b>96.5 µm</b>, below every
|
| 227 |
+
one of 3D Cal's three published figures (152.8 / 171.6 / 290.0 µm) — and
|
| 228 |
+
theirs are reported <i>with</i> a 2D cross-correlation alignment and a fitted
|
| 229 |
+
indentation scale, ours with neither. At 0.6 mm (186.3 µm) we sit inside their
|
| 230 |
+
range. At the 2.25 mm press this dataset actually ships we are an order of
|
| 231 |
+
magnitude worse and recover barely half the peak. <b>So: no accuracy number on
|
| 232 |
+
this site should be quoted without the press depth it was measured at, and the
|
| 233 |
+
working range of this reconstruction is shallow contact.</b></p>
|
| 234 |
+
<p><b>What it corrects, what it confirms.</b></p>
|
| 235 |
+
<table class="matrix">
|
| 236 |
+
<tr><th>earlier claim</th><th>after per-pixel ground truth</th></tr>
|
| 237 |
+
<tr><td>Flat-topped indenters over-dome badly — centre/rim 1.23–1.42
|
| 238 |
+
where 1.0 would be correct</td>
|
| 239 |
+
<td class="dead"><b>retracted.</b> The premise was wrong: compliant gel wraps
|
| 240 |
+
around a flat edge, so c/r > 1 is <i>expected</i>. GT says the true depth
|
| 241 |
+
map of a pressed digit has c/r <b>1.400</b> (the gel surface itself 1.334)
|
| 242 |
+
while we reconstruct 1.539–1.562 — <b>+10–12%</b>; on an
|
| 243 |
+
enclosed plateau control whose truth is exactly 1.000 we measure <b>1.069</b>,
|
| 244 |
+
<b>+7%</b>. The over-doming is real and small, not the +23–42% we
|
| 245 |
+
implied.</td></tr>
|
| 246 |
+
<tr><td>Up to 22% of contact pixels land in unobserved LUT bins — a
|
| 247 |
+
leading defect</td>
|
| 248 |
+
<td class="dead"><b>demoted.</b> 13.8% / 16.9% on the GT set, correlating with
|
| 249 |
+
per-touch Type-2 error at only <b>0.098 / 0.294</b>.</td></tr>
|
| 250 |
+
<tr><td>The <code>|dI| > 8</code> valid mask is halo-dominated</td>
|
| 251 |
+
<td class="best"><b>confirmed and quantified.</b> Against the true contact
|
| 252 |
+
region: IoU <b>0.614</b>, recall <b>0.917</b>, over-segmentation <b>0.531</b>
|
| 253 |
+
— it finds nearly all the contact and then adds half as much again in
|
| 254 |
+
halo.</td></tr>
|
| 255 |
+
<tr><td>The photometric table might be the weak link off-domain</td>
|
| 256 |
+
<td class="best"><b>ruled out.</b> LUT gradient vs true gel gradient is
|
| 257 |
+
<b>24.4°</b> on these renders against <b>26.1°</b> for the same table
|
| 258 |
+
on its own real sensor, and refitting the table on in-domain sphere renders
|
| 259 |
+
does not improve the digits (316.9 vs 273.4 µm).</td></tr>
|
| 260 |
+
</table>
|
| 261 |
+
<p><b>One failure mode, now seen on four datasets.</b> 420/420 of these touches
|
| 262 |
+
have a contact that runs off the pad, and a control that moves a single sphere
|
| 263 |
+
cap from mid-pad to the edge collapses its peak <b>1.39 → 0.30 mm</b>
|
| 264 |
+
against a 0.90 mm truth (Type-2 292 → 450 µm). That is the same effect as
|
| 265 |
+
cnc_Mini's press grid being larger than the field of view (ρ 0.11 →
|
| 266 |
+
0.94 in the field-of-view ablation) and Sparsh's clipped-disc frames
|
| 267 |
+
scoring worse despite carrying the highest median force. <b>Contact
|
| 268 |
+
visibility, not force range or gel type, is this pipeline's single biggest
|
| 269 |
+
external failure mode</b> — the Poisson solve's zero boundary cannot
|
| 270 |
+
represent a surface that leaves the frame.</p>
|
| 271 |
+
<p class="footnote"><b>Honest caveat.</b> These images are Taxim renders, not
|
| 272 |
+
real GelSight frames, so this validates the <i>geometry solver</i> —
|
| 273 |
+
table, mask, integration — rather than the sensor model, and the domain
|
| 274 |
+
check above is what licenses reading it that way. Taxim's gel also follows the
|
| 275 |
+
object geometry to within ~38 µm, so it barely models real gel
|
| 276 |
+
non-conformance: the true numbers on a physical sensor at the same press depth
|
| 277 |
+
will be worse, not better. Reproduce with
|
| 278 |
+
<code>python -m force_recovery.mnist_validation stage1|controls|sweep</code>.</p>
|
| 279 |
+
</div>
|
| 280 |
+
|
| 281 |
<h2>React — no ground truth, so: do independent methods agree?</h2>
|
| 282 |
<div class="card"><img src="assets/results_react.png" alt="React agreement">
|
| 283 |
<p class="footnote">On the dataset we actually care about, the two surviving
|
|
|
|
| 290 |
Mini): FeelAnyForce as the primary labeller, the physics pipeline as an
|
| 291 |
independent audit, disagreement rows flagged. <b>For any new gel or sensor</b>
|
| 292 |
where no trained model matches the domain: the physics pipeline is the only
|
| 293 |
+
option that works out of the box — and its FEATS-dataset score (0.77) shows
|
| 294 |
+
what it does on a domain nobody tuned it for.</p>
|
| 295 |
+
<p><b>And state the scope with it.</b> Those ρ are
|
| 296 |
+
<i>force</i> scores, per group. The <i>depth</i> underneath is now measured
|
| 297 |
+
against exact per-pixel ground truth and is a strong function of press depth —
|
| 298 |
+
11 µm MAE at 0.3 mm, 281 µm at 2.25 mm — so the honest one-line summary is:
|
| 299 |
+
<b>accurate shallow-contact geometry, monotone force within a calibrated
|
| 300 |
+
group, and neither claim survives a contact that leaves the field of view.</b>
|
| 301 |
+
Marker gels get one extra step (dots inpainted before differencing) which
|
| 302 |
+
buys geometry and not force.</p></div>
|
| 303 |
|
| 304 |
<p><a href="debug_pipeline.html"><b>Pipeline debug page</b></a>: raw
|
| 305 |
image → force step by step on all three datasets, and the cnc
|
| 306 |
+
field-of-view ablation (in-view ρ=0.95).</p>
|
| 307 |
|
| 308 |
<footer>React force recovery · <a href="index.html">overview</a> ·
|
| 309 |
<a href="method.html">method design</a> · <a href="gallery.html">gallery</a> ·
|
| 310 |
data: FEATS (2411.03315) · FoTa/T3 (2406.13640) · GlowTact
|
| 311 |
+
(dacongming666/GlowTact_Datasets) · FeelAnyForce (2410.02048) ·
|
| 312 |
+
Tactile MNIST (TUDa-RL) · Sparsh (facebook/gelsight-force-estimation)</footer>
|
| 313 |
</div></body></html>
|
results_zh.html
CHANGED
|
@@ -57,10 +57,11 @@ th,td{white-space:normal;min-width:110px}}
|
|
| 57 |
|
| 58 |
<header>
|
| 59 |
<div class="kicker">React 力恢复 · 评测结果</div>
|
| 60 |
-
<h1>三个估计器 ×
|
| 61 |
<p class="sub">每个方法在每个有力传感器标注的数据集上评测,逐数据集画预测 vs 真值——
|
| 62 |
数据集质量在行内被控制,面板之间的差异就是方法之间的差异。</p>
|
| 63 |
<a class="pill" href="method_zh.html">↖ 方法设计</a>
|
|
|
|
| 64 |
<a class="pill" href="index.html">总览(英文)</a>
|
| 65 |
<a class="pill" href="gallery.html">图库</a>
|
| 66 |
<a class="pill" href="results.html">English</a>
|
|
@@ -73,25 +74,62 @@ th,td{white-space:normal;min-width:110px}}
|
|
| 73 |
<th>FeelAnyForce<br>(训练域:无点)</th></tr>
|
| 74 |
<tr><td>FEATS val(有点)</td><td>0.77</td>
|
| 75 |
<td class="best">0.96 · 本域</td><td class="dead">0.43</td></tr>
|
| 76 |
-
<tr><td>FoTa cnc_Mini(无点)</td><td>0.
|
| 77 |
<td class="dead">0.07</td><td class="best">0.83</td></tr>
|
| 78 |
-
<tr><td>GlowTact(无点)</td><td>0.
|
| 79 |
<td class="dead">0.04</td><td class="best">0.90</td></tr>
|
|
|
|
|
|
|
|
|
|
| 80 |
</table>
|
| 81 |
<p>规律本身就是发现:<b>每个网络只统治自己的 gel 域,出域即塌</b>
|
| 82 |
(FEATS 0.96 → 0.04–0.07;FeelAnyForce 0.90 → 0.43);
|
| 83 |
-
而<b>物理管线是唯一在所有域都工作的估计器</b>(0.
|
| 84 |
它没见过训练数据,所以也没有可以离开的域。</p>
|
| 85 |
</div>
|
| 86 |
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 87 |
<h2>FEATS 数据集——有点 gel</h2>
|
| 88 |
<div class="card"><img src="assets/results_feats.png" alt="FEATS dataset panels">
|
| 89 |
<p class="footnote">本域内 FEATS U-net 非常出色(ρ=0.96)——它在别处的失败是域效应,
|
| 90 |
-
不是模型弱。FeelAnyForce(无点训练)在有点 gel 上退化到 0.43:这把刀两边都割。</p>
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 91 |
|
| 92 |
<h2>FoTa cnc_Mini——无点 gel</h2>
|
| 93 |
<div class="card"><img src="assets/results_cnc.png" alt="cnc_Mini panels">
|
| 94 |
-
<p class="footnote">条件苛刻:只有 4 帧无接触,62% 的按压贴边。我们严格视野内 ρ=0.
|
| 95 |
FeelAnyForce 非边缘达 0.92。</p></div>
|
| 96 |
|
| 97 |
<h2>GlowTact——无点 gel,清洗过</h2>
|
|
@@ -127,6 +165,64 @@ FeelAnyForce 非边缘达 0.92。</p></div>
|
|
| 127 |
逐轨迹配对前 ρ≈0)、sharp/batch_2 以 BGR 存储而其余九个是 RGB、
|
| 128 |
flat/batch_2 只有 3 个图像文件。</p></div>
|
| 129 |
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 130 |
<h2>React——没有真值,那就问:独立方法是否一致?</h2>
|
| 131 |
<div class="card"><img src="assets/results_react.png" alt="React agreement">
|
| 132 |
<p class="footnote">在我们真正关心的数据集上,两个幸存的估计器——物理(零训练)与
|
|
@@ -136,12 +232,18 @@ FeelAnyForce(20 万帧)——一致性 ρ=0.91,且物理管线判无接触的每
|
|
| 136 |
<h2>结论</h2>
|
| 137 |
<div class="card"><p style="margin-top:0"><b>给 React 打标签</b>(无点 Mini):FeelAnyForce 主标,
|
| 138 |
物理管线独立审计,分歧行打标。<b>换任何新 gel 或新传感器</b>、没有训练模型匹配该域时:
|
| 139 |
-
物理管线是唯一开箱即用的选项——它在 FEATS 数据集上的 0.
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 140 |
|
| 141 |
-
<p><a href="debug_pipeline.html"><b>管线调试页</b></a>:三个数据集上从原始图像到力的逐步展示,以及 cnc 视野消融(视野内 ρ=0.
|
| 142 |
|
| 143 |
<footer>React 力恢复 · <a href="index.html">总览</a> ·
|
| 144 |
<a href="method_zh.html">方法设计</a> · <a href="gallery.html">图库</a> ·
|
| 145 |
数据:FEATS (2411.03315) · FoTa/T3 (2406.13640) · GlowTact
|
| 146 |
-
(dacongming666/GlowTact_Datasets) · FeelAnyForce (2410.02048)
|
|
|
|
| 147 |
</div></body></html>
|
|
|
|
| 57 |
|
| 58 |
<header>
|
| 59 |
<div class="kicker">React 力恢复 · 评测结果</div>
|
| 60 |
+
<h1>三个估计器 × 四个真值数据集</h1>
|
| 61 |
<p class="sub">每个方法在每个有力传感器标注的数据集上评测,逐数据集画预测 vs 真值——
|
| 62 |
数据集质量在行内被控制,面板之间的差异就是方法之间的差异。</p>
|
| 63 |
<a class="pill" href="method_zh.html">↖ 方法设计</a>
|
| 64 |
+
<a class="pill" href="recon_workbench.html">3D 工作台</a>
|
| 65 |
<a class="pill" href="index.html">总览(英文)</a>
|
| 66 |
<a class="pill" href="gallery.html">图库</a>
|
| 67 |
<a class="pill" href="results.html">English</a>
|
|
|
|
| 74 |
<th>FeelAnyForce<br>(训练域:无点)</th></tr>
|
| 75 |
<tr><td>FEATS val(有点)</td><td>0.77</td>
|
| 76 |
<td class="best">0.96 · 本域</td><td class="dead">0.43</td></tr>
|
| 77 |
+
<tr><td>FoTa cnc_Mini(无点)</td><td>0.95 (视野内)</td>
|
| 78 |
<td class="dead">0.07</td><td class="best">0.83</td></tr>
|
| 79 |
+
<tr><td>GlowTact(无点)</td><td>0.99</td>
|
| 80 |
<td class="dead">0.04</td><td class="best">0.90</td></tr>
|
| 81 |
+
<tr><td>Sparsh / Meta(无点,10 块 gel pad)</td>
|
| 82 |
+
<td>0.97(视野内,自标定查找表)</td>
|
| 83 |
+
<td colspan="2">未运行 — 没有公开的预测结果</td></tr>
|
| 84 |
</table>
|
| 85 |
<p>规律本身就是发现:<b>每个网络只统治自己的 gel 域,出域即塌</b>
|
| 86 |
(FEATS 0.96 → 0.04–0.07;FeelAnyForce 0.90 → 0.43);
|
| 87 |
+
而<b>物理管线是唯一在所有域都工作的估计器</b>(0.77–0.99)——
|
| 88 |
它没见过训练数据,所以也没有可以离开的域。</p>
|
| 89 |
</div>
|
| 90 |
|
| 91 |
+
<h2>每个数字都配上足以否定它的对照</h2>
|
| 92 |
+
<div class="card">
|
| 93 |
+
<p style="margin-top:0">在深度管线加入 marker 修补之后端到端重跑。四个数据集使用同一套协议:
|
| 94 |
+
在每个组内(压头族 / 探头 / 采集组 / gel pad)一半帧拟合 5 特征最小二乘模型并用保序回归标定,
|
| 95 |
+
另一半用于评分;5 个随机种子,报告中位数。对照列用完全相同的协议,但把力标签
|
| 96 |
+
<b>在组内打乱</b>——组结构和力的分布都不变,只破坏帧与力的配对。</p>
|
| 97 |
+
<table class="matrix"><tr><th>dataset</th><th>n (eval)</th><th>ρ</th><th>ρ across seeds</th><th>MAE [N]</th><th>within-group shuffle</th></tr><tr><td>GlowTact (markerless, 0-20 N)</td><td>201</td><td class='best'><b>0.986</b></td><td>0.981–0.987</td><td>0.525</td><td>+0.171</td></tr><tr><td>FoTa cnc_Mini (markerless, in view)</td><td>337</td><td class='best'><b>0.946</b></td><td>0.929–0.949</td><td>0.252</td><td>+0.056</td></tr><tr><td>FEATS (marker gel)</td><td>186</td><td class='best'><b>0.775</b></td><td>0.713–0.787</td><td>5.025</td><td>-0.003</td></tr><tr><td>Sparsh / Meta (markerless, Sparsh LUT, in view)</td><td>1667</td><td class='best'><b>0.968</b></td><td>0.967–0.971</td><td>0.042</td><td>+0.264</td></tr><tr><td>FEATS (marker gel, dots inpainted — rejected for force)</td><td>186</td><td class='dead'><b>0.737</b></td><td>0.682–0.816</td><td>4.934</td><td>-0.010</td></tr></table>
|
| 98 |
+
<p class="footnote">没有任何数字变动。这正是预期结果,也值得明确说出来:marker 修补只被采纳用于
|
| 99 |
+
<b>几何</b>,力的路径被刻意保持逐字节不变;从原始帧重算缓存特征的抽查也证实了这一点
|
| 100 |
+
(40 帧 cnc 上 max |缓存 − 重算| = 0)。最后一行是同样的 FEATS 帧、同样的划分,
|
| 101 |
+
只是把 marker 修补后的特征喂给力模型——ρ <b>下降</b> 0.037,这就是它没有进入力路径的原因。</p>
|
| 102 |
+
<p class="footnote">这里正确的对照是组内打乱,而不是全局打乱:在 FeelAnyForce 上,
|
| 103 |
+
混合后的 ρ 在<i>全局</i>打乱下仍有 0.442(对比 0.455),我们正是这样发现它的帧对齐从未被验证。
|
| 104 |
+
读表方式:cnc 与 GlowTact 高出各自对照约 0.9;FEATS 高出 0.78,而它的对照平在 0.00。</p>
|
| 105 |
+
</div>
|
| 106 |
+
|
| 107 |
<h2>FEATS 数据集——有点 gel</h2>
|
| 108 |
<div class="card"><img src="assets/results_feats.png" alt="FEATS dataset panels">
|
| 109 |
<p class="footnote">本域内 FEATS U-net 非常出色(ρ=0.96)——它在别处的失败是域效应,
|
| 110 |
+
不是模型弱。FeelAnyForce(无点训练)在有点 gel 上退化到 0.43:这把刀两边都割。</p>
|
| 111 |
+
<h3>去掉 marker 点:几何上的胜利,不是力上的</h3>
|
| 112 |
+
<img src="assets/feats_marker_removal.png" alt="FEATS marker 修补前后对比">
|
| 113 |
+
<p class="footnote">点会遮挡 gel,因此光度查找表在点下没有有效颜色,Poisson 积分会把一层
|
| 114 |
+
点阵凹坑积进深度图——在 <b>3D mesh BEFORE</b> 面板上表现为满屏麻点。在参考帧上检测这些点,
|
| 115 |
+
并在做差分<b>之前</b>把它们从参考帧<b>和</b>当前帧里一起���补掉(cv2 Telea,相当于 GelSight
|
| 116 |
+
Wedge 图 10 中孔洞插值的图像域版本),凹坑就消失了:31.9 px 点距对应频率上的功率从
|
| 117 |
+
<b>1.523 降到 0.890</b>(×0.65),在 1 N 以上的 120 帧中有 <b>91%</b> 变低,
|
| 118 |
+
Wilcoxon p = 2.6e-19。检测器是 marker 专用的,不是通用斑点检测器——在该参考帧上 63/63 个点、
|
| 119 |
+
0 个误检,阈值从 3 到 16 灰阶都稳定;而在无 marker 的 GlowTact 与 cnc 参考帧上恰好检出
|
| 120 |
+
<b>0</b> 个,此时该步骤是逐比特的空操作。</p>
|
| 121 |
+
<p class="footnote">它<b>做不到</b>两件事。第一,它对力没有帮助:在相同帧、相同划分下
|
| 122 |
+
ρ 从 0.7747 降到 0.7371,且每个配对中位差都是负的,所以力特征仍然来自未改动的管线。
|
| 123 |
+
第二,它抓不全所有点——点会随 gel 剪切移动(中位 1.7 px,8% 的帧超过 8 px),
|
| 124 |
+
静态参考掩码追不上位移的点,第 3 列里残留的点就是它们。对照实验:把同样<i>面积</i>的
|
| 125 |
+
随机假 marker 修补掉得到 0.7697,即没有增益,说明这些微小变化并不是"修补=平滑=更好"。
|
| 126 |
+
真正卡住 FEATS 的是参考帧而非点——在最轻的 20 次按压上,点外区域的 |dI| 已经有 11 个灰阶,
|
| 127 |
+
88% 的点外像素通过 |dI|>8 的有效性判据,掩码几乎覆盖整幅画面,特征积分的是参考帧失配;
|
| 128 |
+
换成逐压头的轻压参考帧反而更差(0.7747 → 0.7261)。</p></div>
|
| 129 |
|
| 130 |
<h2>FoTa cnc_Mini——无点 gel</h2>
|
| 131 |
<div class="card"><img src="assets/results_cnc.png" alt="cnc_Mini panels">
|
| 132 |
+
<p class="footnote">条件苛刻:只有 4 帧无接触,62% 的按压贴边。我们严格视野内 ρ=0.95(MAE 0.25 N,见管线调试页);
|
| 133 |
FeelAnyForce 非边缘达 0.92。</p></div>
|
| 134 |
|
| 135 |
<h2>GlowTact——无点 gel,清洗过</h2>
|
|
|
|
| 165 |
逐轨迹配对前 ρ≈0)、sharp/batch_2 以 BGR 存储而其余九个是 RGB、
|
| 166 |
flat/batch_2 只有 3 个图像文件。</p></div>
|
| 167 |
|
| 168 |
+
<h2>第一份外部逐像素真值——它改变了主结论</h2>
|
| 169 |
+
<div class="card">
|
| 170 |
+
<p style="margin-top:0">上面评的都是<b>力</b>。在此之前,底层的<b>深度</b>只被拿来和我们自己的
|
| 171 |
+
解析球冠比较,而球冠的幅值还是从重建本身锚定的。Tactile MNIST 补上了缺失的一环:
|
| 172 |
+
由 3D 打印数字网格光线投射得到的精确逐像素深度,且是球面标定无法自证的<b>非球面</b>几何——
|
| 173 |
+
420 次触碰、106 个物体。位姿对应关系是端到端验证过的而非假设的
|
| 174 |
+
(用真值高度图重渲染可复现出厂图像,误差约 2/255 灰阶)。</p>
|
| 175 |
+
<img src="assets/mnist_examples.png" alt="重建与精确网格真值对比">
|
| 176 |
+
<p><b>结论是一个区间,不是一个数字:精度是压入深度的陡峭函数。</b>
|
| 177 |
+
同样的数字网格,在五个压入深度上重渲染,没有逐帧配准,也没有拟合压入尺度:</p>
|
| 178 |
+
<table class="matrix">
|
| 179 |
+
<tr><th>压入深度 [mm]</th><th>0.30</th><th>0.60</th><th>1.00</th><th>1.50</th>
|
| 180 |
+
<th>2.25 — 数据集实际发布的</th></tr>
|
| 181 |
+
<tr><td>MAE [µm]</td><td class="best"><b>11.2</b></td><td class="best">35.0</td>
|
| 182 |
+
<td>67.8</td><td>127.4</td><td class="dead">281.1</td></tr>
|
| 183 |
+
<tr><td>Type-2 误差 [µm]</td><td class="best"><b>96.5</b></td><td>186.3</td>
|
| 184 |
+
<td>308.6</td><td>514.6</td><td class="dead">961.8</td></tr>
|
| 185 |
+
<tr><td>峰值还原比(我们 / 真值)</td><td>1.00</td><td>0.97</td><td>0.77</td>
|
| 186 |
+
<td>0.68</td><td class="dead">0.55</td></tr>
|
| 187 |
+
</table>
|
| 188 |
+
<p class="footnote">在 0.3 mm 处 Type-2 误差为 <b>96.5 µm</b>,低于 3D Cal 公布的全部三个数字
|
| 189 |
+
(152.8 / 171.6 / 290.0 µm)——而且他们的结果是<i>带</i>二维互相关配准和拟合压入尺度得到的,
|
| 190 |
+
我们两者都没有。在 0.6 mm(186.3 µm)我们落在他们的区间内。而在该数据集实际使用的 2.25 mm
|
| 191 |
+
压入下,我们差了一个数量级,峰值只还原了一半左右。<b>所以:本站任何精度数字都必须连同
|
| 192 |
+
它所对应的压入深度一起引用,而这套重建的适用区间是浅接触。</b></p>
|
| 193 |
+
<p><b>它纠正了什么,又确认了什么。</b></p>
|
| 194 |
+
<table class="matrix">
|
| 195 |
+
<tr><th>此前的说法</th><th>逐像素真值之后</th></tr>
|
| 196 |
+
<tr><td>平头压头过度穹顶化——中心/边缘比 1.23–1.42,而 1.0 才是正确值</td>
|
| 197 |
+
<td class="dead"><b>撤回。</b>前提本身就是错的:gel 是柔顺的,会包裹平边,所以
|
| 198 |
+
c/r > 1 是<i>应当出现</i>的。真值显示被压数字的真实深度图 c/r 为 <b>1.400</b>
|
| 199 |
+
(gel 表面本身是 1.334),而我们重建出 1.539–1.562——<b>+10–12%</b>;
|
| 200 |
+
在真值恰为 1.000 的封闭平台对照上我们测得 <b>1.069</b>,即 <b>+7%</b>。
|
| 201 |
+
过度穹顶化真实存在但很小,不是我们暗示的 +23–42%。</td></tr>
|
| 202 |
+
<tr><td>多达 22% 的接触像素落在未观测过的 LUT bin 里——一个��要缺陷</td>
|
| 203 |
+
<td class="dead"><b>降级。</b>在真值集上为 13.8% / 16.9%,
|
| 204 |
+
与逐次触碰 Type-2 误差的相关性仅 <b>0.098 / 0.294</b>。</td></tr>
|
| 205 |
+
<tr><td><code>|dI| > 8</code> 有效掩码被光晕主导</td>
|
| 206 |
+
<td class="best"><b>确认并量化。</b>相对真实接触区域:IoU <b>0.614</b>,
|
| 207 |
+
召回 <b>0.917</b>,过分割 <b>0.531</b>——它几乎找全了接触,然后又多加了半个接触面积的光晕。</td></tr>
|
| 208 |
+
<tr><td>出域时光度查找表可能是薄弱环节</td>
|
| 209 |
+
<td class="best"><b>排除。</b>LUT 梯度与真实 gel 梯度的夹角在这些渲染上是 <b>24.4°</b>,
|
| 210 |
+
而同一张表在它自己的真实传感器上是 <b>26.1°</b>;用域内球压重渲染重新拟合查找表
|
| 211 |
+
也没有改善数字(316.9 vs 273.4 µm)。</td></tr>
|
| 212 |
+
</table>
|
| 213 |
+
<p><b>同一个失效模式,现在已在四个数据集上看到。</b>这里 420/420 次触碰的接触都跑出了 pad,
|
| 214 |
+
而一个把单个球冠从 pad 中心移到边缘的对照,使峰值从 <b>1.39 塌到 0.30 mm</b>
|
| 215 |
+
(真值 0.90 mm,Type-2 292 → 450 µm)。这与 cnc_Mini 的按压网格大于视野
|
| 216 |
+
(视野消融实验里 ρ 0.11 → 0.94)、以及 Sparsh 中被裁切的接触圆盘虽然力中位数最高
|
| 217 |
+
却得分更差,是同一回事。<b>接触可见性——而不是力程或 gel 类型——才是这条管线最大的外部失效模式</b>:
|
| 218 |
+
Poisson 求解的零边界无法表示一个跑出画面的曲面。</p>
|
| 219 |
+
<p class="footnote"><b>诚实的边界。</b>这些图像是 Taxim 渲染,不是真实 GelSight 帧,
|
| 220 |
+
所以它验证的是<i>几何求解器</i>(查找表、掩码、积分),而不是传感器模型;
|
| 221 |
+
上面的域检查正是允许这样解读的依据。另外 Taxim 的 gel 与物体几何的偏差只有约 38 µm,
|
| 222 |
+
几乎没有建模真实 gel 的非贴合性:在同样压深下,真实传感器上的数字只会更差,不会更好。
|
| 223 |
+
复现:<code>python -m force_recovery.mnist_validation stage1|controls|sweep</code>。</p>
|
| 224 |
+
</div>
|
| 225 |
+
|
| 226 |
<h2>React——没有真值,那就问:独立方法是否一致?</h2>
|
| 227 |
<div class="card"><img src="assets/results_react.png" alt="React agreement">
|
| 228 |
<p class="footnote">在我们真正关心的数据集上,两个幸存的估计器——物理(零训练)与
|
|
|
|
| 232 |
<h2>结论</h2>
|
| 233 |
<div class="card"><p style="margin-top:0"><b>给 React 打标签</b>(无点 Mini):FeelAnyForce 主标,
|
| 234 |
物理管线独立审计,分歧行打标。<b>换任何新 gel 或新传感器</b>、没有训练模型匹配该域时:
|
| 235 |
+
物理管线是唯一开箱即用的选项——它在 FEATS 数据集上的 0.77 就是"无人为它调过的域"上的表现。</p>
|
| 236 |
+
<p><b>并且要把适用范围一起说清楚。</b>上面那些 ρ 是逐组的<i>力</i>得分。
|
| 237 |
+
底层的<i>深度</i>现在已经用精确逐像素真值测过,它是压入深度的强函数——
|
| 238 |
+
0.3 mm 处 MAE 11 µm,2.25 mm 处 281 µm——所以诚实的一句话总结是:
|
| 239 |
+
<b>浅接触几何精确、标定组内力单调,而一旦接触跑出视野,两条结论都不成立。</b>
|
| 240 |
+
有 marker 的 gel 多一步(差分前把点修补掉),它买到的是几何,不是力。</p></div>
|
| 241 |
|
| 242 |
+
<p><a href="debug_pipeline.html"><b>管线调试页</b></a>:三个数据集上从原始图像到力的逐步展示,以及 cnc 视野消融(视野内 ρ=0.95)。</p>
|
| 243 |
|
| 244 |
<footer>React 力恢复 · <a href="index.html">总览</a> ·
|
| 245 |
<a href="method_zh.html">方法设计</a> · <a href="gallery.html">图库</a> ·
|
| 246 |
数据:FEATS (2411.03315) · FoTa/T3 (2406.13640) · GlowTact
|
| 247 |
+
(dacongming666/GlowTact_Datasets) · FeelAnyForce (2410.02048) ·
|
| 248 |
+
Tactile MNIST (TUDa-RL) · Sparsh (facebook/gelsight-force-estimation)</footer>
|
| 249 |
</div></body></html>
|